Qijun QIN won the Best URIS Research Project Award 2024. The project developed a high-definition (HD) map generation method that integrates semantic segmentation with SLAM algorithms, opening new possibilities for large-scale data resources in intelligent transportation and autonomous driving.
Qijun QIN, winner of the Best URIS Research Project Award 2024.
An HD map with traffic signs based on a LiDAR-Visual-IMU fusion SLAM method
An HD map is a crucial component of autonomous driving and intelligent transportation systems. However, generating HD maps for large-scale urban environments involves enormous data volumes, reaching hundreds of terabytes, which makes manual data extraction and labelling very costly.
This research introduces a new method for HD map generation that integrates semantic segmentation with SLAM algorithms. The system combines data from LiDAR, cameras and IMU sensors to construct 3D colour scenes. Image features such as lanes, traffic lights and road signs are extracted and labelled through semantic segmentation and then fused into the 3D scene, producing an HD map embedded with labelling information. The approach offers a scalable way to acquire and generate segmented and labelled training data, which is essential for autonomous driving development.
In the future, advanced multi-modal AI technologies will be integrated to fuse higher-dimensional data, and the system has the potential to be deployed on drones for more flexible and efficient mapping.
Mapping demonstration
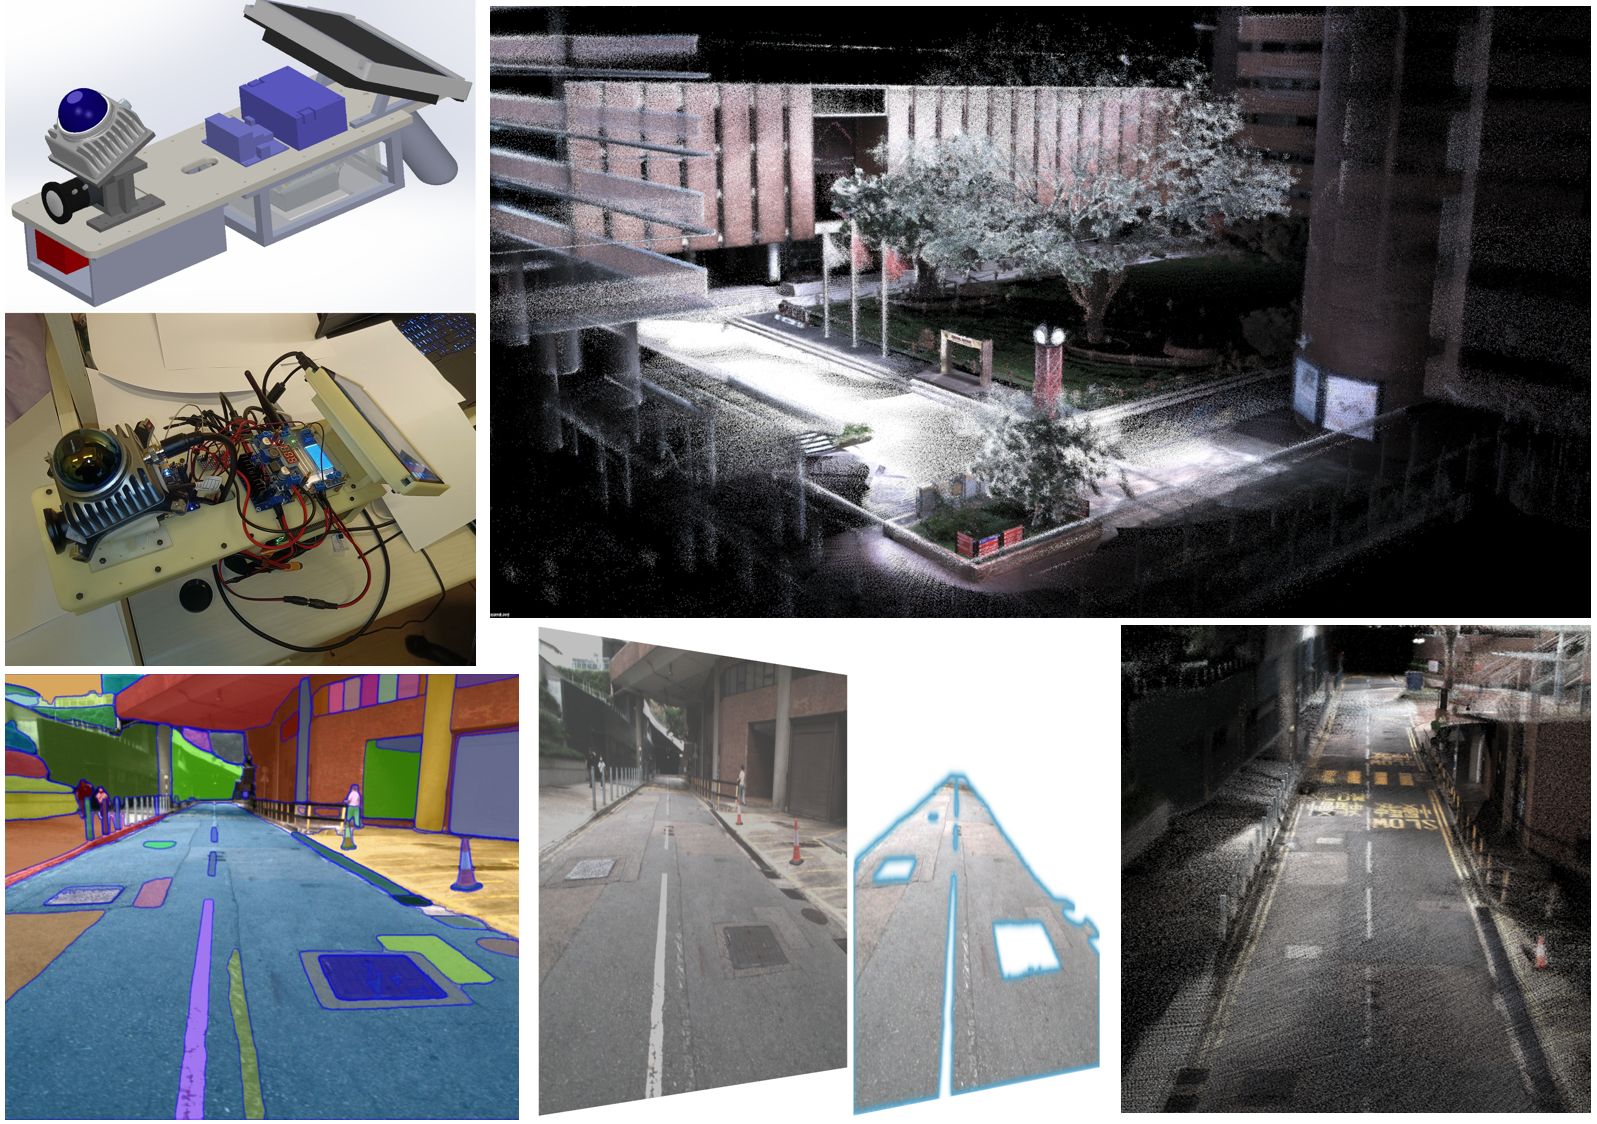
Demonstration of the HD map generation system.