PolyU · Department of Aeronautical and Aviation Engineering
Trustworthy AI and Autonomous Systems Lab
Trustworthy autonomy for dense cities: from satellites to embodied robots.
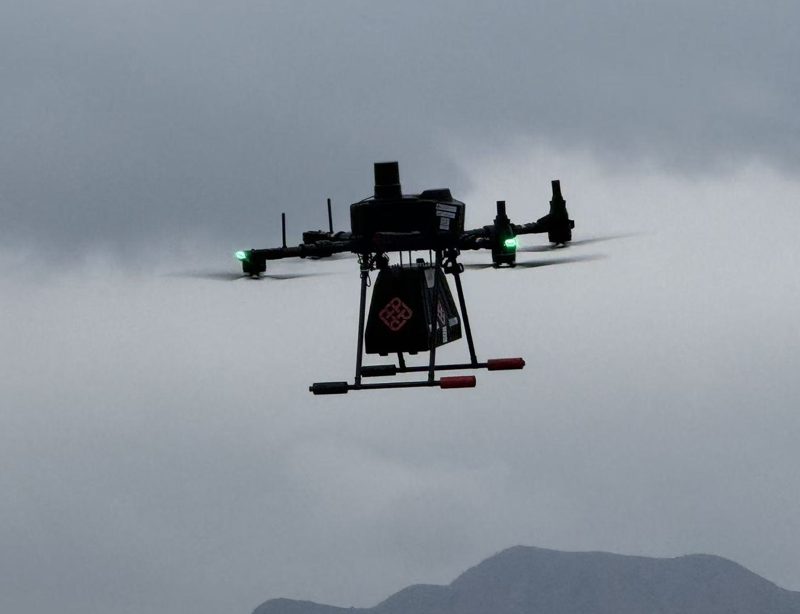
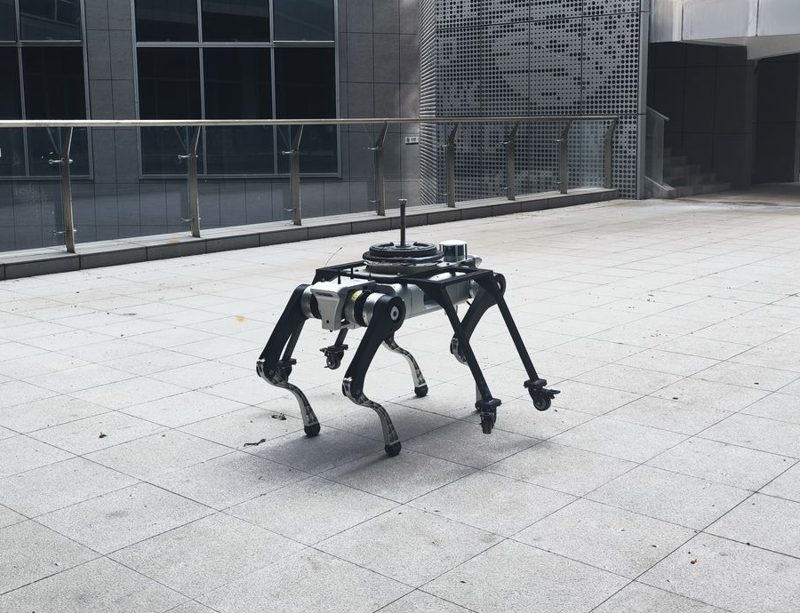
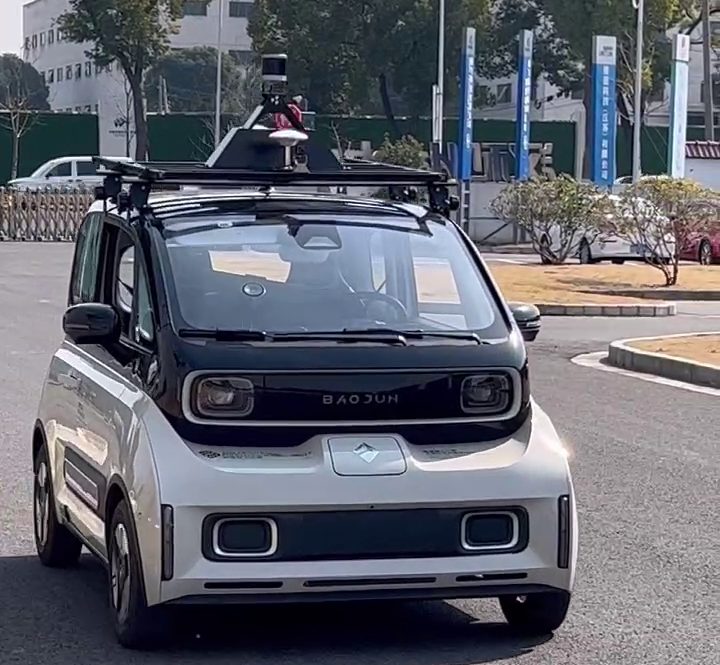
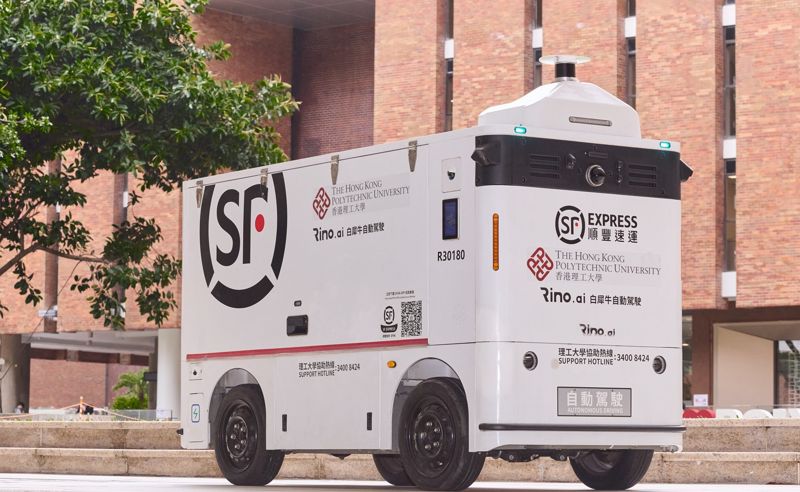
We build the algorithmic foundations of trustworthy embodied AI — perception, navigation and control that stay safe and reliable in GNSS-challenged urban canyons — and deploy them on drones, intelligent vehicles and legged/humanoid robots together with our industry partners.
- 129 Papers · 70 journal (51 JCR Q1) · 59 conference
- 3,800+ Google Scholar citations · h-index 31
- 30+ Members · 15 PhD · 11 MPhil · 3 postdocs
- 5+ Industry partners using our technology · 60K+ devices deployed
- 2,600+ GitHub stars on our open datasets & code
Research Directions
Algorithm foundations for embodied AI with end-to-end learning and safety certification — spanning large AI models, vision-language-action models, AI-enabled multi-sensor fusion and software-hardware co-design.
AI-driven GNSS positioning (RTK, PPP, PPP-RTK), 3D LiDAR aided NLOS/multipath mitigation and multi-sensor fusion for robust urban navigation.
🔒 Safety-Certifiable Multi-Sensor FusionSafety-certifiable AI for navigation, LiDAR/camera/IMU/GNSS fusion, integrity monitoring and navigation-control joint optimization.
🚗 End-to-End Autonomous VehiclesEnd-to-end learning for self-driving, safety certification for logistics applications and V2X-assisted connected autonomous driving.
🤖 Embodied AI for Legged/Humanoid RobotsLarge AI models and vision-language-action models for perception and control, bio-inspired embodied intelligence and multimodal learning.
🚁 Embodied Drones for City MaintenanceIntelligent drones and UAV swarms, aerial manipulation for urban infrastructure and efficient software-hardware co-design.
🎓 Embodied AI for Robotics EducationAI-powered robotics education platforms, project-based learning with drones and ground robots, and GitHub-based collaborative pedagogy.
Latest Updates
All news-
Prof. Weisong Wen Receives Merit Award for Outstanding Early Career Researcher in PolyU Faculty Awards 2026
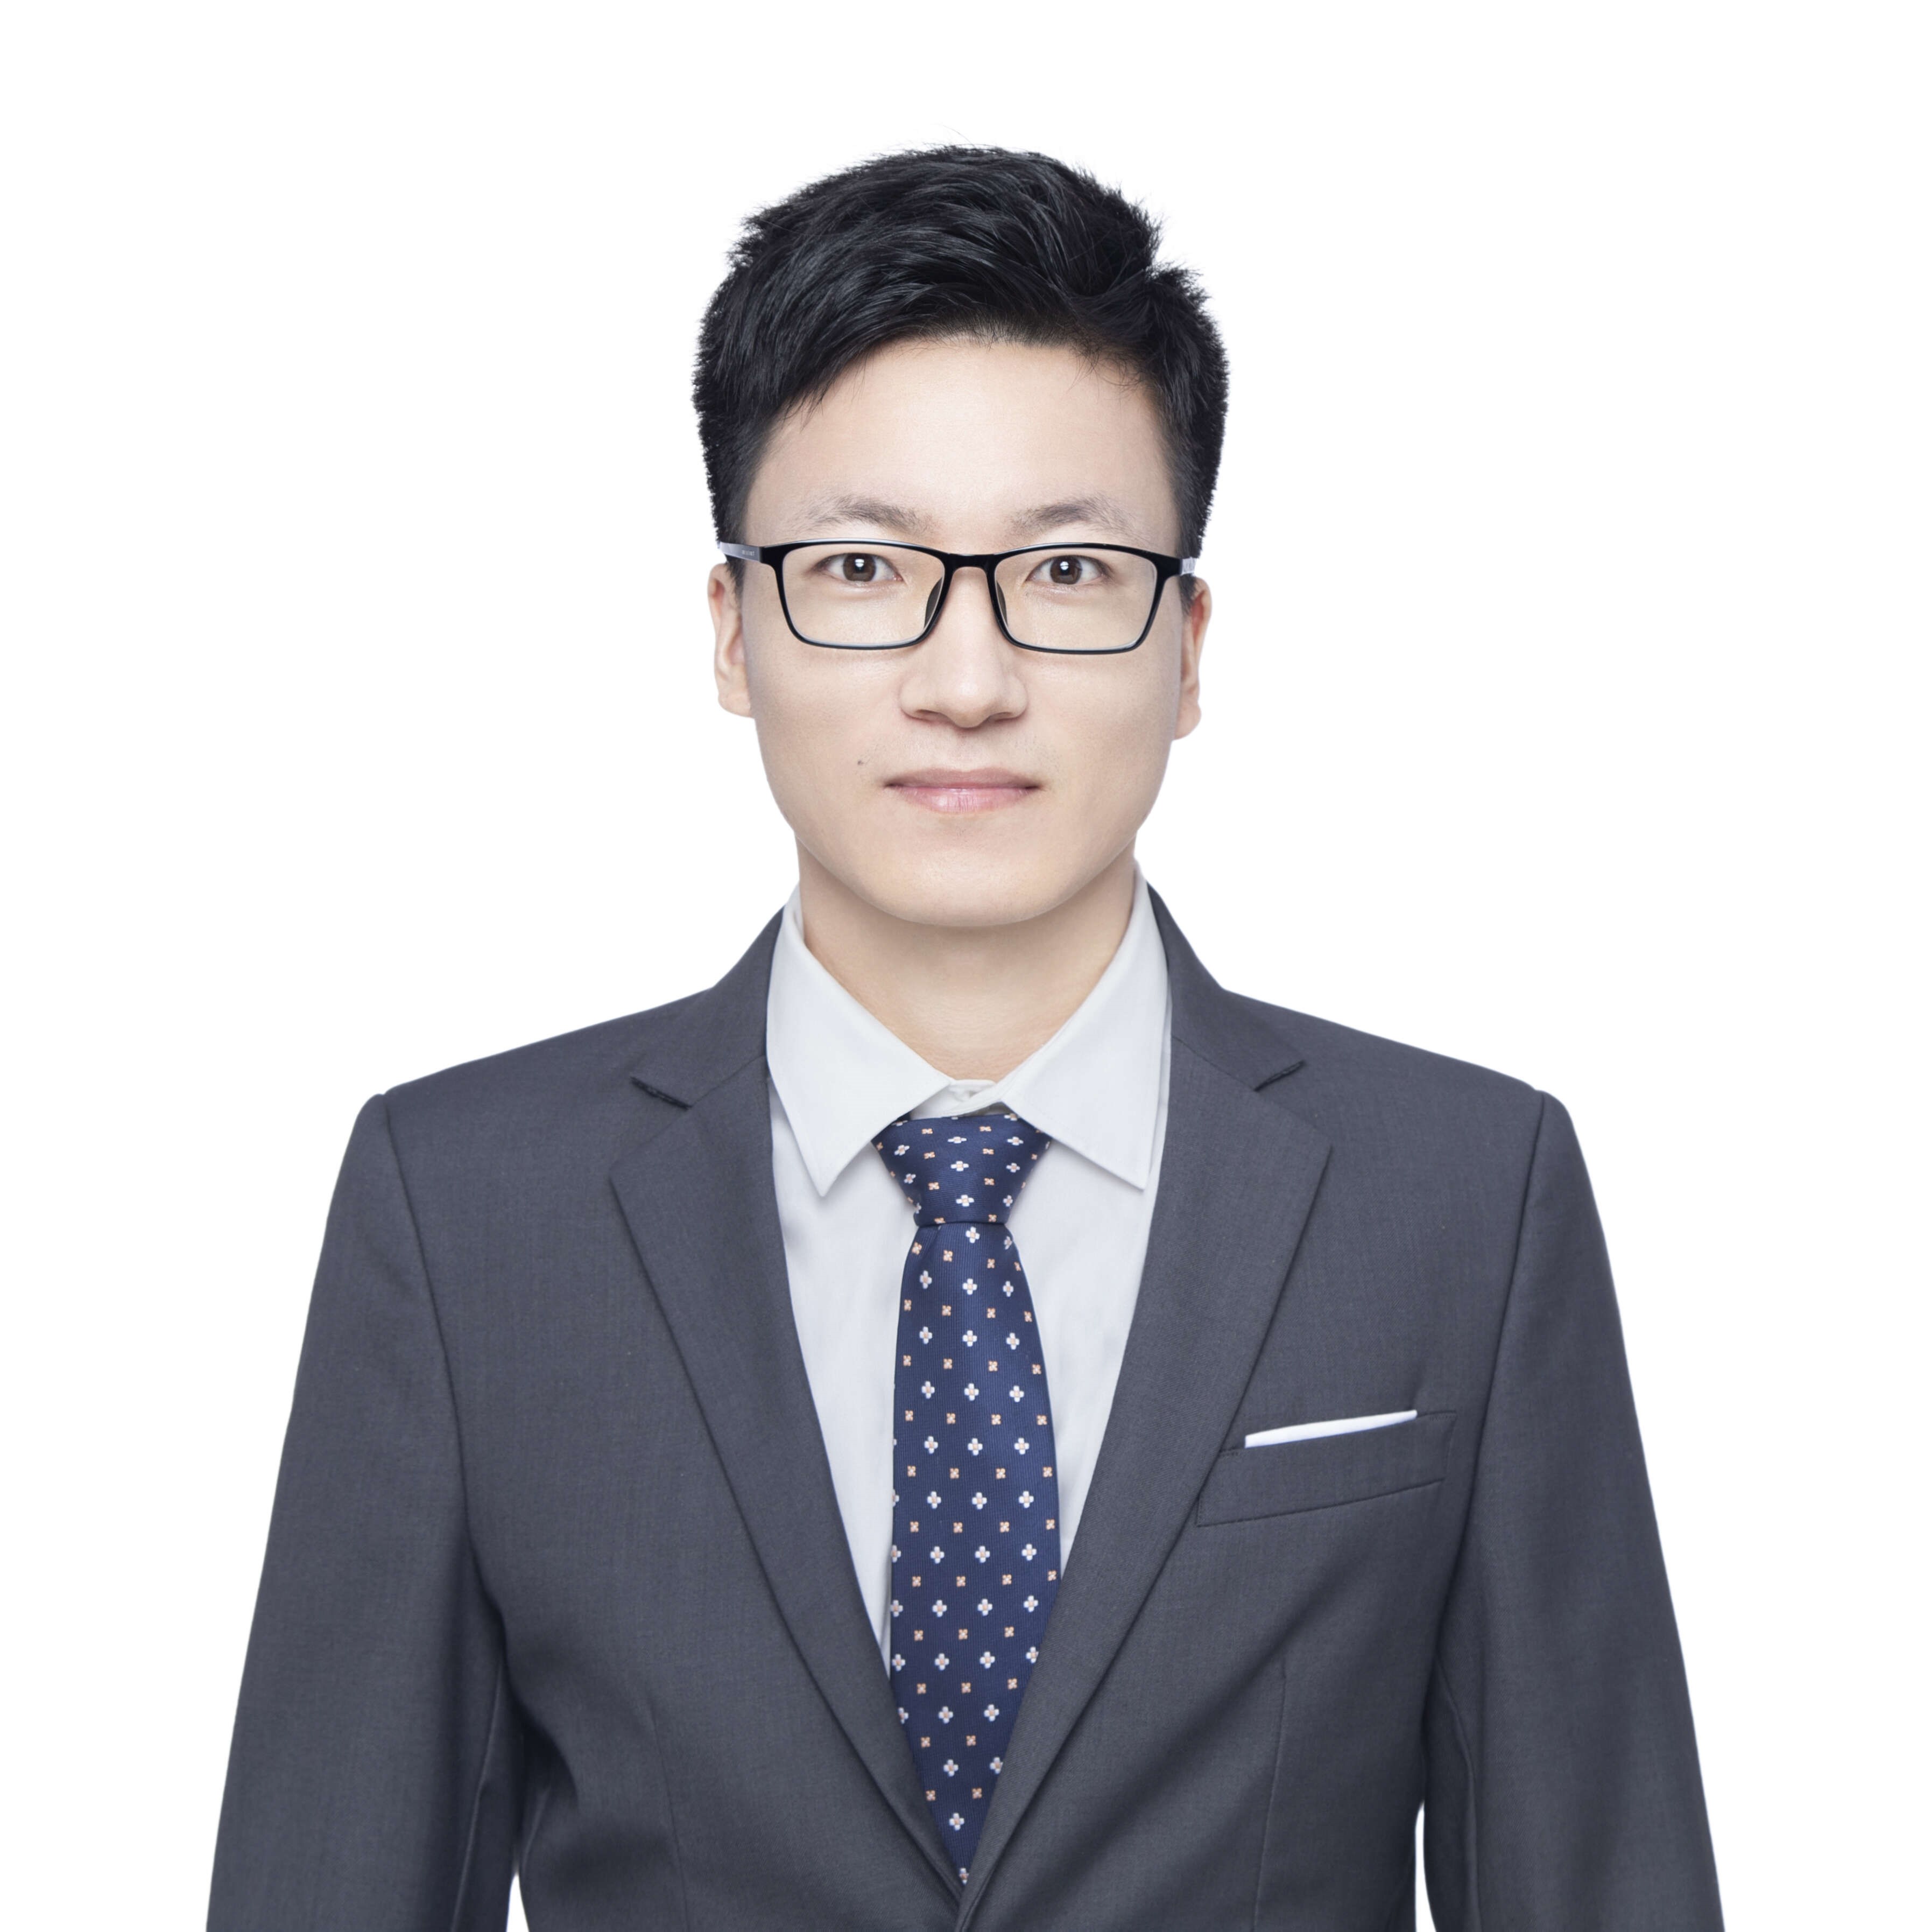
-
Mammotion Delegation Visits TASLAB and Hosts Recruitment Event at PolyU
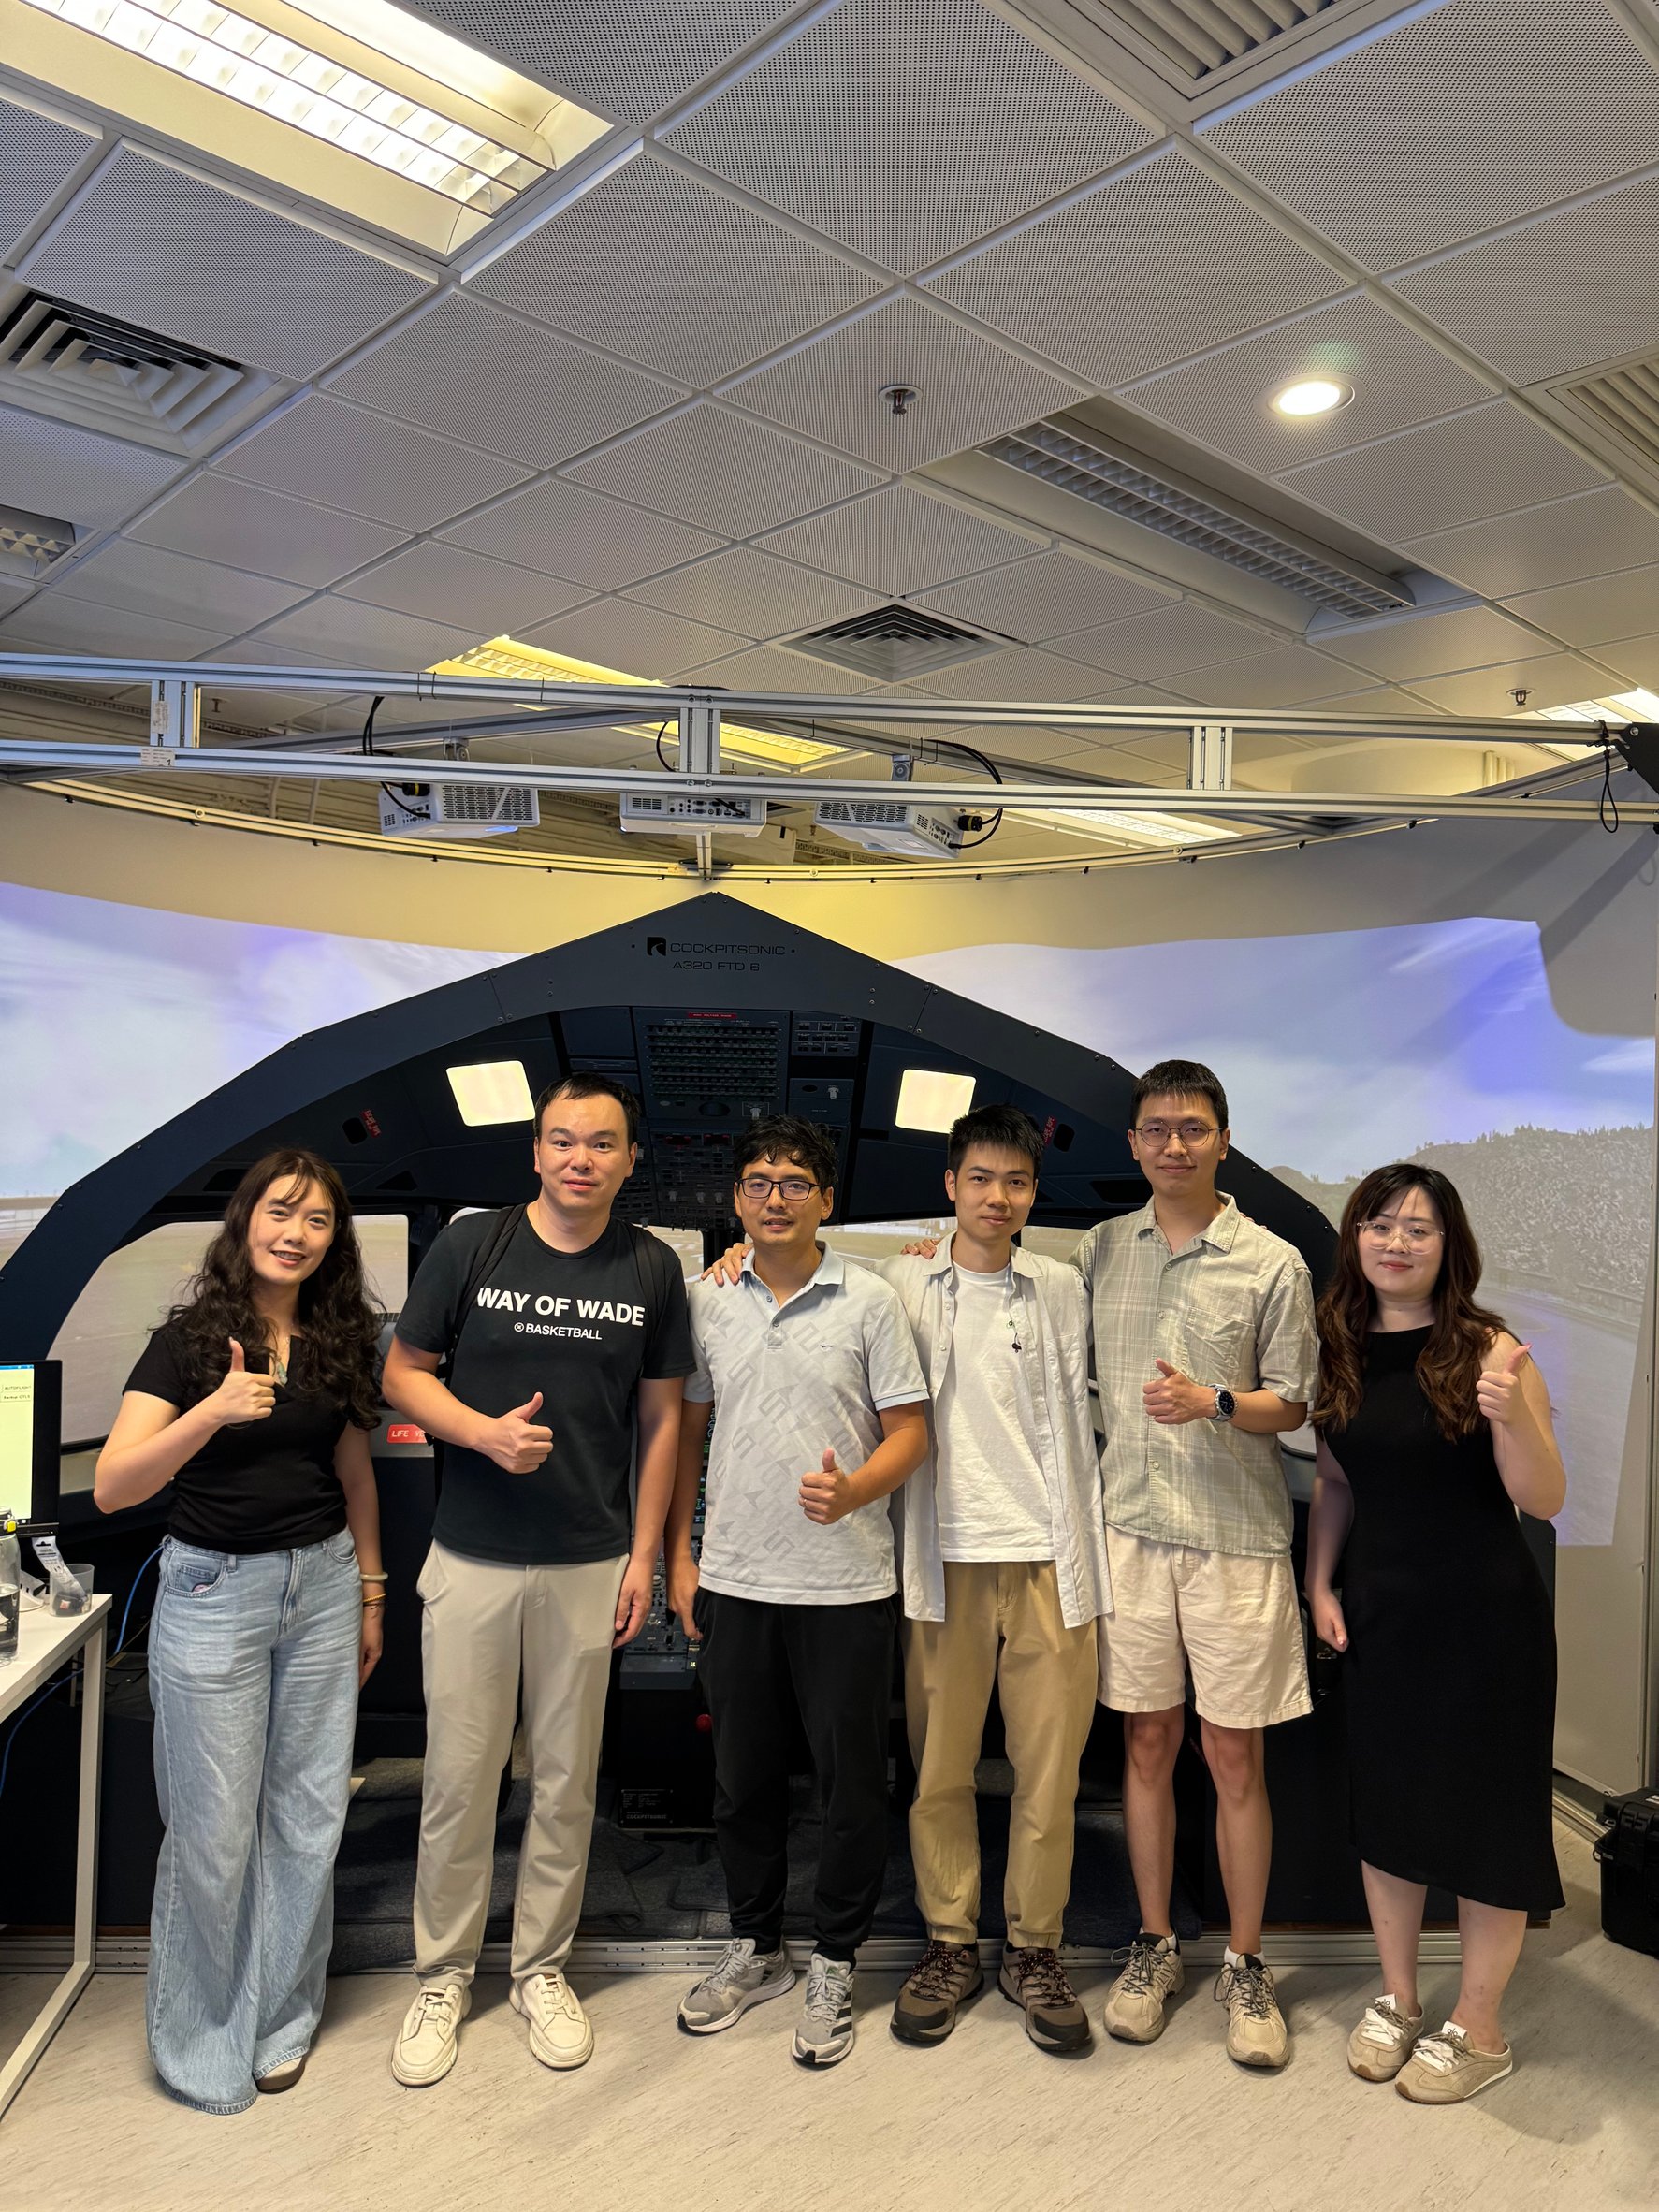
-
Prof. Weisong Wen Visits Skysys to Explore UAV-Based Solar Panel Cleaning Collaboration
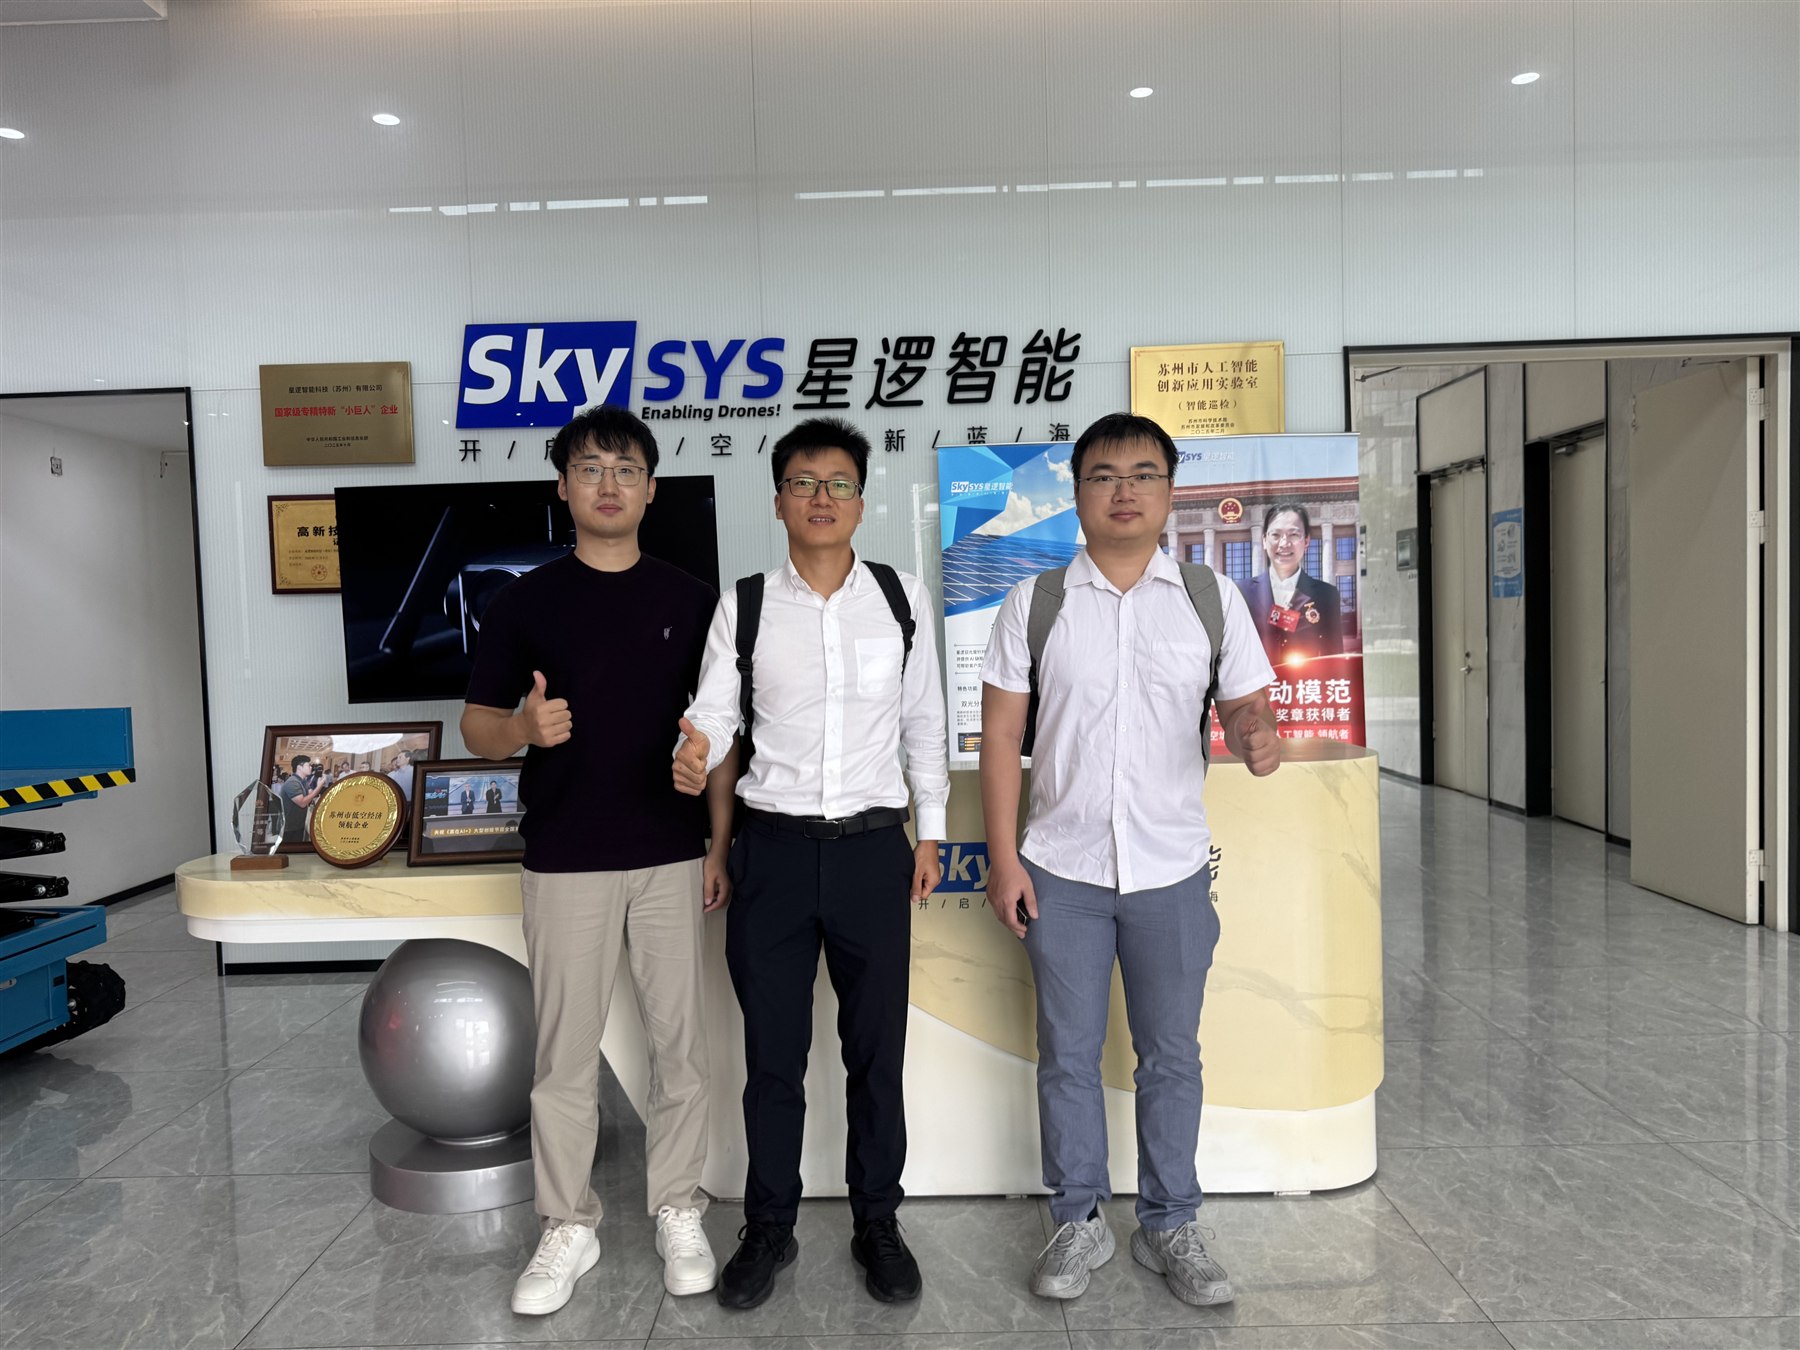
-
TASLAB Supports PolyU FENG AI & Robotics Club at Student Orientation 2026
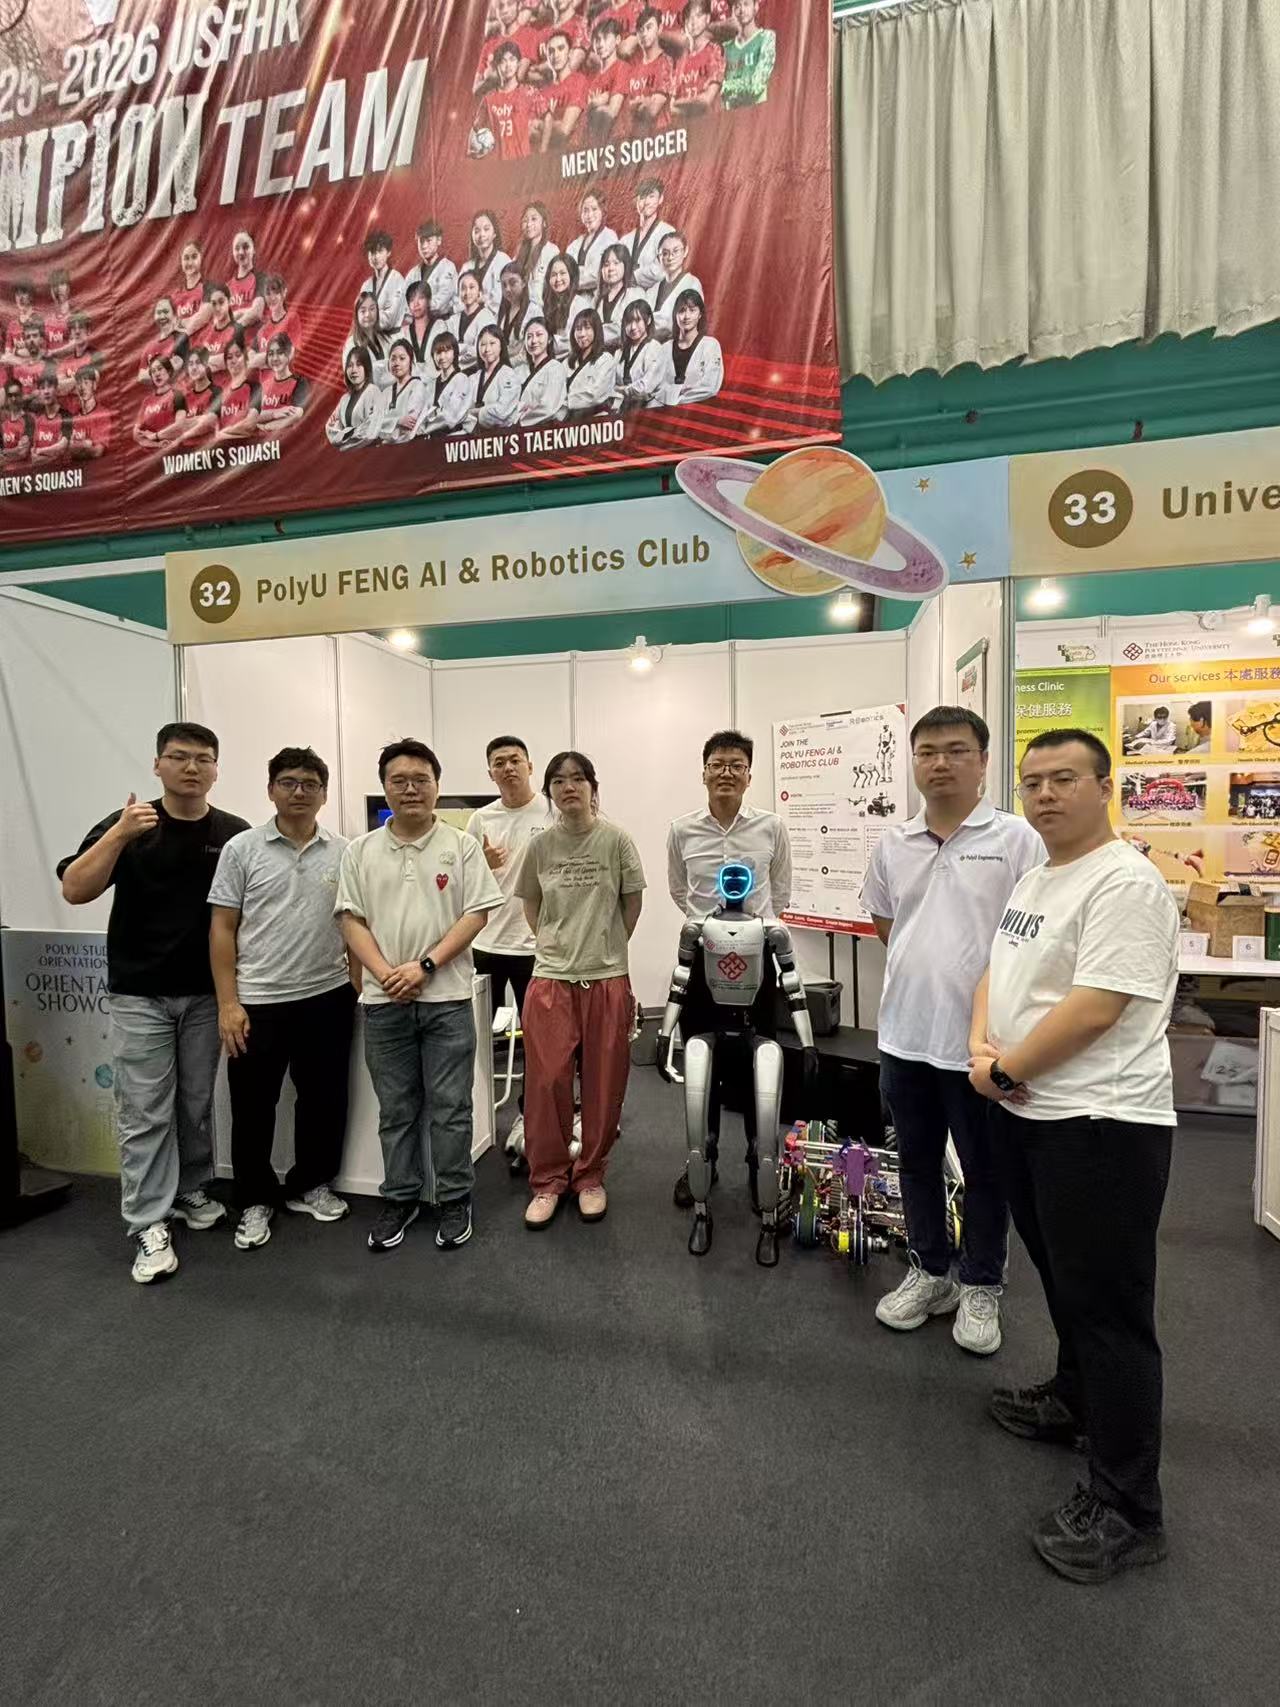
-
TASLAB Members Attend ABU Robocon 2026 in Hong Kong
Recognition
Selected honours of the lab and its director.
Natural Science First Prize
China Simulation Federation · Prof. Weisong Wen
Merit Award, Outstanding Early Career Researcher
PolyU Faculty of Engineering · Prof. Weisong Wen
Associate Editor, IEEE Transactions on Intelligent Vehicles
Also Associate Editor of IEEE T-VT (2024–) and ICRA/IROS (2025–26)
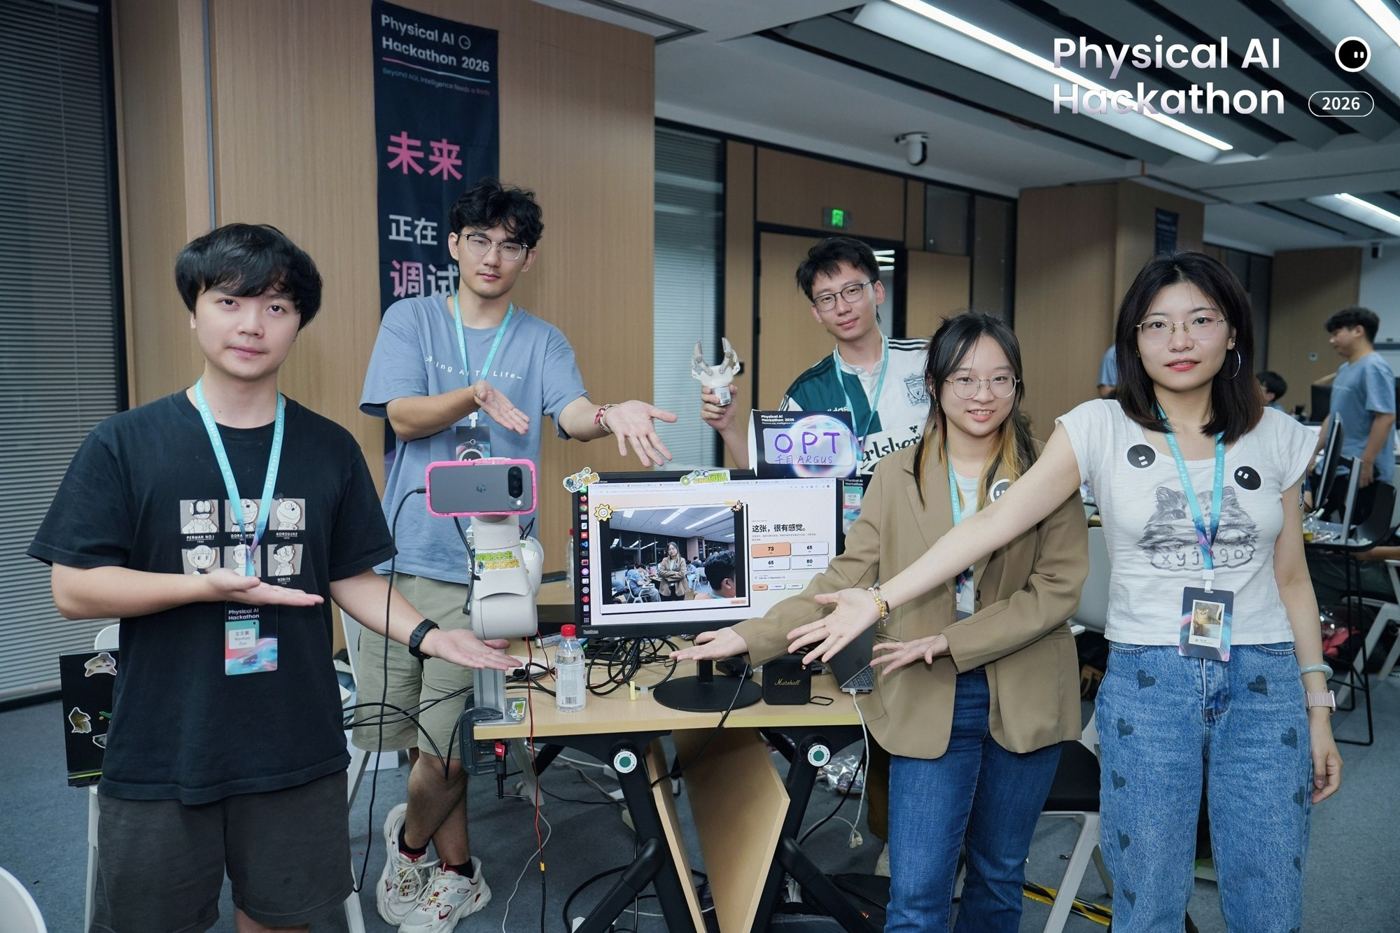
Champion, OneRobotics Track
Hong Kong Physical AI Hackathon · TAS Lab students
World's Top 2% Most-Cited Scientists
Stanford University / Elsevier · three consecutive years
Best Student Paper Award
ION GNSS+ 2024, Baltimore · Institute of Navigation
Videos
Gallery
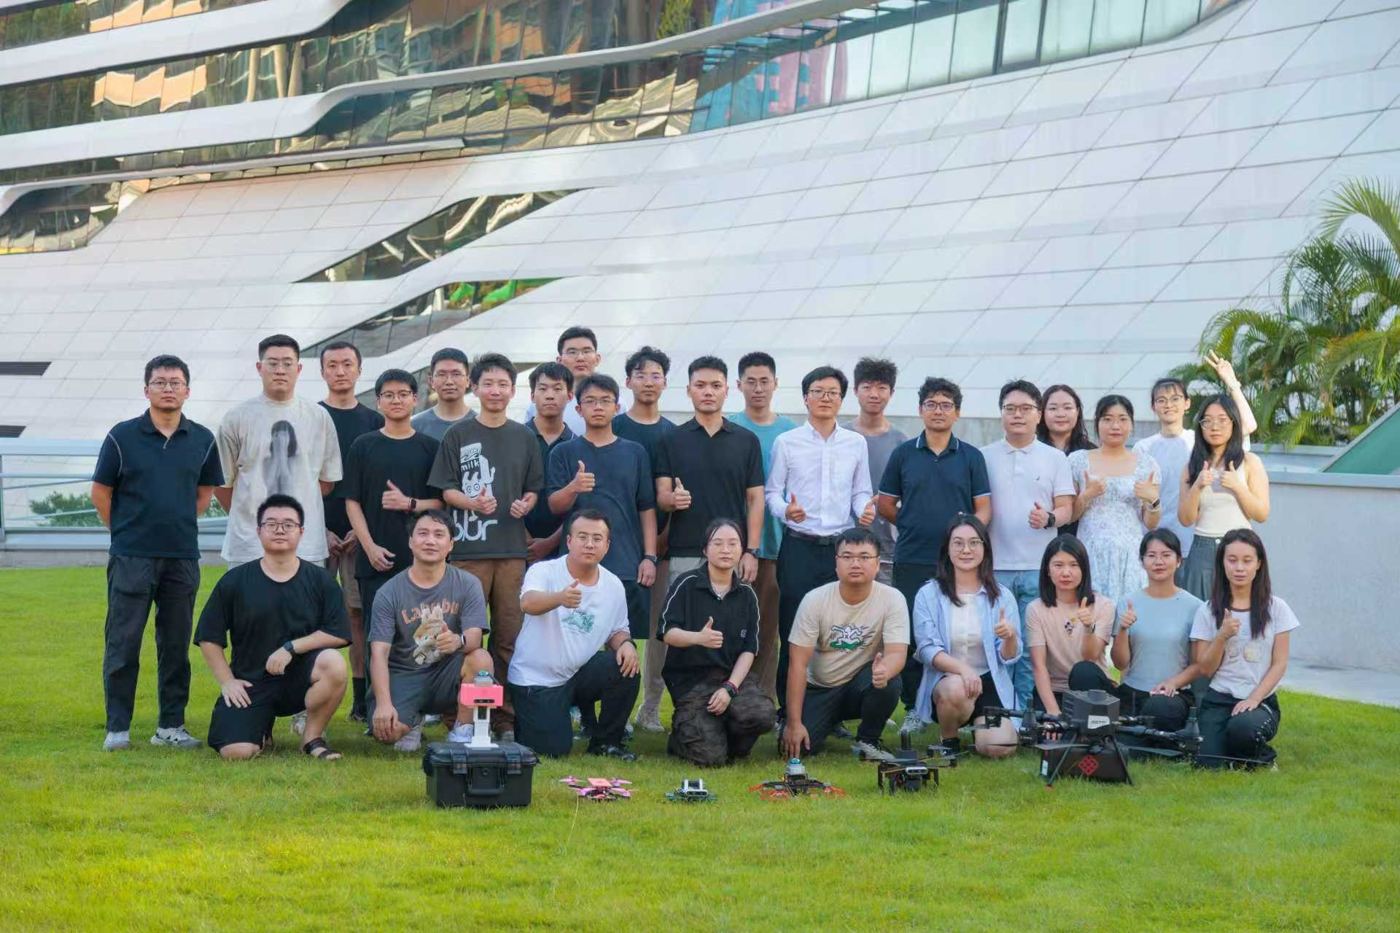
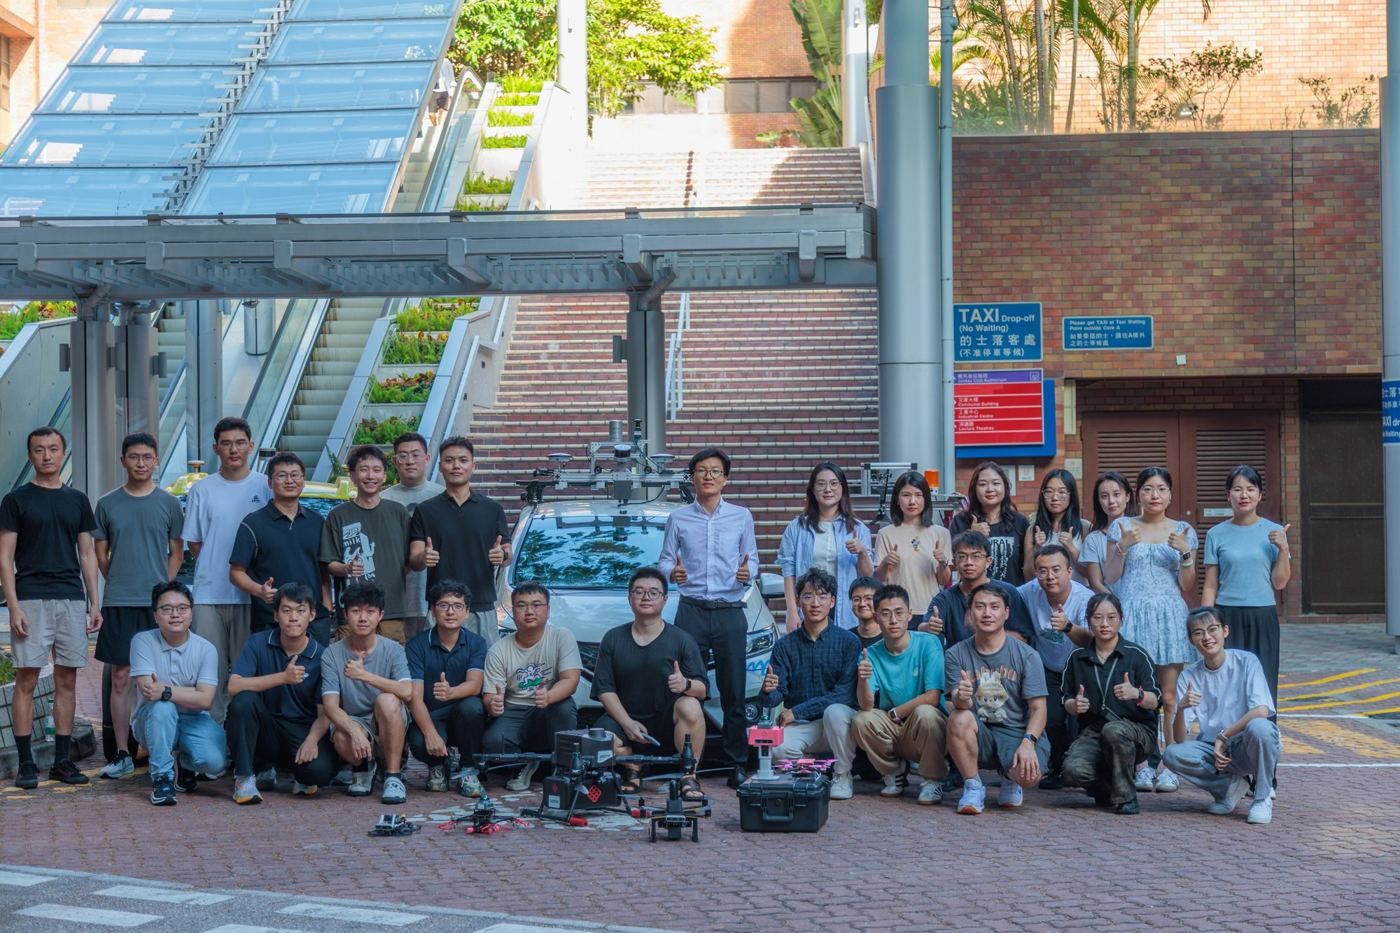
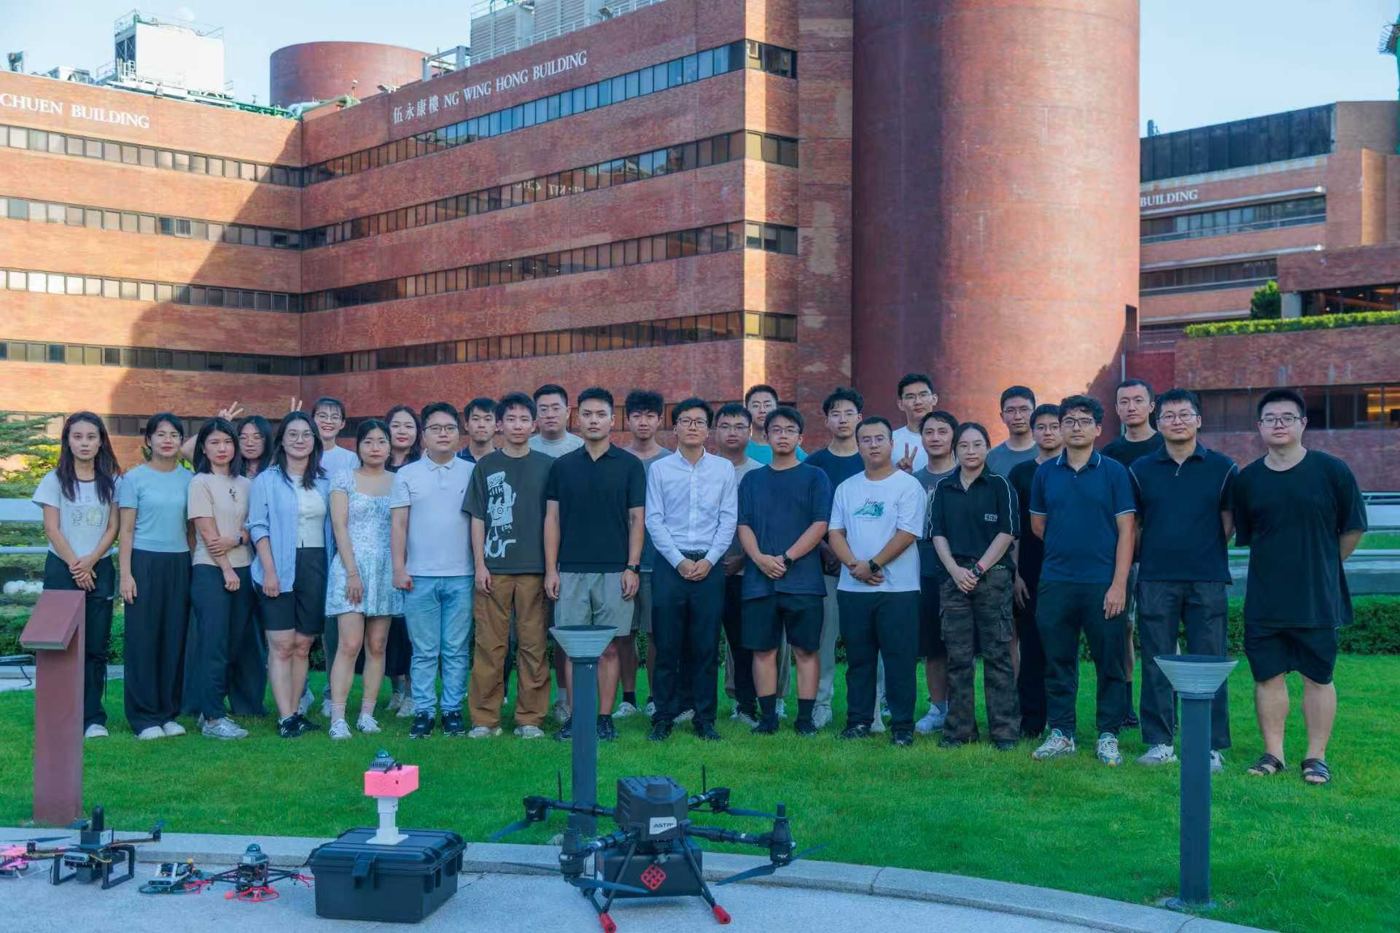
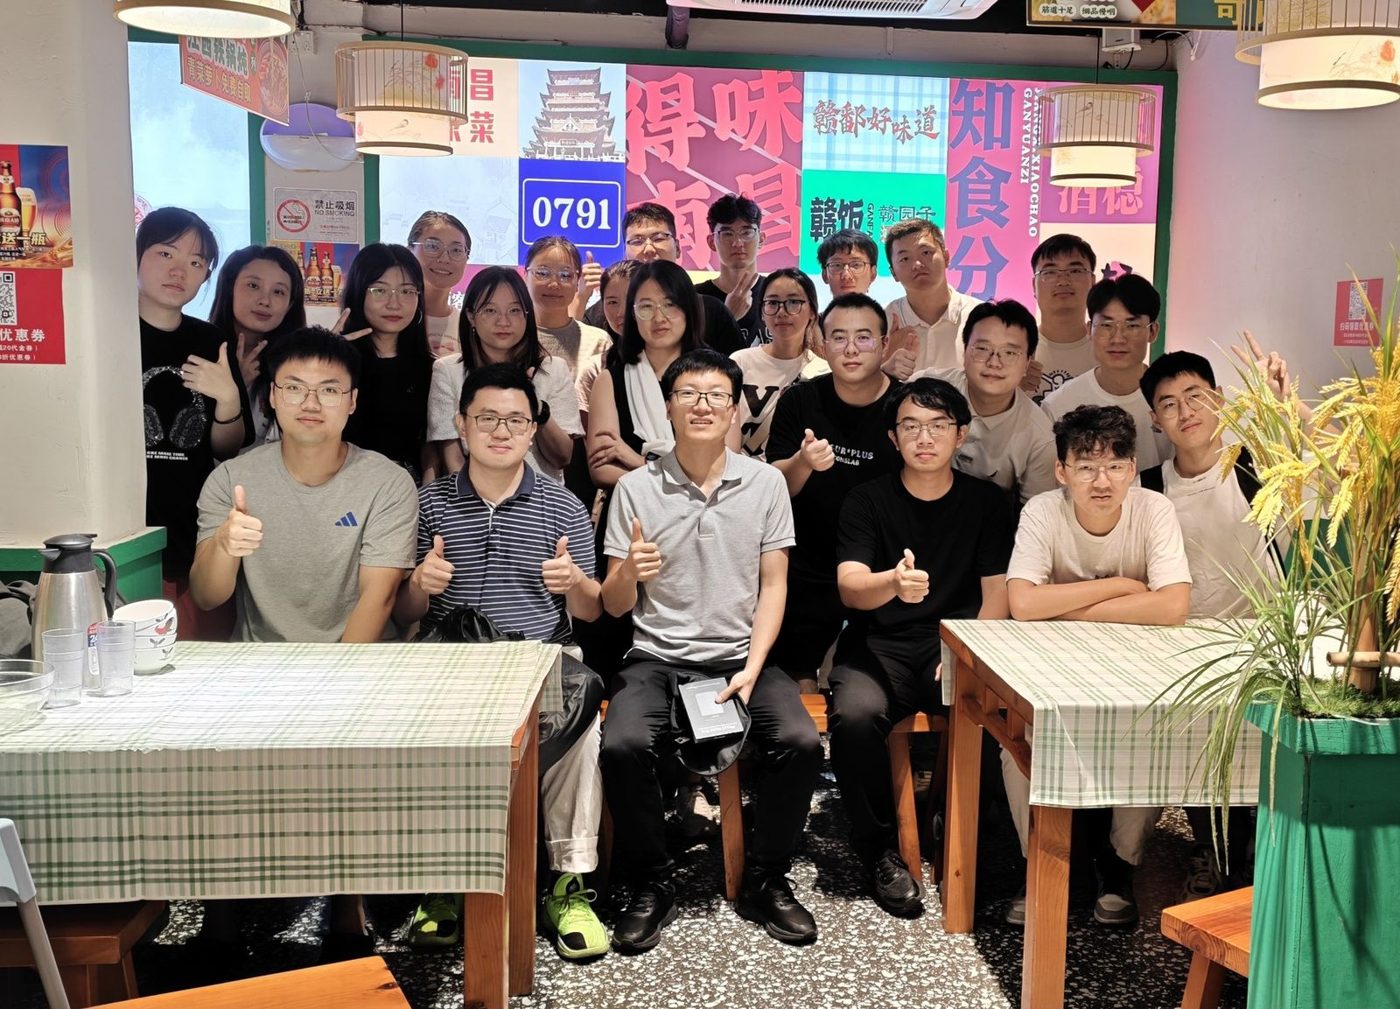
All photosLife at TAS Lab: our team, competitions, field tests and partner visits.
Funders & Partners
Our advisory boardWith gratitude to the government bodies, industry partners and university units whose support turns our research into impact for Hong Kong and beyond.
Hong Kong SAR Government
Mainland China
-
 Guangdong DST · Guangdong NSF
-
 Offshore-wind UAV inspection (GD–HK Joint Lab)
-
 ITS & Unmanned Systems Center, PolyU-Wuxi Institute
Industry Partners
-
-
-
-
-
-
-
 Joint lab
-
 Joint lab
-
 Joint lab
-
 Autonomous logistics
-
 Autonomous logistics
-
 Lab spin-off
International
PolyU & Philanthropy
Explore
Six directions from GNSS positioning to humanoid robots, with projects and demos.
PublicationsJournal and conference papers, searchable by year, topic and author.
Dataset & CodeUrbanNav, GraphGNSSLib, pyrtklib and more — 2,600+ GitHub stars.
TeamPhD and MPhil students, postdocs, research assistants and alumni.
NewsAwards, visits, competitions, talks and lab events.
OpeningsPhD, MPhil, postdoc and RA positions — we are recruiting.
Visitors
Visitors by countryWorldwide reach of the TAS Lab site.