News
2026 (56)
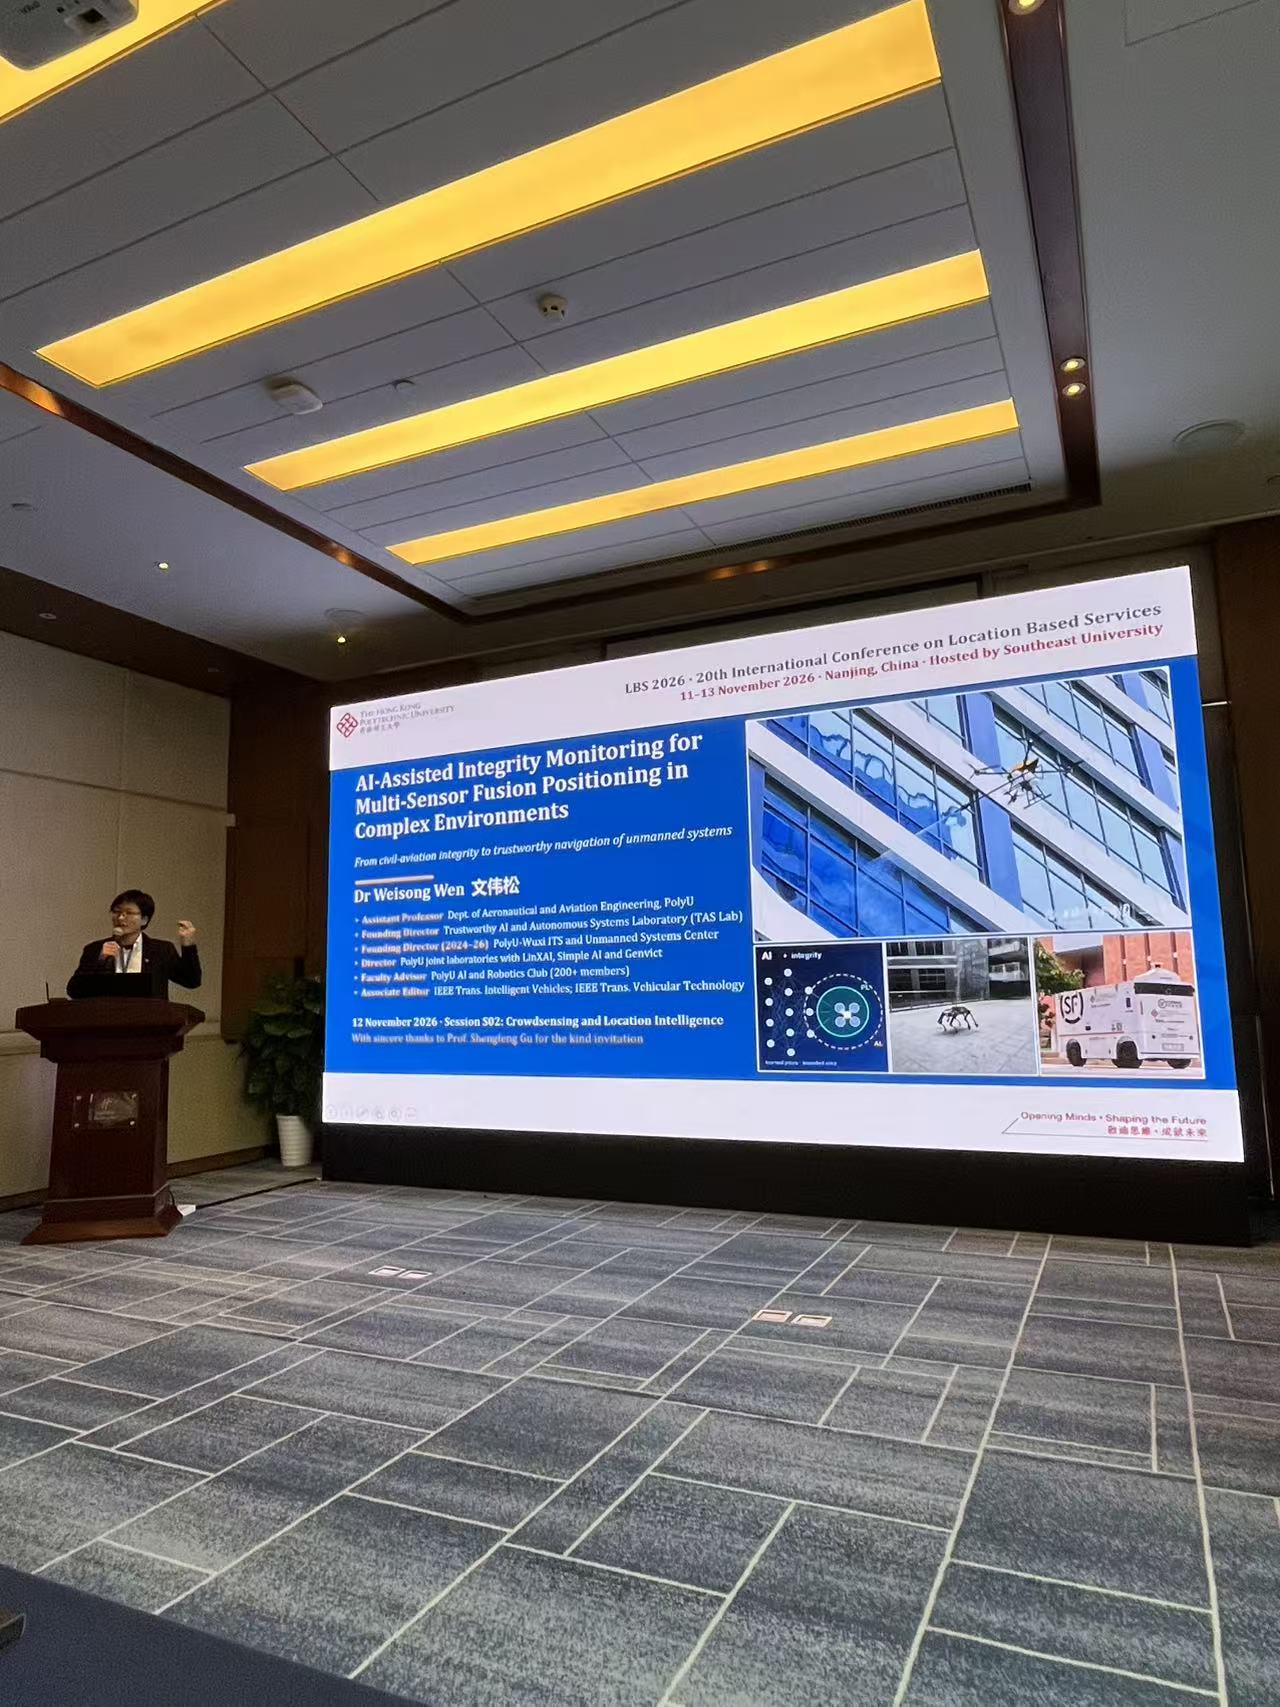
On 12 November 2026, Prof. Weisong Wen of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB), The Hong Kong Polytechnic University, delivered a talk at LBS 2026, the 20th International Conference on Location Based Services, in Nanjing, China. His presentation, titled AI-Assisted Integrity Monitoring for Multi-Sensor Fusion Positioning in Complex Environments, focused on trustworthy positioning and navigation for unmanned systems.
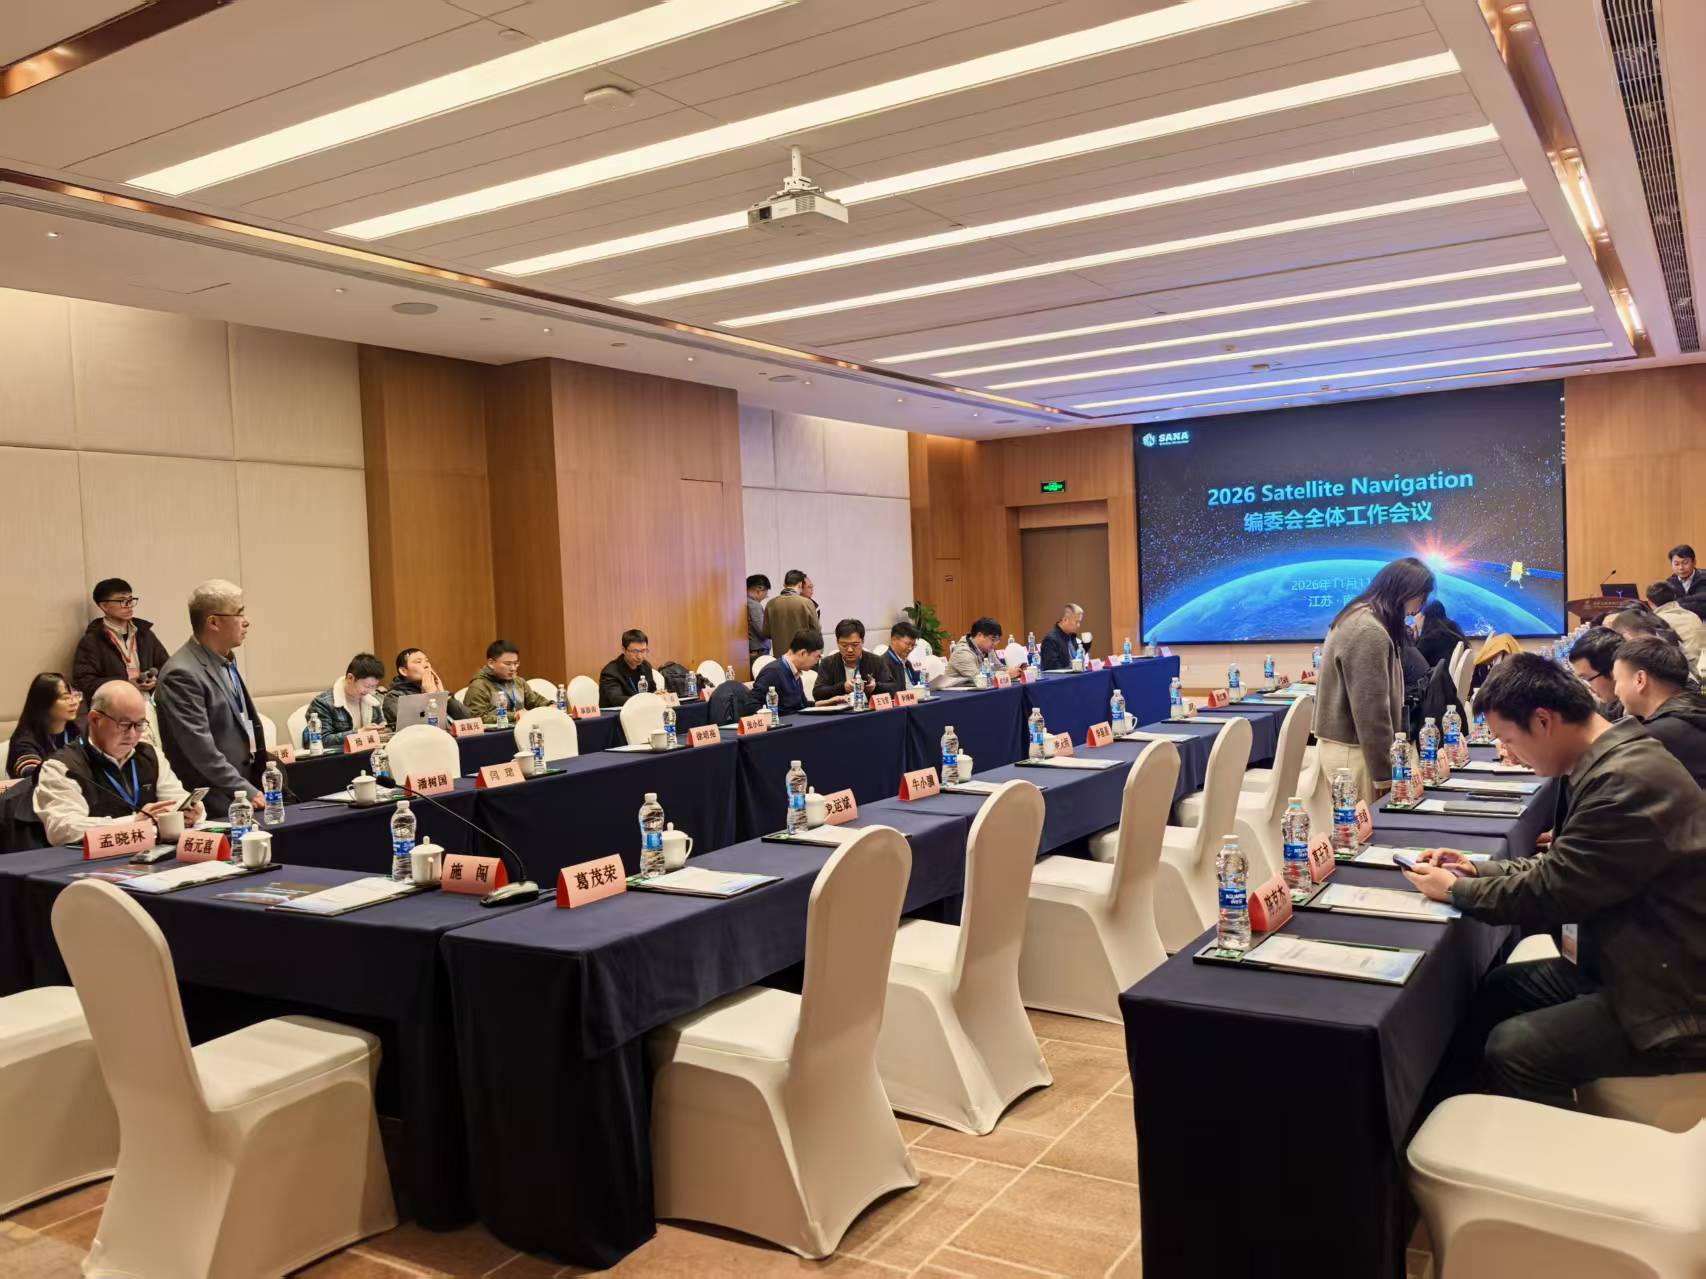
On 11 November 2026, Prof. Weisong Wen attended the 2026 Satellite Navigation Editorial Board Meeting (2026《卫星导航(英文)》编委会全体工作会议) in Nanjing, Jiangsu Province. The meeting was hosted by the journal Satellite Navigation and organised by Southeast University, and brought together the journal’s editorial board members to review its 2026 work and discuss its plans for the period ahead.
On 4 November 2026, TASLAB PhD student YANG Peiwen successfully passed his PhD oral defense at The Hong Kong Polytechnic University. His dissertation, supervised by Prof. Weisong Wen and co-supervised by Prof. Li-Ta Hsu, is titled Towards Agile and Reliable Autonomy: A Unified Framework for Planning, Control, and Adaptation in Aerial Robotics.
Professor Weisong Wen, Director of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU), has accepted an invitation to serve as an Associate Editor (Contributed Papers) on the International Program Committee of the 2027 IEEE Intelligent Vehicles Symposium (IV 2027).
On 14 October 2026, Prof. Weisong Wen visited the College of Engineering, Peking University (PKU) in Beijing. During the visit, he met with Prof. Zhiyong Sun and Prof. Chang Liu to exchange research progress and discuss future collaboration between TASLAB and their research groups.
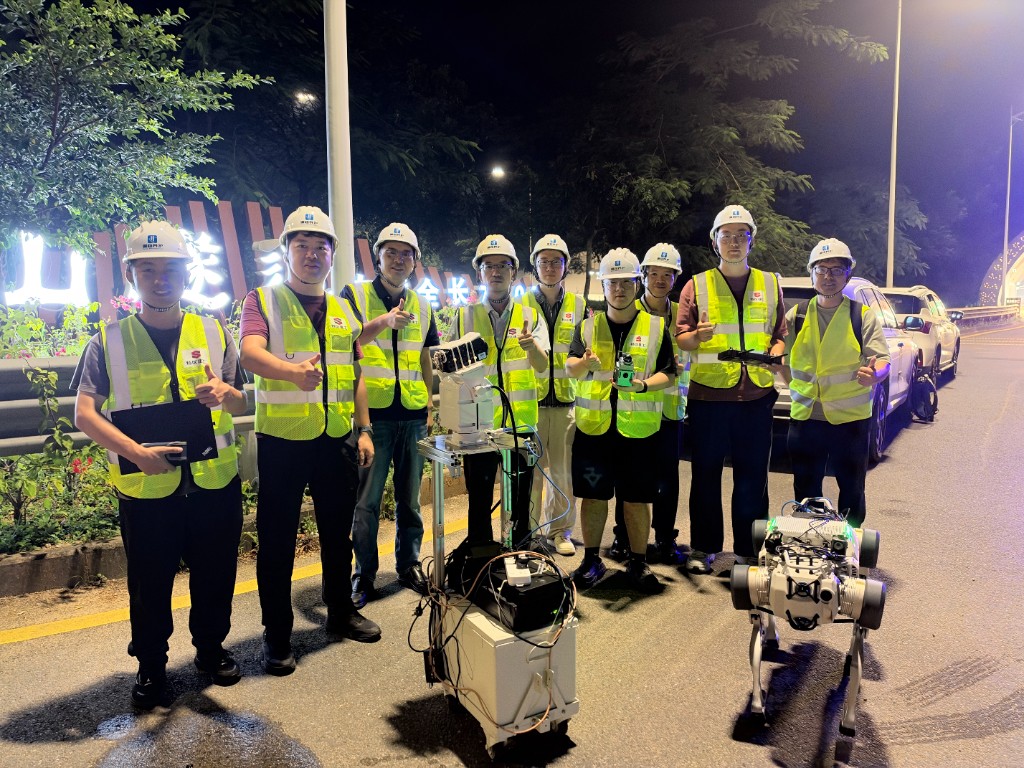
From 13 to 14 October 2026, TASLAB visited Shenzhen Genvict Technologies Co., Ltd. (Genvict, 金溢科技) for an academic exchange and a field test of unmanned systems in intelligent-transportation scenarios. As part of the visit, the joint team carried out robotic inspection data collection inside the Maluanshan Tunnel (马峦山隧道) in Shenzhen, whose right bore is 7,904 m long.
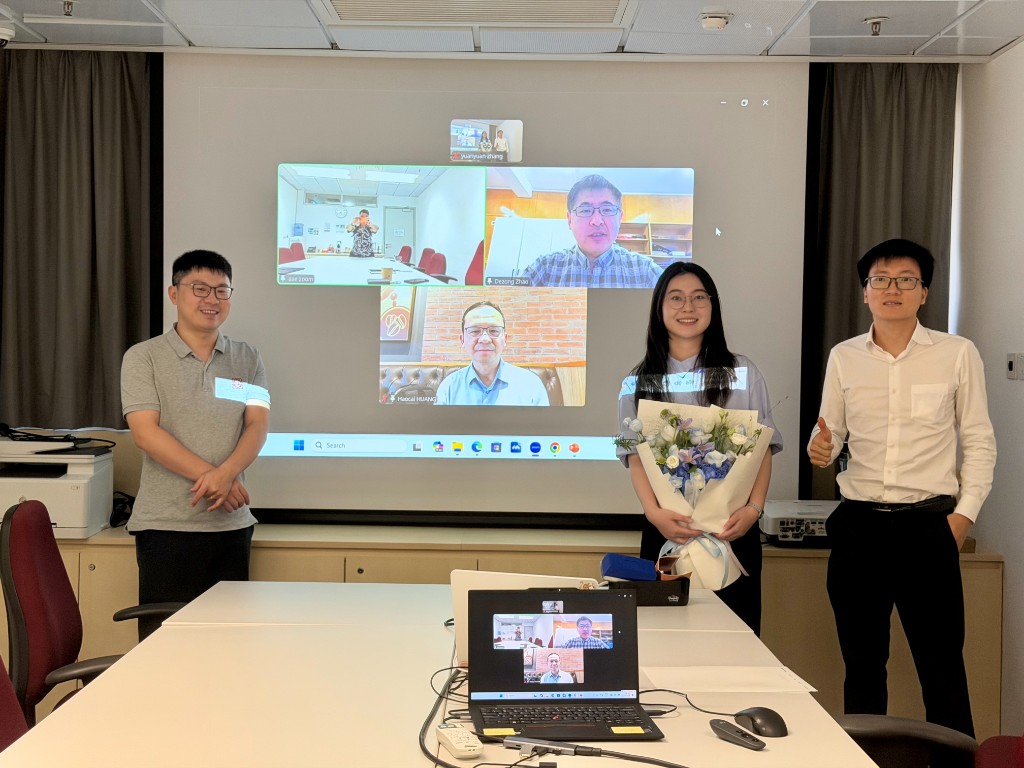
On 12 October 2026, TASLAB PhD student ZHANG Yuanyuan successfully passed her PhD oral defense at The Hong Kong Polytechnic University. Her dissertation, supervised by Prof. Weisong Wen and co-supervised by Prof. Li-Ta Hsu, is titled Trustworthy Learning-enabled Safe and Robust Autonomous Navigation for Uncertain Environments.
We are pleased to share that our new paper, “GLIO2: A GPU-Parallelized Tightly-Coupled LiDAR–Inertial–GNSS System for Robust and Real-Time Global Localization and Mapping”, is now available on arXiv.
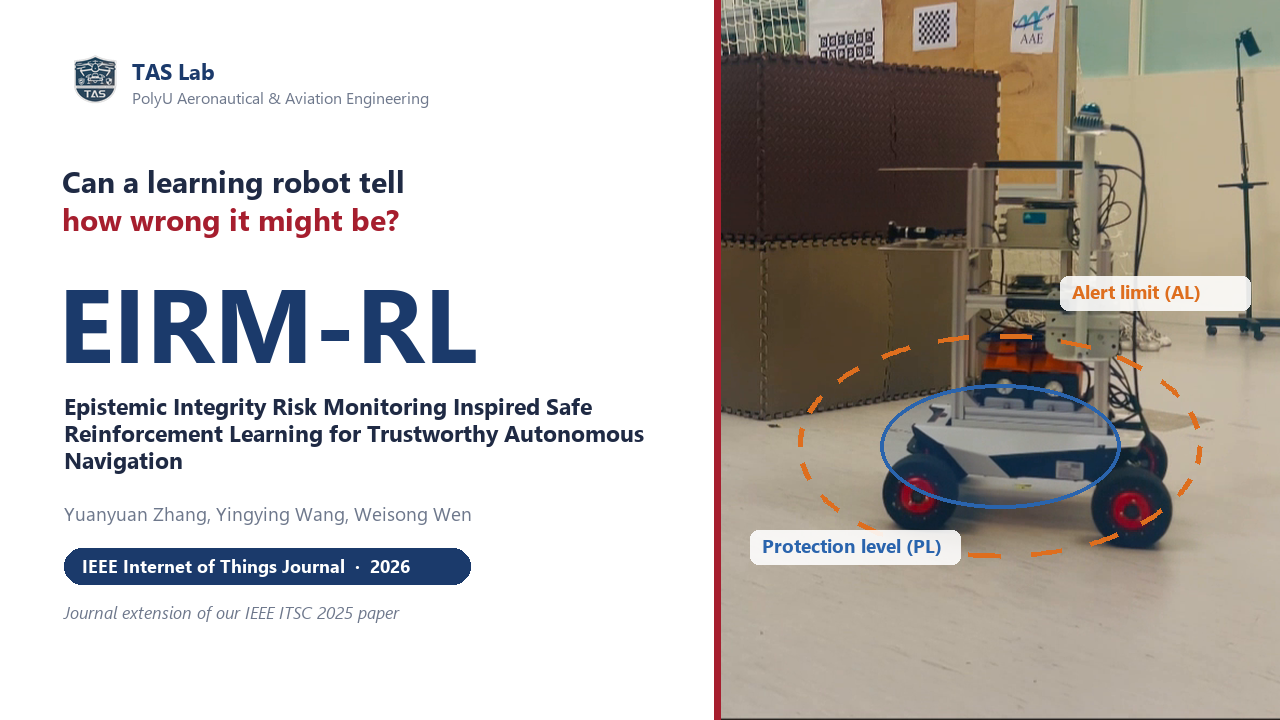
We are pleased to feature our paper, “Epistemic Integrity Risk Monitoring Inspired Safe Reinforcement Learning for Trustworthy Autonomous Navigation”, published in the IEEE Internet of Things Journal.
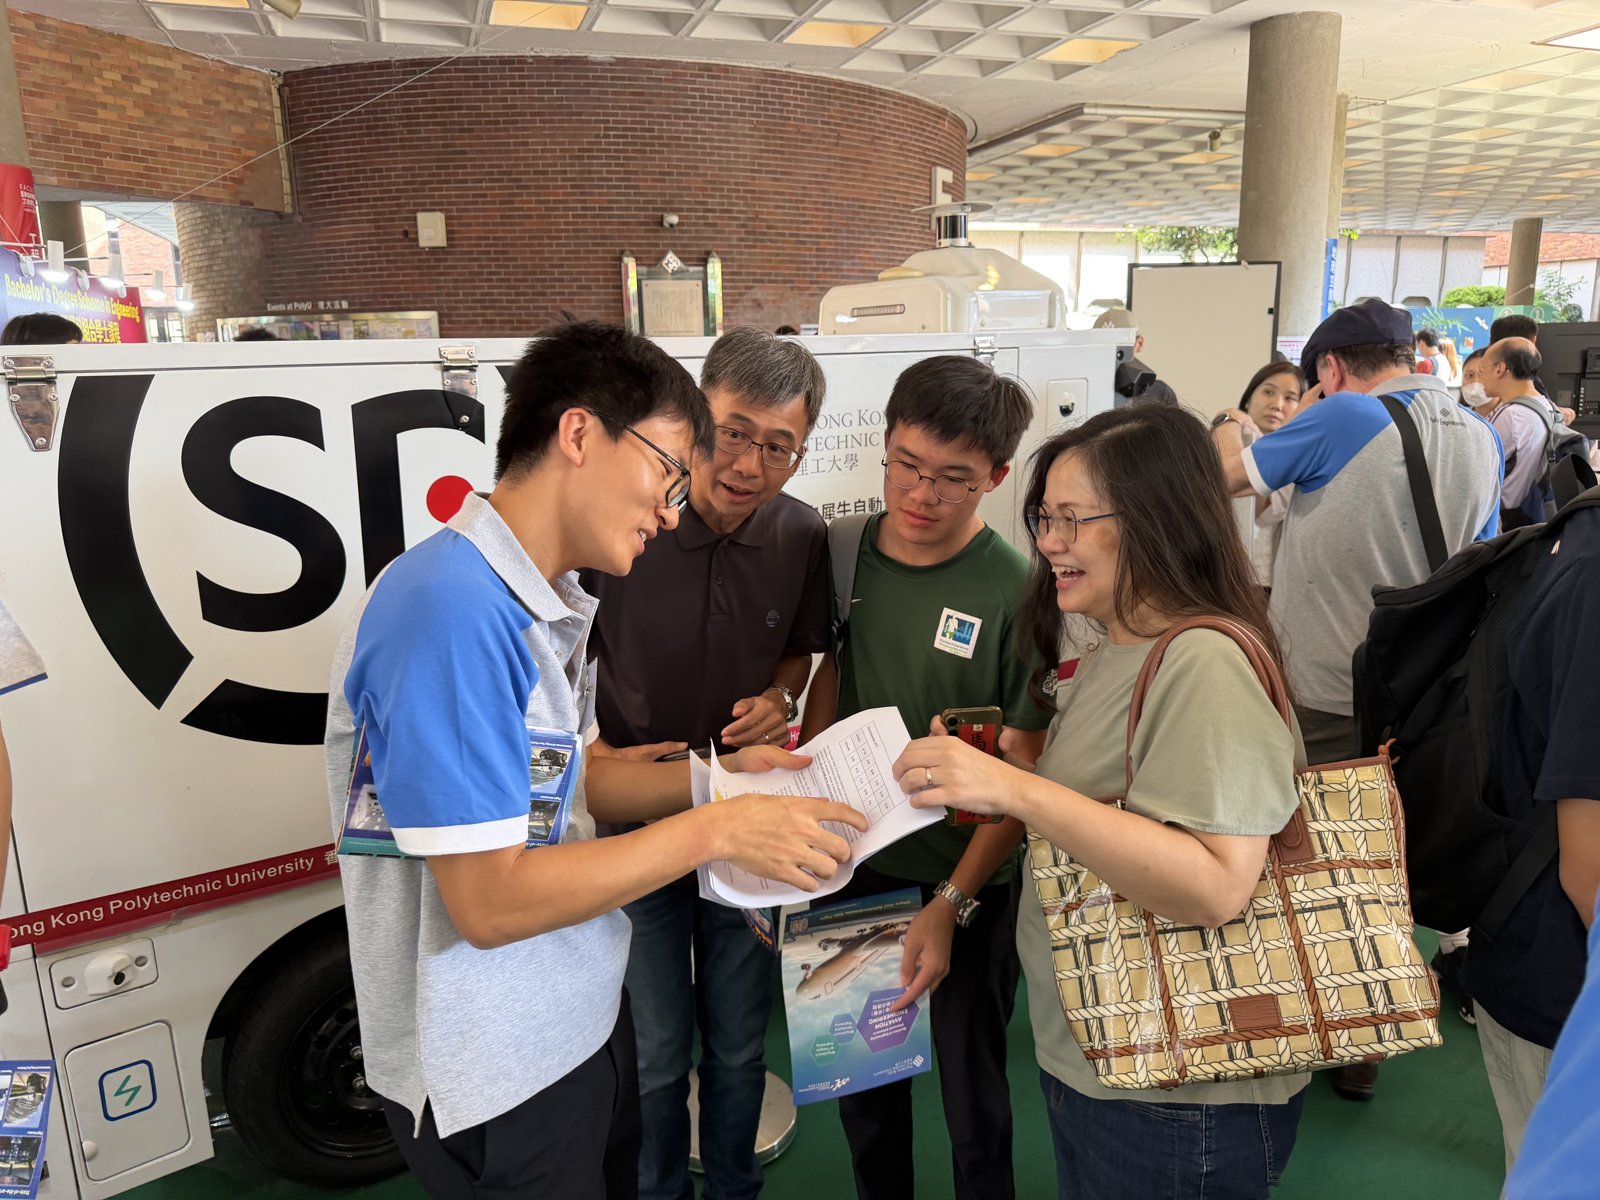
On 10 October 2026, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) took part in the PolyU Information Day for Undergraduate Admissions 2026 at The Hong Kong Polytechnic University (PolyU). At the Department of Aeronautical and Aviation Engineering (AAE) exhibition area, Prof Weisong WEN and TASLAB members presented the lab’s trustworthy intelligent driving logistics vehicle to prospective students, parents and members of the public.
We are pleased to share that the paper “Edge-AI Driven Low-Altitude Security: A Robust UAV Tracking System With Multi-Scale Attention And Adaptive Motion Modeling” was accepted for publication in a special section of the IEEE Transactions on Vehicular Technology (TVT) on 10 October 2026.
Dr Weisong Wen, Assistant Professor in the Department of Aeronautical and Aviation Engineering (AAE) at The Hong Kong Polytechnic University (PolyU) and founding Director of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB), has been named in the latest World’s Top 2% Scientists list, compiled by Stanford University and Elsevier. He appears in both the single-year and the career-long rankings, and has been named in the list every year since 2023.
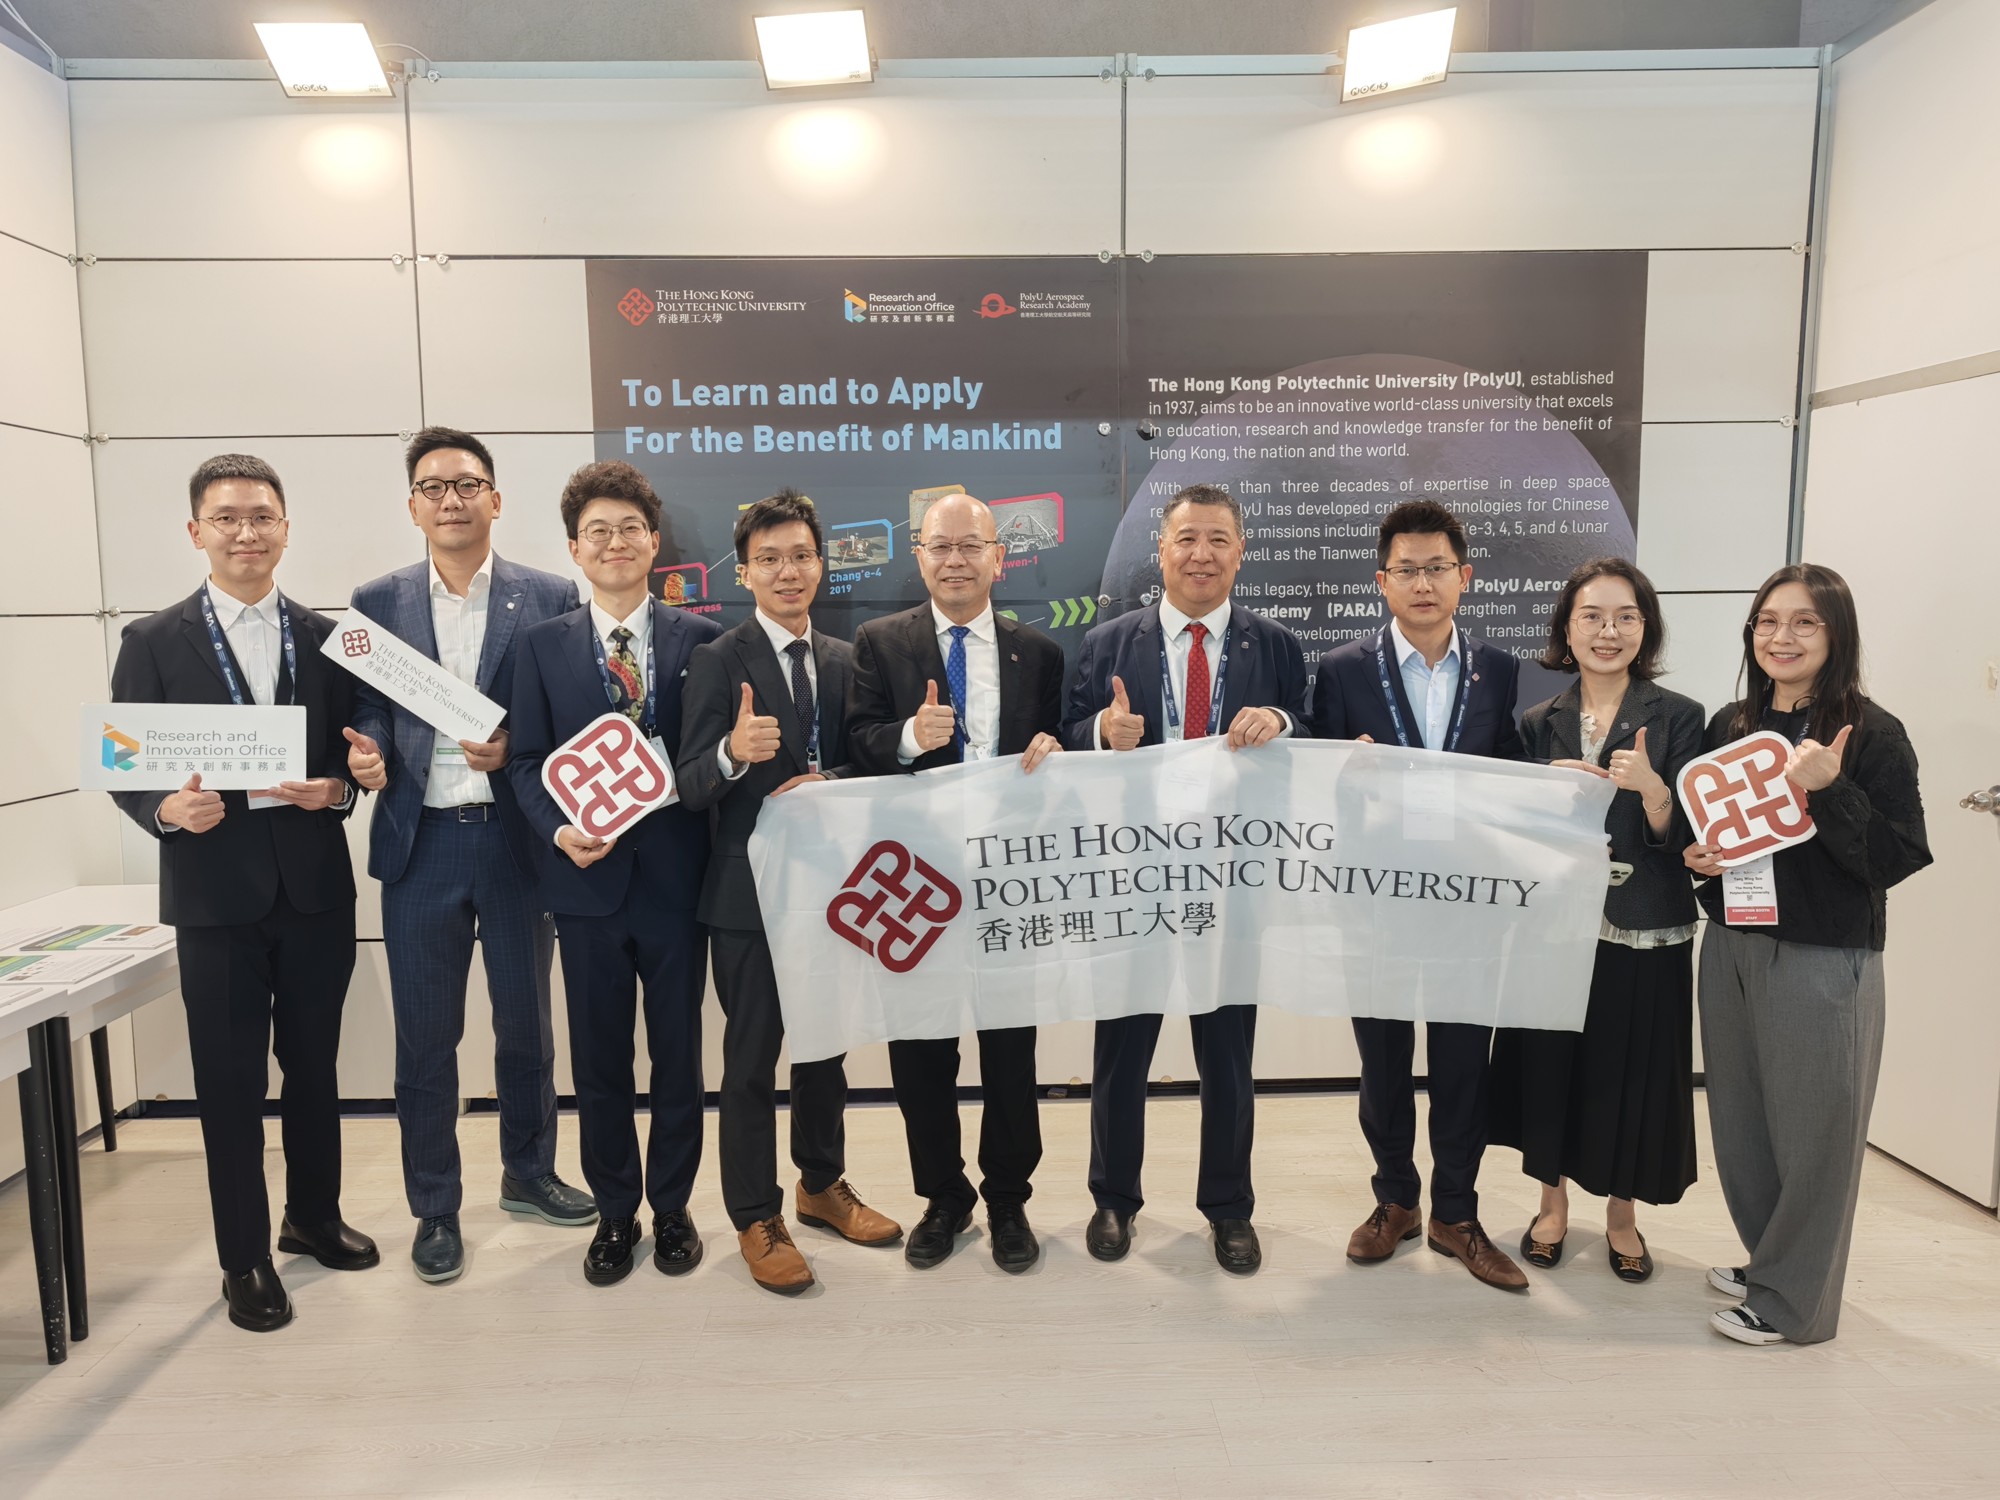
The 77th International Astronautical Congress (IAC 2026), held in Antalya, Türkiye, from 5 to 9 October 2026, brought together the international space community to share research, discuss future exploration and explore opportunities for cooperation.
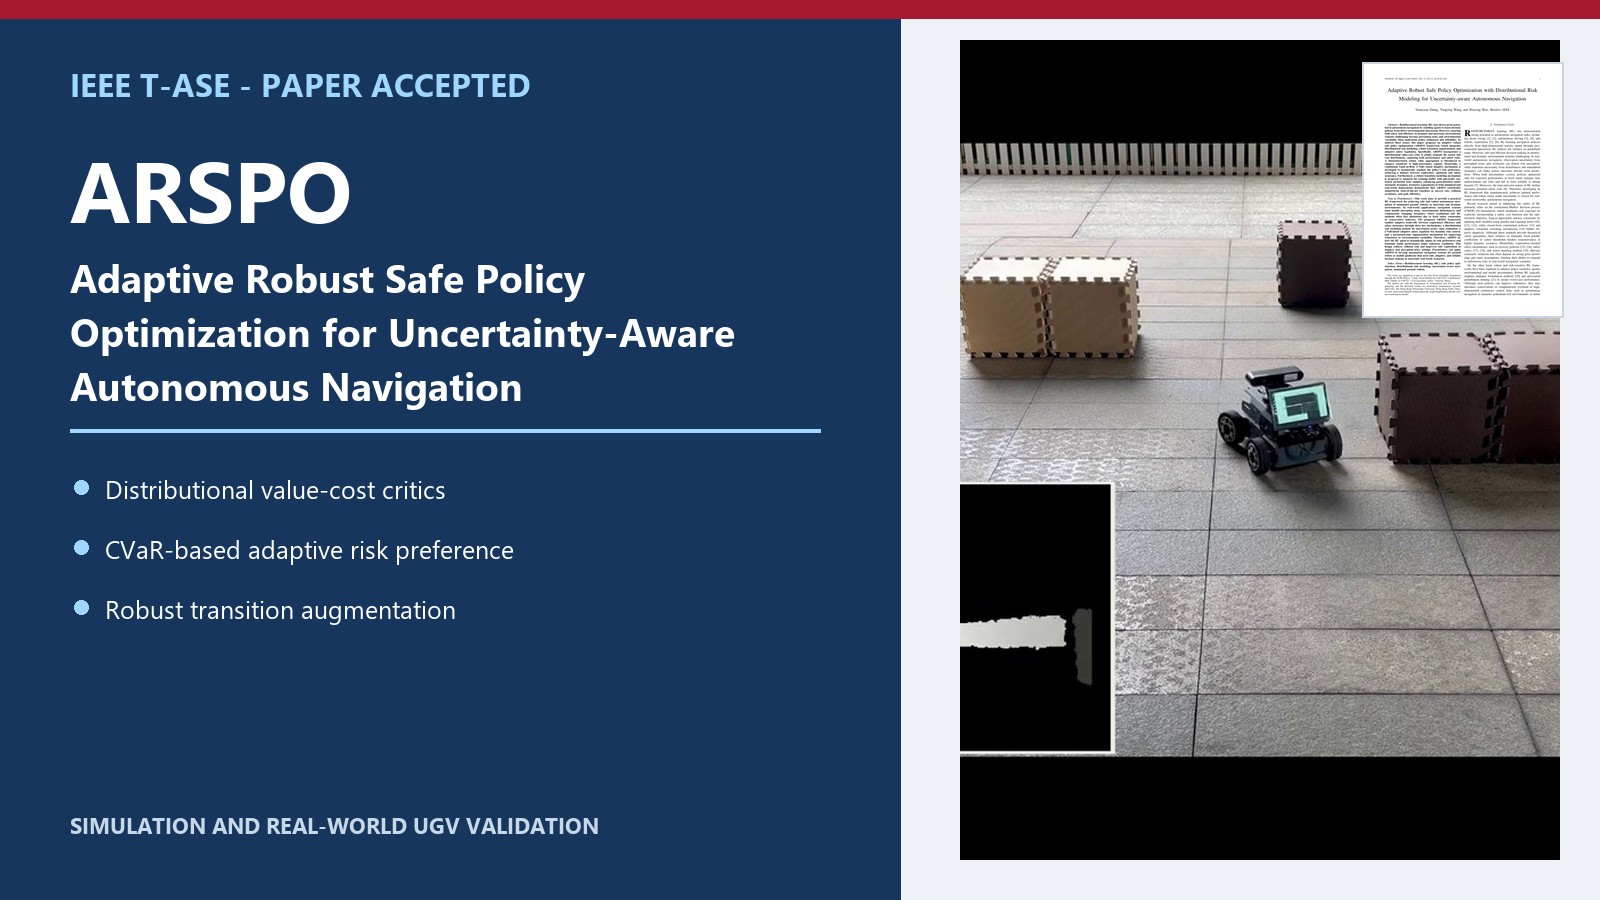
We are pleased to share that the paper “Adaptive Robust Safe Policy Optimization with Distributional Risk Modeling for Uncertainty-aware Autonomous Navigation” has been accepted for publication in the IEEE Transactions on Automation Science and Engineering (T-ASE) on 8 October 2026.
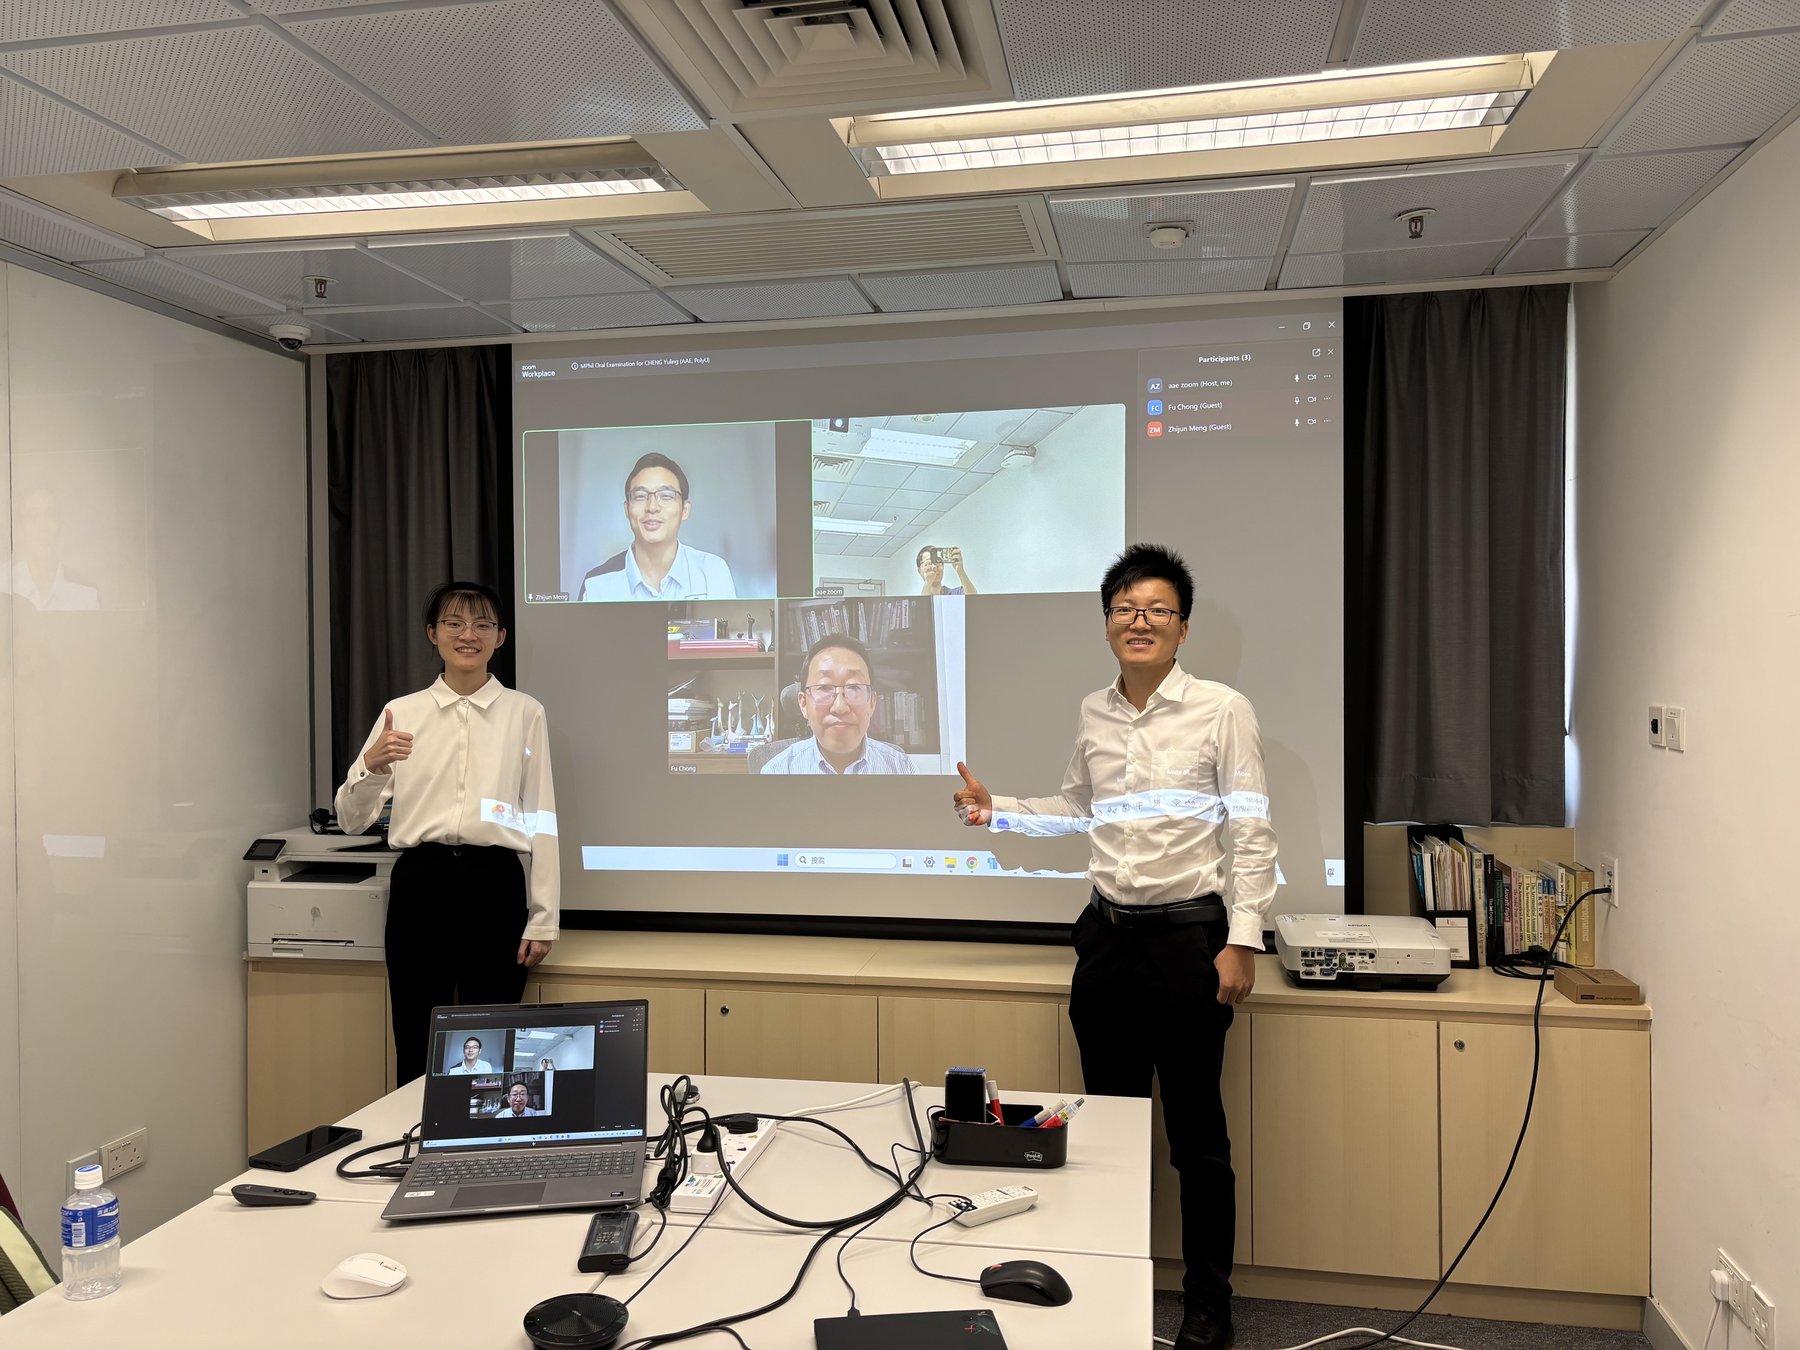
On 25 September 2026, TASLAB student CHENG Yuling successfully completed her MPhil oral defense at The Hong Kong Polytechnic University. Her thesis, supervised by Prof. Weisong Wen, is titled Multimodal Perception-Driven Semantic Traversability Mapping and Path Planning for Quadruped Robots.
Prof. Weisong Wen, Assistant Professor in the Department of Aeronautical and Aviation Engineering at The Hong Kong Polytechnic University (PolyU) and founding Director of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB), has been named a Merit Award recipient in the Research and Scholarly Activities: Outstanding Early Career Researcher category of the Faculty Awards for Outstanding Achievement 2026. The Faculty of Engineering announced the results on 15 September 2026.
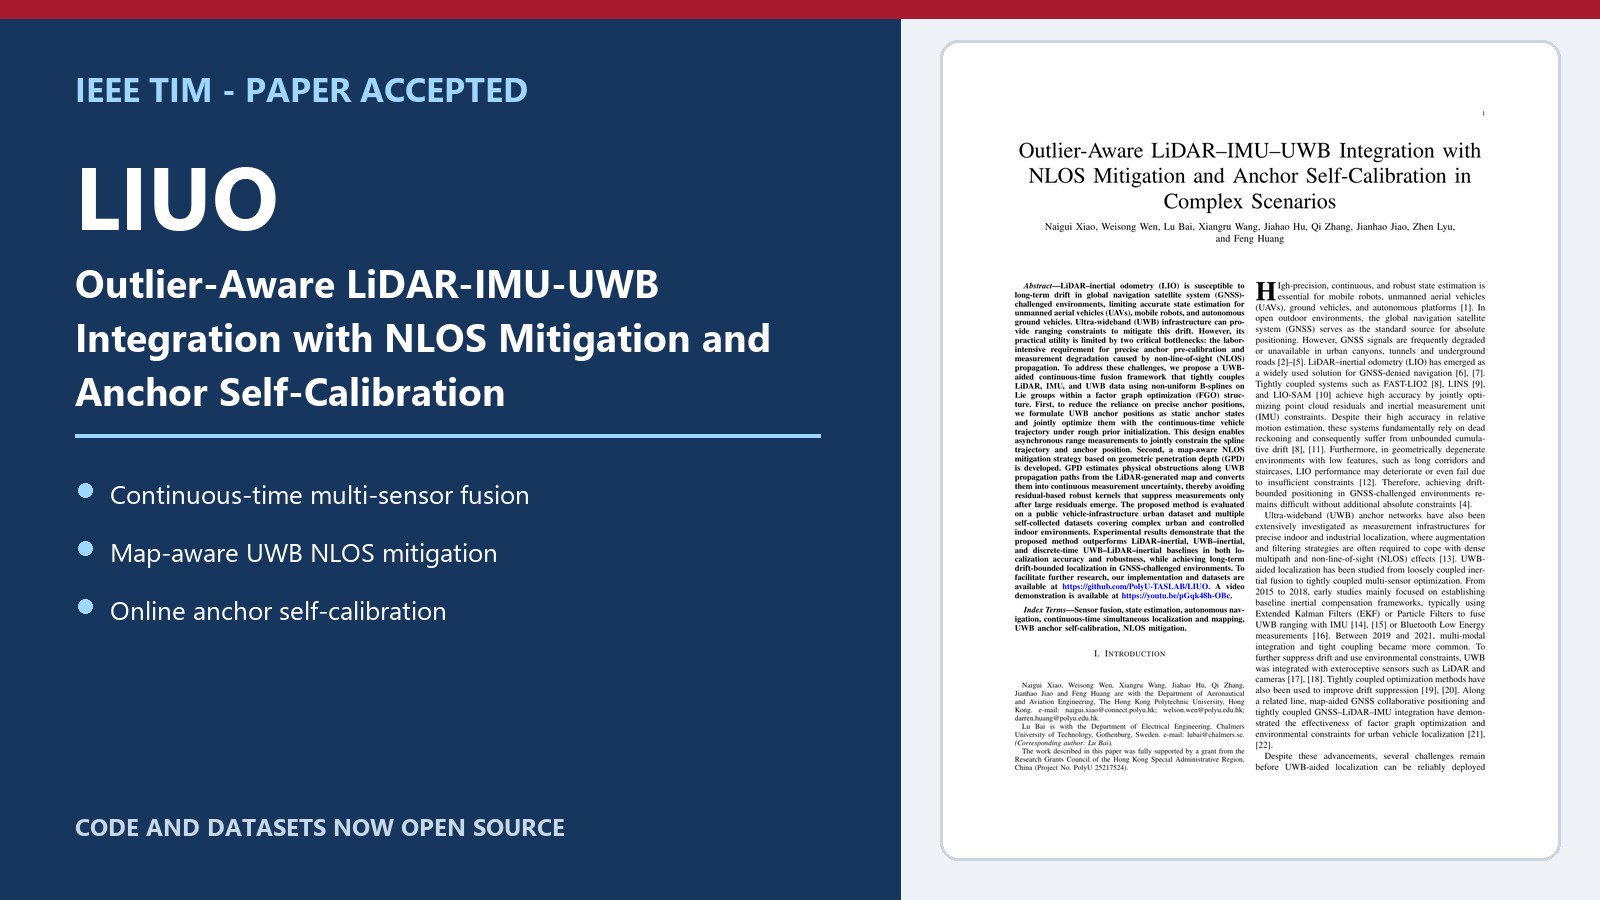
We are pleased to share that the paper “Outlier-Aware LiDAR/IMU/UWB Integration with NLOS Mitigation and Anchor Self-Calibration in Complex Scenarios” has been accepted for publication in the IEEE Transactions on Instrumentation and Measurement (TIM) on 15 September 2026.
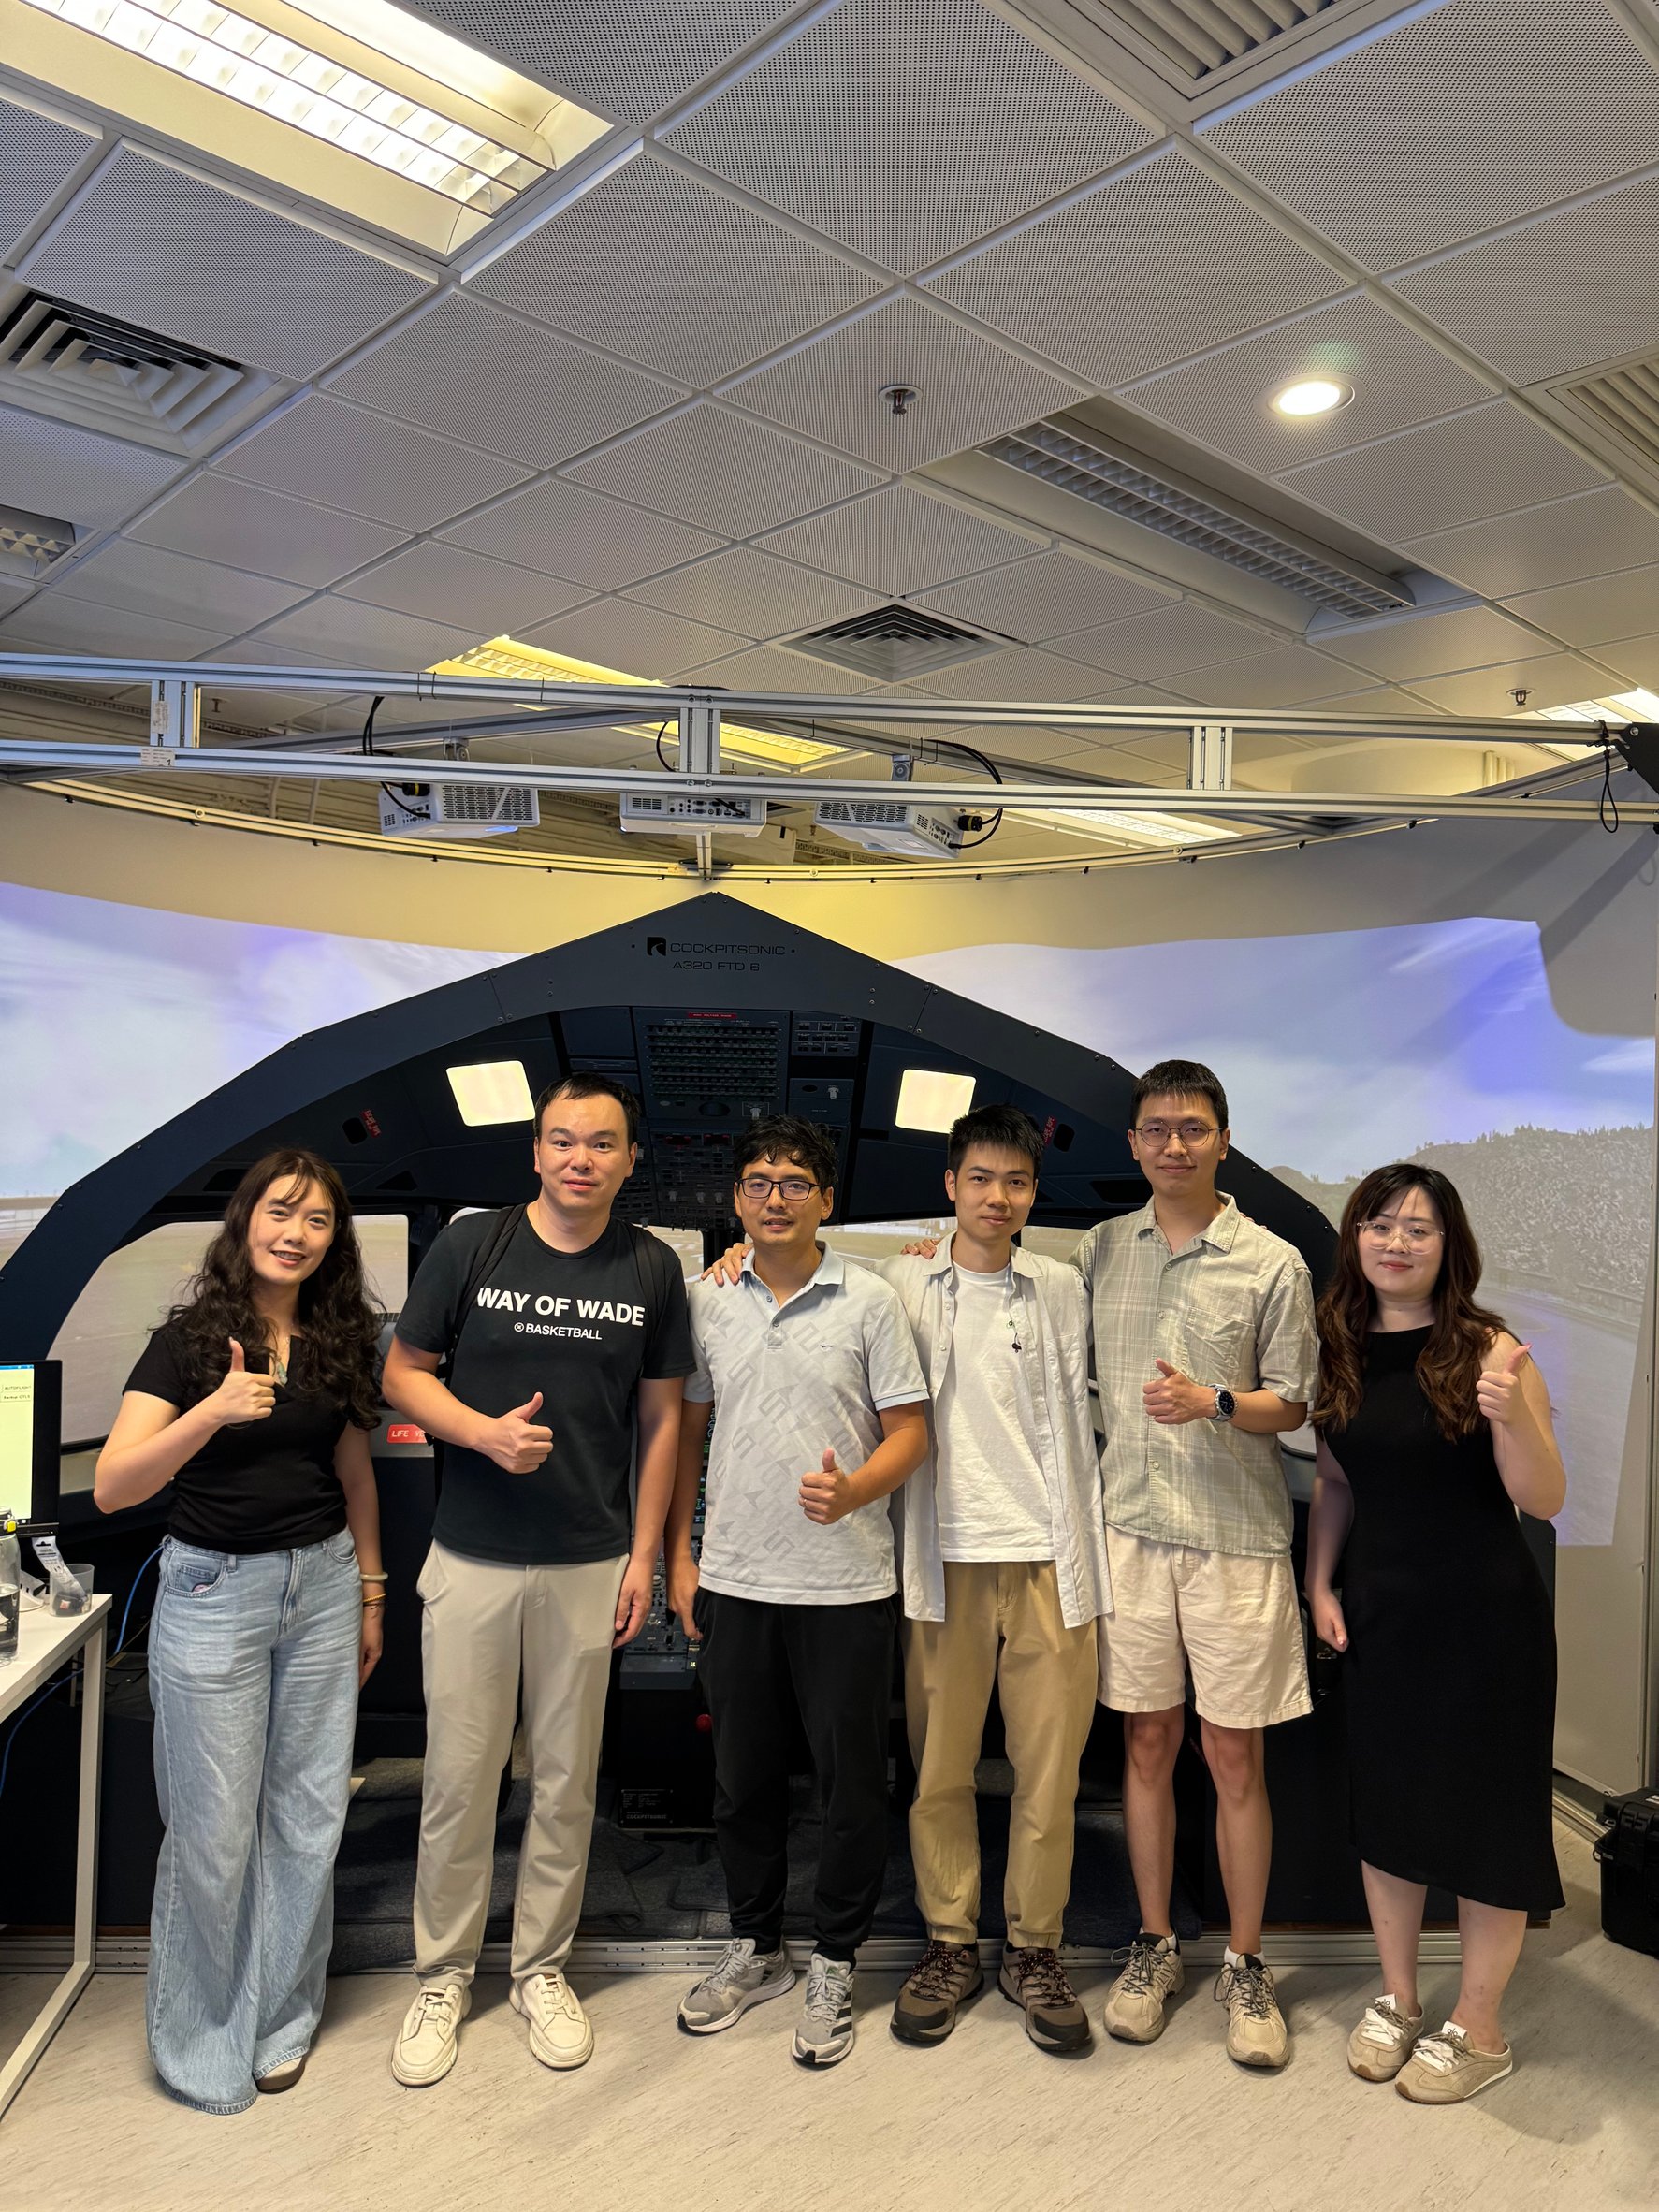
On 15 September 2026, a delegation from Mammotion (Shenzhen KUMA Technology Co., Ltd.), a Shenzhen-based developer of intelligent outdoor robotics led by Dr. Chuhao Liu, visited the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU). Mammotion is a national-level “little giant” enterprise specializing in smart courtyard robotics. It is known for its LUBA and YUKA series robotic lawn mowers and for the Tri-Fusion positioning system, which fuses LiDAR, RTK and vision on a single navigation platform to deliver centimetre-level localization without boundary wires or additional base stations.
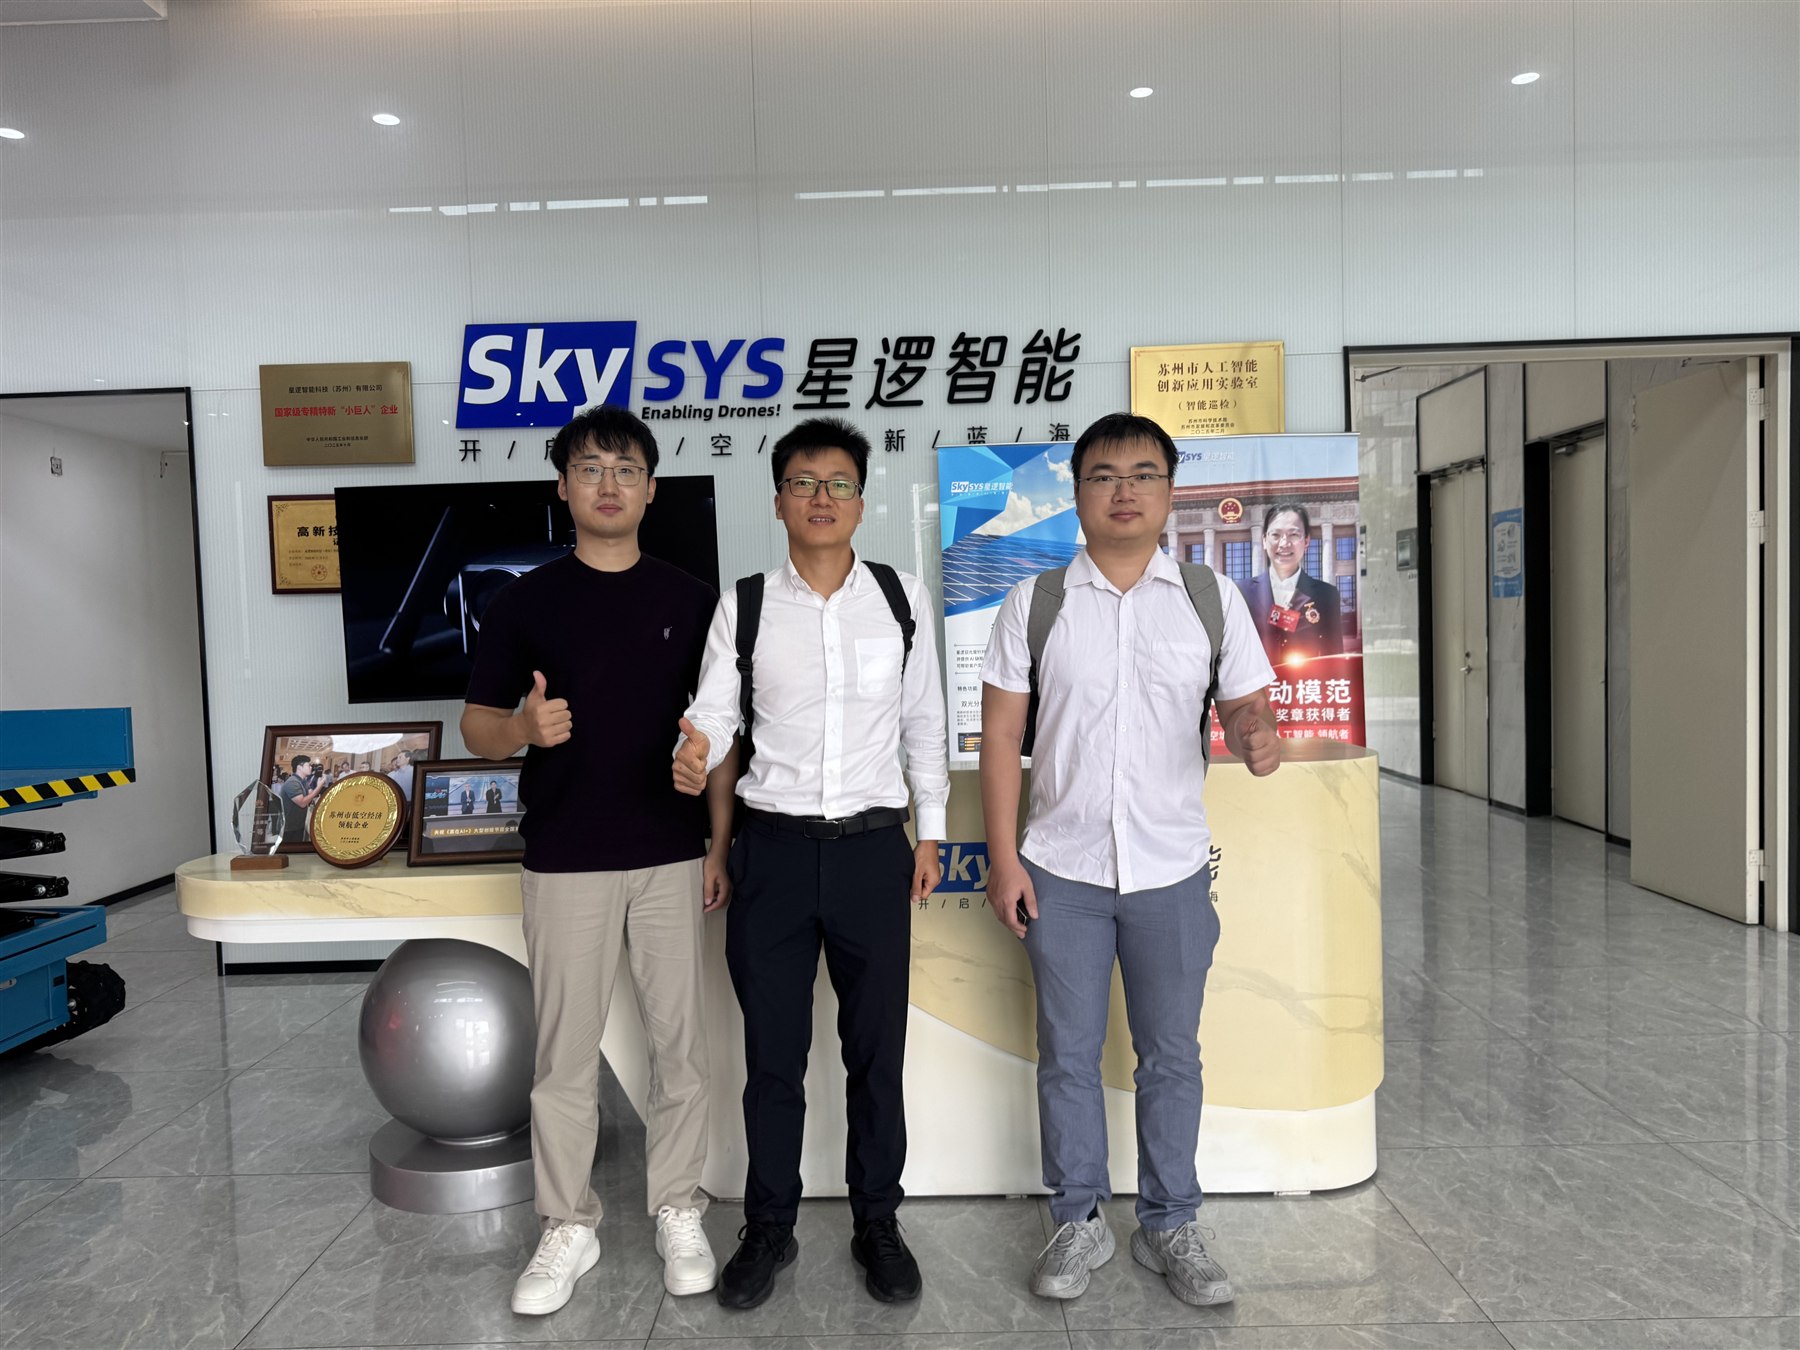
On 9 September 2026, Prof. Weisong Wen visited Skysys, an intelligent unmanned-systems company, for a technical exchange on autonomous aerial technologies and their potential applications in solar panel cleaning. The visit focused on possible collaboration between the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) and Skysys in developing UAV-based solutions for photovoltaic panel inspection, maintenance and cleaning.
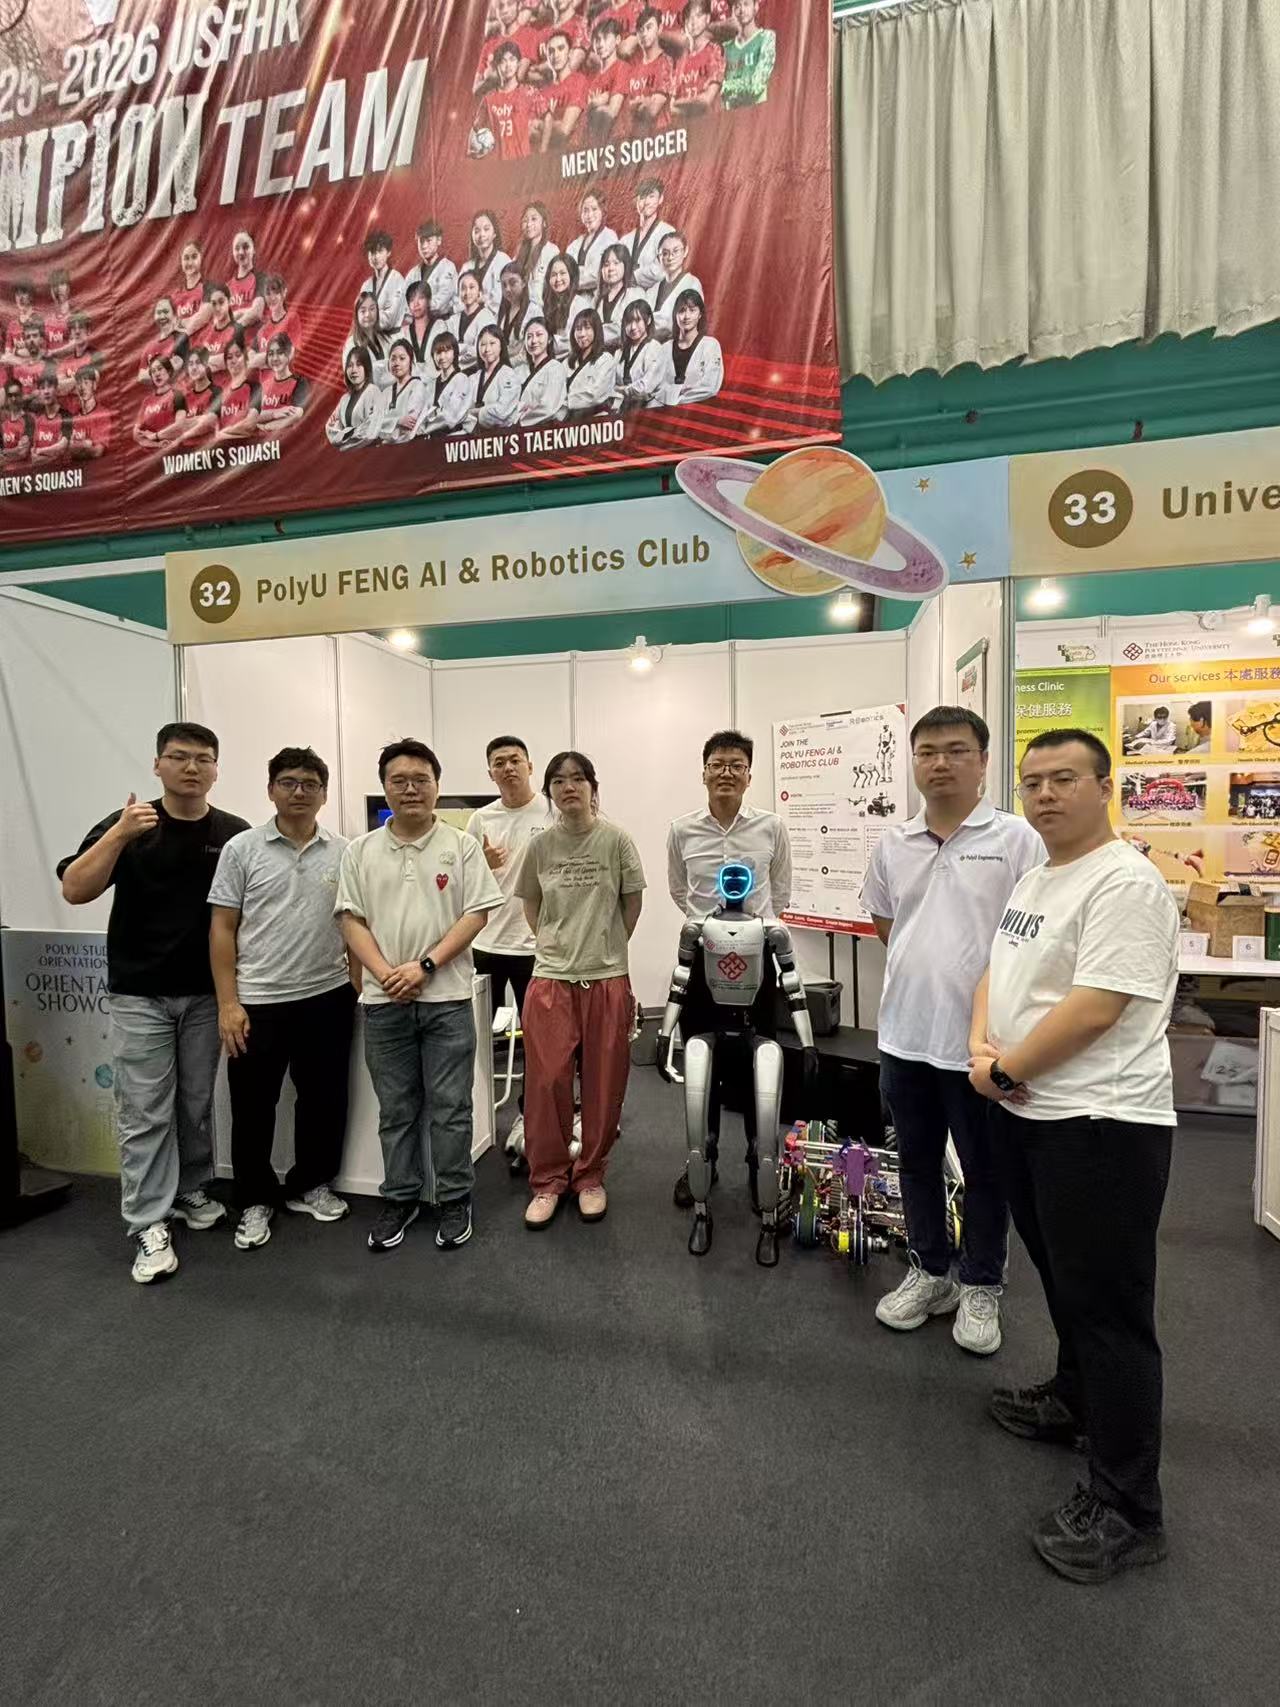
On 1 September 2026, members of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) supported the PolyU FENG AI & Robotics Club during PolyU Student Orientation 2026. The event welcomed new students to campus and gave them an opportunity to discover the club’s activities, meet its members and explore how artificial intelligence and robotics can be applied through hands-on engineering projects.
On 23 August 2026, members of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) attended the ABU Asia-Pacific Robot Contest 2026 at Queen Elizabeth Stadium in Wan Chai, Hong Kong. The visit gave our laboratory members an opportunity to experience one of the region’s leading university robotics competitions and observe how student teams transformed mechanical design, perception, control, and real-time strategy into complete robotic systems.
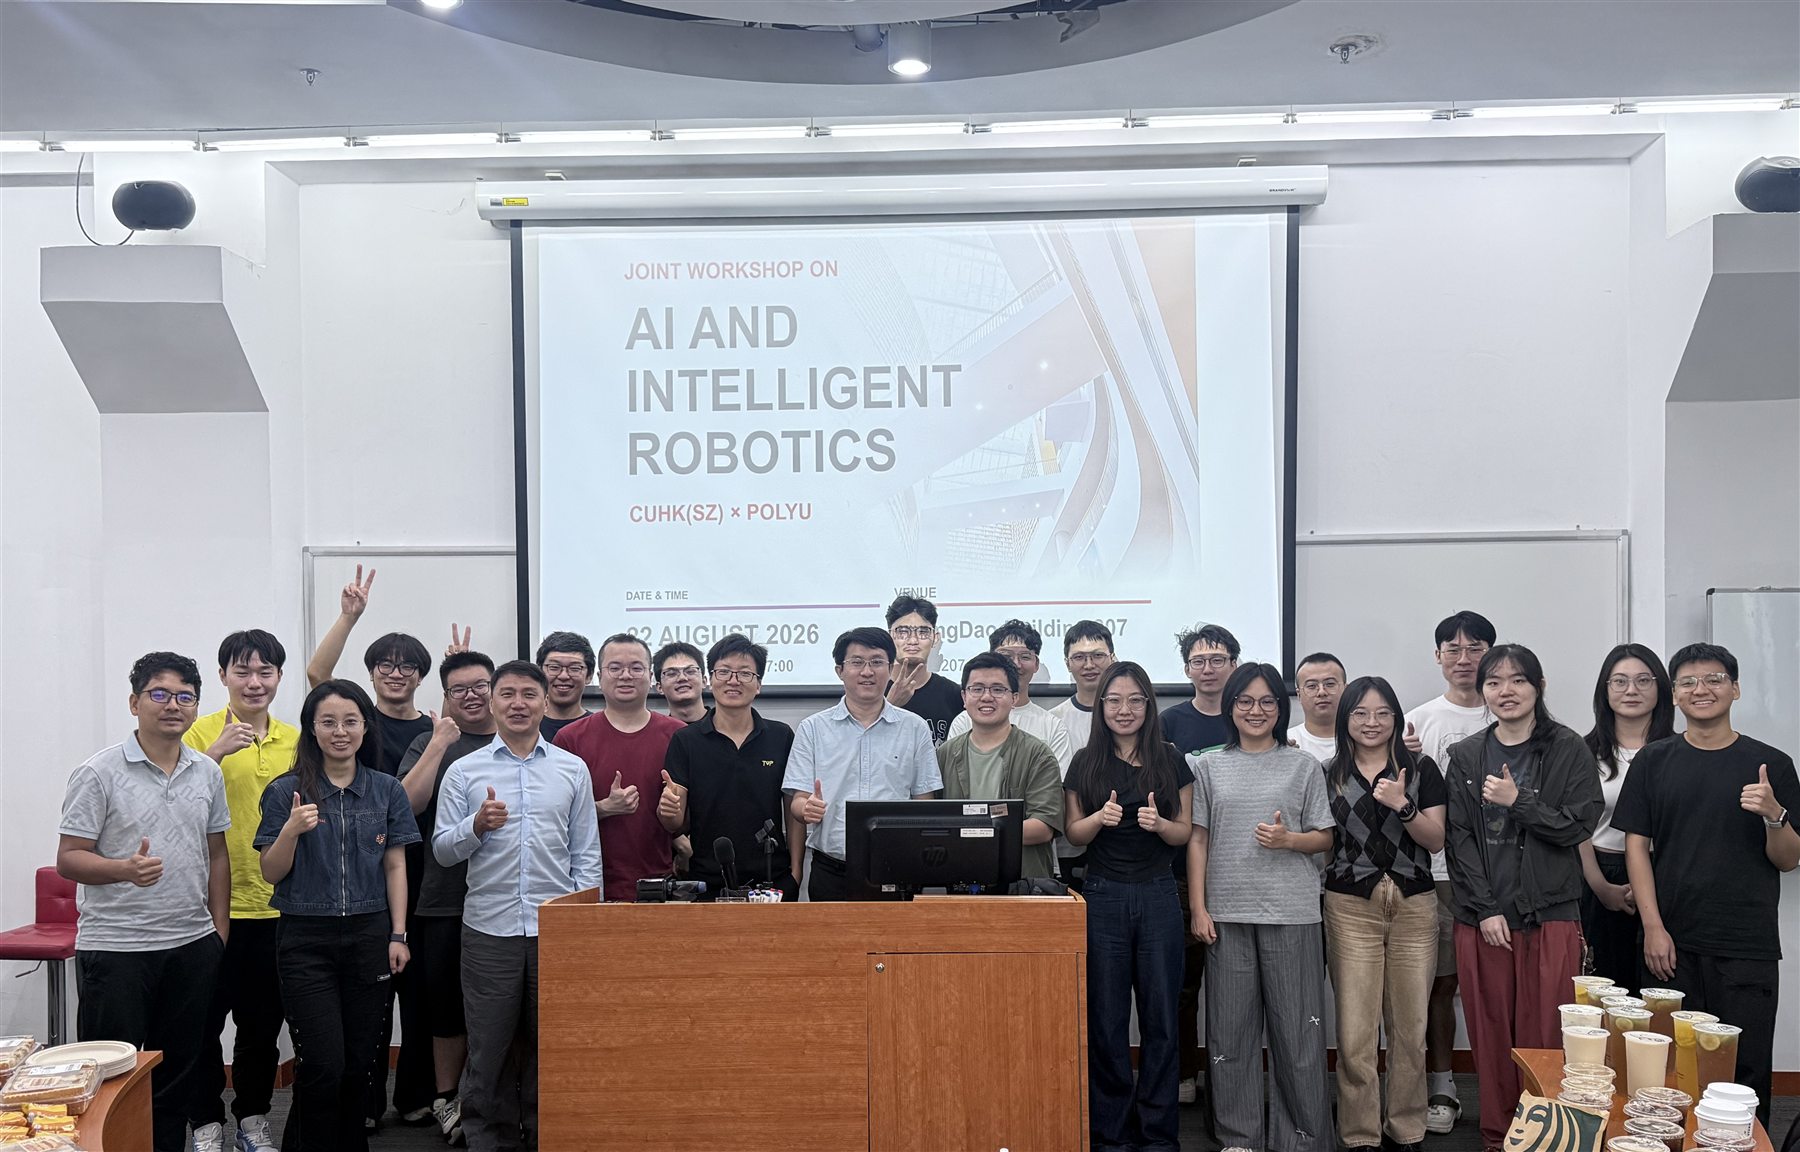
On 22 August 2026, The Hong Kong Polytechnic University (PolyU) and The Chinese University of Hong Kong, Shenzhen (CUHK-Shenzhen) co-hosted a Joint Workshop on AI and Intelligent Robotics at CUHK-Shenzhen. The workshop brought together faculty members and students from both universities for an afternoon of research presentations, technical discussions and laboratory exchange.
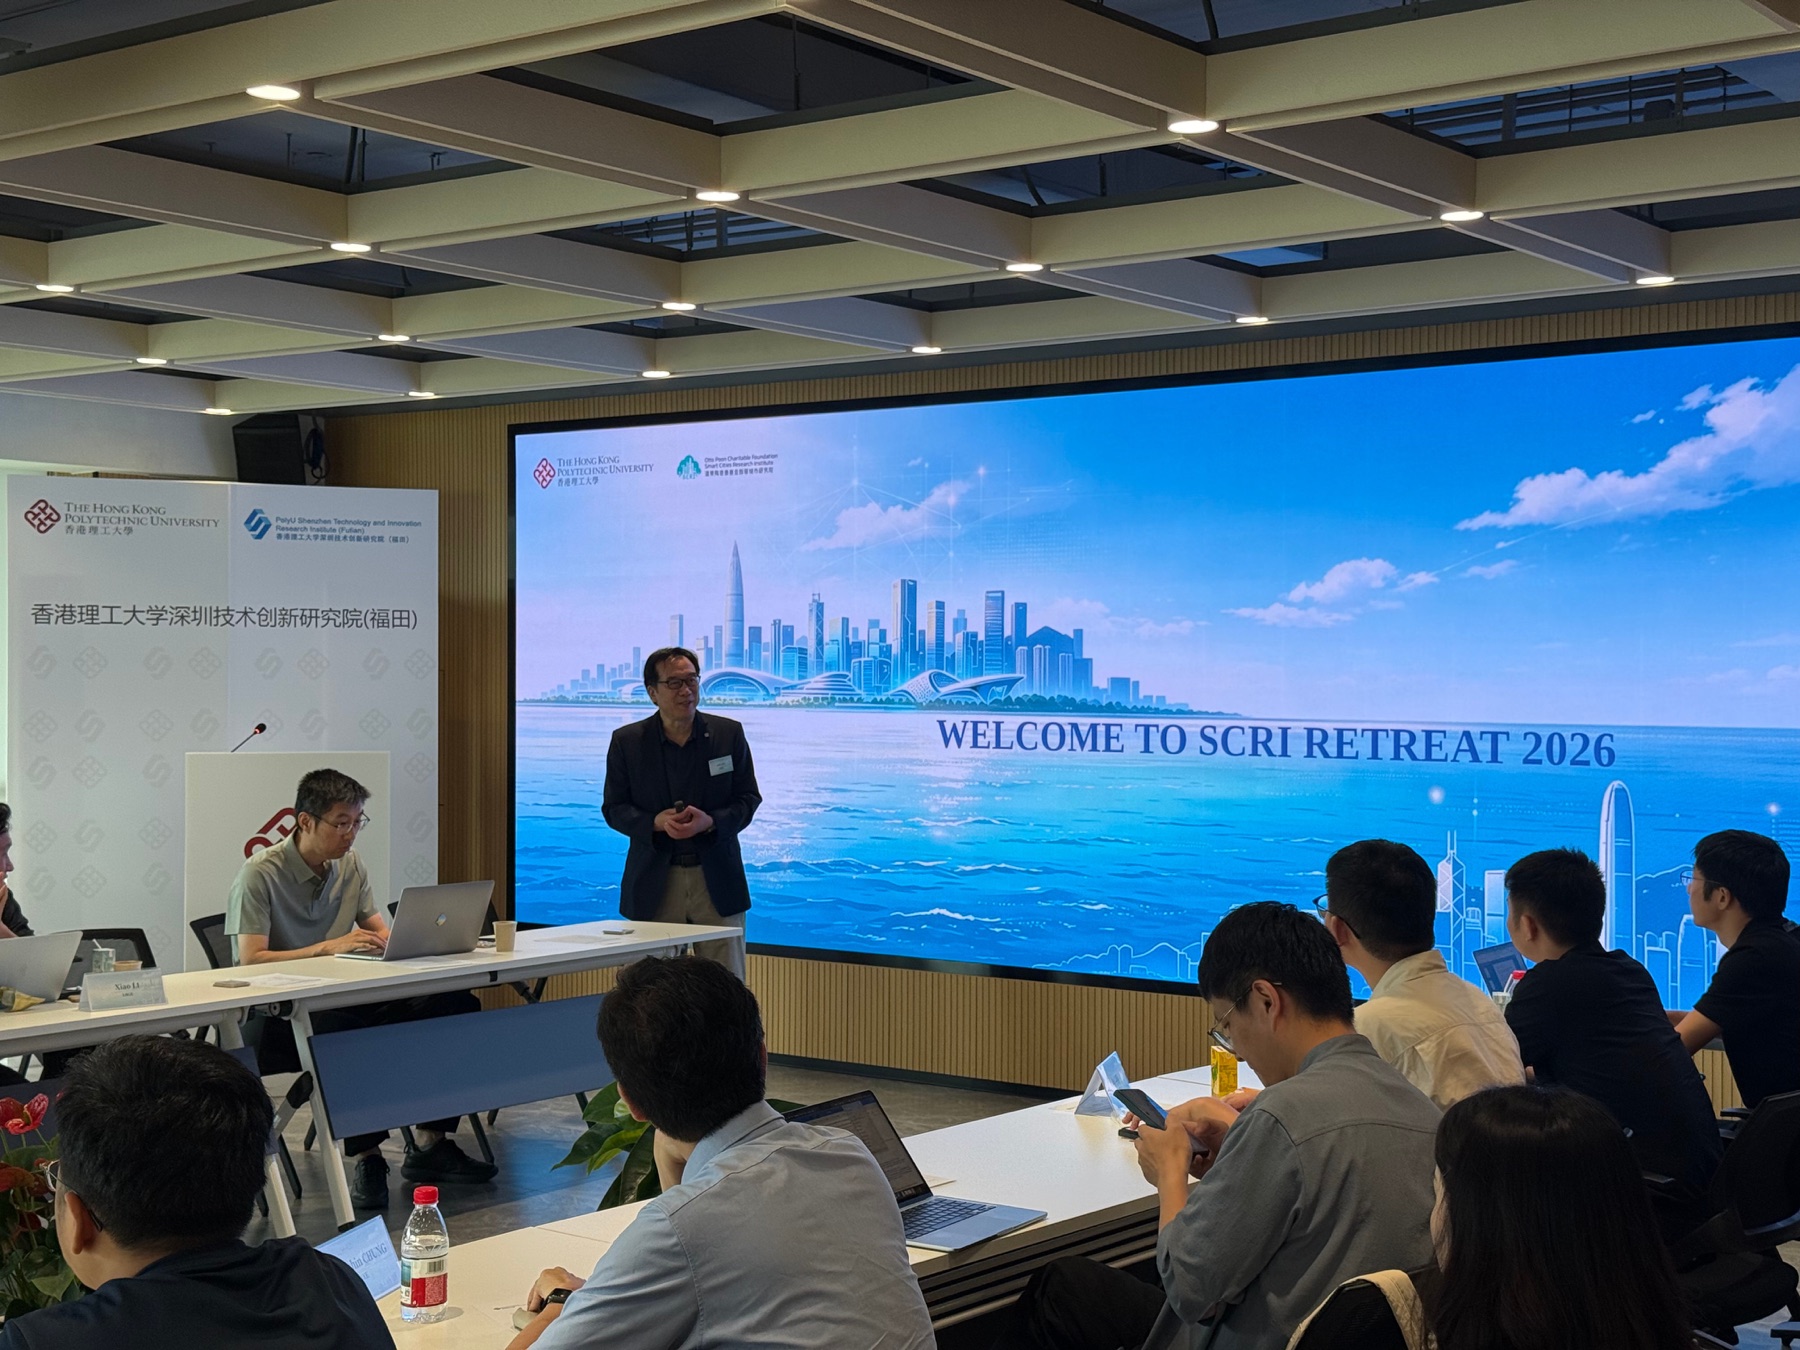
On 21 August 2026, Prof. Weisong Wen took part in SCRI Retreat 2026 at the PolyU Shenzhen Technology and Innovation Research Institute (Futian). The retreat, hosted by Prof. SHI Wenzhong, brought researchers together to exchange ideas, strengthen collaboration and discuss future research directions for the Otto Poon Charitable Foundation Smart Cities Research Institute (SCRI).
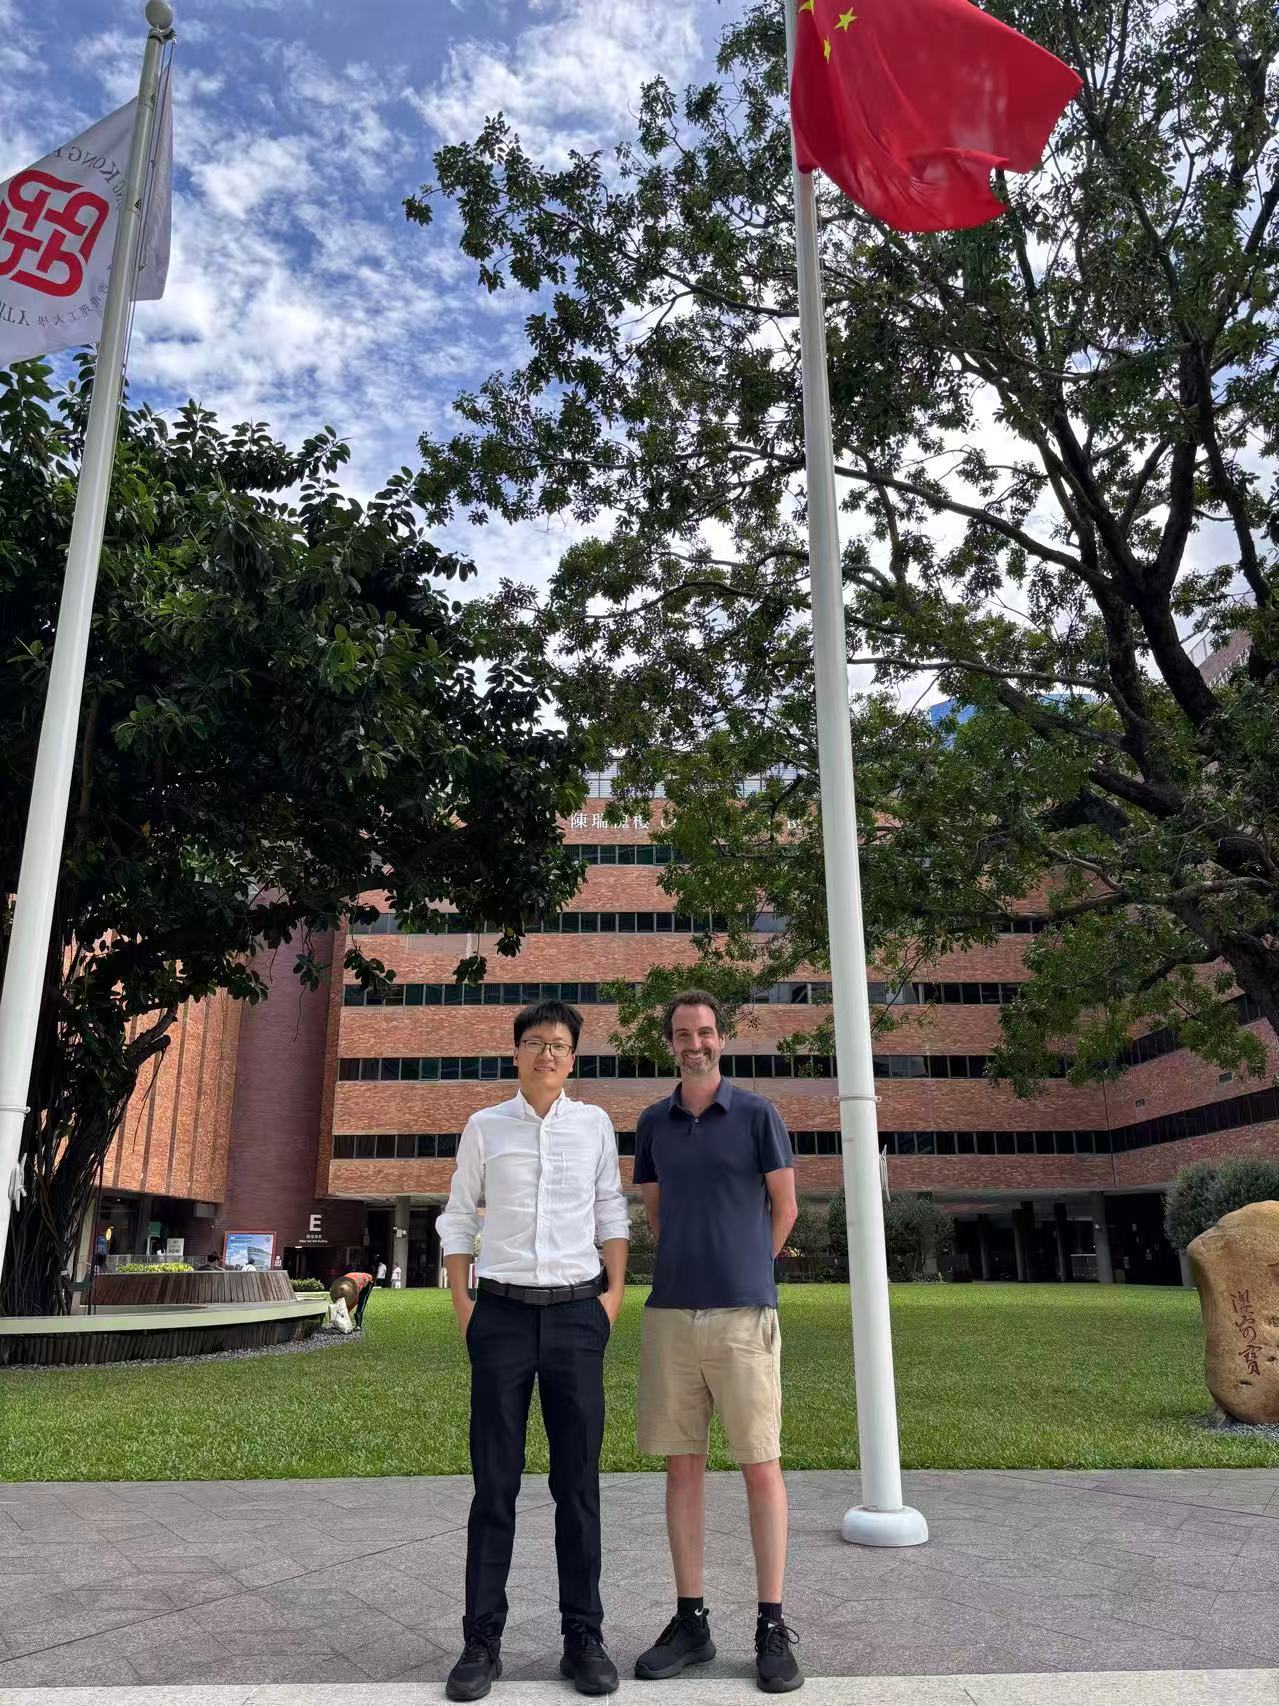
From 4 to 7 August 2026, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) welcomed Prof. David M. Rosen of Northeastern University for an academic visit hosted by Prof. Weisong WEN. The visit included meetings with colleagues at The University of Hong Kong (HKU), a visit to TASLAB with research discussions with lab members, and an AAE research seminar, bringing together perspectives on the mathematical foundations and practical development of trustworthy autonomous systems.
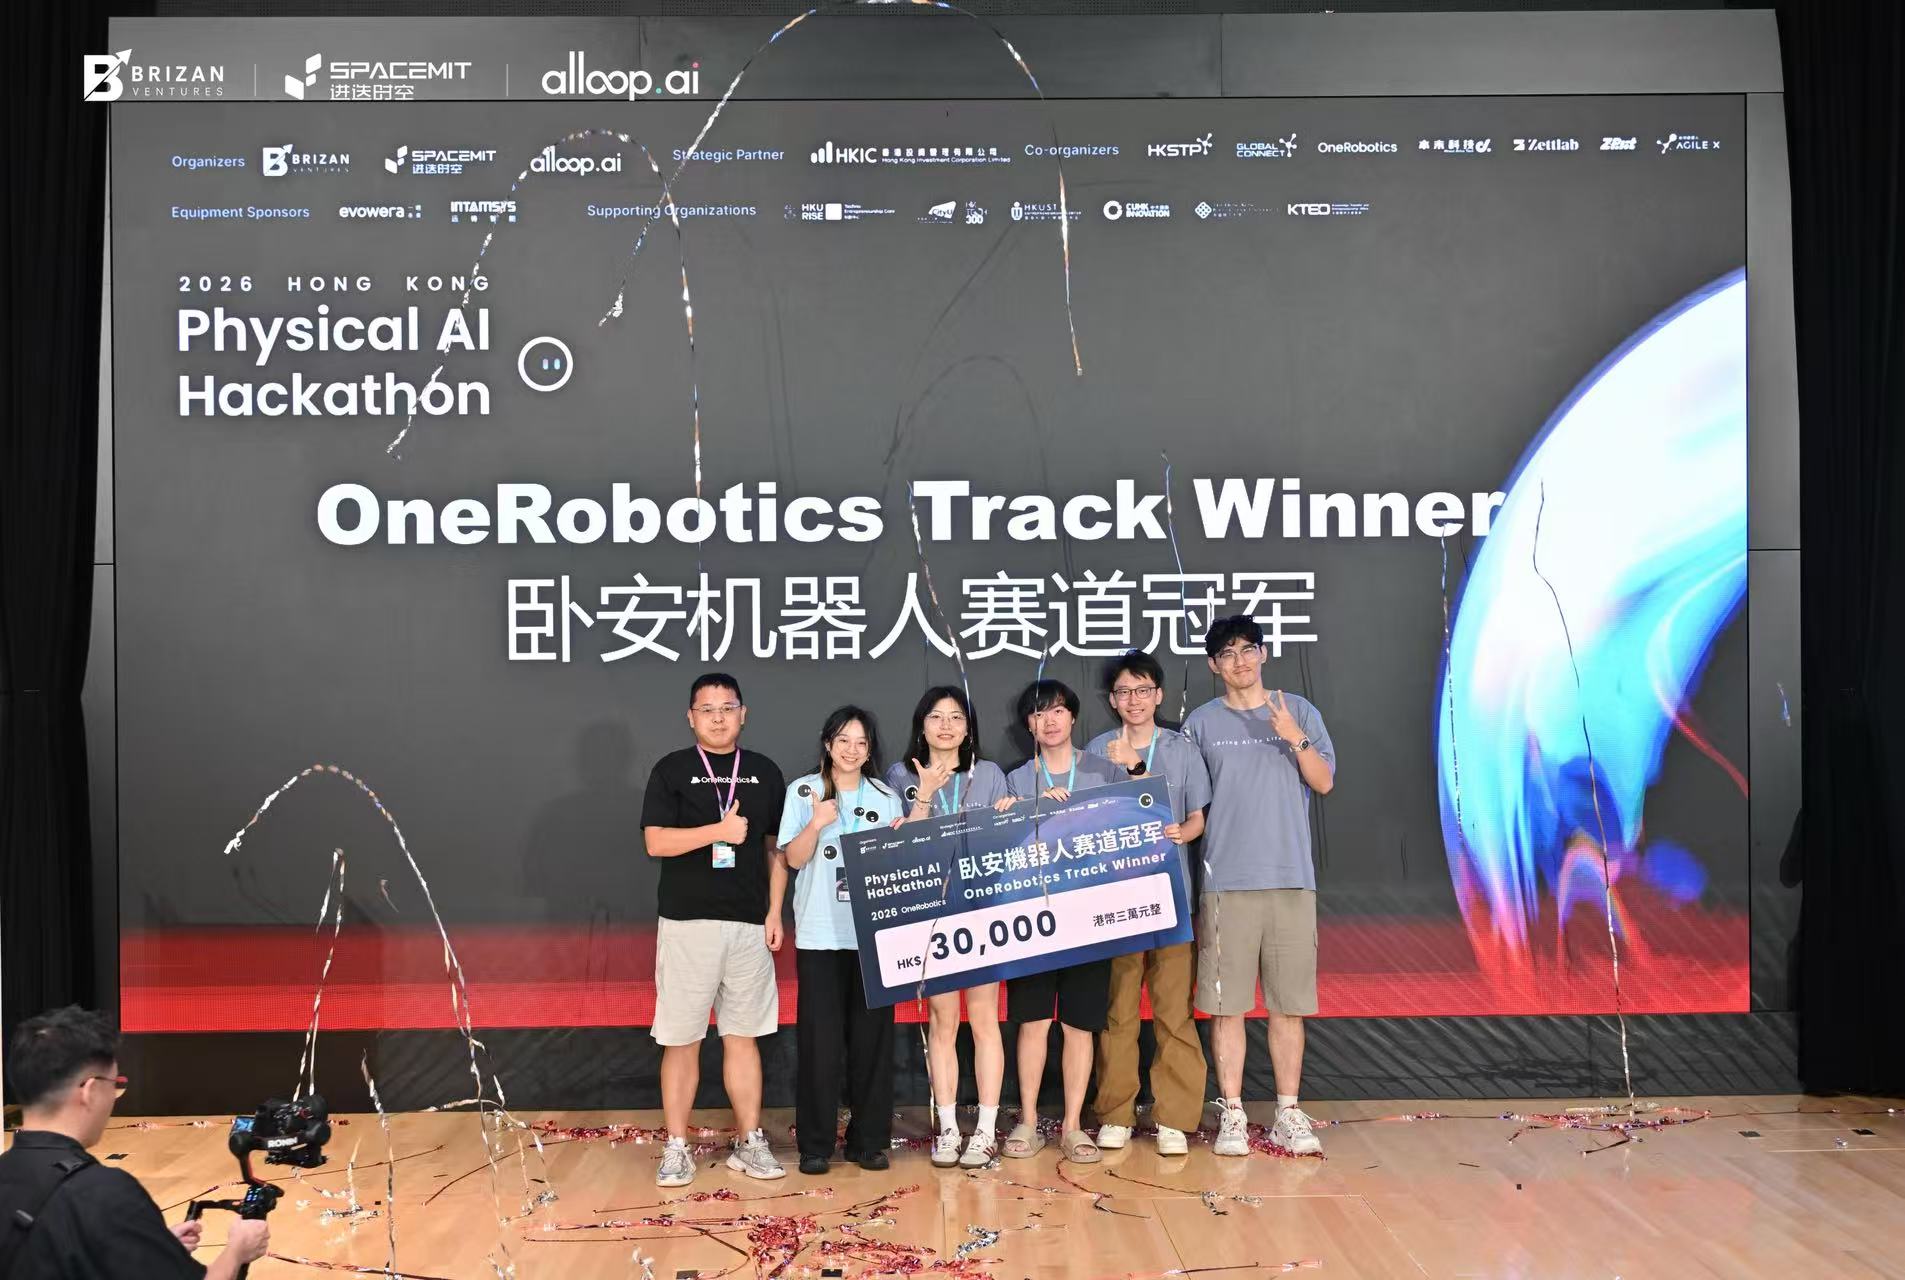
Four PhD students from the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU), Xu Ruijie, Feng Yu, Xiao Naigui and Wang Xin, won the championship of the OneRobotics “Third Hand” Track at Hong Kong’s inaugural Physical AI Hackathon. The 48-hour competition concluded on 5 August 2026 at the Charles K. Kao Auditorium in Hong Kong Science Park.

On 29 July 2026, members of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) visited the Institute of Sensing and Navigation at Shanghai Jiao Tong University at the invitation of Prof. Ling Pei. The TASLAB delegation comprised Mr. Ziqi Zhang, Mr. Qi Zhang, Mr. Qijun Qin, Mr. Yingming Chen and Dr. Feng Huang.

On 29 July 2026, Prof. Wenfeng Nie, Head of the Department of Navigation Engineering and Remote Sensing at the School of Space Science and Technology, Shandong University, led a delegation of undergraduate students on a visit to the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU). The delegation was hosted by Prof. Weisong Wen, Director of TASLAB.

HONG KONG, 26 July 2026 – The Hong Kong Polytechnic University (PolyU) and Shenzhen Genvict Technologies Co., Ltd. (Genvict) have established the Joint Laboratory for Artificial Intelligence and Connected Unmanned Systems, marking a new stage in their industry–academia collaboration on intelligent transportation and autonomous systems. The five-year cooperation agreement was signed on 3 June 2026.
Prof. Weisong Wen, Director of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU), has contributed as Co-Investigator (Co-I) to a research project that has received the Natural Science Award (First Prize) from the China Simulation Federation.
Professor Weisong Wen, Director of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU), has been officially appointed an Associate Editor of the IEEE Transactions on Intelligent Vehicles (T-IV).

On 11 July 2026, Prof. Weisong Wen, Director of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU), received a Best Oral Presentation Award at the 2026 International Conference on Robotics and Learning (ICRL 2026). The conference was held from 10 to 14 July in Yili, Xinjiang, China.

On 10 July 2026, Prof. Weisong Wen, Director of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU), received a Best Presentation Award at the 2026 3rd Navigation Technology and Application Conference (NaviCON 2026) in Chengdu, China. The conference was held from 8 to 10 July at the Chengdu Century City Convention Center and organized by the Chinese Institute of Electronics (CIE) together with the Sichuan Provincial Committee of the CCPIT and the Sichuan International Chamber of Commerce. Under the theme “Multi-source Augmentation, Advancing Toward Intelligence” (多基增强、向智而行), it brought together academicians, researchers and industry practitioners working on BeiDou-based positioning, navigation and timing (PNT).

On 30 June 2026, representatives from the Housing Department and China Resources visited the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) for an exchange on autonomous systems, robotic technologies and potential smart facility applications. The visitors included PC Wang from the Housing Department and William Wong from China Resources.

On 29 June 2026, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) took part in the PolyU-Tsinghua Alumni Association Jiangsu Visit and the PolyU industry-university-research achievements exhibition held in Wuxi. The event brought together university leaders, alumni representatives, government officials, research institutes and industry partners to promote technology exchange, innovation collaboration and the translation of research outcomes into real-world applications.
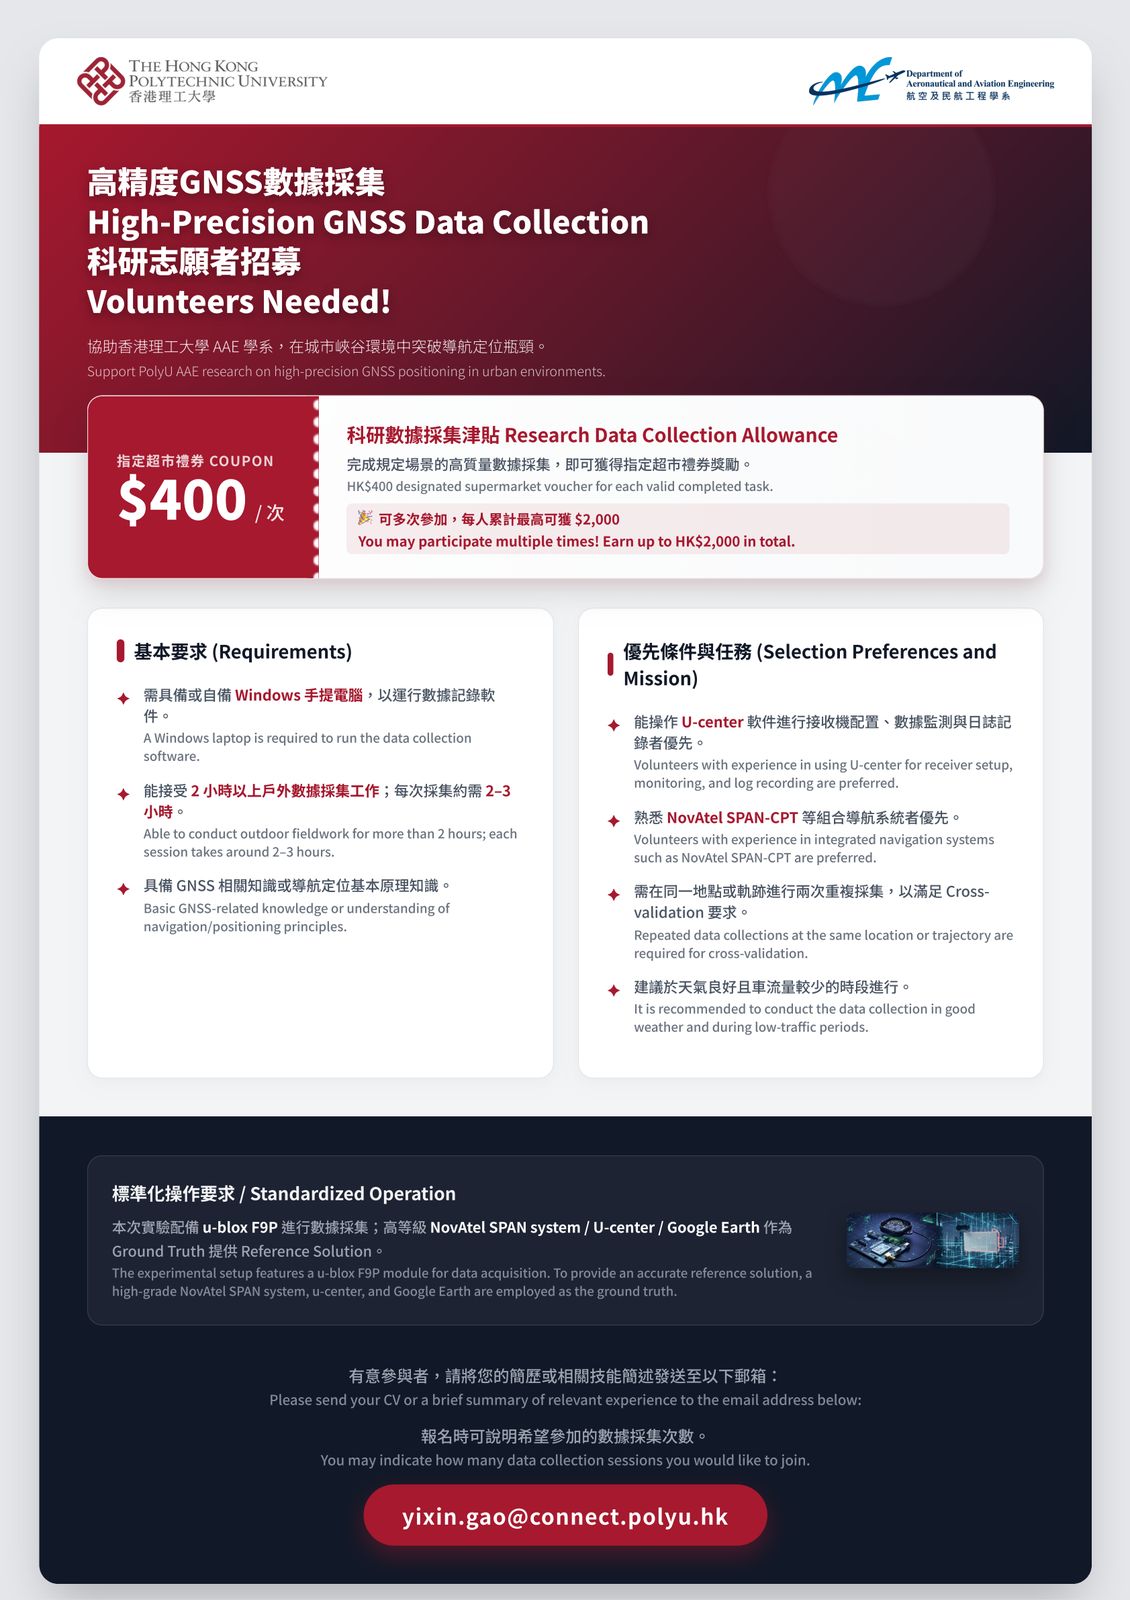
The Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) is conducting a research project on high-precision GNSS positioning in urban environments. We are looking for enthusiastic volunteers to assist with outdoor GNSS data collection and equipment cross-validation.

On 25 June 2026, Prof. Weisong Wen, Director of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU), presented at the International Technical Symposium on Navigation and Timing (ITSNT 2026), held at the École Nationale de l’Aviation Civile (ENAC) in Toulouse, France.
On 5 June 2026, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) announced that it will help supervise the PolyU AI and Robotics Club, reflecting its support for student-led innovation in artificial intelligence and robotics. The effort will be led by Prof. Weisong Wen, with support from the PolyU Faculty of Engineering, Ir Prof. H.C. Man, Dean of the Faculty of Engineering, and the PolyU Industrial Centre.

The Trustworthy AI and Autonomous Systems Laboratory (TASLAB) hosted the 1st Workshop on Robot Meets GNSS and Ranging for Seamless Autonomy at the 2026 IEEE International Conference on Robotics and Automation (ICRA 2026) in Vienna, Austria. The workshop brought together researchers from the robotics, navigation, positioning and intelligent transportation communities to discuss how GNSS, UWB, ranging and multi-sensor fusion technologies can support reliable robot autonomy in complex real-world environments. More details are available on the workshop page.

On 3 June 2026, a delegation from the Zhuhai High-tech Industrial Development Zone visited the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) for an exchange on intelligent autonomous systems, technology transfer and potential project implementation.

On 31 May 2026, members of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) gathered to celebrate two experienced and respected members, Dr. Runqiu Yang and Dr. Jianhao Jiao, as they prepare to begin new chapters in their careers.

On 15 May 2026, members of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB), Dr. Huang Feng, Mr. Zhang Ziqi and Mr. Qin Qijun, visited the Hong Kong Science Park Shenzhen Branch (HKSTPSZ) and met ASTRI members for an on-site technology exchange.

On 7 May 2026, the Research Centre for Unmanned Autonomous Systems (RCUAS) at The Hong Kong Polytechnic University (PolyU) hosted its 2nd Research Workshop on the PolyU campus. The workshop brought together leading scholars, industry experts and students to explore the future of intelligent autonomous technologies.

On 6 May 2026, Prof. WEN attended the 1st Research Workshop of Safety of AI-Driven Autonomous Systems: From Intelligent Connected Vehicles to the Low-Altitude Economy, held at CPD-2.58, Mok Sau King Lecture Hall, HKU. At the workshop, Prof. WEN introduced the recent research progress of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) on GNSS/SLAM localization, multi-sensor fusion and urban autonomous navigation.

On 21 April 2026, Dr. Runqiu Yang and Mr. Junzhe Wang of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) showcased a robotic dog at the Inauguration of the 10th Executive Committee of the PolyU CEO Club.
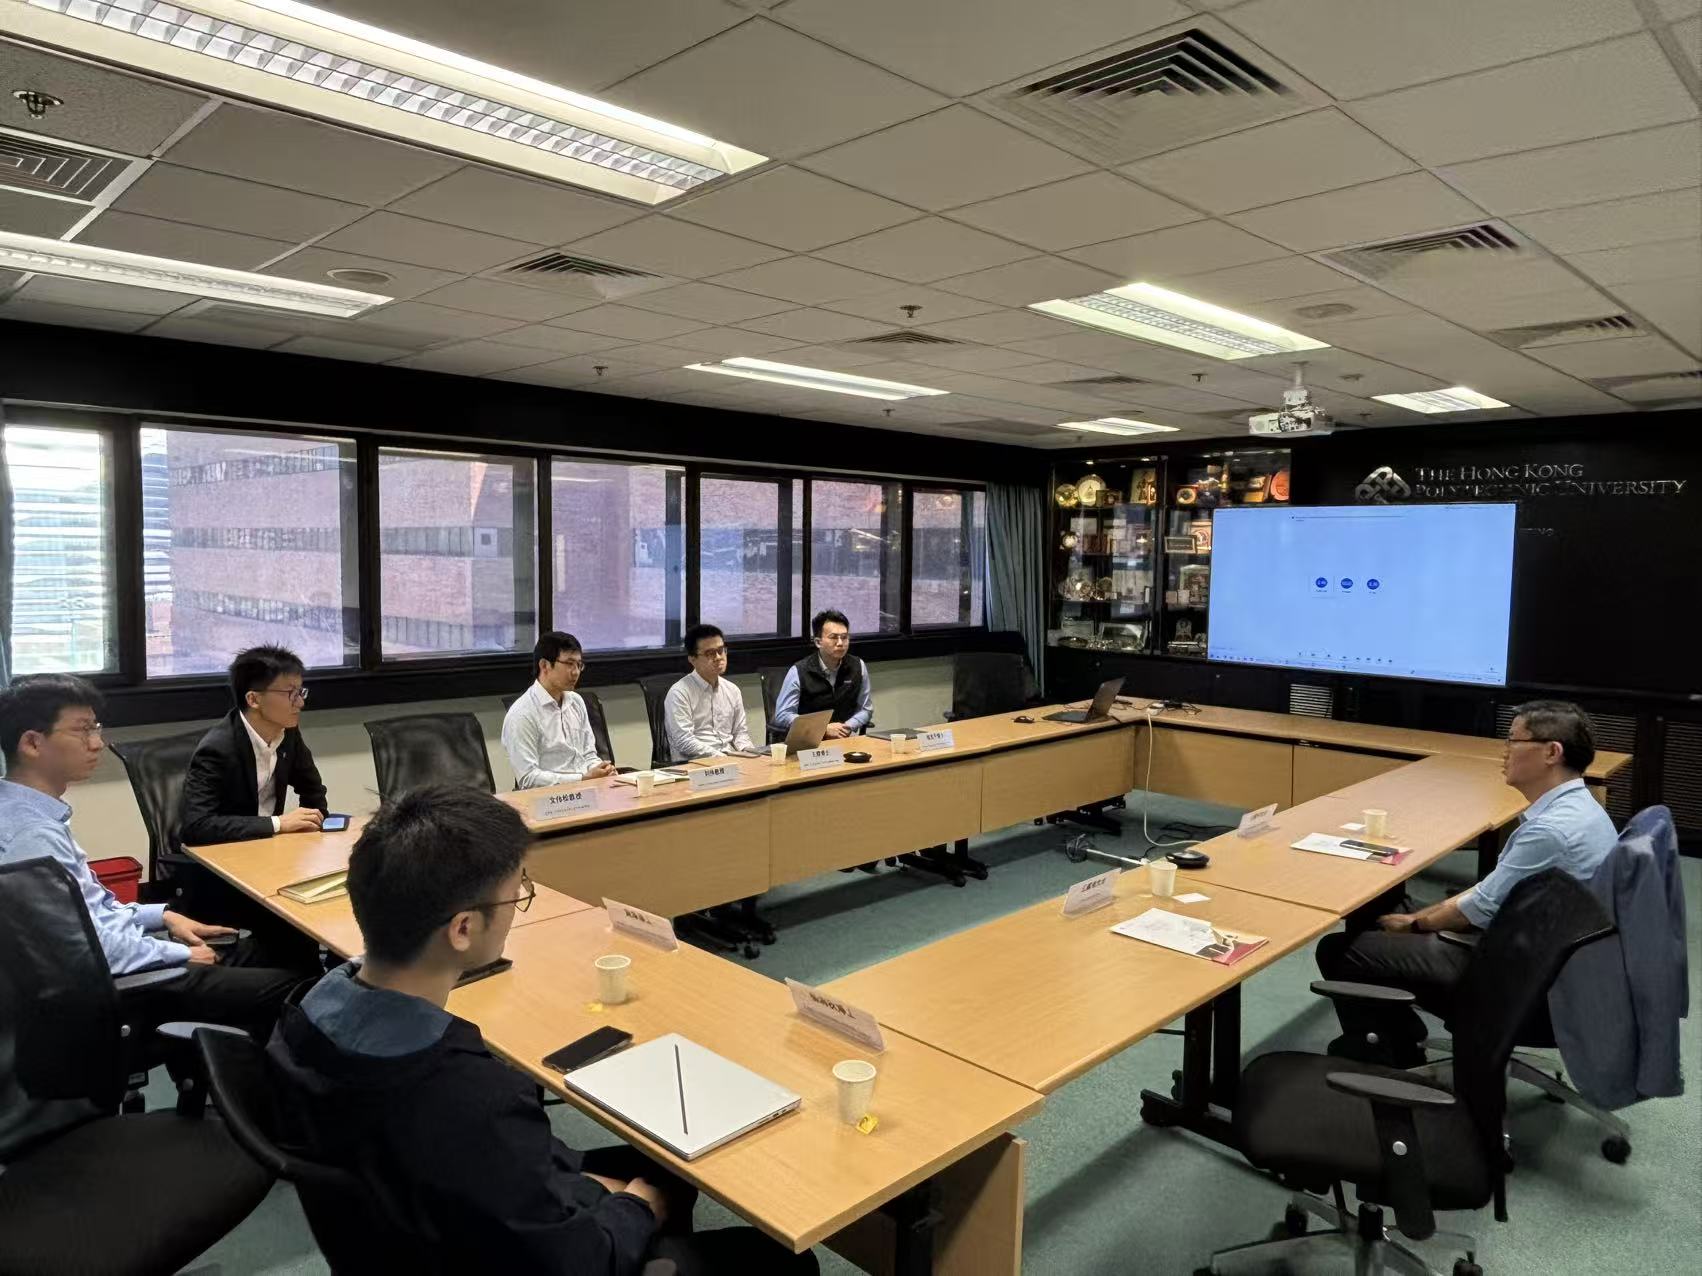
On 12 March, the China Intelligent & Connected Vehicles (Beijing) Research Institute (CICV) visited The Hong Kong Polytechnic University (PolyU). The meeting with PolyU representatives explored collaboration opportunities in vehicle security, wireless charging, V2X, the low-altitude economy and embedded AI. The visit underscores PolyU’s commitment to industry–academia partnerships and to practical solutions for next-generation transportation systems that address real-world challenges.
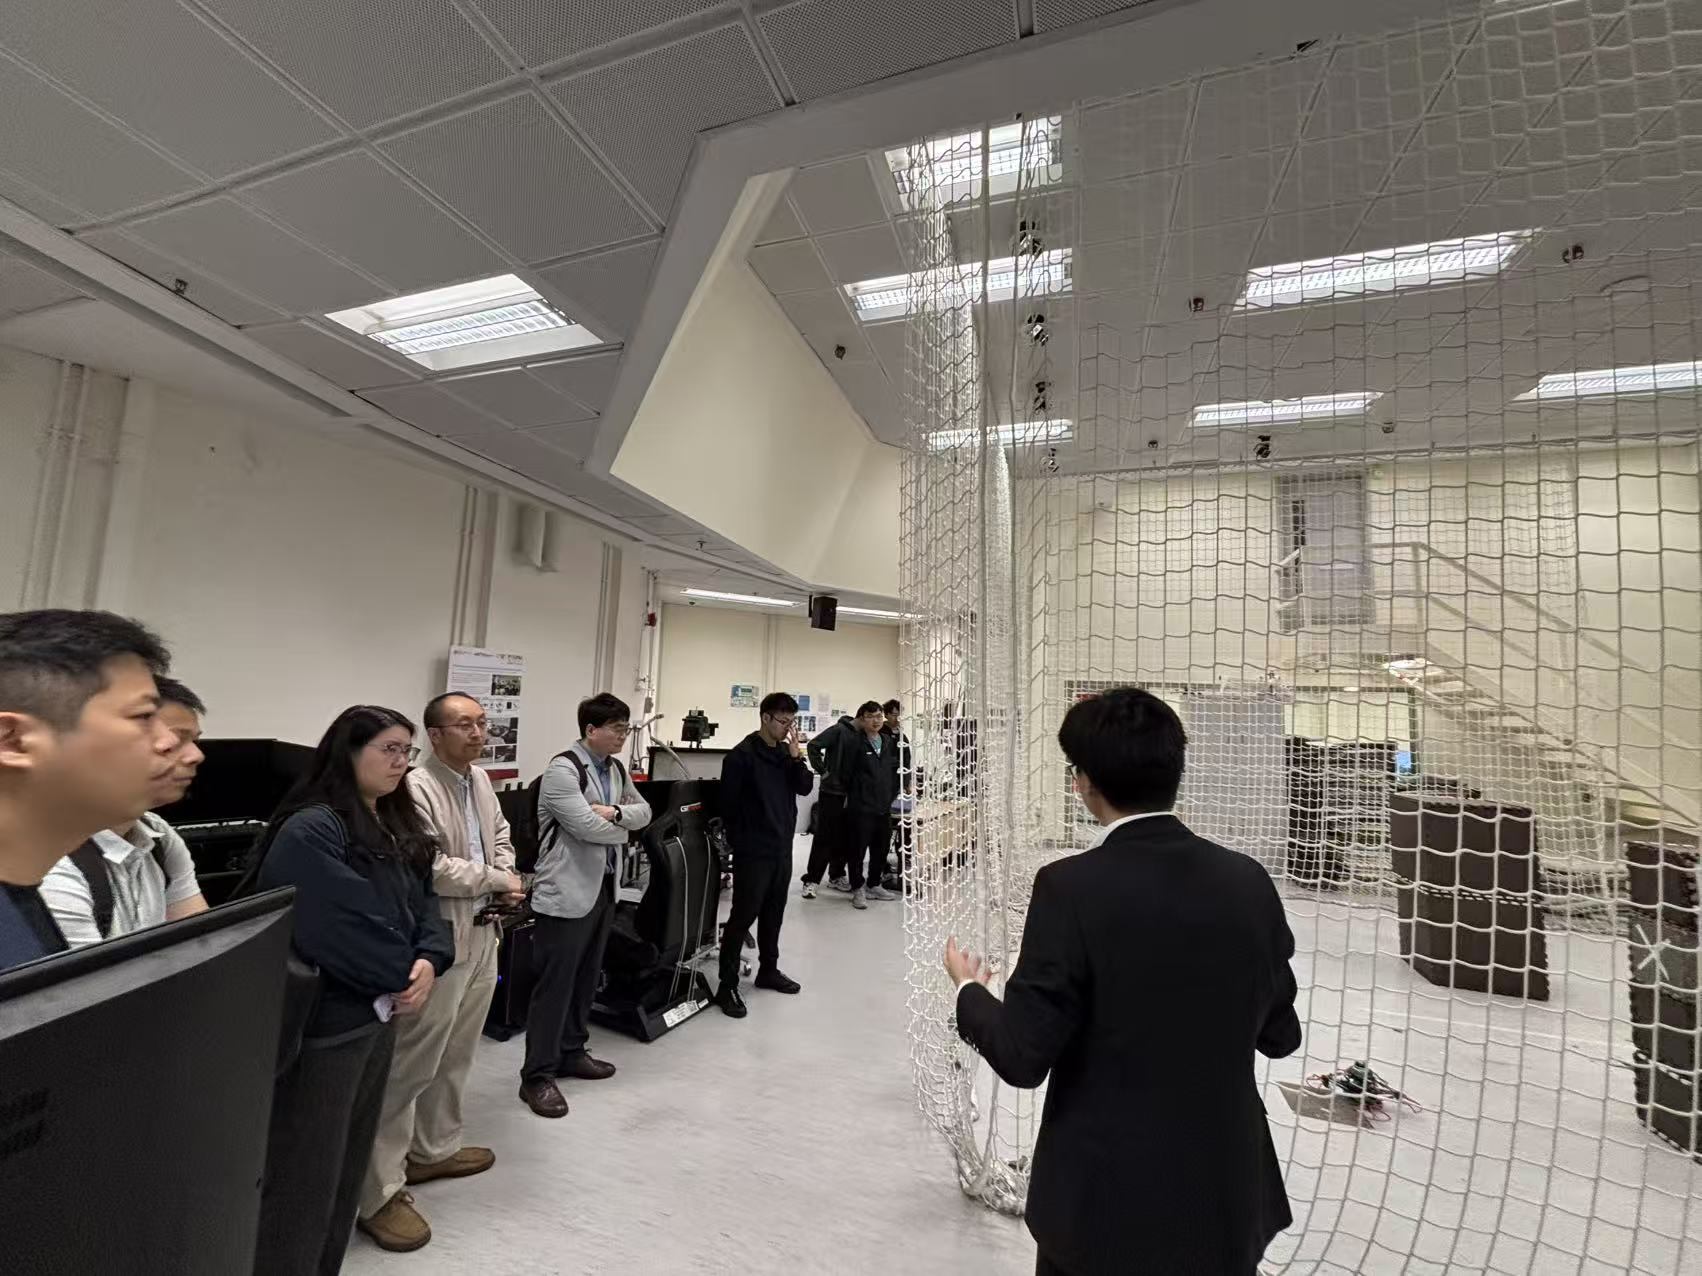
The Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) held a strategic cooperation meeting with Shenzhen Genvict Technologies Co., Ltd., a leading end-to-end provider of mobility intelligence solutions specialising in electronic toll collection (ETC), smart urban mobility and cooperative ITS (C-ITS). The meeting explored opportunities for collaboration in smart mobility and the low-altitude economy. The engagement reflects PolyU’s commitment to industry–academia partnerships and to practical solutions for next-generation transportation systems that address real-world challenges in urban and highway mobility.

On 5 March 2026, The Hong Kong Polytechnic University (PolyU) published a feature story titled “两会热点!理大深空造梦者实践科学家精神”, highlighting PolyU researchers whose work supports national priorities in high-level scientific and technological self-reliance, frontier innovation and the spirit of scientists. Among the featured researchers, Prof. Weisong Wen and his team were introduced for their vision and research direction in deep-space robotics.
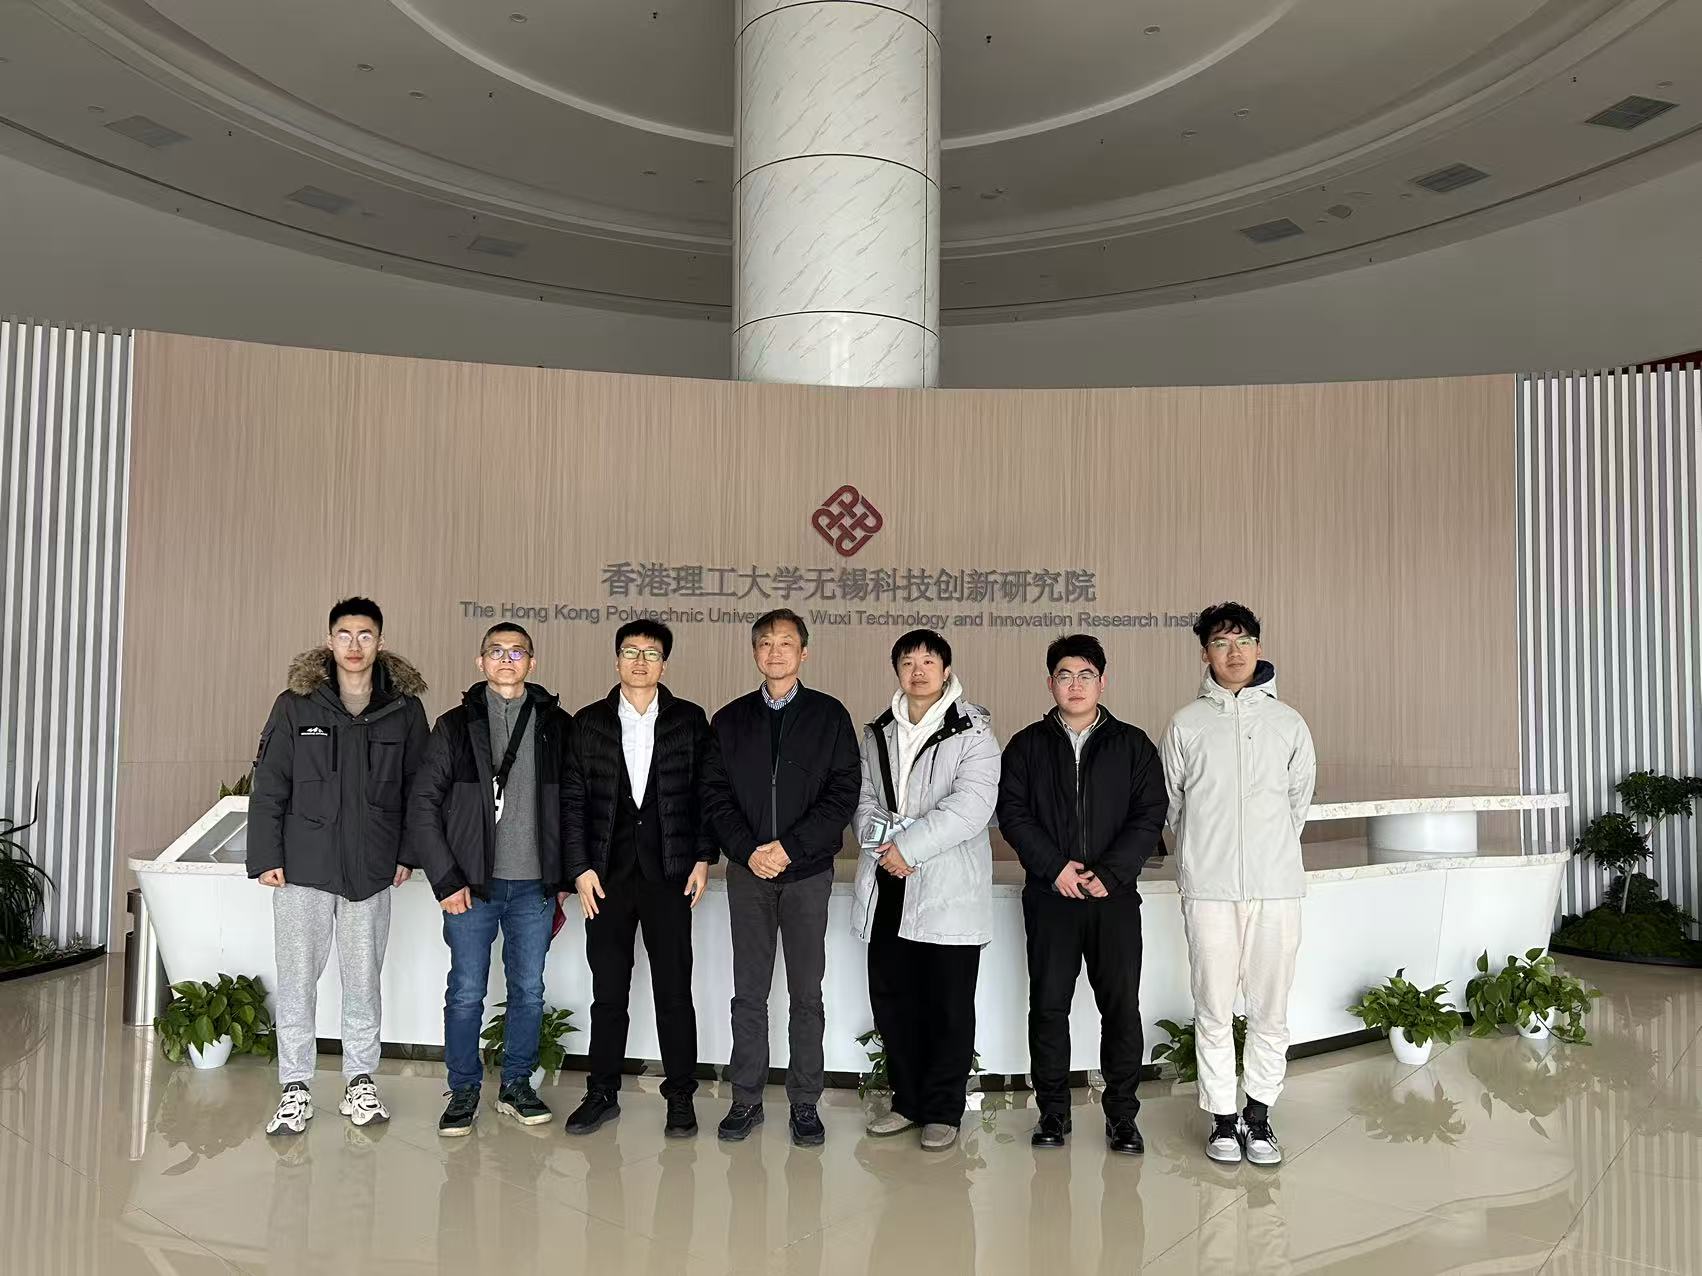
On 4 February 2026, a delegation from the Campus Facilities and Sustainability Office (CFSO) of The Hong Kong Polytechnic University (PolyU), including Mr. Wong and Mr. Cheung, accompanied by Dr. Wang from the PolyU Wenzhou Research Institute, visited the PolyU Wuxi Technology and Innovation Research Institute and the Shanghai Sanlin Low-altitude Economy Industrial Park for technical exchange and guidance.
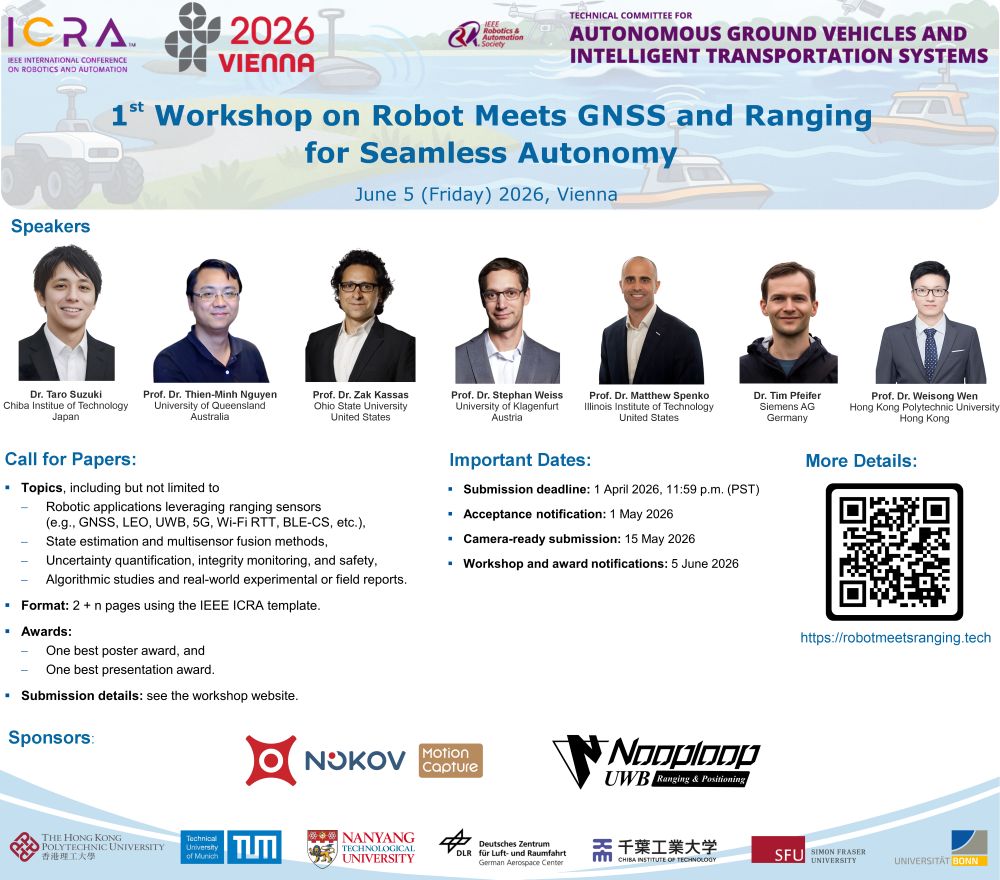
The Trustworthy AI and Autonomous Systems Laboratory (TASLAB) is organizing the 1st Workshop on Robot Meets GNSS and Ranging for Seamless Autonomy at IEEE ICRA 2026, taking place on Friday, 5 June 2026, in Vienna. If you work on reliable autonomy in the real world, especially where GNSS/UWB/ranging gets messy, this workshop is for you. More details are available on the workshop page.
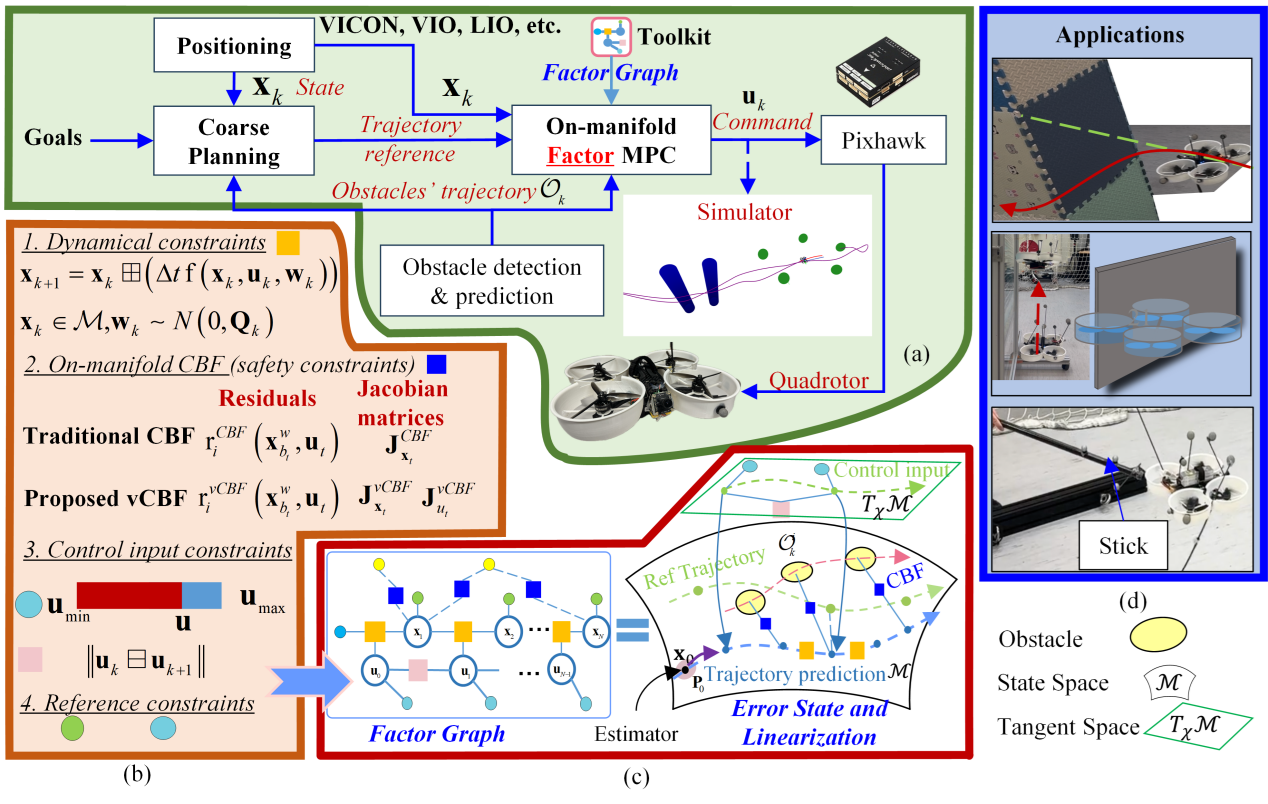
Our paper “Integrated Planning and Control on Manifolds: Factor Graph Representation and Toolkit” by Peiwen Yang, Weisong Wen, Runqiu Yang, Yuanyuan Zhang, Jiahao Hu, Yingming Chen, Naigui Xiao and Jiaqi Zhao has been accepted by the 2026 IEEE International Conference on Robotics & Automation (ICRA 2026). Congratulations to Peiwen and the co-authors!
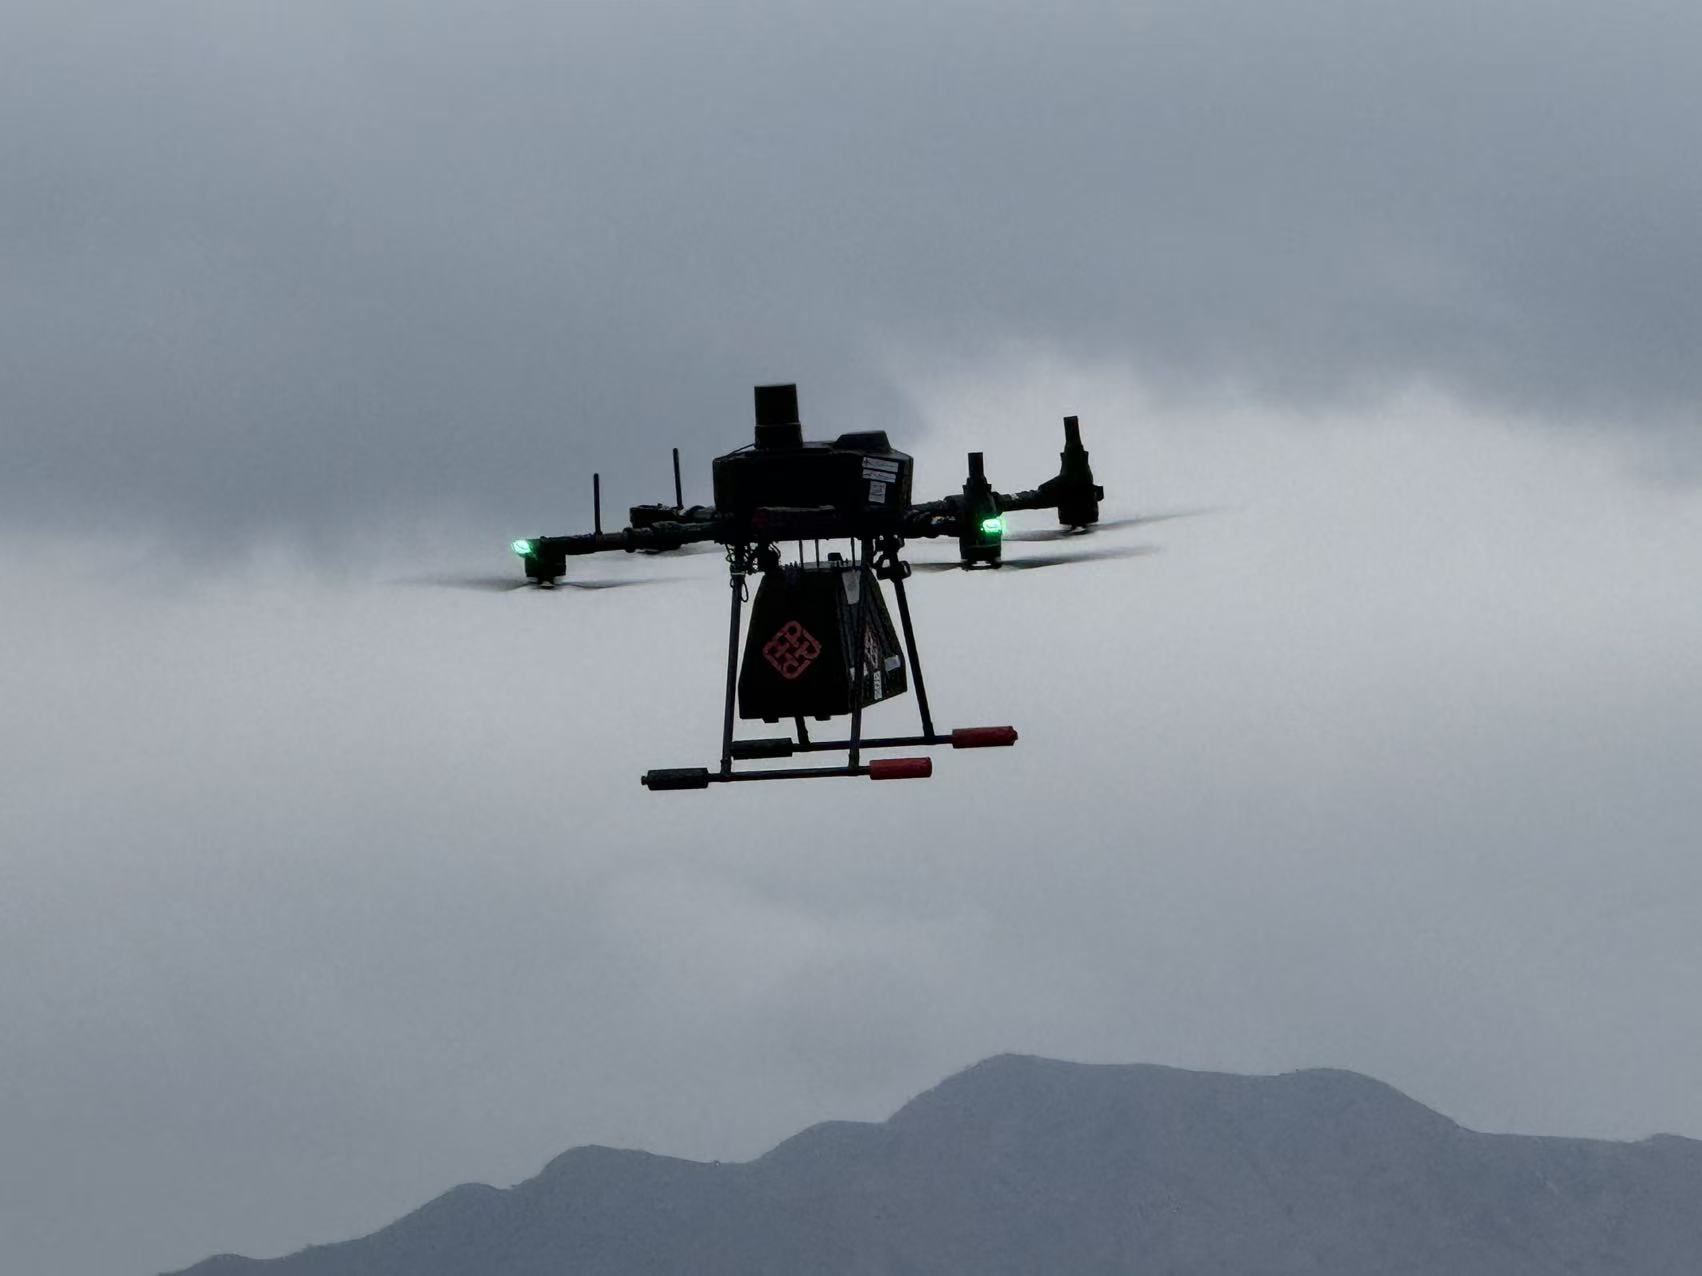
On 30 January 2026, the team reached a significant milestone by completing its first cross-sea logistics test flight for Phase 1 of the Hong Kong Low-altitude Economy Regulatory Sandbox.
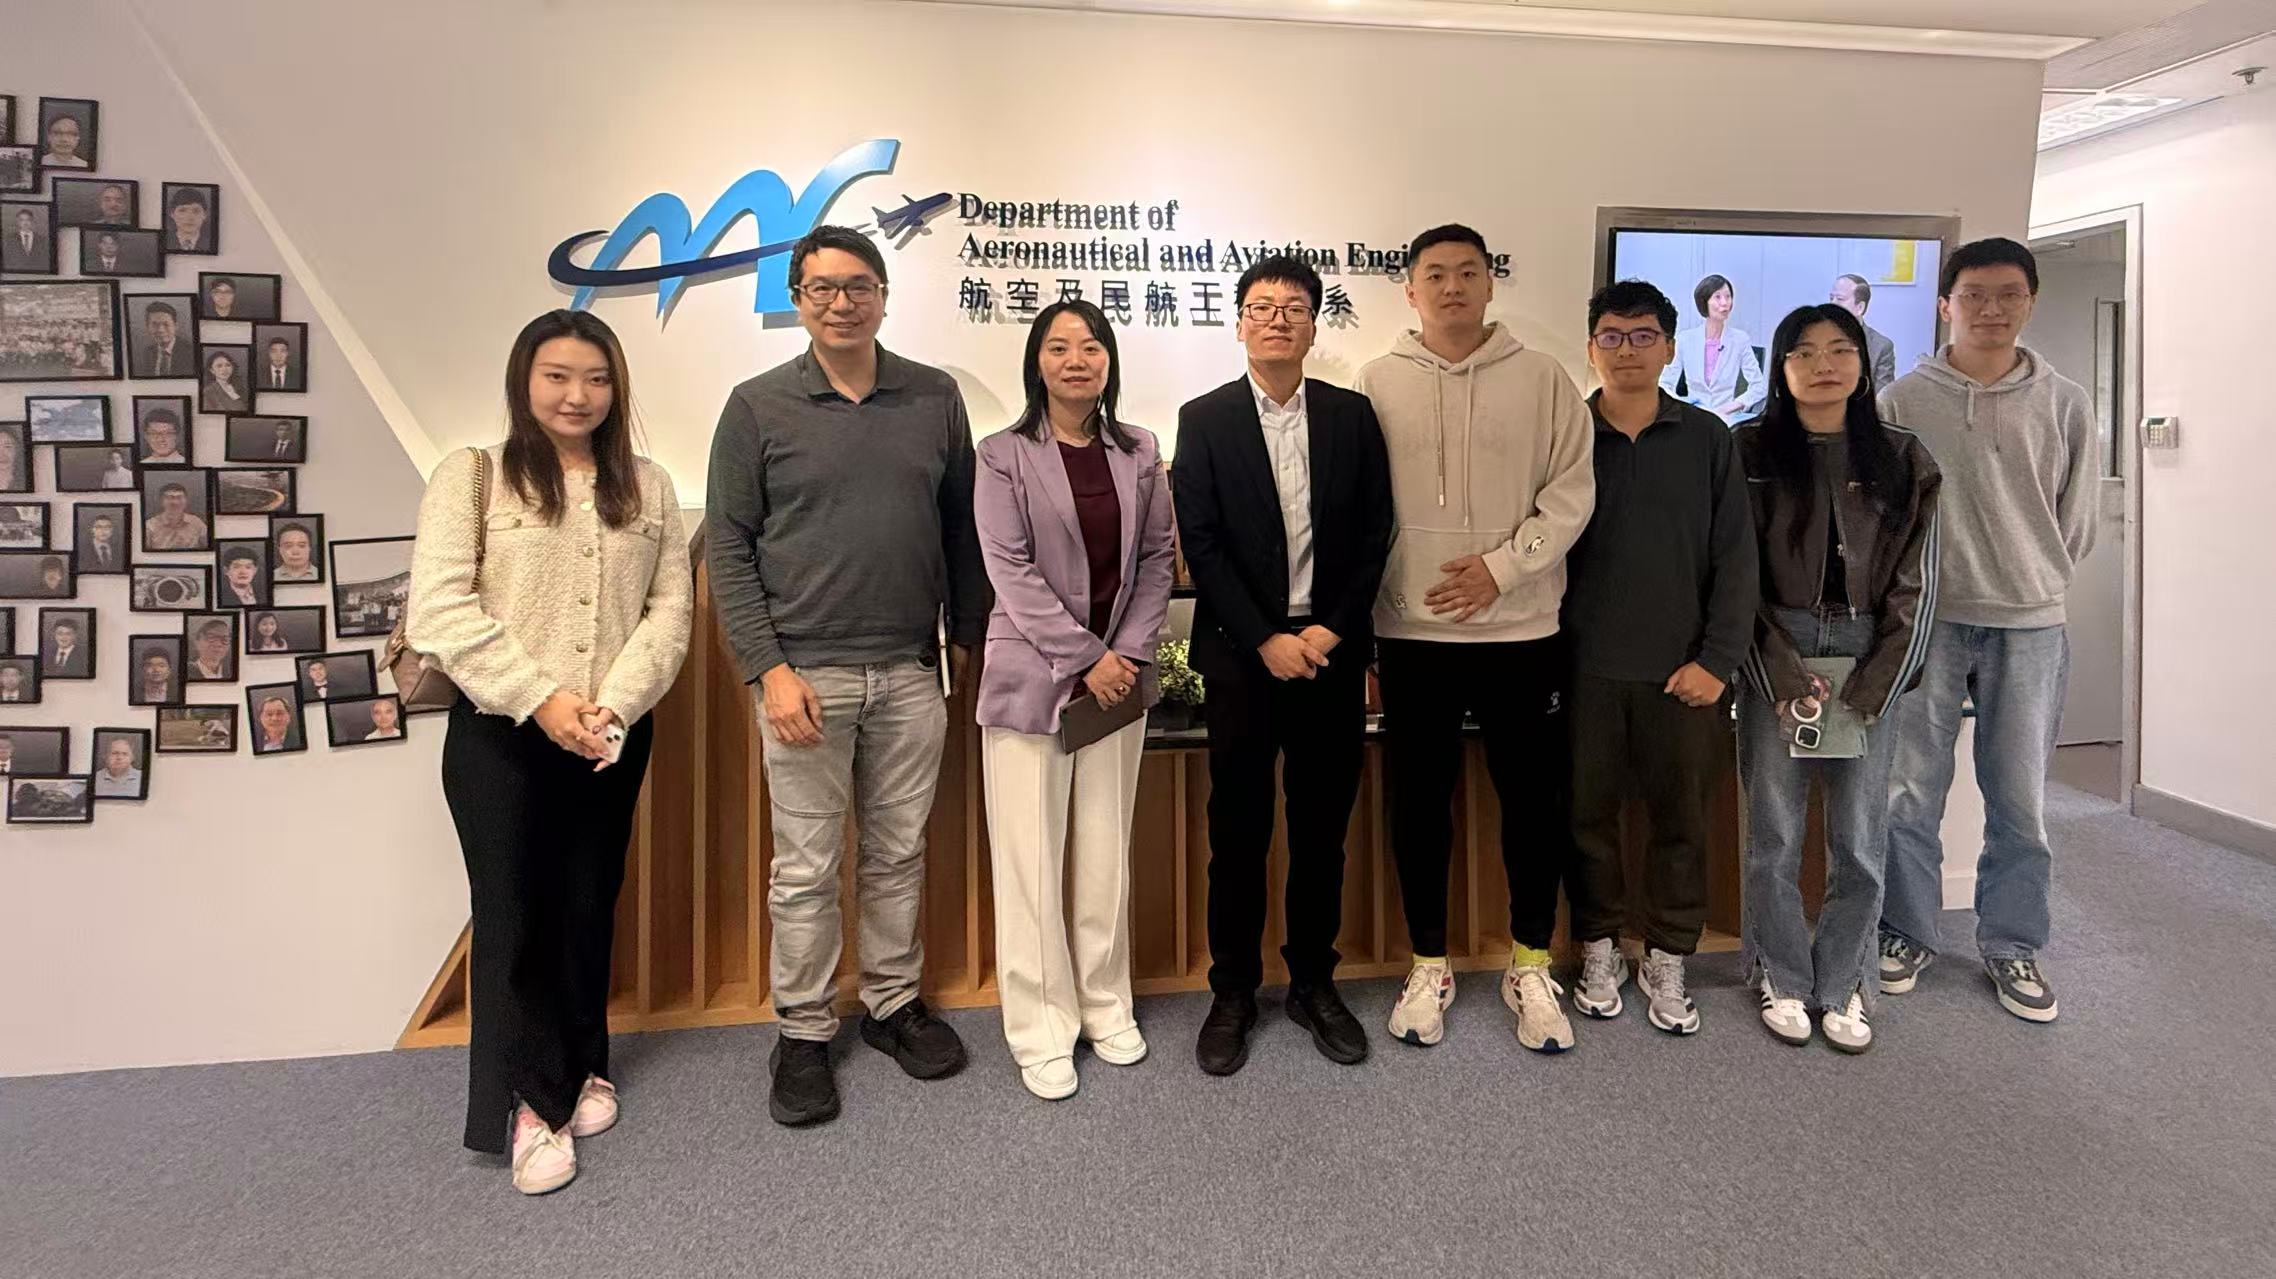
On 29 January 2026, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) held a strategic cooperation meeting in Hong Kong with SF Express (Hong Kong) and Rino AI. The meeting explored collaboration on smart logistics and autonomous campus delivery vehicles, and reflects PolyU’s commitment to industry-academia partnerships and to practical solutions for next-generation logistics in urban delivery and campus mobility.
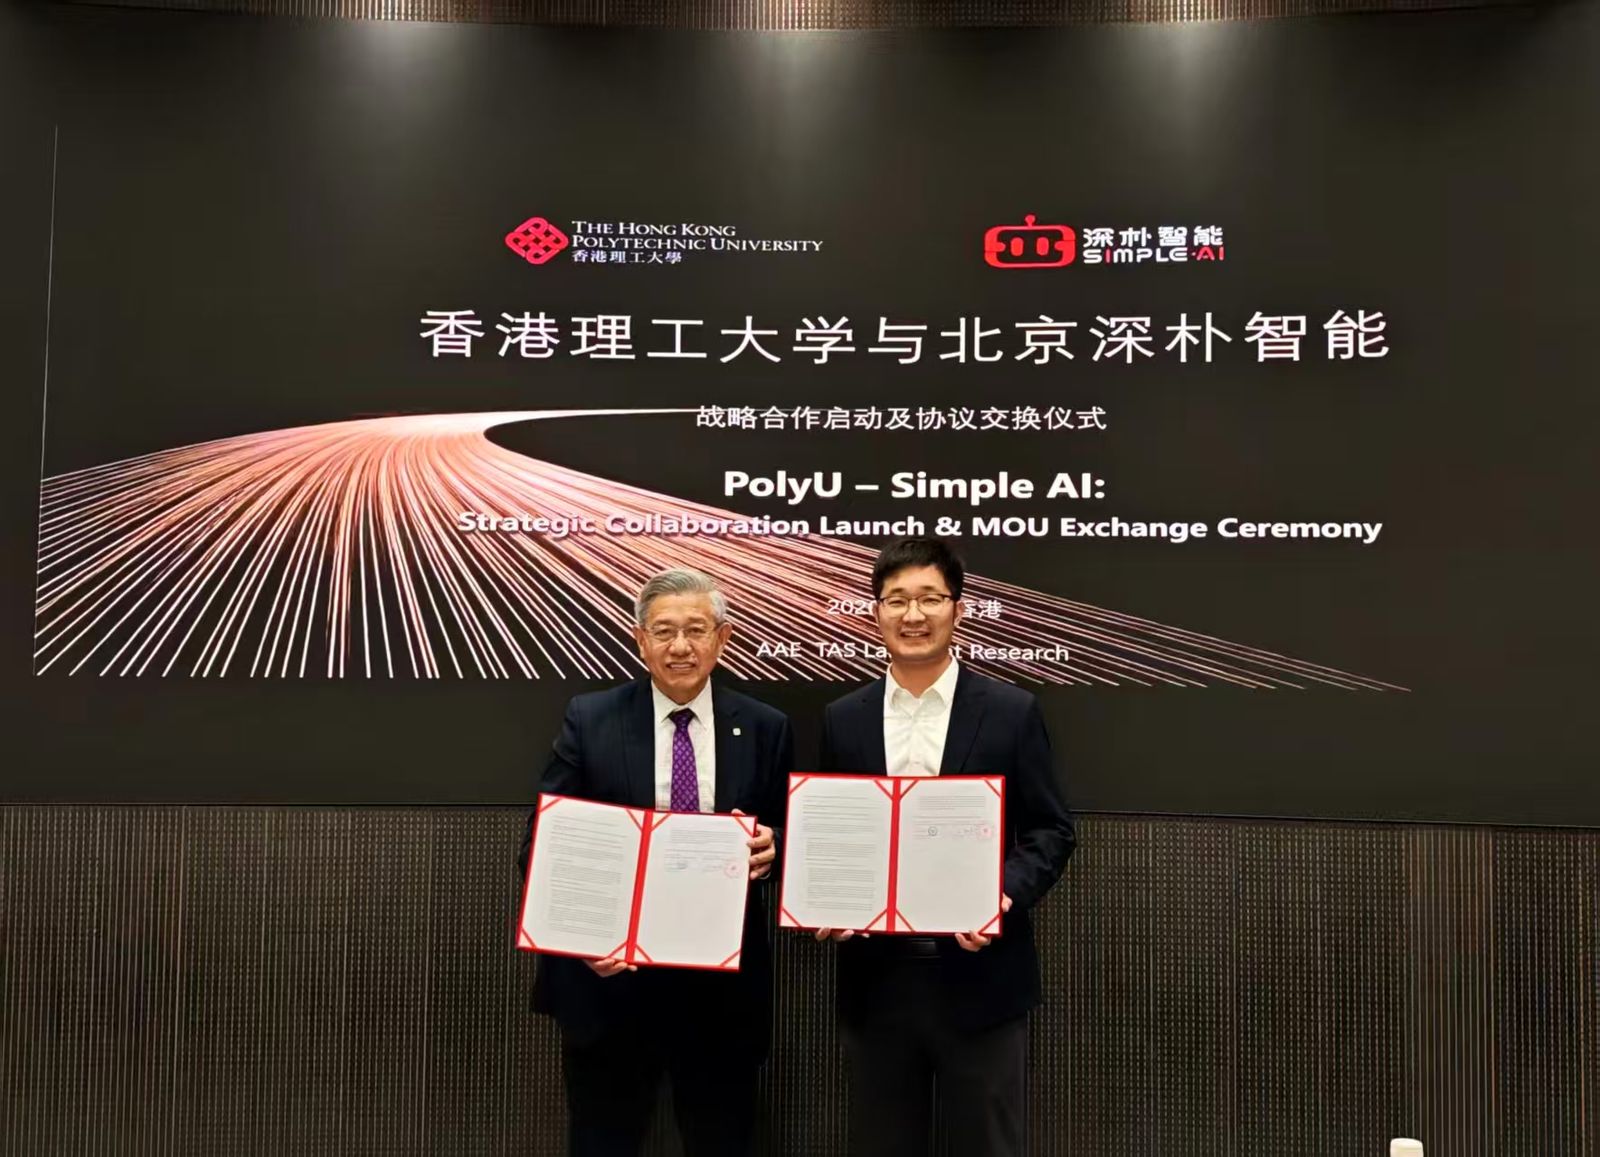
On 19 January 2026, The Hong Kong Polytechnic University (PolyU) and Beijing Simple AI Technology Co., Ltd. (Simple AI) officially launched their strategic partnership with a Memorandum of Understanding (MOU) signing ceremony at PolyU’s Chiang Chen Studio Theatre (AG204), Hong Kong. Representatives from both institutions exchanged the agreement and discussed future collaboration in embodied intelligent robotics. The partnership reflects PolyU’s commitment to industry-academia collaboration and to AI-driven technologies for real-world applications.
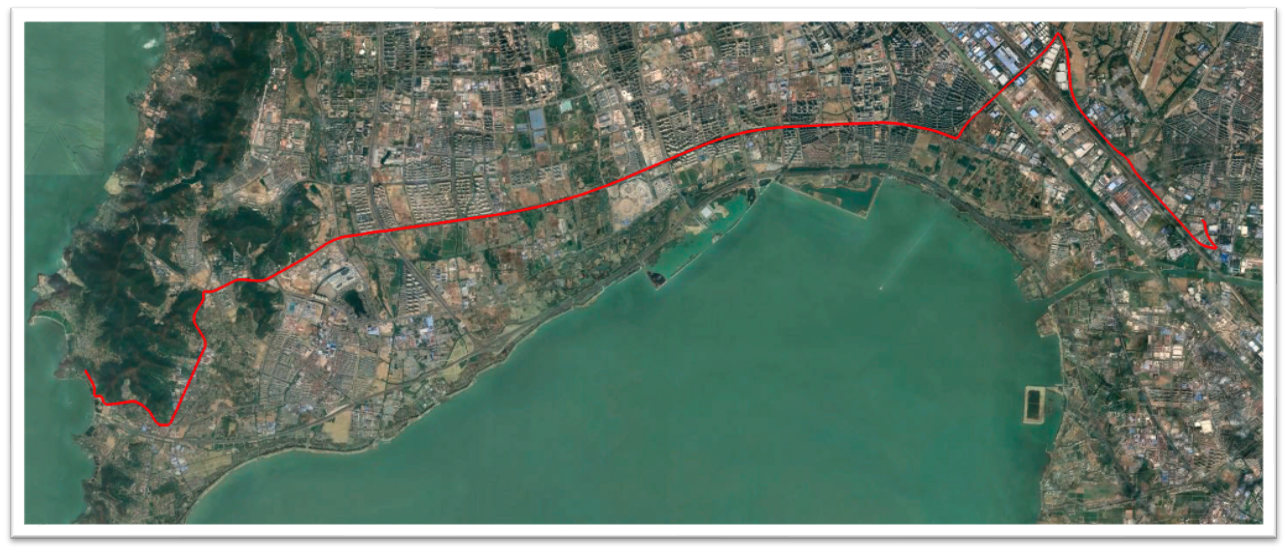
The Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) has released TasFusion, an open-source ROS1 framework for multi-sensor navigation and state estimation. The project is publicly available on GitHub: https://github.com/PolyU-TASLAB/TasFusion.
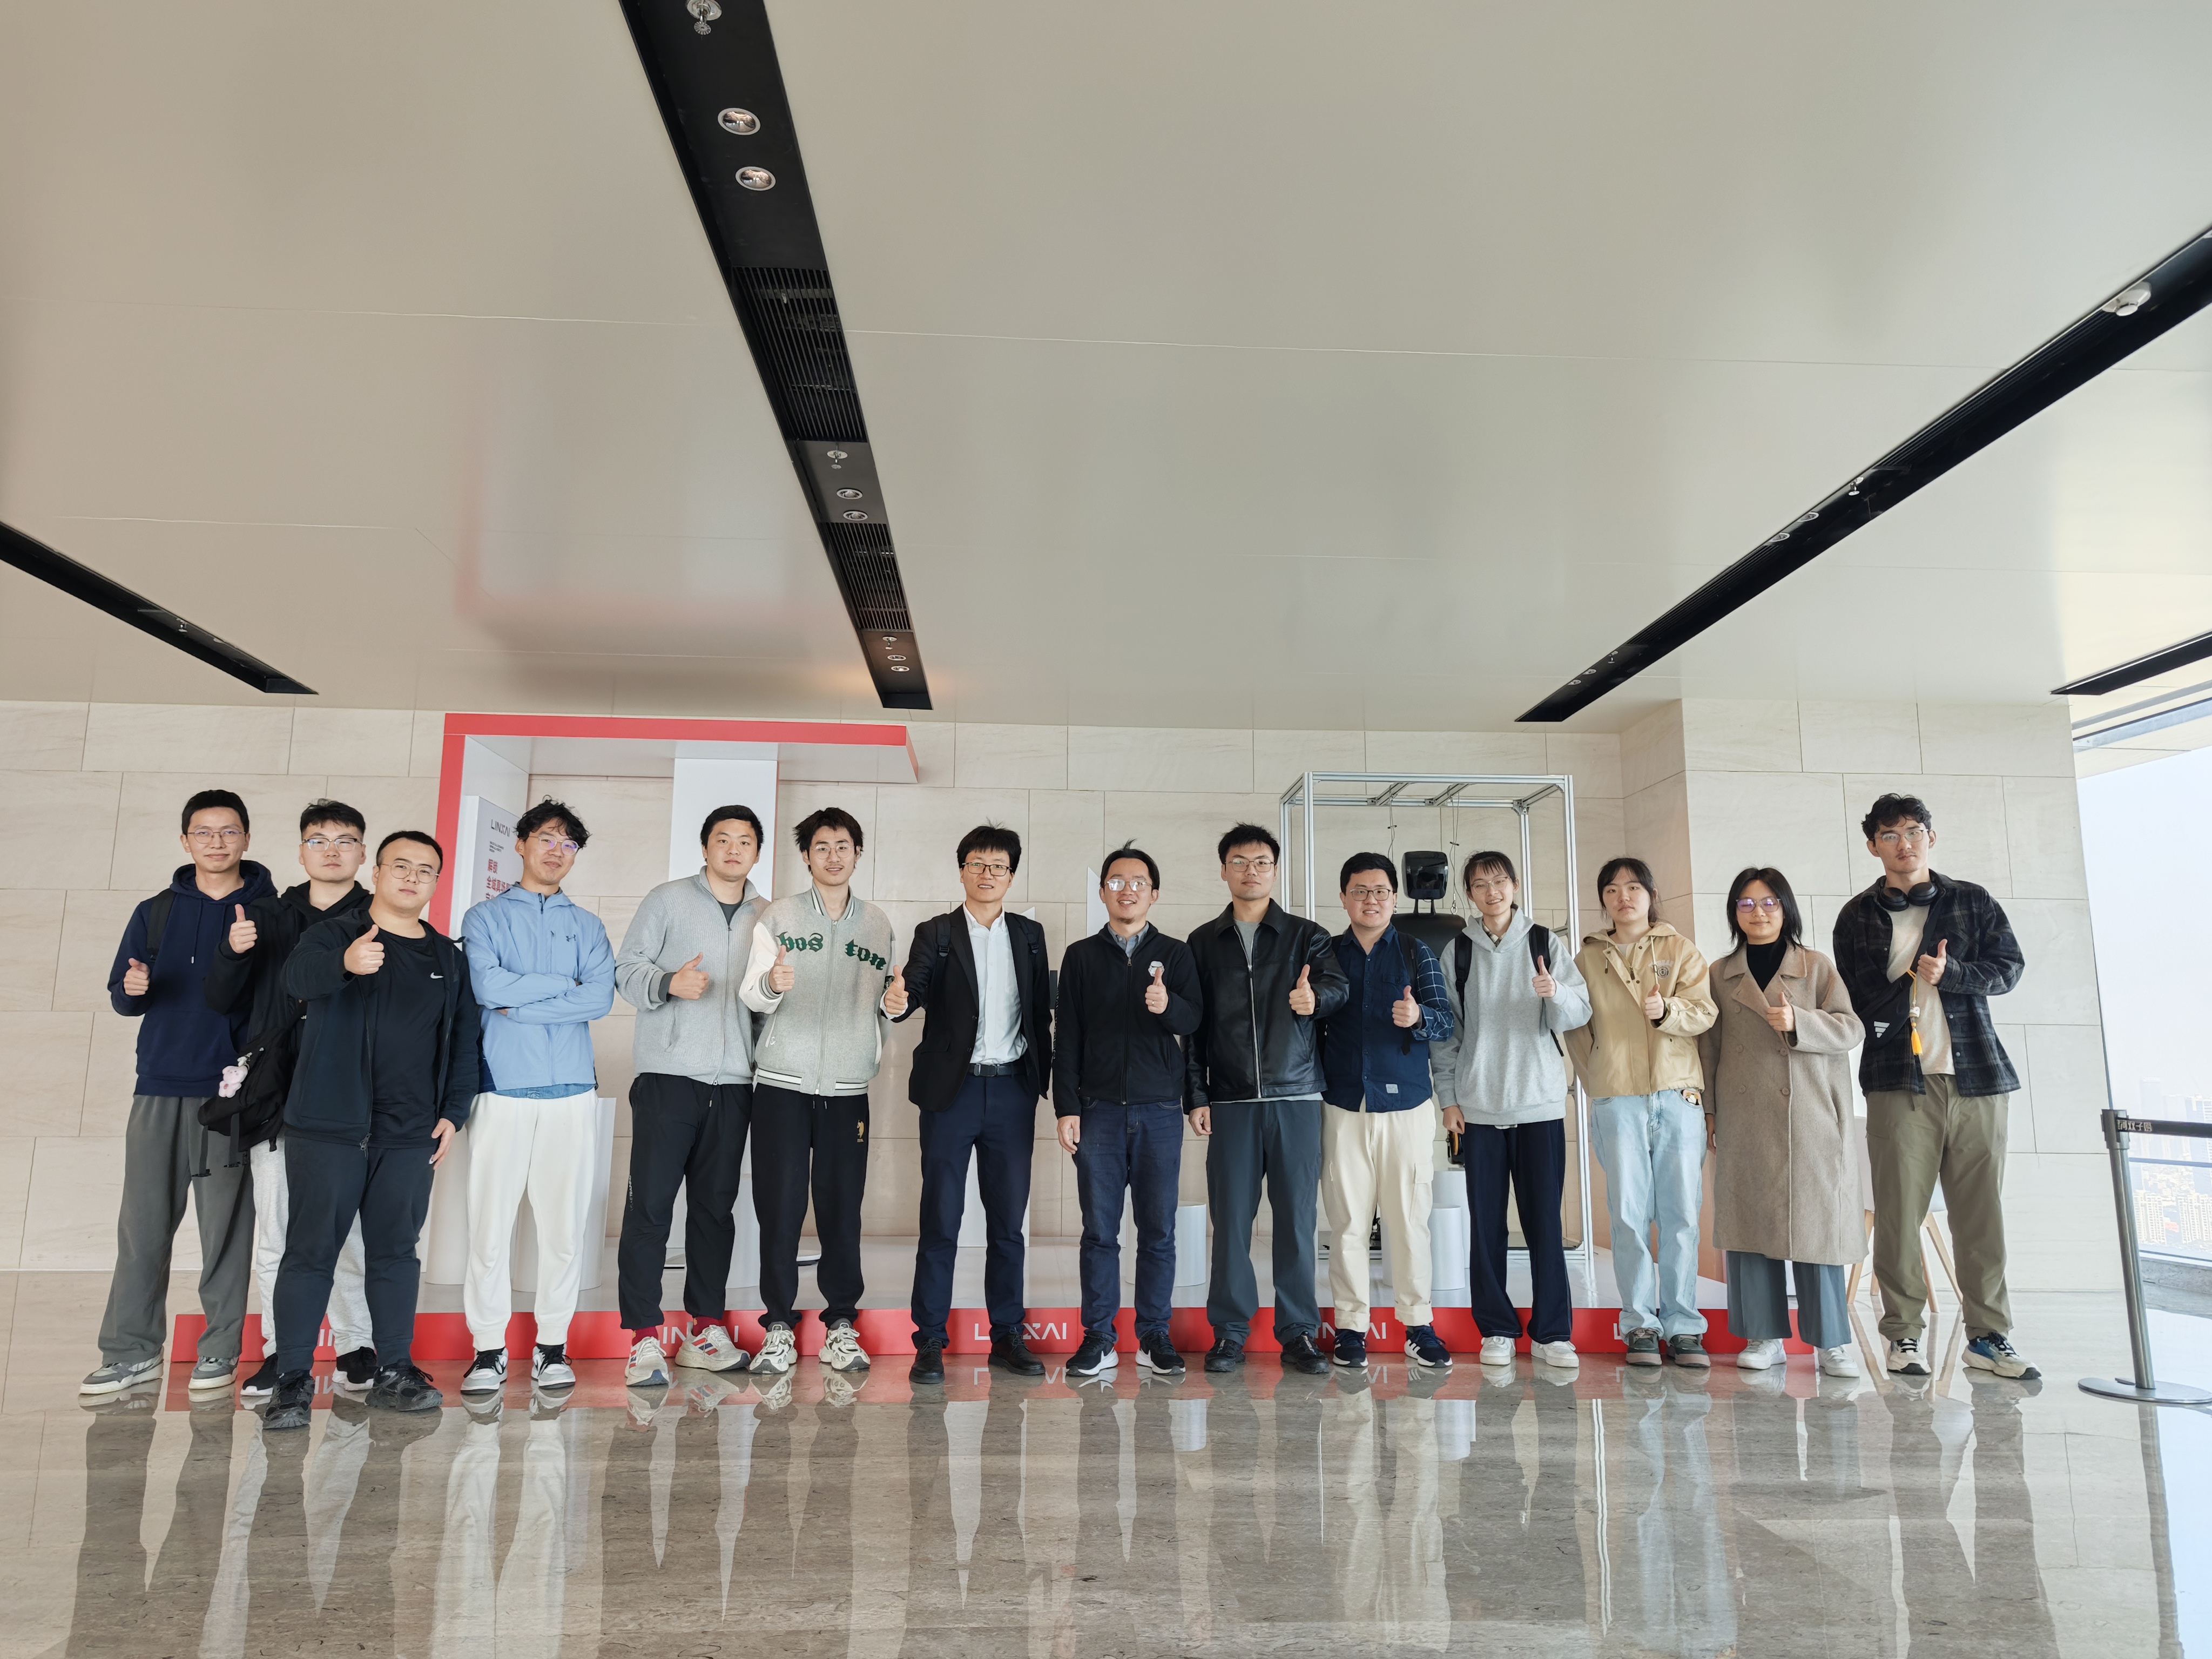
On 16 January 2026, members of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) visited LINXAI Company in Shenzhen, China, a leading innovator in robotics technology. The team discussed ongoing collaboration projects centred on the quadruped robot and toured the company’s laboratory facilities. The exchange reflects The Hong Kong Polytechnic University’s (PolyU) commitment to industry-academia partnerships and practical applications of robotics.
The Department of Aeronautical and Aviation Engineering (AAE) at The Hong Kong Polytechnic University (PolyU) has signed an MOU with Rino.ai, a leading L4 autonomous driving company, to co-develop and pilot autonomous vehicle applications on campus. Initial focus areas include last-mile delivery and security patrols, with solutions tailored to dynamic pedestrian and traffic flows.
2025 (70)
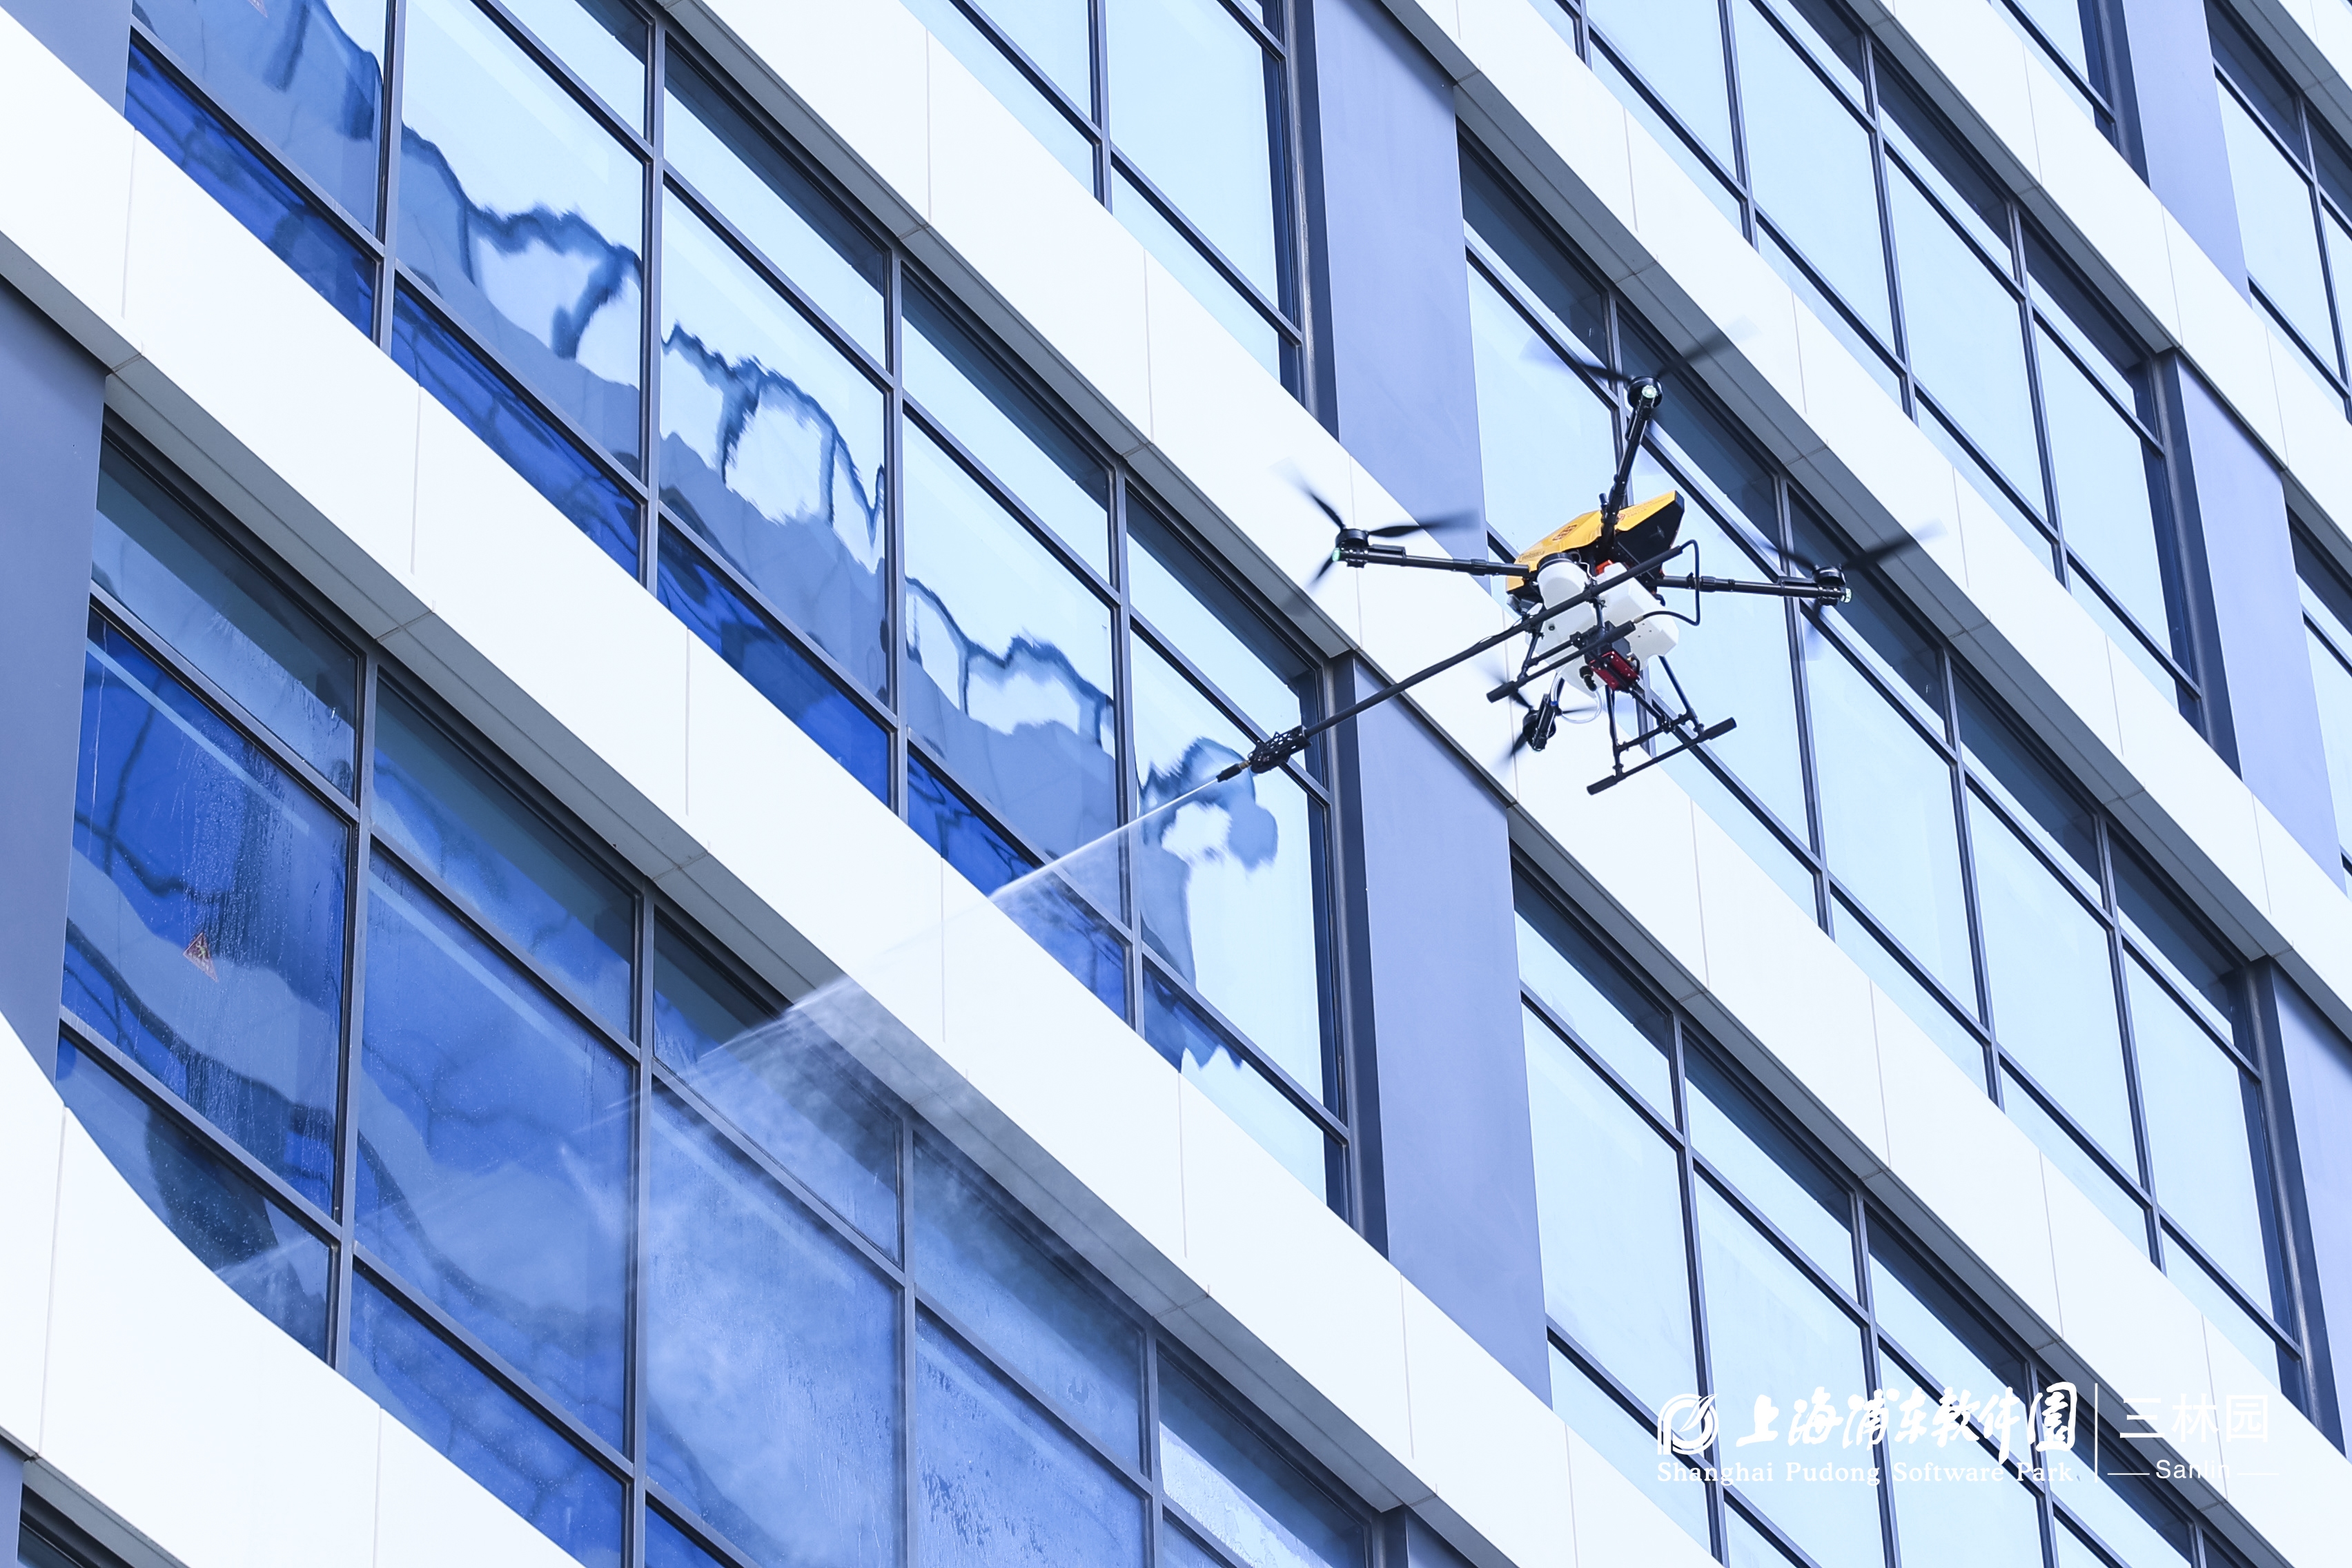
Today, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) team conducted a field demonstration of automated drone building cleaning at the Shanghai Pudong Software Park in China. The demonstration was a key part of the launch ceremony for the Shanghai Pudong Software Park Low-Altitude Economy Service Platform.
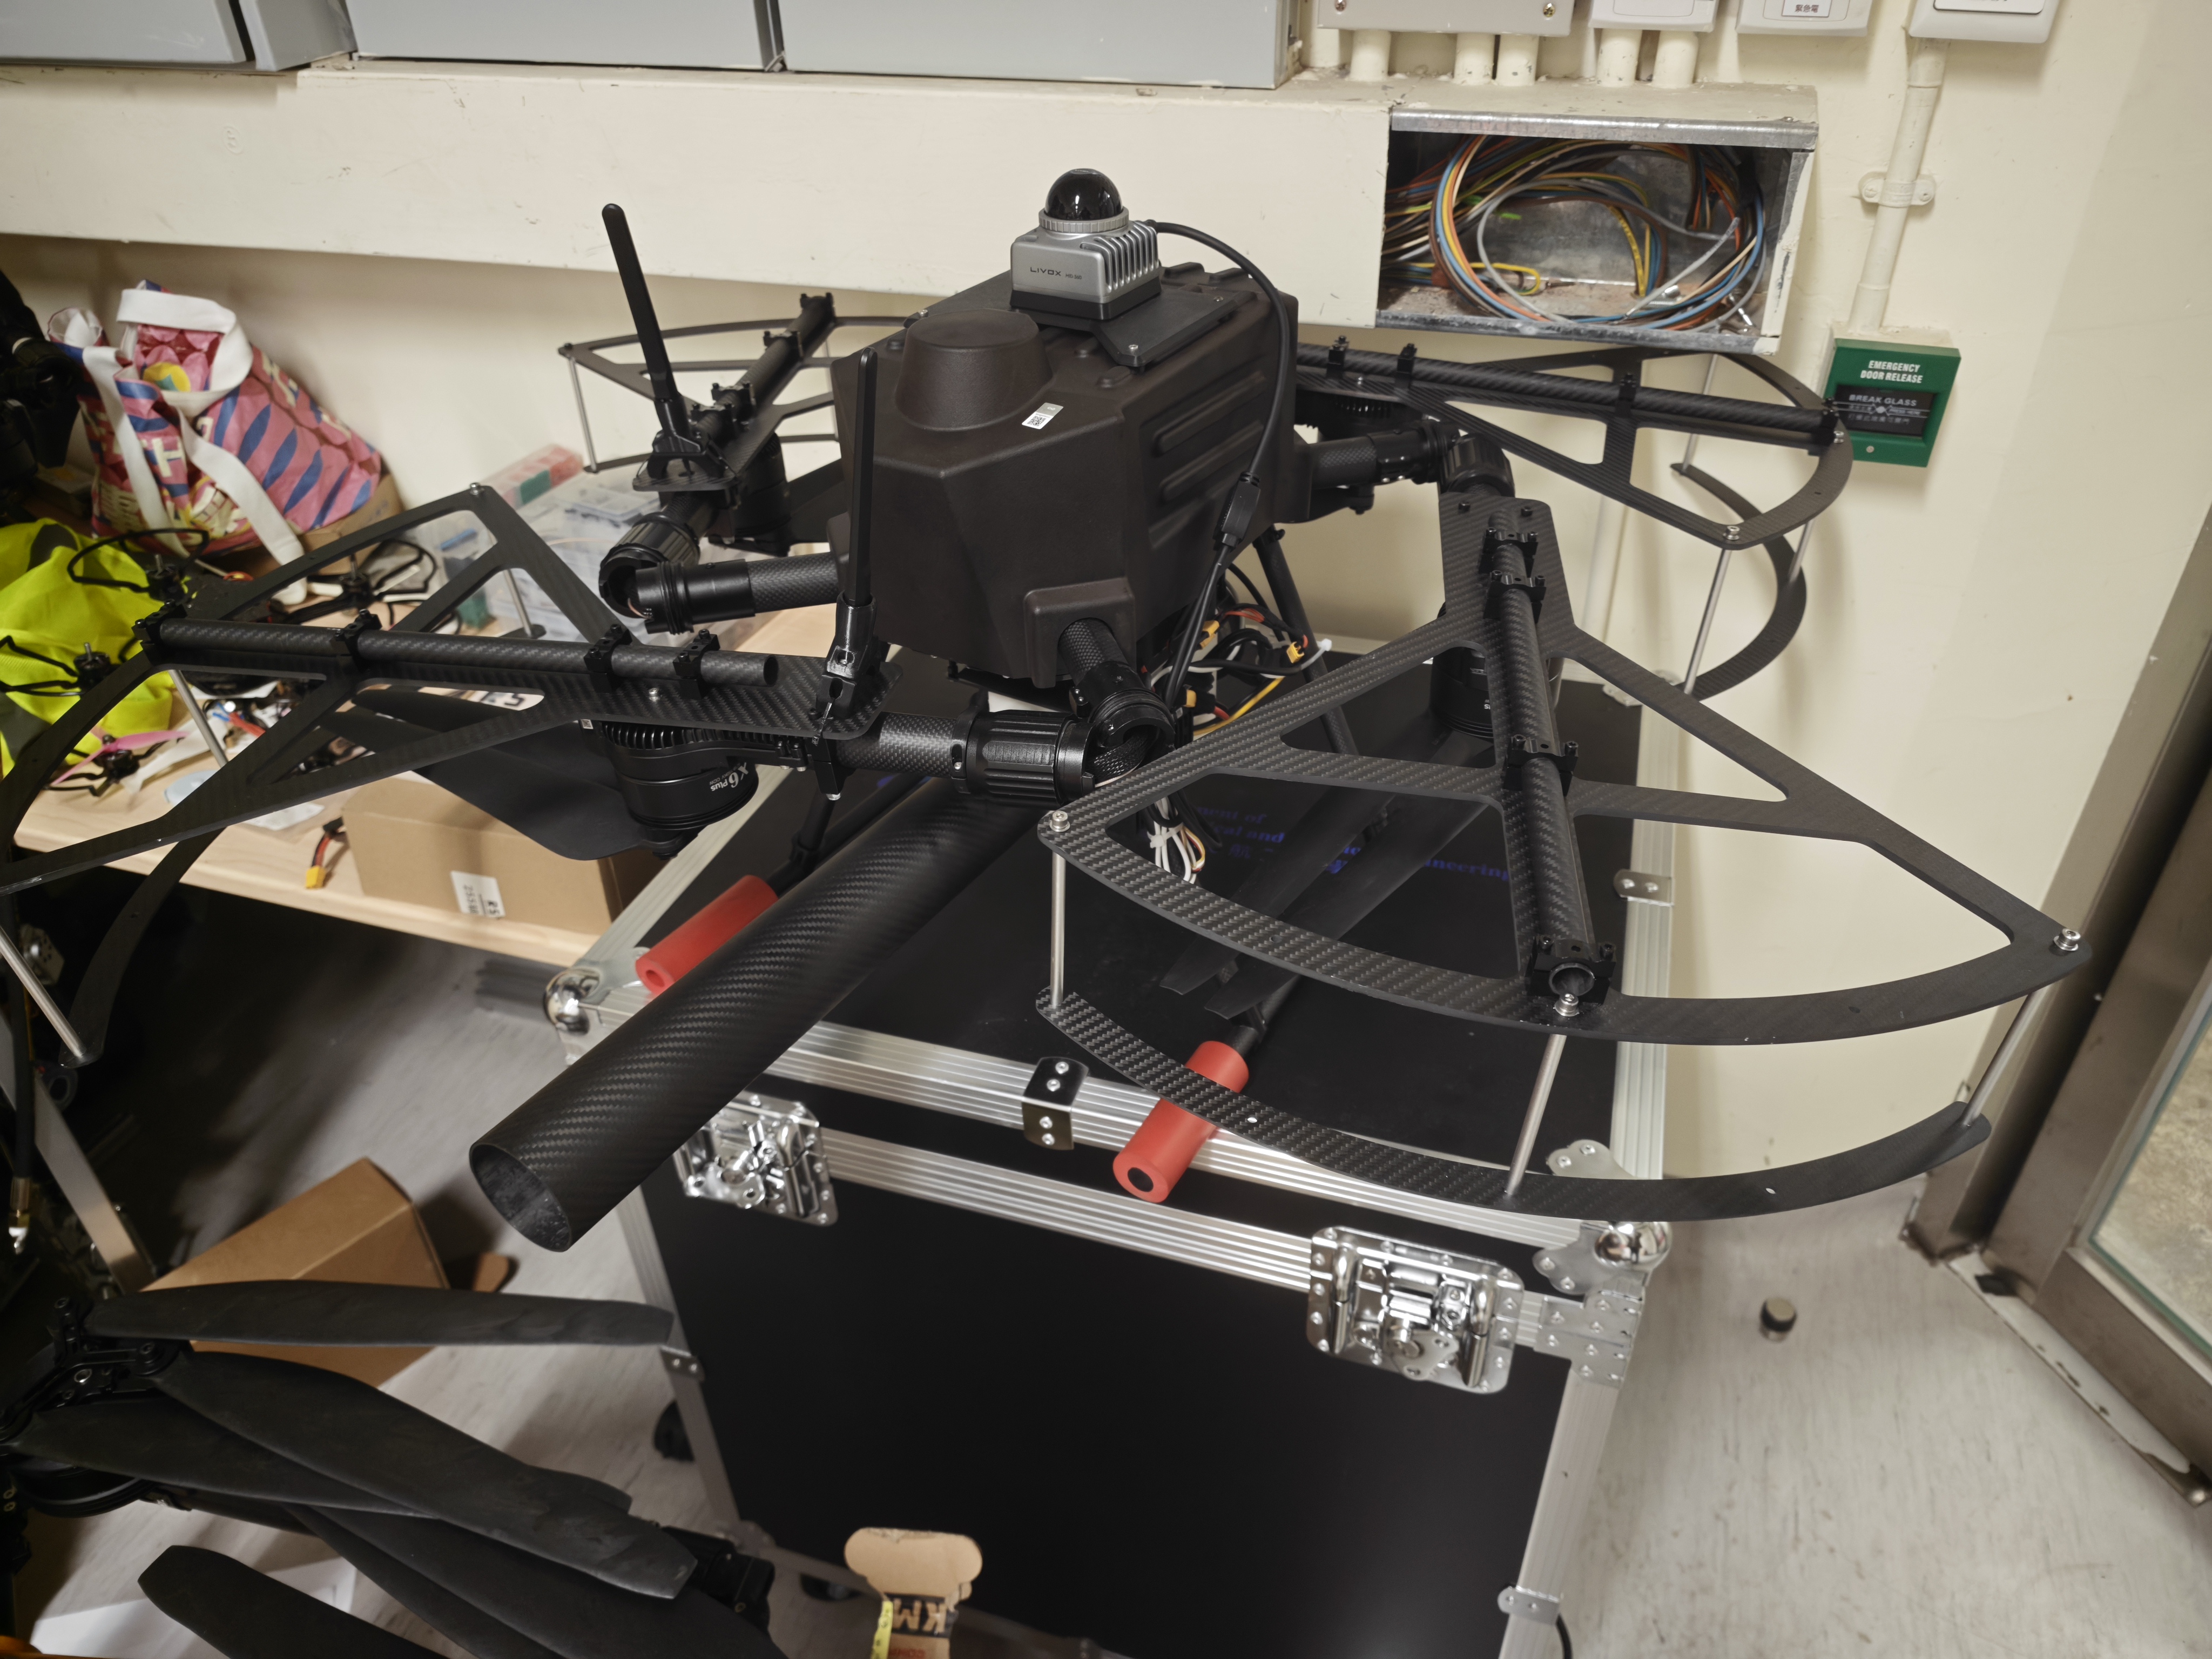
On 18 December 2025, the team conducted a demonstration of airblower UAV technology with the Civil Aviation Department (CAD) at The Hong Kong Polytechnic University (PolyU). The demonstration presented the capabilities of the airblower UAV system to CAD representatives, highlighting its potential applications in urban environments and its compliance with aviation safety standards in enclosed areas.
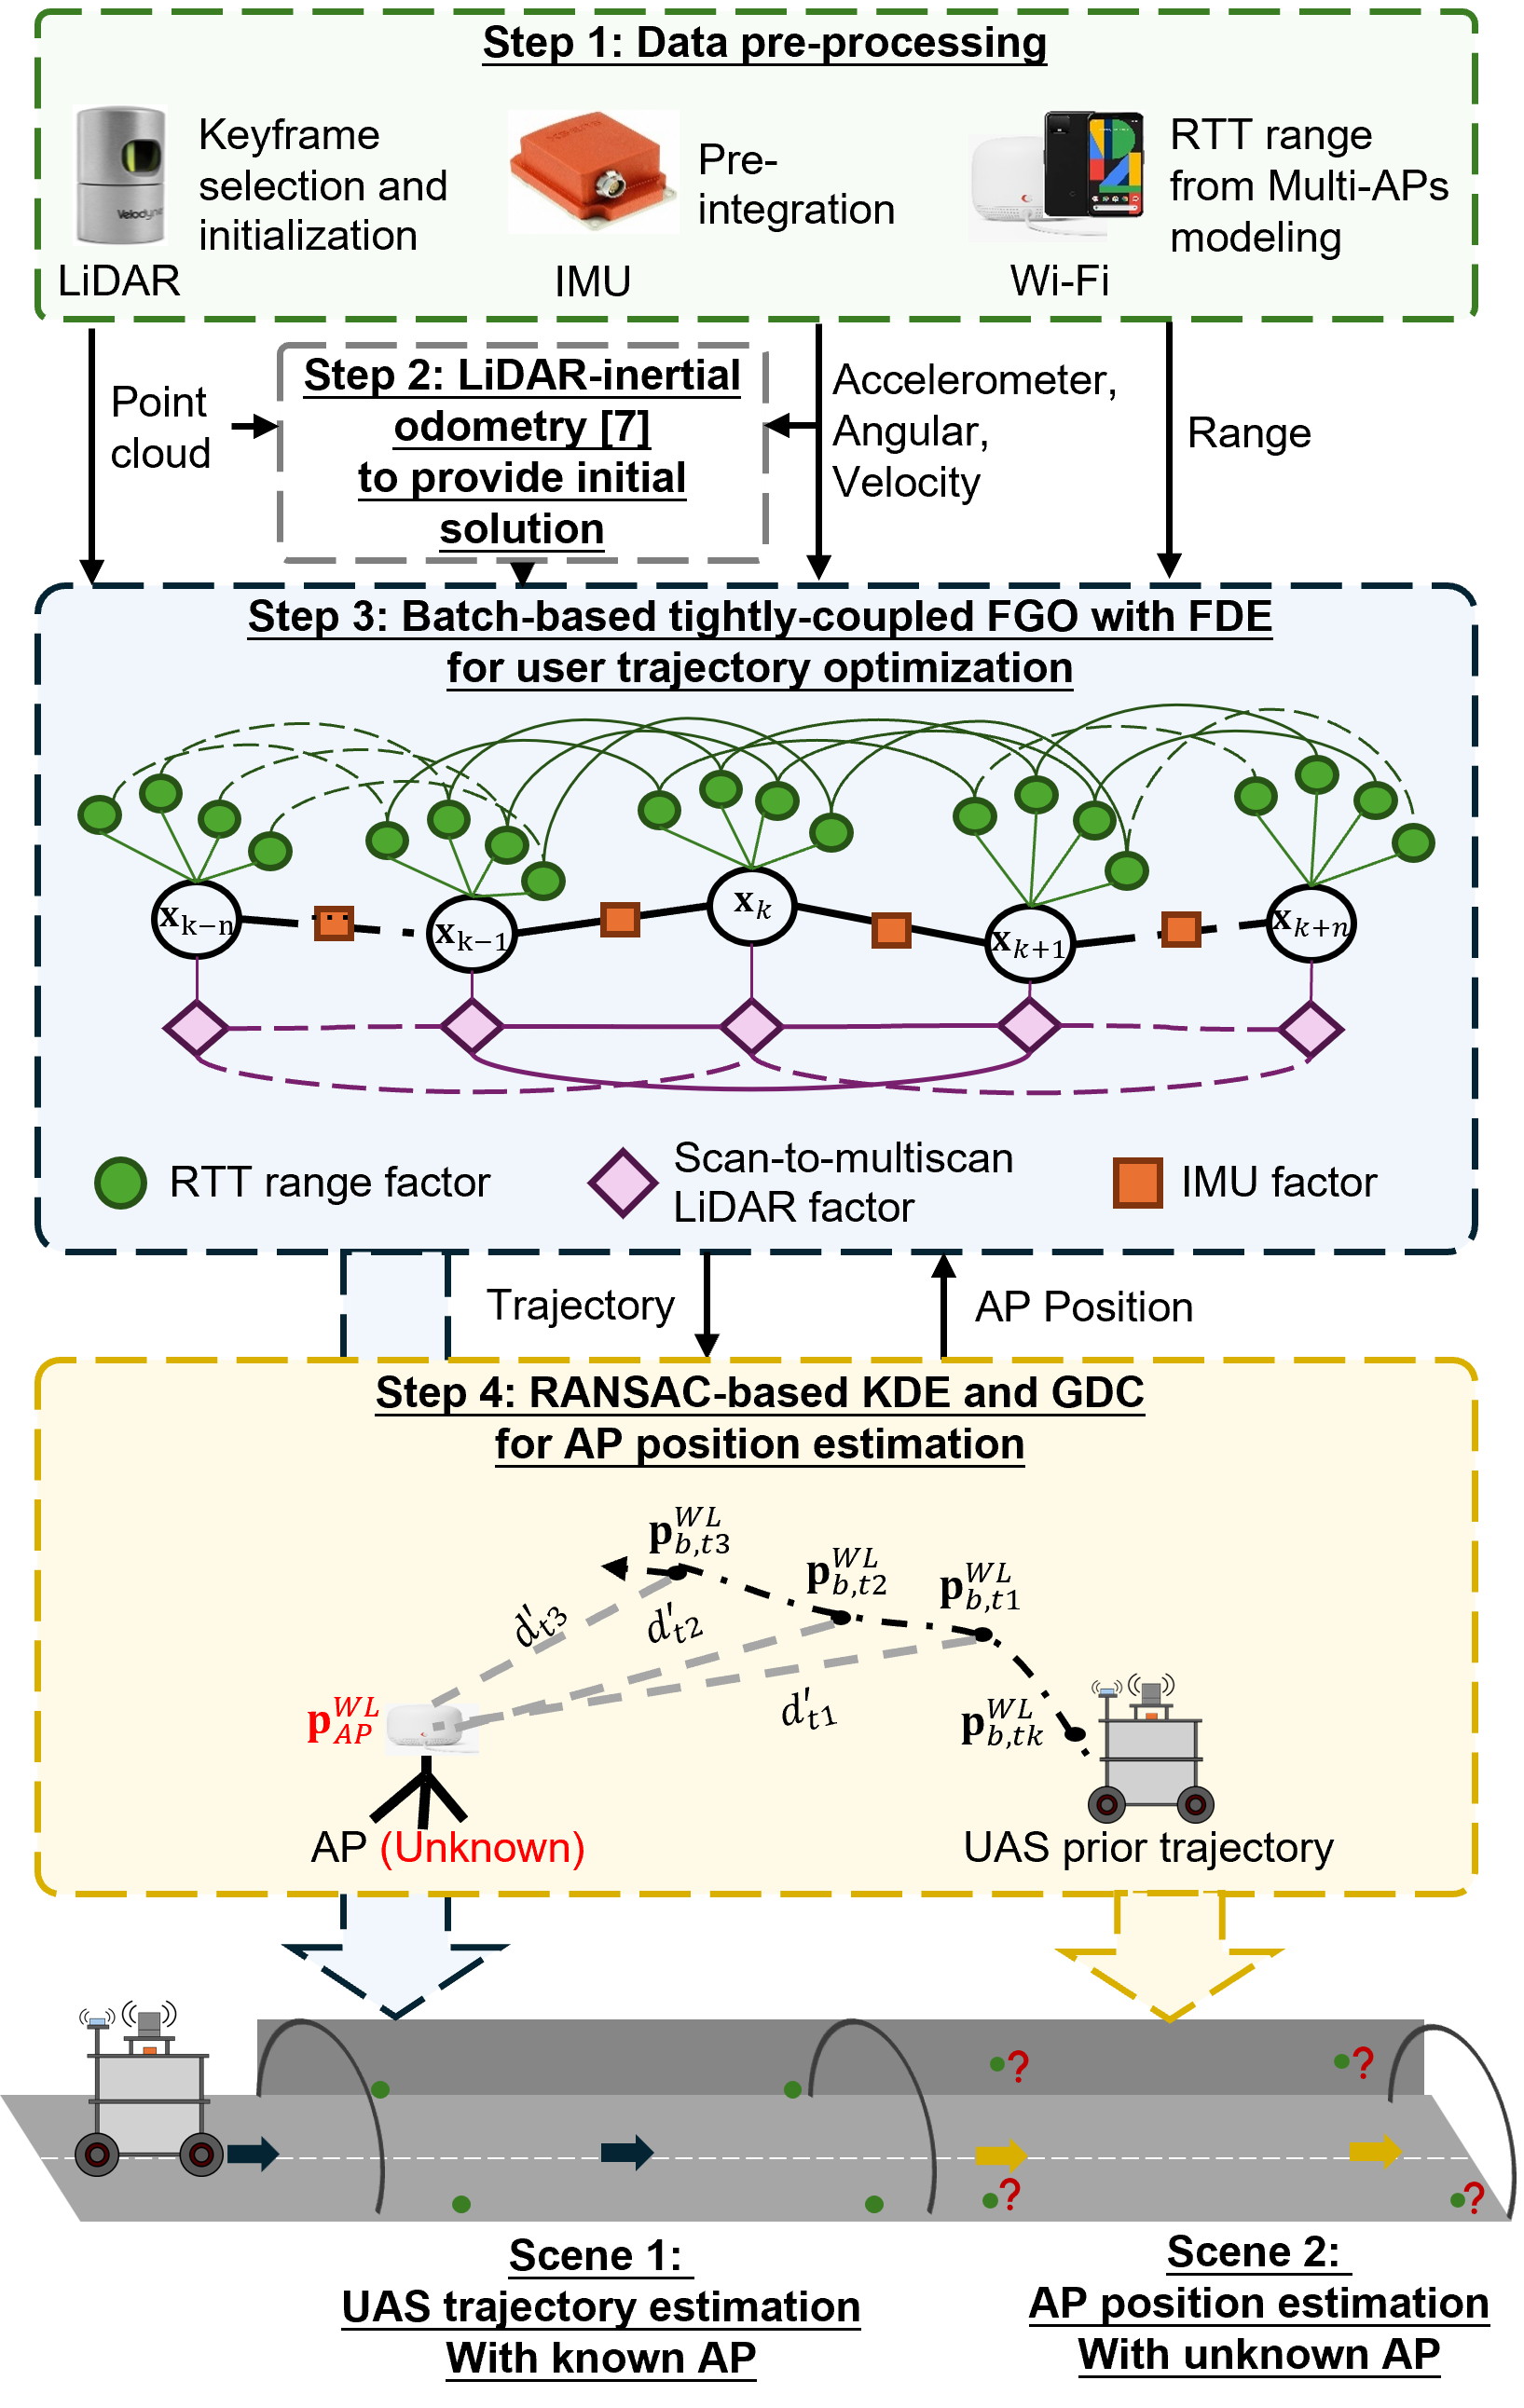
The paper “RTT-LIO: A Wi-Fi RTT-aided LiDAR-Inertial Odometry via Tightly-Coupled Factor Graph Optimization in Complex Scenes” has been accepted by the IEEE Internet of Things Journal. Congratulations to Ruijie and the co-authors!
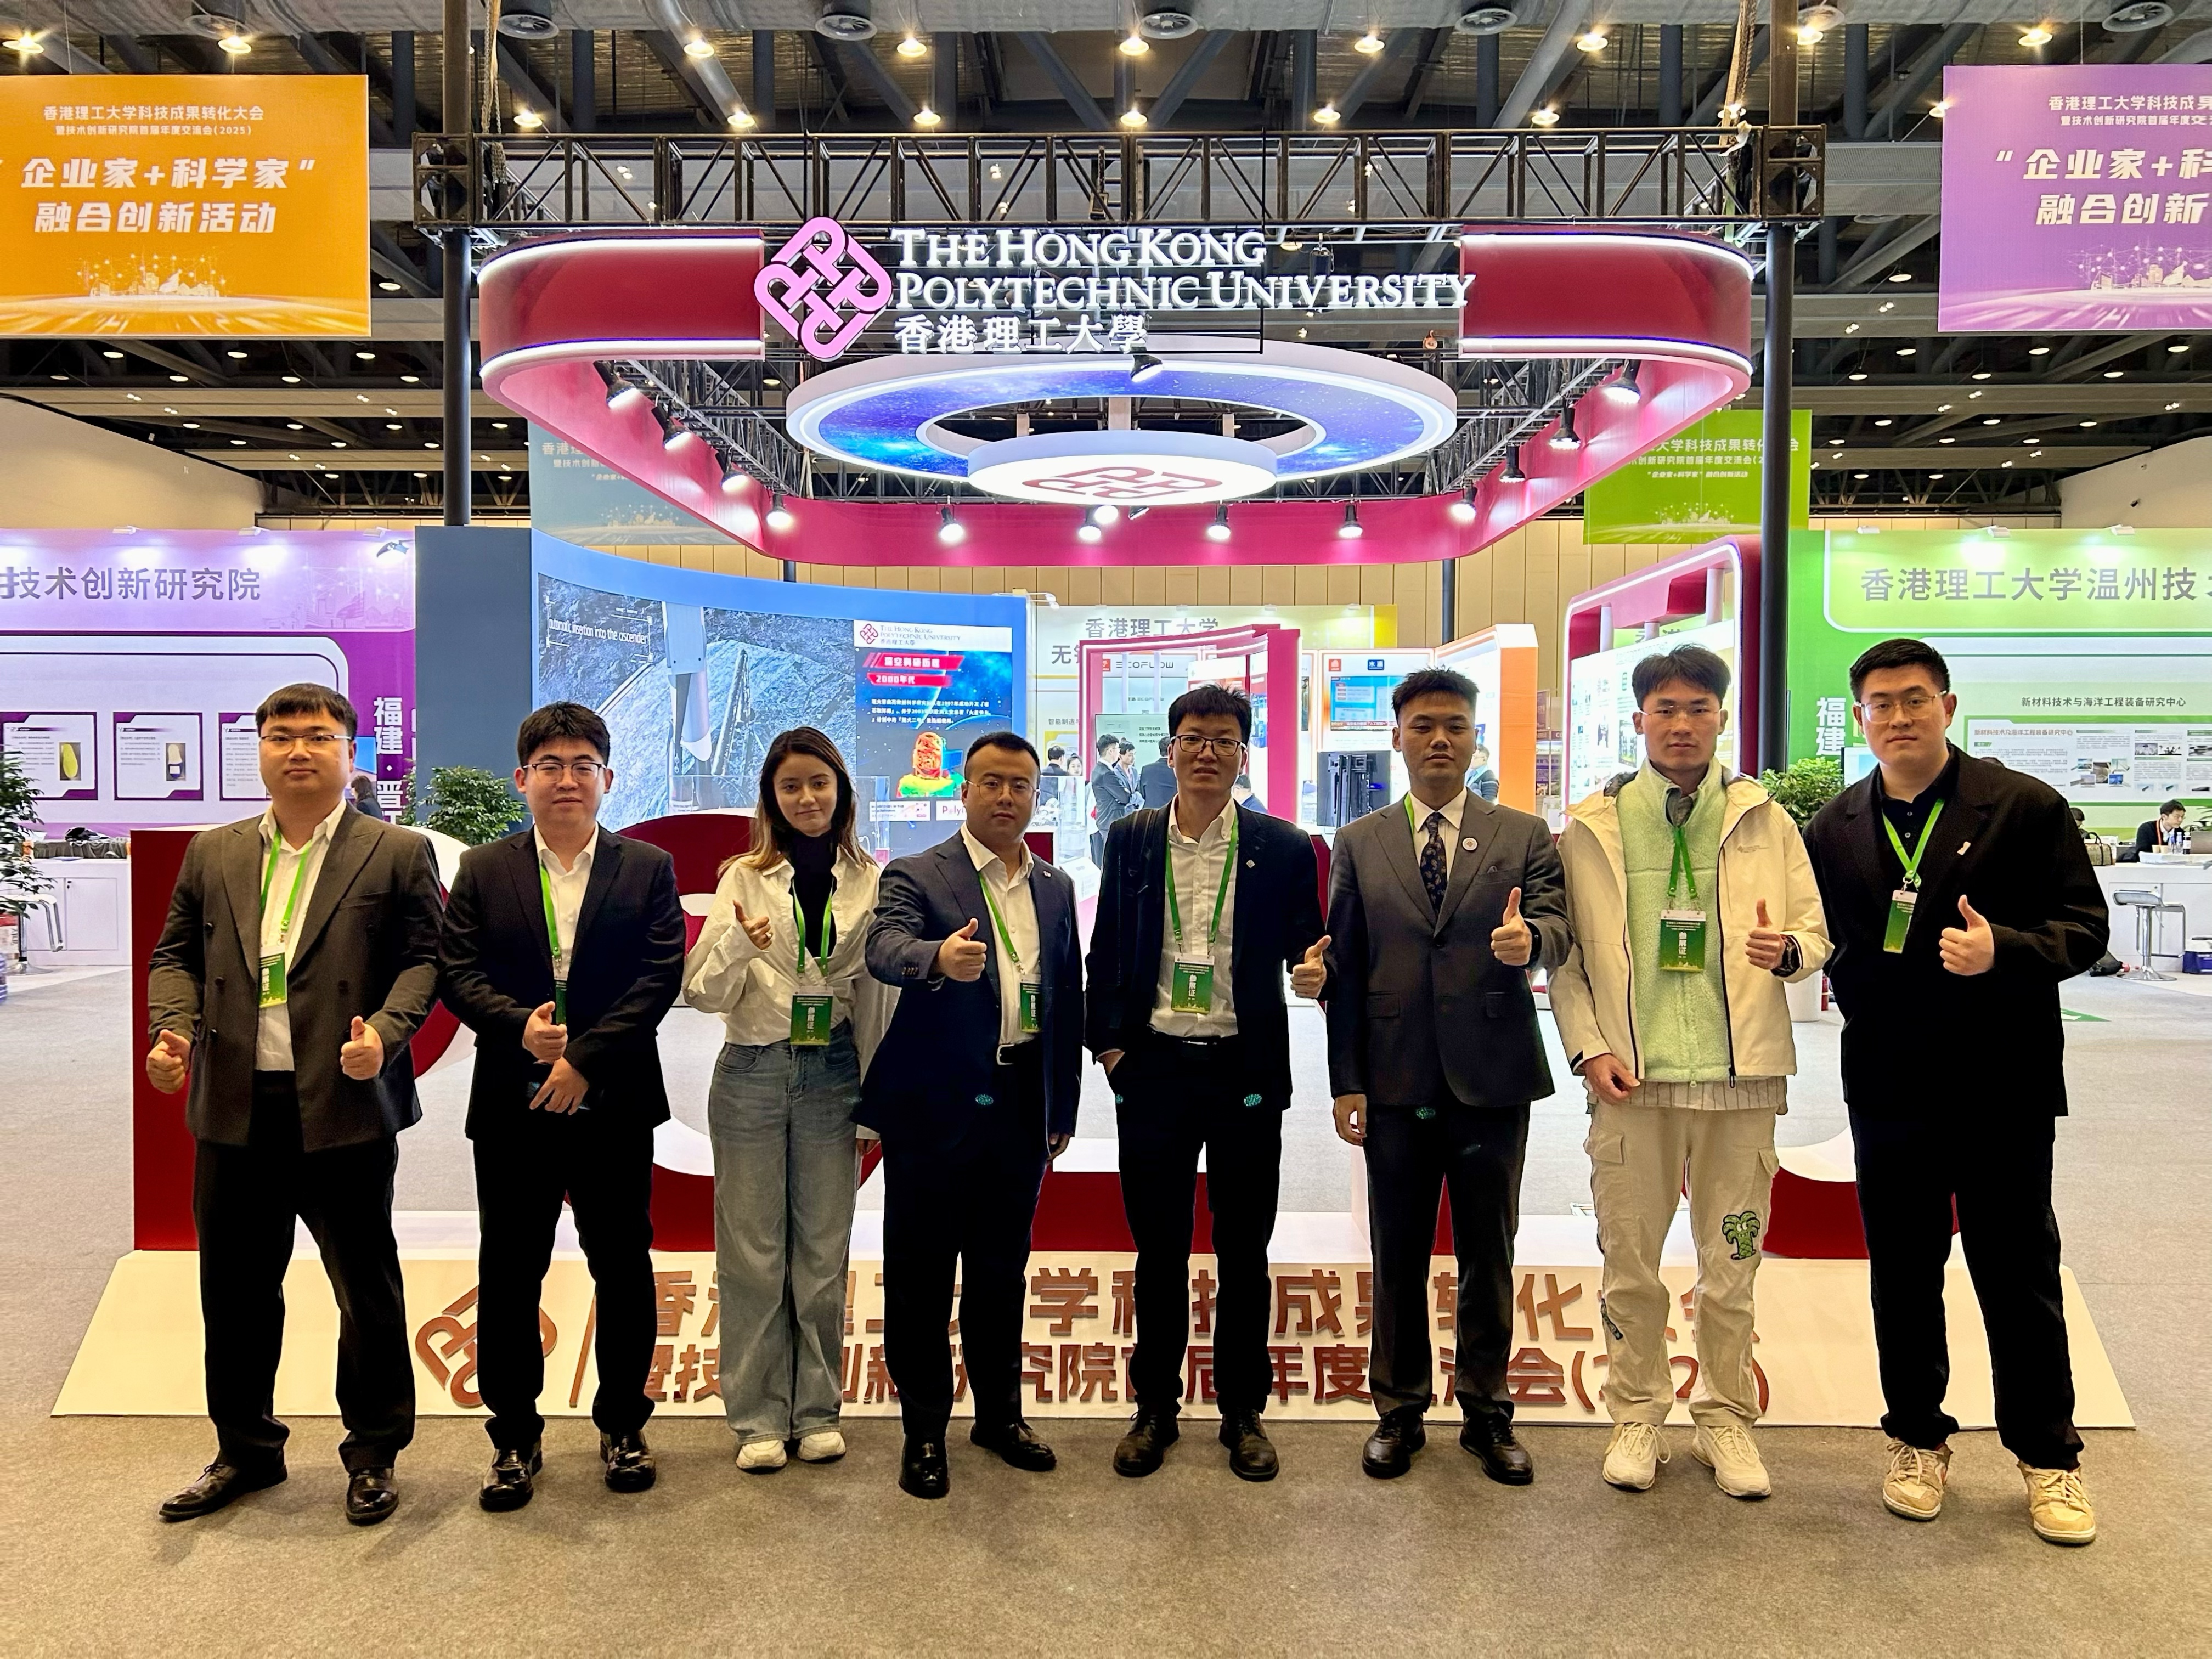
On 14 December 2025, the research team of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) took part in the inaugural “Hong Kong Polytechnic University Technology Transfer Conference & Inaugural Annual Exchange Meeting of the Institute for Technological Innovation (2025)” in Jinjiang City, Fujian Province, China. The event drew over 3,500 participants from government, academia and industry, and focused on advancing industry-academia-research integration and fostering an innovation ecosystem.
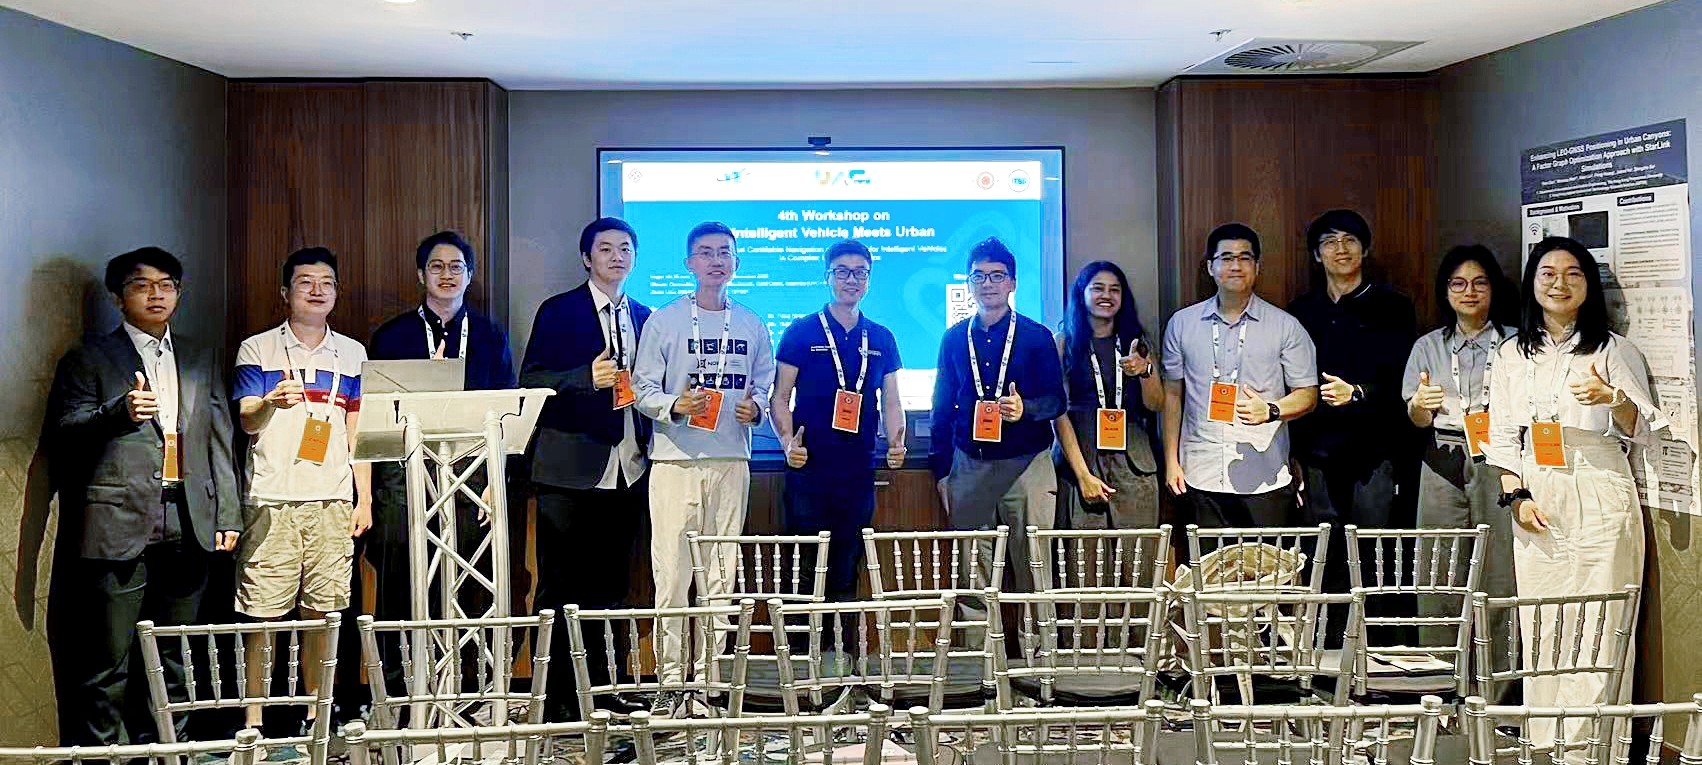
On 18 November 2025, the 4th Workshop on Intelligent Vehicle Meets Urban: Safe And Certifiable Navigation And Control was held at the Star Grand, Broadbeach, Gold Coast, Australia, in conjunction with the ITSC 2025 conference. The event brought together experts and researchers to address the critical challenges of ensuring safe, robust and certifiable autonomous navigation in complex urban environments.
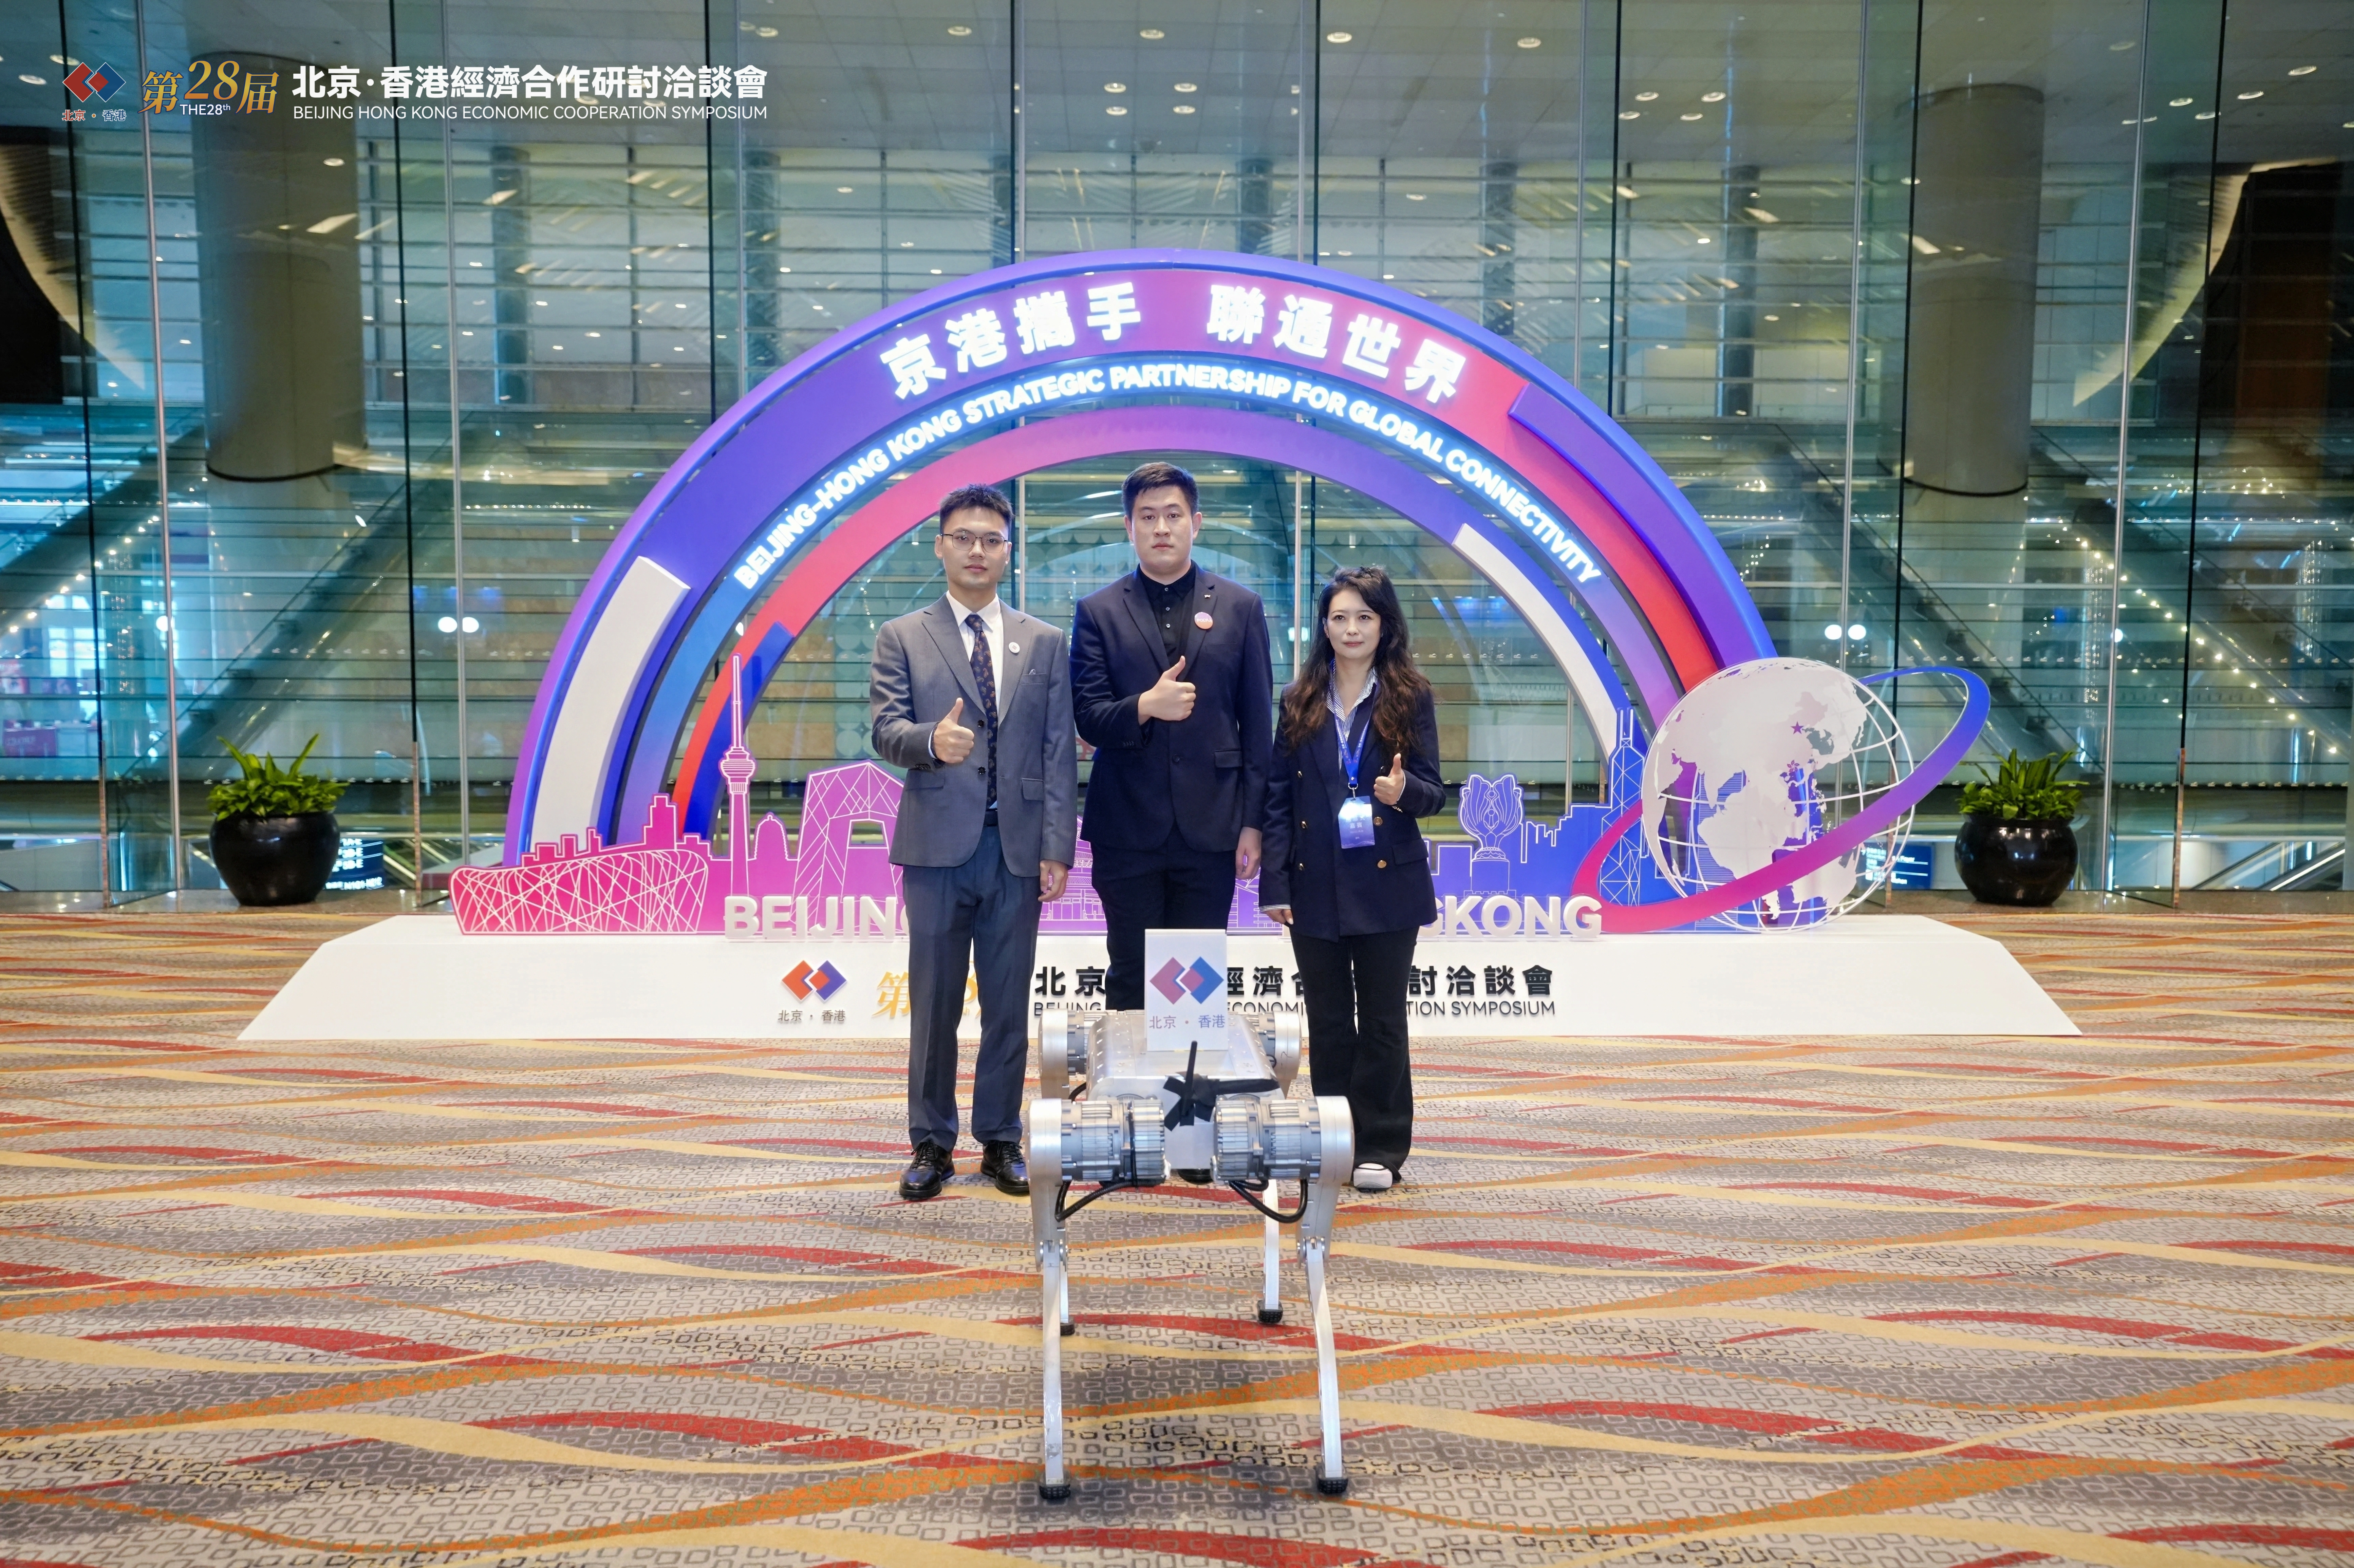
On 12 November 2025, Dr. Runqiu Yang and Mr. Zhongqi Wang from the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) presented the lab’s quadruped robot at the 28th Beijing-Hong Kong Economic Cooperation Symposium in Hong Kong. The robot is designed for inspection, logistics and search-and-rescue operations, and can carry heavy loads for extended periods. The demonstration attracted considerable attention from government officials, industry leaders and academics.
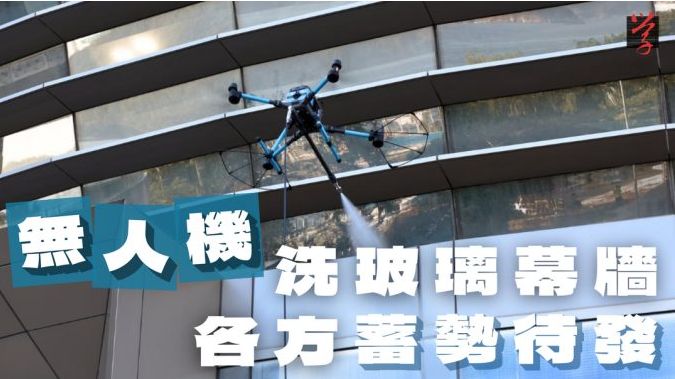
UBeat recently ran the feature “Drones for glass curtain wall cleaning: all parties gearing up.” In the interview, Weisong Wen, lead of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) and Assistant Professor, outlined the technology roadmap, regulatory compliance and application outlook for drone-based curtain wall cleaning, and presented the team’s progress in autonomous localization, control and operational safety.
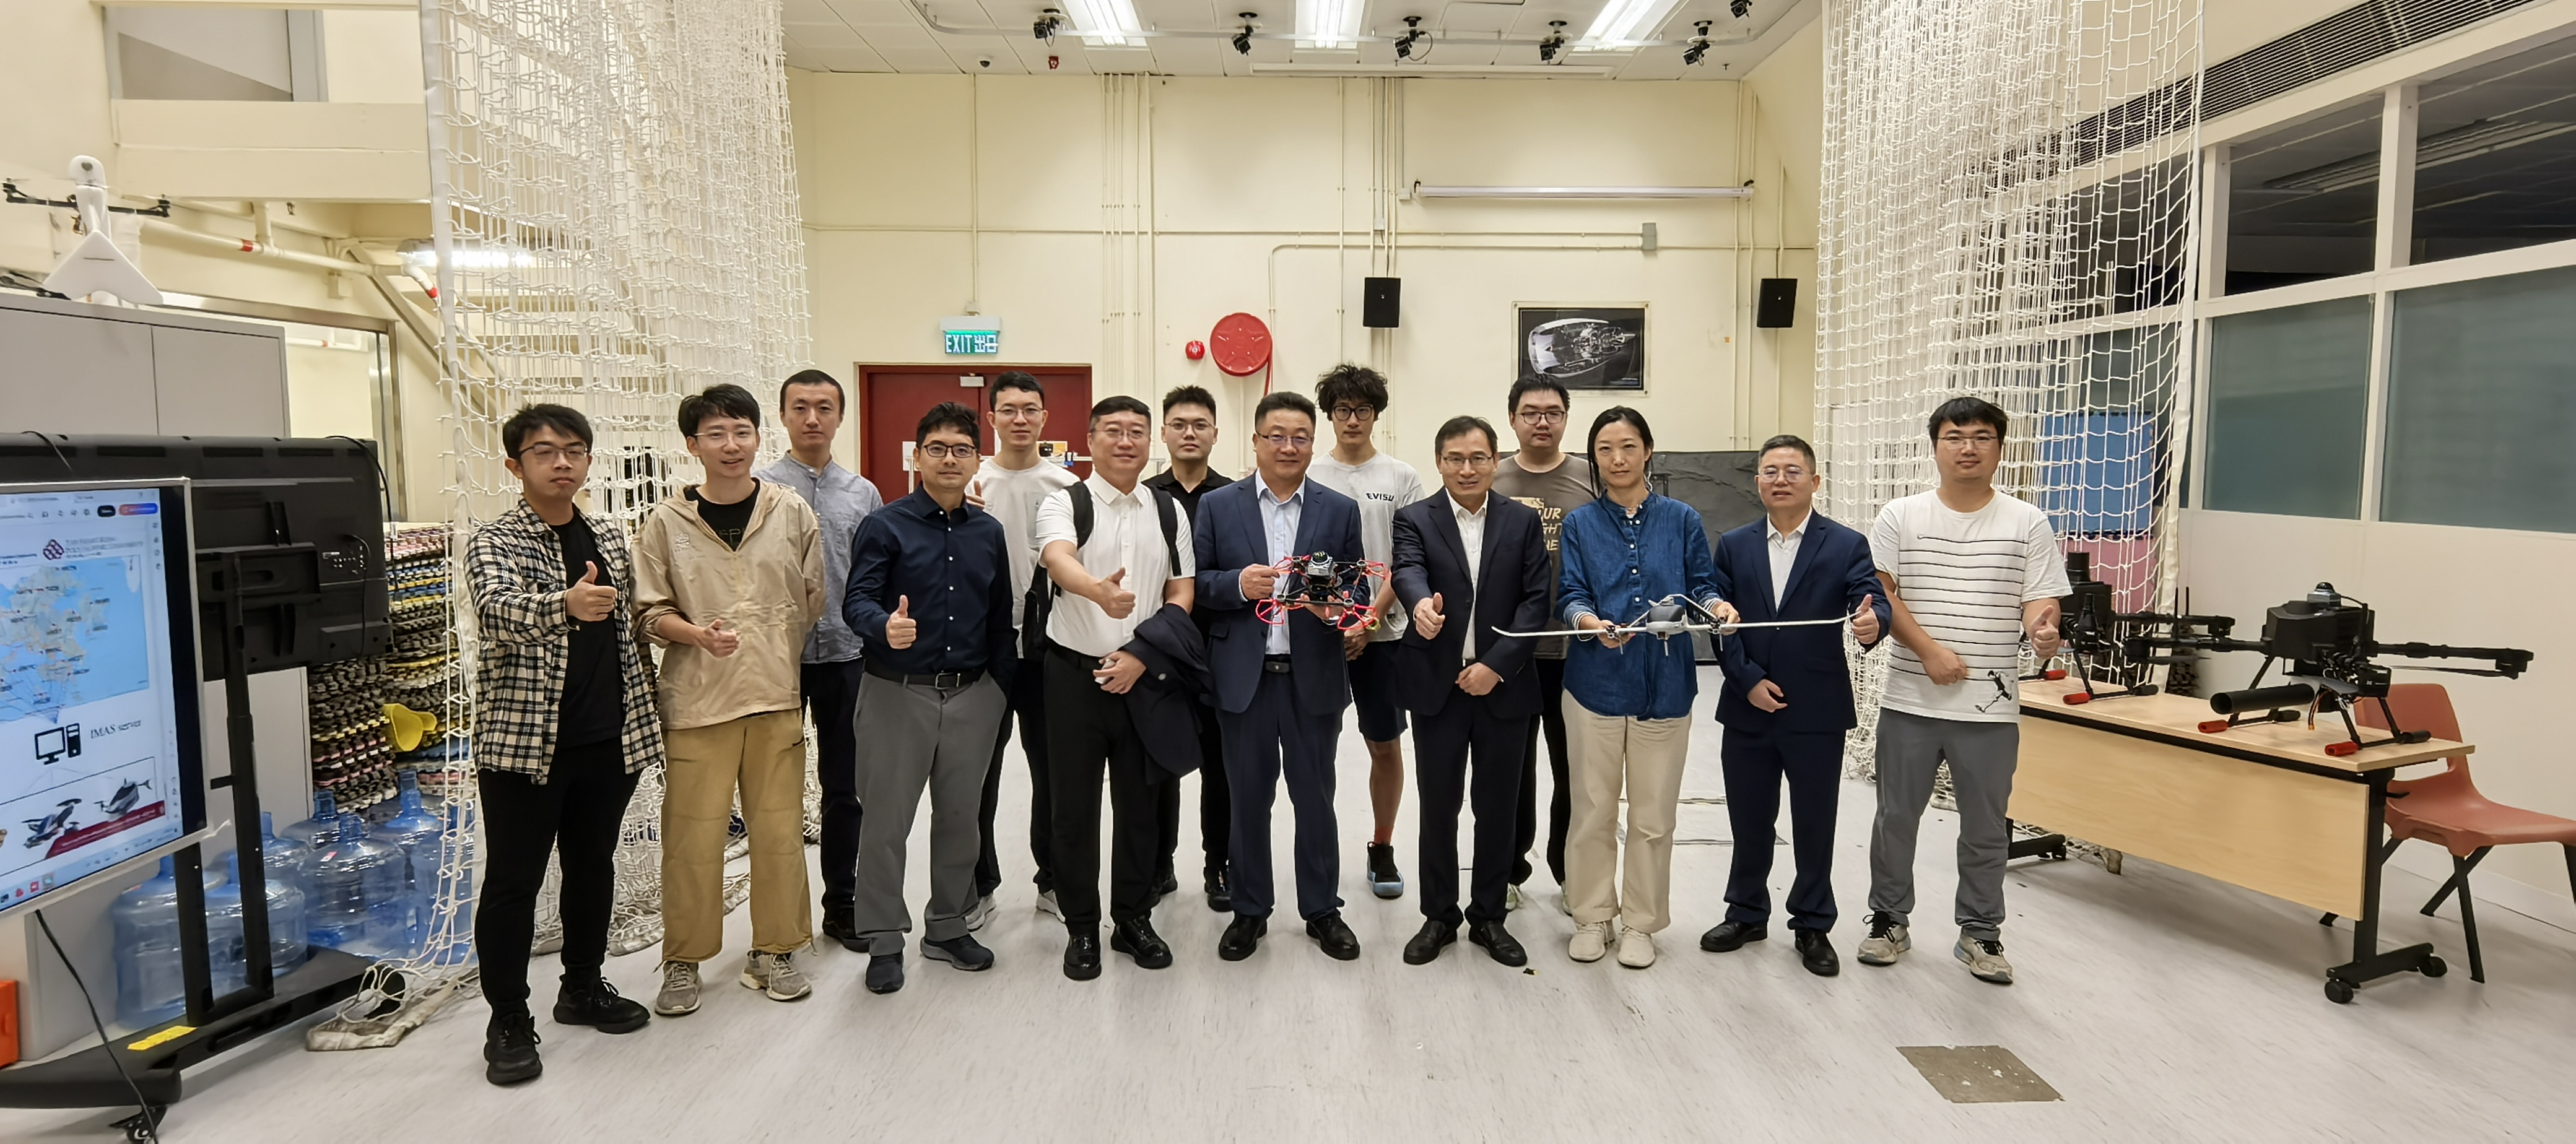
HONG KONG – 10 November 2025 – The Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) today welcomed a delegation from Harbin Engineering University (HEU), led by Vice President YU Zhiwen. The visit was organised to demonstrate the lab’s latest advances in autonomous systems and to deepen the research partnership between the two institutions.
On 6 November 2025, a research delegation from The Hong Kong Polytechnic University (PolyU), led by Professor Weisong Wen, visited the offices of Shenzhen Chuanghuan in Shenzhen, China, for technical discussions on future collaboration. The meeting focused on the application of advanced unmanned aerial vehicle (UAV) technology to internal pipeline exploration and inspection.
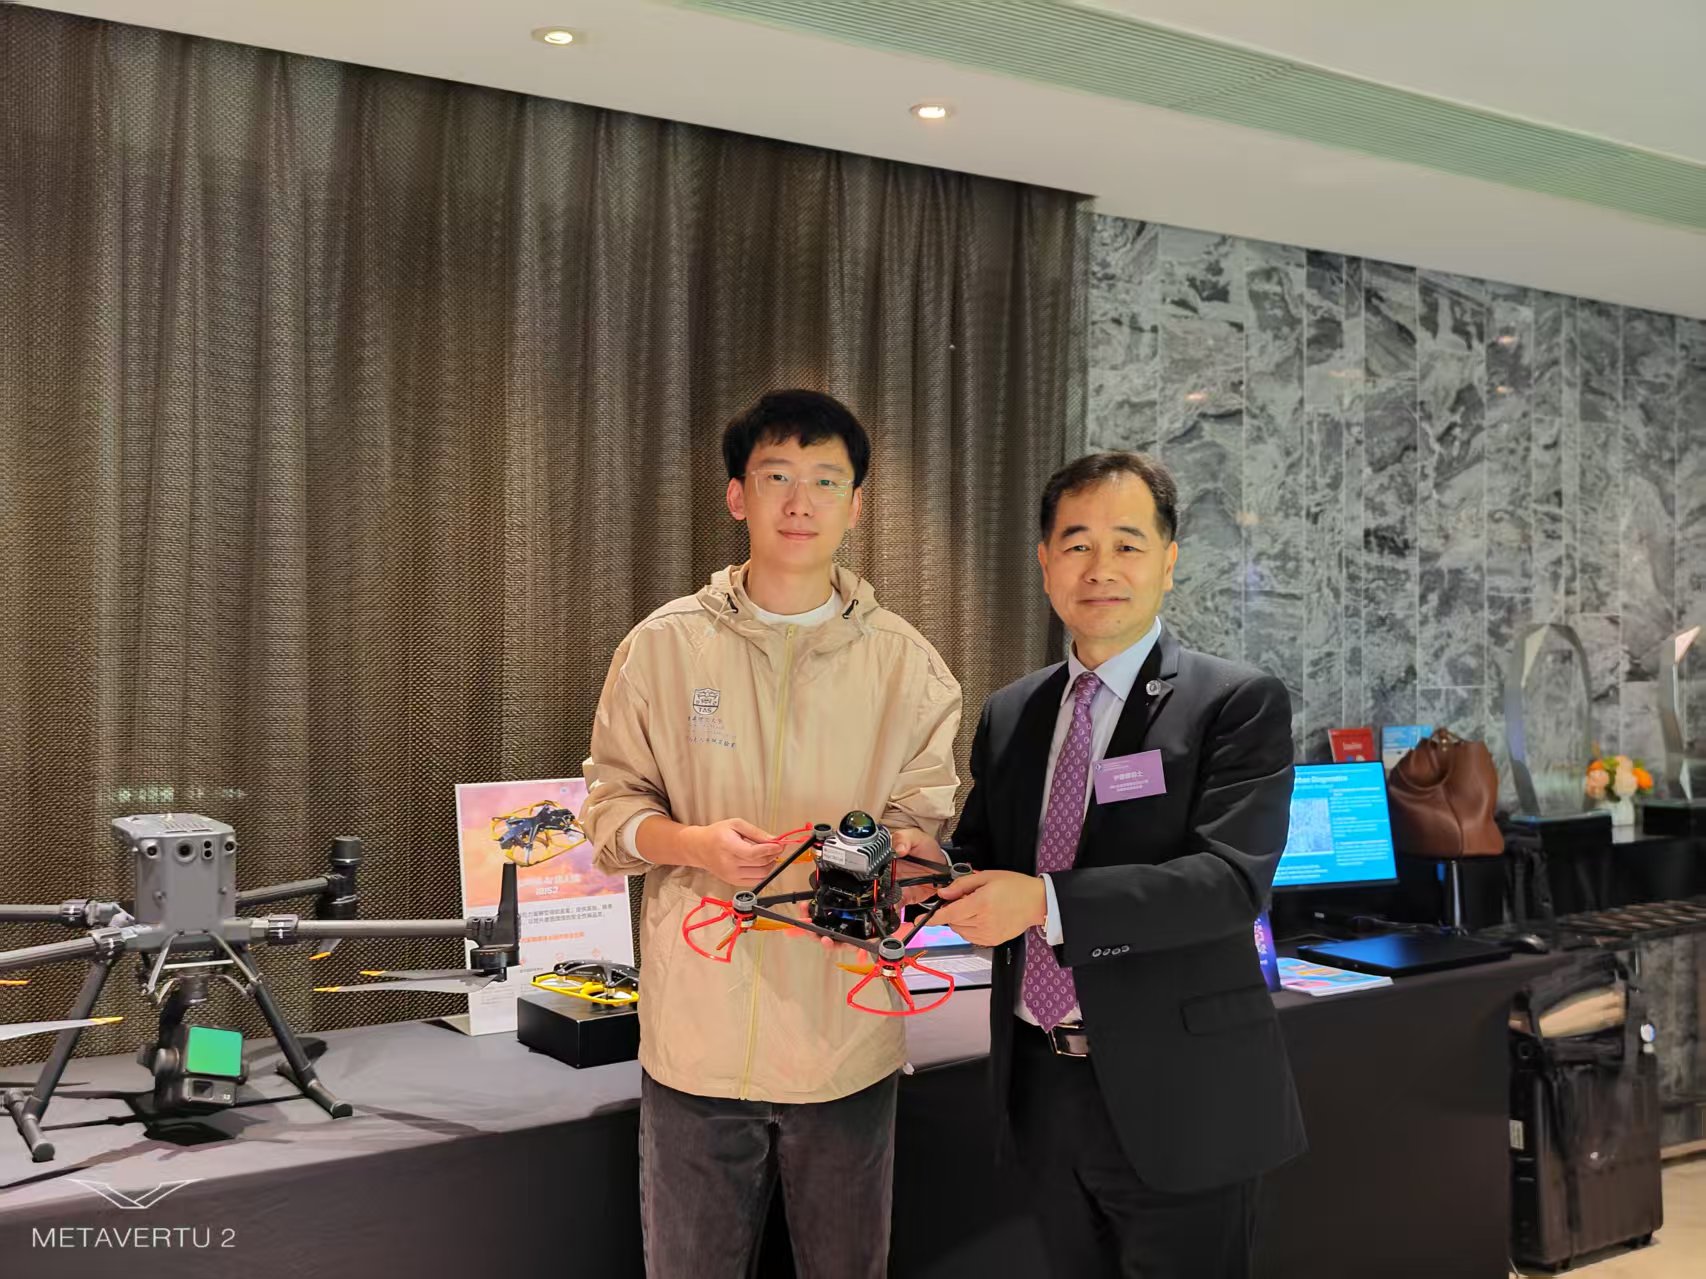
On 3 November 2025, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) presented its unmanned aerial vehicle (UAV) technology at a special exhibition during the annual dinner of The Chartered Institute of Housing (CIH) Asian Pacific Branch in Hong Kong. The event, attended by key figures and professionals from the housing and property management industry, gave the PolyU research team an opportunity to demonstrate practical applications of its drone systems.
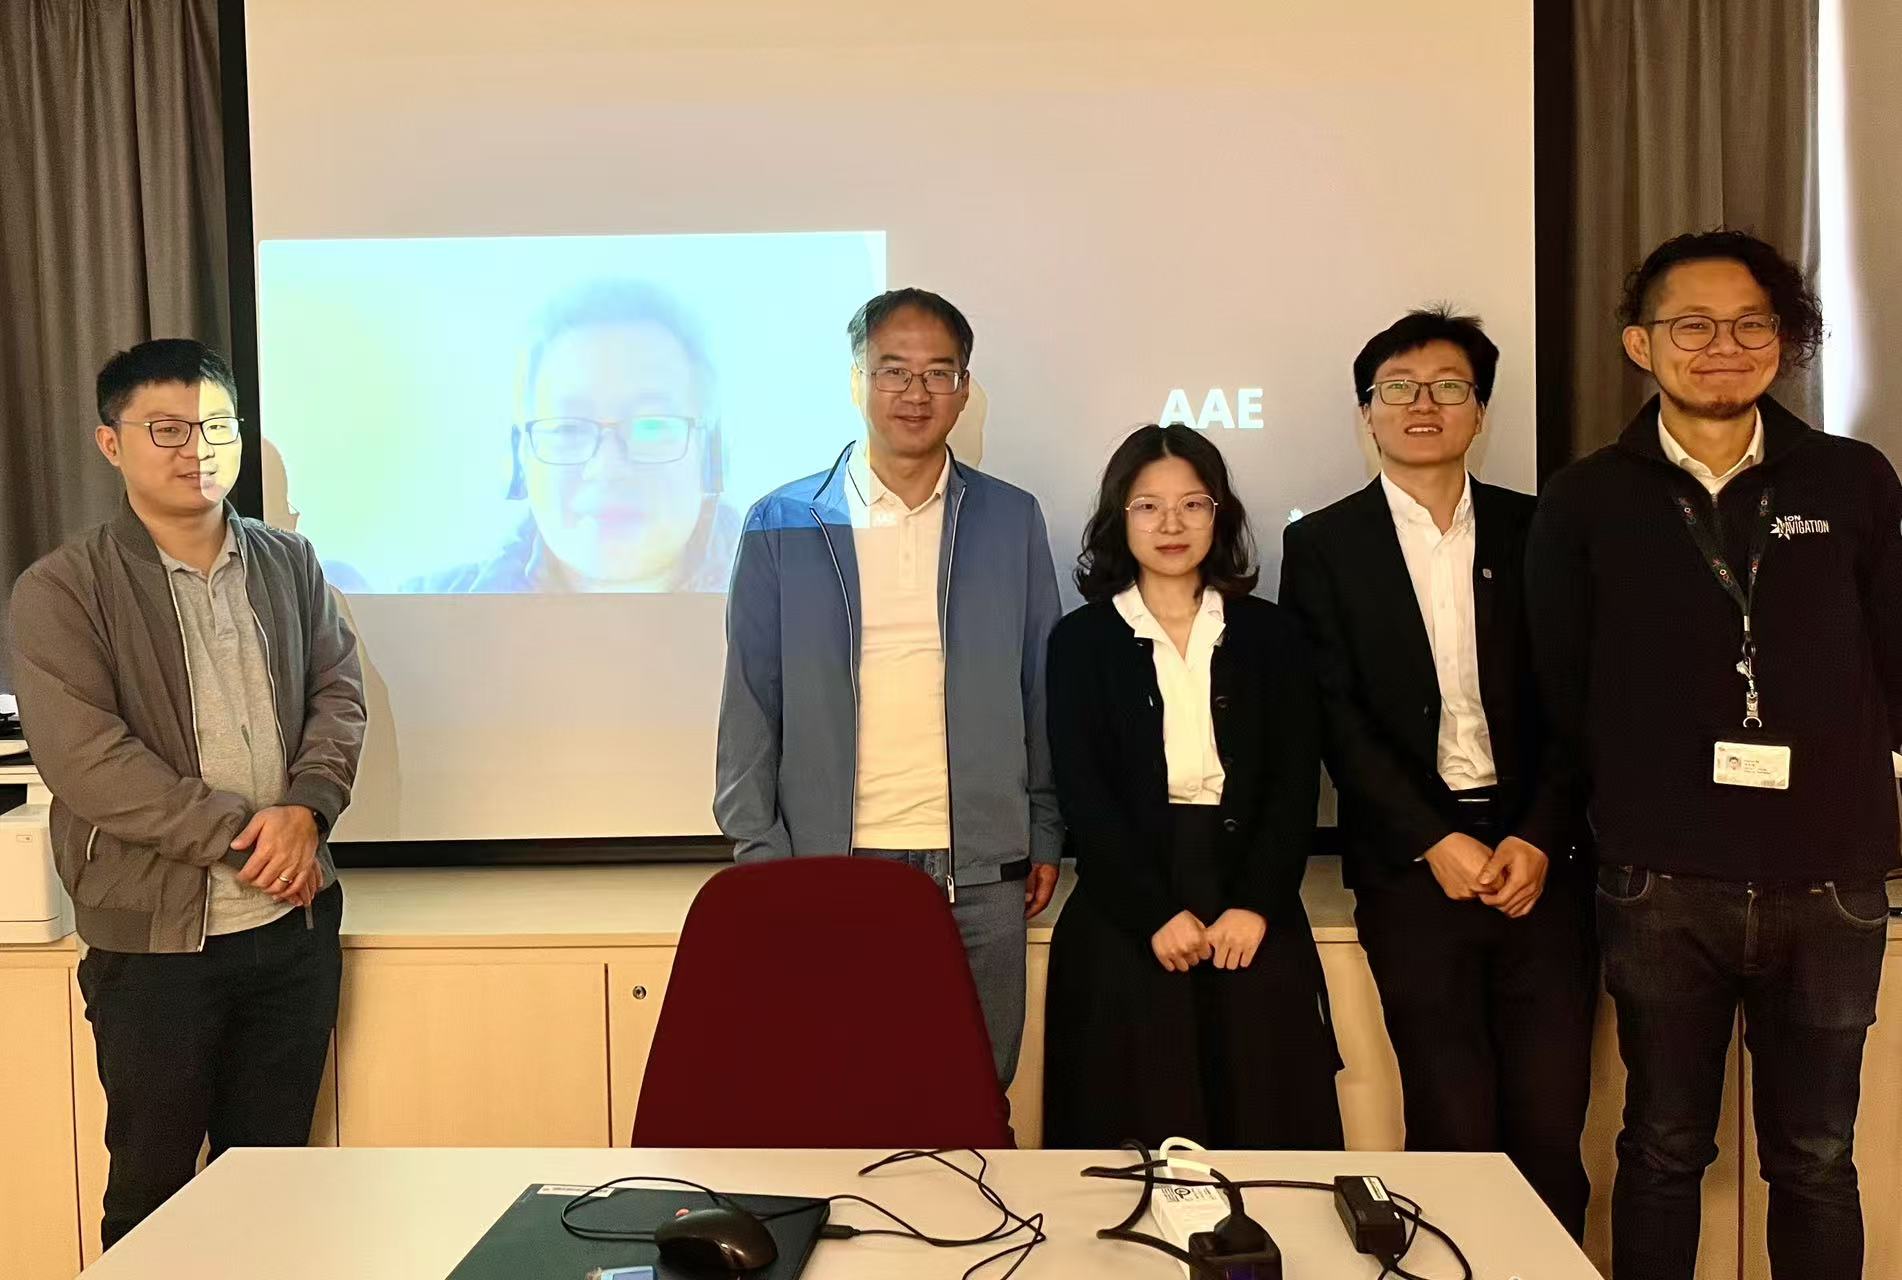
Dr. ZHENG Xi has successfully passed the PhD oral defense. Congratulations!
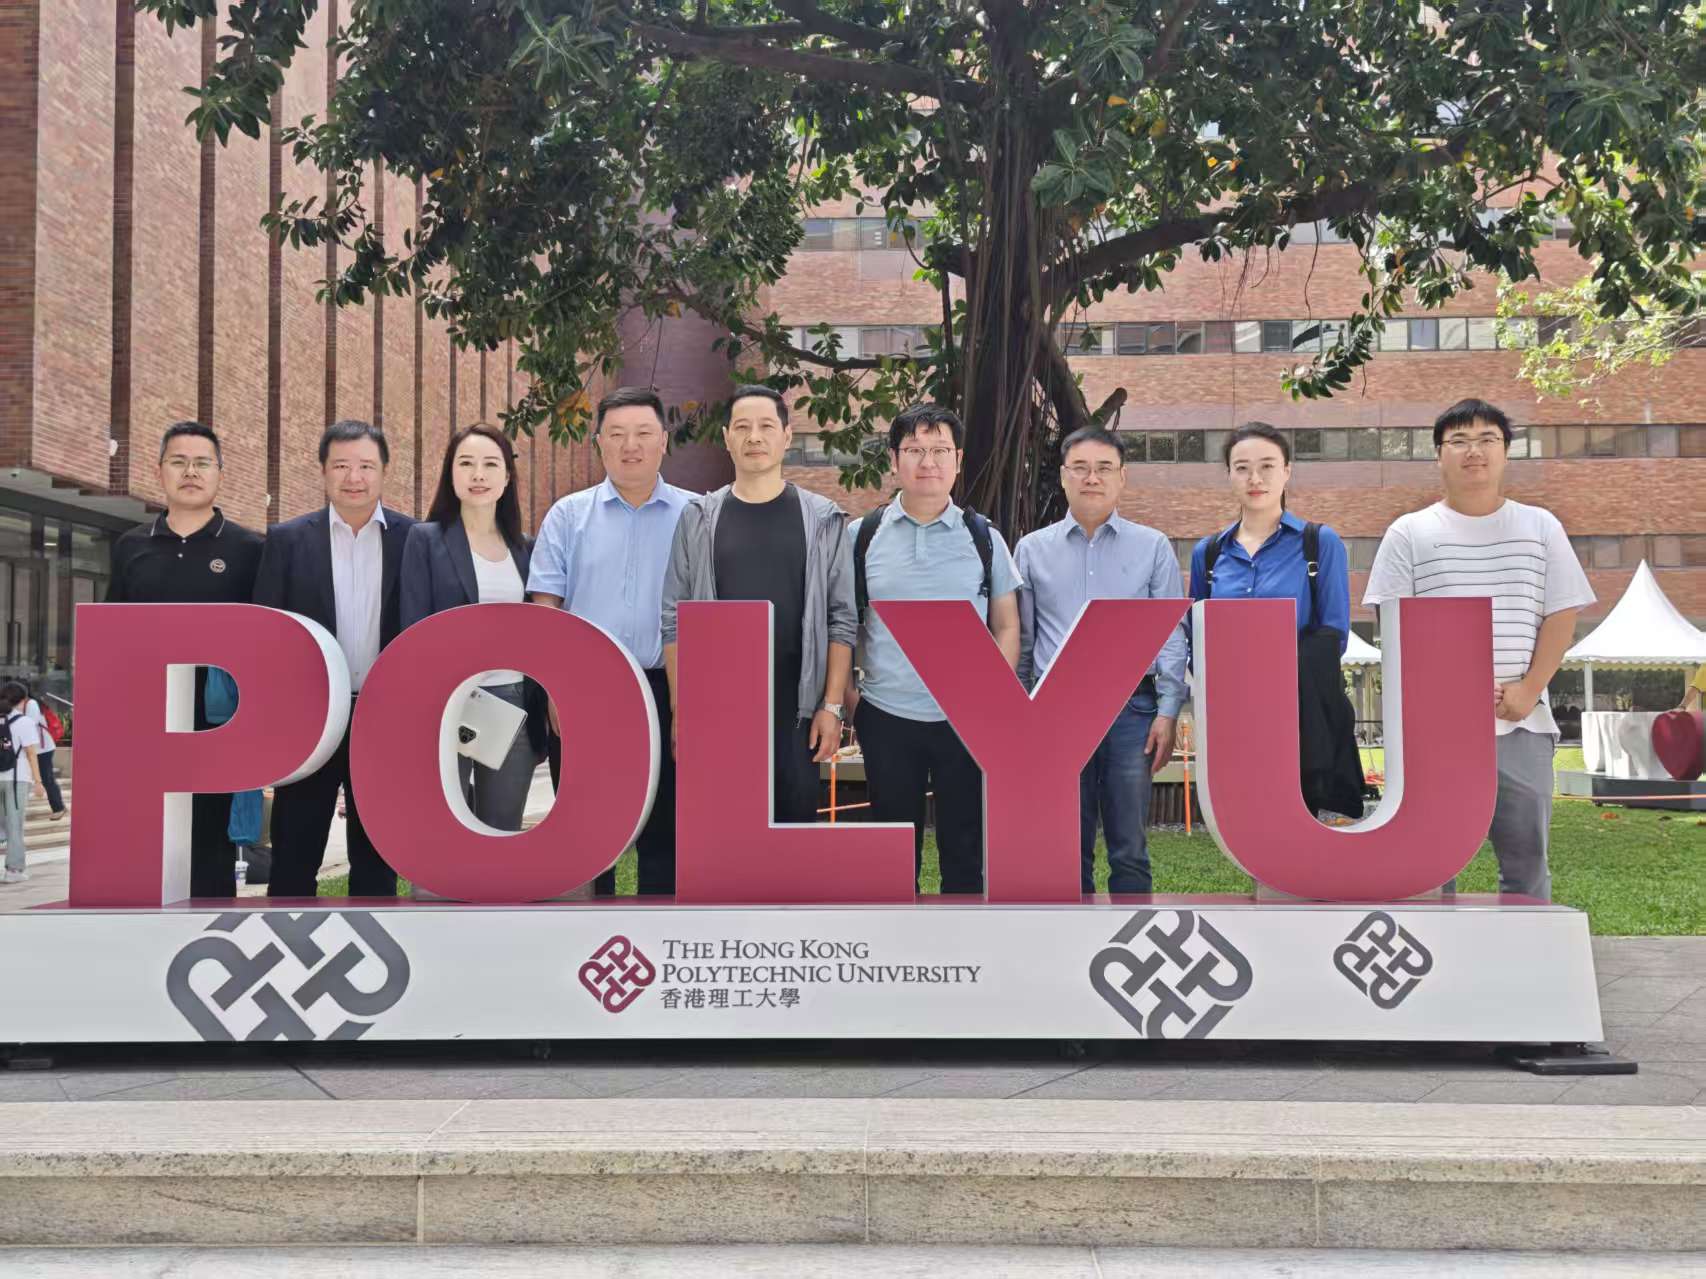
Officials from the Nanjing Jiangning Economic Development Zone visited The Hong Kong Polytechnic University (PolyU), where they were introduced to the research of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB). The delegation was given an overview of several projects, including cleaning drones, tunnel inspection drones, humanoid robots and end-to-end autonomous driving systems.
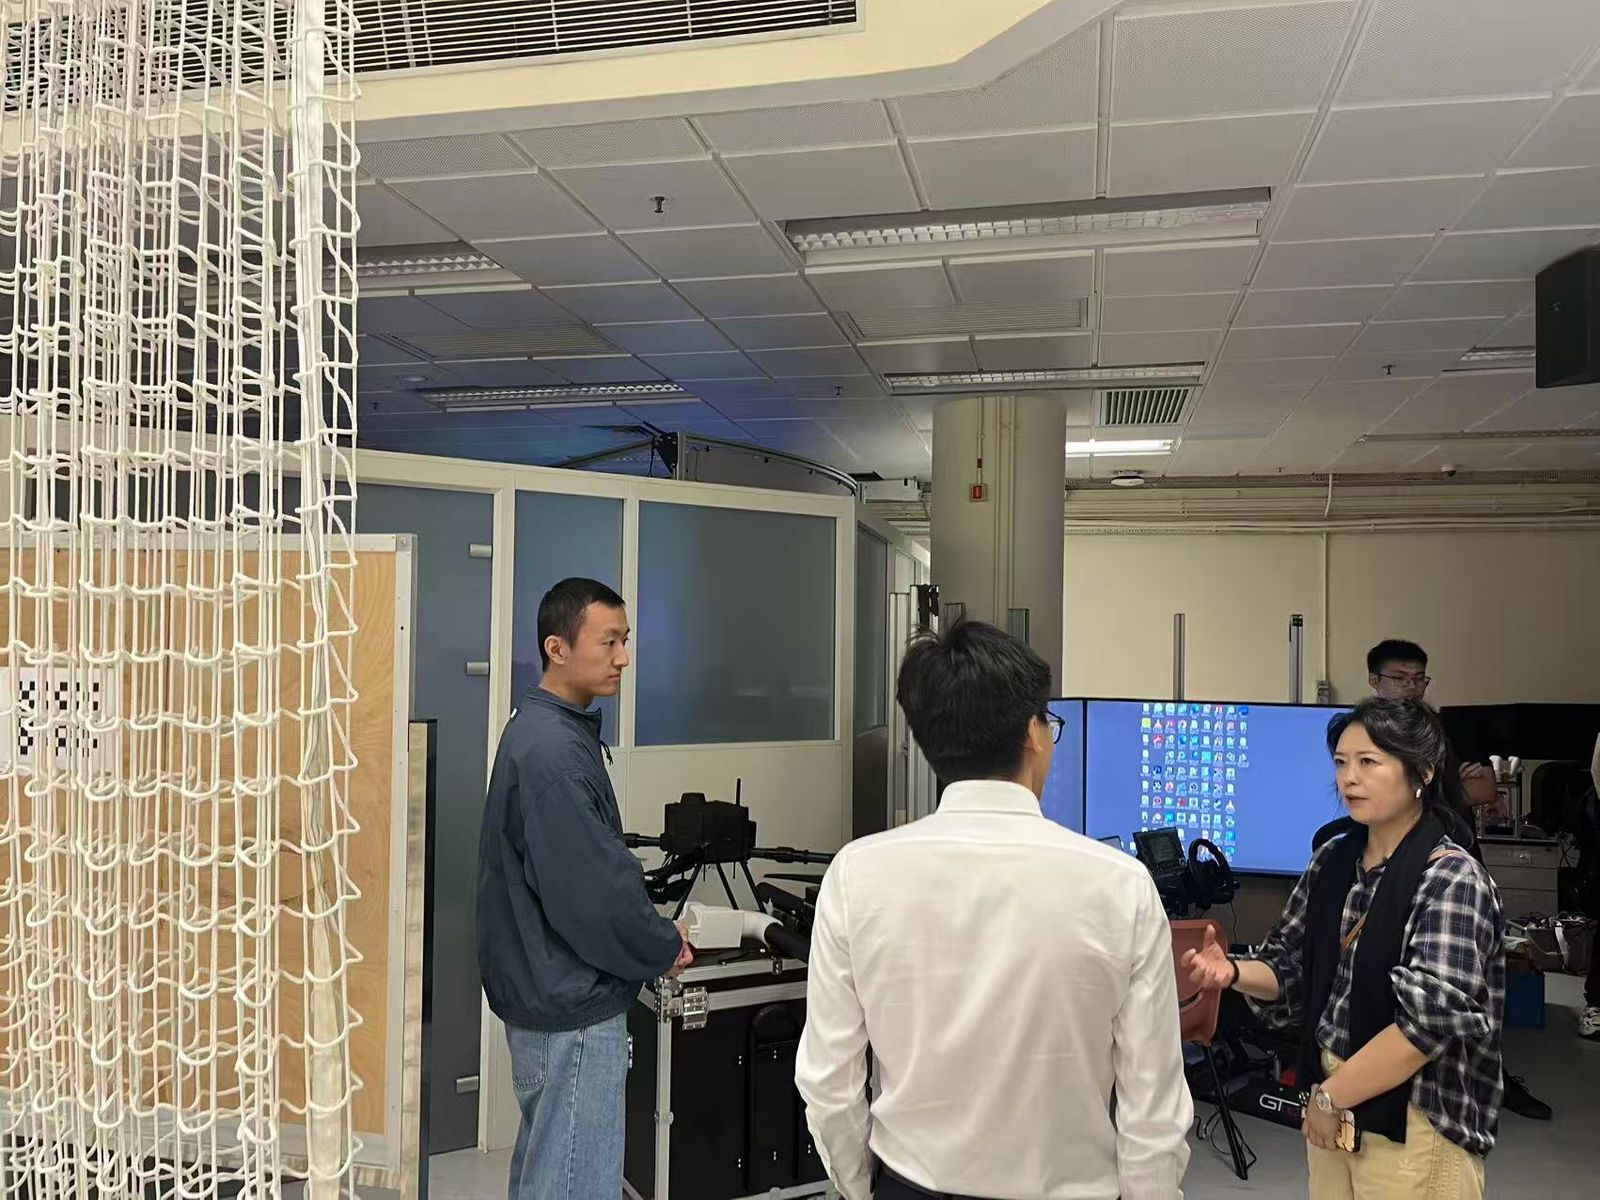
Representatives from the Shougang Jinggang Innovation Center visited The Hong Kong Polytechnic University (PolyU), where they were introduced to the research of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB).
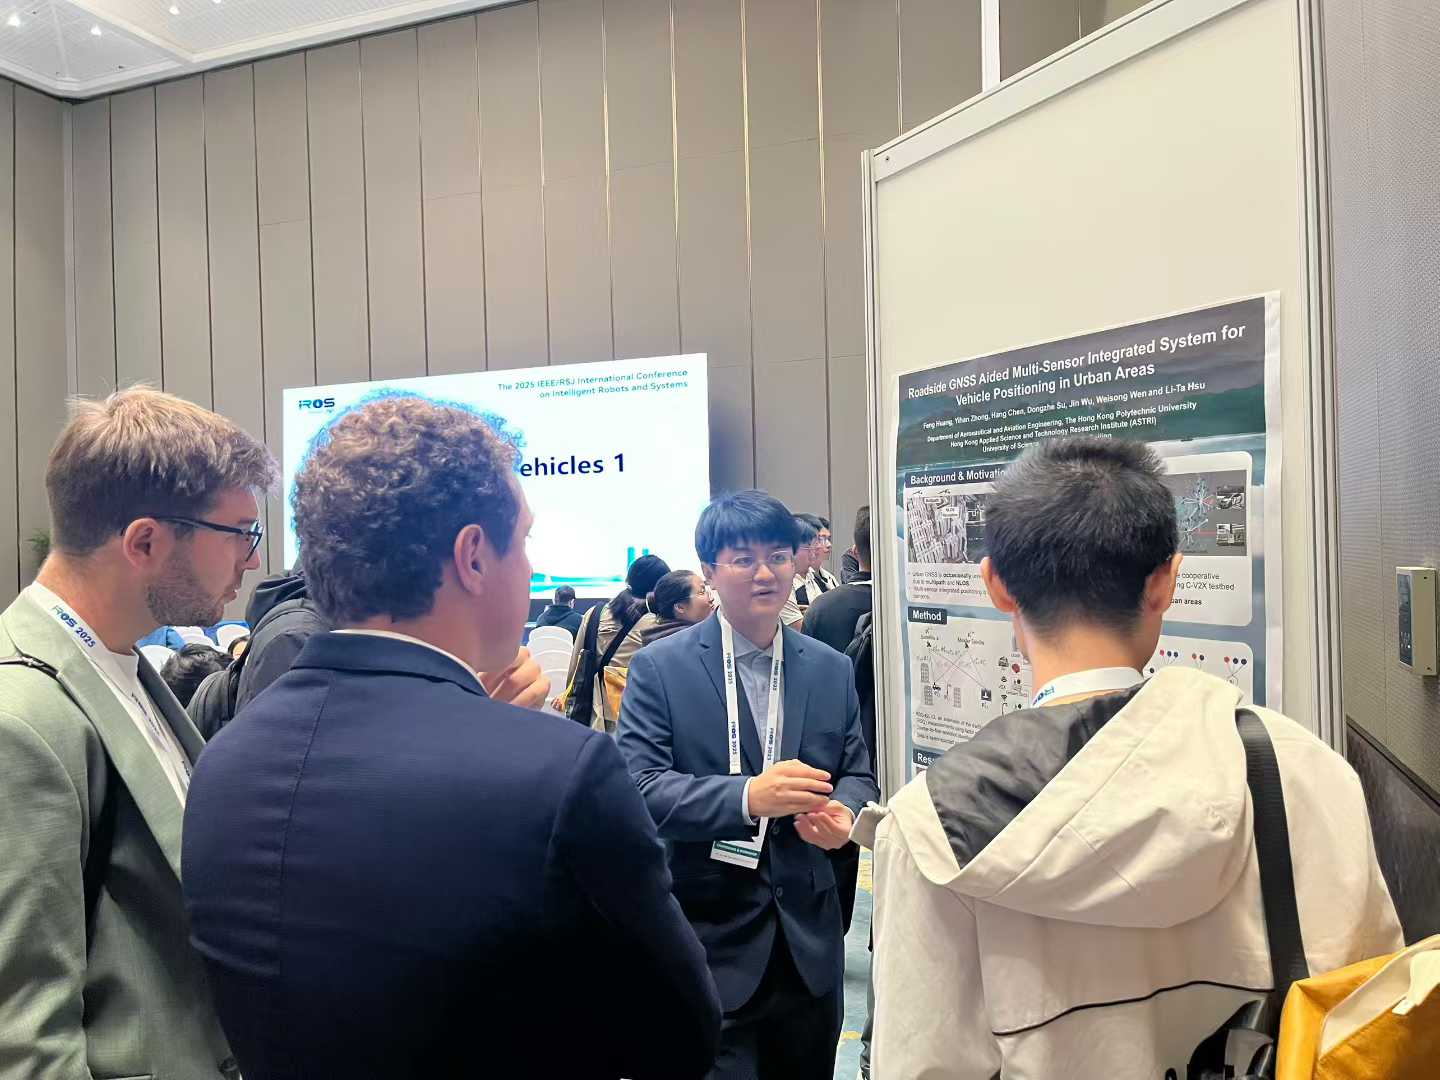
Our lab members Dr. HUANG Feng and PhD student ZHONG Yihan are presenting their work at IEEE IROS 2025. After 19 years, IROS has returned to China, at a pivotal moment in the rapid advancement of AI and robotics, making IROS 2025 an excellent venue for discussion and networking. The data of our work is available on GitHub.
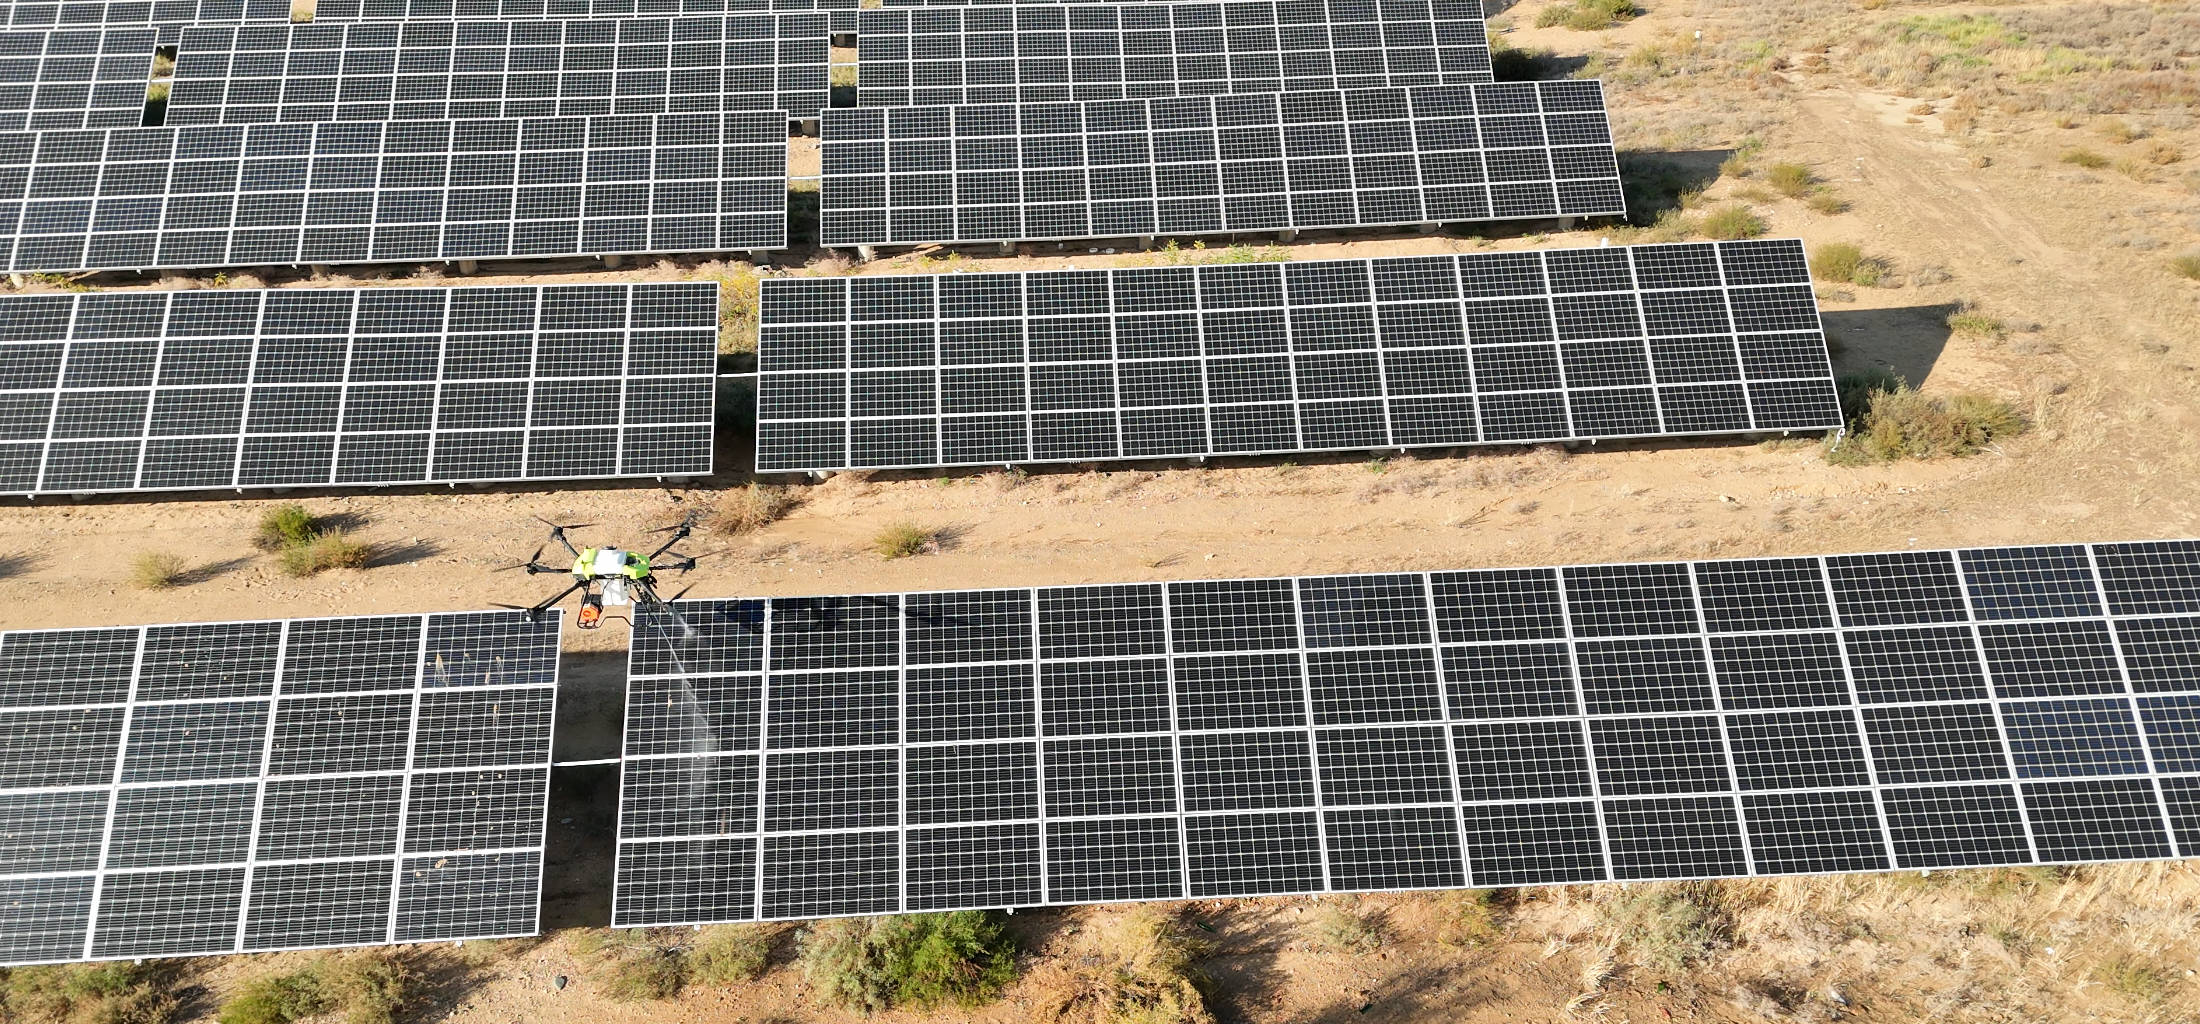
In late October, members of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) visited several key institutions and enterprises in Inner Mongolia to discuss the application of unmanned systems, and carried out drone-based photovoltaic cleaning and data collection at a desert power station.
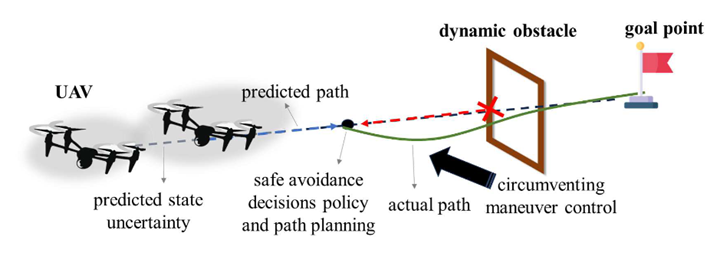
We are pleased to share that our paper “Learning Safe, Optimal, and Real-Time Flight Interaction With Deep Confidence-Enhanced Reachability Guarantee”, by Yuanyuan Zhang, Yingying Wang, Penggao Yan and Weisong Wen, has been accepted by the IEEE Transactions on Intelligent Transportation Systems. Congratulations to Yuanyuan and our colleagues.
On 30 September 2025, a team led by Dr. Weisong Wen of the Department of Aeronautics and Civil Aviation at The Hong Kong Polytechnic University (PolyU) held a successful meeting in Zhuhai with China Southern Power Grid Southern Offshore Wind Power Joint Development Co., Ltd. The meeting marked a significant step forward in discussions on a joint laboratory research project.
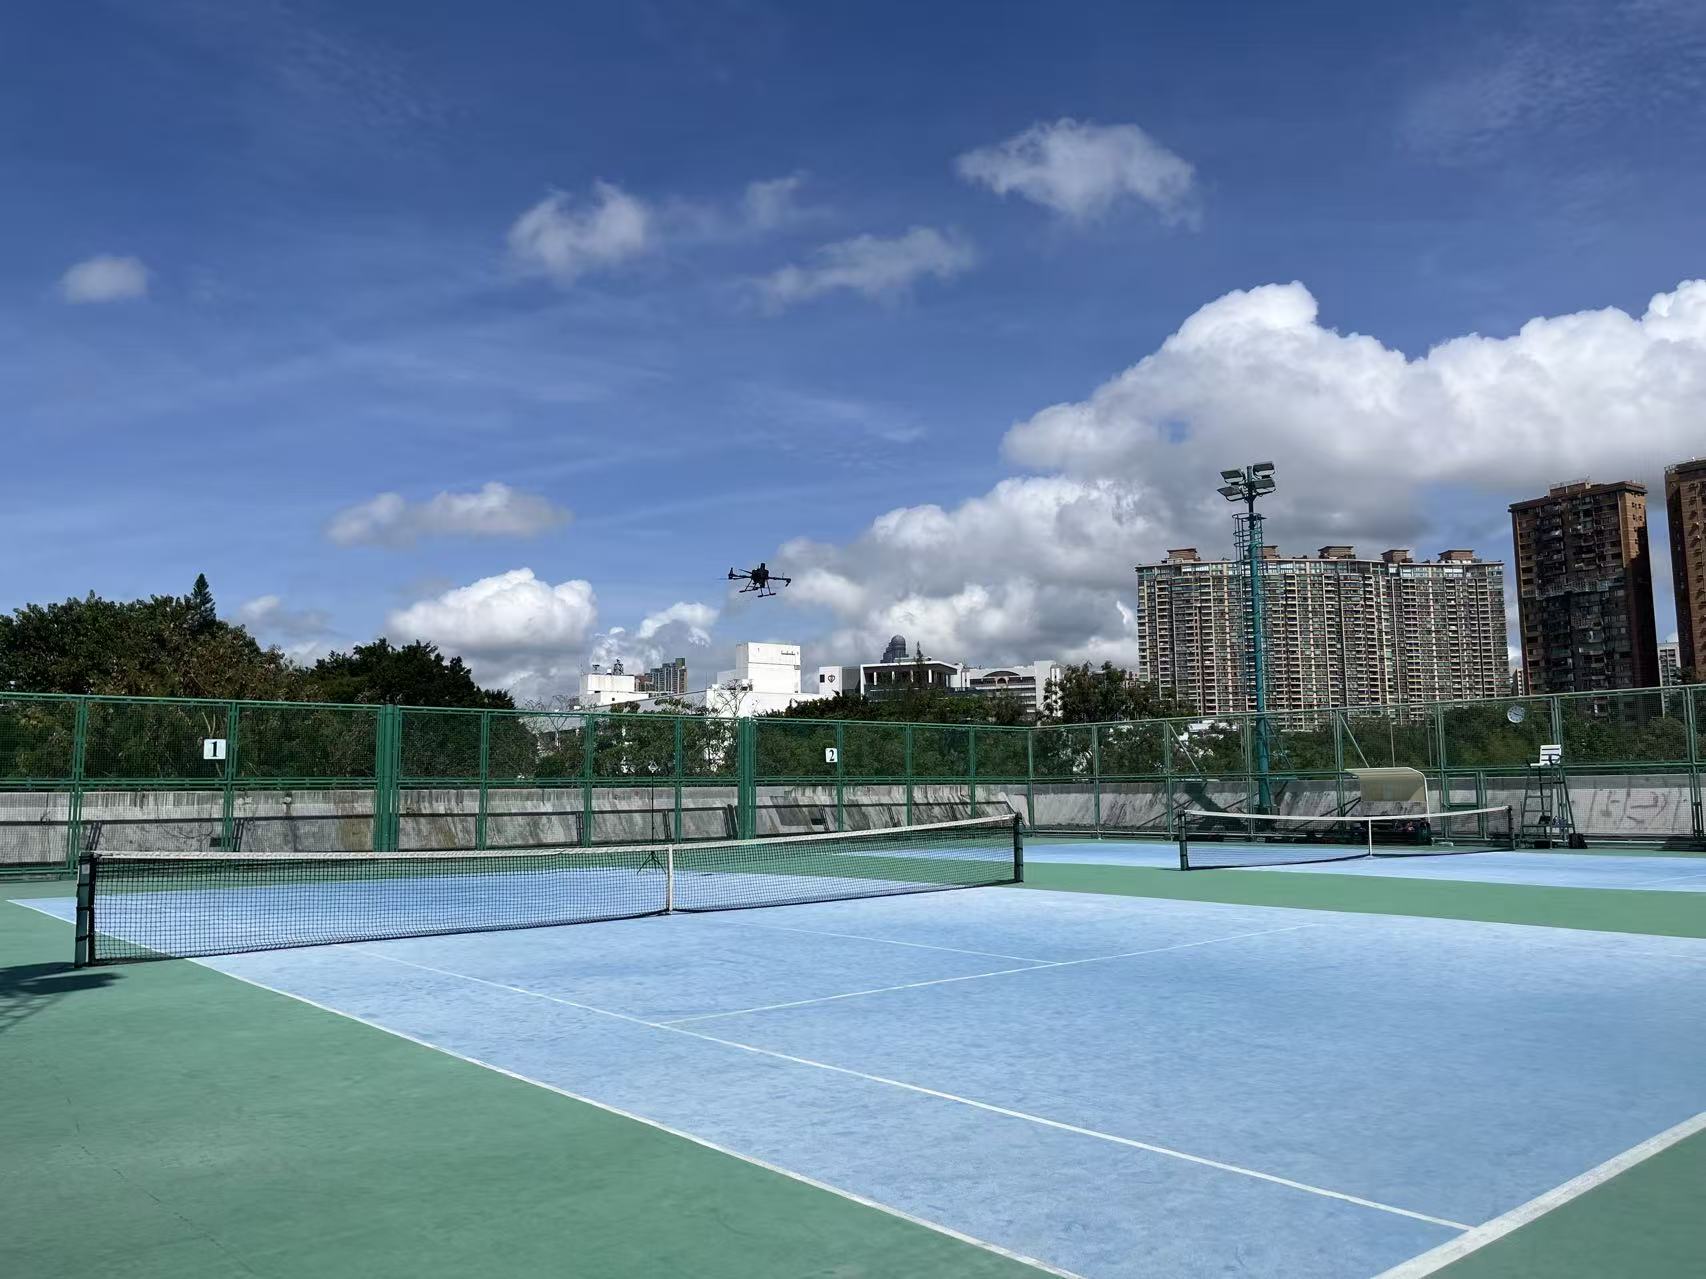
On 29 September 2025, the Department of Aeronautical and Aviation Engineering (AAE) at The Hong Kong Polytechnic University (PolyU) conducted a drone performance test flight at the Shaw Sports Complex on campus, as part of the sandbox regulatory project for the low-altitude economy (LAE). The successful test marks a new phase in PolyU AAE’s initiative to advance regulatory frameworks and operational standards for unmanned aerial vehicles (UAVs) in urban environments.
This month, Our Hong Kong Foundation (OHKF) released its latest research report, “Taking Flight — Forging a Future for Hong Kong’s Low-Altitude Economy”, an in-depth discussion of the future development of Hong Kong’s low-altitude economy (LAE). The Trustworthy AI and Autonomous Systems Laboratory (TASLAB) was one of the teams supporting the report.
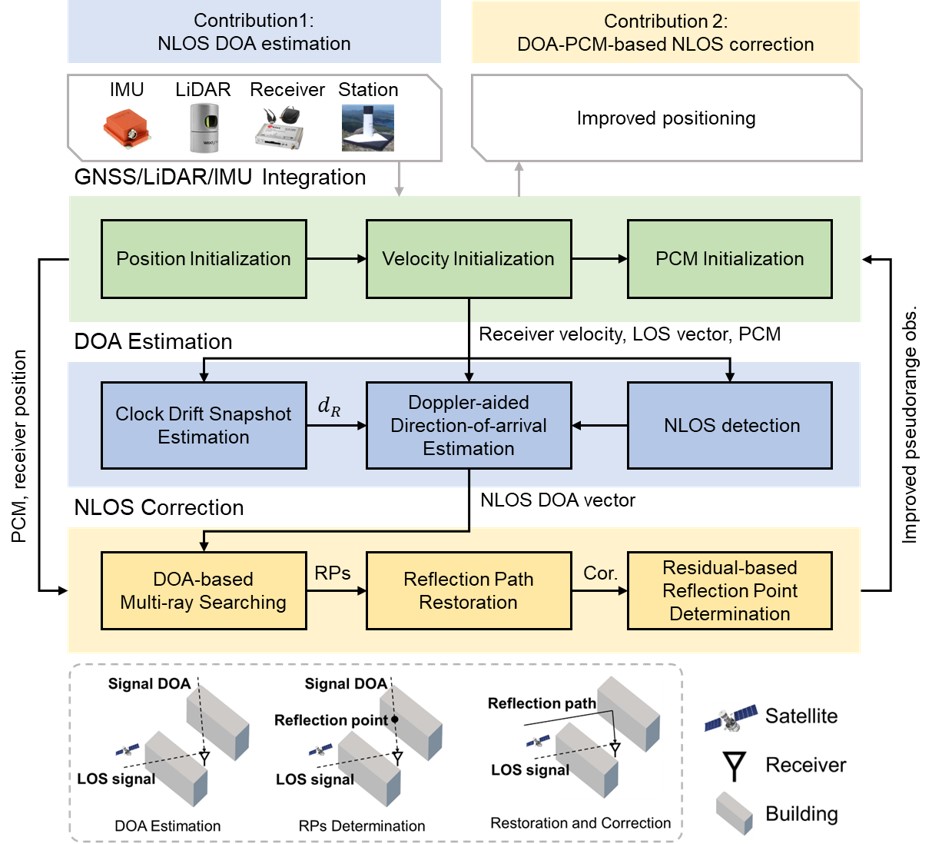
The paper “3D LiDAR Aided GNSS NLOS Correction by Direction-of-Arrival Estimation Using Doppler Measurements in Urban Canyons”, by Xikun Liu, Weisong Wen, Liyuan Zhang and Li-Ta Hsu of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB), has been accepted by the IEEE Transactions on Intelligent Transportation Systems. Congratulations to Xikun and the co-authors.
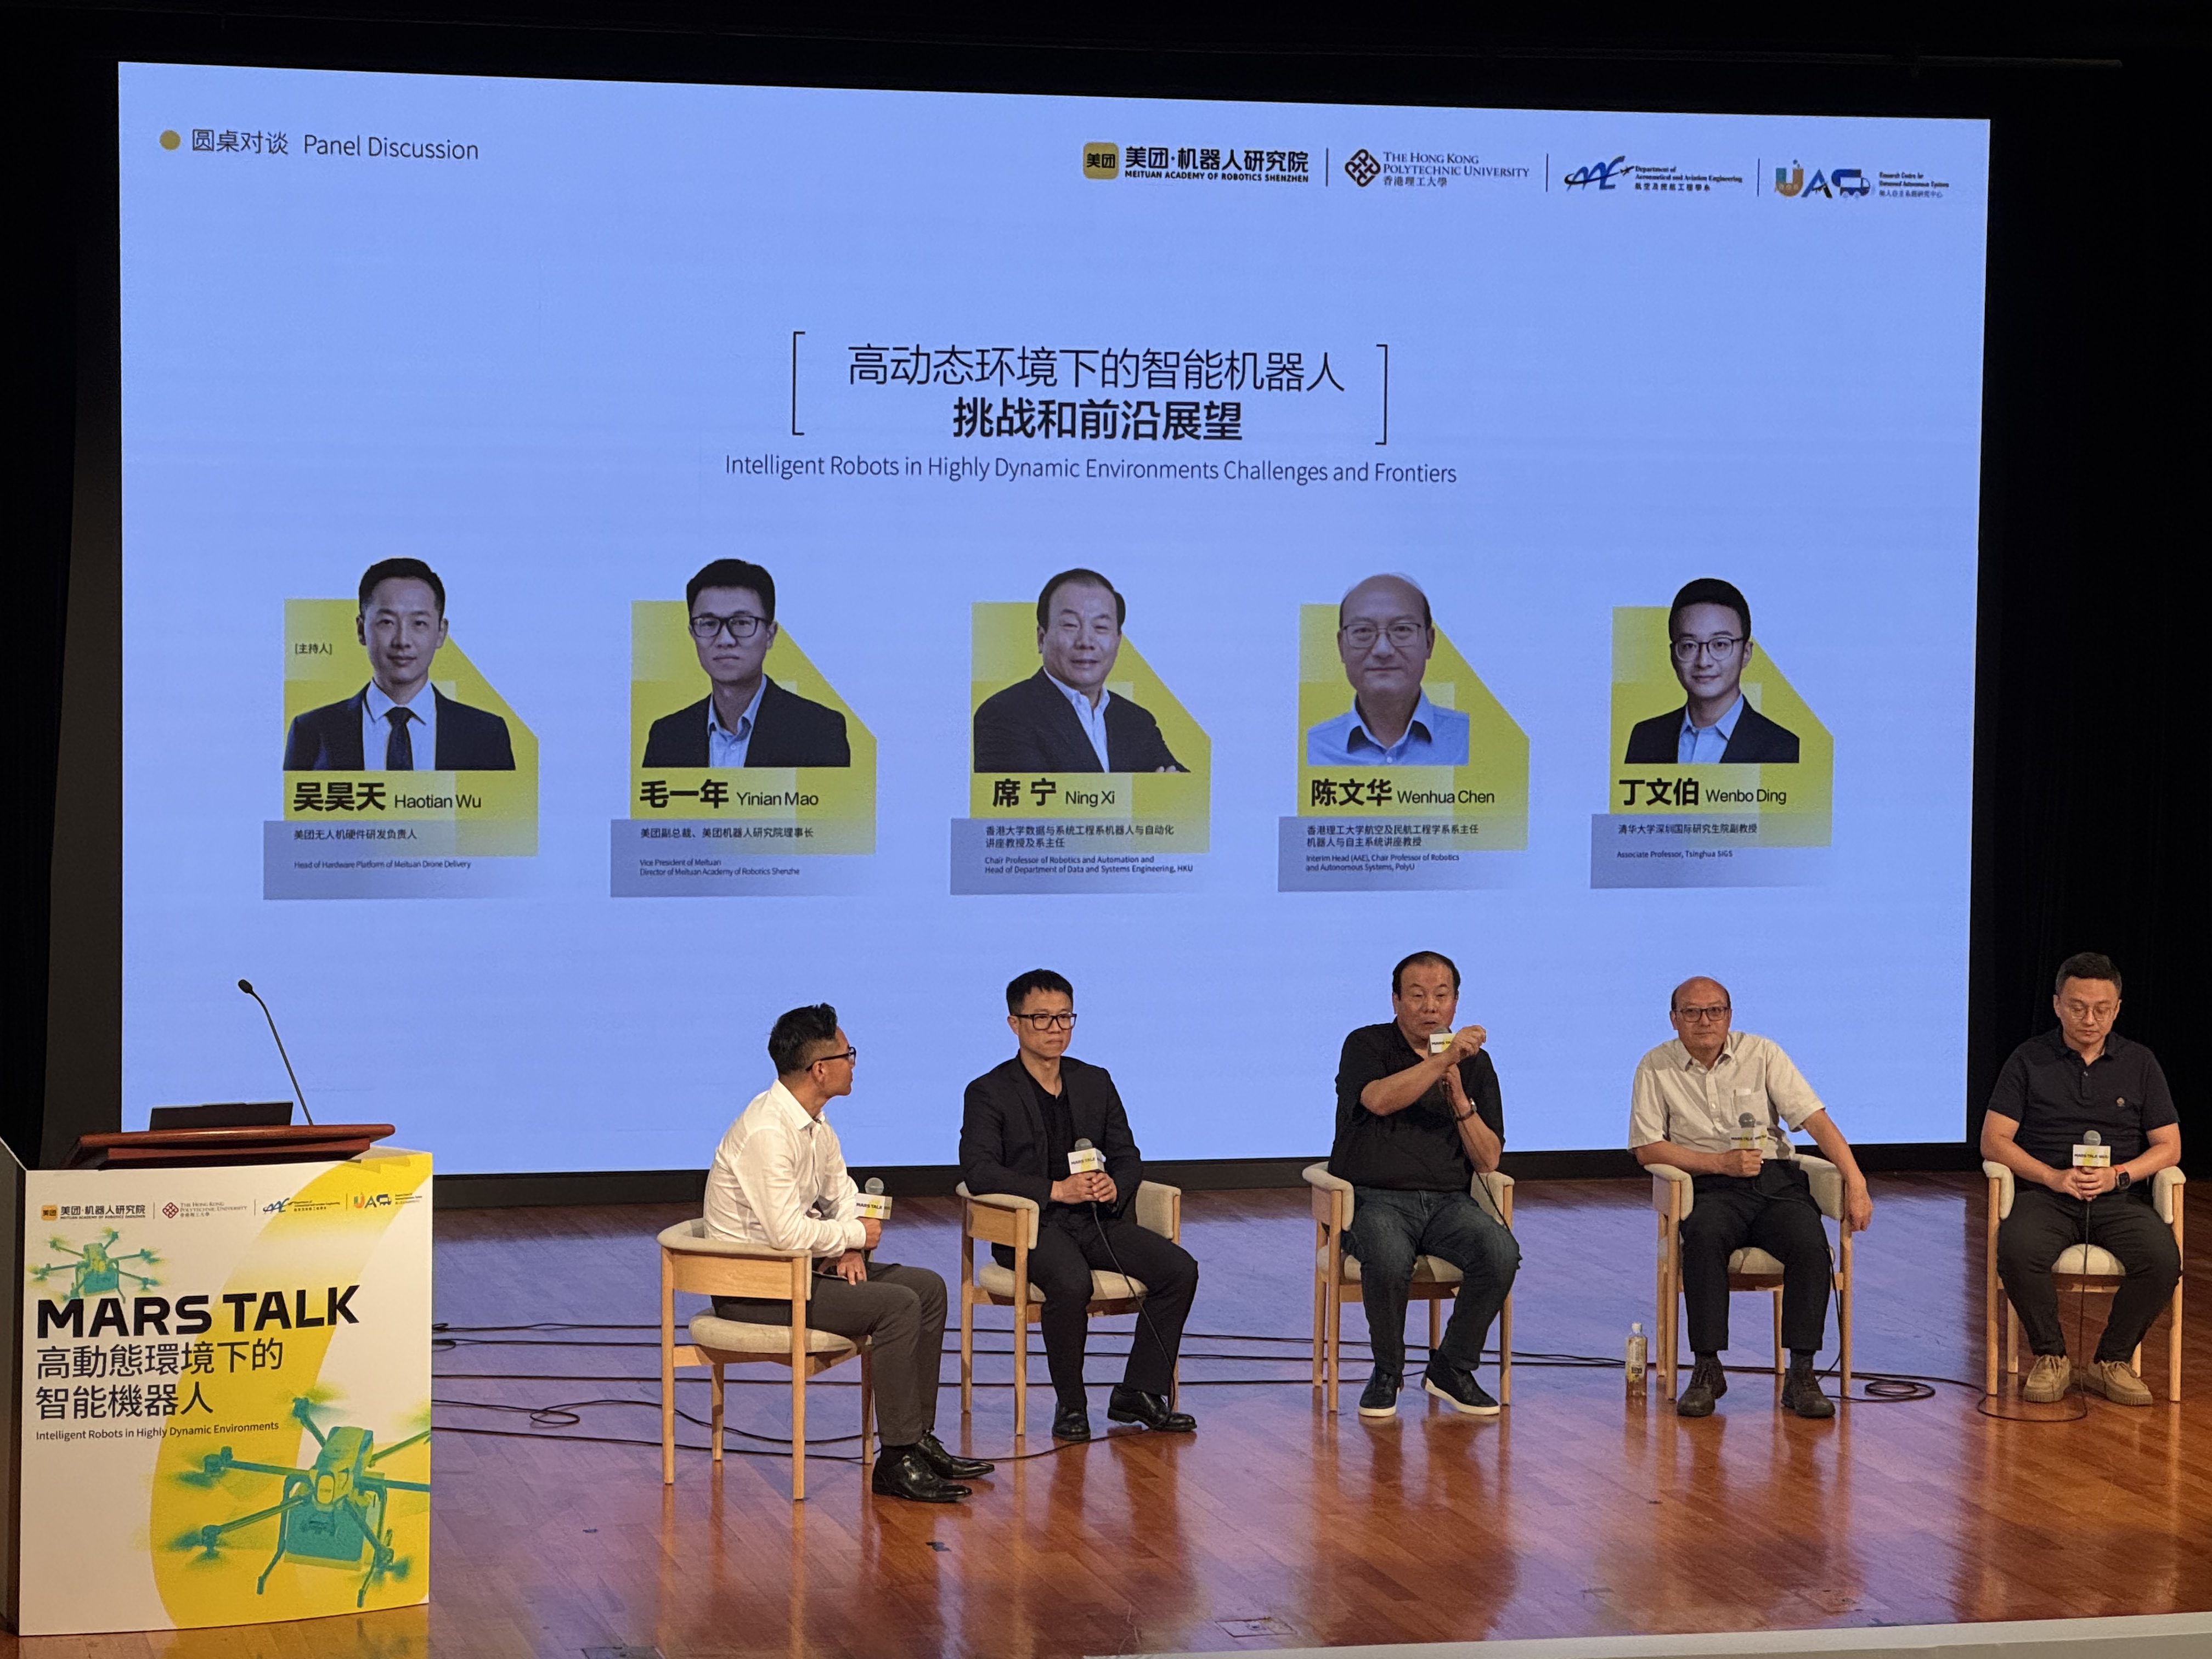
Hong Kong, 14 September 2025 – The Hong Kong Polytechnic University (PolyU) hosted the Meituan MarsTalk, bringing together leading experts in robotics, automation and artificial intelligence to explore technological breakthroughs in intelligent systems for dynamic environments.
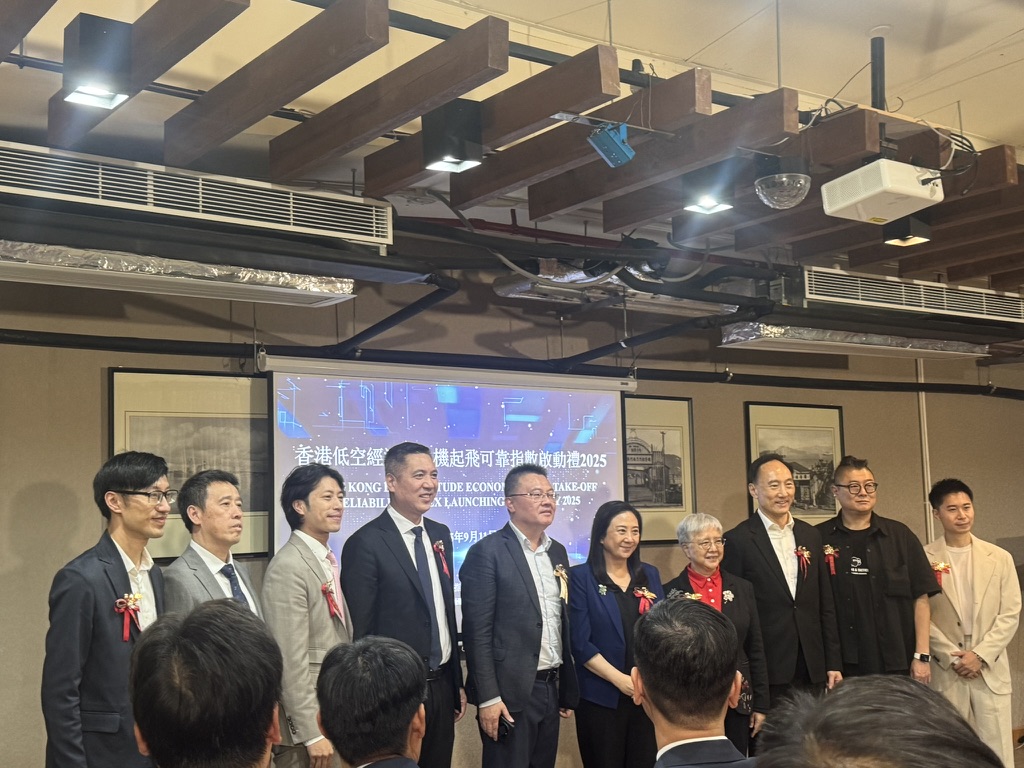
Hong Kong, 11 September 2025 – The Hong Kong Low Altitude Economy Drone Take-off Reliability Index (DTORI) was officially launched today at a ceremony attended by government officials, industry leaders and academic experts. The initiative, introduced by the Hong Kong Innovative Smart Applications Association (HKISA), aims to standardise and enhance the safety and operational reliability of drones across the city’s rapidly expanding low-altitude economy (LAE).
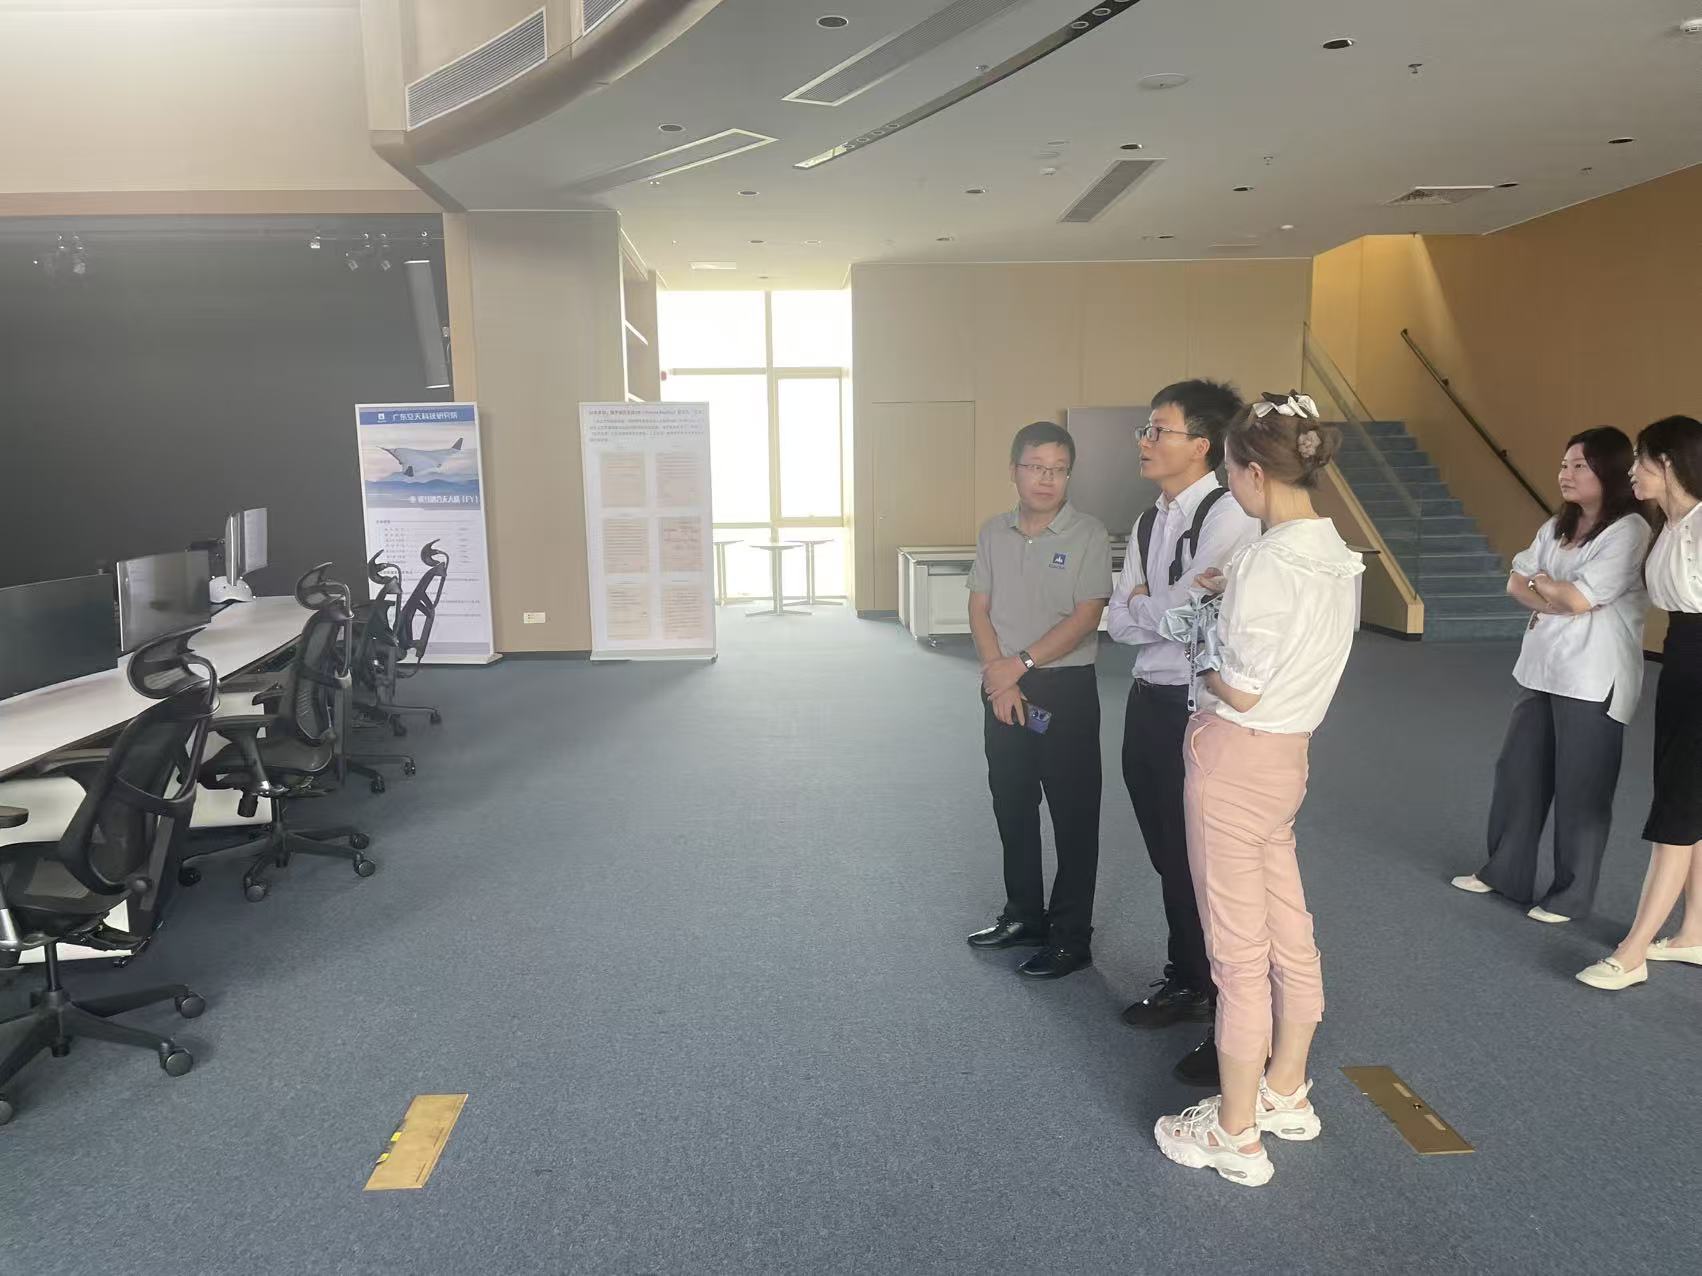
On 21 August 2025 in Guangzhou, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB), the Guangzhou Aerospace Science and Technology Research Institute (GASTI) and Sunwah InnoHub held an in-depth exchange forum. The parties held extensive discussions on industry-academia-research collaboration in fields such as the low-altitude economy (LAE) and drone technology.
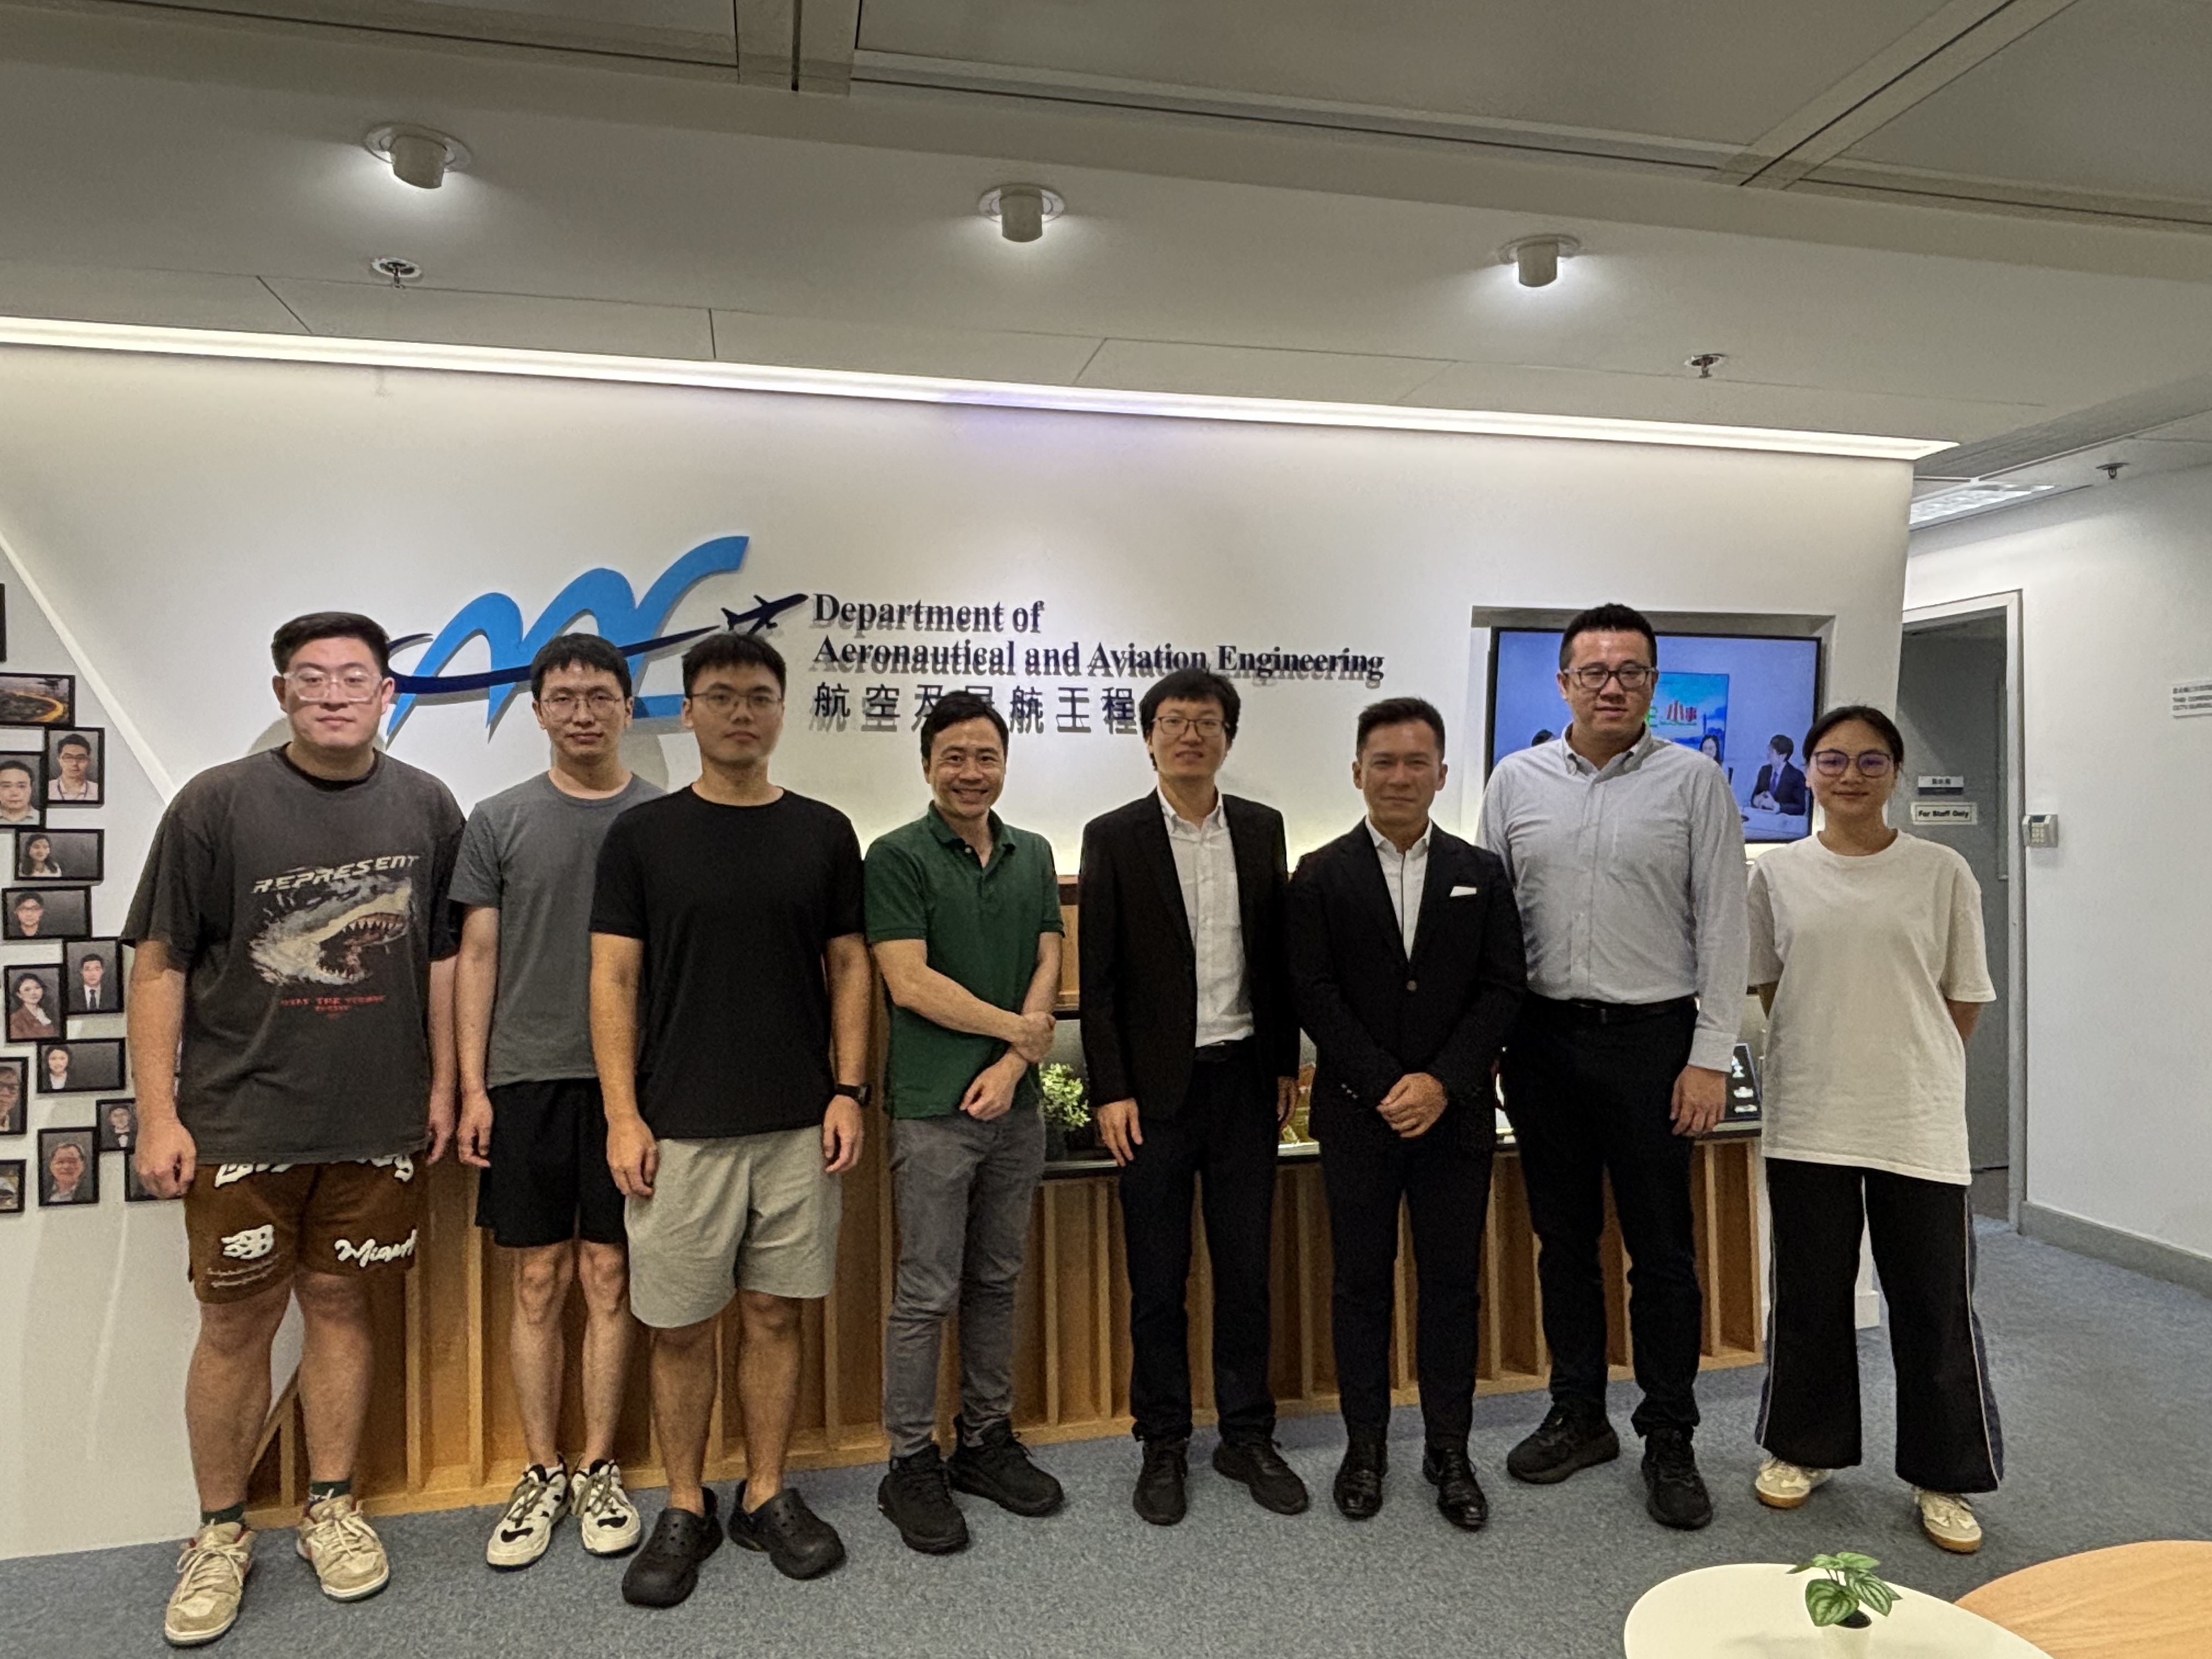
On 15 July 2025, a delegation from MTR Corporation, consisting of Ir. Prof. Lawrence Poon, Mr. Kody Lee and Mr. Henry Cheung, met with researchers at the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) in Hong Kong to explore potential technology partnerships.
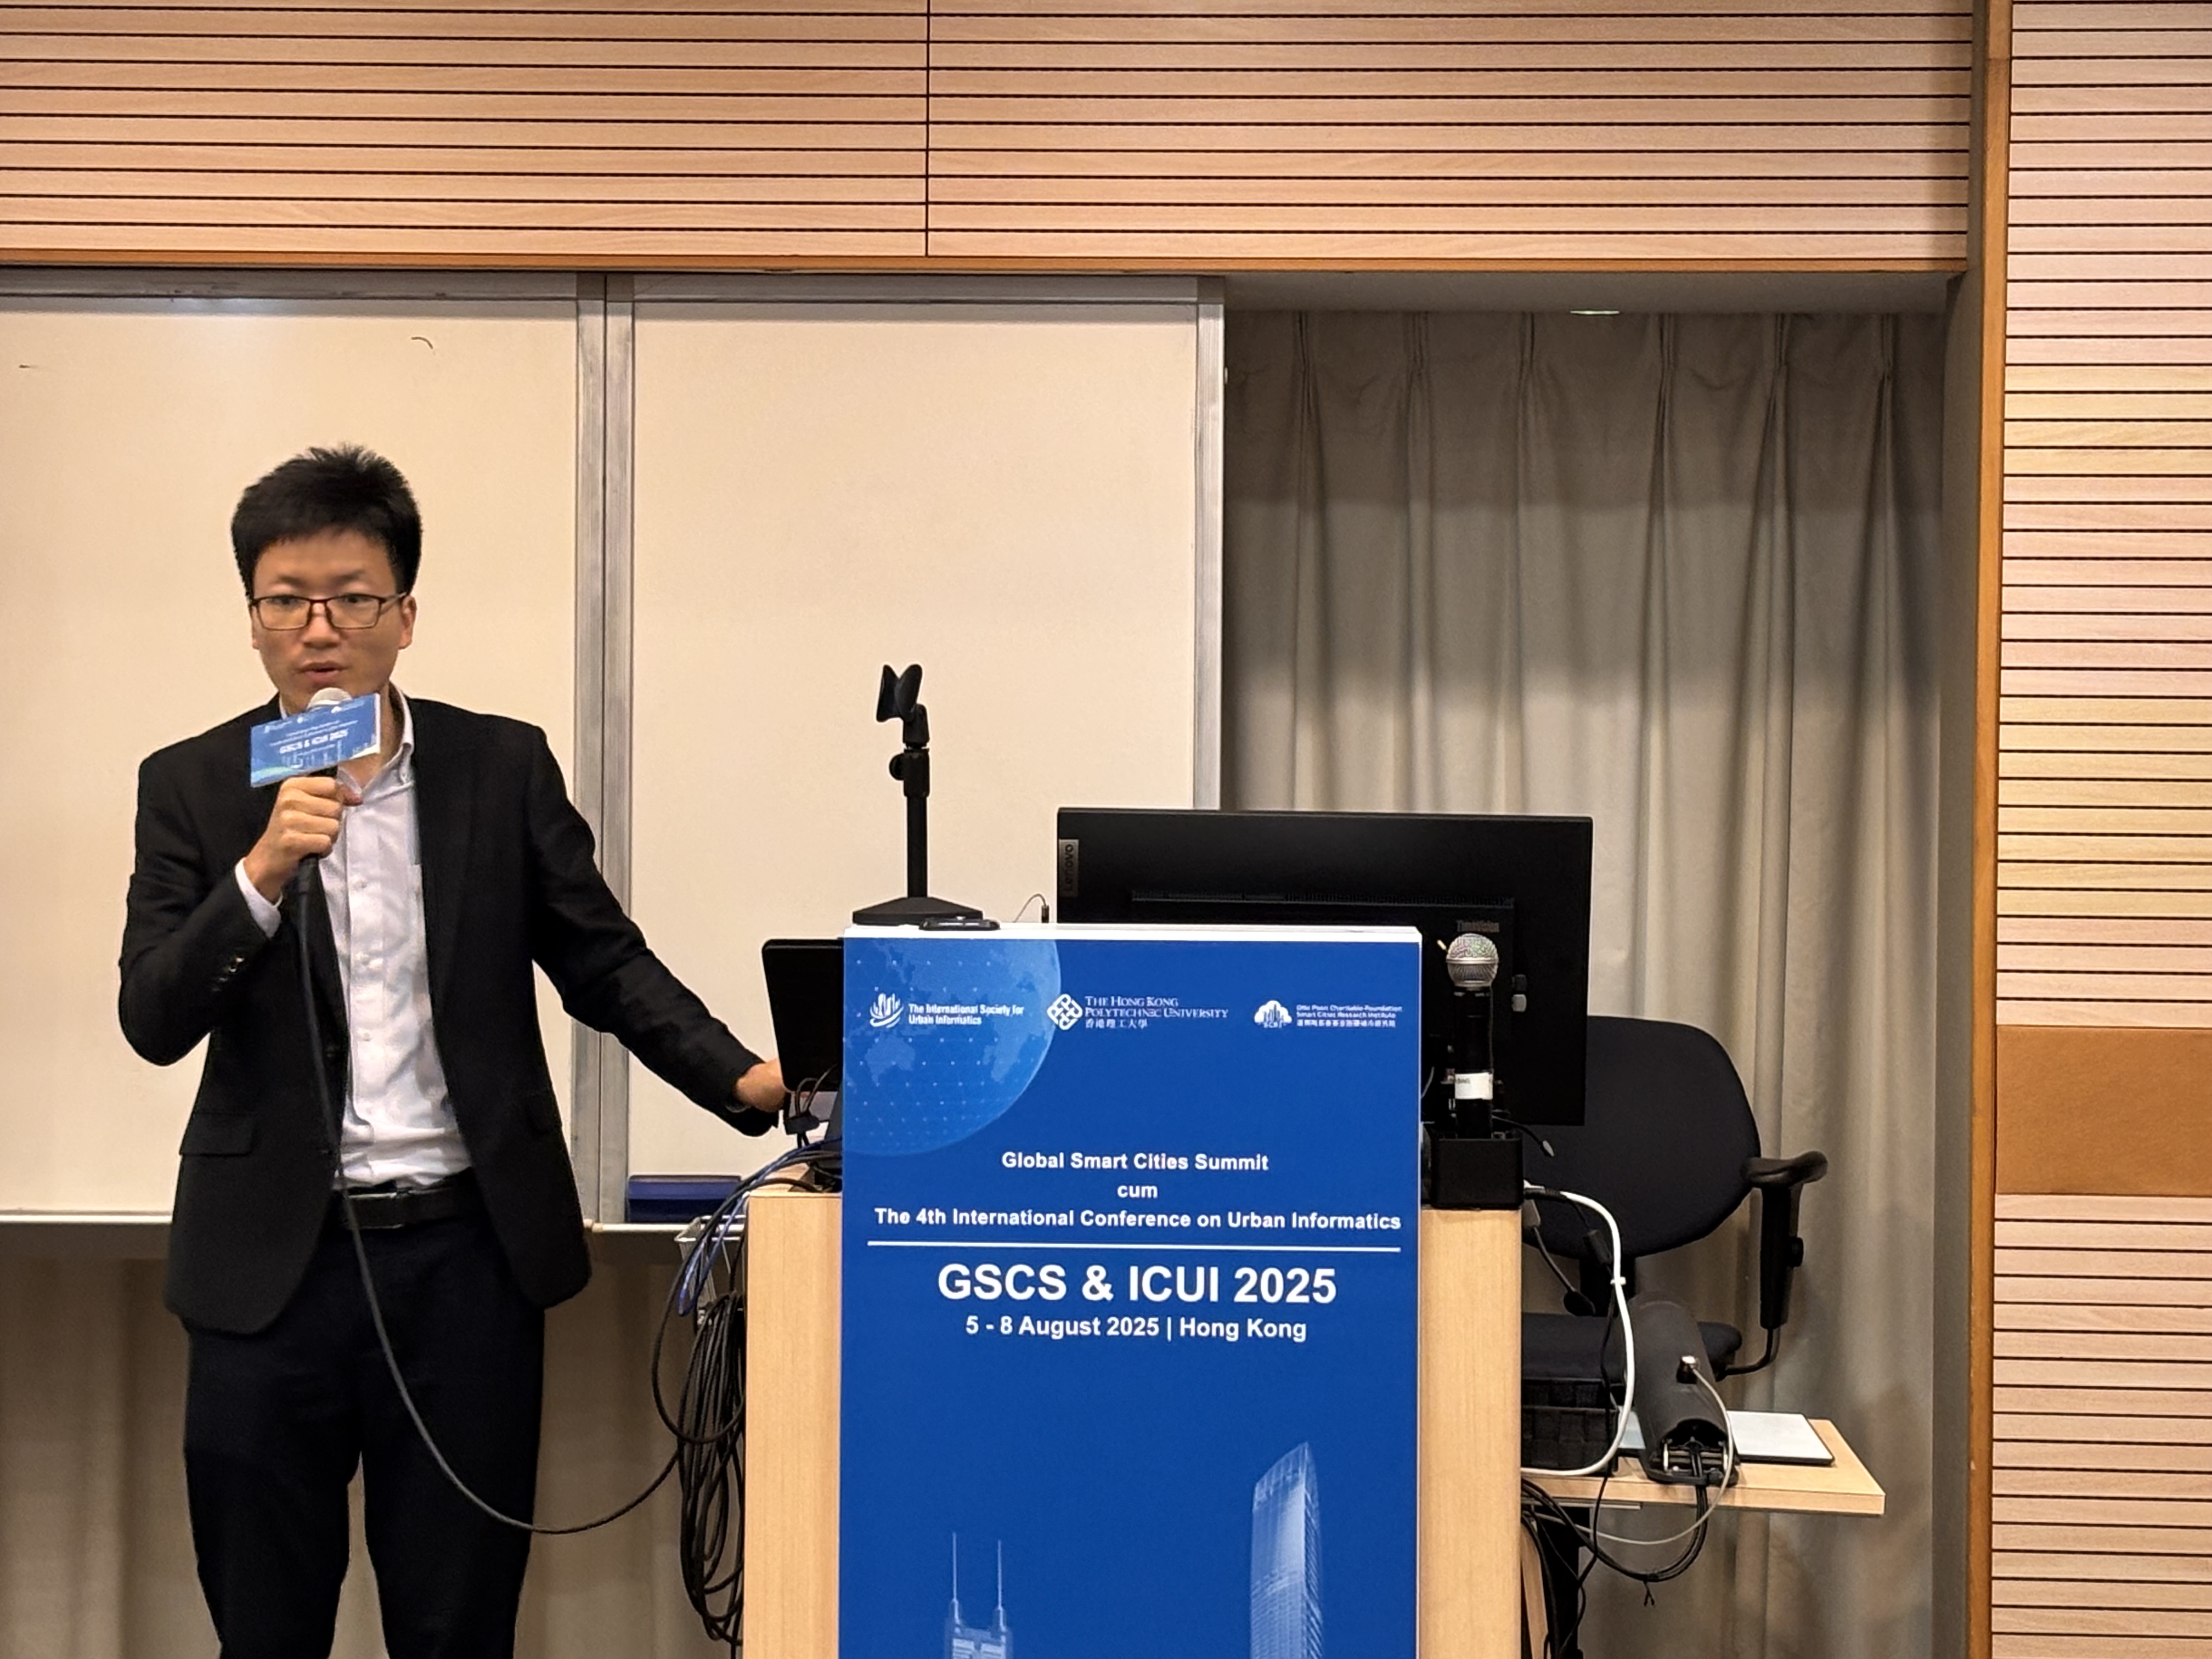
On 7 August 2025, with the help of Prof. Wen, PhD student Ruijie Xu and Dr. Feng Huang organised the special session “Urban Navigation and Sensing for Next-Generation Smart Cities” at the Global Smart Cities Summit cum The 4th International Conference on Urban Informatics (GSCS & ICUI 2025). The session explored advances in urban navigation and sensing, addressing the challenges of accurate localization, seamless mobility and intelligent sensing in increasingly complex urban environments.
On 15 July 2025, a delegation from MTR Corporation, consisting of Ir. Prof. Lawrence Poon, Mr. Kody Lee and Mr. Henry Cheung, met researchers at the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) in Hong Kong to explore potential technology partnerships.
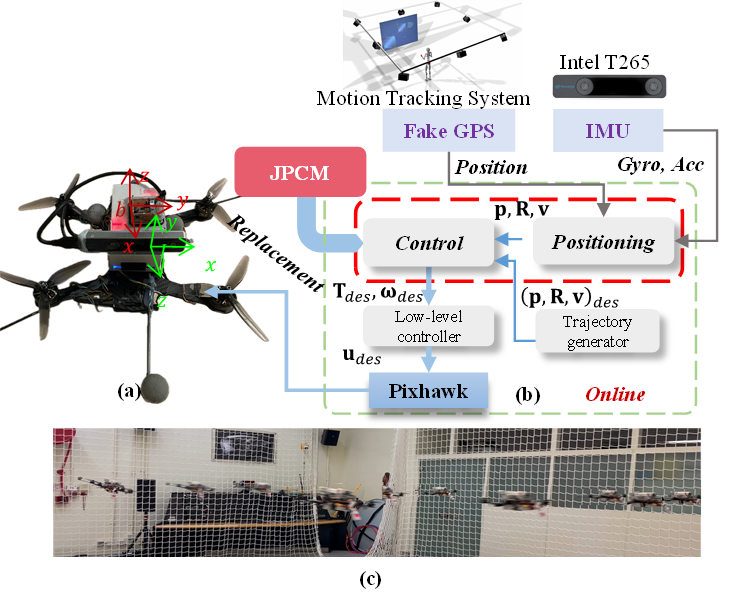
The paper “Tightly Joined Positioning and Control Model for Unmanned Aerial Vehicles Based on Factor Graph Optimization”, by Peiwen Yang, Weisong Wen, Shiyu Bai and Li-Ta Hsu of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB), has been accepted by the IEEE Transactions on Vehicular Technology. Congratulations to Peiwen and the co-authors.
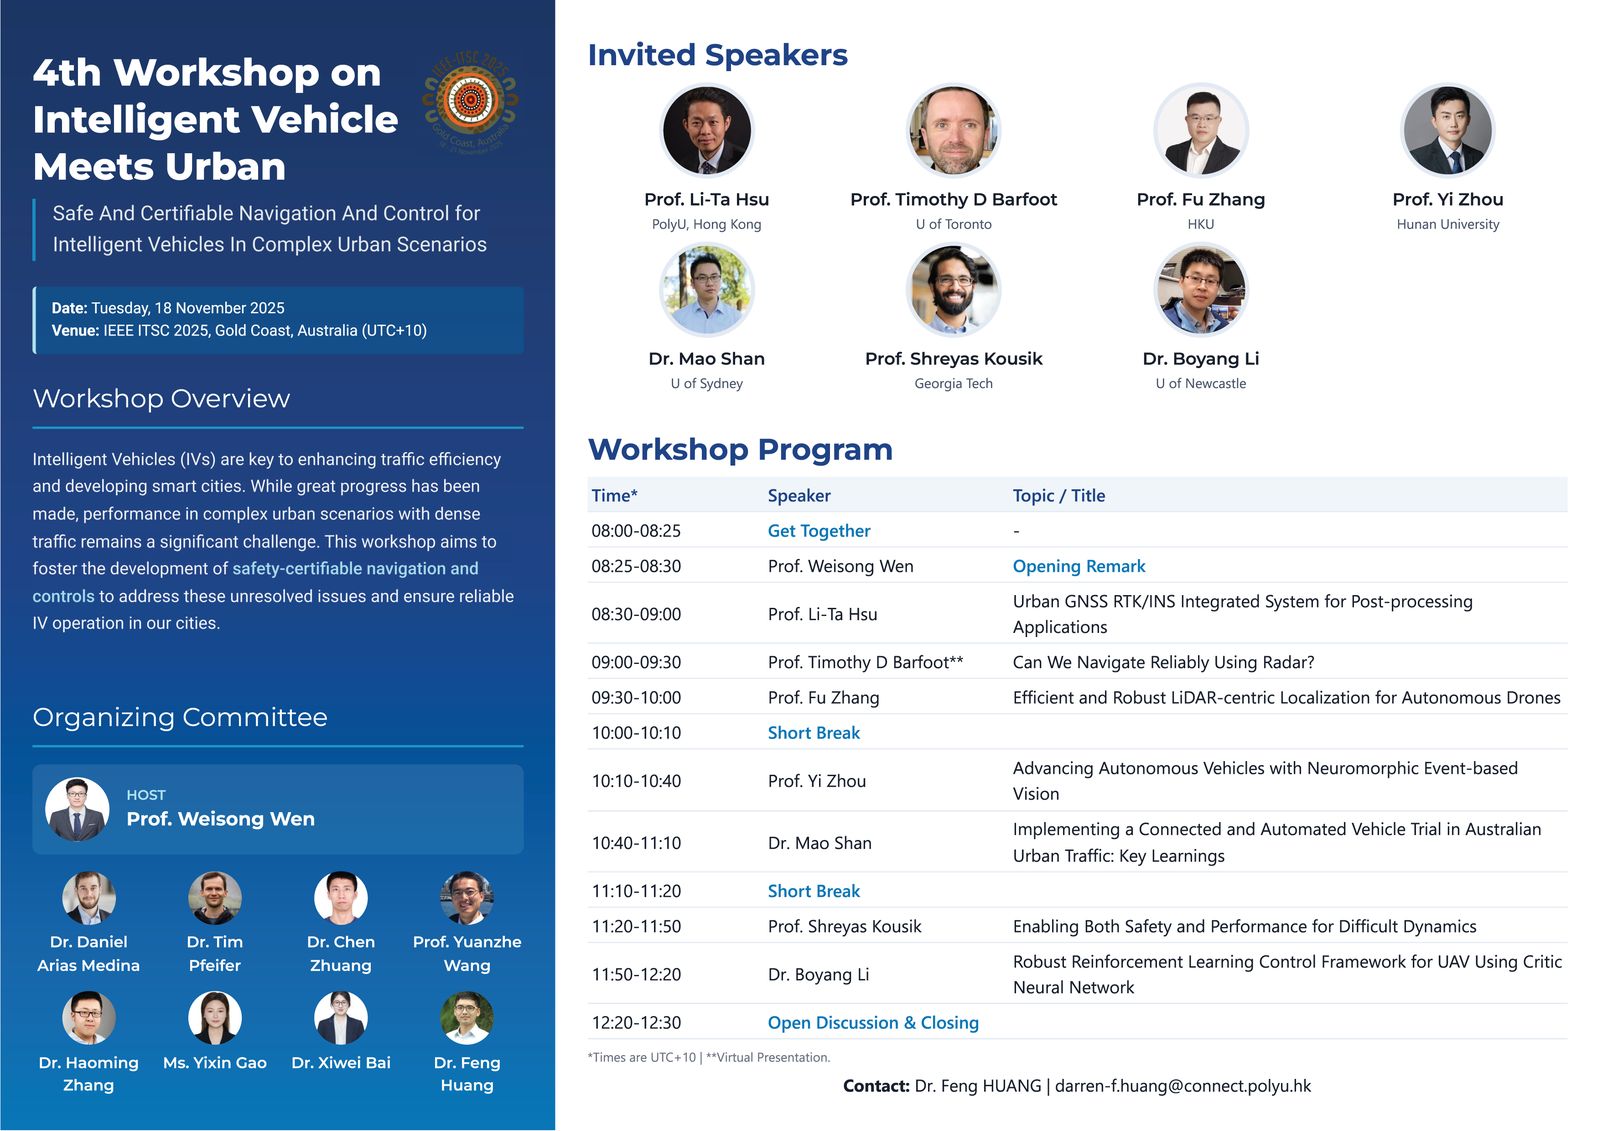
Hong Kong, 6 July 2025 – The Trustworthy AI and Autonomous Systems Laboratory (TASLAB) will have a strong presence at the upcoming 2025 IEEE 28th International Conference on Intelligent Transportation Systems (IEEE ITSC 2025), to be held on 18-21 November 2025 in Gold Coast, Australia. The conference will feature three accepted research papers and a dedicated workshop led by our research team, reflecting our commitment to advancing solutions in intelligent transportation.
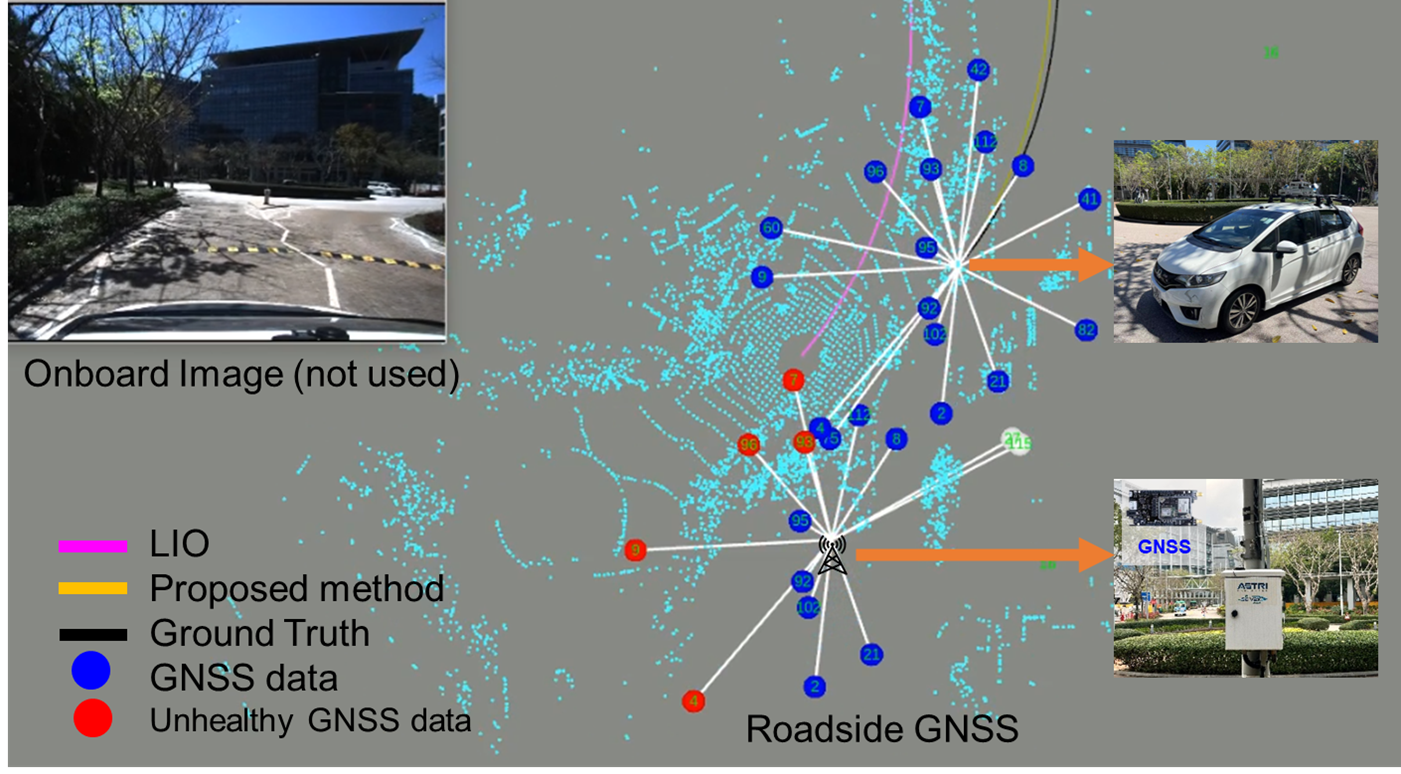
Our paper “Roadside GNSS Aided Multi-Sensor Integrated System for Vehicle Positioning in Urban Areas” by Feng Huang*, Yihan Zhong*, Hang Chen, Dongzhe Su, Jin Wu, Weisong Wen and Li-Ta Hsu has been accepted by IEEE IROS 2025. The data will be available on GitHub.
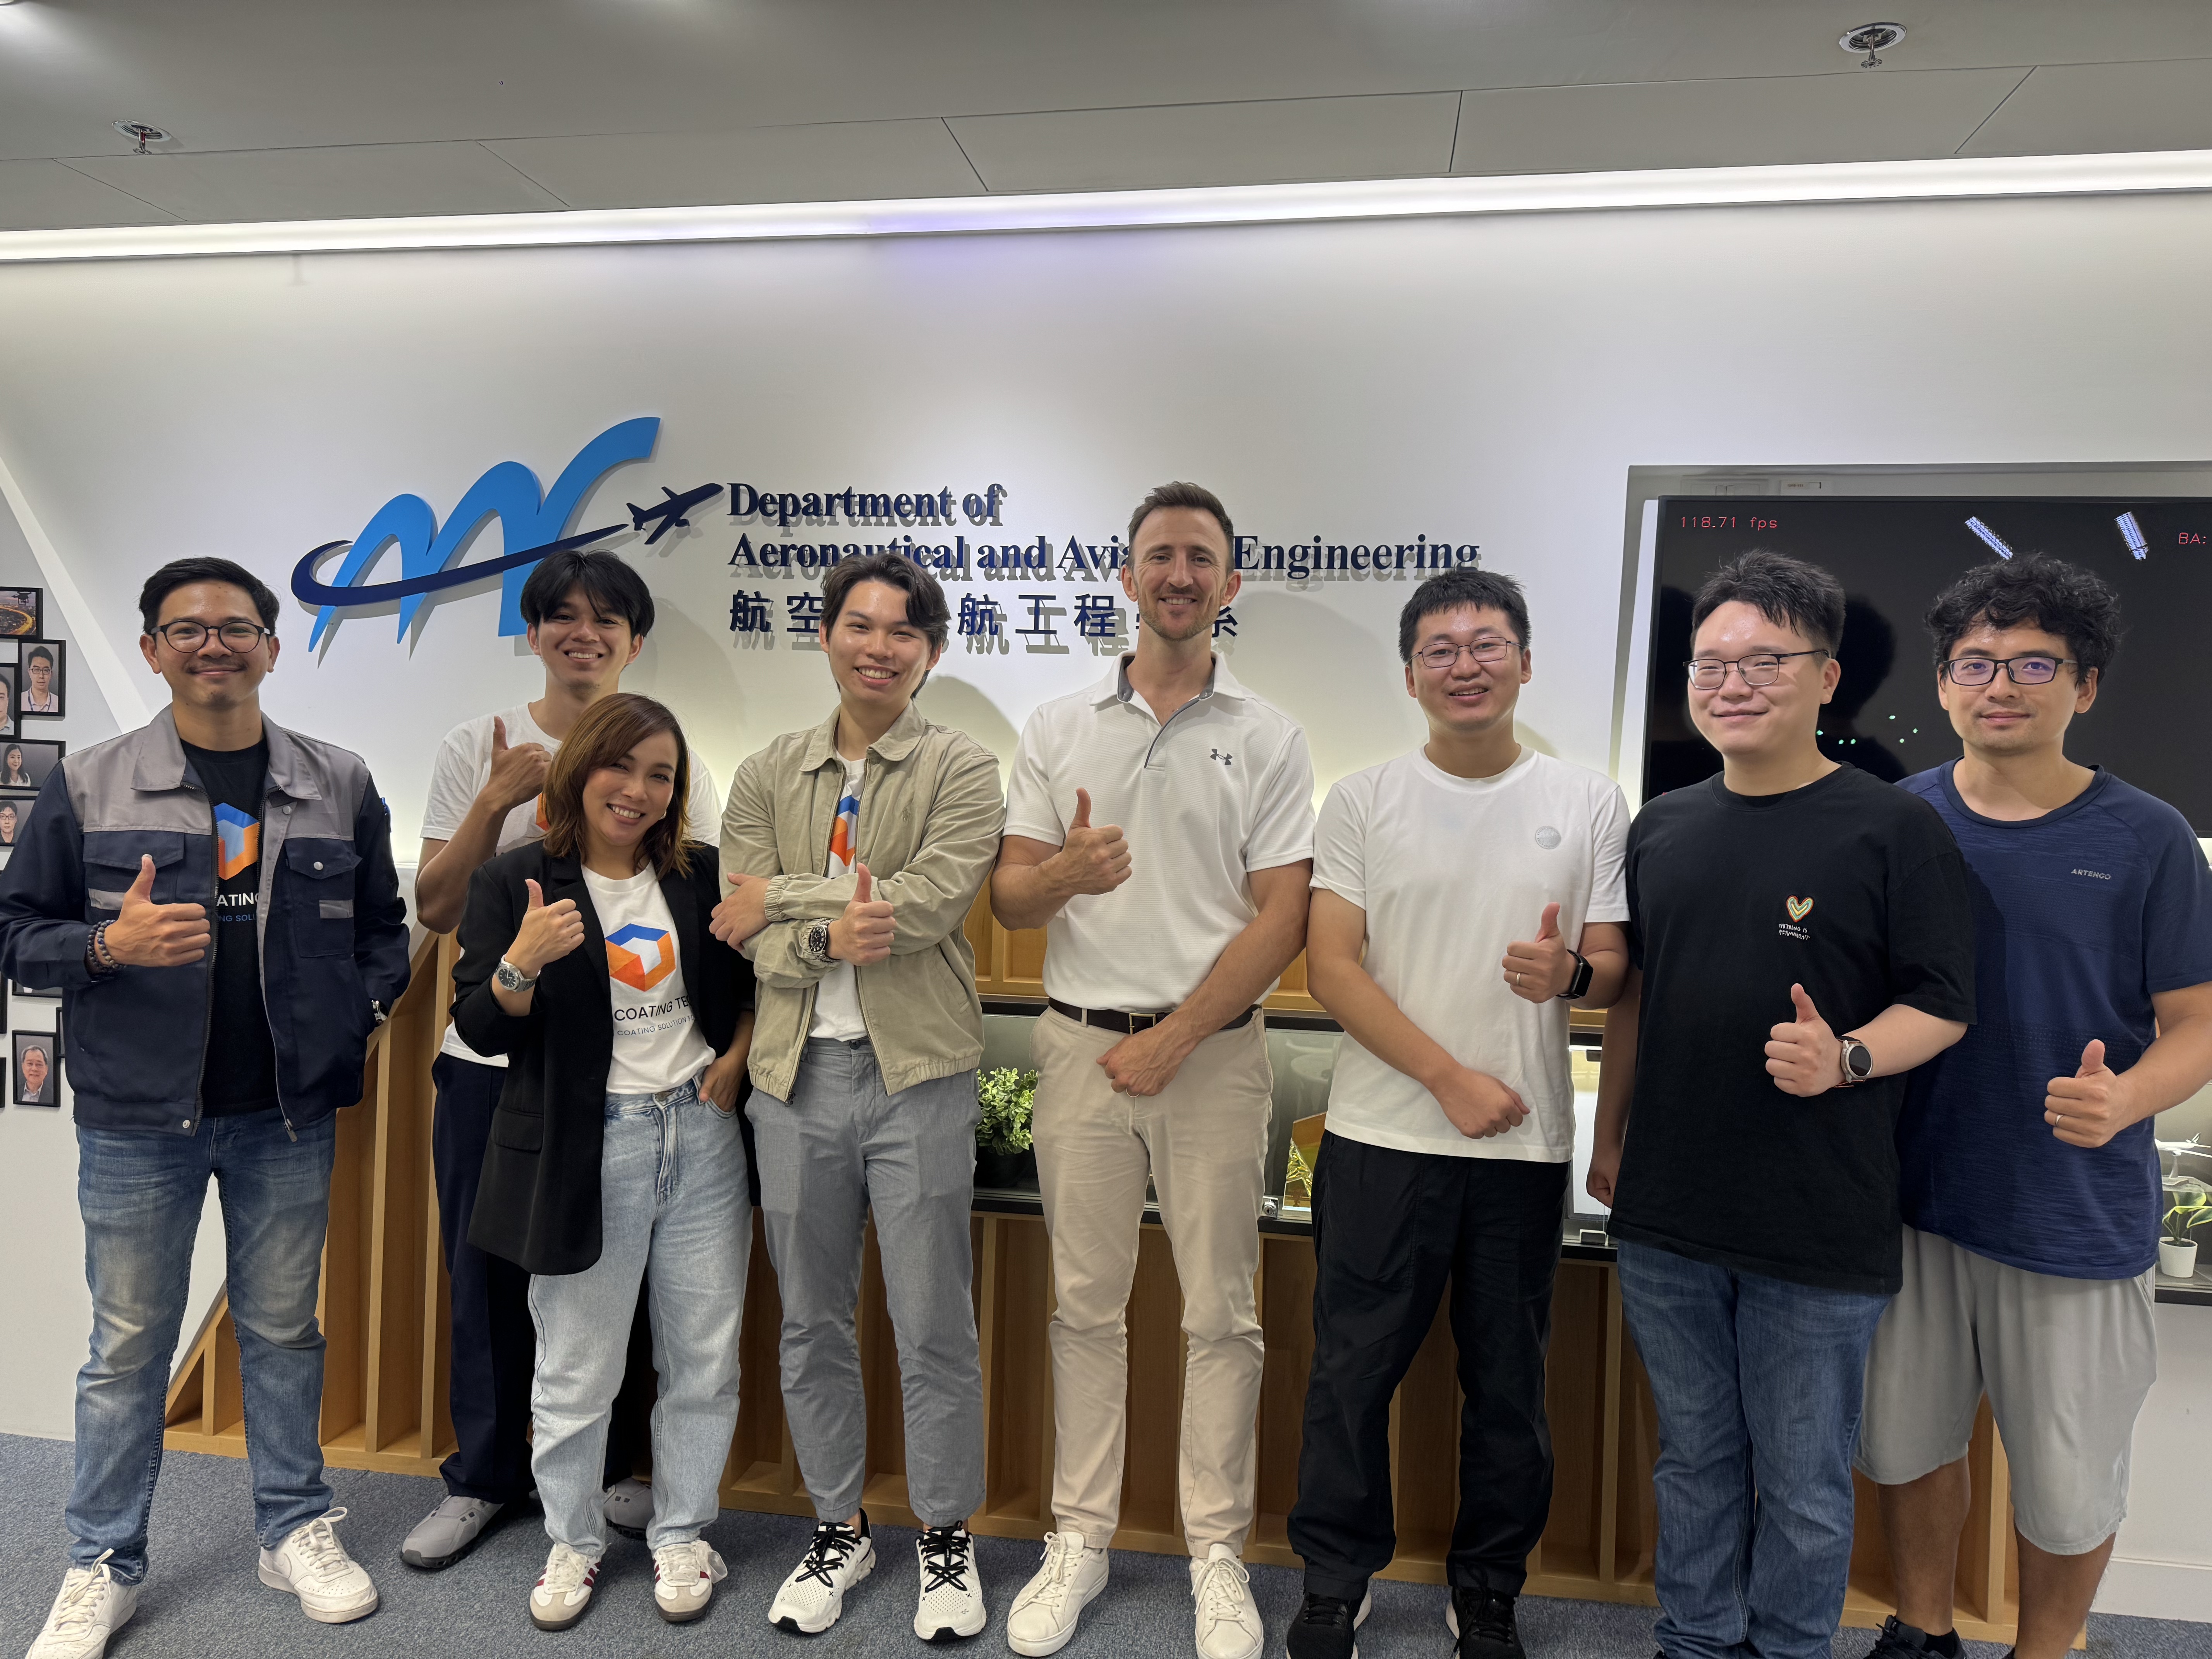
On 3 July 2025, Nano Coating Tech and DRONE SOLUTIONS ASIA visited the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) in Hong Kong. The visit aimed to explore collaboration opportunities and facilitate technical exchange in UAV technology and nano-tech applications.
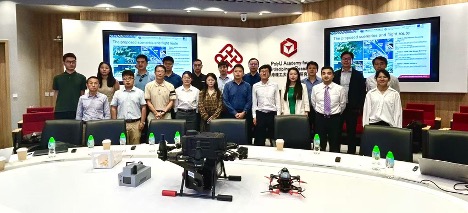
On 2 July 2025, The Hong Kong Polytechnic University (PolyU) brought together industry leaders, researchers and policymakers in Hong Kong for an LAE Sandbox Workshop and Public Seminar. The event spotlighted Hong Kong’s ambition to become a hub for drone technology and the development of the low-altitude economy (LAE).
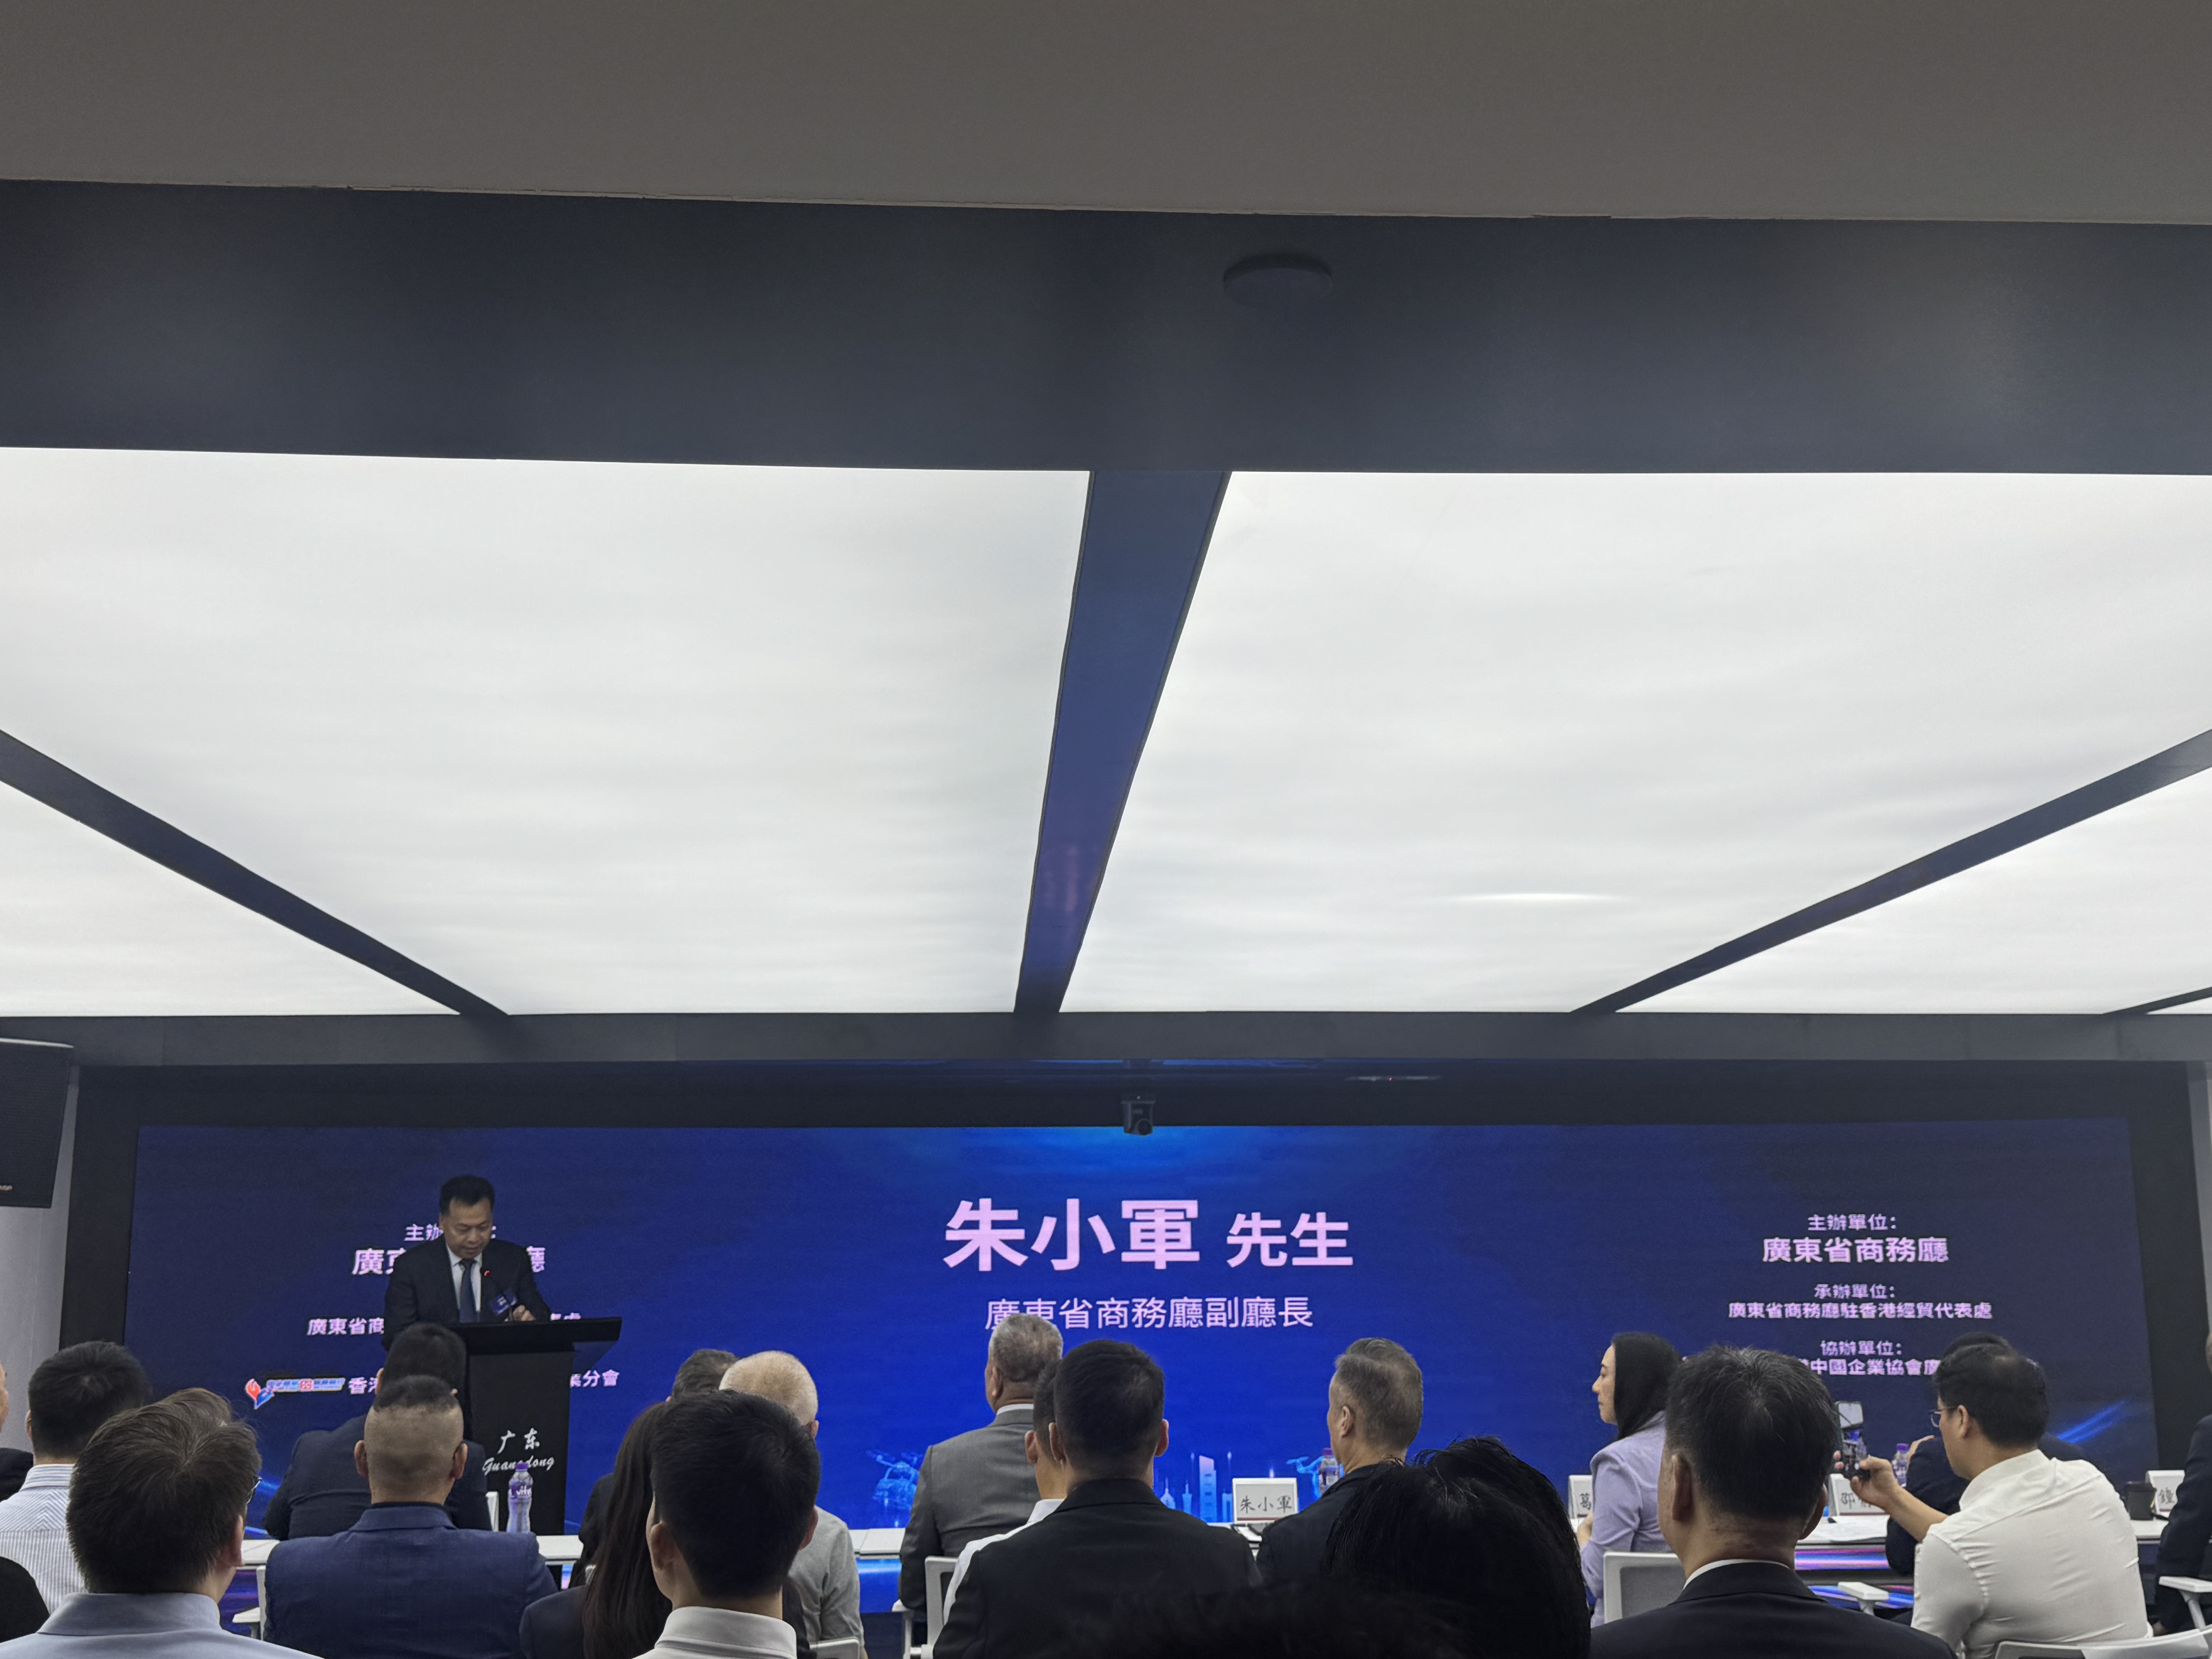
On 30 June 2025, a member of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) was invited to attend the Guangdong-Hong Kong Low-Altitude Economy Industry Exchange Conference in Hong Kong as a representative of the lab. The event, hosted by the Hong Kong Economic and Trade Office of the Guangdong Provincial Department of Commerce, brought together government officials, industry leaders and innovators to explore opportunities for collaboration in the fast-growing low-altitude economy (LAE) sector.
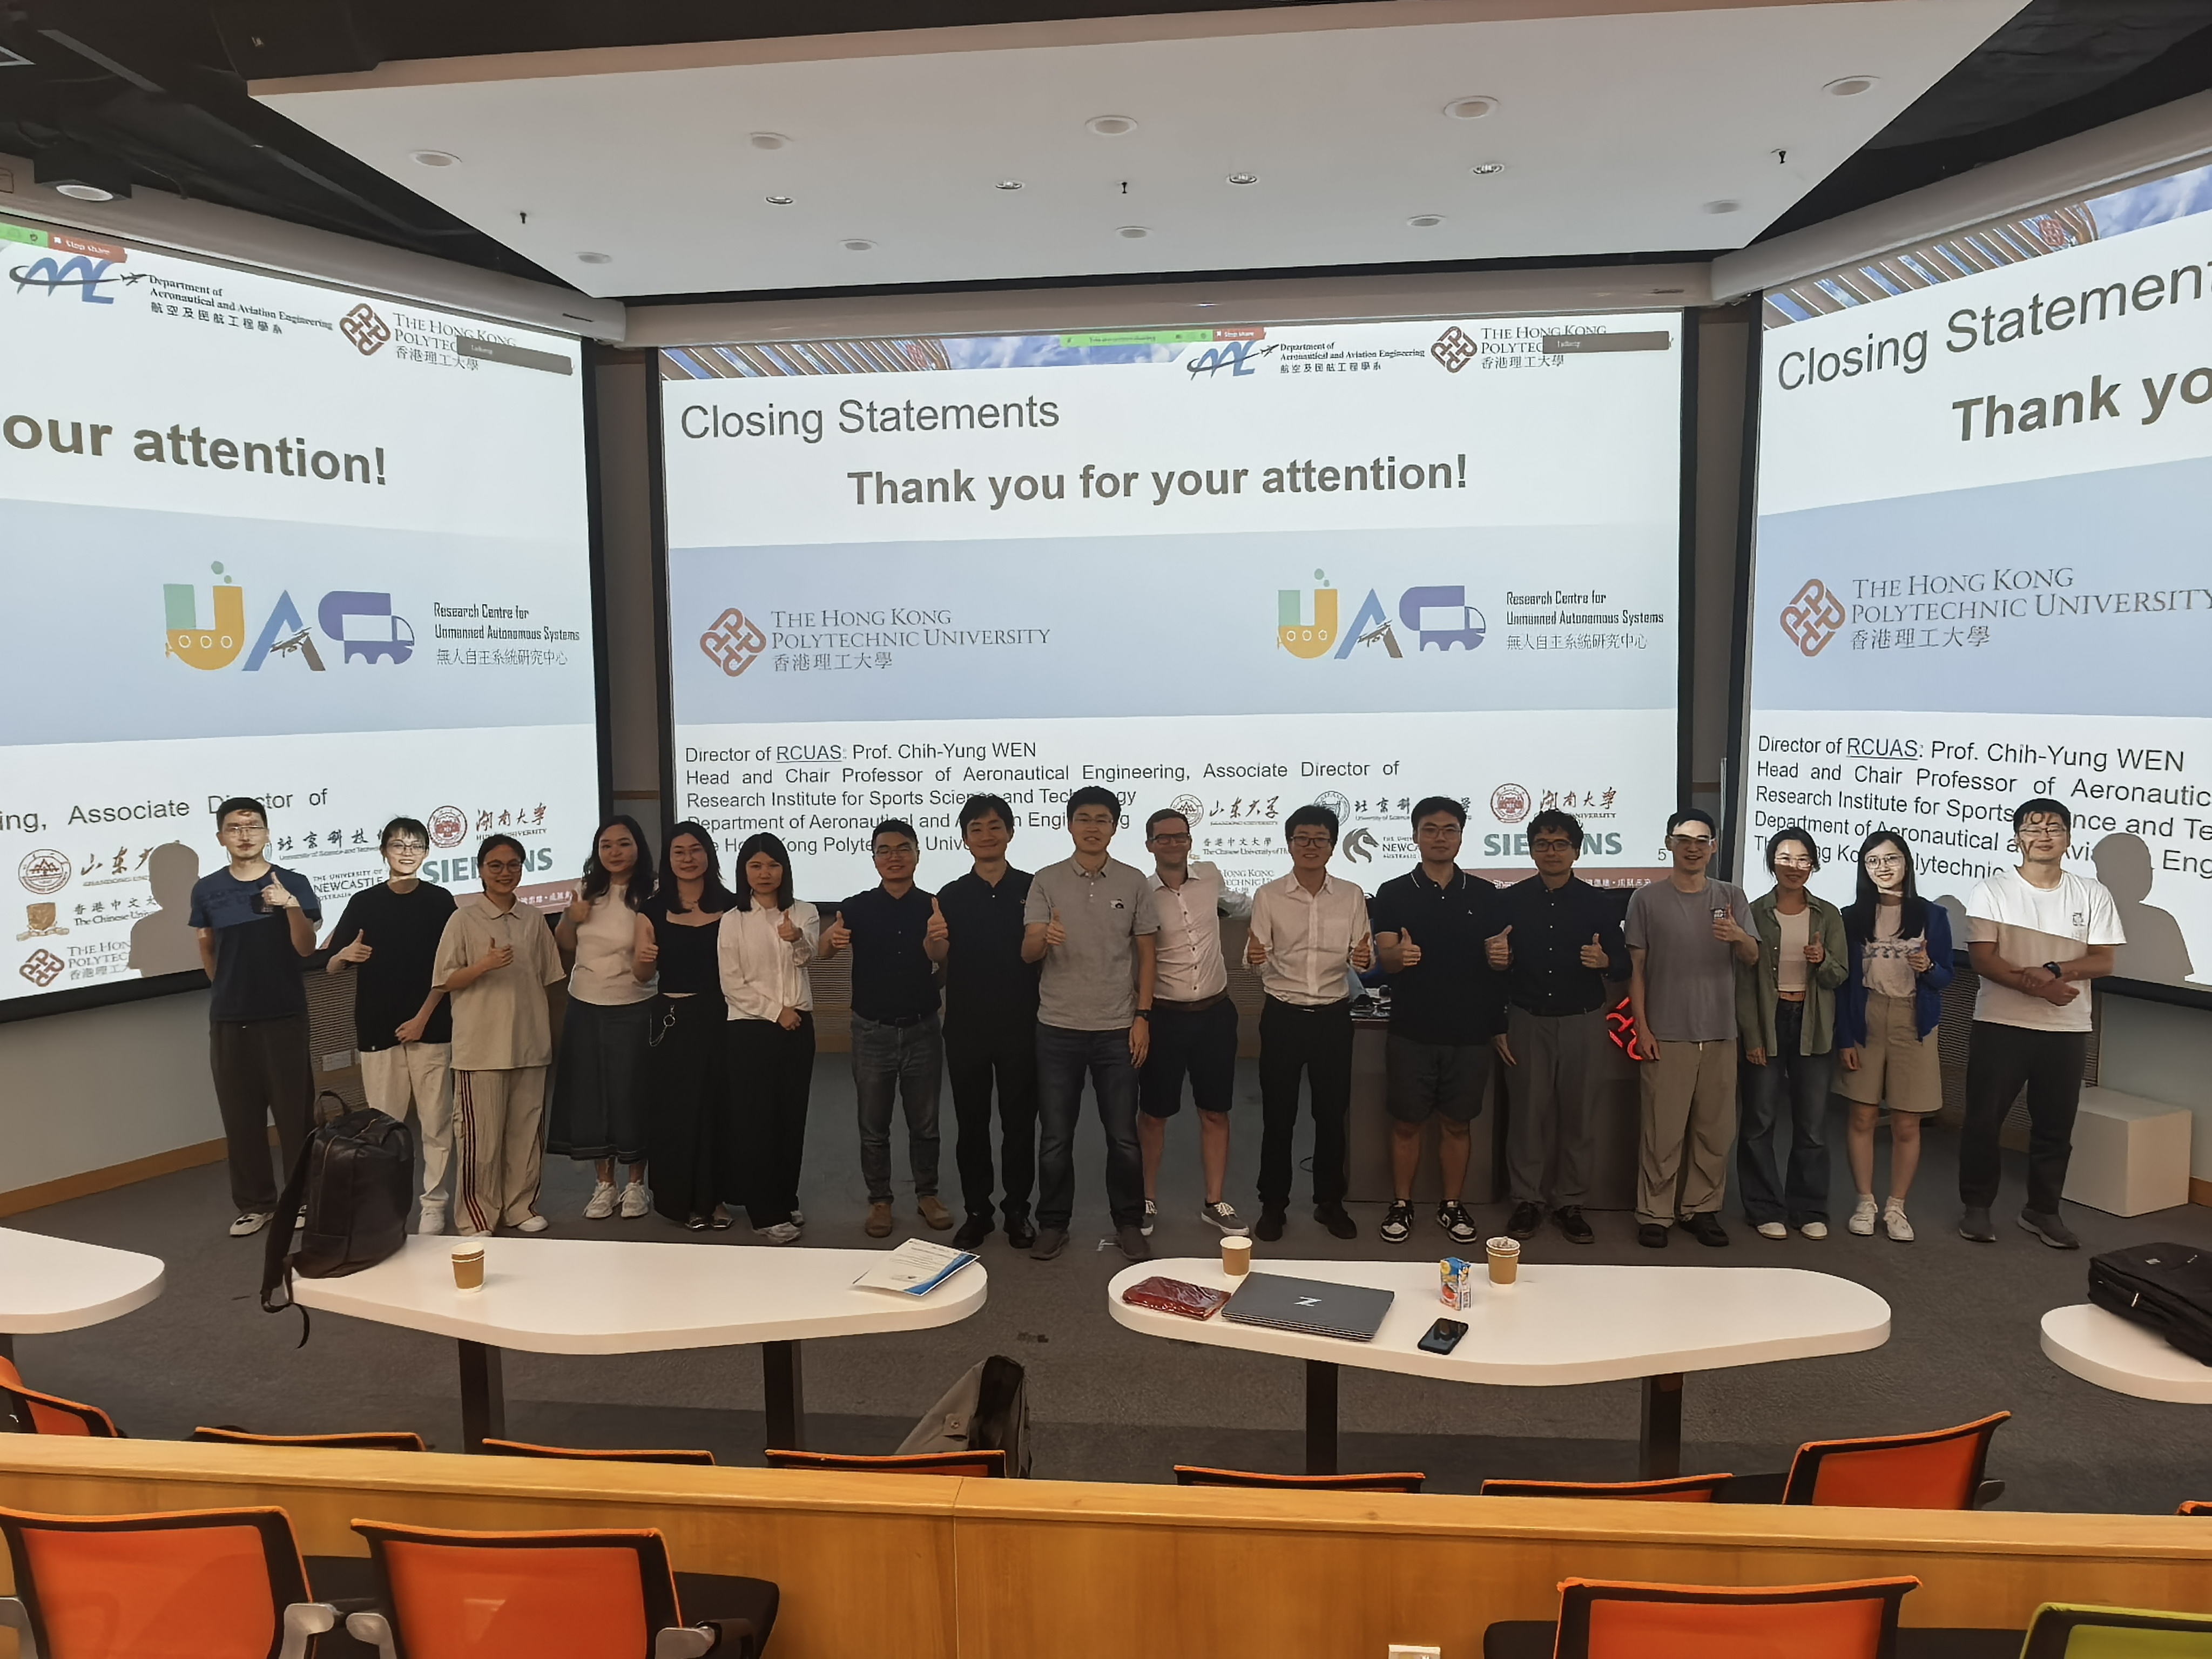
On 24 June 2025, the Research Centre for Unmanned Autonomous Systems (RCUAS) and the Department of Aeronautical and Aviation Engineering (AAE) of The Hong Kong Polytechnic University (PolyU) hosted the 1st Research Workshop of the Research Centre for Unmanned Autonomous Systems. The full-day workshop, held on the PolyU campus and broadcast online, brought together experts, scholars and industry collaborators from Hong Kong and around the world. It covered perception and navigation, multi-robot systems, embodied intelligence, large language models and trustworthy AI, with in-depth discussions on the latest research progress, technological breakthroughs and real-world applications.
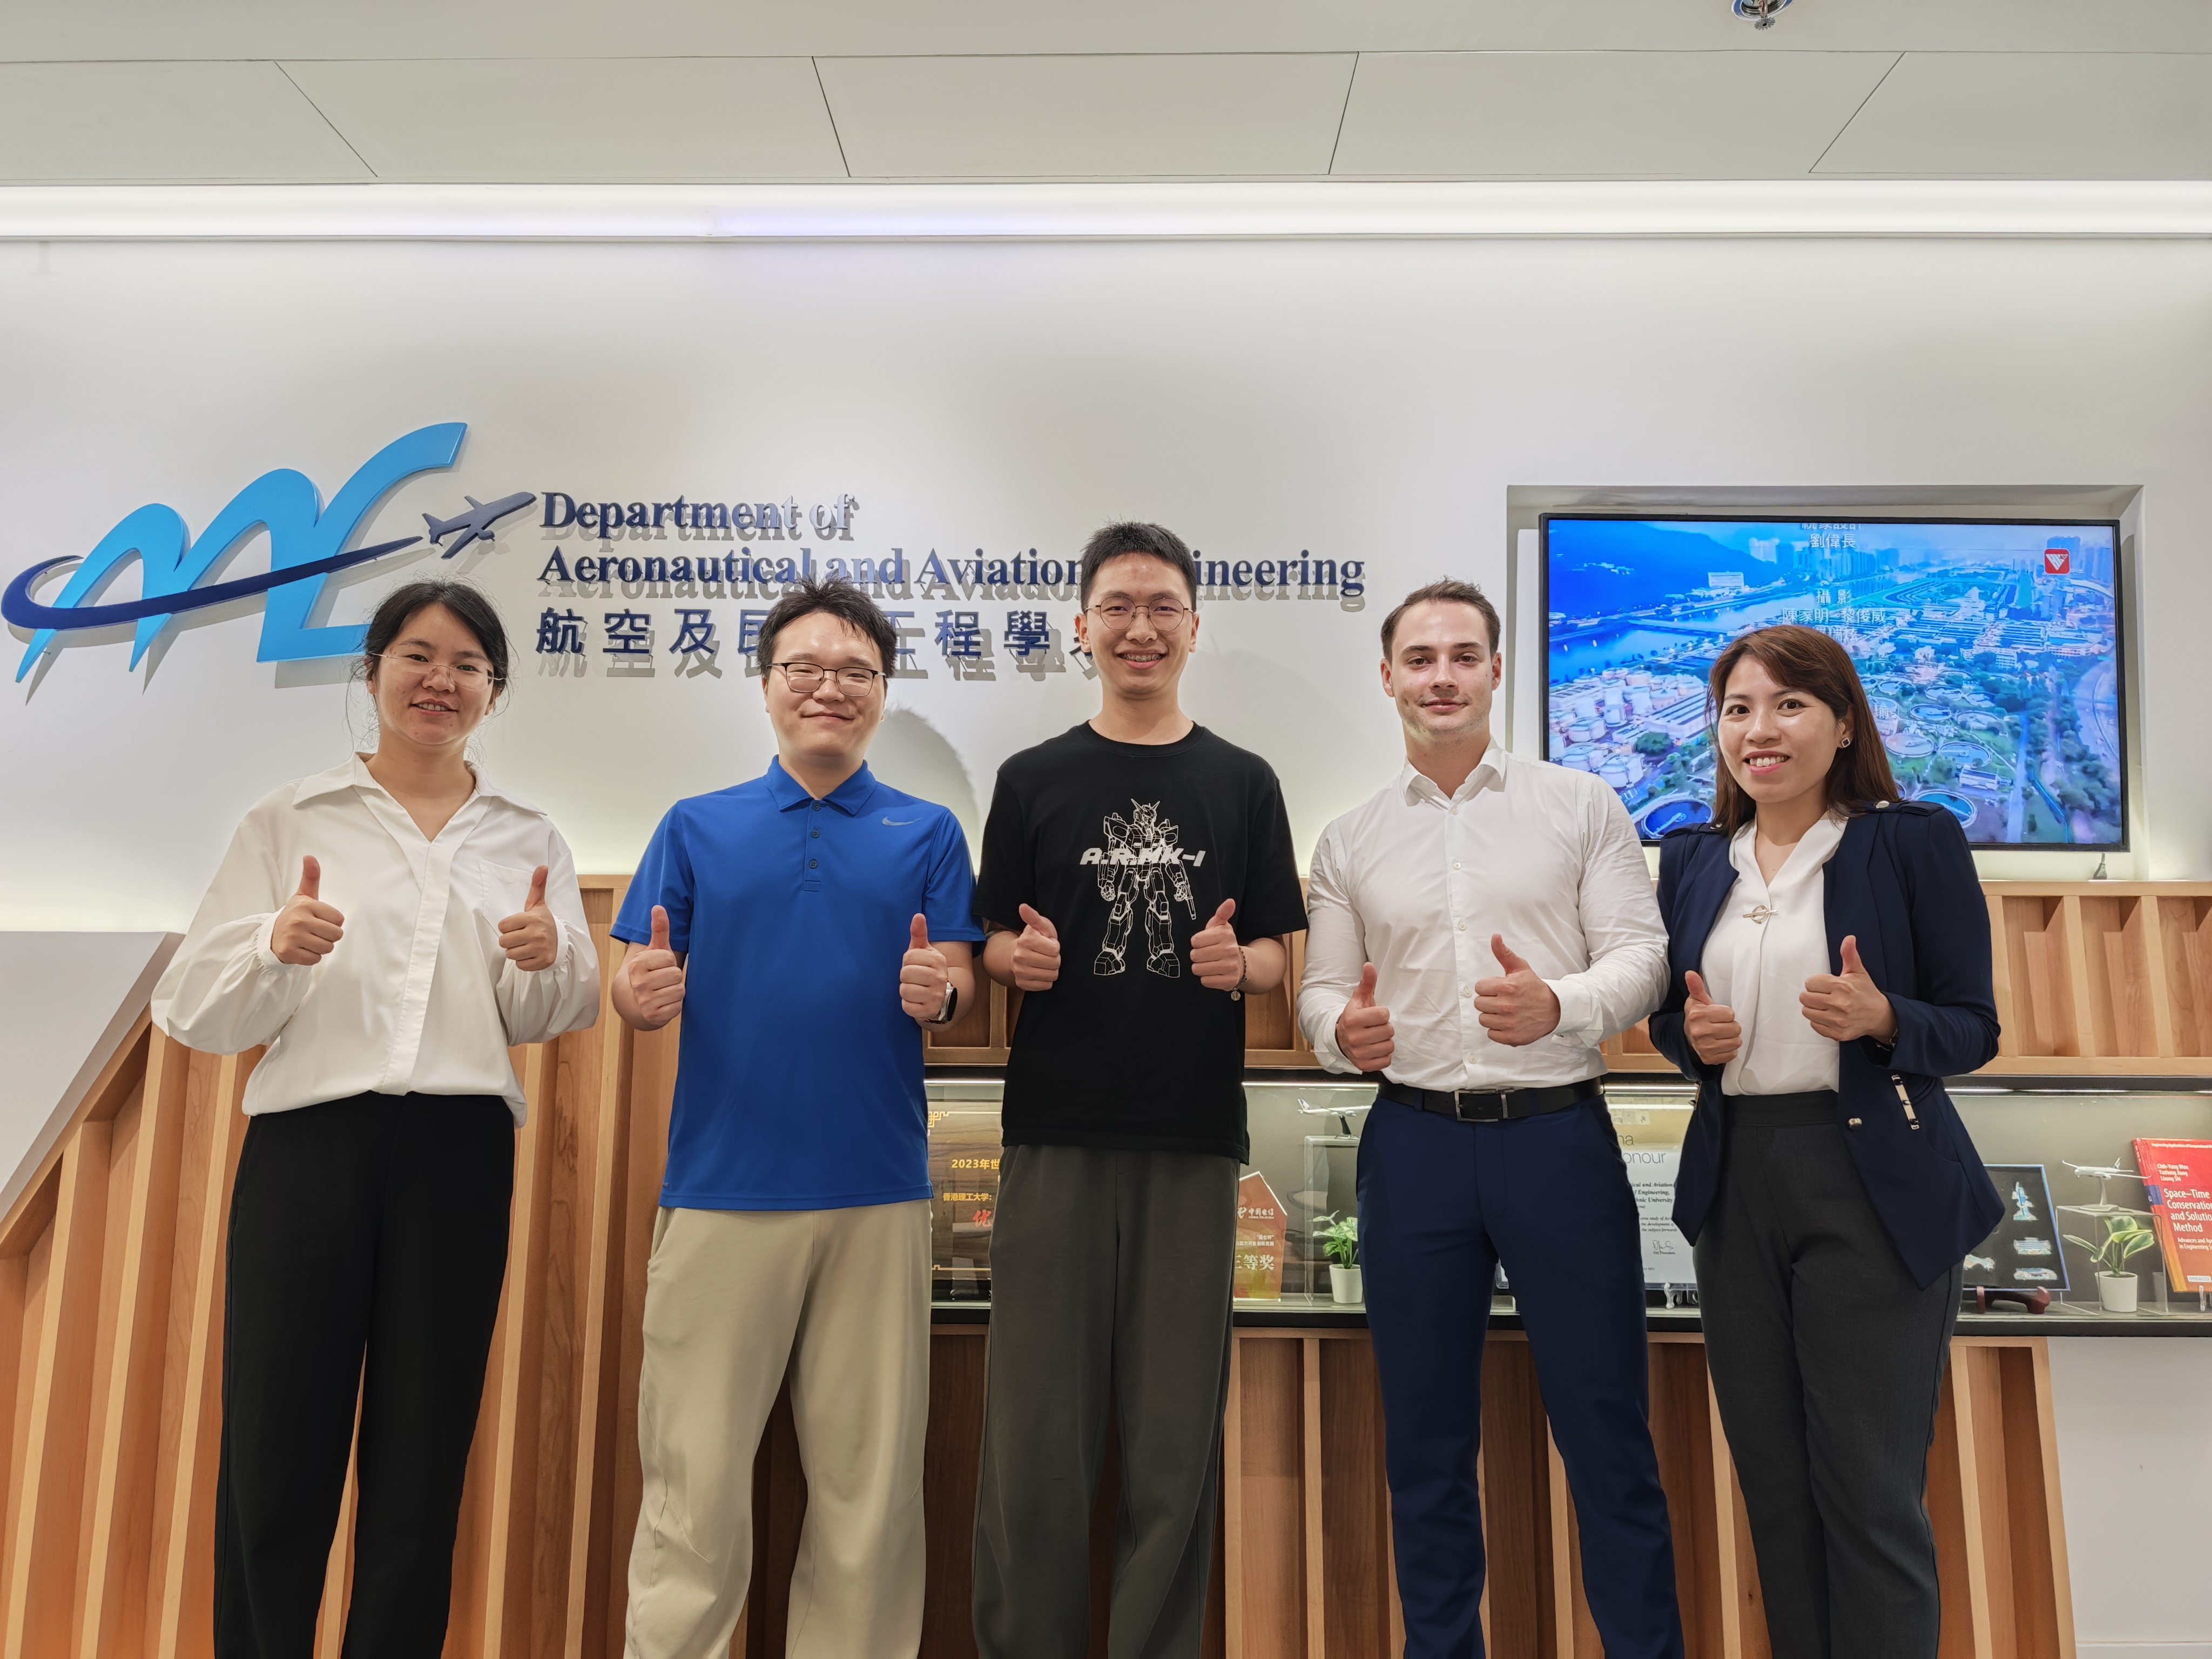
On the afternoon of 17 June 2025, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) in Hong Kong welcomed Mr. Georg Alles and Ms. Wendy Tse, representatives of Messe Frankfurt, for a visit.
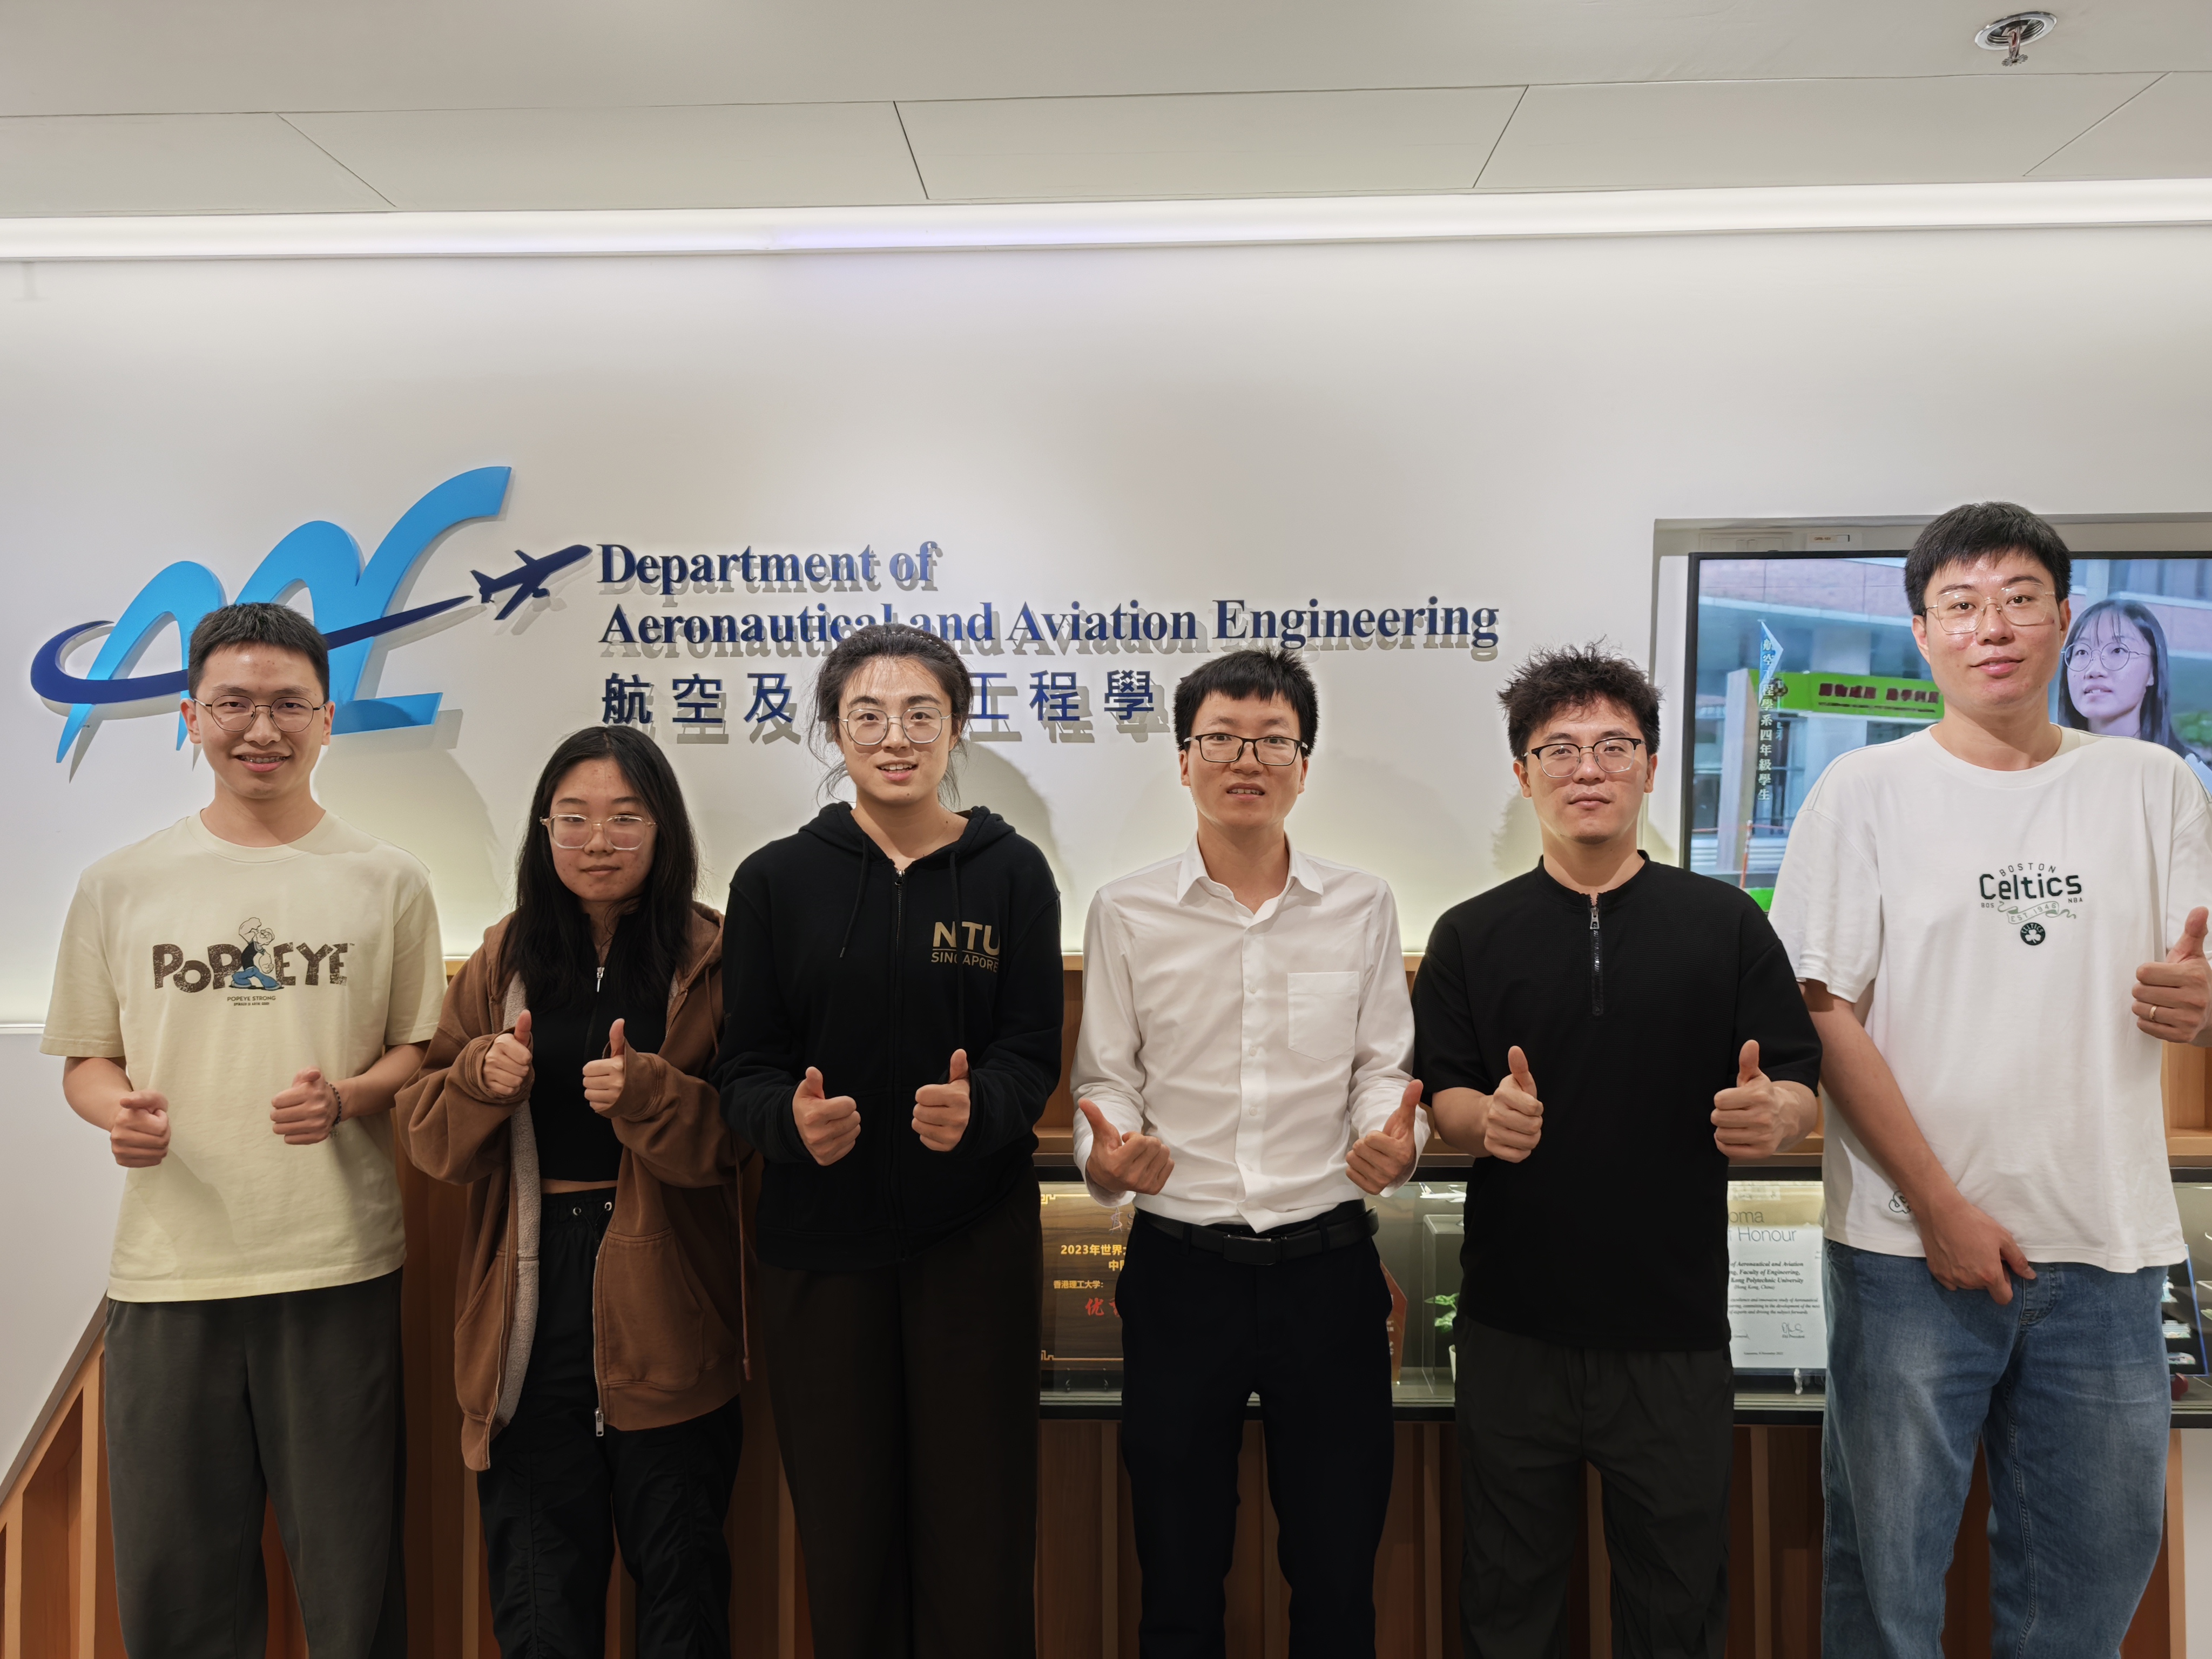
Hong Kong, 16 June 2025 – In the afternoon, Prof. Wen held a productive meeting with Dr. Yuyue Zhong and his research group from the Department of Food Science and Nutrition to explore potential collaboration between their fields in material science and unmanned aerial systems (UAS).
Hong Kong – 12 June 2025 – On the morning of 12 June 2025, members of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) visited Gammon Construction. The group included Prof. WEN Weisong, Dr. HUANG Feng, PhD students XIAO Naigui and CHEN Yingming, and research assistant WANG Xiangru. The purpose of the visit was to introduce TASLAB’s research to Gammon and discuss potential applications in the construction industry.
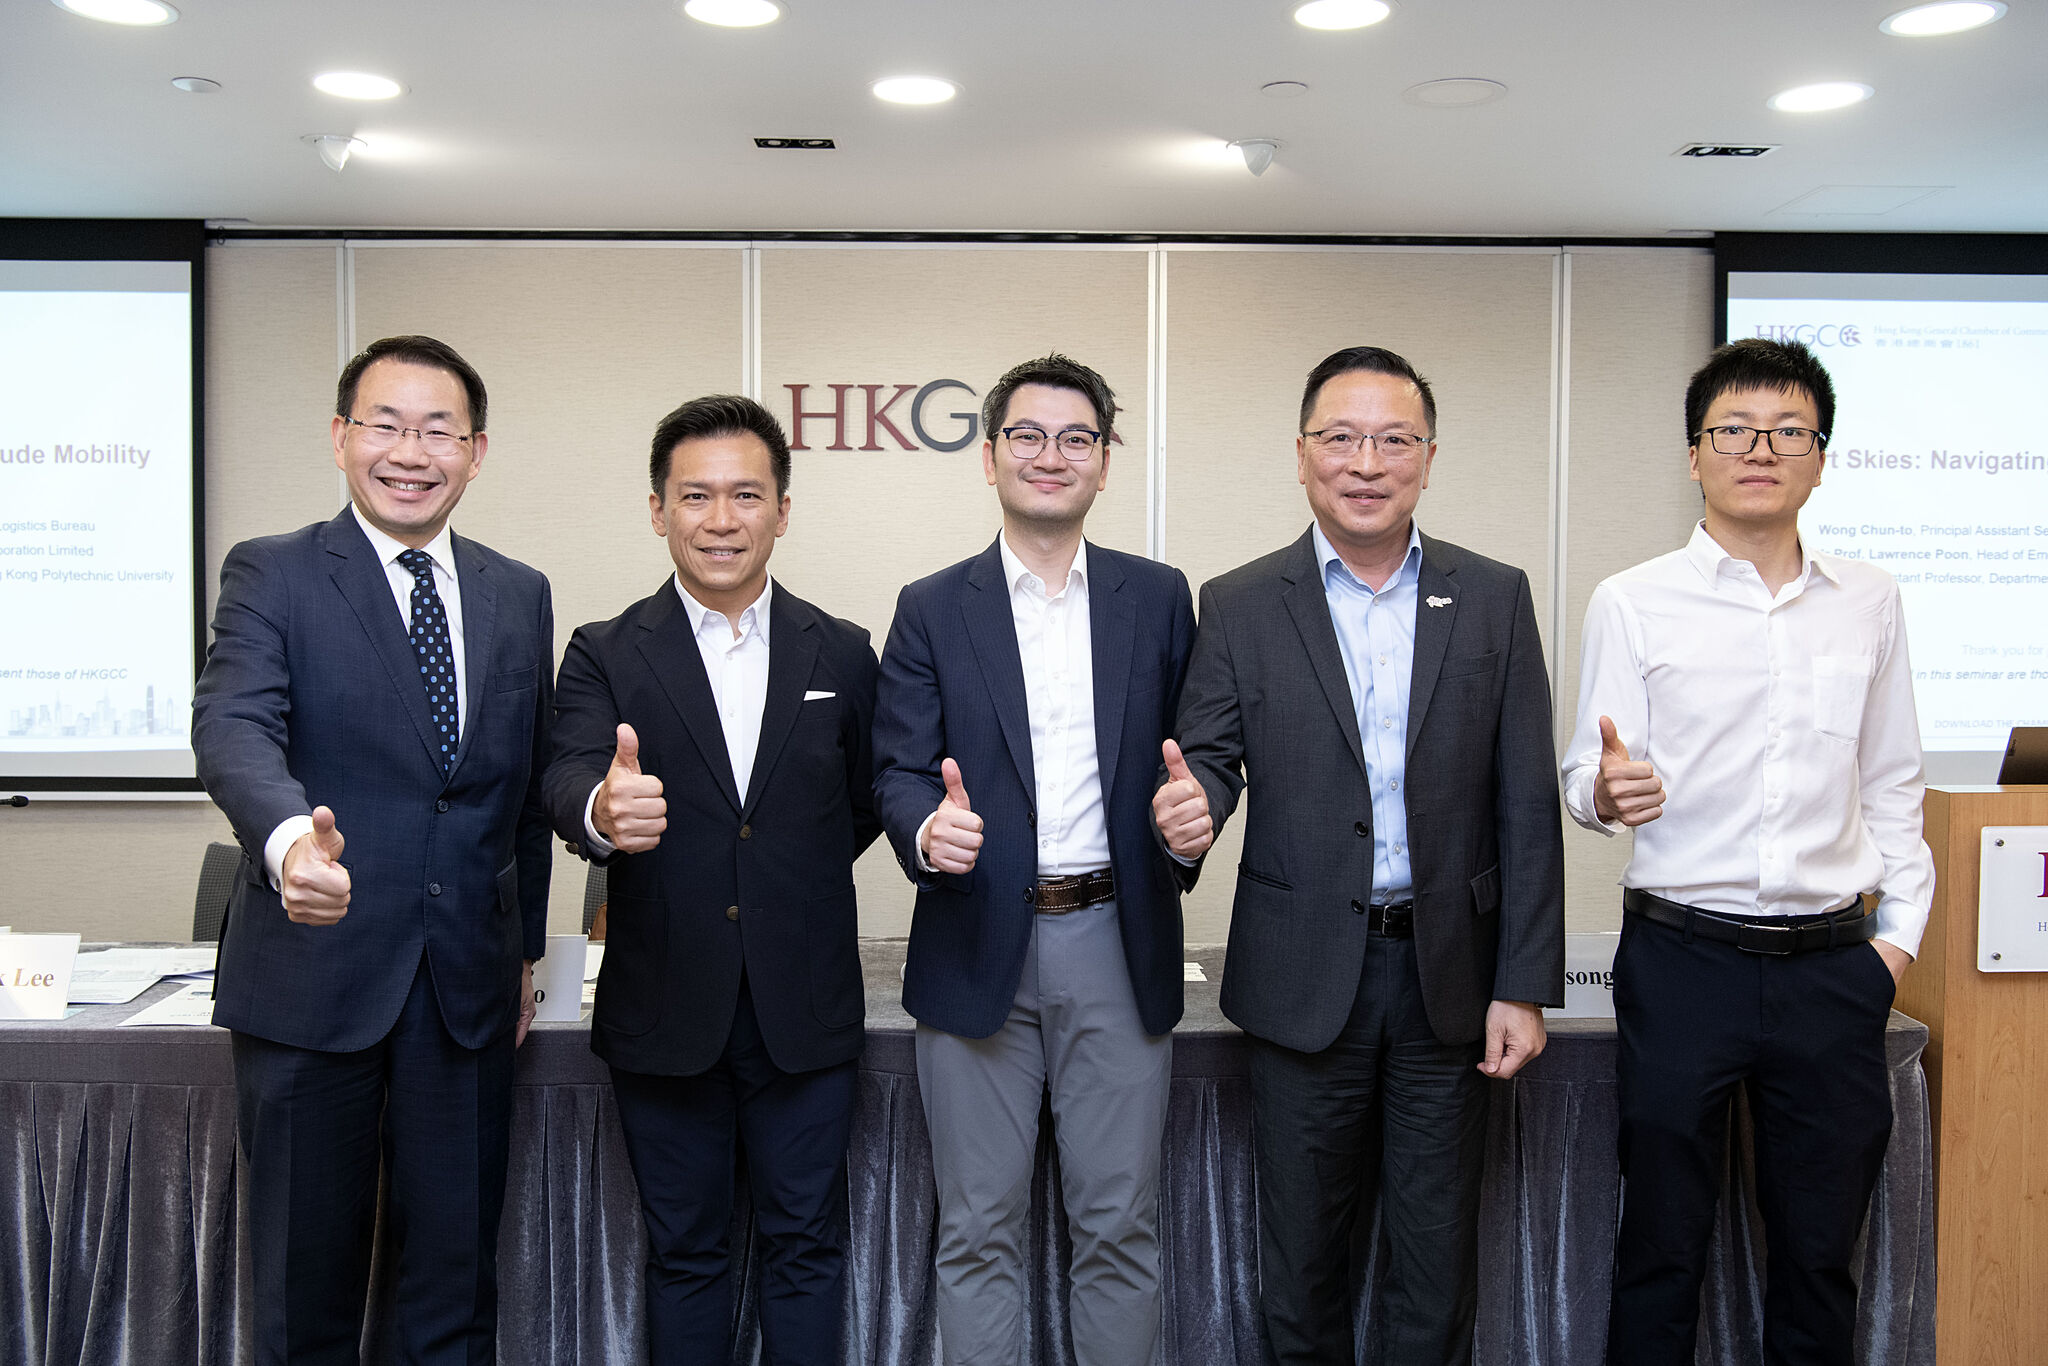
On the morning of 10 June 2025 in Hong Kong, Prof. Weisong Wen of the Department of Aeronautical and Aviation Engineering at The Hong Kong Polytechnic University (PolyU) served as a guest speaker at a seminar on the development of the low-altitude economy (LAE) in Hong Kong. The event was hosted by the Hong Kong General Chamber of Commerce (HKGCC).
On 9 June 2025, Dr. Weisong Wen, Principal Investigator (PI) of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB), together with postdoctoral researchers Dr. Runqiu Yang and Dr. Yingying Wang and research assistant Xiangru Wang, visited LinxAI Intelligent Technology Co., Ltd. in Shenzhen to explore advancements in quadruped robotics. The team toured the company’s quadruped robot assembly facility and R&D lab, gaining insights into its robotic technologies and industrial applications.
Shenzhen, 9 June 2025 – Dr. Weisong Wen, Principal Investigator (PI) of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB), recently visited Honor Device Co., Ltd. in Shenzhen together with postdoctoral researchers Dr. Shiyu Bai, Dr. Runqiu Yang and Dr. Yingying Wang, and research assistant Xiangru Wang. The visit focused on the continuity and future direction of the AI-driven pedestrian dead reckoning (AI-PDR) project.
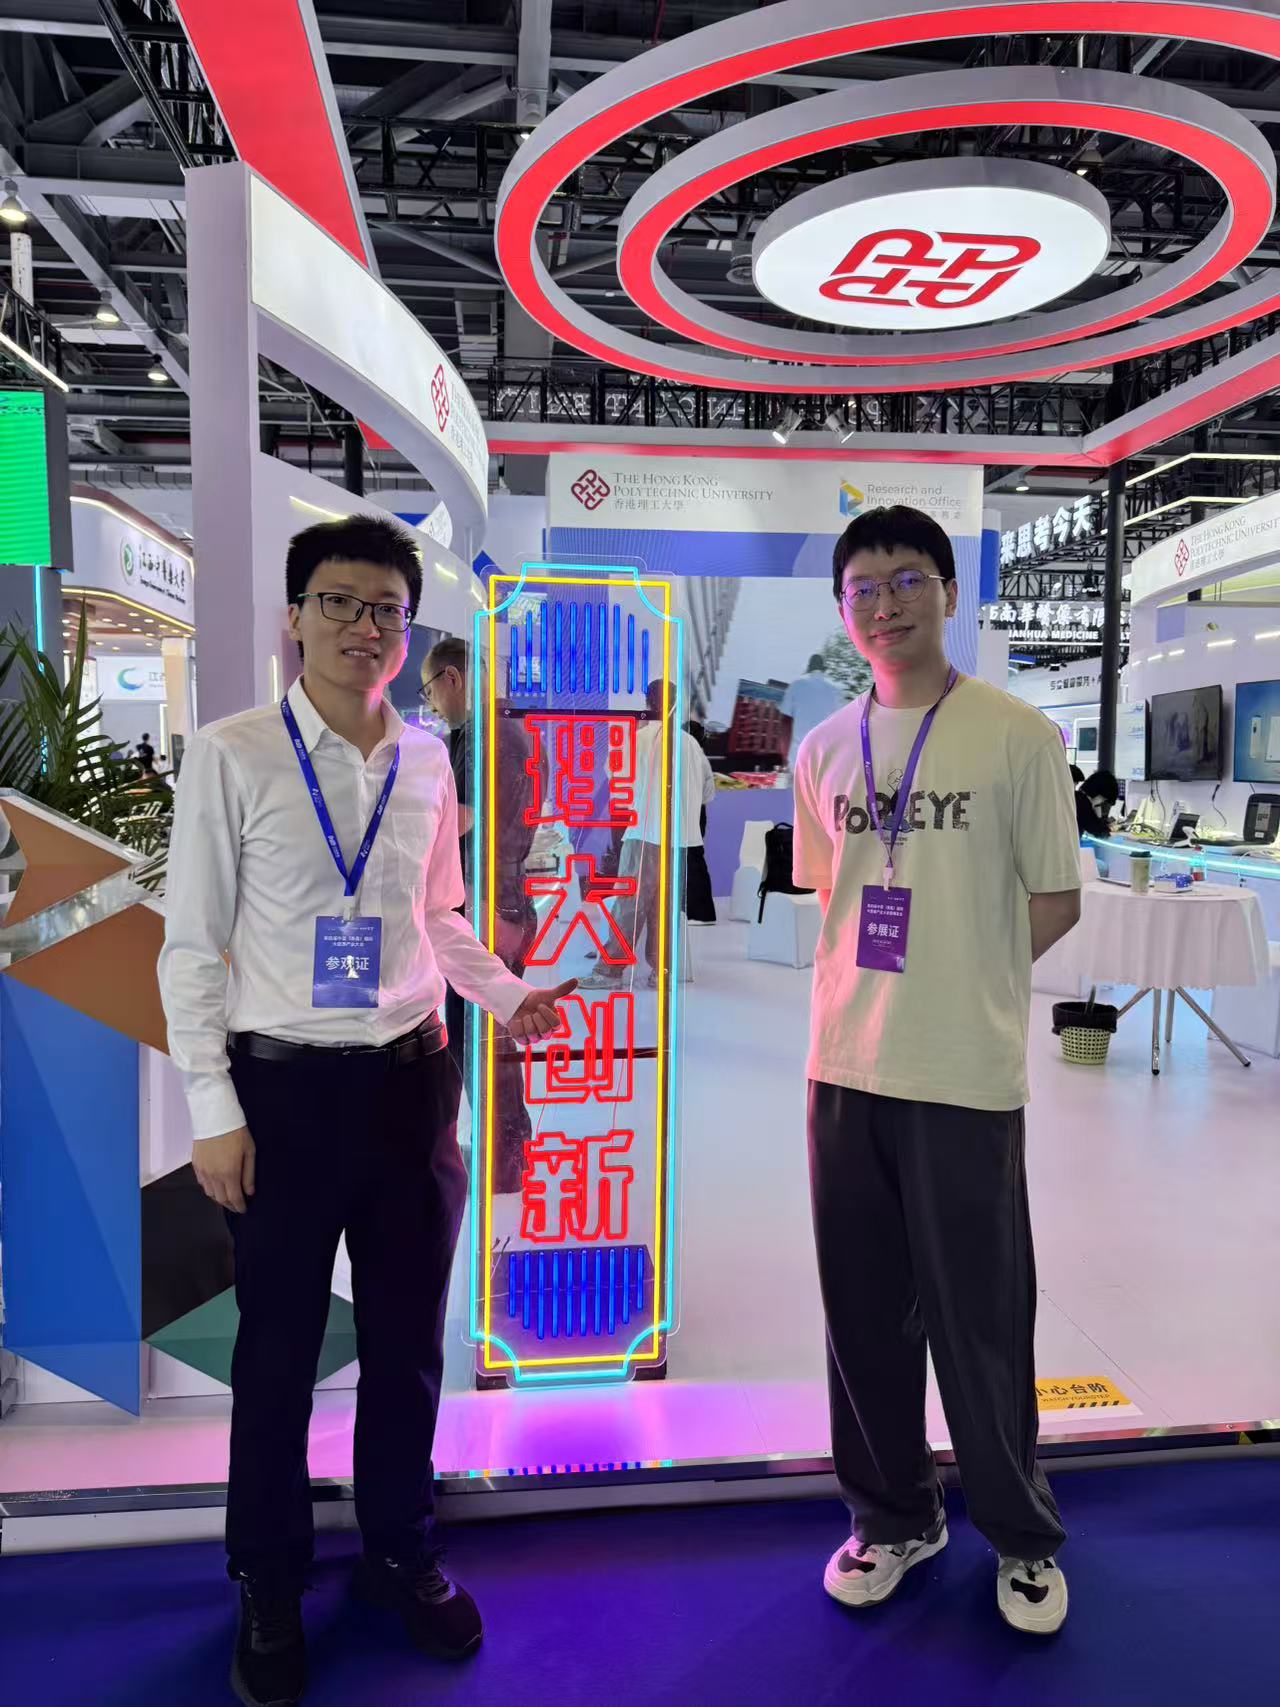
On 6 June 2025, at the Nanchang Health Expo, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) presented a concept for a wearable navigation system designed to enhance independence for visually impaired individuals. The goal is a system that gives users a deeper, more interactive understanding of their surroundings to significantly improve mobility and safety.
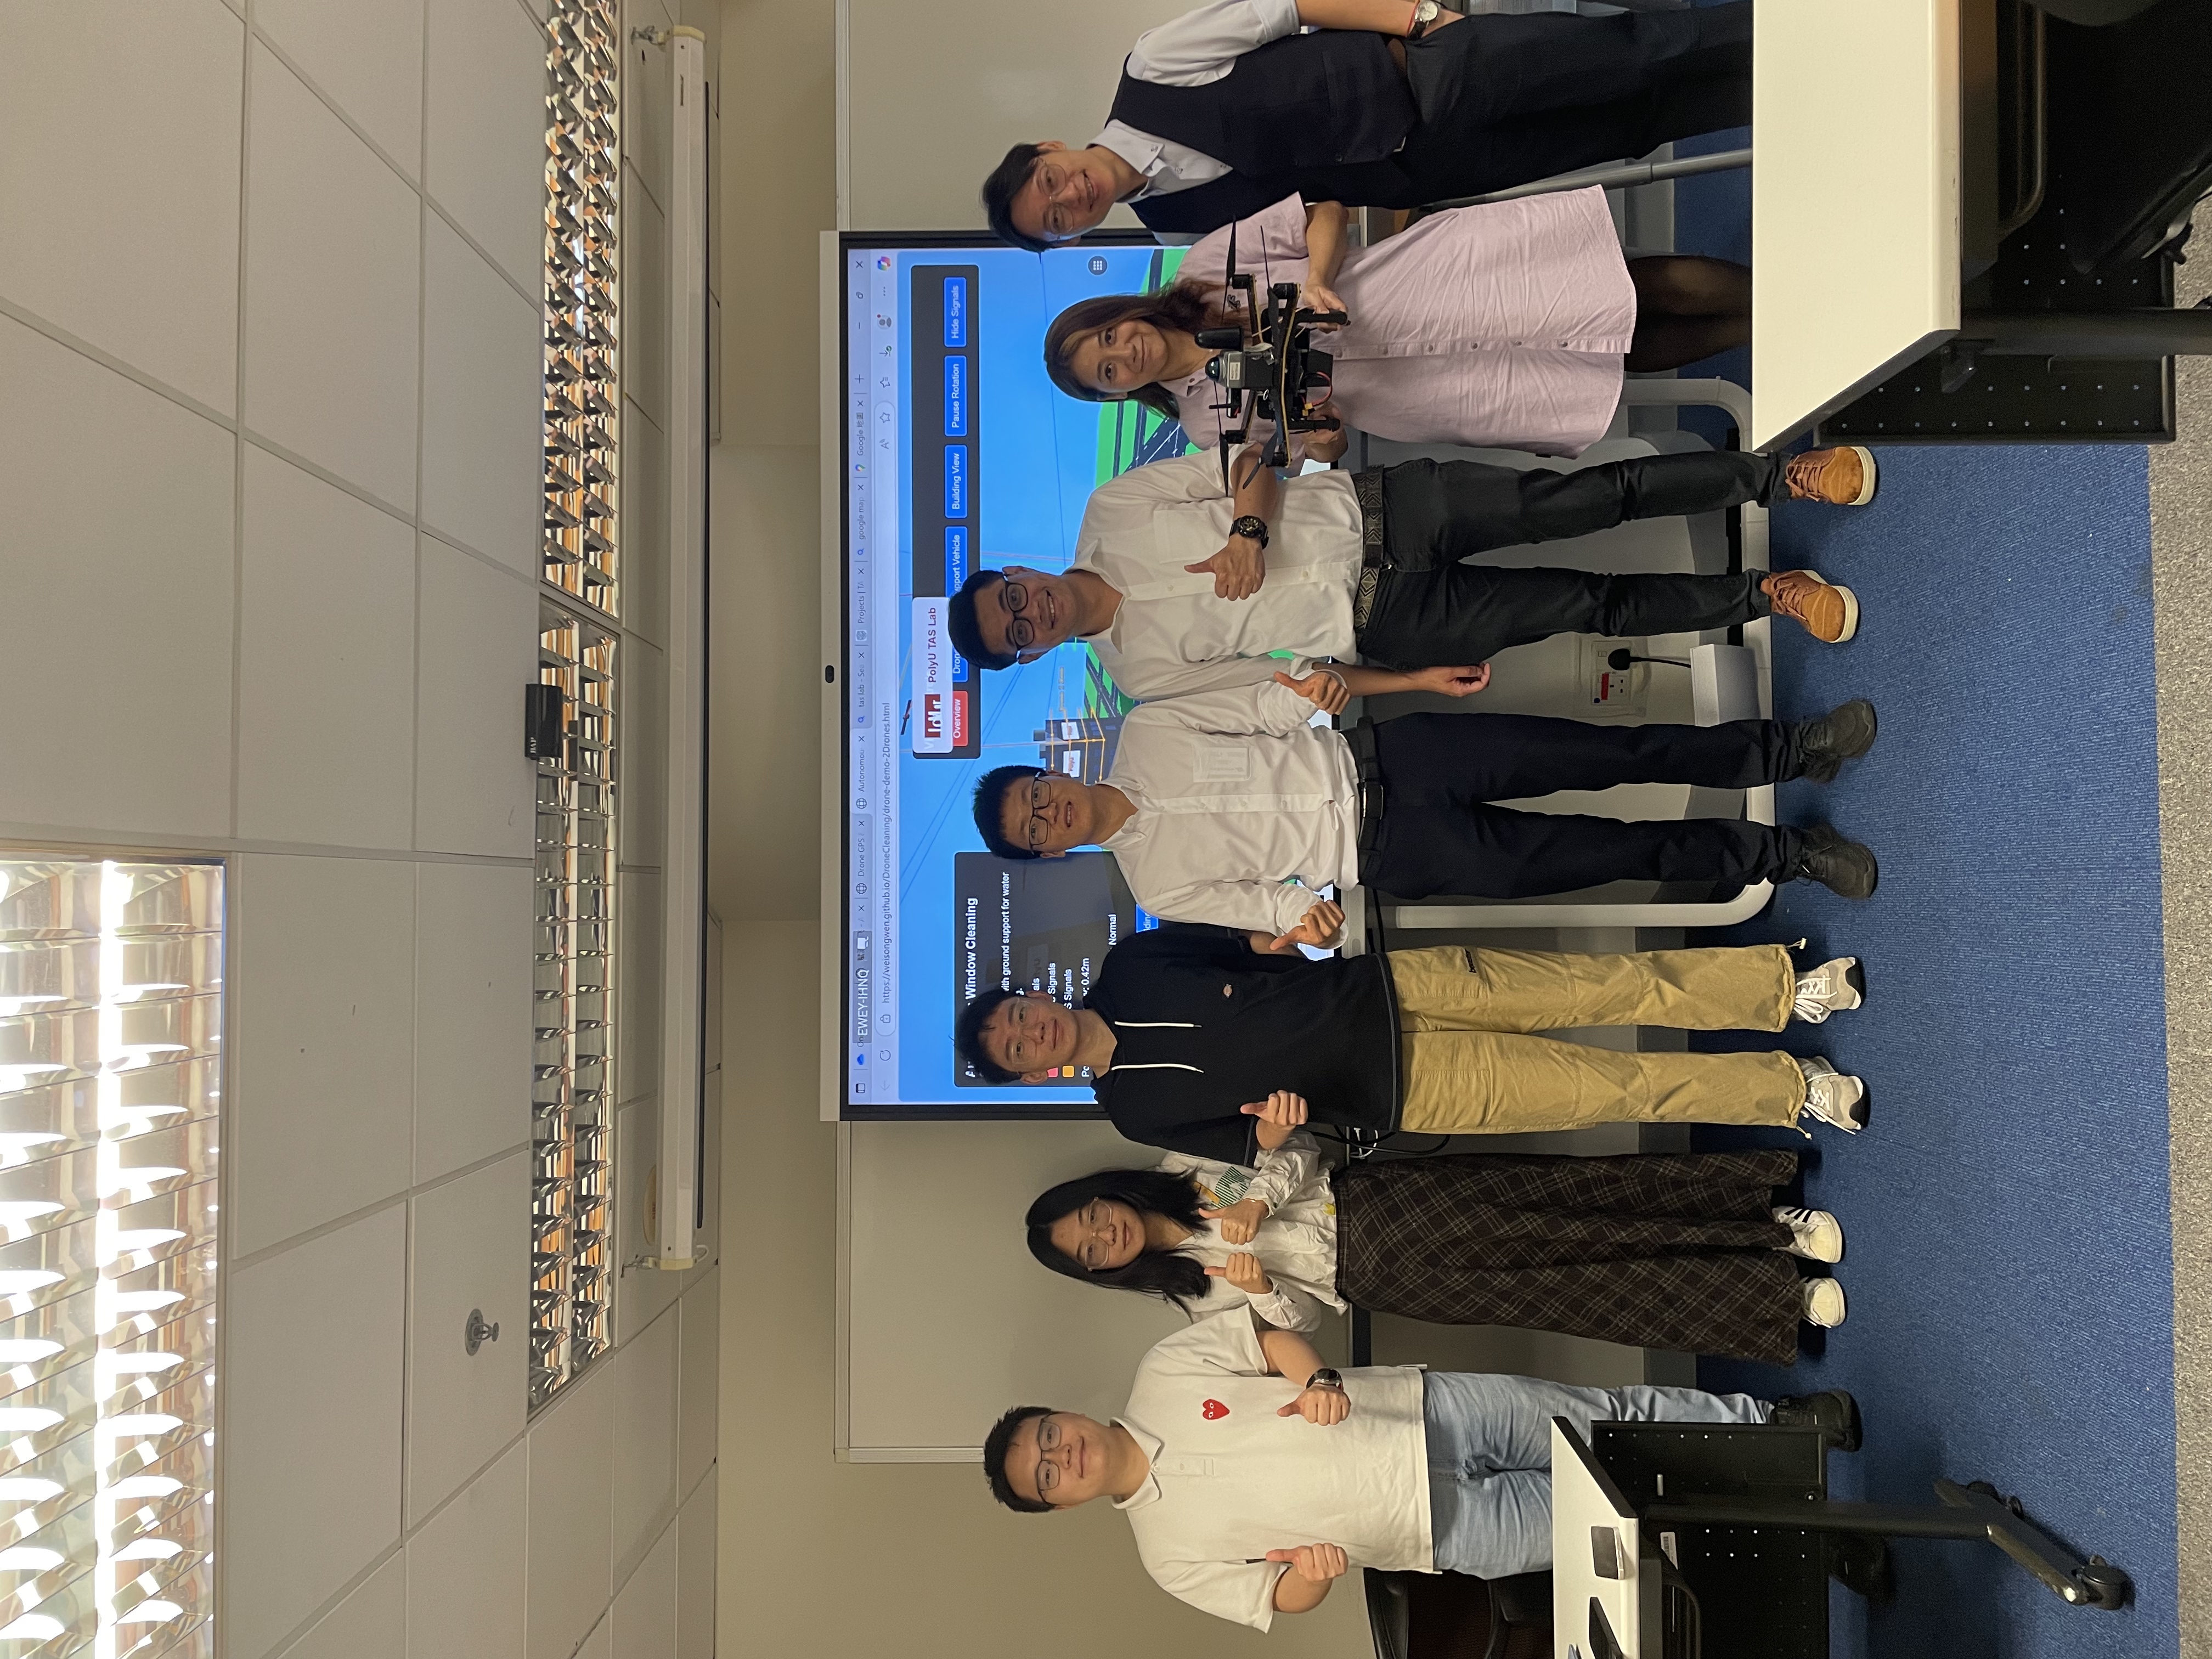
On 3 June 2025, researchers from the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) hosted an information exchange session with representatives from ATAL Company, a leading firm in iconic building design and management. The meeting aimed to strengthen ties between academia and industry and to explore collaboration on drone applications in the low-altitude economy (LAE).
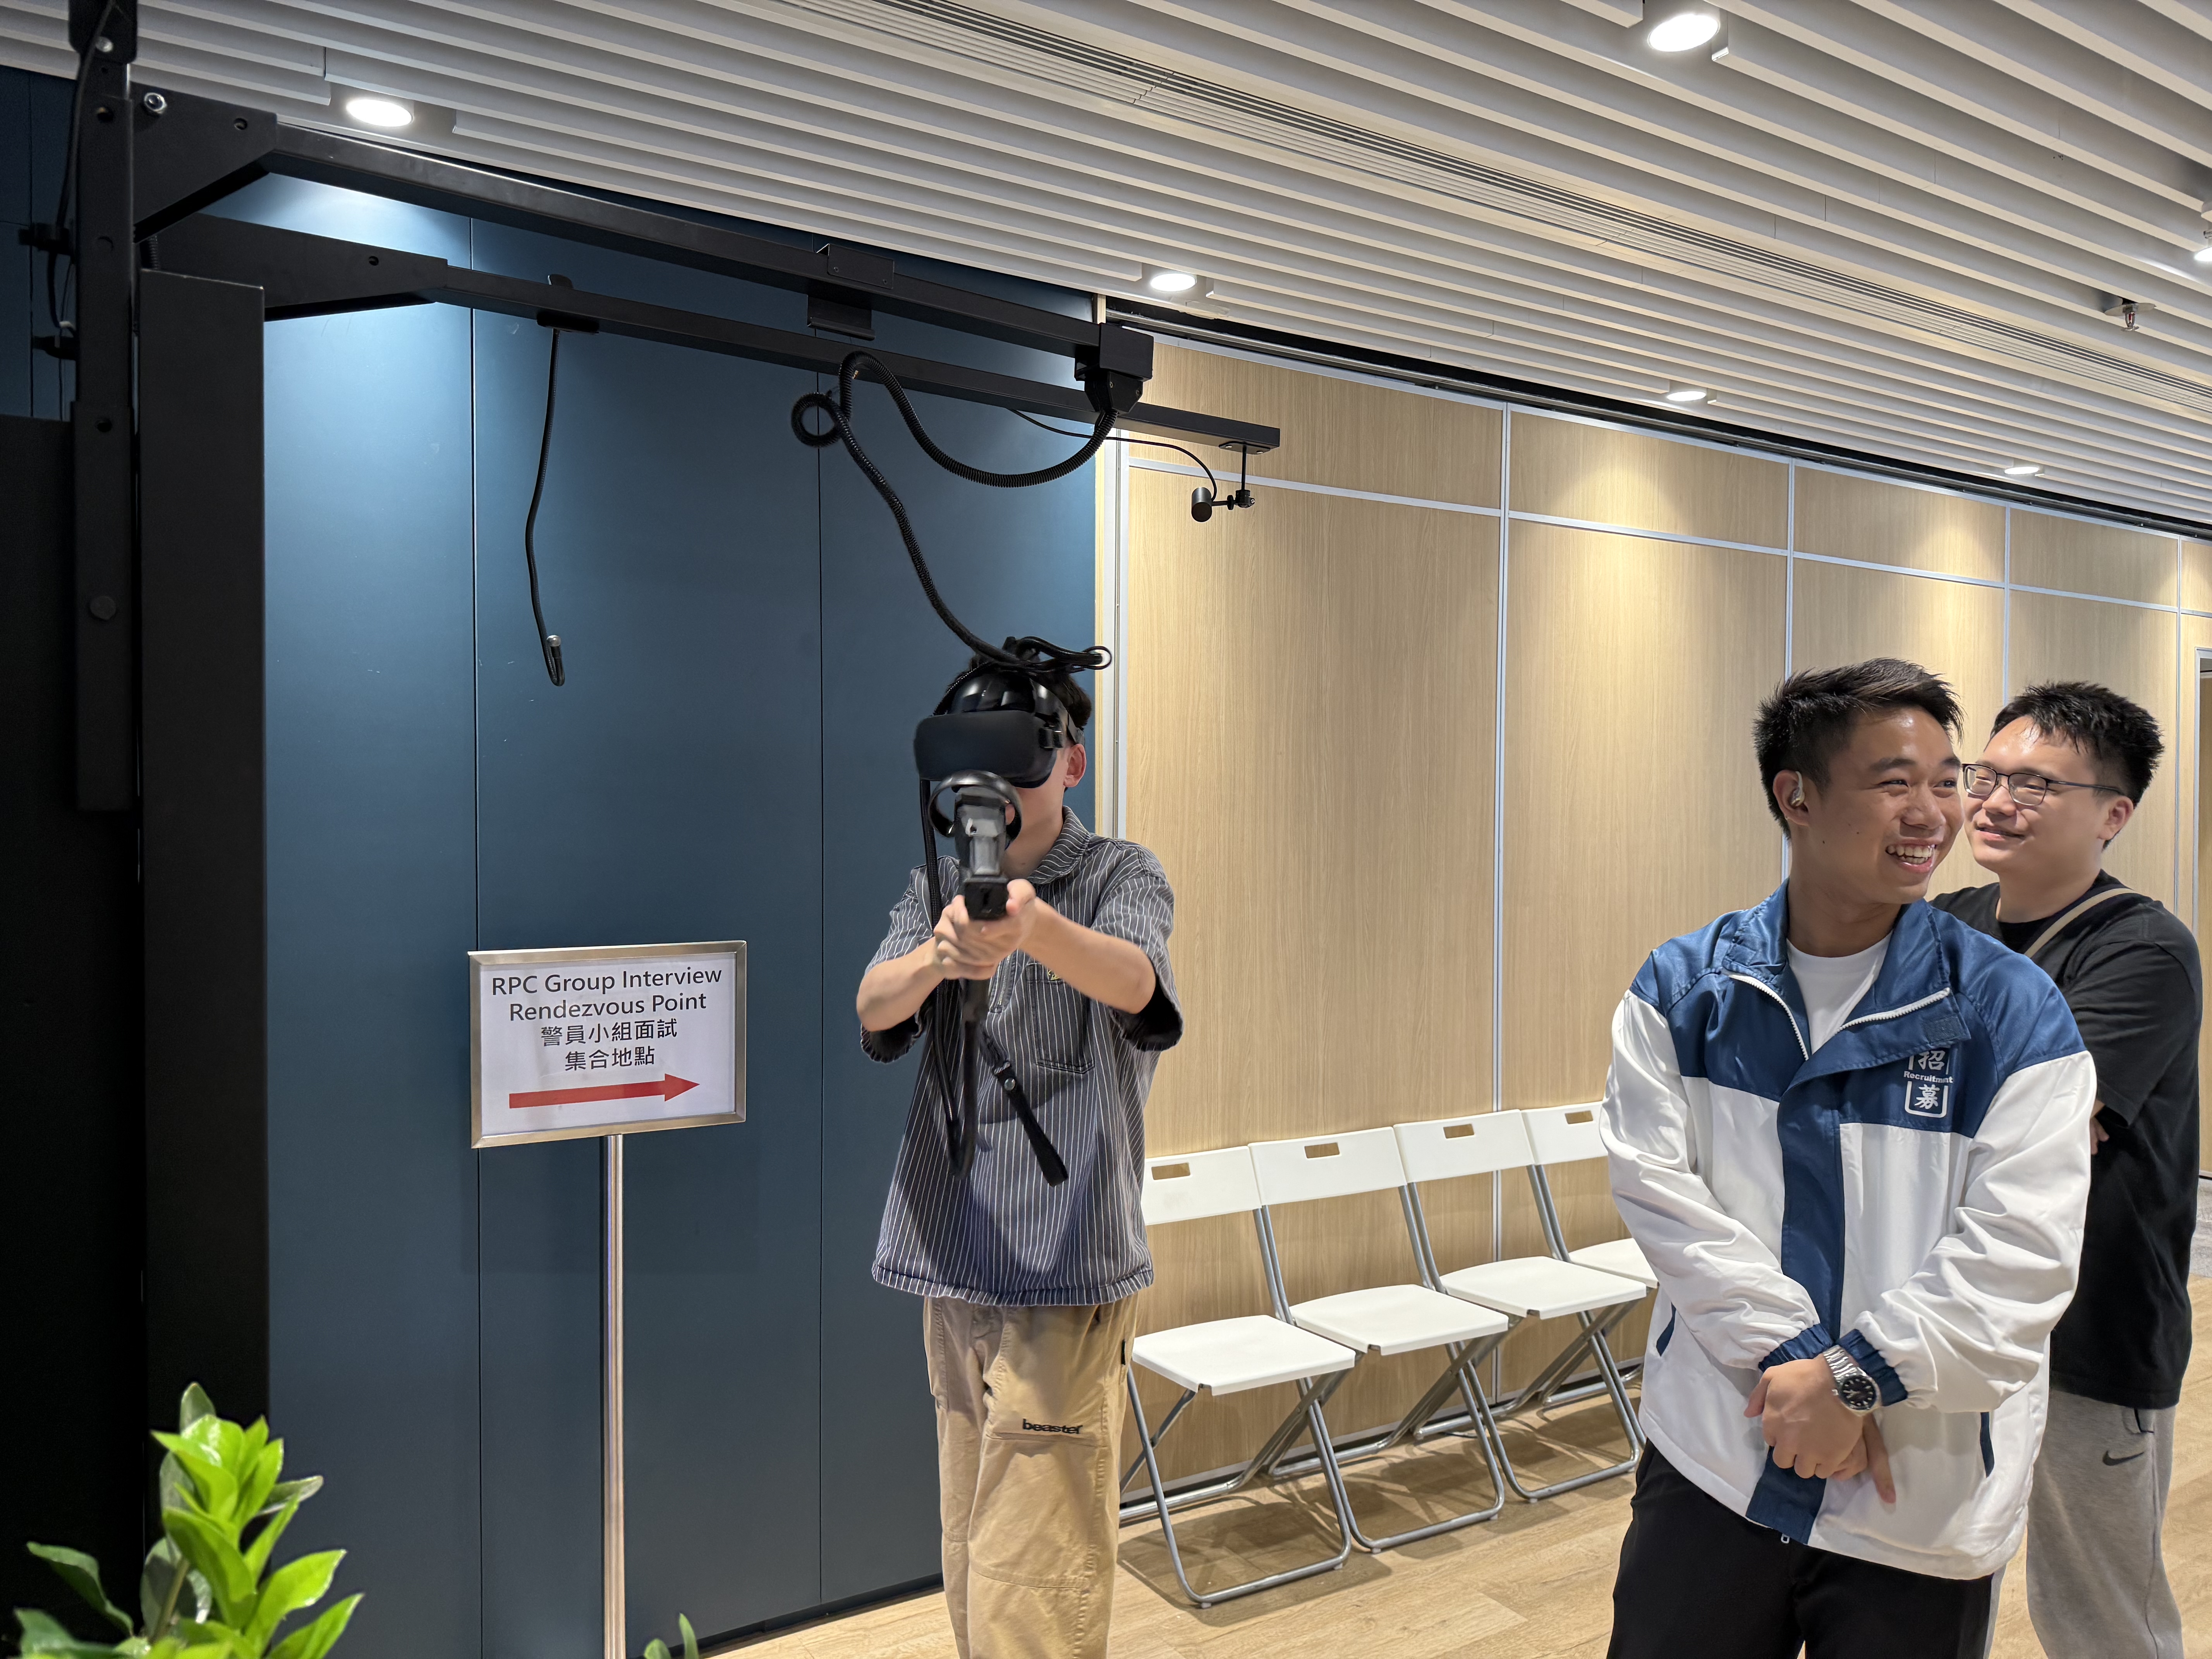
Hong Kong, 27 May 2025 – A delegation from the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) recently visited the Hong Kong Police Force’s Force Drone Cadre (FDC) to discuss advances in drone technology and explore ways to support law enforcement operations. The meeting highlighted the growing importance of unmanned aerial vehicles (UAVs) in public safety and emergency response.
In Spring 2025, Ph.D. candidate Xikun Liu from the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) began an academic visit to the University of California, Los Angeles (UCLA) School of Engineering. He is conducting joint research under the supervision of Professor Sriram Narasimhan.
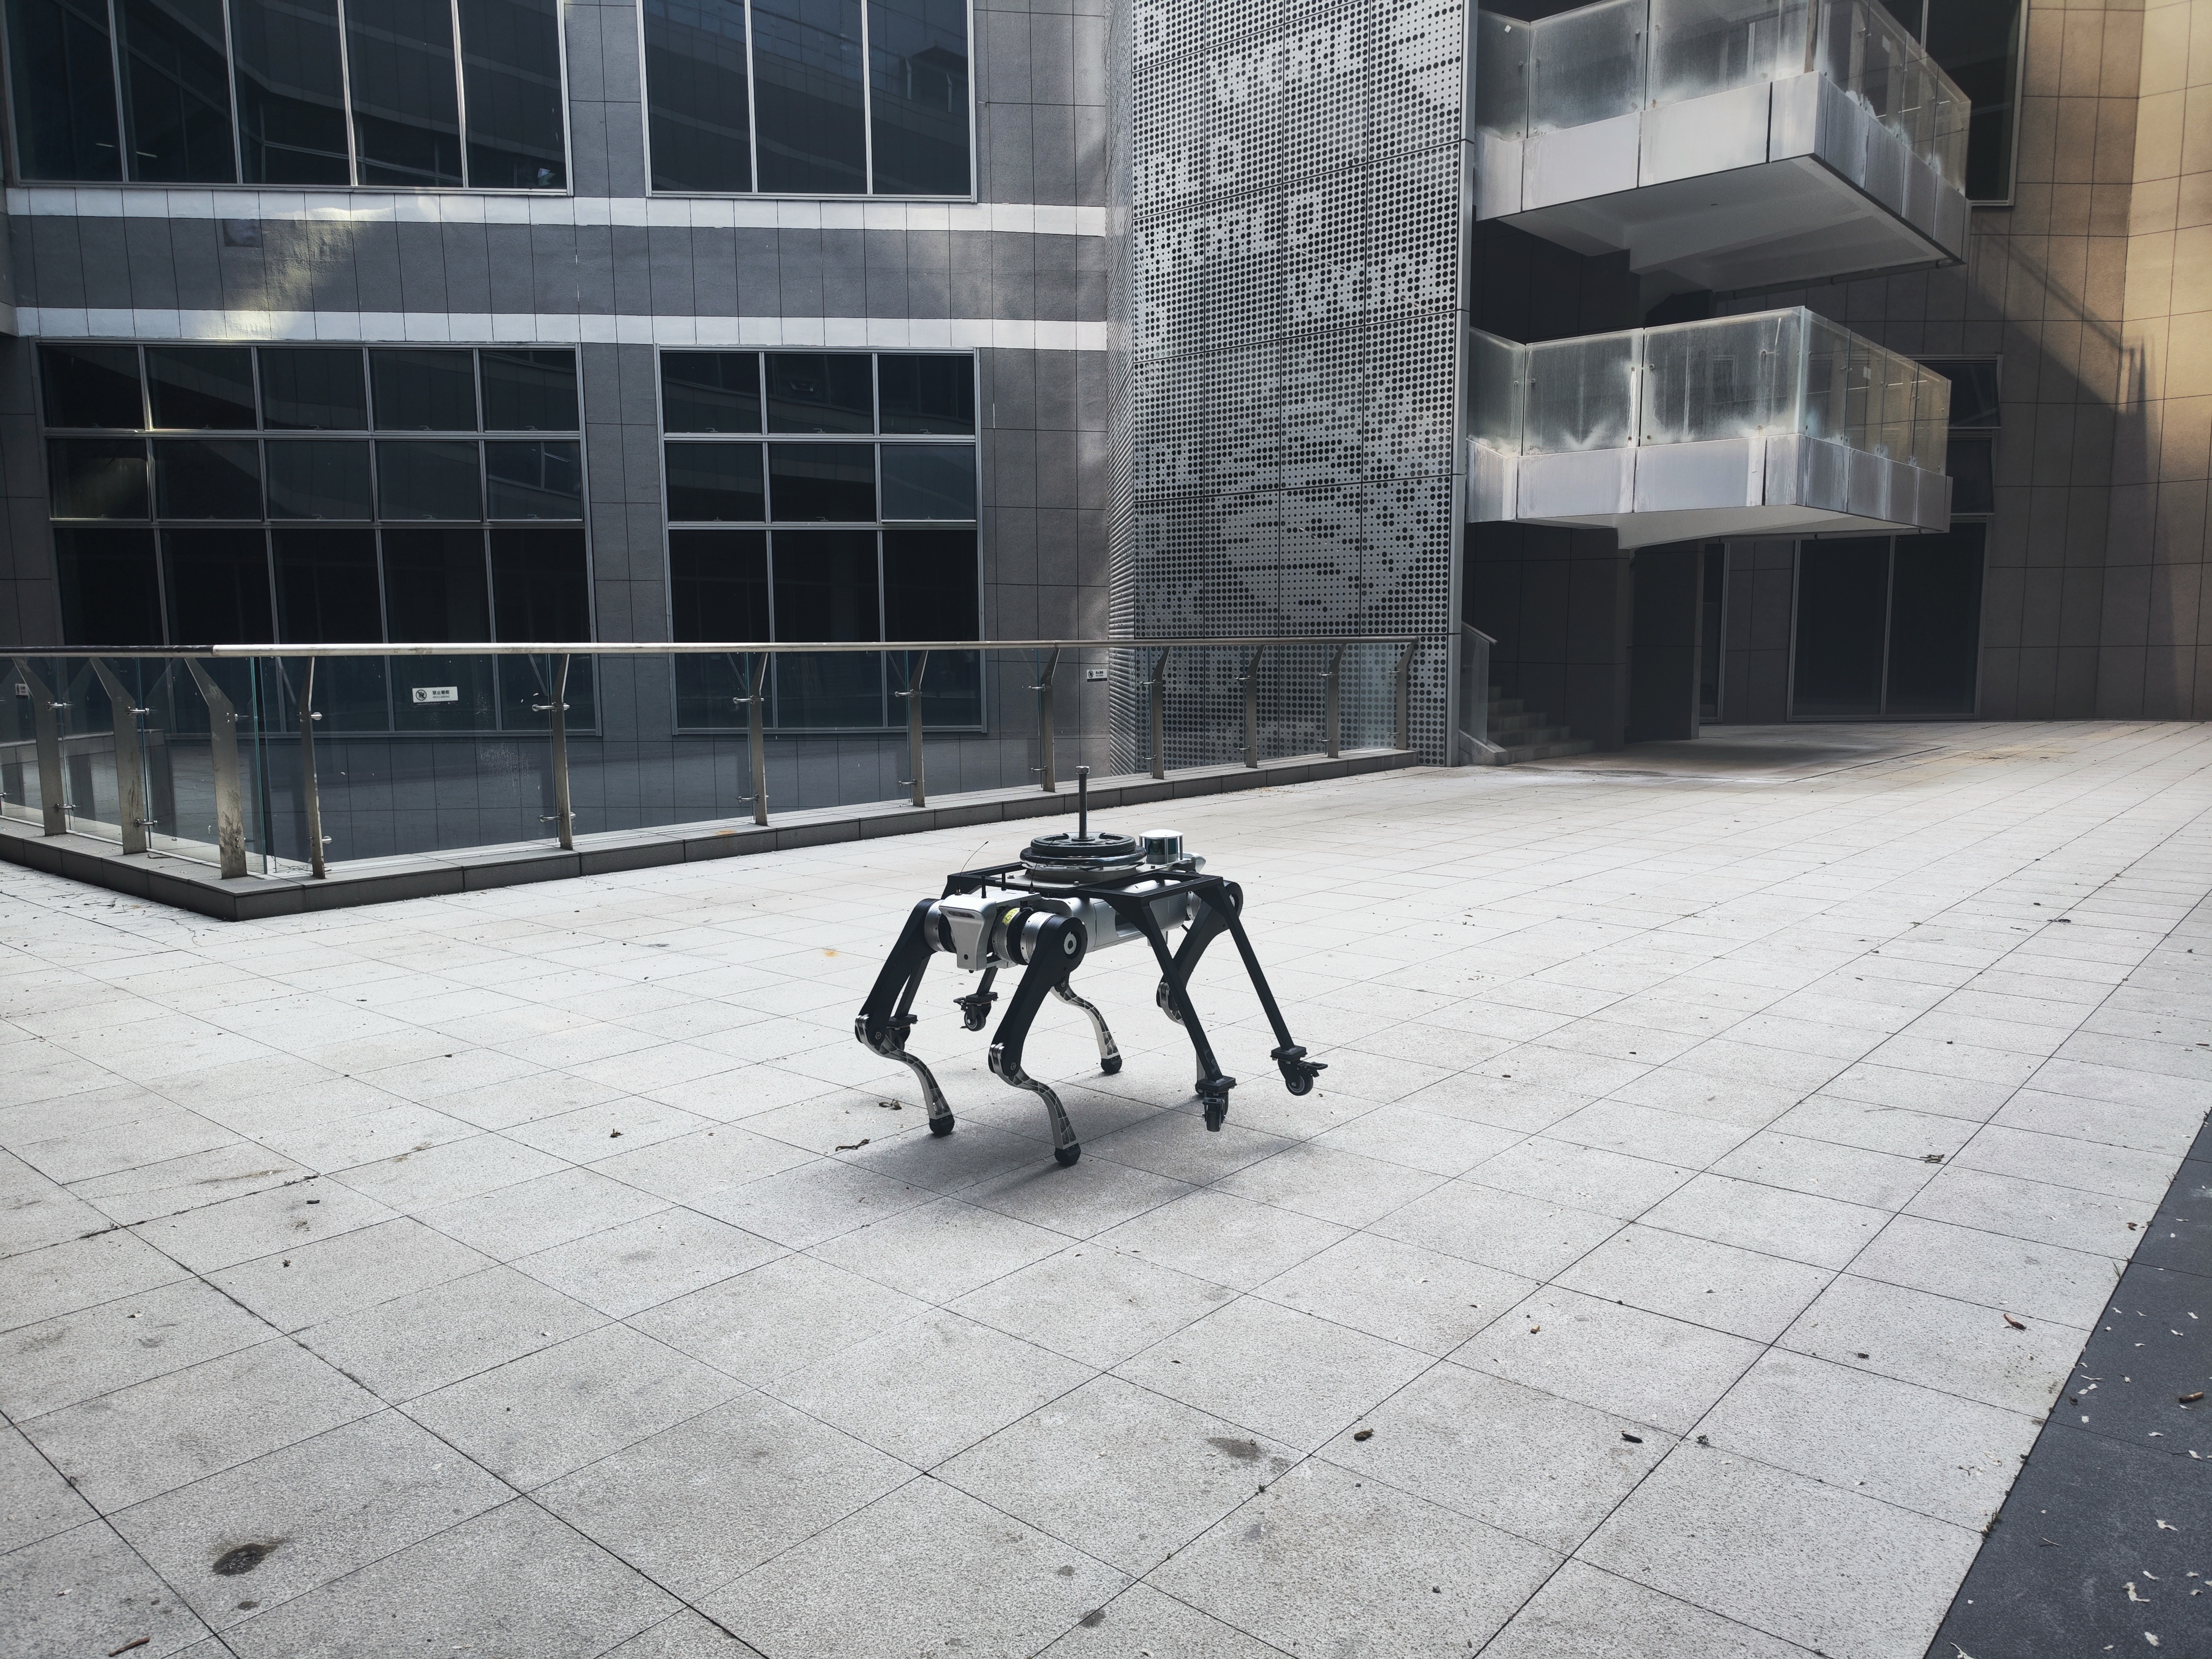
Dr. Runqiu Yang and MPhil student Yuling Cheng recently visited LinxAI Intelligent Technology Co., Ltd, where they toured the company’s quadruped robot assembly base and research laboratory. During the visit, they held in-depth discussions with LinxAI’s engineering team, exchanging insights on the latest advances in robotic locomotion, AI-driven control systems and industrial applications of quadruped robots.
The paper “Continuous Error Map Aided Adaptive Multi-Sensor Integration for Connected Autonomous Vehicles in Urban Scenarios” has been accepted by the IEEE Transactions on Instrumentation & Measurement. Congratulations to HUANG Feng and the co-authors. The open-source code is available on GitHub.
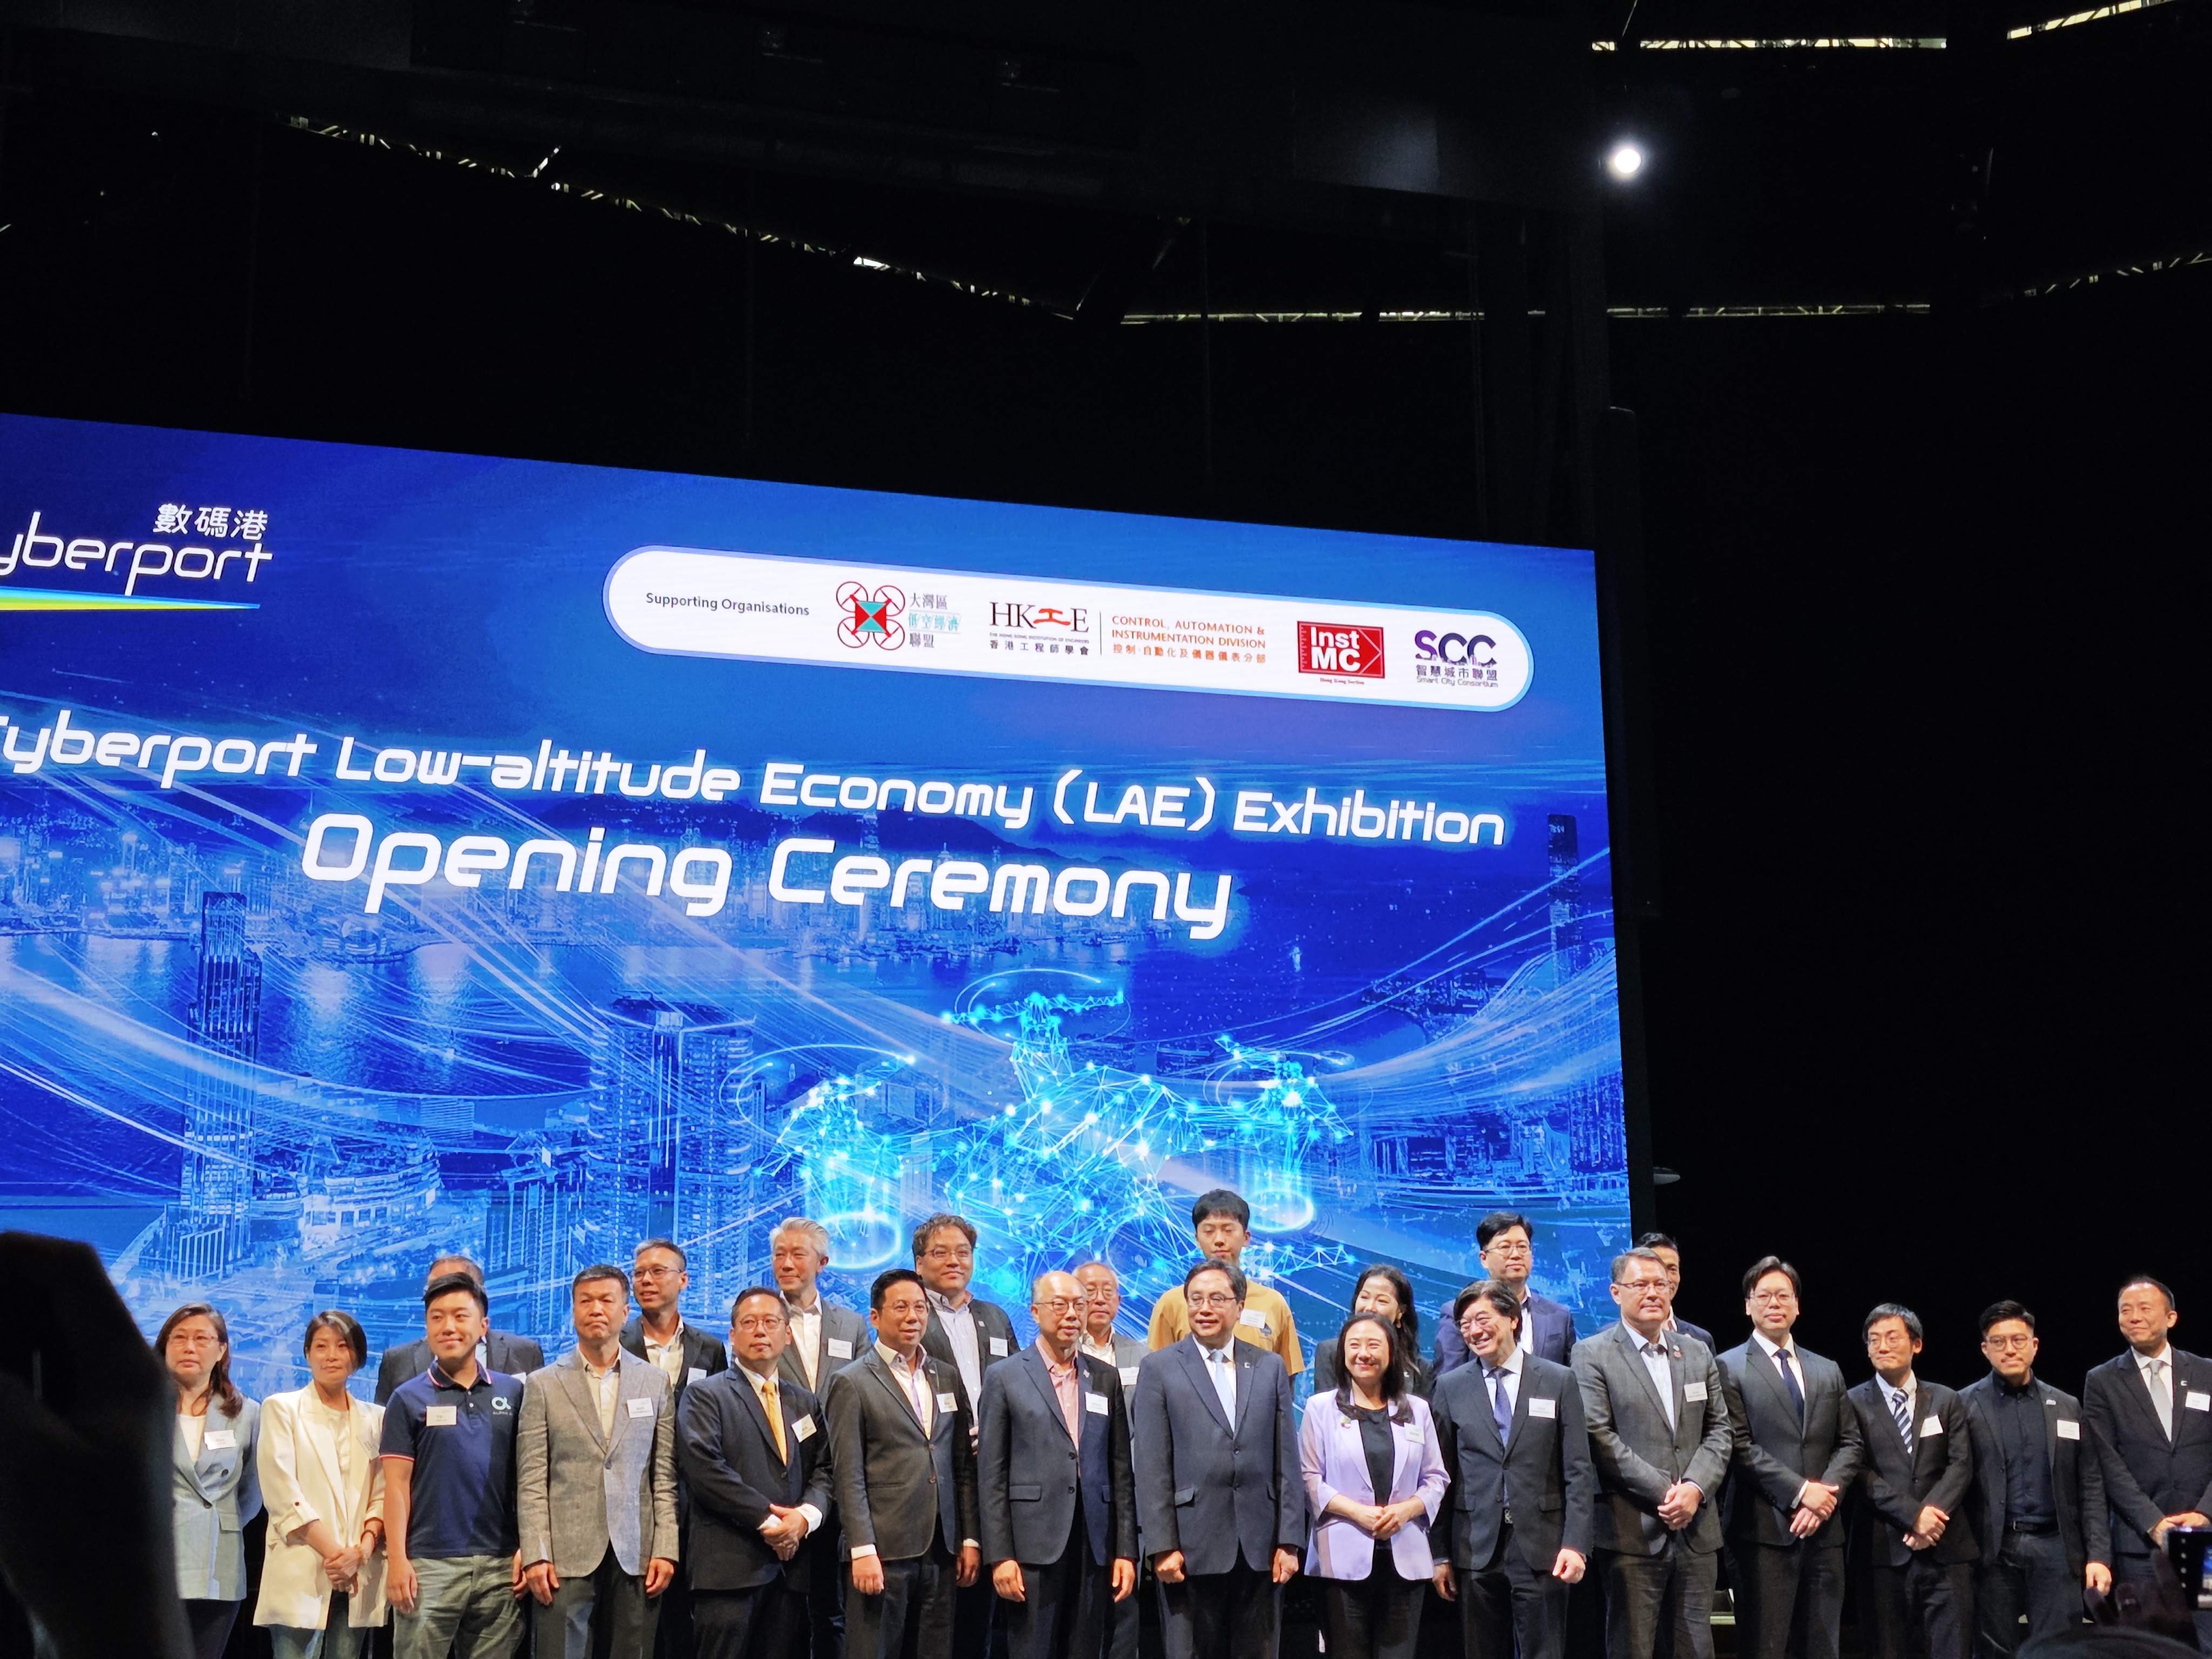
The Low-altitude Economy (LAE) Exhibition 2025 officially opened at Hong Kong Cyberport and ran for three days, from 9 to 11 May 2025, marking a milestone in the city’s push to become a regional hub for aerial innovation. The event featured UAV technologies from leading companies such as FlightPro and Phoenix Wings (丰翼), highlighting Hong Kong’s growing role in smart urban mobility and logistics.
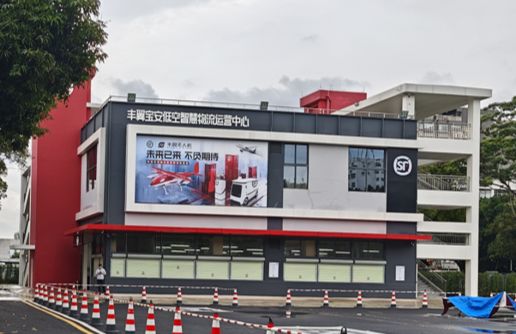
The Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) visited the Shenzhen Phoenix Wings UAV Bao’an Operations Center. The academic-industry visit explored the future of UAV logistics and possible areas of collaboration.
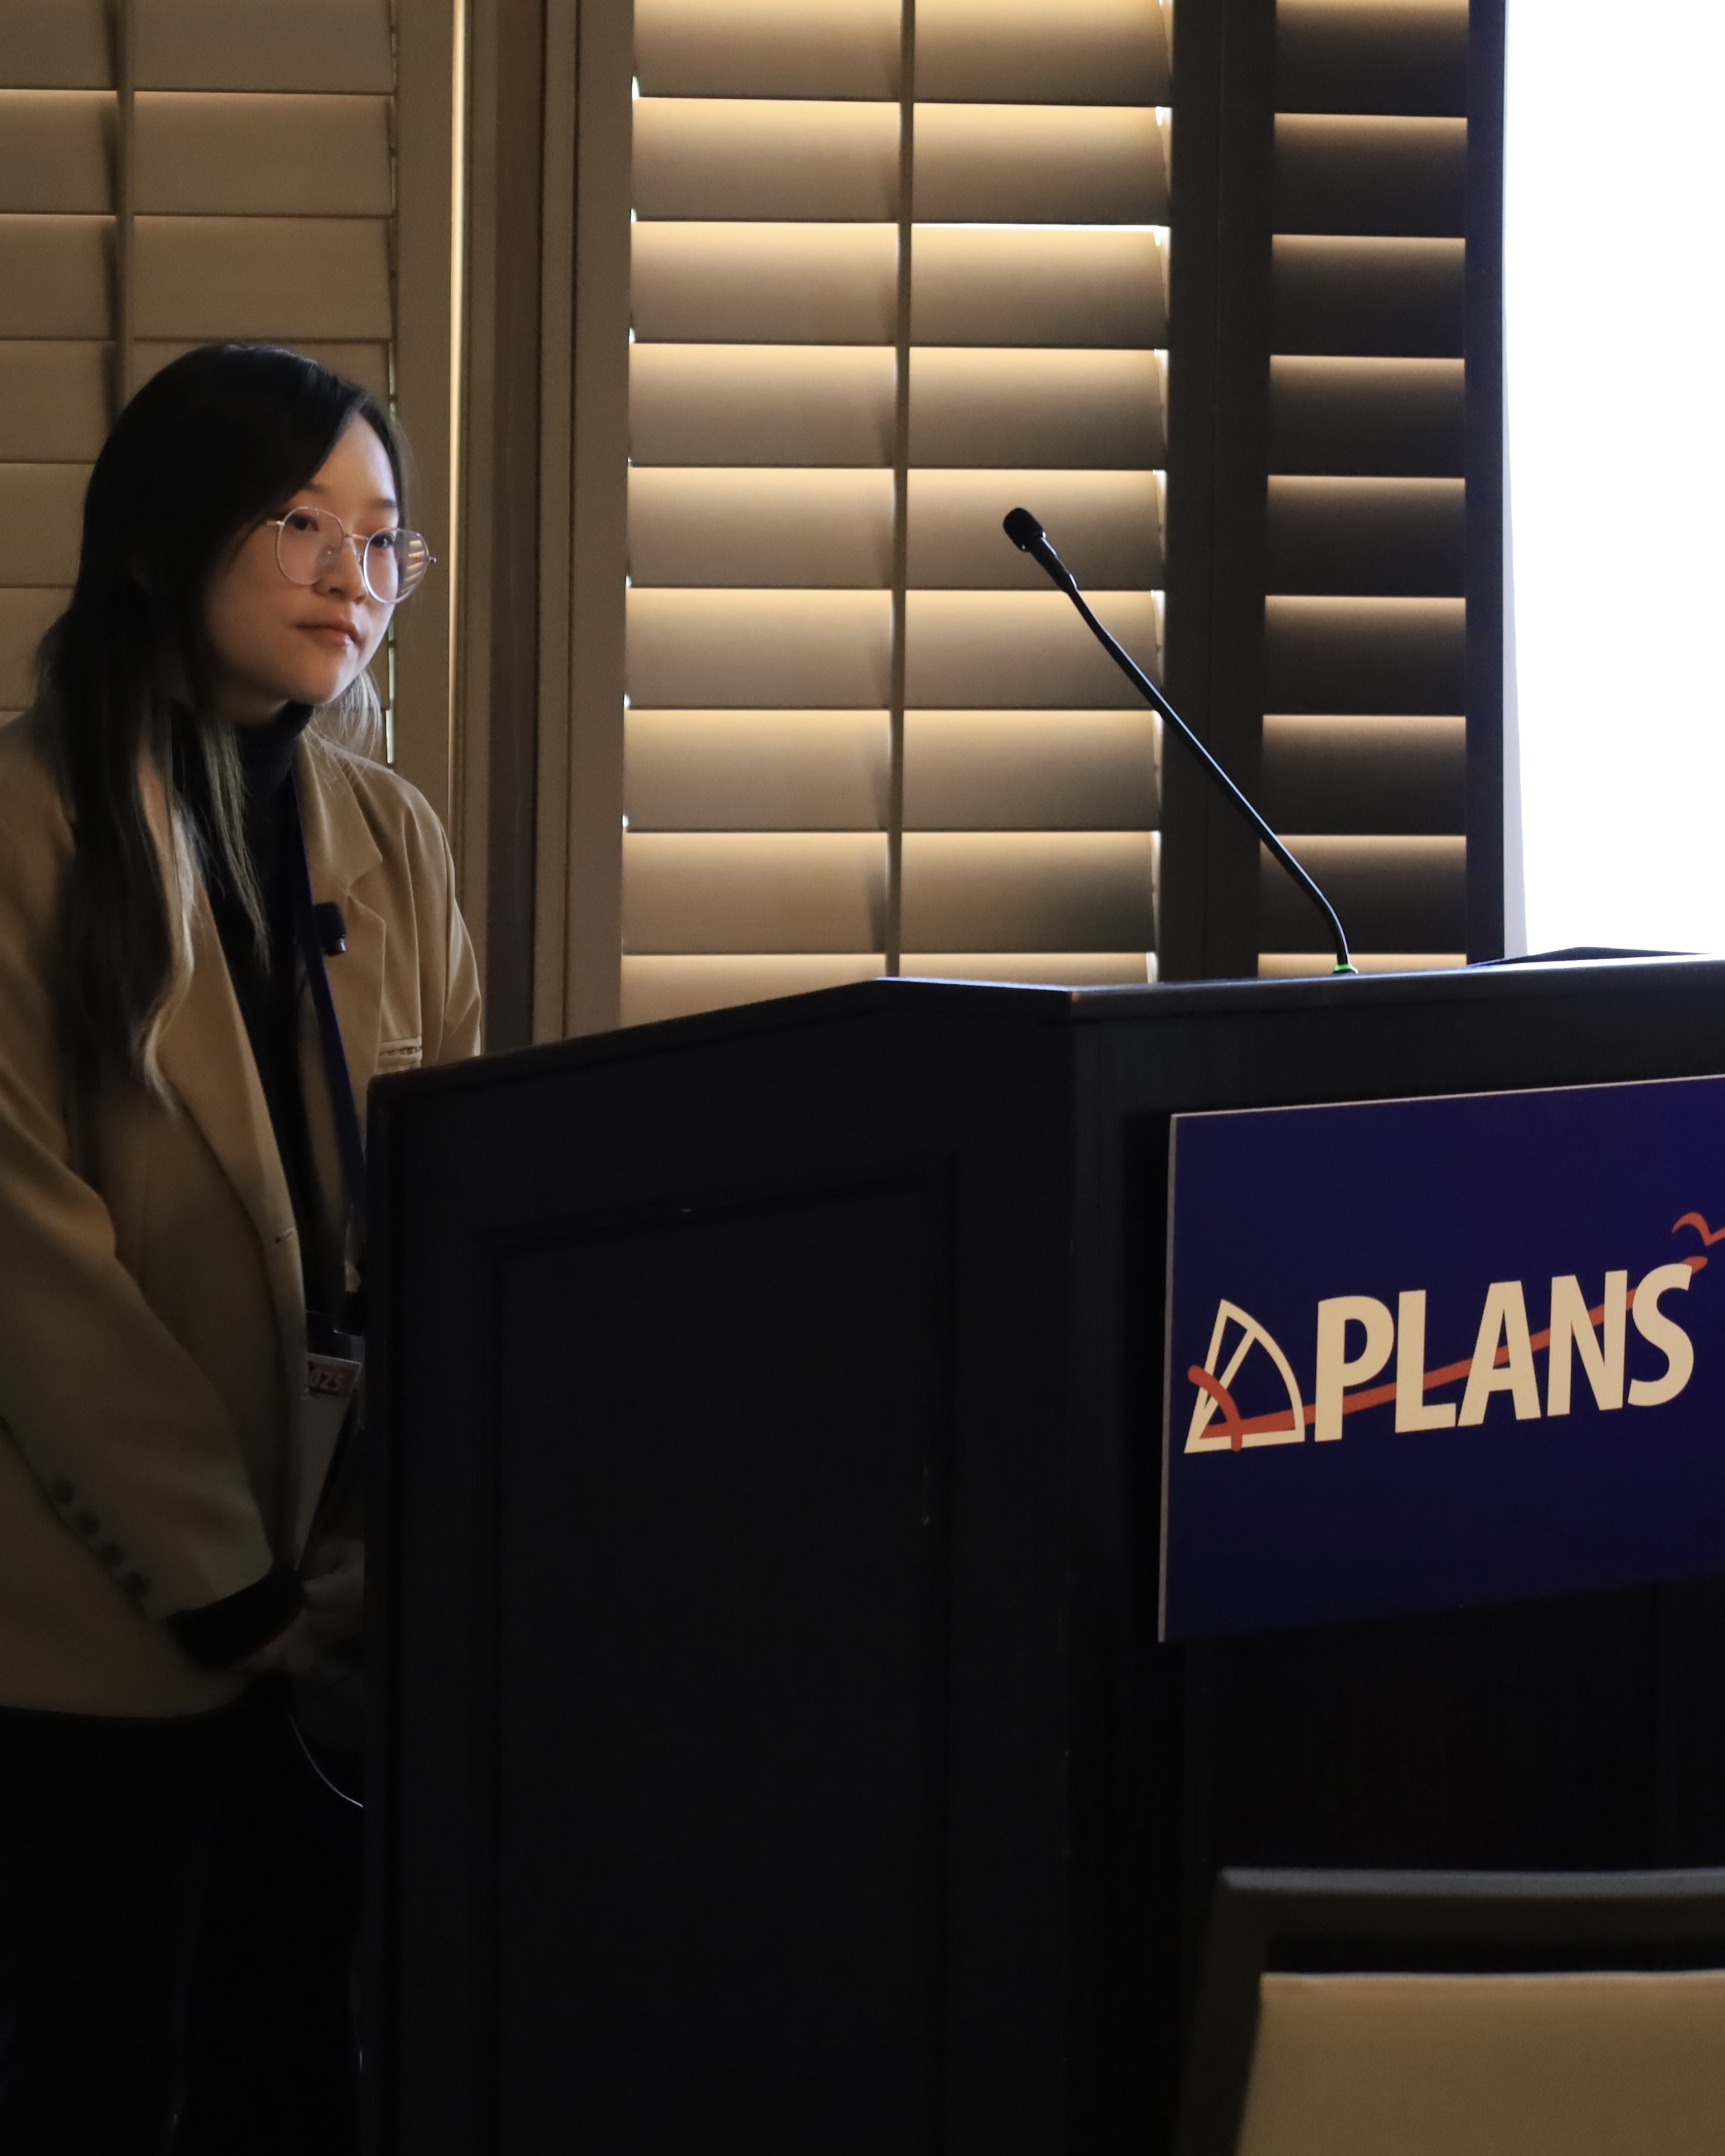
From 28 April to 1 May 2025, PhD student Ruijie Xu from the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) attended the IEEE/ION Position, Location and Navigation Symposium (PLANS) in Salt Lake City, Utah, USA. At this leading conference for positioning, navigation and timing technologies, Xu presented the paper Tightly-Coupled Wi-Fi/LiDAR/Inertial Integration via Factor Graph Optimization for UAS.
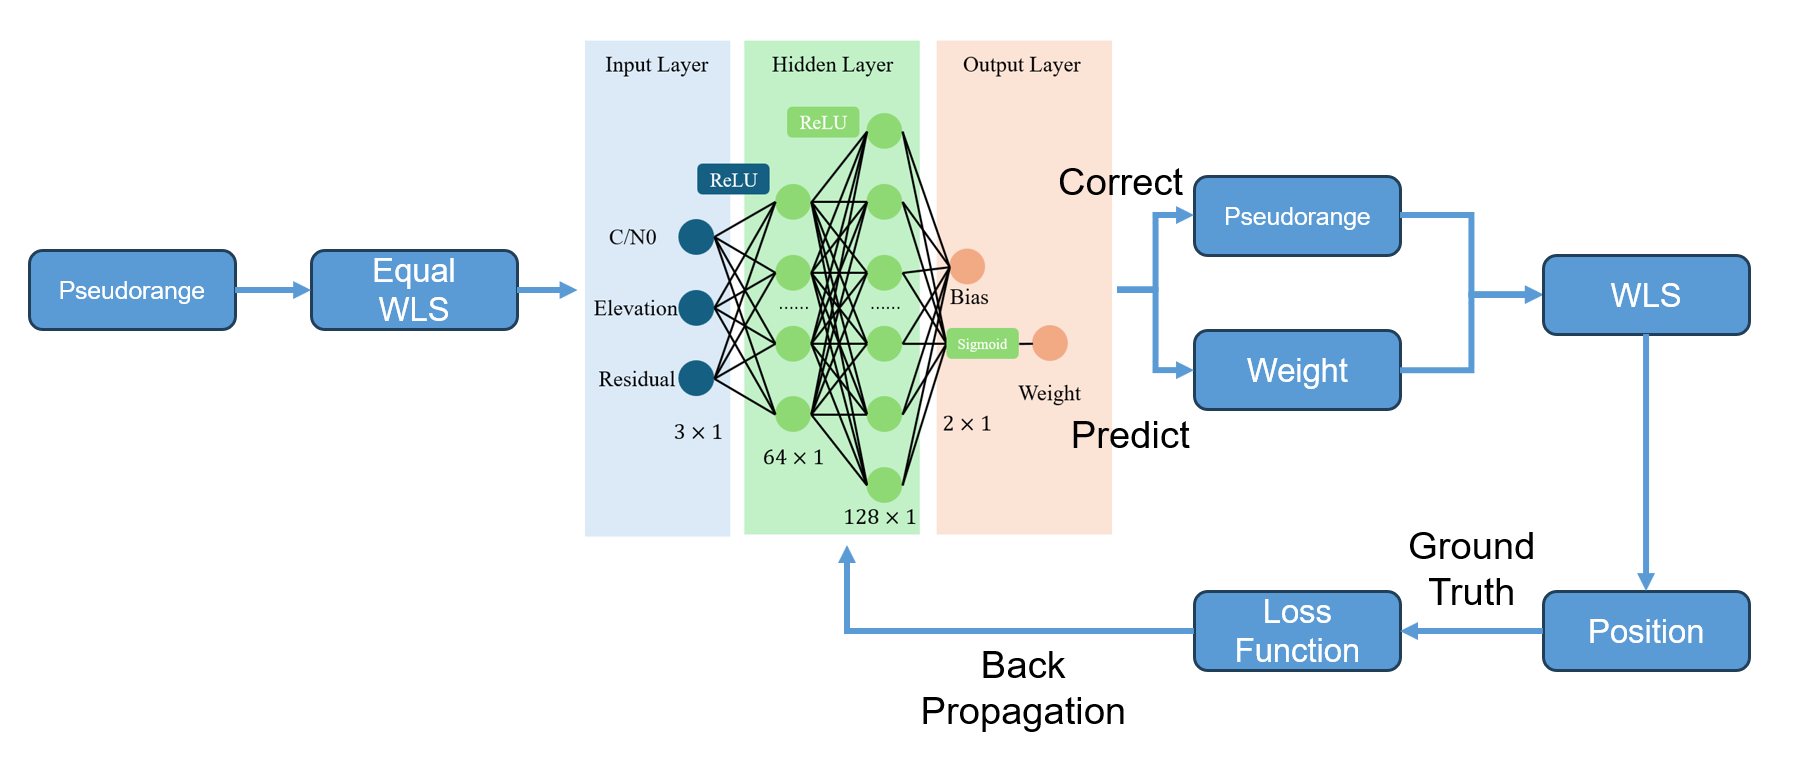
Our paper “pyrtklib: An open-source package for tightly coupled deep learning and GNSS integration for positioning in urban canyons” by Runzhi Hu, Penghui Xu, Yihan Zhong and Weisong Wen has been accepted by the IEEE Transactions on Intelligent Transportation Systems. Congratulations to Runzhi and the co-authors. The open-source code is available on GitHub.
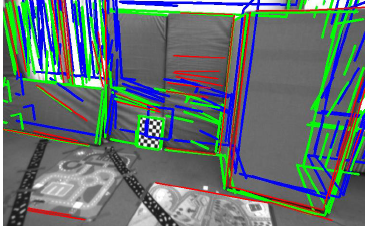
Our paper “Safety-quantifiable Line Feature-based Monocular Visual Localization with 3D Prior Map” by Xi Zheng, Weisong Wen and Li-Ta Hsu has been accepted by the IEEE Transactions on Intelligent Transportation Systems. Congratulations to Xi Zheng and the co-authors. The open-source code is available on GitHub.
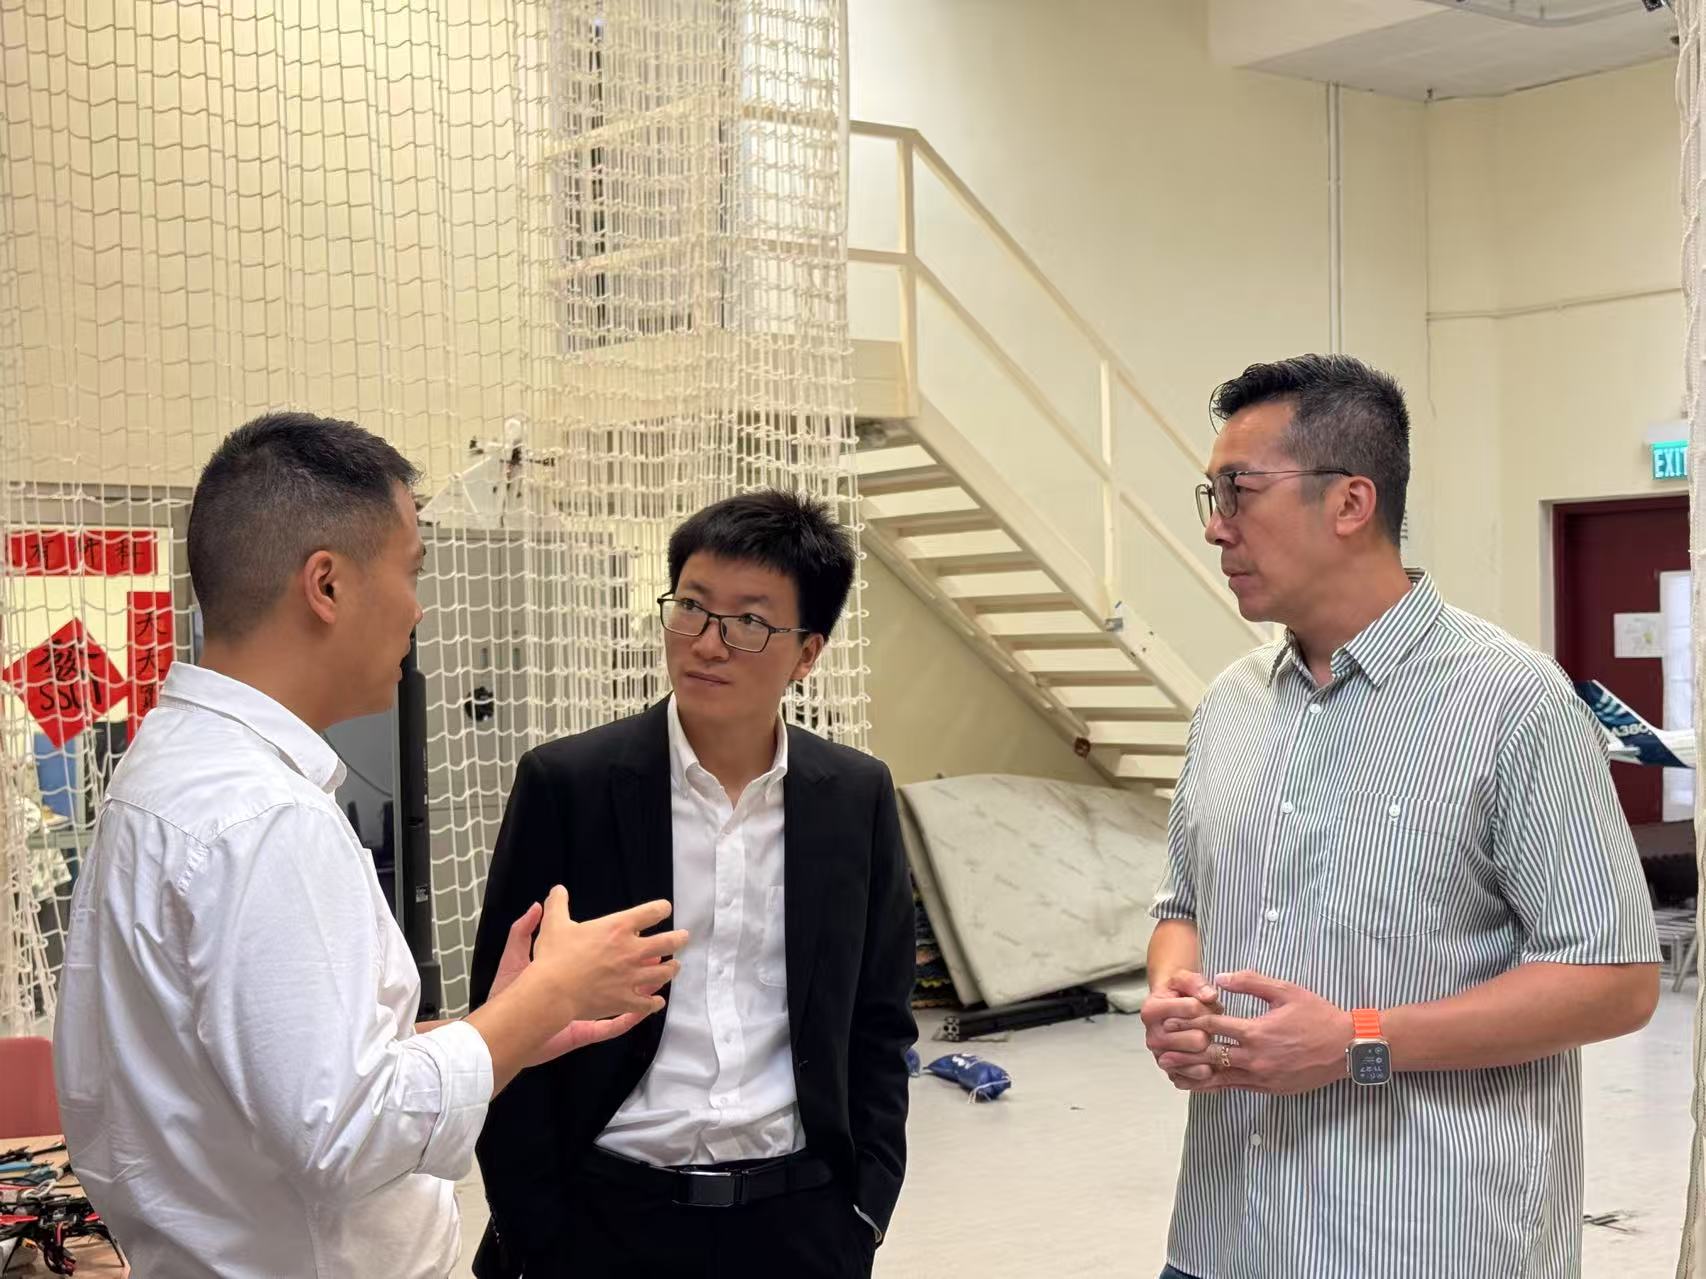
On 30 April 2025, the UAV Team of the Hong Kong Police Force, led by Superintendent KO Chung-ying of the Key and Search Division of the Major Events Division, visited the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU). The visit aimed to facilitate technical exchange and explore opportunities for collaboration in UAV technology and safety.
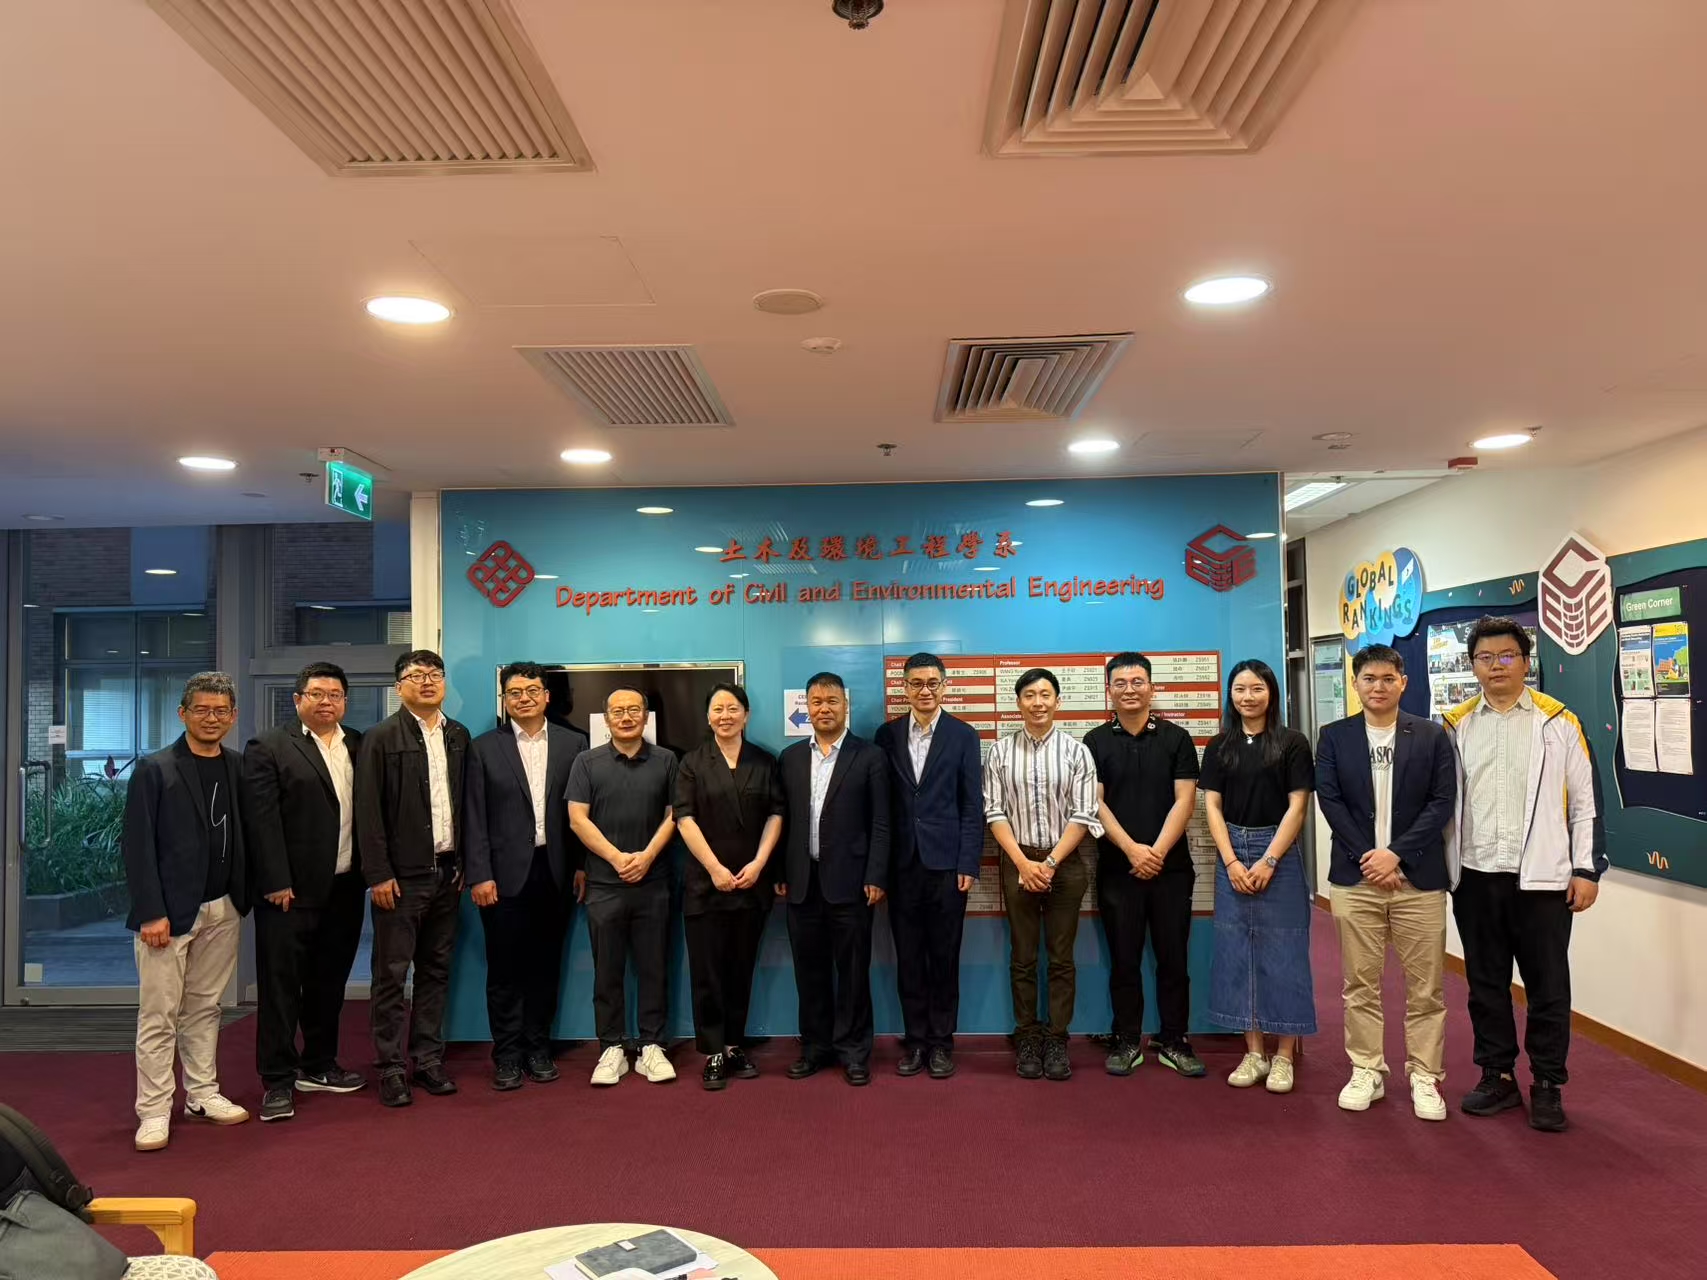
On 28 April 2025, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) hosted an information exchange session with the Zhejiang Handover and Maintenance Engineering Branch Company and PolyU’s Department of Civil and Environmental Engineering (CEE). The session focused on cross-boundary knowledge sharing on UAV-enabled inspection technologies and on integrating autonomous UAV systems into next-generation infrastructure maintenance.
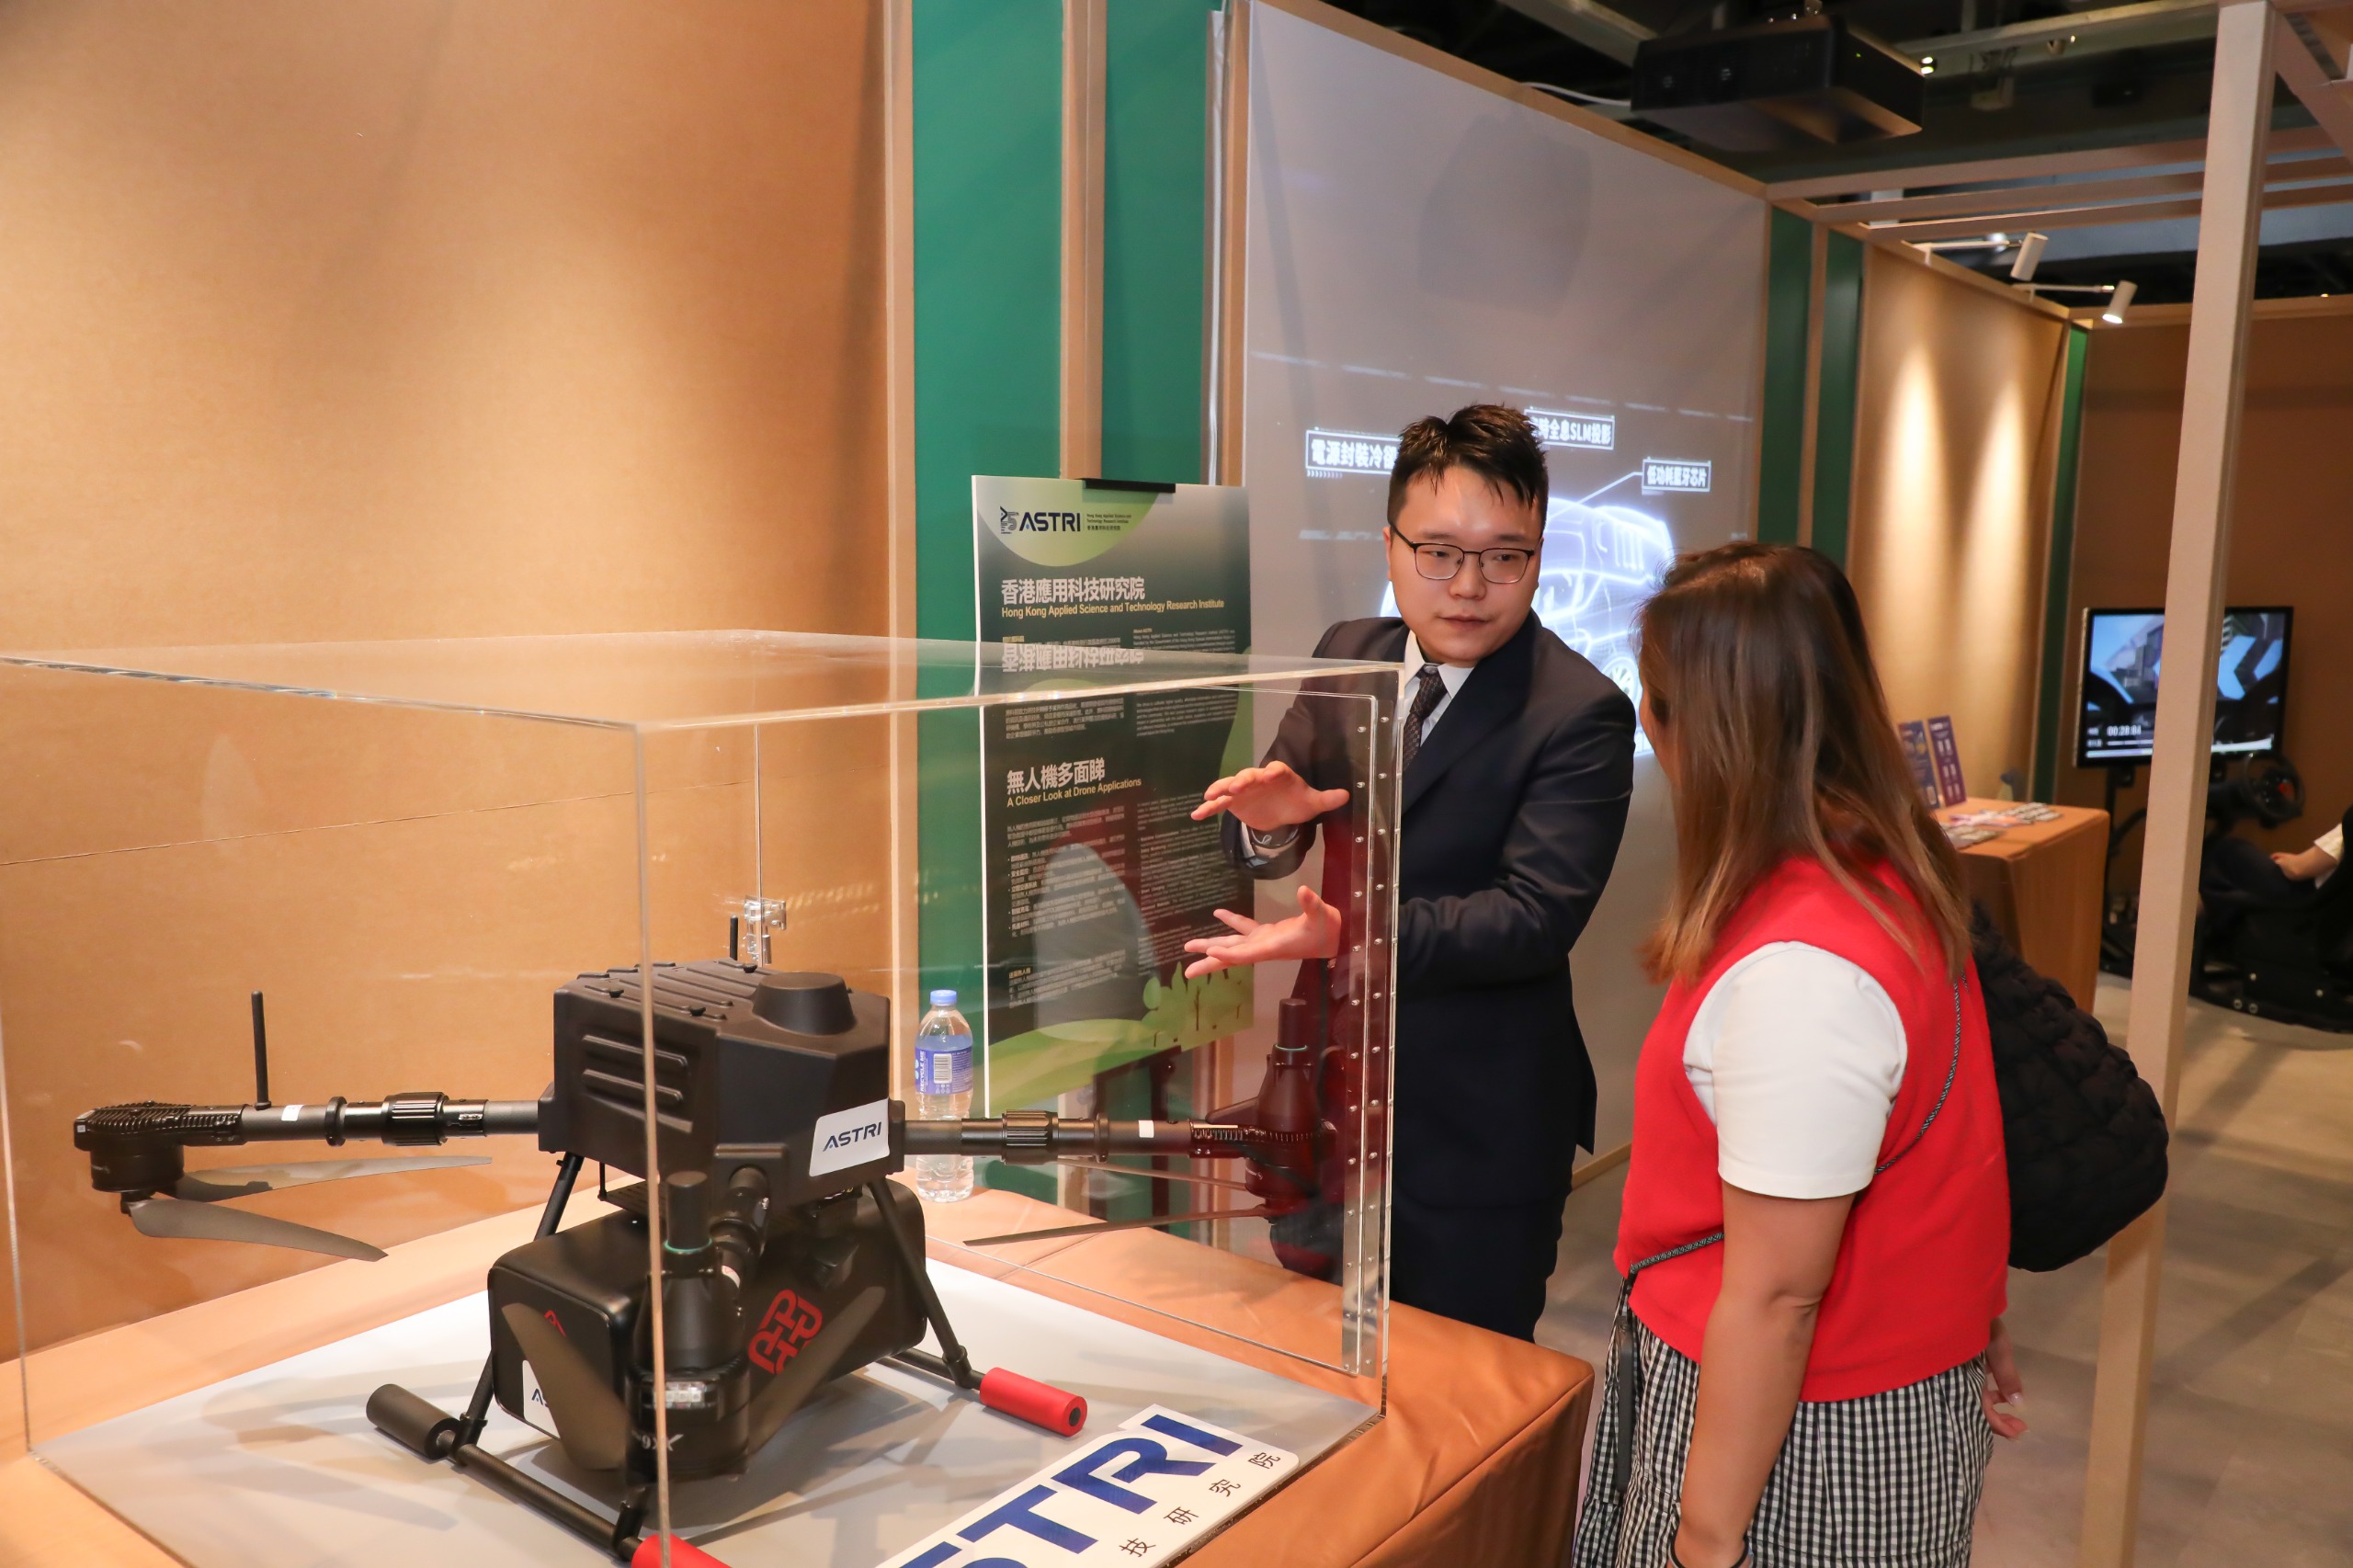
In April 2025, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) demonstrated its Medical Delivery Drone System at the Hong Kong Science Festival (HK SciFest) in Hong Kong, drawing significant public and media attention. The project was featured in an exclusive interview by Radio Television Hong Kong (RTHK), which highlighted its potential to transform emergency medical supply chains in remote and urban areas.
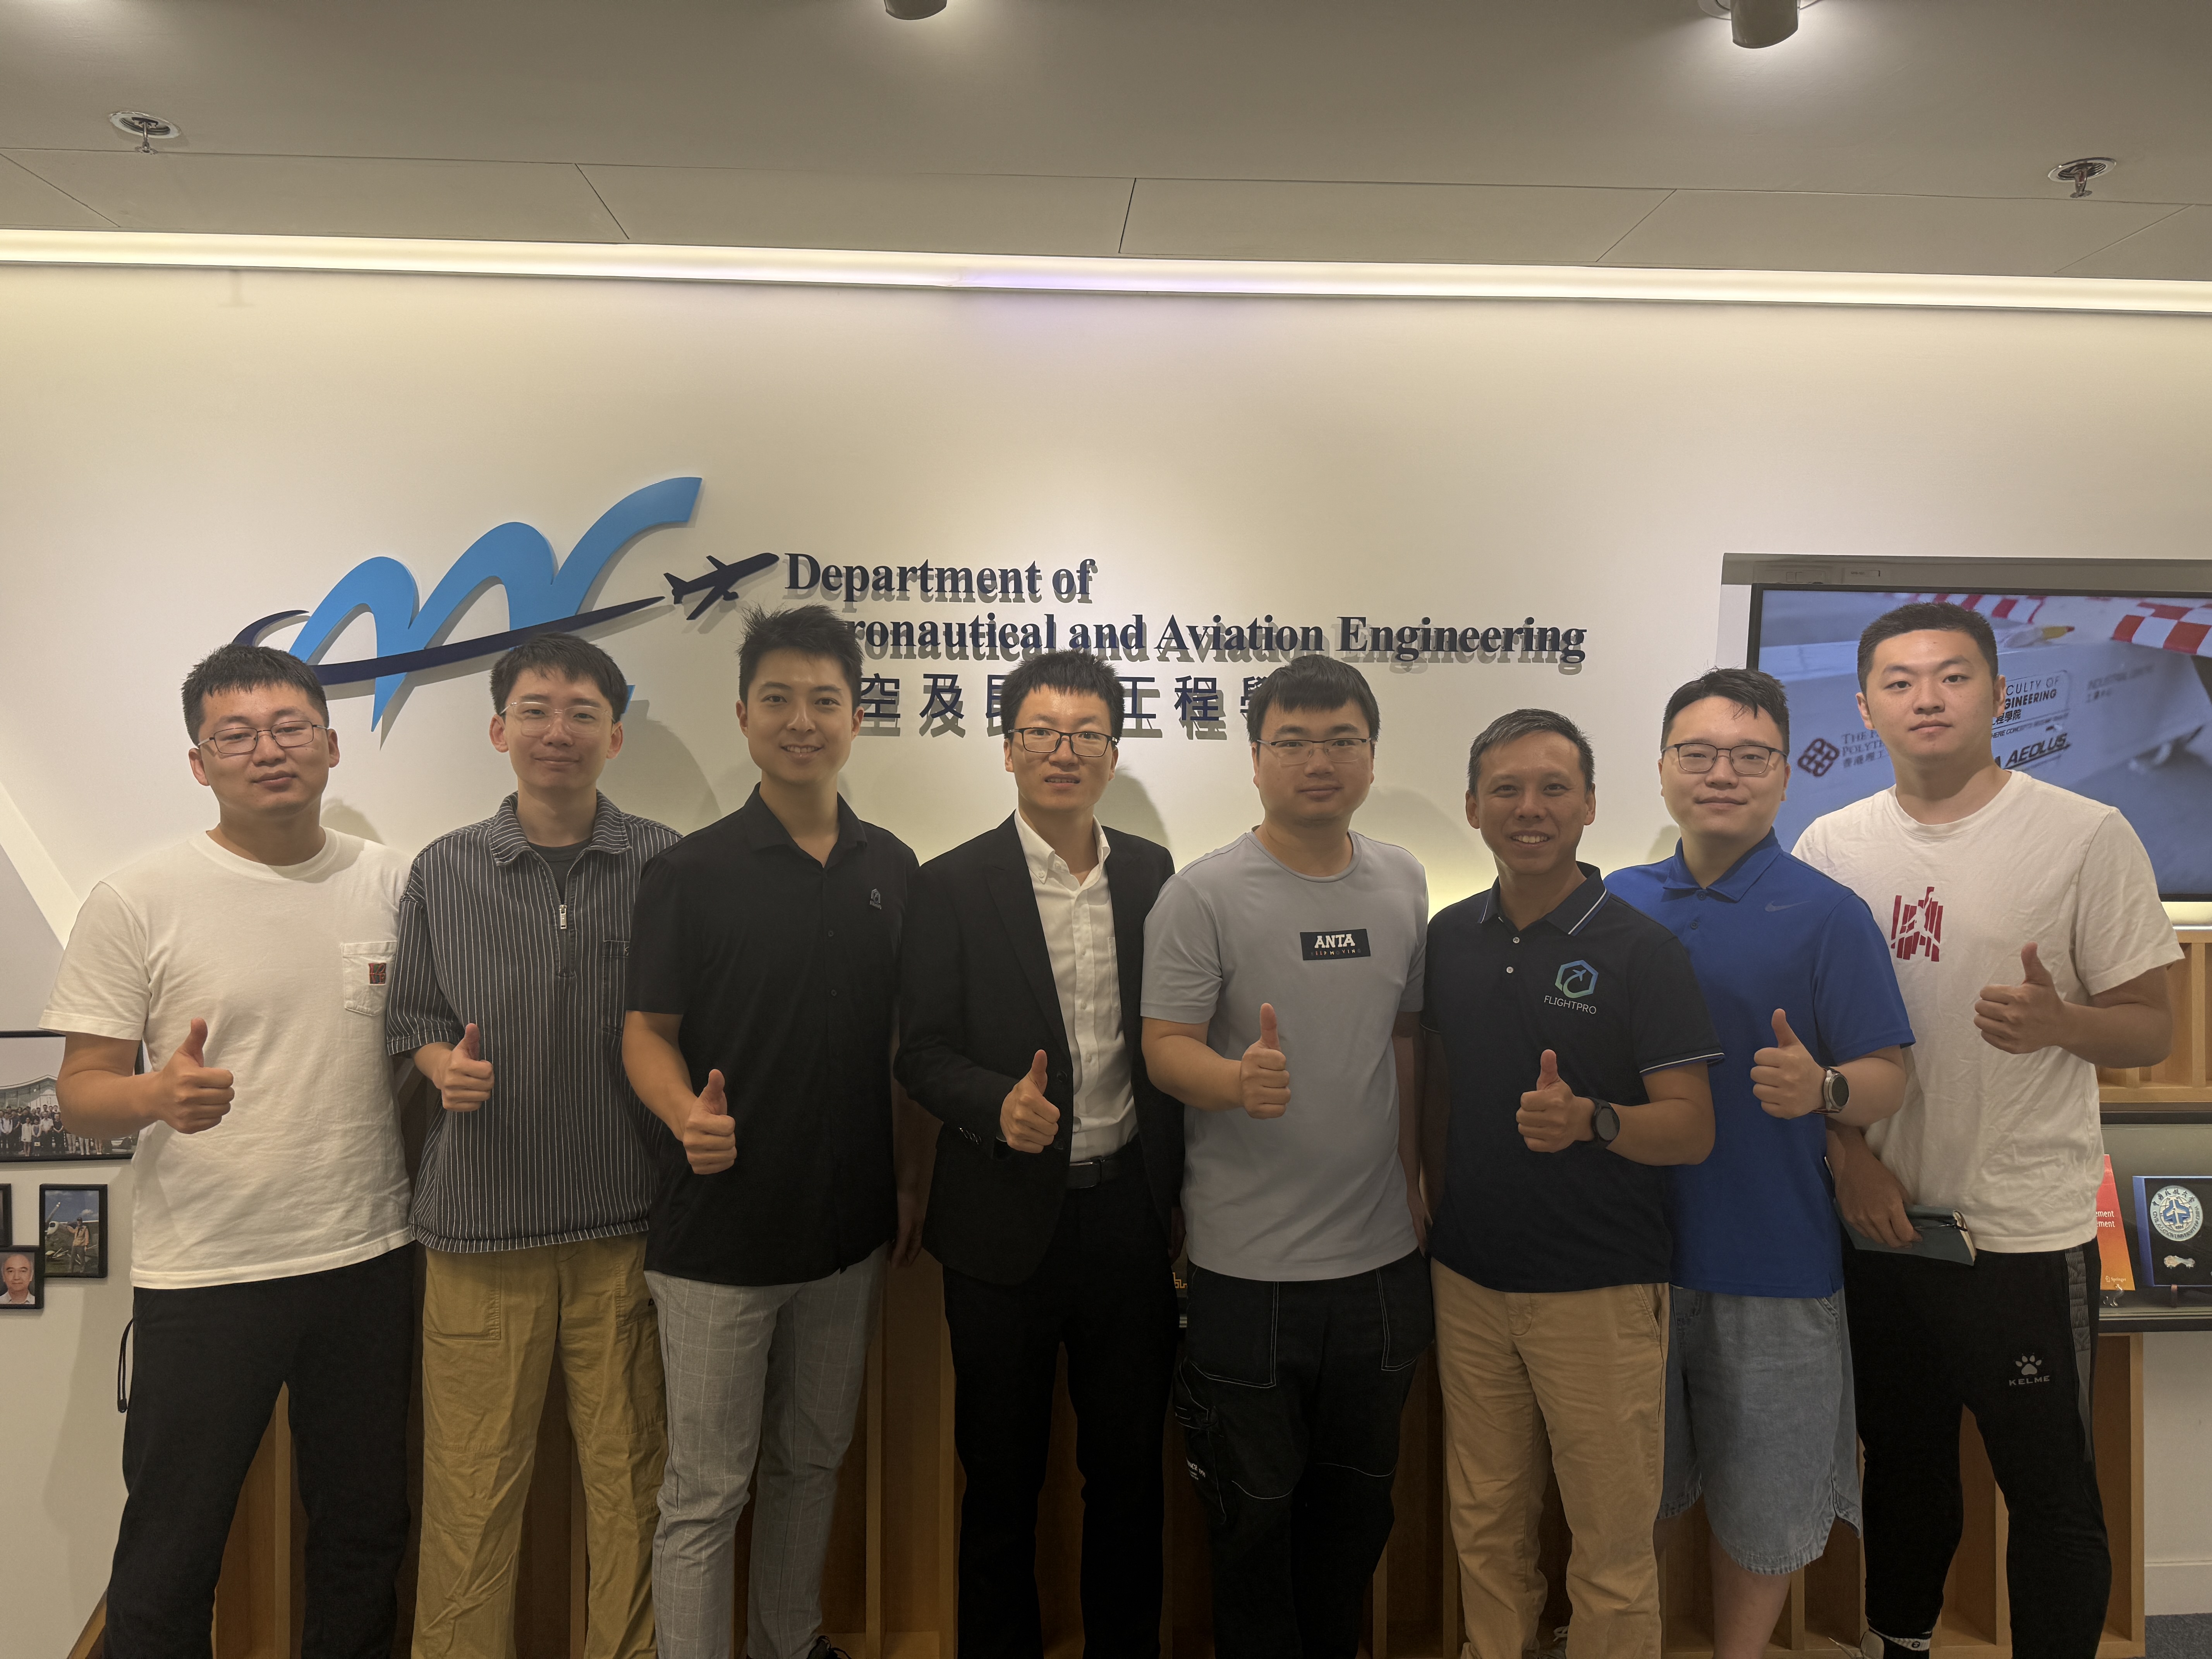
In April 2025, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) hosted an exchange meeting in Hong Kong with FlightPro, a UAV consultancy and training firm. The two sides explored synergies in talent development, regulatory compliance and real-world application testing. The discussions centred on using FlightPro’s industry expertise to support TASLAB’s research commercialisation efforts, particularly in Hong Kong’s growing low-altitude economy (LAE) ecosystem.
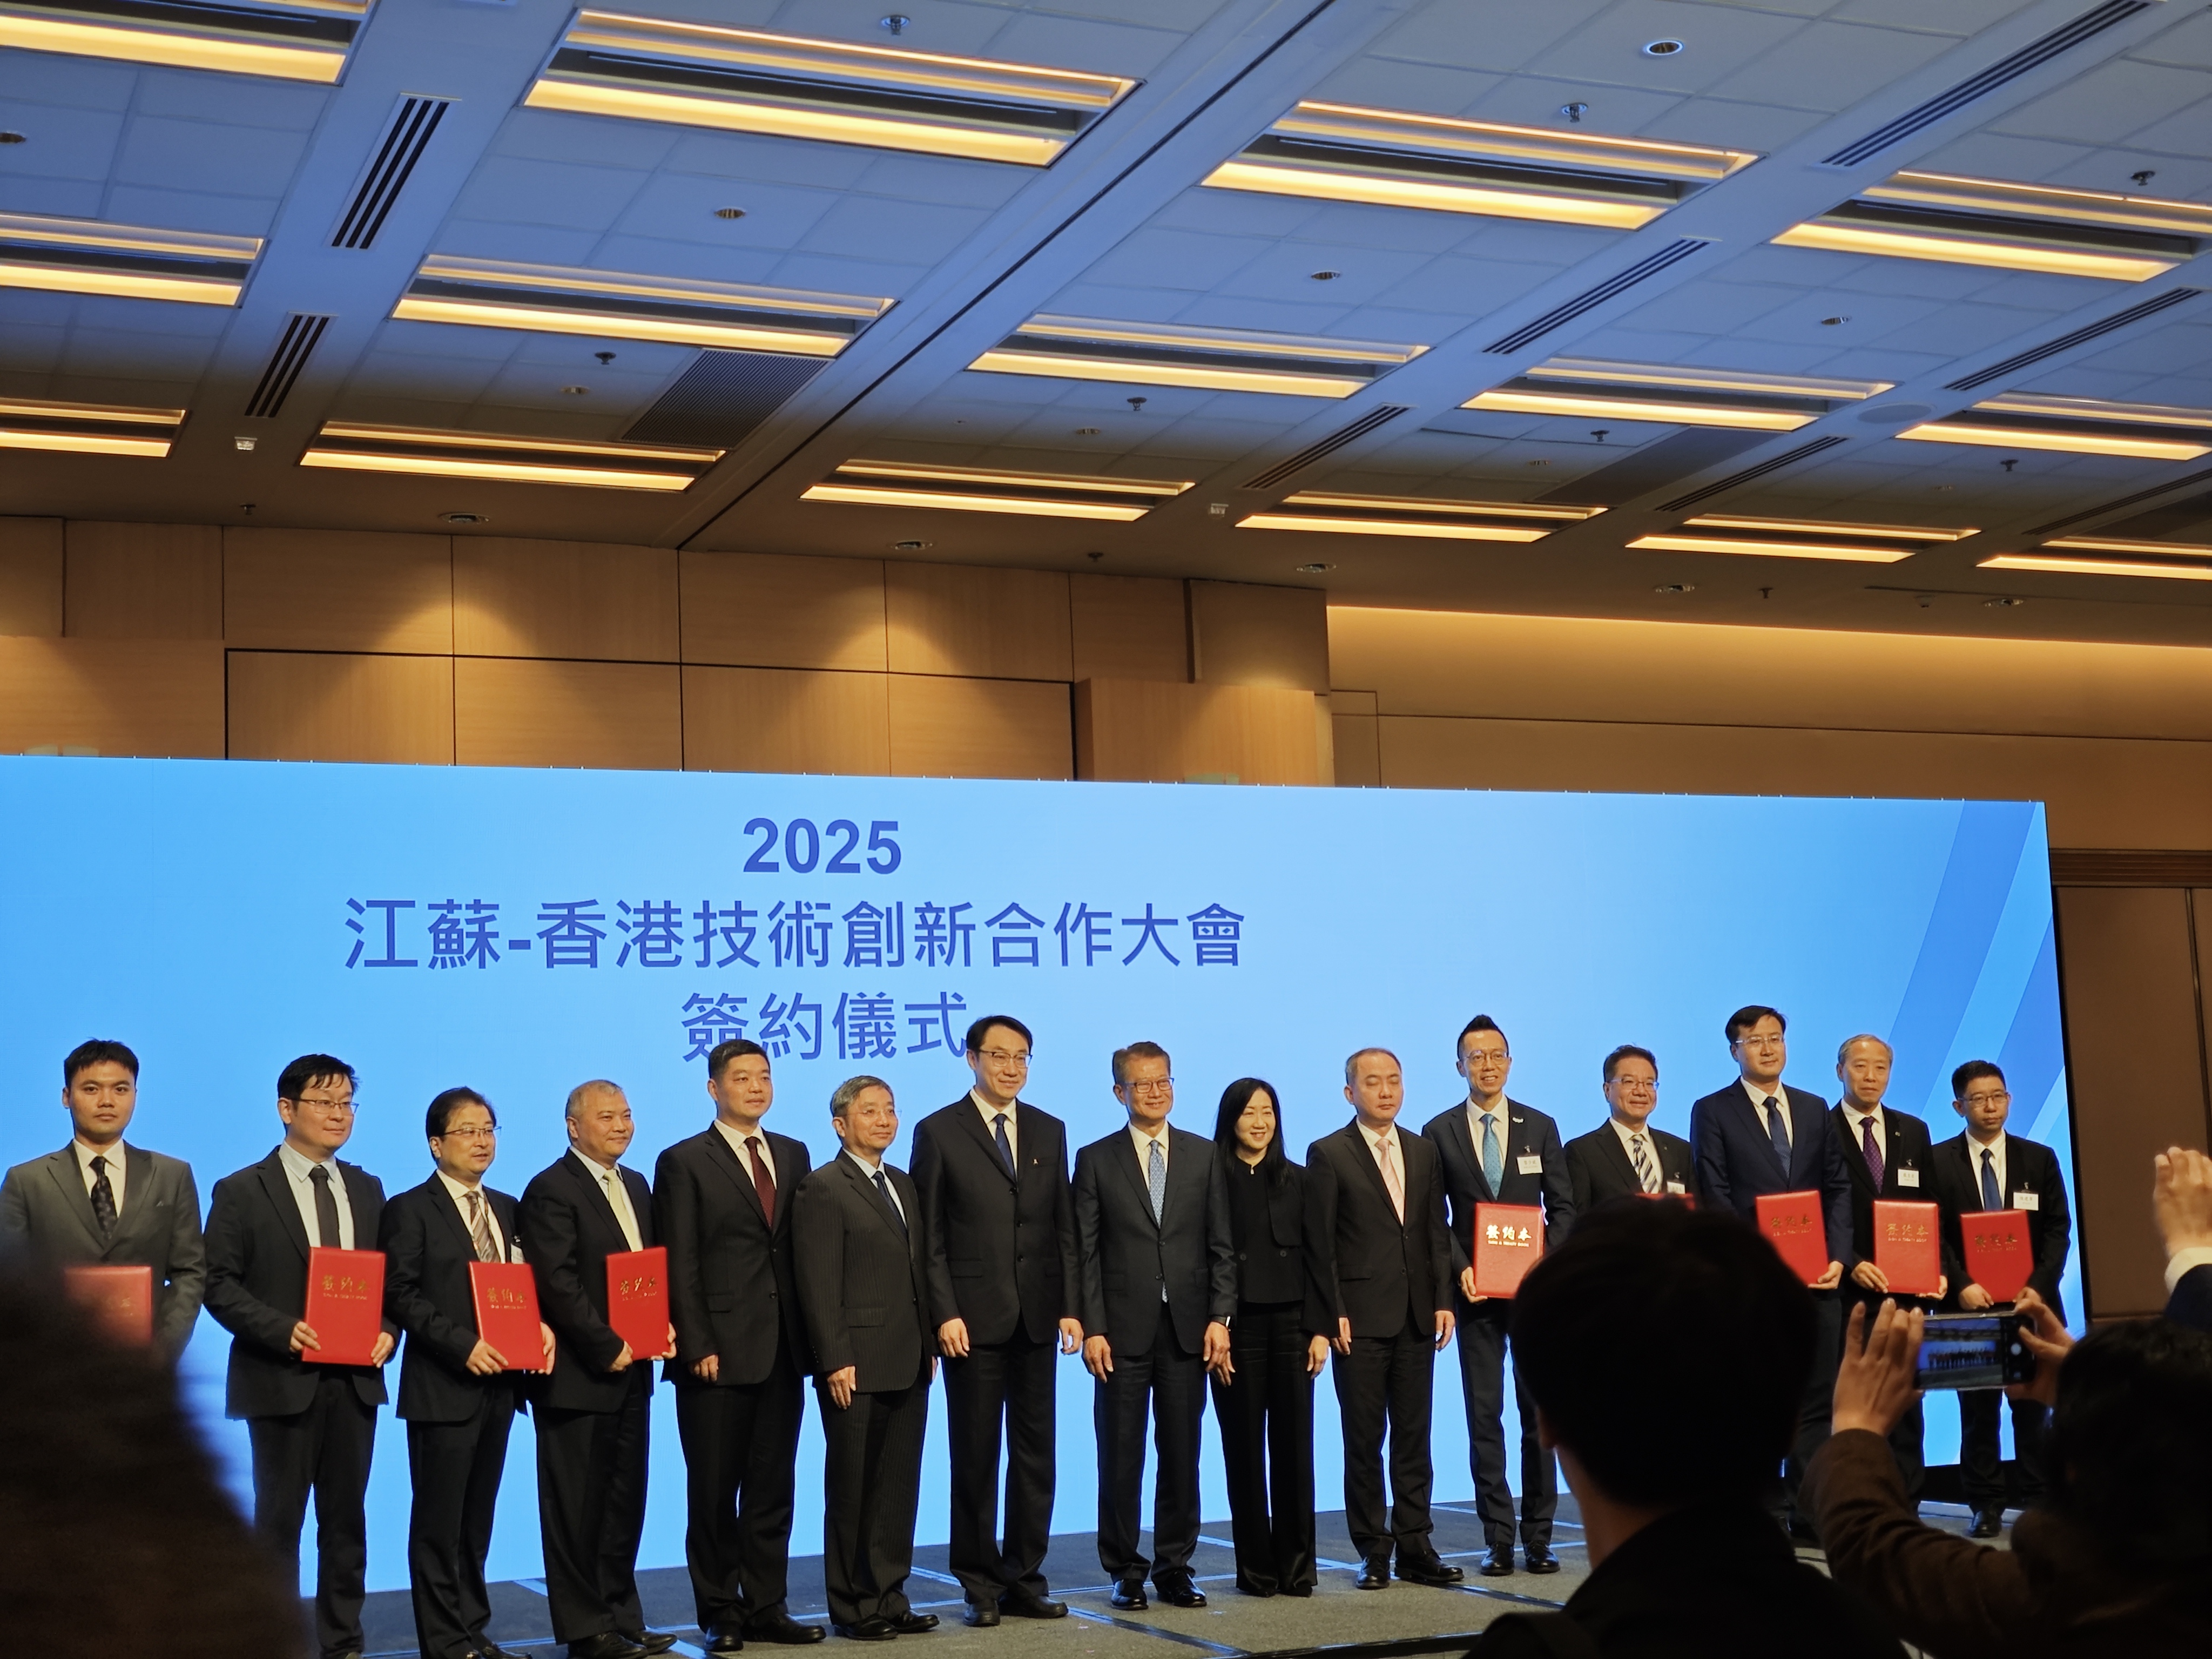
On 14 April 2025, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) presented its Smart Building Cleaning UAV System at InnoEX 2025, Asia’s innovation and technology expo in Hong Kong. The system was demonstrated to a delegation of enterprise leaders from Jiangsu Province, China. It aims to transform high-rise building maintenance through autonomous aerial robotics, in line with national goals for smart city development and low-altitude economy (LAE) growth.
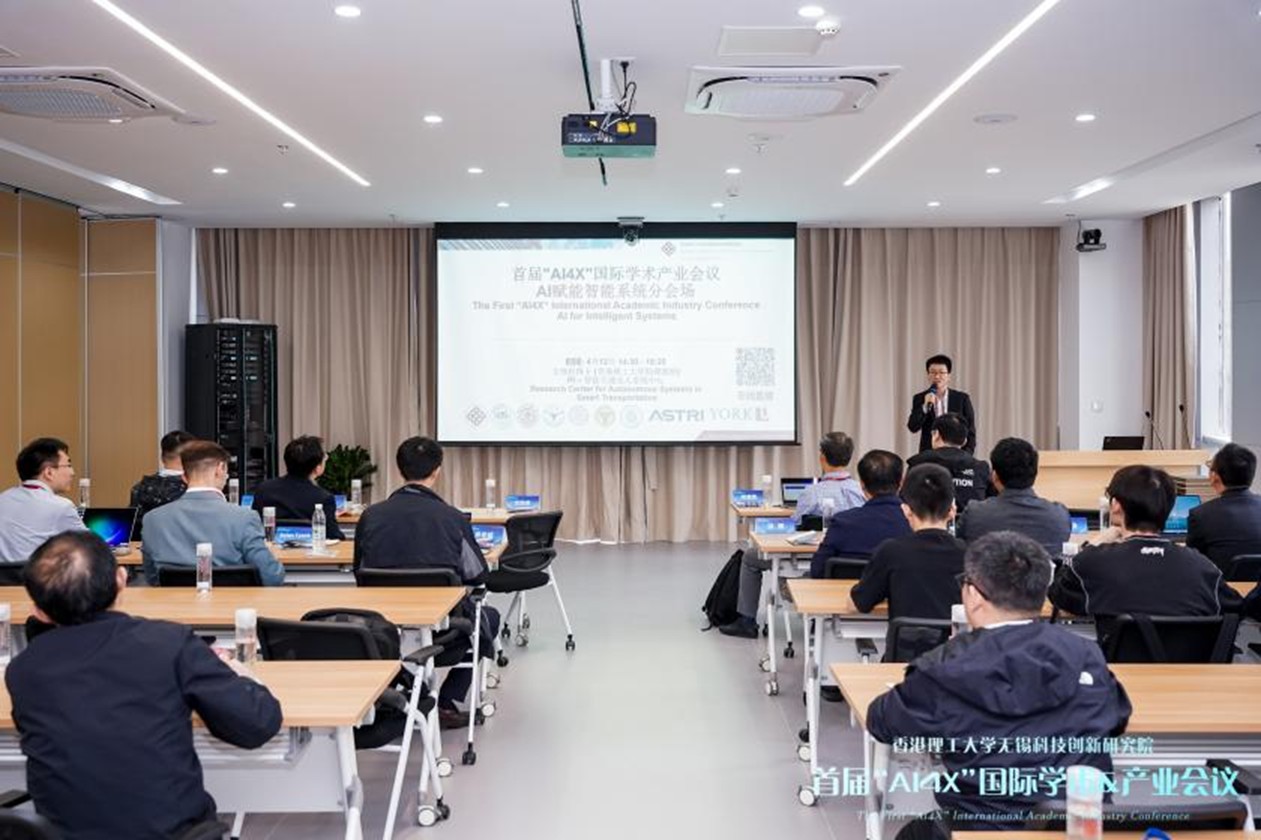
The inaugural “AI4X” International Academic and Industry Conference in Wuxi featured a dedicated sub-forum on AI-powered intelligent systems and the low-altitude economy. The forum brought together experts from academia and industry to discuss new developments in autonomous vehicles, drones and embodied intelligence. Attendance in the venue exceeded capacity, and over 2,300 viewers followed the forum online, many of them young and urban audiences. The full programme is available on the conference poster.
Ph.D. candidate Runzhi has started a Research Student Attachment Programme at the University of New South Wales (UNSW), supervised by Prof. Jinling Wang, a globally recognized authority in precise GNSS positioning and stochastic modeling.
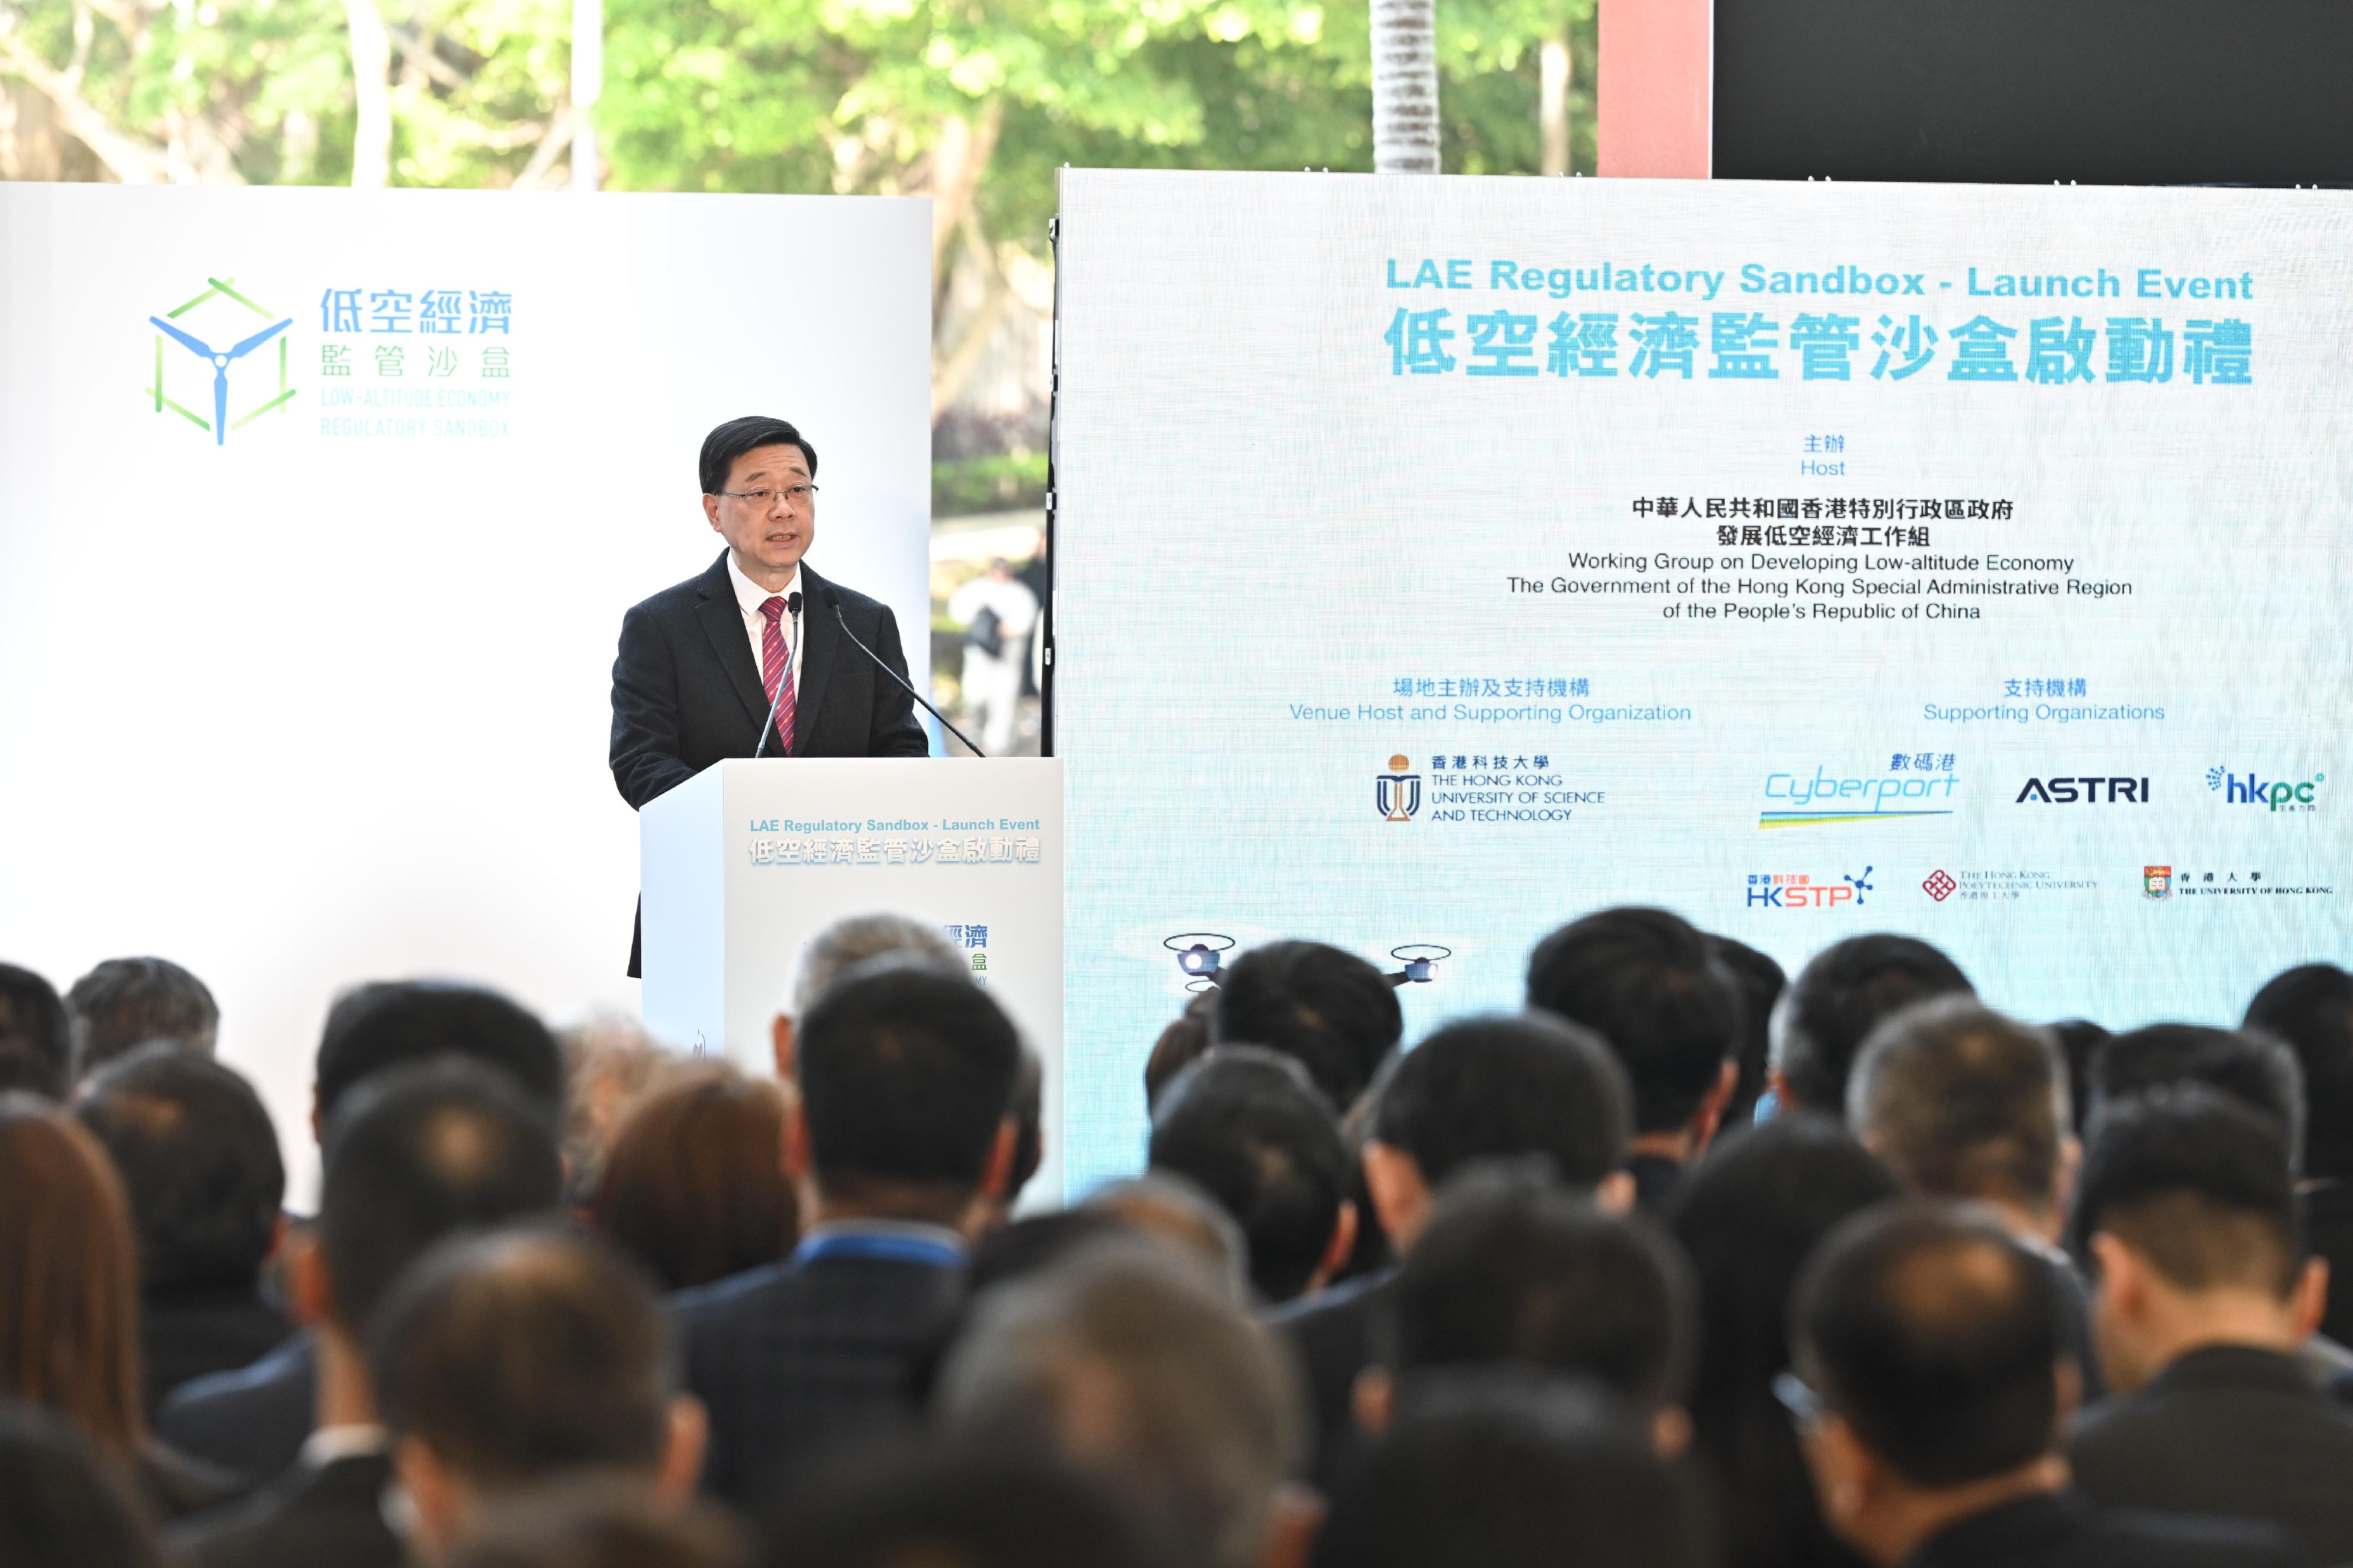
HONG KONG, April 2025 — The Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) has reached a key milestone in urban air mobility. In collaboration with SUTPC Digital Technology (Hong Kong) Limited, TASLAB has secured formal approval for trial operations under the Low-altitude Economy (LAE) Regulatory Sandbox, an initiative led by the Transport and Logistics Bureau (TLB) of the HKSAR Government.
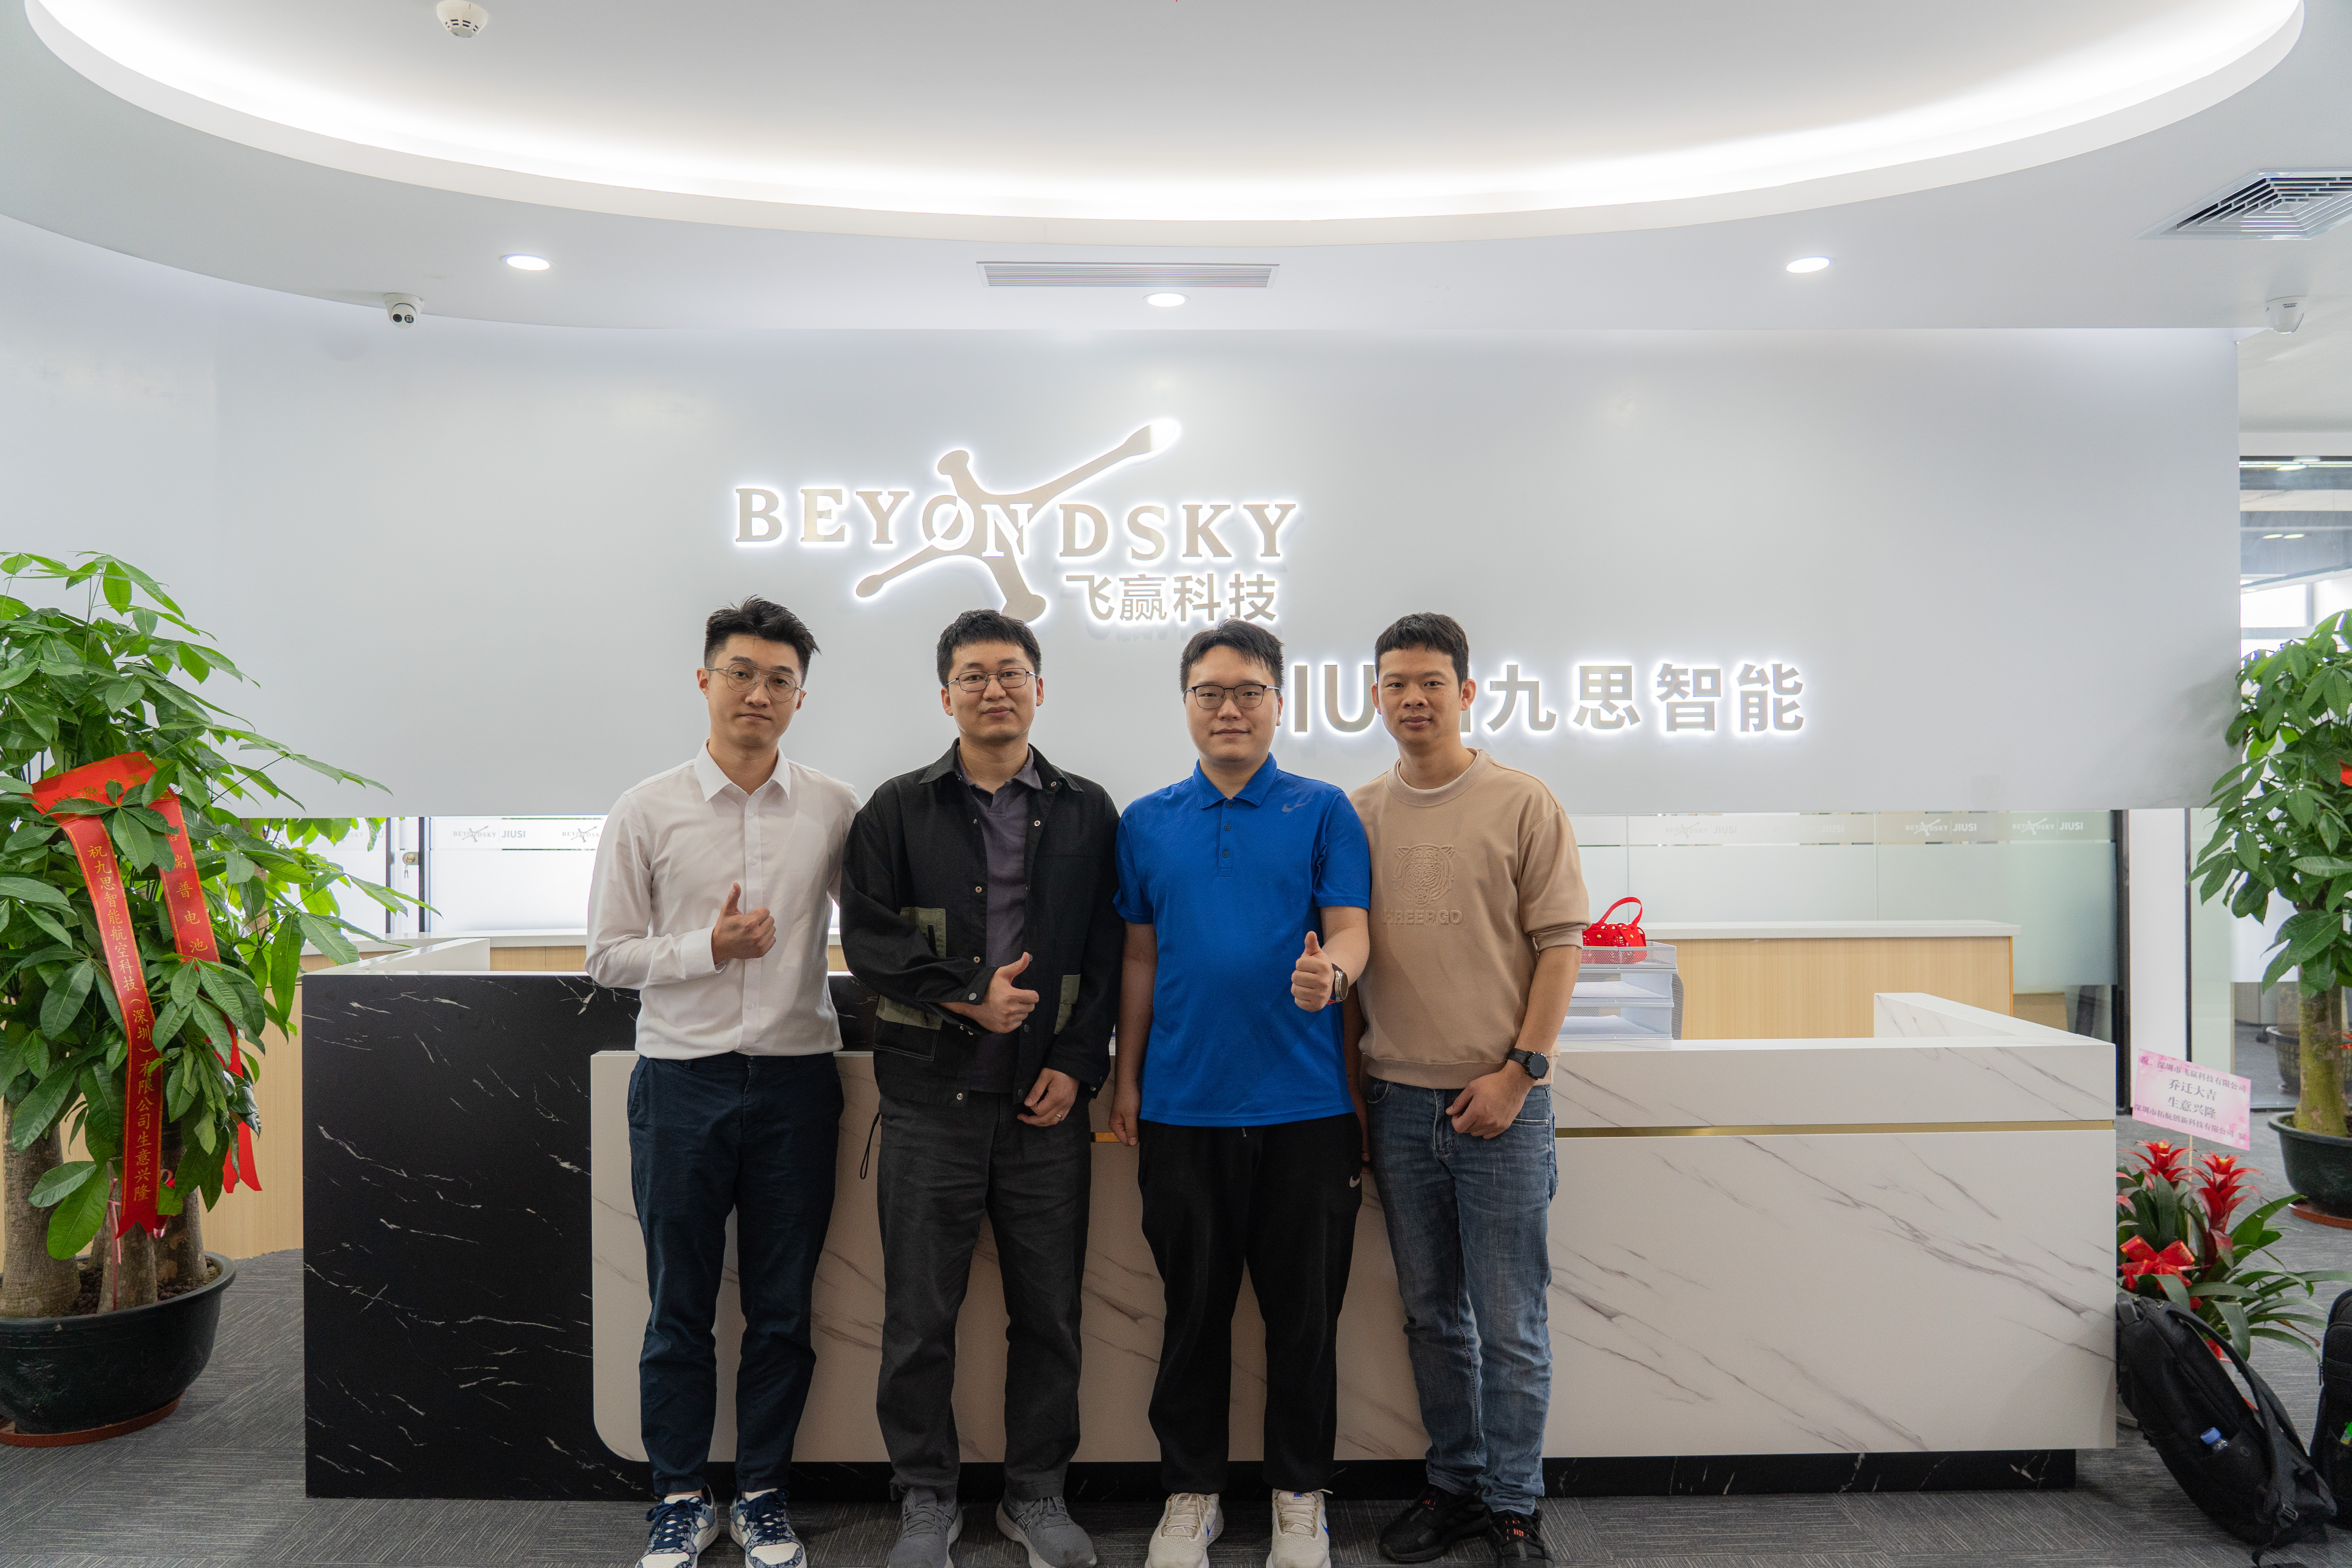
On 27 March 2025, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) visited JIUSI Intelligent Aviation Technology (Shenzhen) Co., Ltd., a provider of autonomous drones for smart city maintenance. The visit, an academic-industry exchange on the future of smart city maintenance, featured a demonstration of Jiusi’s next-generation facade cleaning drone and a knowledge exchange session.
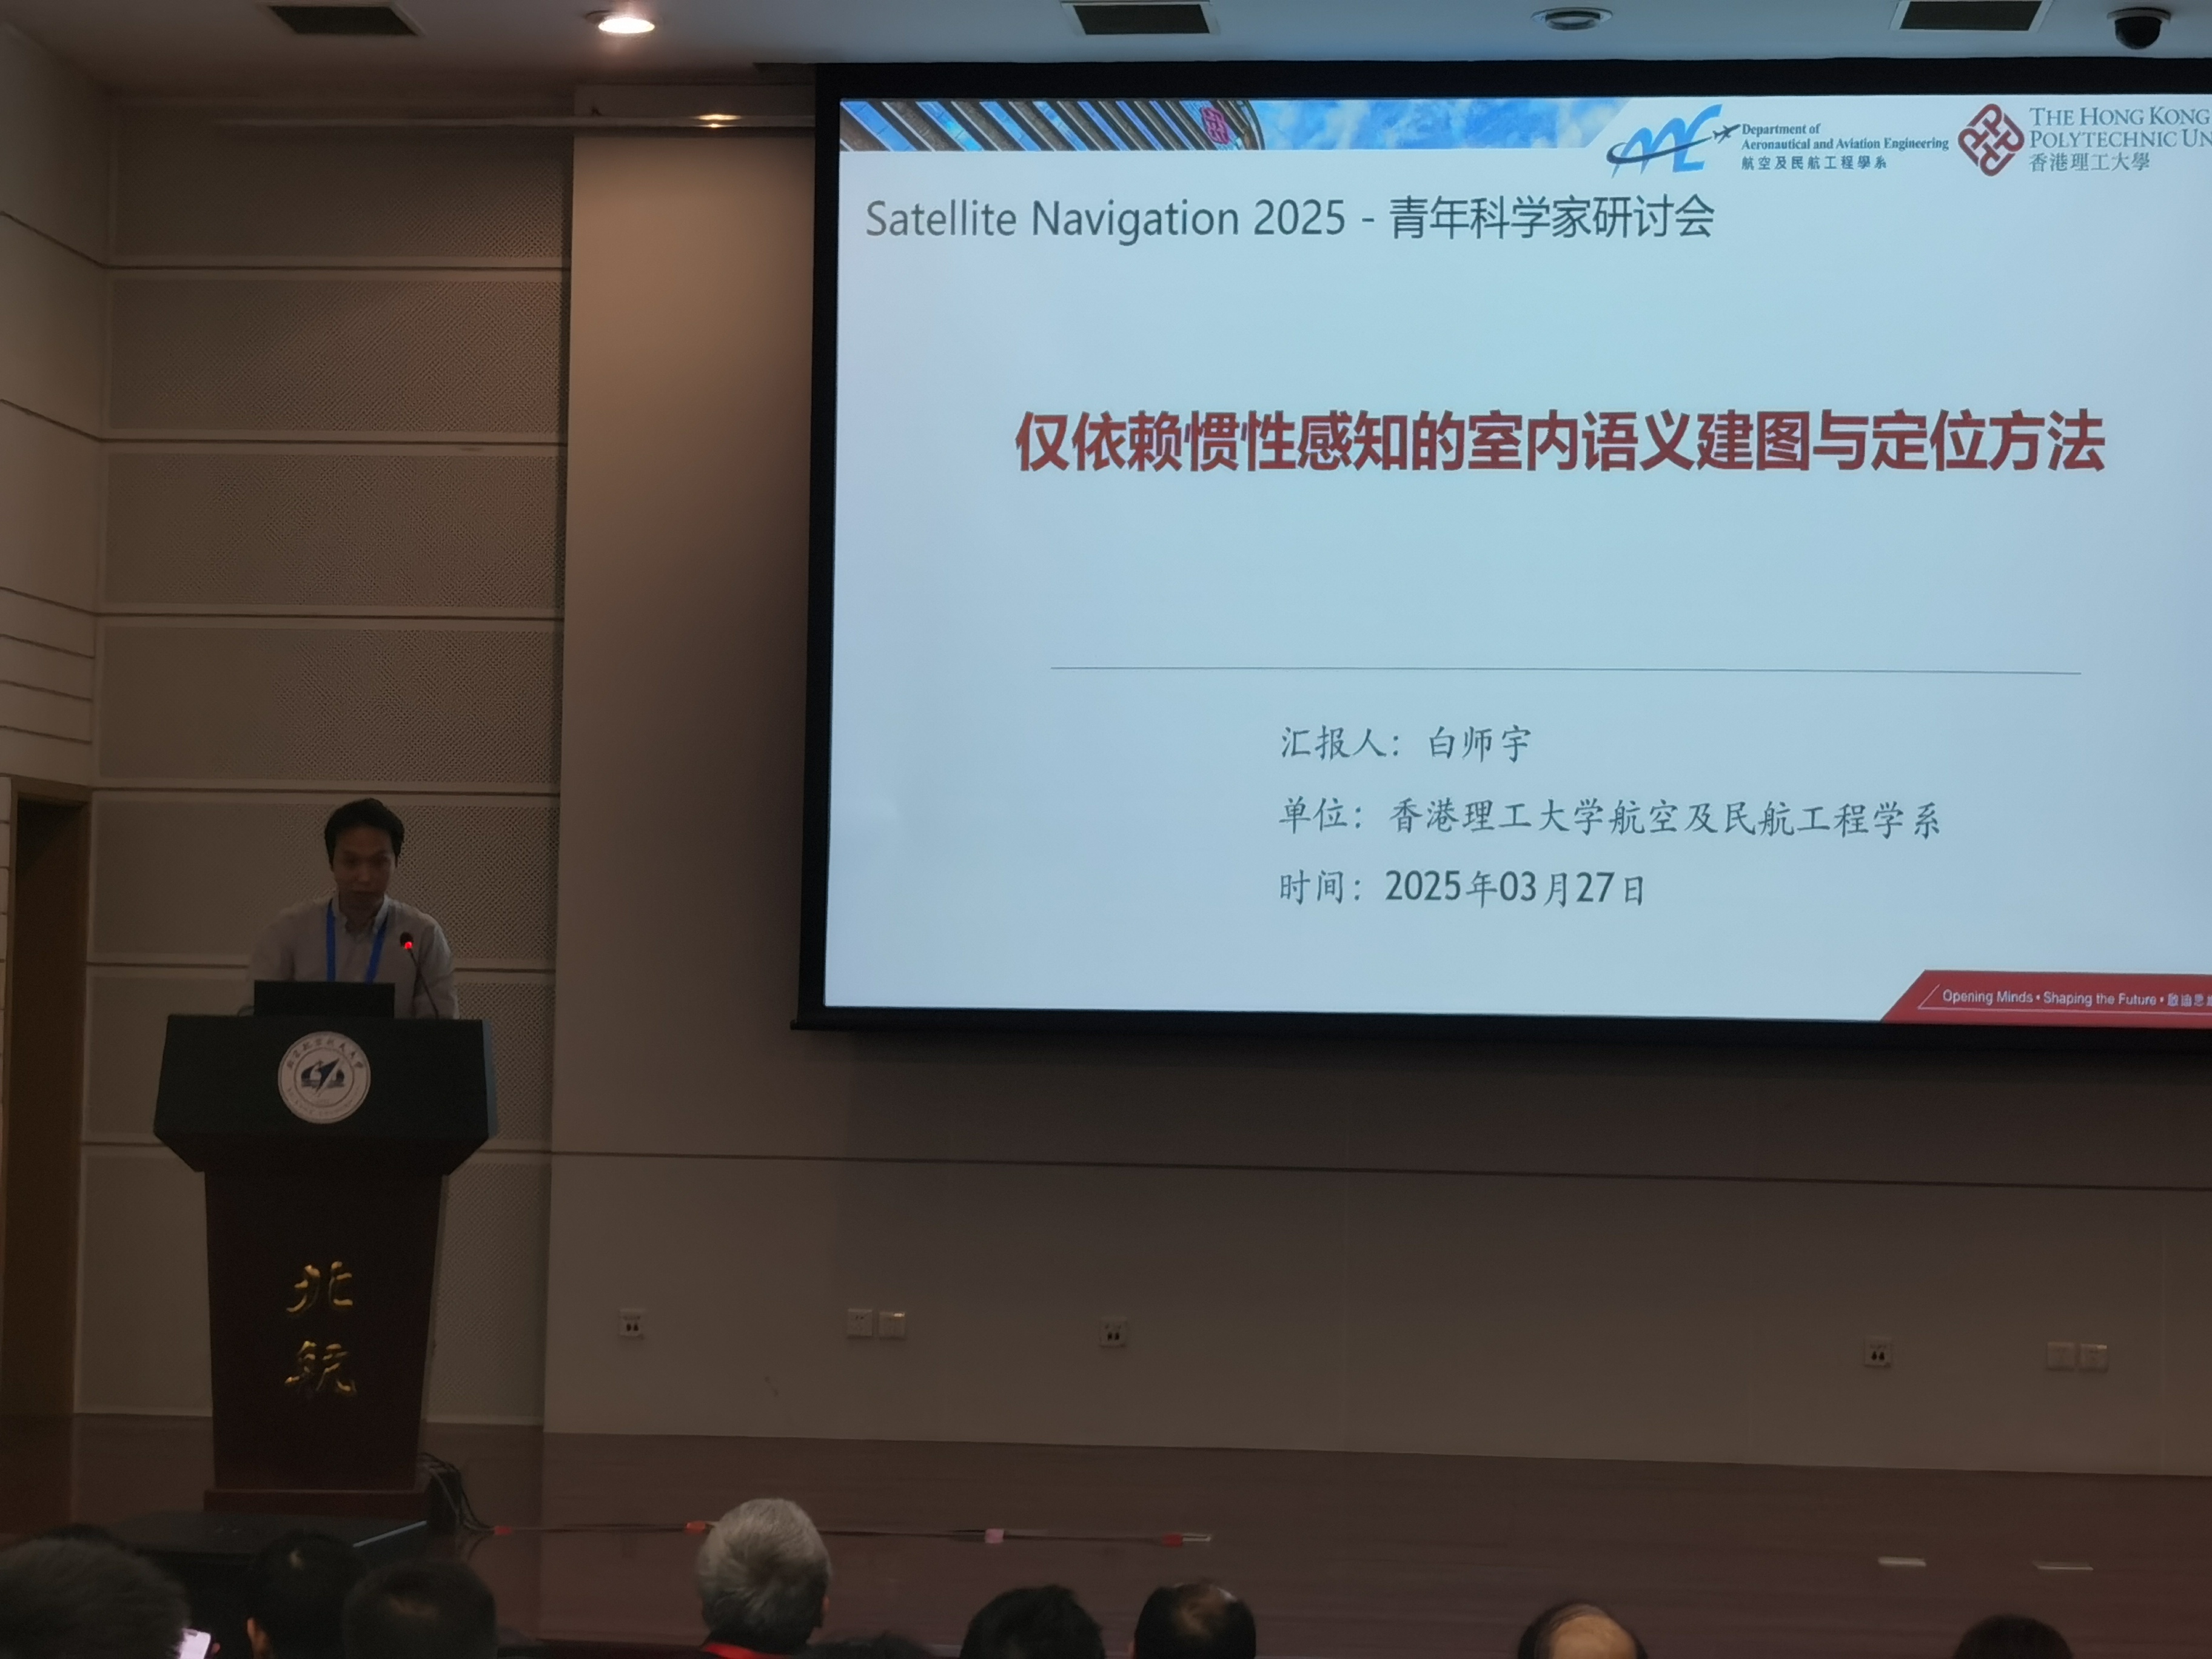
On 27 March 2025, Dr. BAI Shiyu, a postdoctoral fellow of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB), represented the lab with a talk at the Satellite Navigation 2025 – International Workshop for Young Scientists, held at Beihang University. His talk, “Indoor Semantic Mapping and Localization Method Based On Inertial-Only Perception”, highlighted TASLAB’s academic research on indoor pedestrian localization.
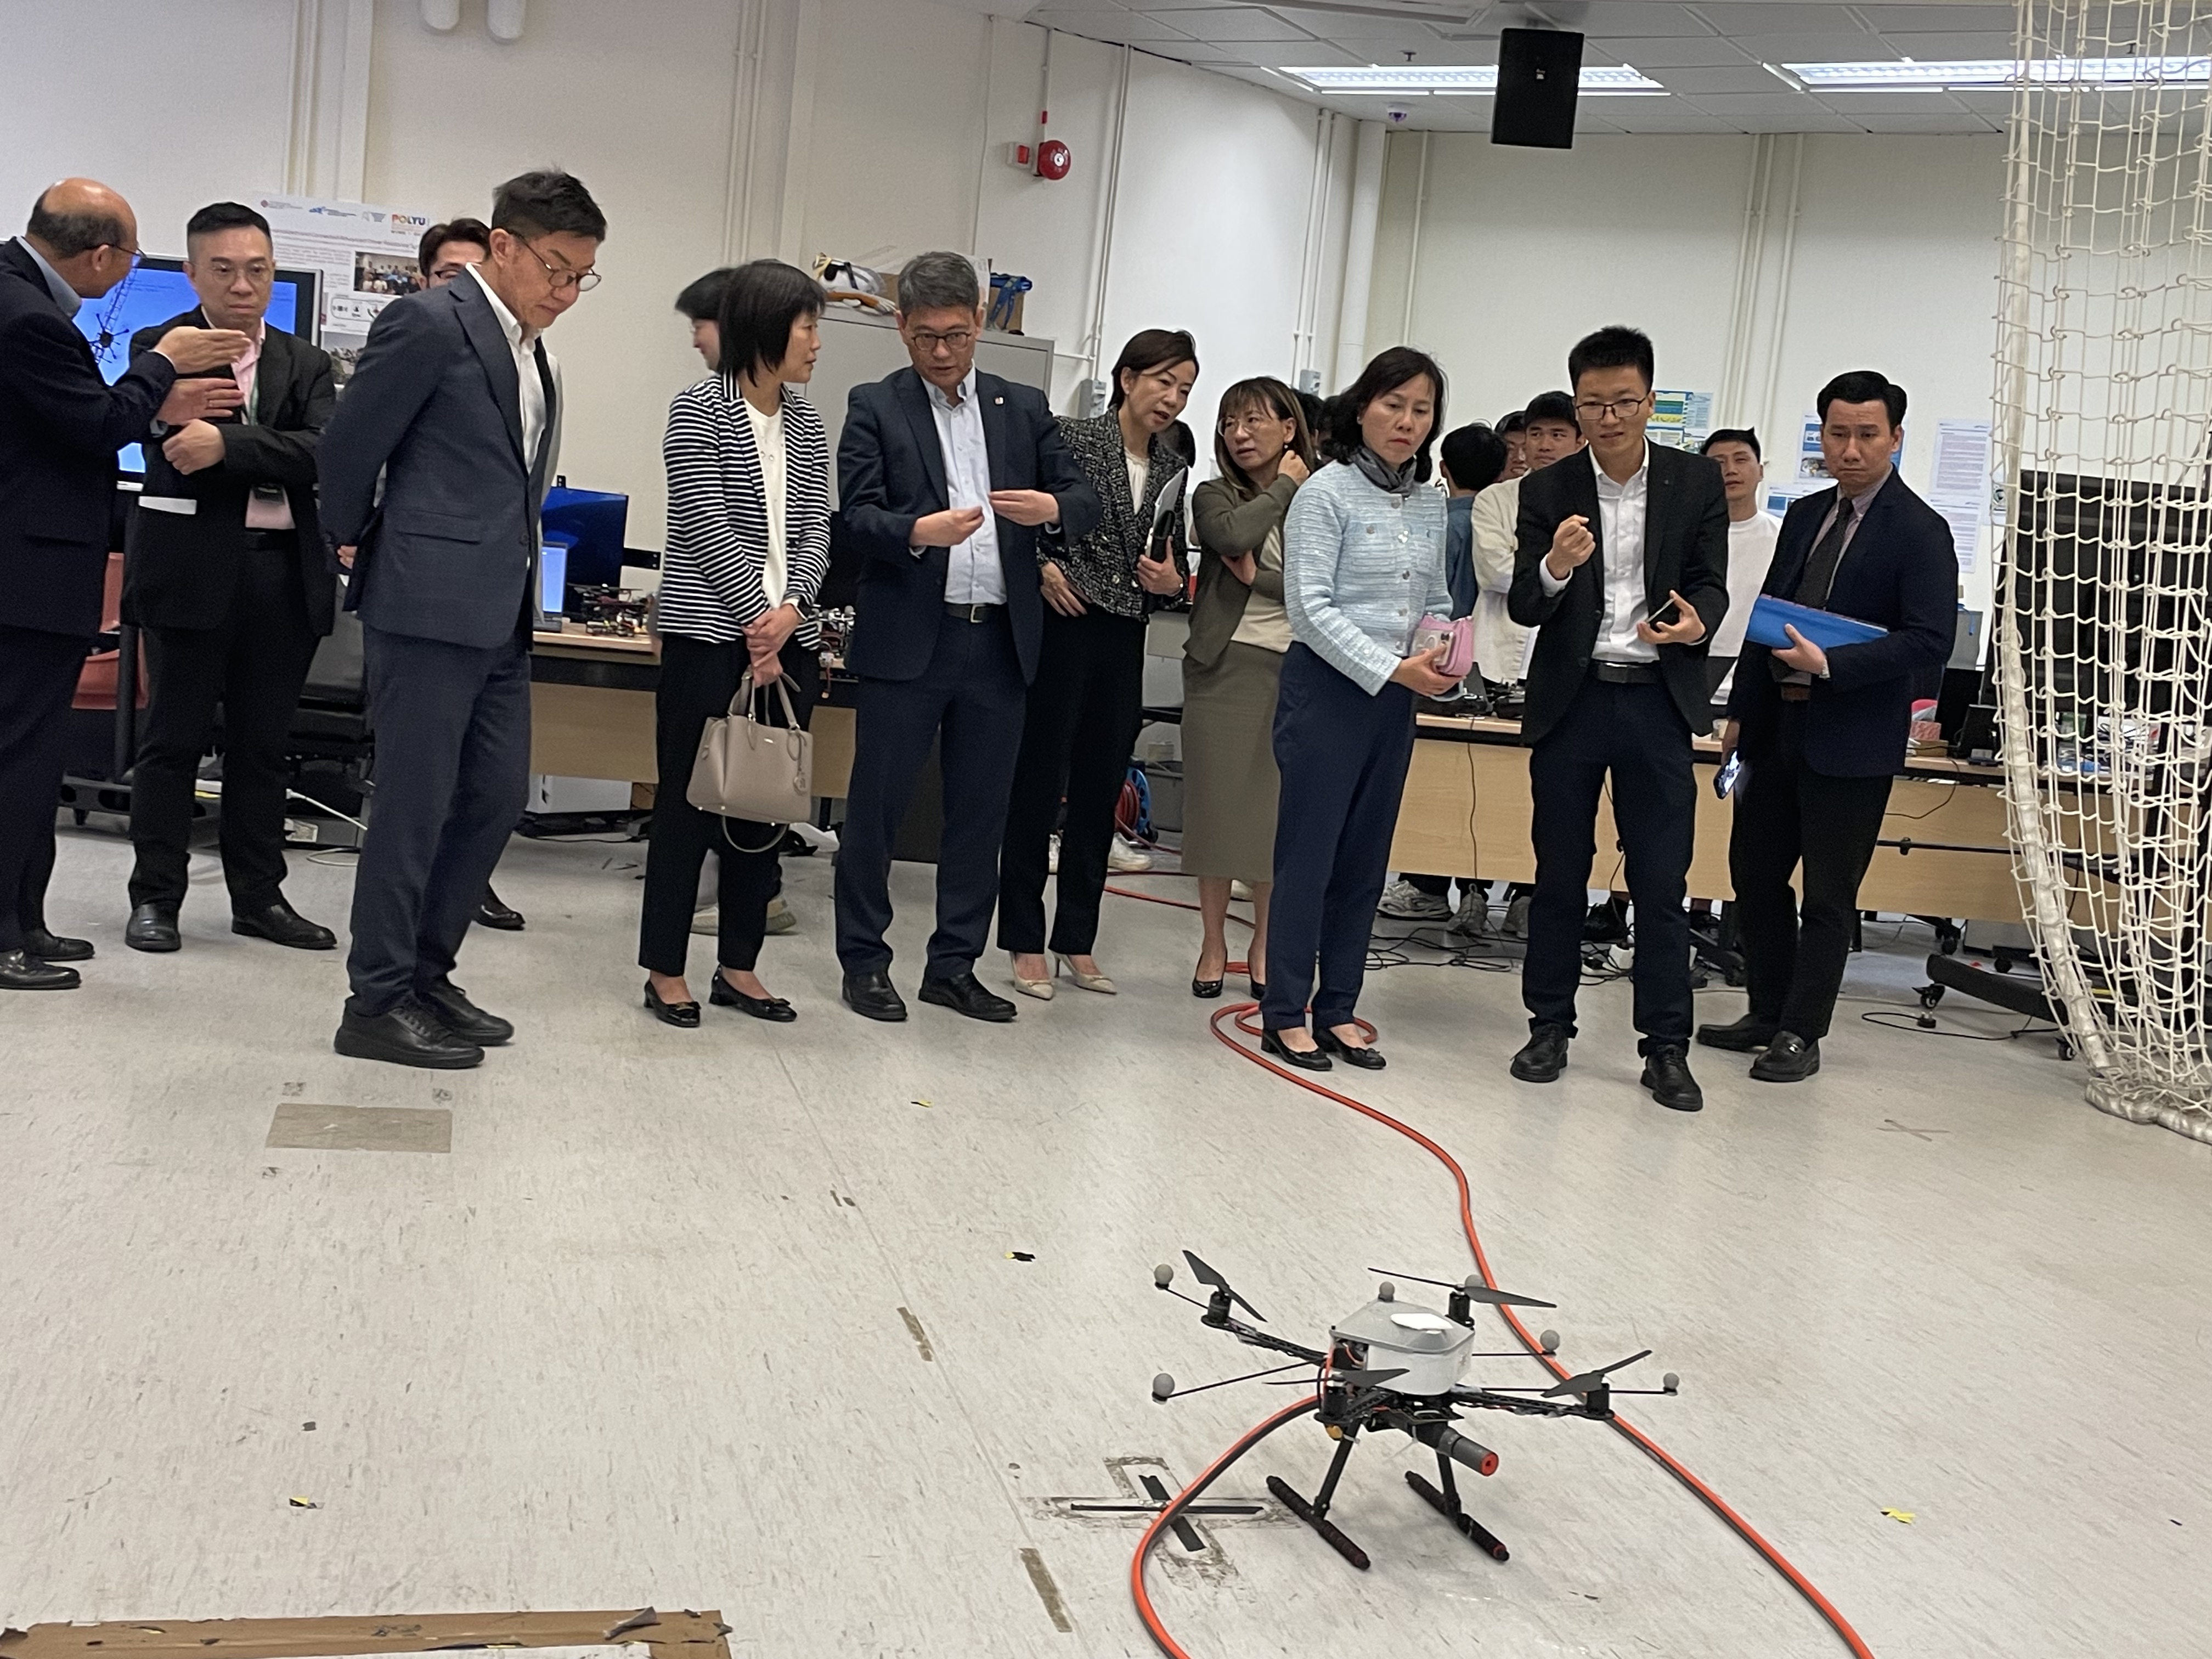
On 24 March 2025, Hong Kong’s Secretary for Transport and Logistics, Ms. Mable Chan, visited The Hong Kong Polytechnic University (PolyU) to discuss the low-altitude economy (LAE) policy and to see demonstrations by the PolyU Department of Aeronautical and Aviation Engineering (AAE). The Trustworthy AI and Autonomous Systems Laboratory (TASLAB) took part in the visit and presented an indoor demonstration of its window-cleaning UAV, a step towards safer and smarter urban maintenance in a smart city.
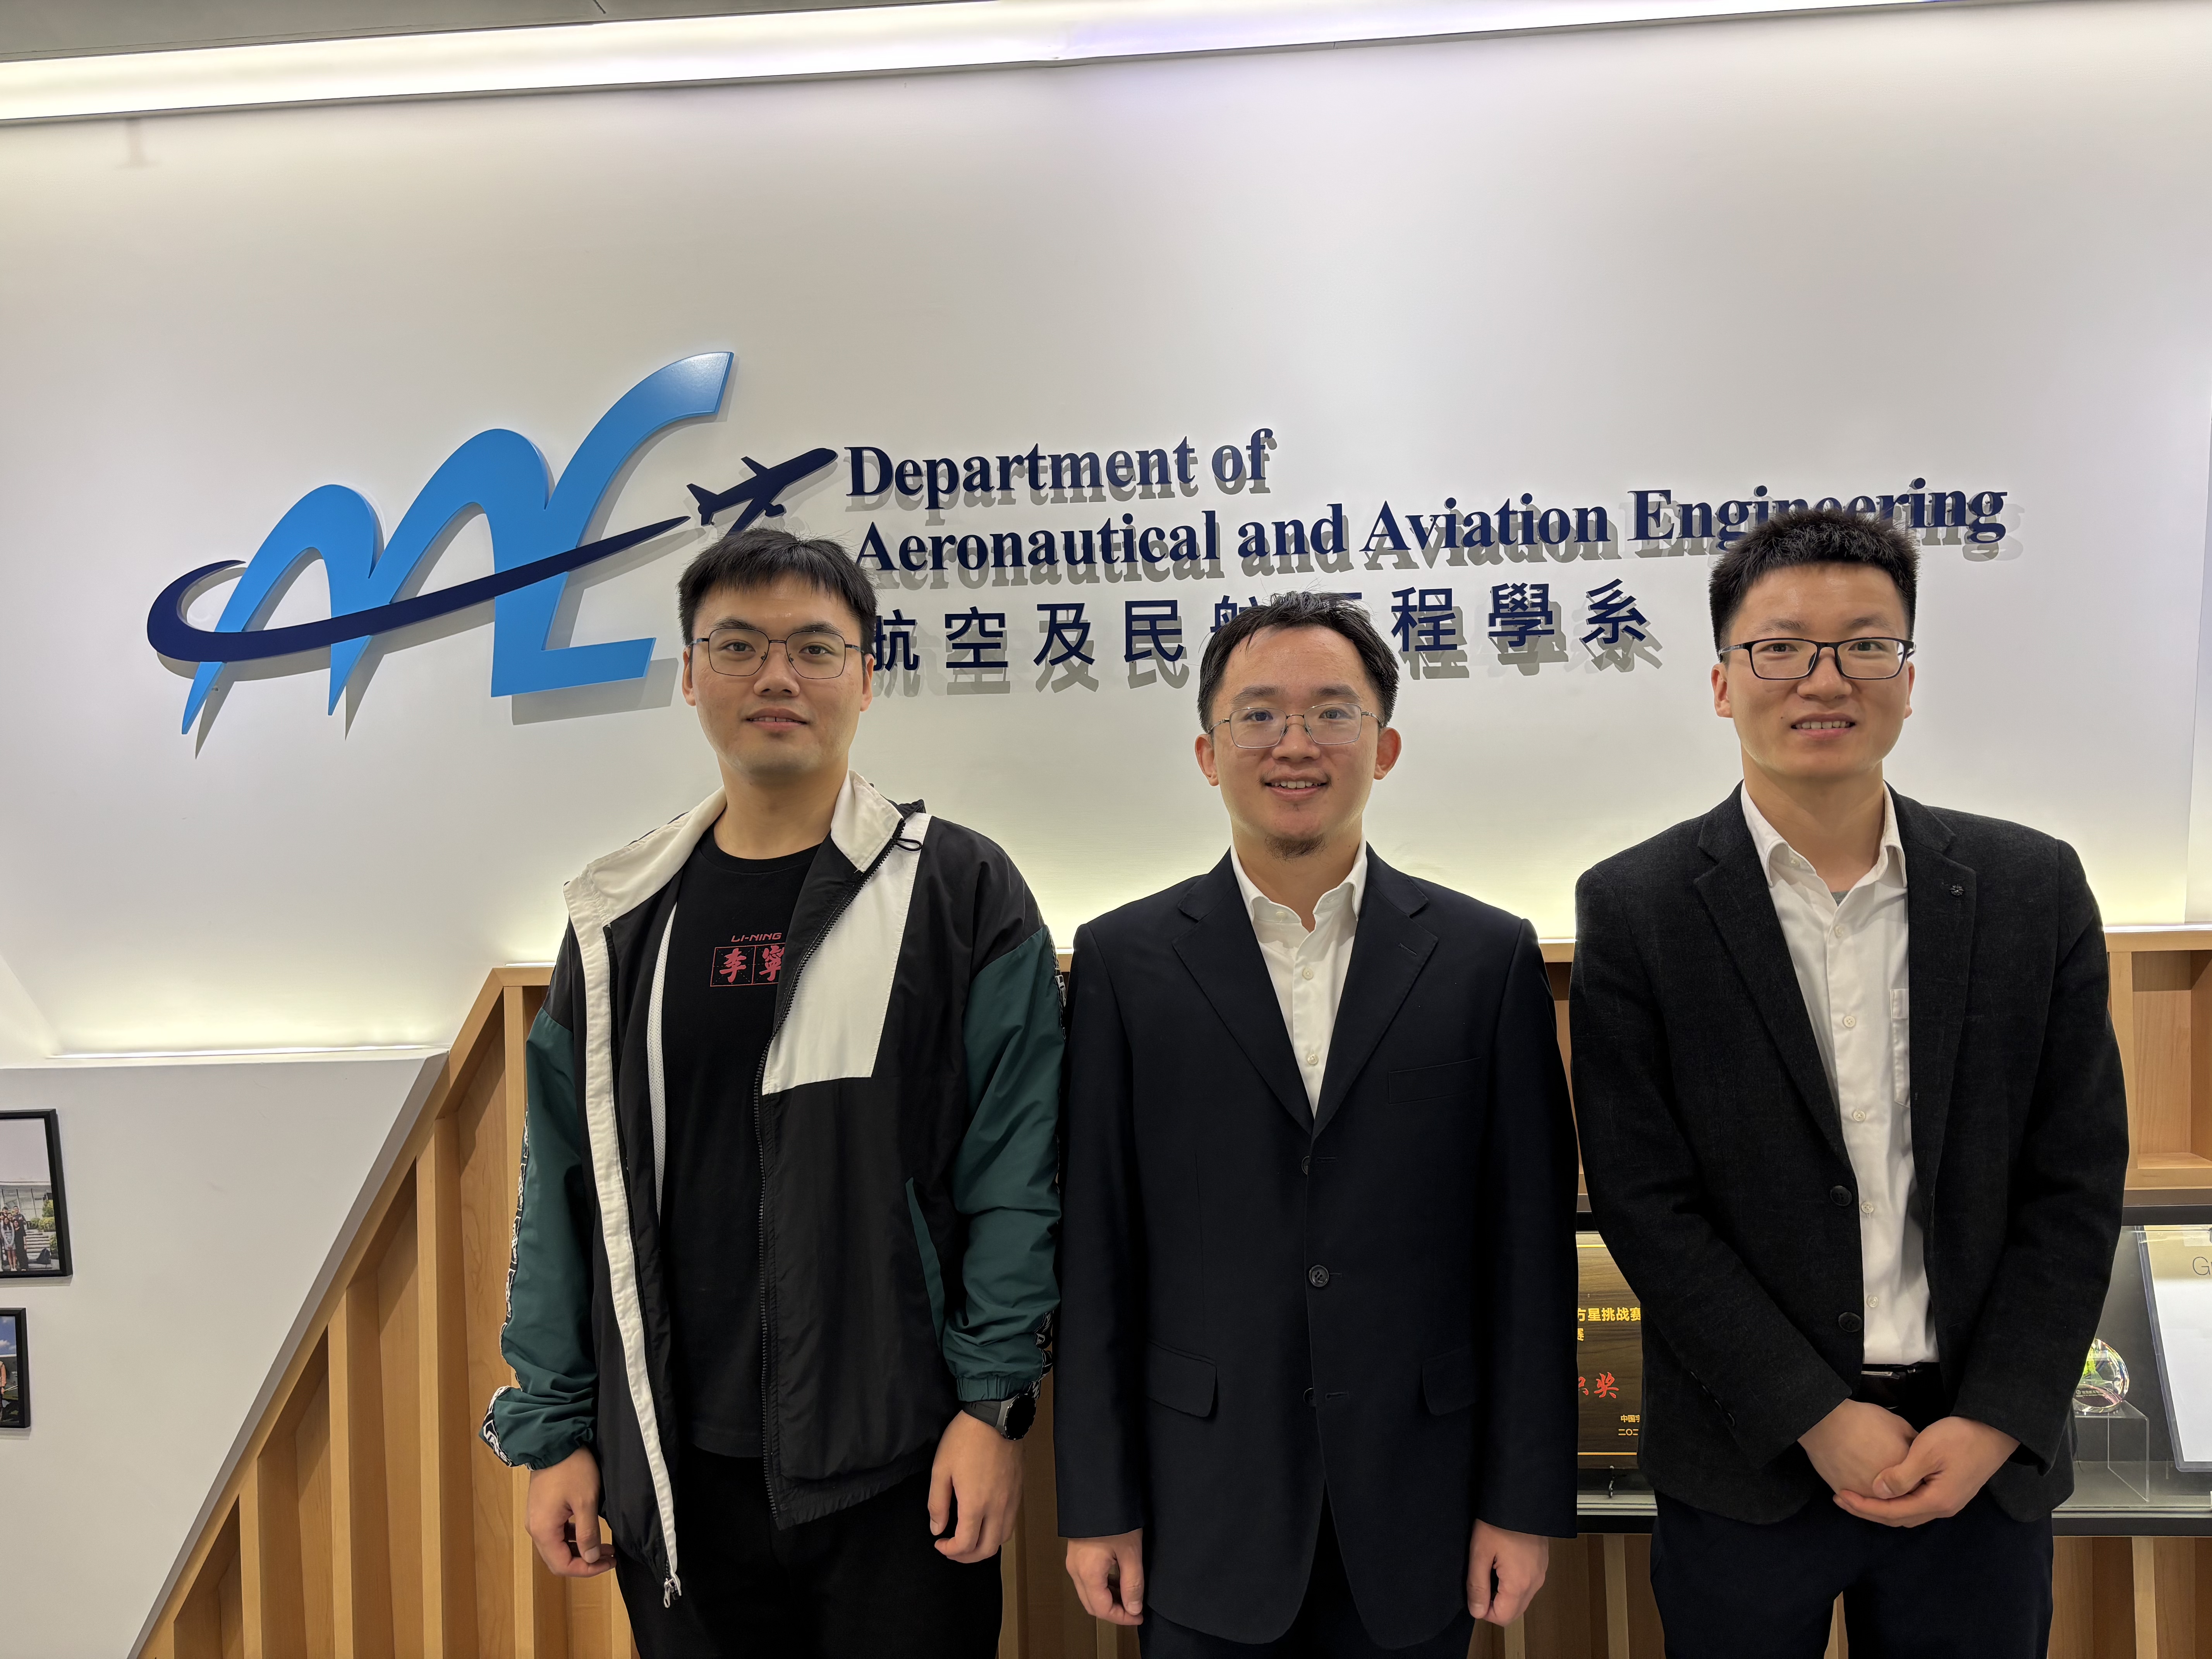
On 21 March 2025 in Hong Kong, The Hong Kong Polytechnic University (PolyU) and Guangdong LinXAI Robotics Co., Ltd. (LinXAI Robotics) signed an agreement to establish the Space Robotics and Embodied Intelligence Joint Laboratory. The agreement marks a significant step in advancing research and industrial applications of intelligent robotics.
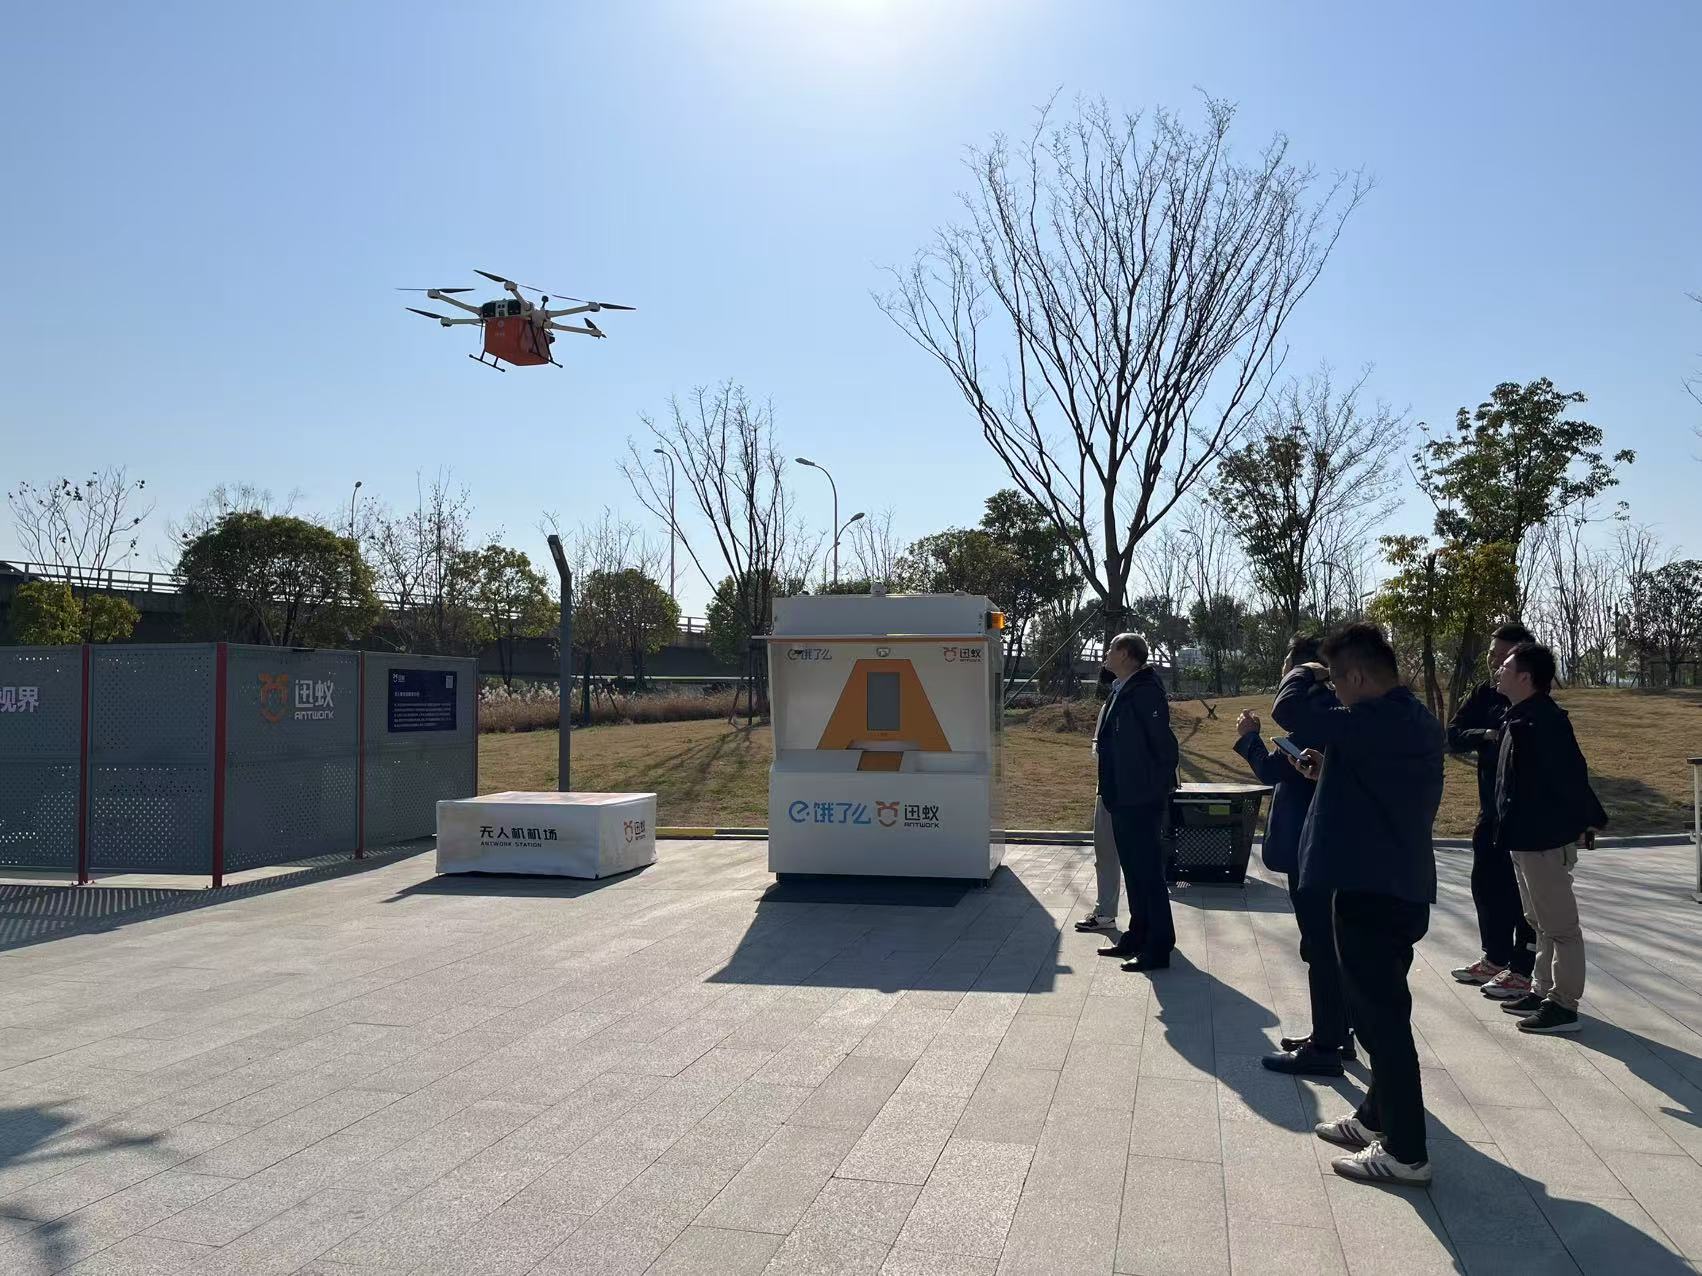
Hefei, in Anhui Province, has been selected by the Central Air Traffic Management Committee as one of the pilot cities for low-altitude economy (LAE) reform. As part of this initiative, Hefei is actively developing its LAE industry and exploring new opportunities in the field.
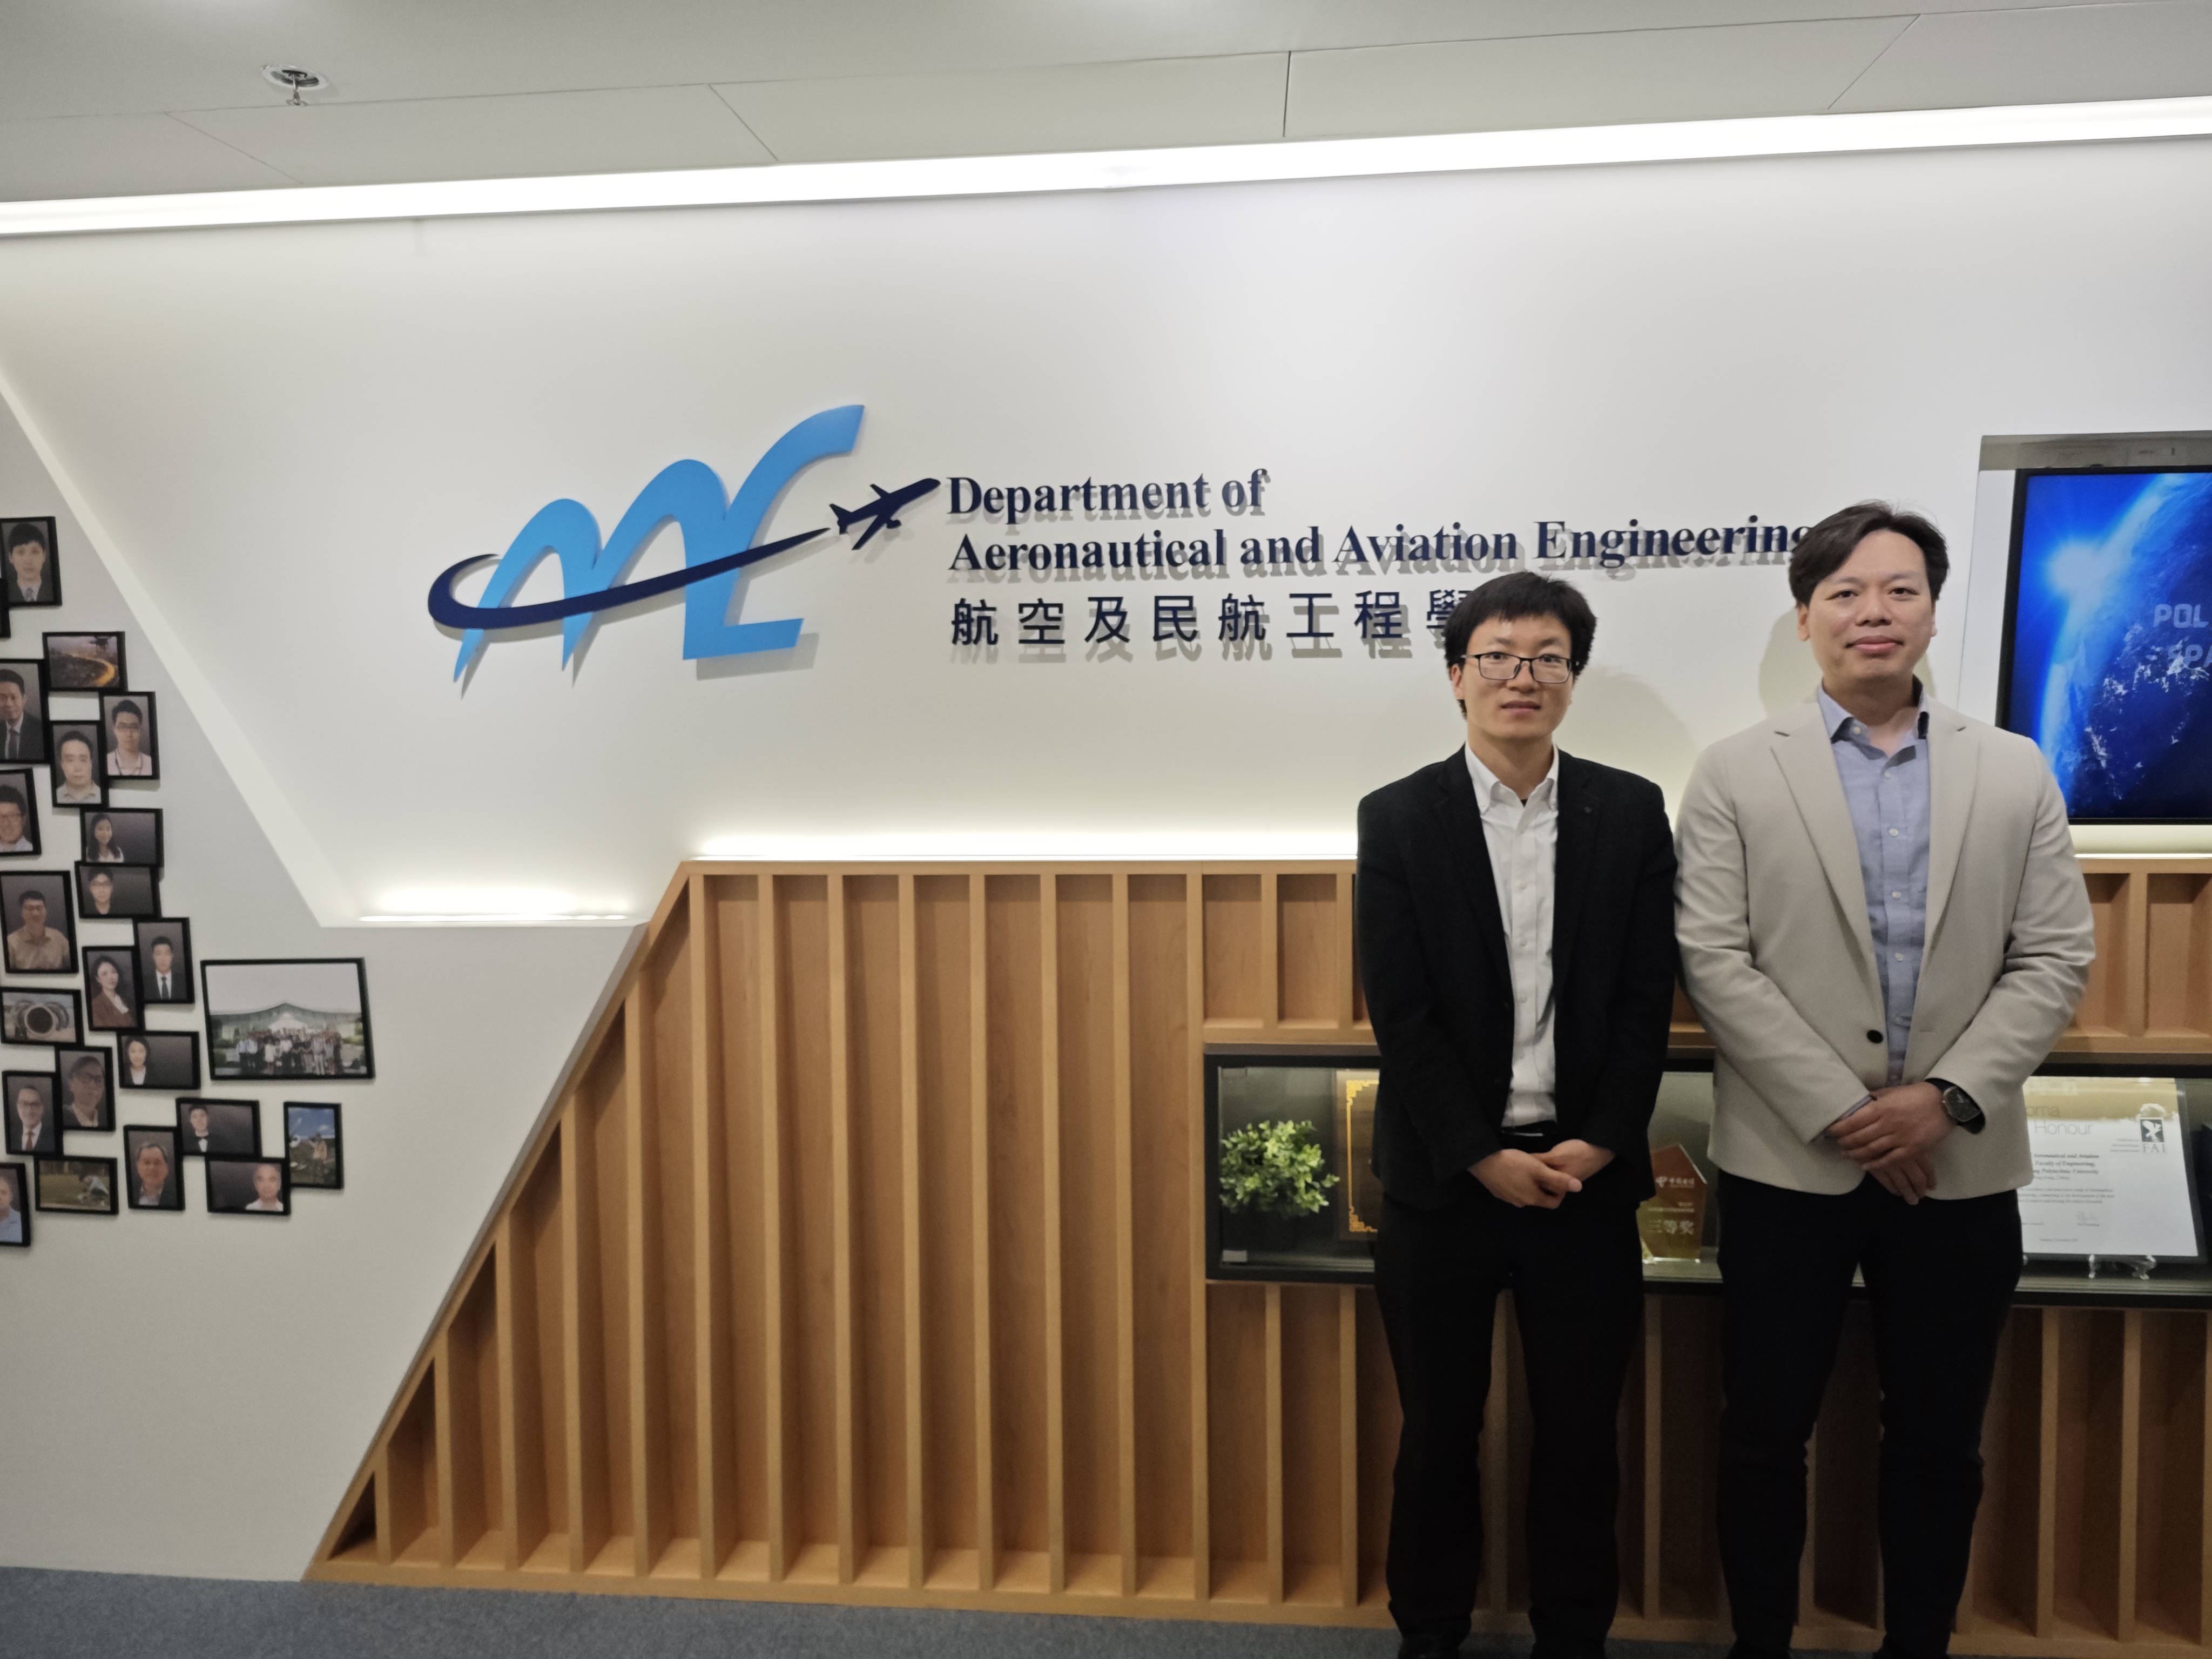
On 14 March 2025, the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) welcomed Mr. Kenny Lau, Chief Technology Officer of S.F. Express Hong Kong, for a strategic visit. The meeting focused on advancing unmanned aerial vehicle (UAV) technologies and accelerating the development of Hong Kong’s low-altitude economy (LAE), a sector poised to redefine urban logistics, emergency response and regional connectivity. Dr. Wen Weisong, Administrative Supervisor of TASLAB, organized the discussion with Mr. Lau.
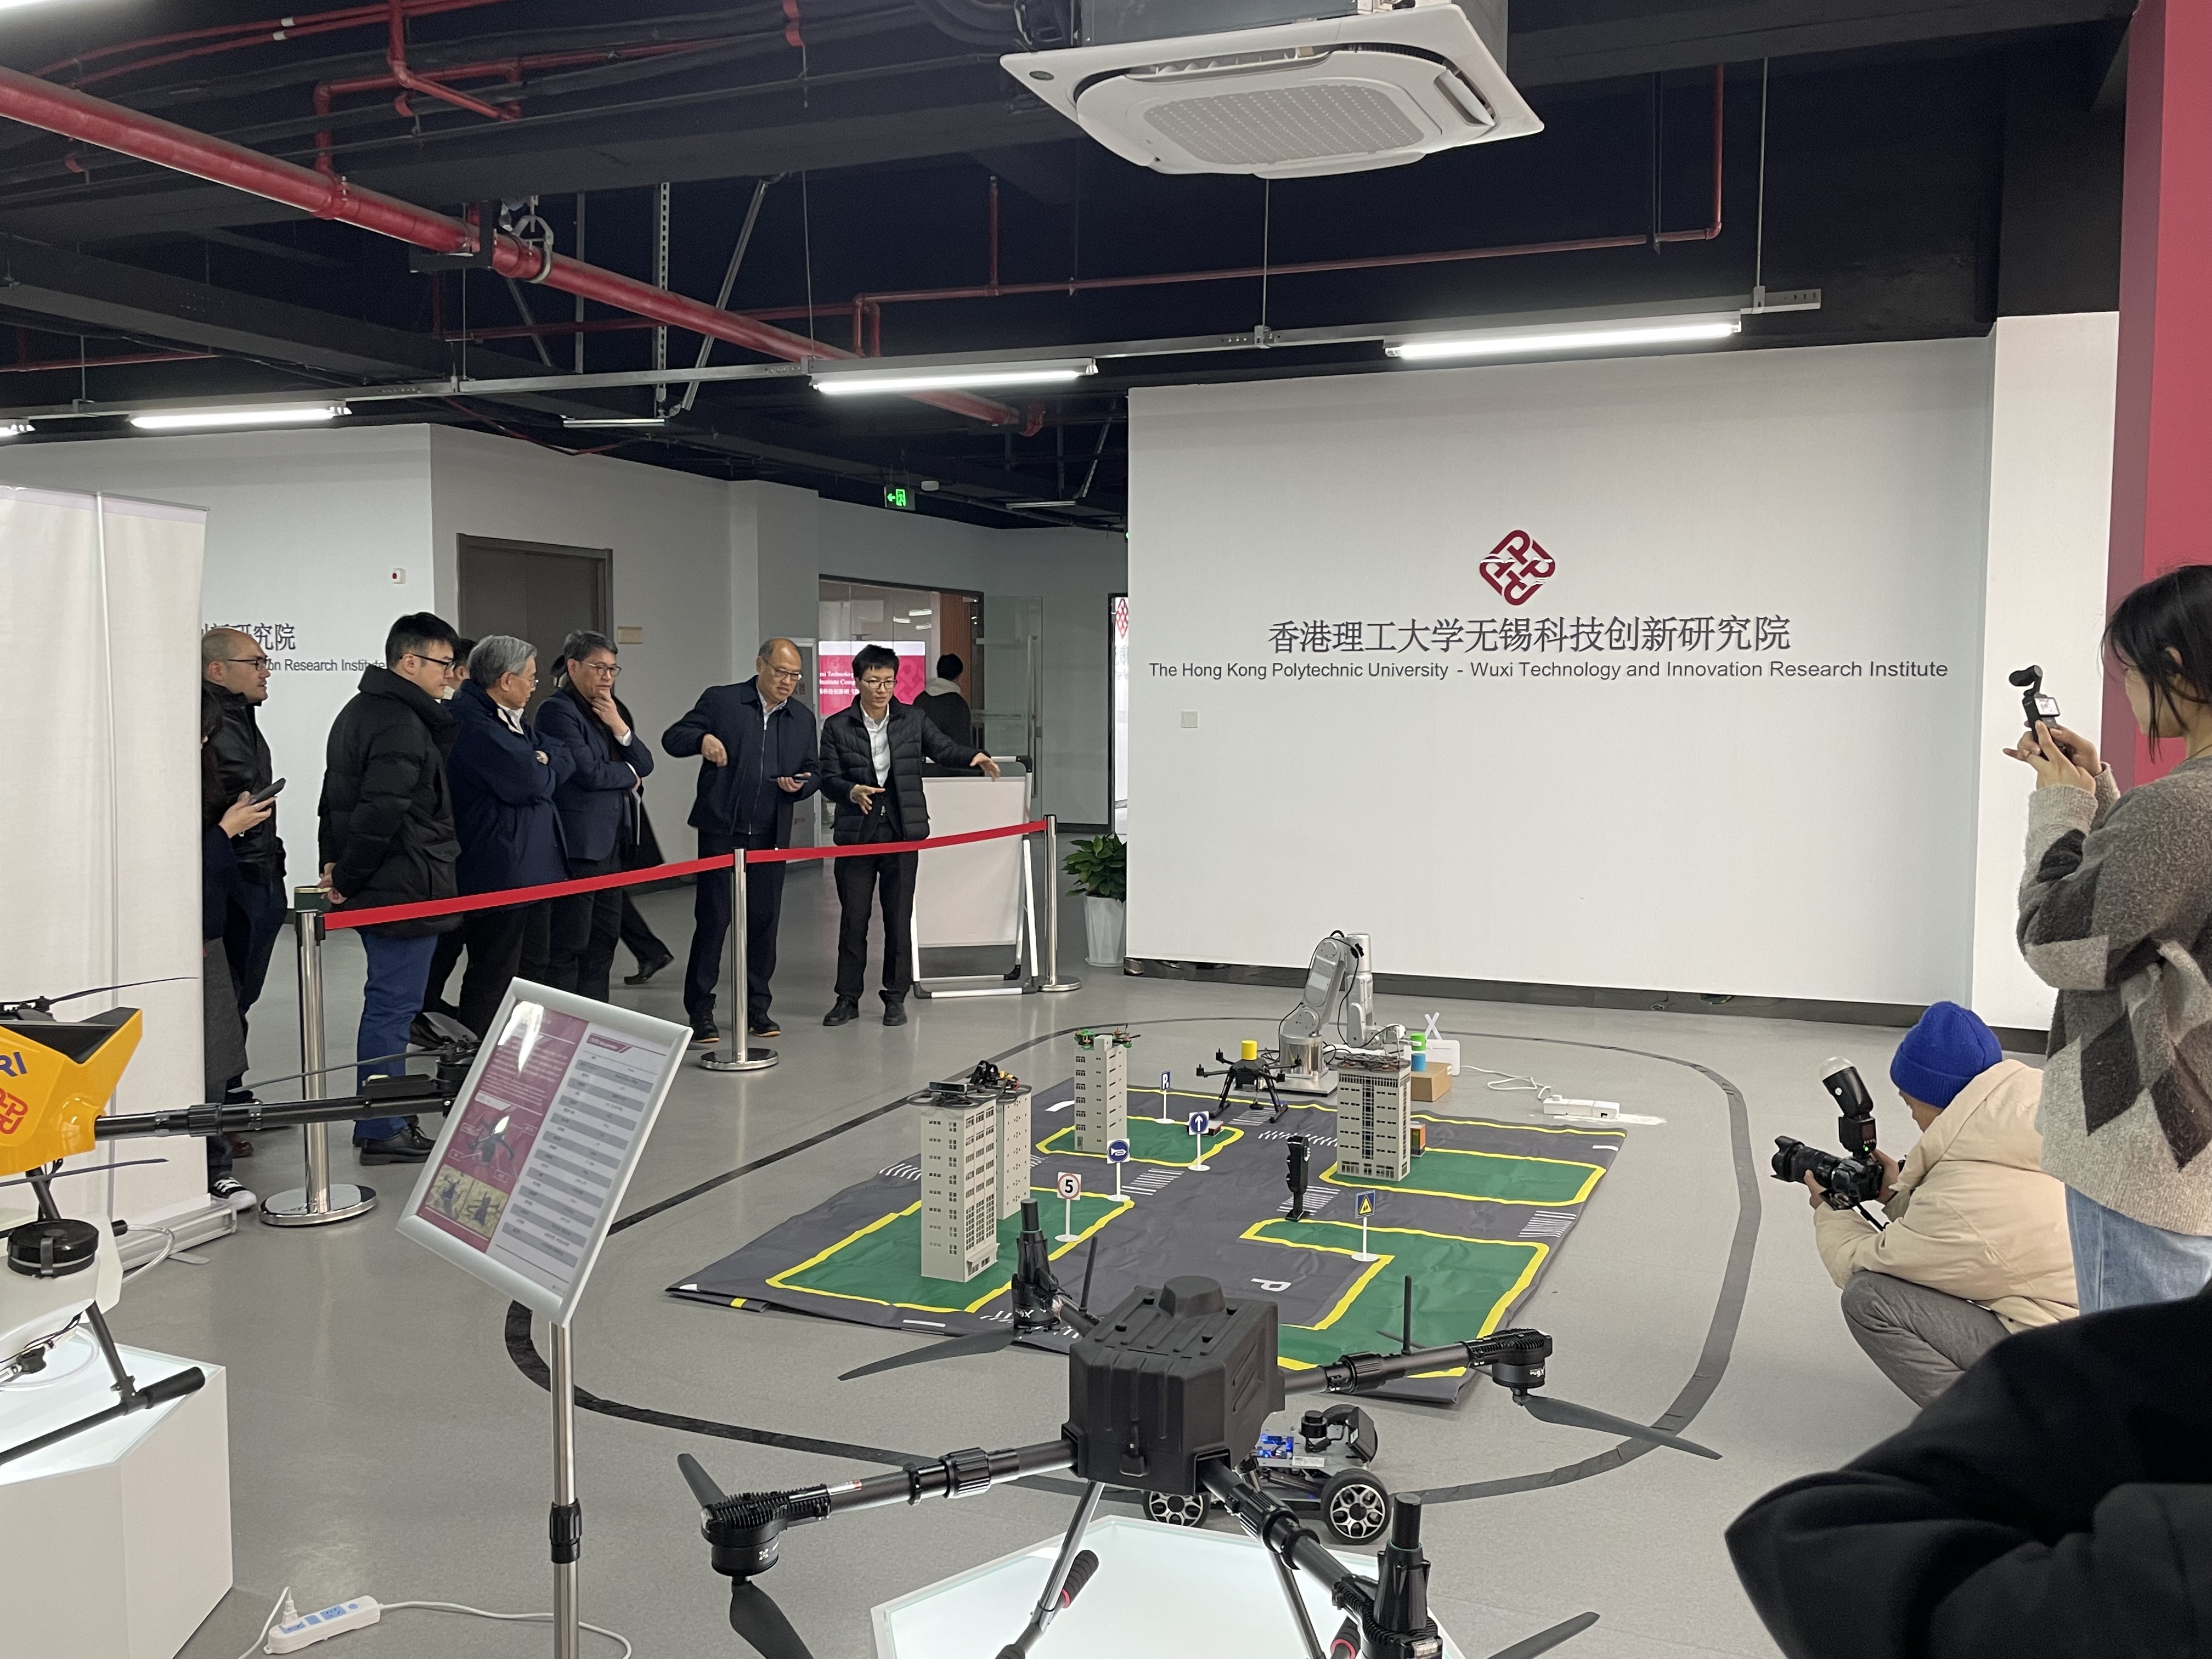
On 23 February 2025, Dr LAM Tai-fai, Chairman of the Council of The Hong Kong Polytechnic University (PolyU), Ir Professor H.C. Man, Dean of the Faculty of Engineering, and the Vice President (Research and Innovation) visited the Hong Kong Polytechnic University – Wuxi Technology and Innovation Research Institute. Dr. Weisong Wen, Director of the Institute’s Intelligent Transportation & Unmanned Systems Center, led the delegation on a tour of the center.
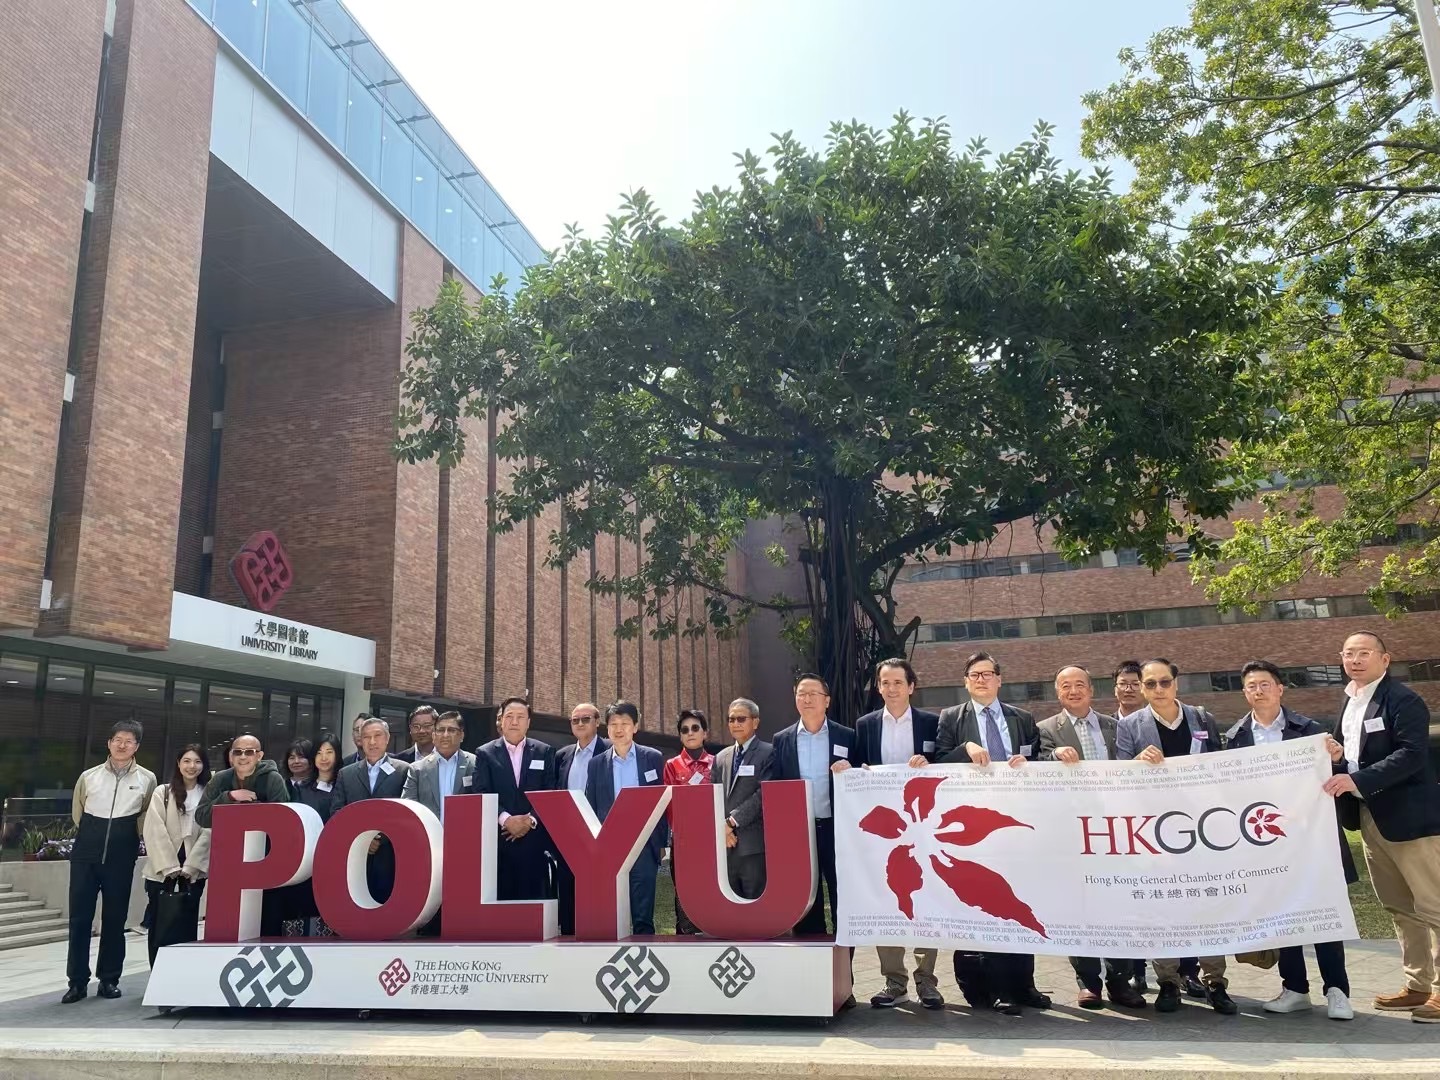
On 18 February 2025, Dr. Weisong Wen gave a talk to fellows of the Hong Kong General Chamber of Commerce (HKGCC) at an event of the Research Centre for Low Altitude Economy (RCLAE), presenting the latest work of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB). The presentation covered recent developments in unmanned aerial vehicle (UAV) technology for the low-altitude economy (LAE) and ended with a live demonstration of UAV trajectory following at the FJ005 Laboratory.
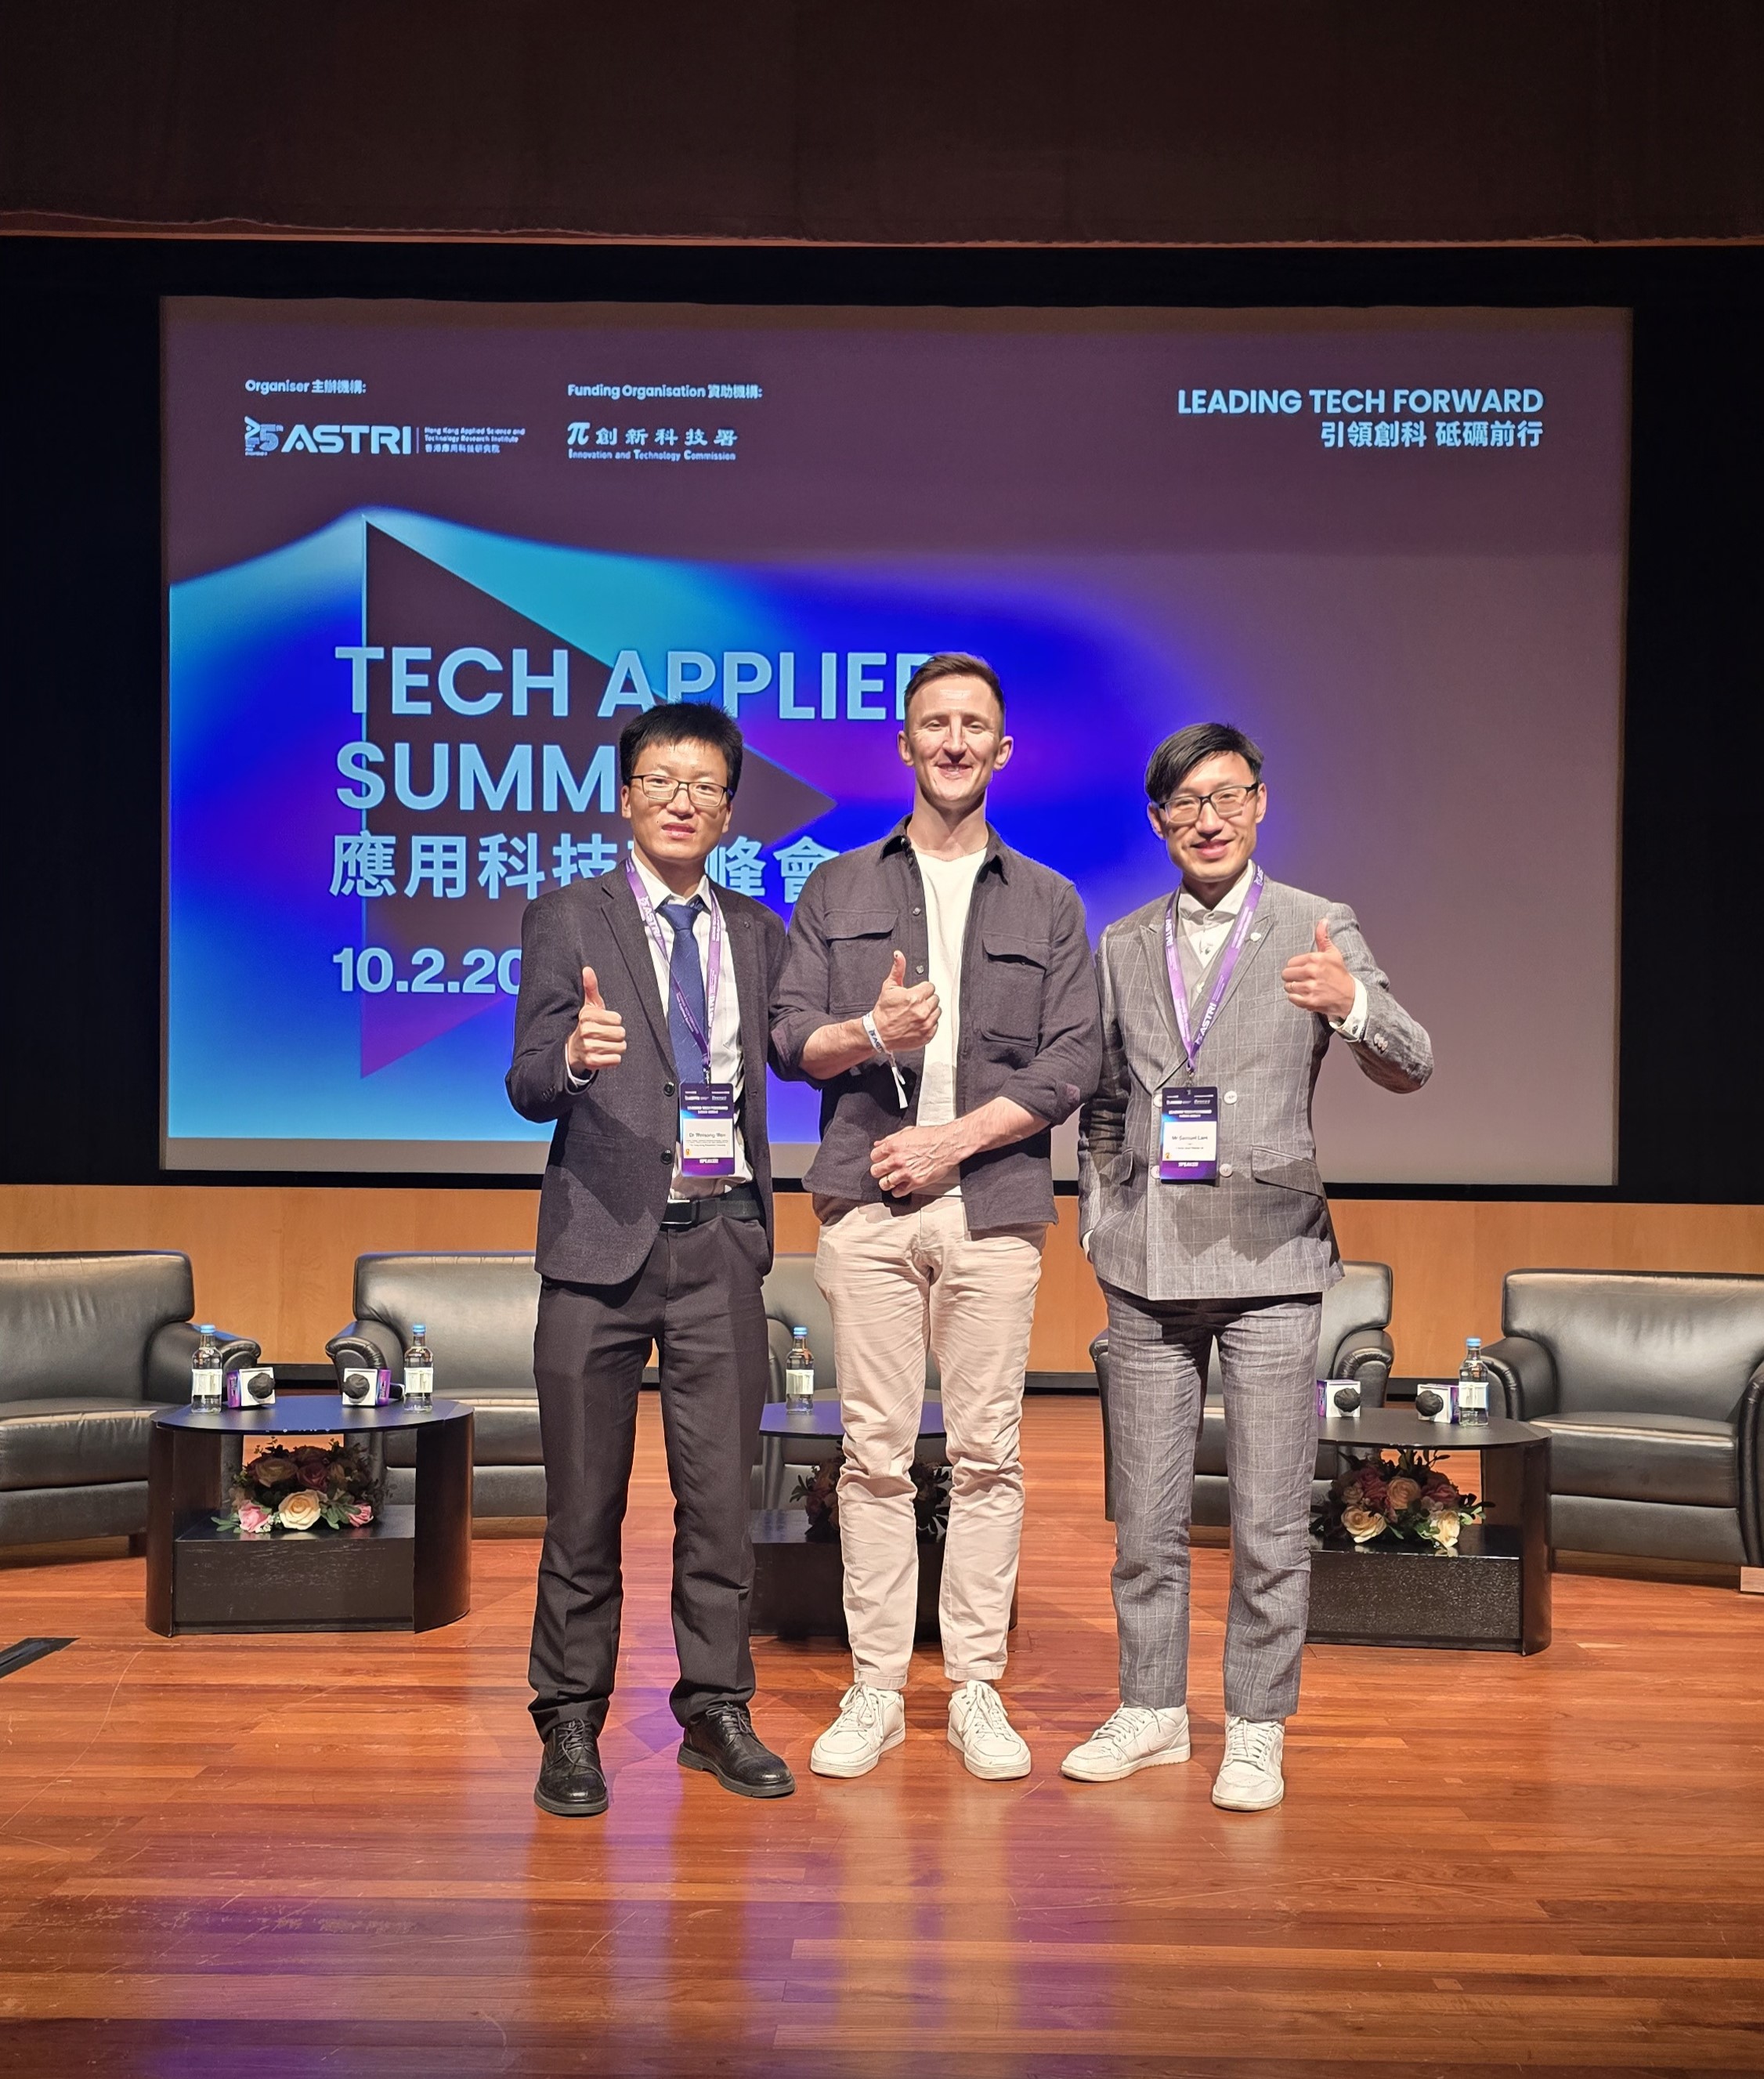
Dr. Weisong Wen was invited to join a panel discussion at the 2025 ASTRI Tech Applied Summit, held on 10 February at the Hong Kong Convention and Exhibition Centre. The summit was the city’s first major innovation and technology event of the year. It was organised by the Hong Kong Applied Science and Technology Research Institute (ASTRI) with the support of the Hong Kong SAR Government’s Innovation and Technology Department, and brought together over 1,500 participants, including leaders from government, industry, academia, research and investment sectors worldwide.
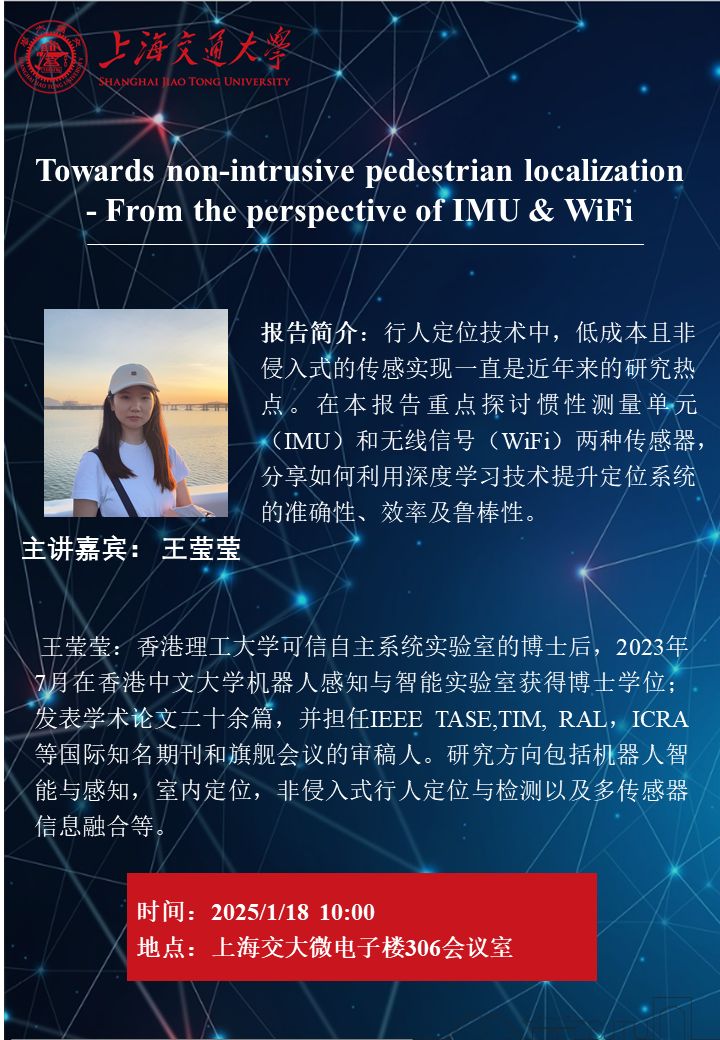
On 18 January 2025, our postdoctoral fellow Dr. WANG Yingying, representing the Trustworthy AI and Autonomous Systems Laboratory (TASLAB), gave a talk at Shanghai Jiaotong University at the invitation of the Institute for Sensing and Navigation. She presented research on non-intrusive indoor pedestrian localization from the perspective of IMU and WiFi, with a focus on the indoor pedestrian localization research carried out at TASLAB.
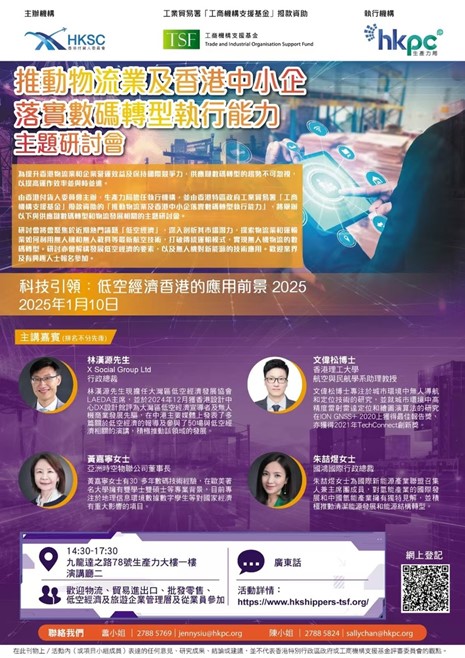
On 10 January 2025, our PhD student Peiwen Yang, representing the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) of The Hong Kong Polytechnic University (PolyU), gave a speech at the Hong Kong Productivity Council (香港生产力局) titled “Technology Leadership: Application Prospects of Low Altitude Economy in Hong Kong by 2025”. He shared the development status of the low-altitude economy (LAE), industry opportunities and, in particular, the current academic research at TASLAB.
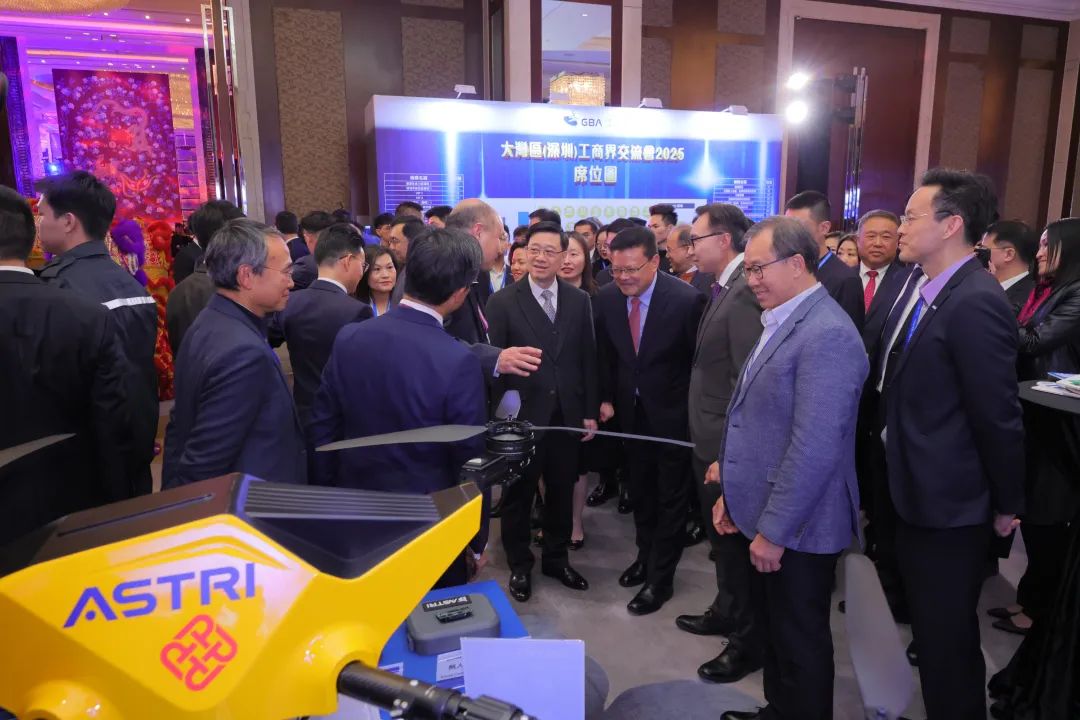
On 10 January 2025, the “Greater Bay Area (Shenzhen) Business Community High-Level Forum and Exchange Conference 2025” was held, organised by the Hong Kong Industrial Committee with support from ASTRI, The Hong Kong Polytechnic University (PolyU) and other organisations. Attendees included Mr. Meng Fanli, Secretary of the Guangdong Provincial Committee and Shenzhen Municipal Committee; Mr. John Lee Ka-Chiu, Chief Executive of the Hong Kong Special Administrative Region; and Professor Sun Dong, Secretary for Innovation, Technology and Industry.
2024 (6)
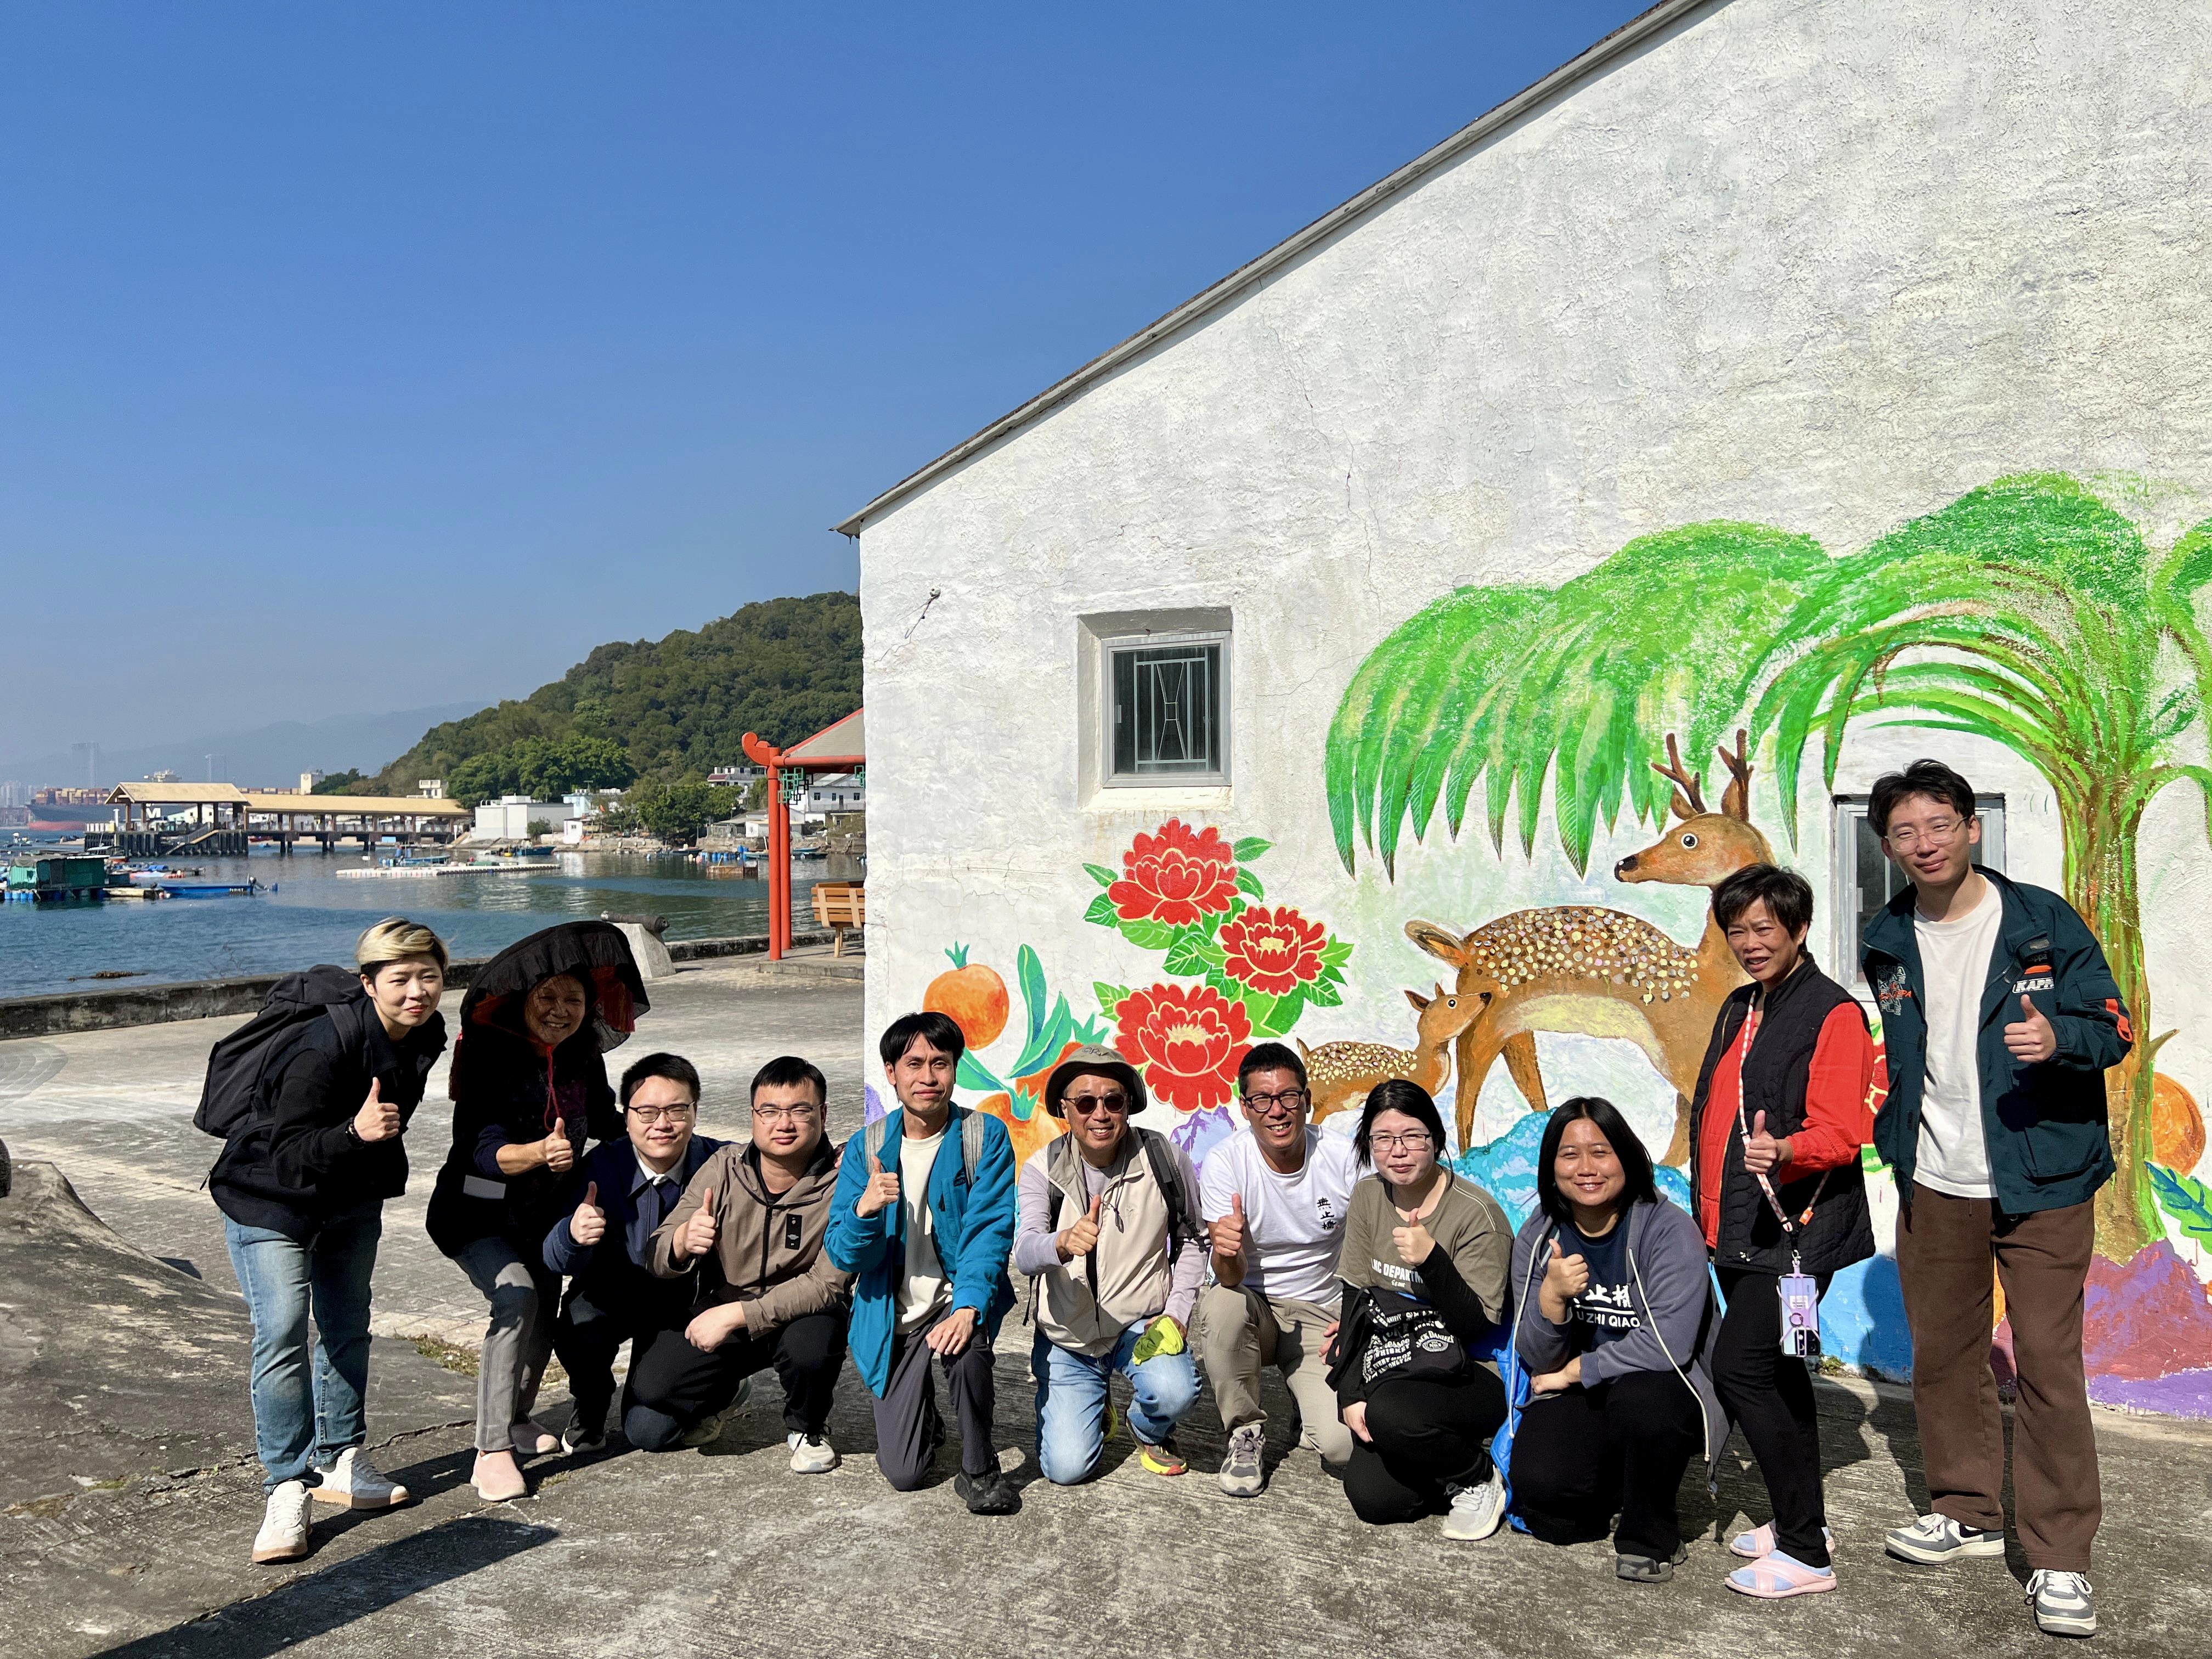
On 30 December, a team from the Trustworthy AI and Autonomous Systems Laboratory (TASLAB), led by Xiao Naigui and supported by volunteers from the Wu Zhi Qiao Charitable Foundation, conducted a preparatory scientific research visit to the Sha Tau Kok Restricted Area. The visit was part of the Pilot North East New Territories Rural Waste Reduction and Sustainability Project, funded by the Hong Kong Jockey Club Charities Trust. The project aims to explore and implement innovative waste management solutions using unmanned aerial vehicles (UAVs) to address the region’s unique waste challenges.
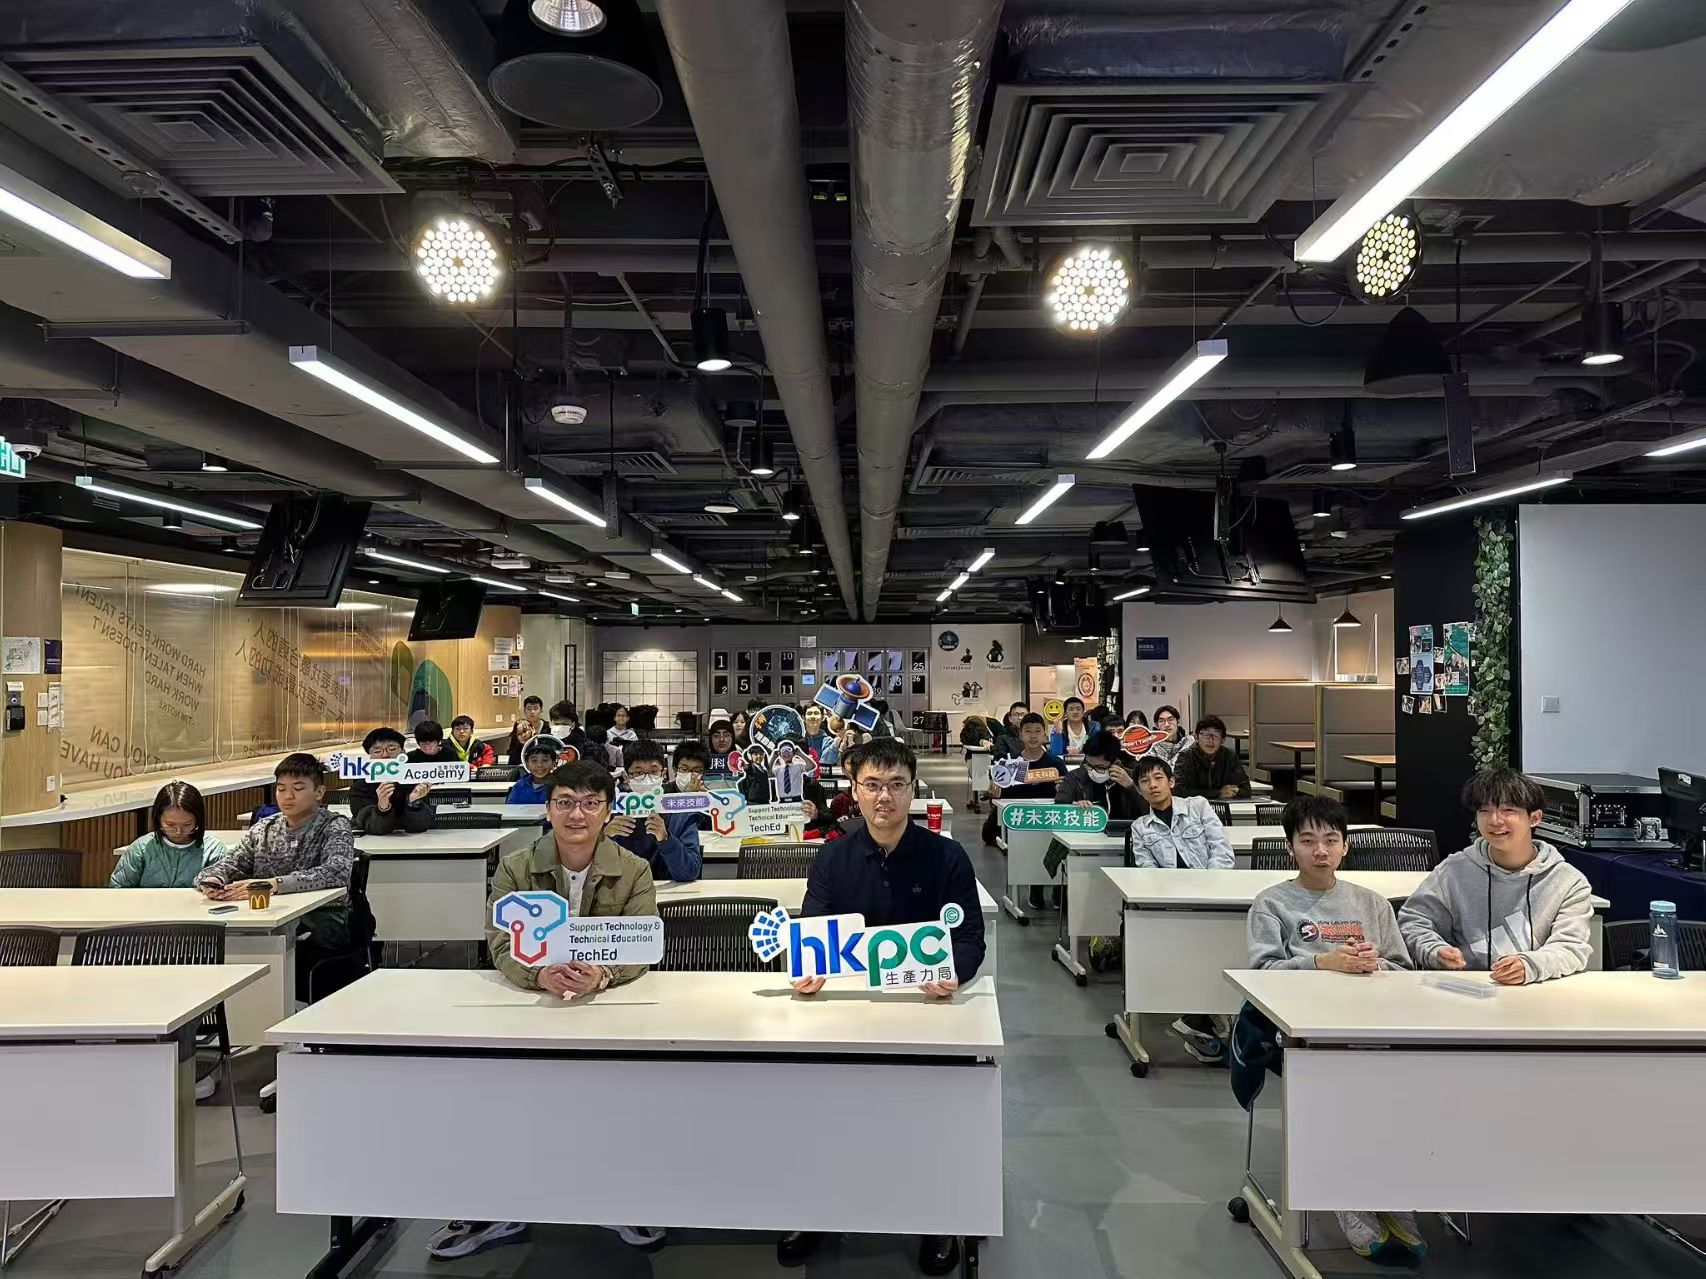
On 27 December, Dr. Runqiu Yang gave a presentation titled “Construction of Space Stations – Introduction to Space Transportation Systems” at HKPC Academy in Kowloon, Hong Kong. The talk was part of the STEM Education in Cultivating Hong Kong Aerospace Talents through Space Station Design and Build 2024/2025 program. It focused on the challenges and advancements in space transportation systems, with an emphasis on educating Hong Kong high school students about space exploration.
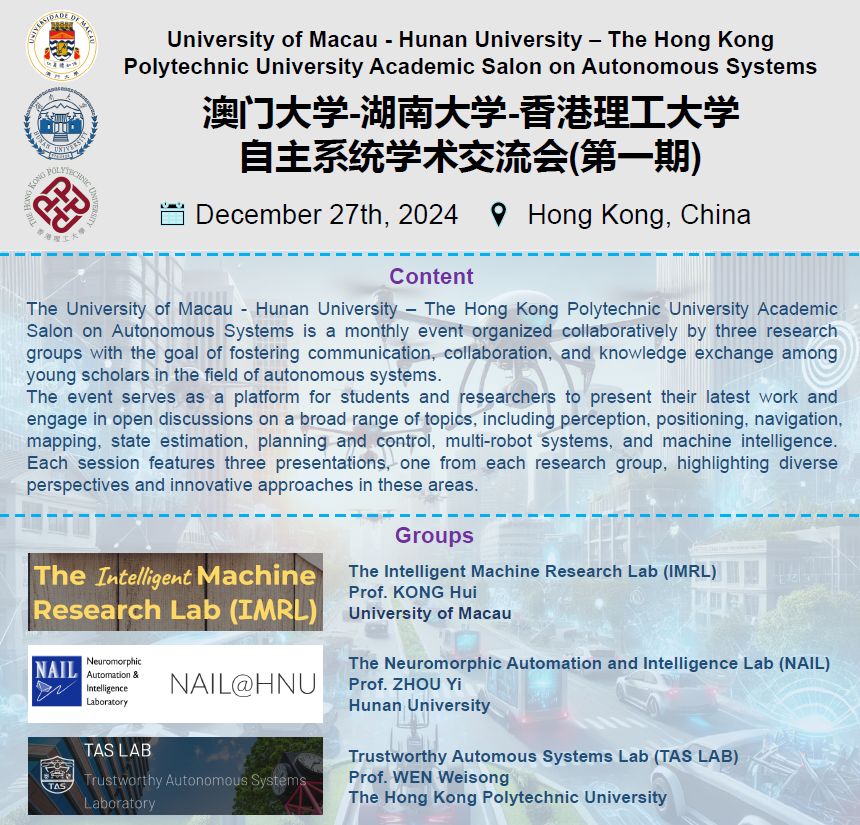
On 27 December 2024, the University of Macau - Hunan University – The Hong Kong Polytechnic University Academic Salon on Autonomous Systems held its first session. The monthly salon is jointly organised by three research groups: the Intelligent Machine Research Lab (IMRL) led by Dr. Kong Hui at the University of Macau, the Neuromorphic Automation and Intelligence Lab (NAIL) led by Prof. Zhou Yi at Hunan University, and the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) led by Dr. Weisong Wen at The Hong Kong Polytechnic University (PolyU). It aims to foster communication, collaboration and knowledge exchange among young scholars in the field of autonomous systems.
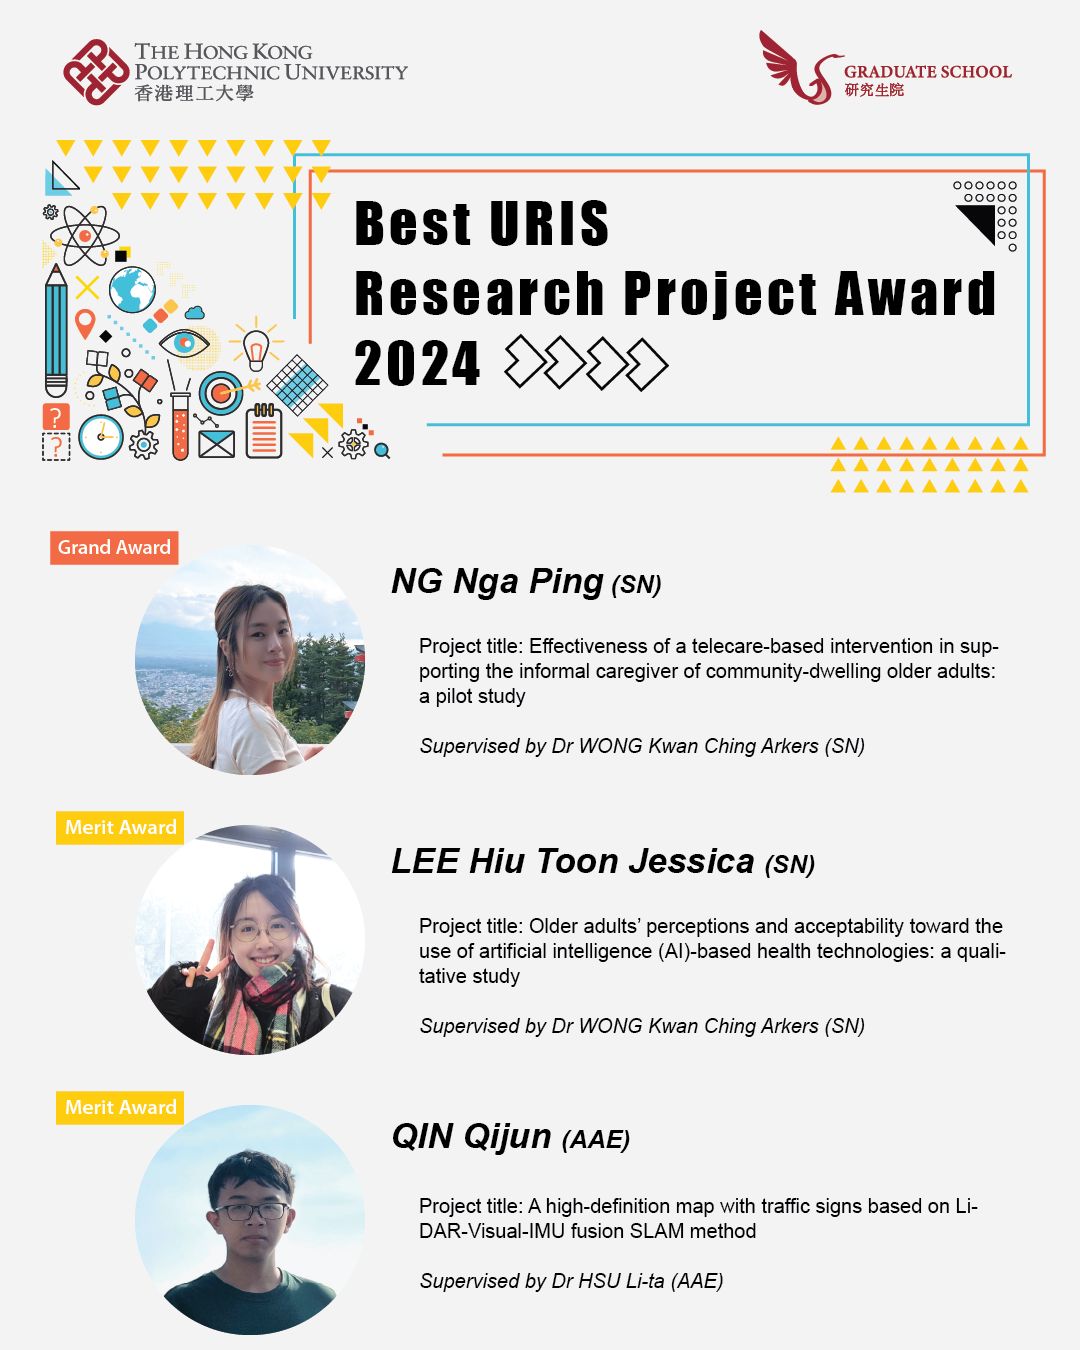
Qijun QIN won the Best URIS Research Project Award 2024. The project developed a high-definition (HD) map generation method that integrates semantic segmentation with SLAM algorithms, opening new possibilities for large-scale data resources in intelligent transportation and autonomous driving.
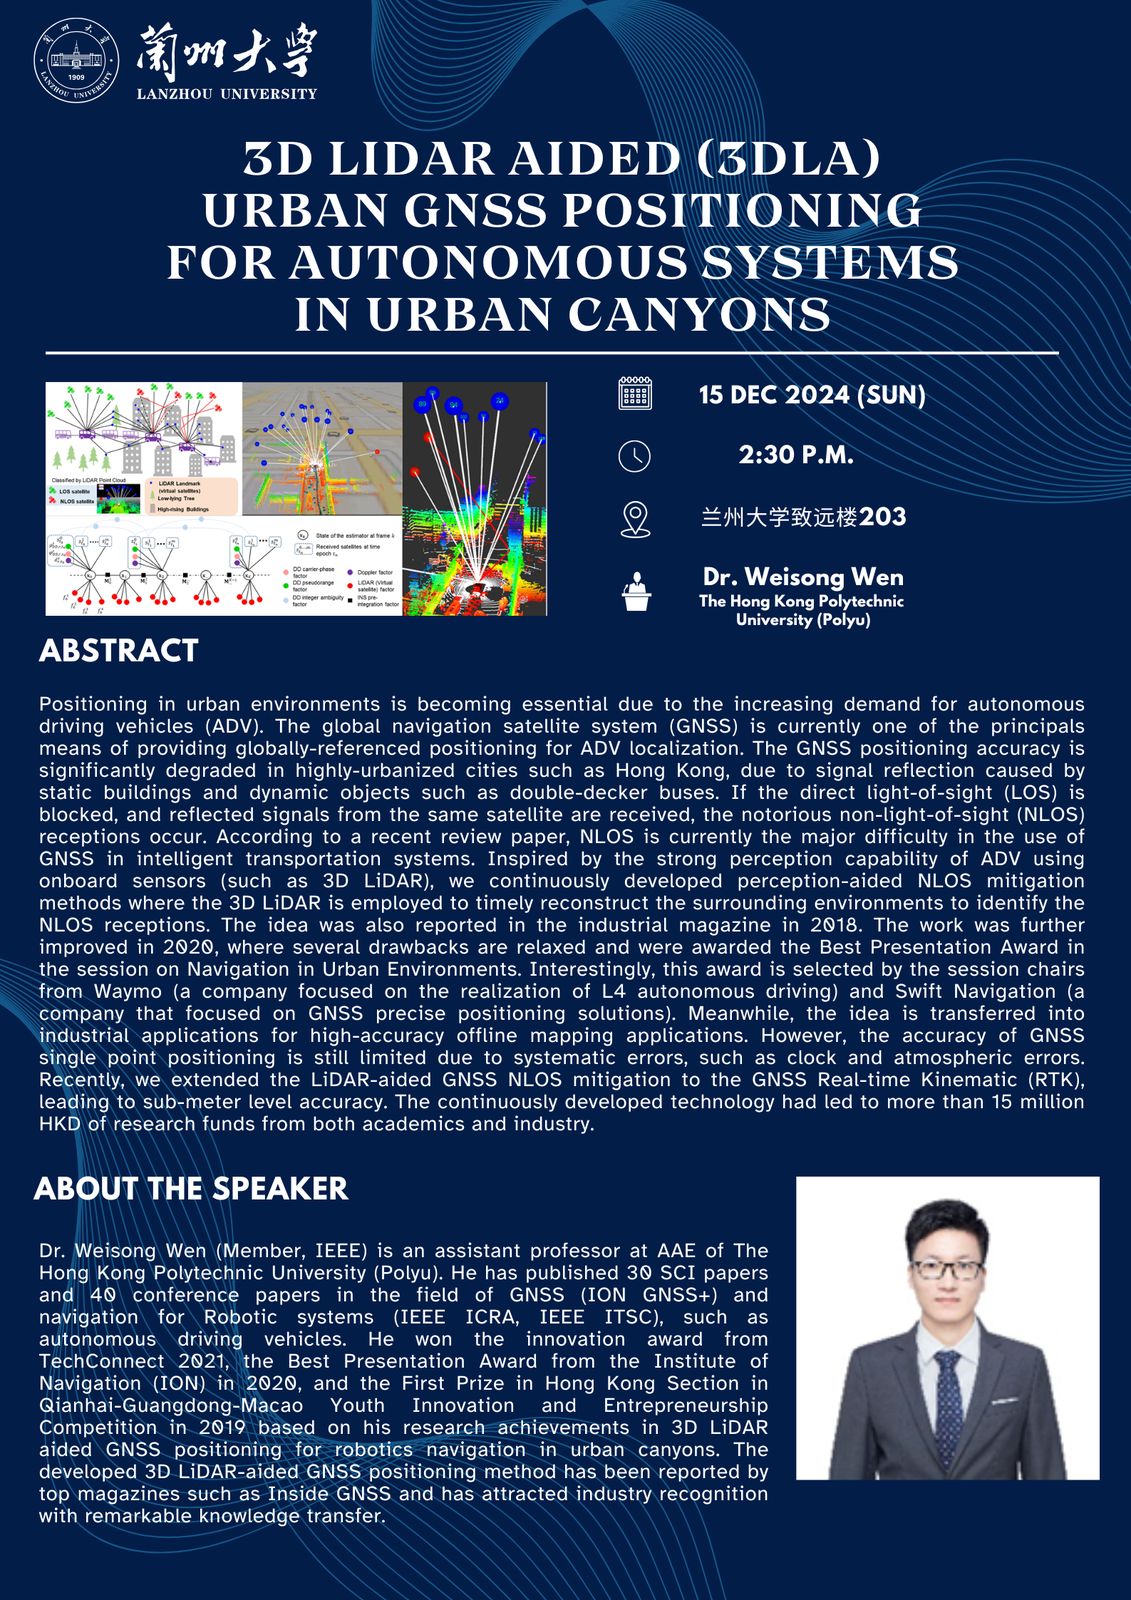
On 15 December, Dr. Wen was invited to give a lecture at Lanzhou University titled “3D LiDAR Aided (3DLA) Urban GNSS Positioning for Autonomous Systems in Urban Canyons”. The lecture focuses on the challenges and advances in urban positioning for autonomous driving vehicles (ADV).

2023 (1)

2022 (1)

2021 (1)

2020 (1)

2019 (1)

2018 (1)
