From 28 April to 1 May 2025, PhD student Ruijie Xu from the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) attended the IEEE/ION Position, Location and Navigation Symposium (PLANS) in Salt Lake City, Utah, USA. At this leading conference for positioning, navigation and timing technologies, Xu presented the paper Tightly-Coupled Wi-Fi/LiDAR/Inertial Integration via Factor Graph Optimization for UAS.
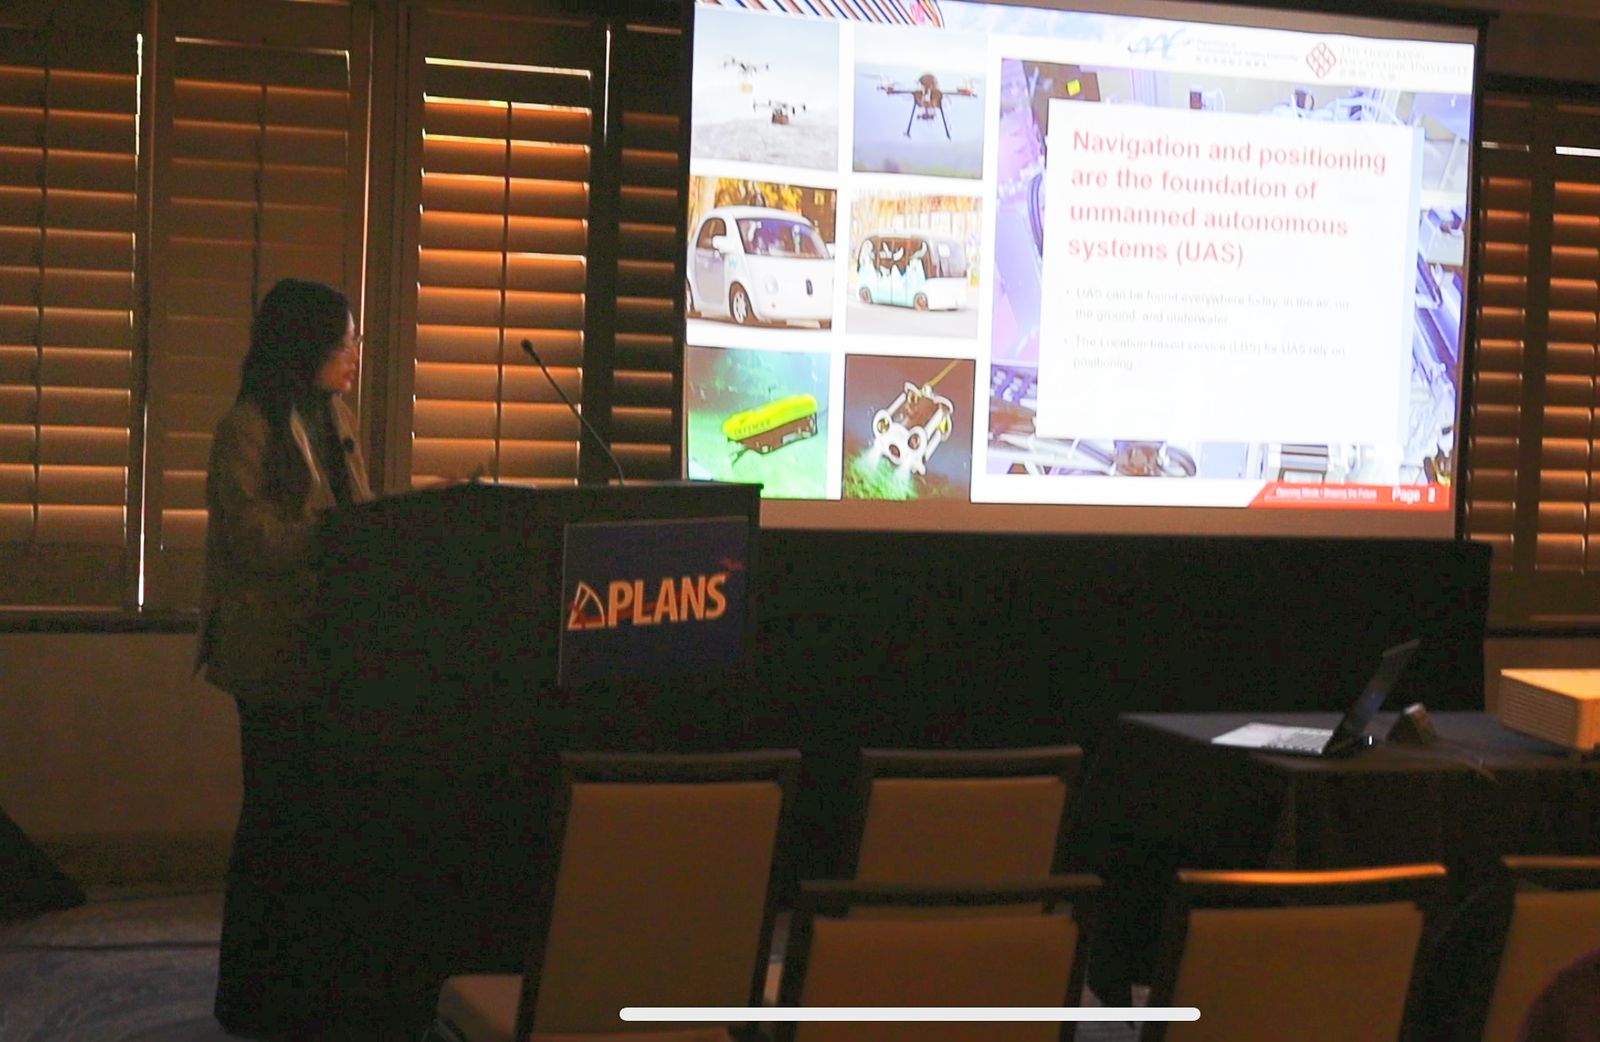
Ruijie Xu presenting his work at IEEE/ION PLANS 2025.
The work addresses the challenge of positioning Unmanned Autonomous Systems (UAS) in outdoor-indoor transition scenarios. It introduces a novel tightly-coupled multi-sensor fusion framework that integrates Wi-Fi Round-Trip-Time (RTT), LiDAR and inertial measurements at the raw data level within a unified factor graph optimization (FGO) framework. A fault detection and exclusion method handles both RTT measurement anomalies and LiDAR-inertial odometry drift. Experiments in controlled indoor and challenging outdoor environments showed high positioning accuracy, a substantial improvement over both conventional Wi-Fi RTT positioning and traditional LiDAR-inertial odometry.
Ruijie Xu at IEEE/ION PLANS 2025 in Salt Lake City.
Taking part in IEEE/ION PLANS 2025 provided valuable opportunities for academic exchange and collaboration with international researchers in the positioning and navigation community, and strengthened TASLAB’s international presence in the field.