On 16 January 2026, members of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) visited LINXAI Company in Shenzhen, China, a leading innovator in robotics technology. The team discussed ongoing collaboration projects centred on the quadruped robot and toured the company’s laboratory facilities. The exchange reflects The Hong Kong Polytechnic University’s (PolyU) commitment to industry-academia partnerships and practical applications of robotics.
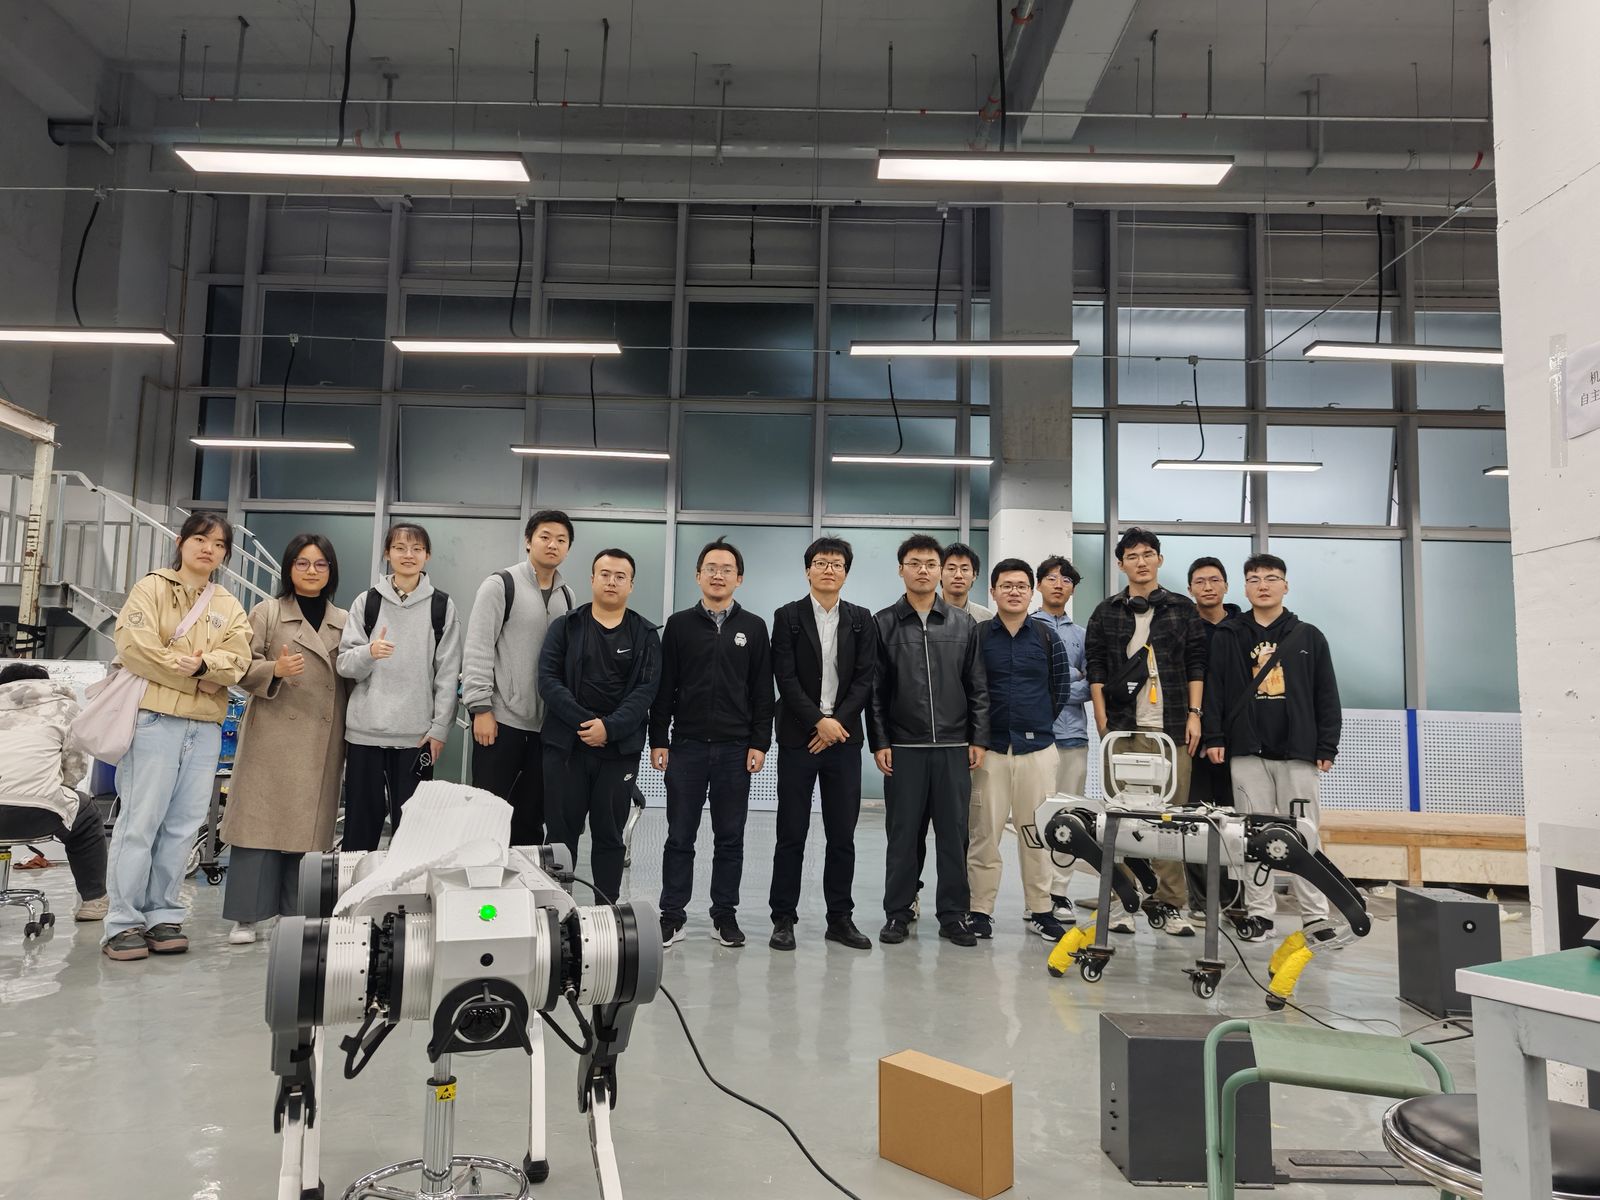
TASLAB members met LINXAI's engineering experts during the visit in Shenzhen.
The visit brought together TASLAB members and LINXAI’s engineering experts. The discussions focused on four projects aimed at enhancing the capabilities of the quadruped robot:
- Robot Dog Following: using Ultra-Wideband (UWB) technology for precise human-following, enabling applications in logistics, security and personal assistance.
- Robot Dog Vision-Based Motion Control: integrating LiDAR sensors and Deep Reinforcement Learning (DRL) to improve terrain adaptability and gait optimisation on unstructured surfaces.
- Guide Dog Application: developing an intelligent system for visually impaired users that combines localisation, vision-language navigation and locomotion modules for safe mobility assistance.
- UAV-Robot Dog Landing: creating an air-ground collaborative logistics system for seamless package transfer between UAVs and the quadruped robot, addressing last-mile delivery challenges.
These projects demonstrate the platform’s potential in diverse fields, from disaster response and industrial inspection to assistive technologies and smart logistics.