← All datasets & code
TC-VIML
Tightly-Coupled Visual-Inertial-Map Localization for Intelligent Vehicles
- Developed by
- Xi Zheng
- Repository
- ZHENGXi-git/TC-VIML
- GitHub
- 45 stars · 6 forks
Summary
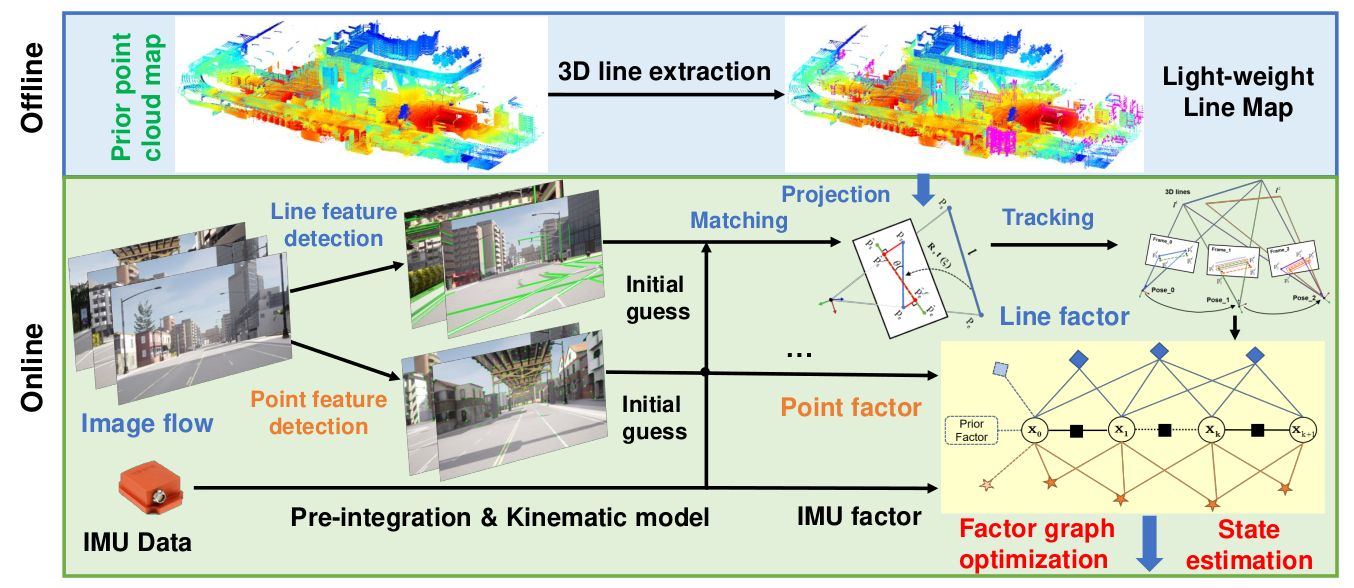
Visual-inertial localization that matches image line features to a lightweight 3D prior line map, giving drift-free poses with a proven observability result.
Key innovations
- 2D image lines tightly integrated with a 3D prior line map in a factor graph
- Robust cross-modality matching and outlier rejection for line association
- First proof that global translation is fully observable (only yaw is not)
Impact
- 45 GitHub stars
- Published in IEEE Transactions on Intelligent Vehicles (2024) and IEEE ITSC 2023
Cite this work
X. Zheng, W. Wen and L.-T. Hsu, "Tightly-coupled visual/inertial/map integration with observability analysis for reliable localization of intelligent vehicles," IEEE Transactions on Intelligent Vehicles, 2024.