← All datasets & code
TasFusion
ROS1 Package for Multi-Sensor GNSS/IMU Fusion Navigation
- Developed by
- ZHAO Jiaqi
- Repository
- PolyU-TASLAB/TasFusion
- GitHub
- 22 stars · 1 forks
- Licence
- GPL-3.0
Summary
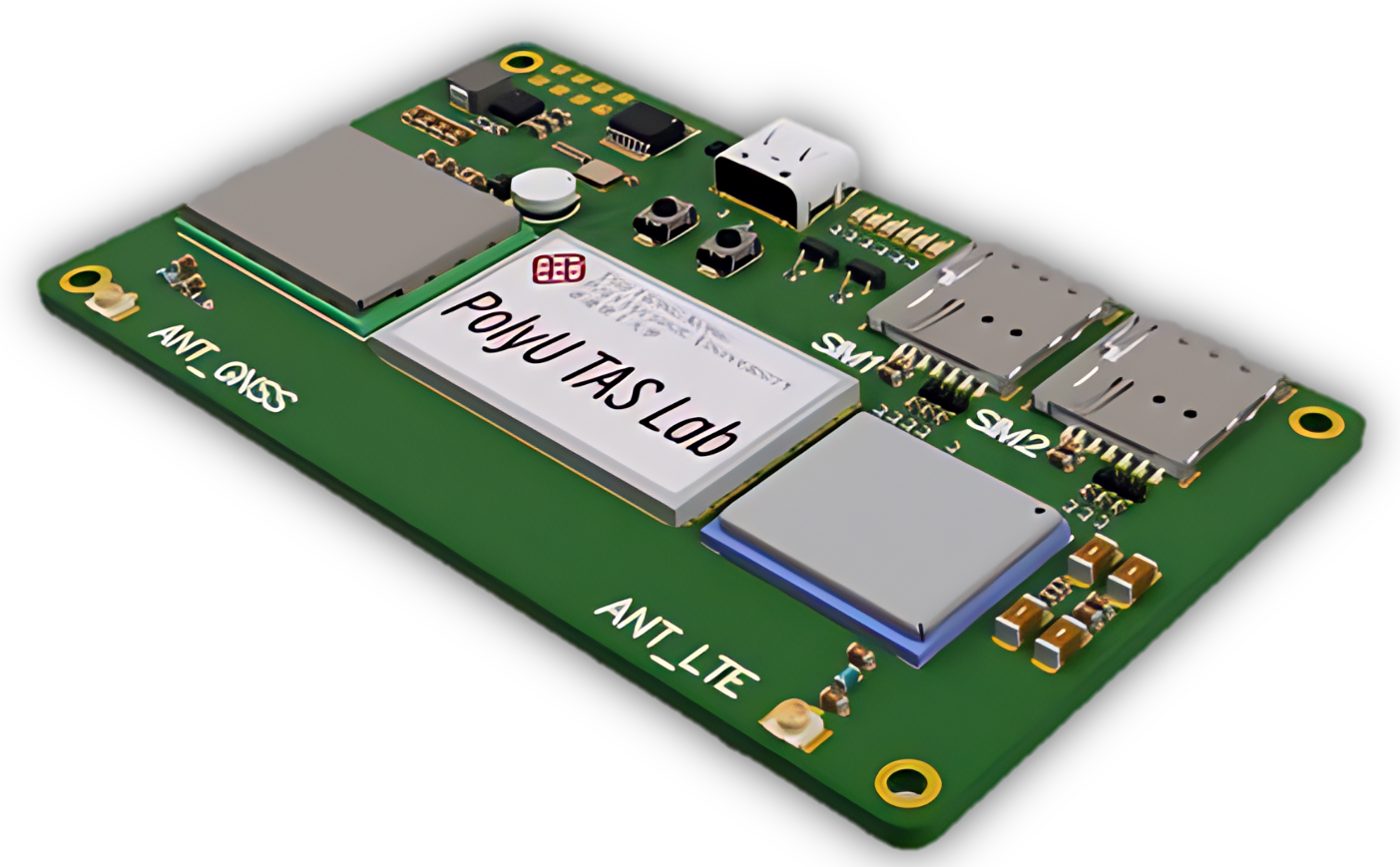
A ROS1 package for Ceres-based GNSS/IMU sliding-window fusion, ready to run on the lab's GNSS-IMU-4G navigation module.
Key innovations
- Sliding-window GNSS/IMU optimisation with IMU pre-integration and online bias estimation
- Marginalisation, GNSS position and velocity constraints and built-in NLOS exclusion
- Every function switchable from the launch file; NovAtel driver and NMEA parsers included
Impact
- Validated on a dual-IMU + u-blox F9P + 4G module for outdoor robots
- Hardware enquiries: hbwu@hkpolyu-wxresearch.cn
Gallery