On 27 March 2025, Dr. BAI Shiyu, a postdoctoral fellow of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB), represented the lab with a talk at the Satellite Navigation 2025 – International Workshop for Young Scientists, held at Beihang University. His talk, “Indoor Semantic Mapping and Localization Method Based On Inertial-Only Perception”, highlighted TASLAB’s academic research on indoor pedestrian localization.
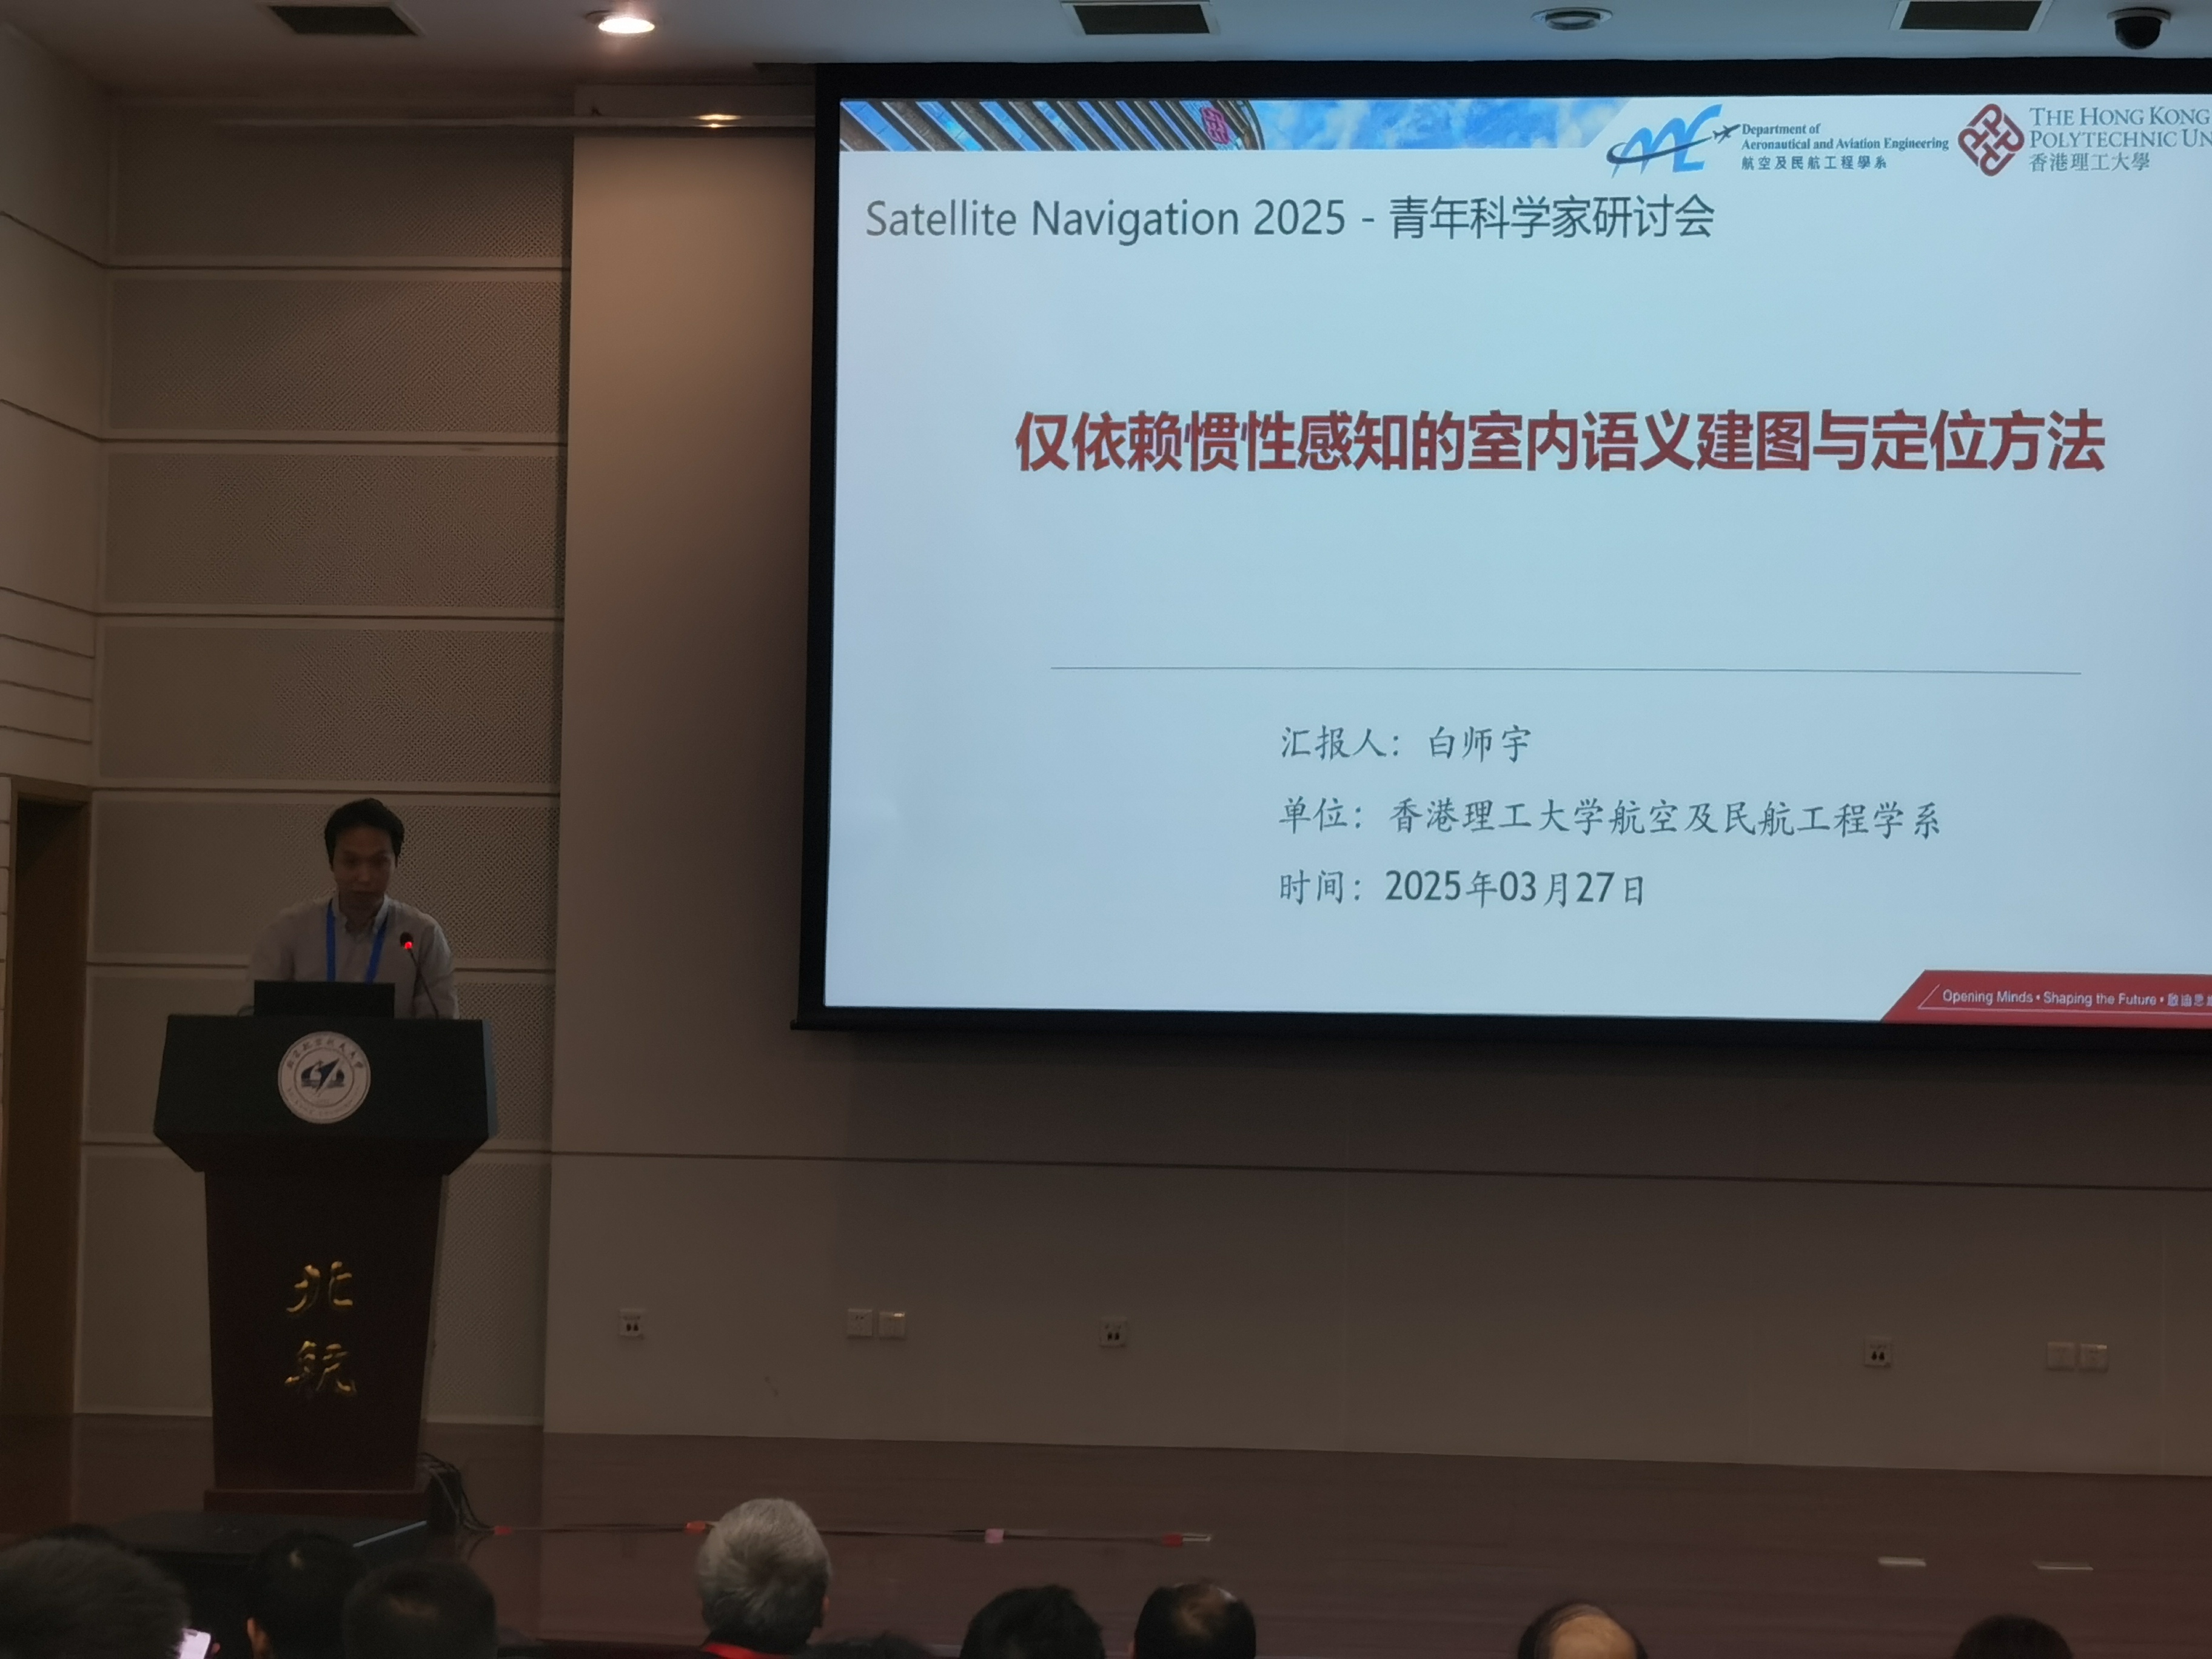
Dr. BAI Shiyu presenting at Beihang University.
Indoor semantic mapping and localization based on inertial-only perception
An inertial measurement unit (IMU) is often used as a small component within an integrated navigation system. In most cases, the IMU only serves to enhance the accuracy of external sensors, so the positioning results rely mainly on those external sensors. If the external sensors fail, the entire navigation system may fail as well, because low-cost IMUs cannot be used on their own due to their rapid error drift.
TASLAB’s research aims to push the boundaries of IMU-based localization. By leveraging motion features and deep learning techniques, the team has developed an indoor semantic mapping and localization method based on inertial-only perception. In addition, in collaboration with Honor Company, the team is exploring smartwatch-based inertial odometry, which is particularly challenging in real-world scenarios because of the vigorous movements of the human body.