Hong Kong, 6 July 2025 – The Trustworthy AI and Autonomous Systems Laboratory (TASLAB) will have a strong presence at the upcoming 2025 IEEE 28th International Conference on Intelligent Transportation Systems (IEEE ITSC 2025), to be held on 18-21 November 2025 in Gold Coast, Australia. The conference will feature three accepted research papers and a dedicated workshop led by our research team, reflecting our commitment to advancing solutions in intelligent transportation.
ITSC is a premier global forum for researchers, practitioners and policymakers to discuss the latest developments and challenges in intelligent transportation systems.
Accepted papers
Enhanced navigation in urban environments. The paper “Enhancing LEO-GNSS Positioning in Urban Canyons: A Factor Graph Optimization Approach with StarLink Simulations” explores new methods to improve the accuracy of Global Navigation Satellite System (GNSS) positioning in challenging urban environments, particularly through the integration of Low Earth Orbit (LEO) satellite constellations such as StarLink. The paper is co-authored by Yixin GAO, Weisong WEN, Xikun LIU, Feng HUANG, Jiahao HU and Dongzhe SU.
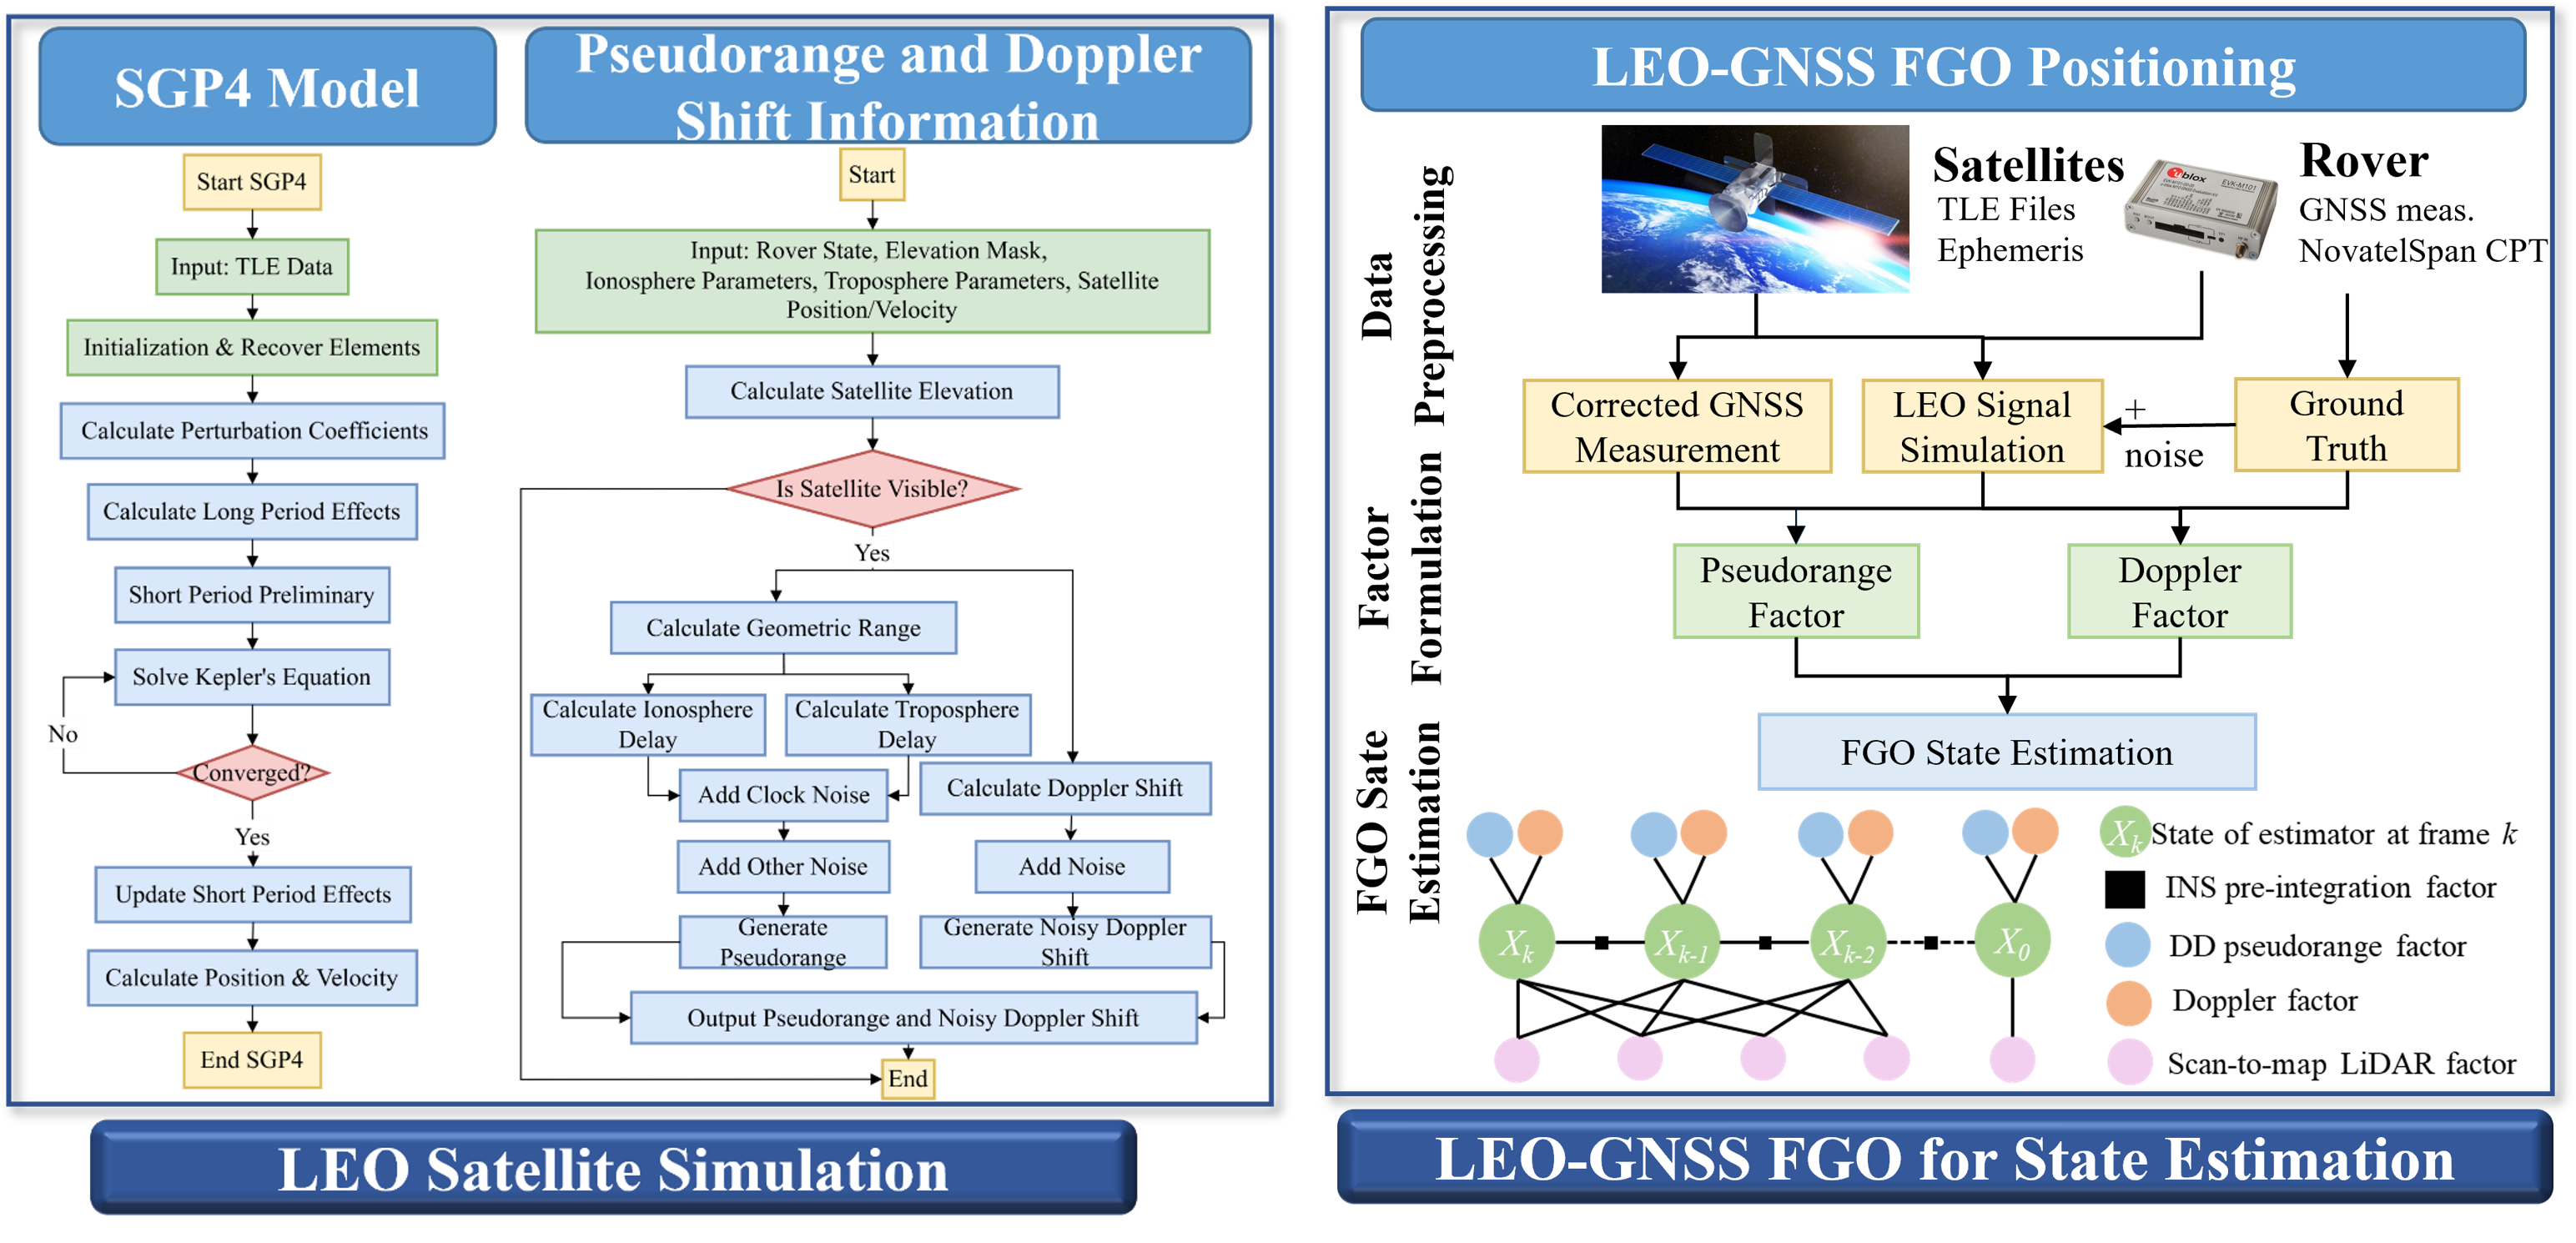
Enhancing LEO-GNSS positioning in urban canyons with factor graph optimization.
Safe and robust autonomous navigation. The paper “Integrity-Monitored Deep Reinforcement Learning for Safe and Robust Autonomous Navigation” develops deep reinforcement learning techniques that incorporate integrity monitoring to ensure the safety and reliability of autonomous driving systems. The paper is co-authored by Yuanyuan ZHANG, Yingying WANG, Baoshan SONG and Weisong WEN.
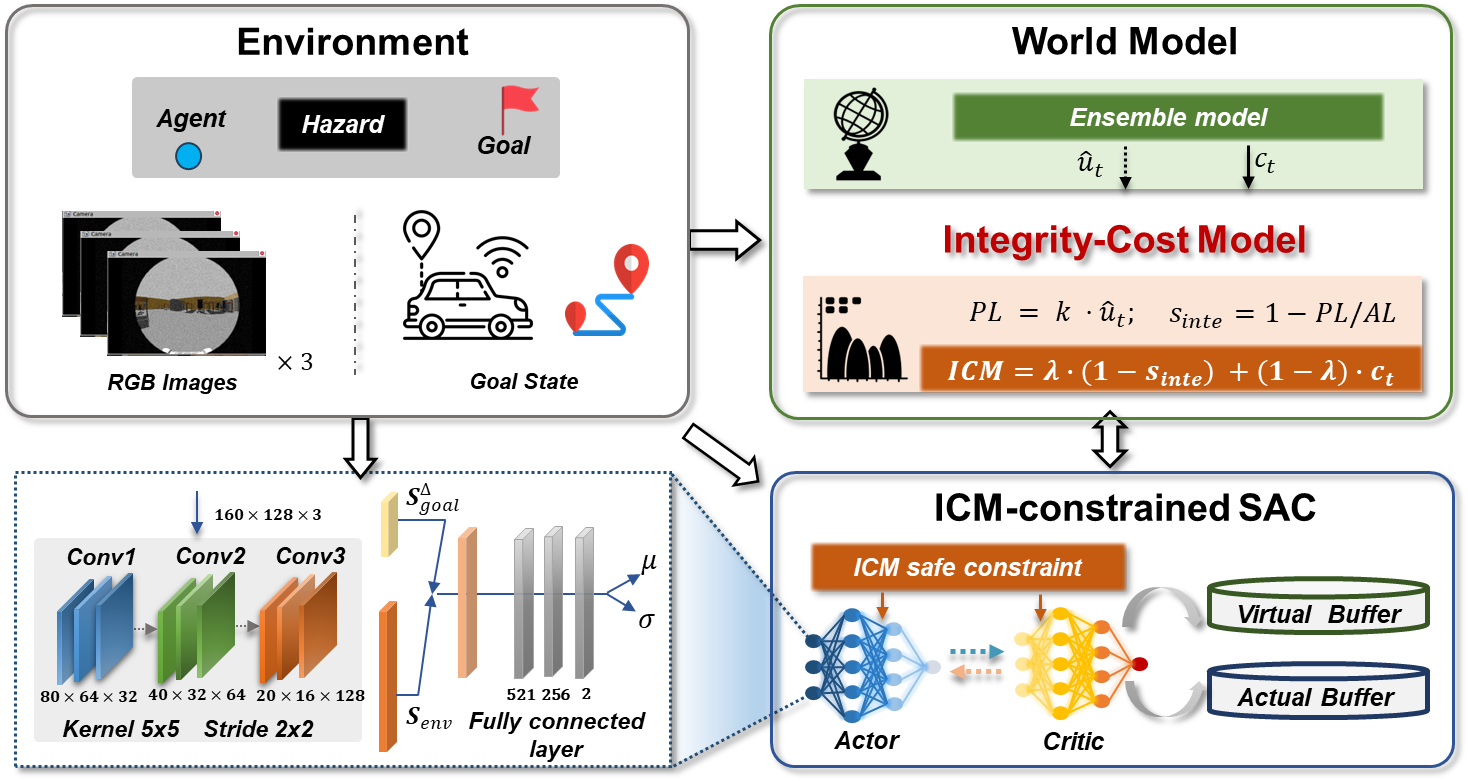
Integrity-monitored deep reinforcement learning for autonomous navigation.
A benchmark for cooperative urban navigation. The paper “UrbanV2X: A Multisensory Vehicle-Infrastructure Dataset for Cooperative Navigation in Urban Areas” introduces a comprehensive multisensory dataset designed to accelerate research in cooperative navigation in urban environments using Vehicle-to-Everything (V2X) communication. The contributors are Qijun QIN, Ziqi ZHANG, Yihan ZHONG, Feng HUANG, Xikun LIU, Runzhi HU, Hang CHEN, Wei HU, Dongzhe SU, Jun ZHANG, Hoi-Fung NG and Weisong WEN.
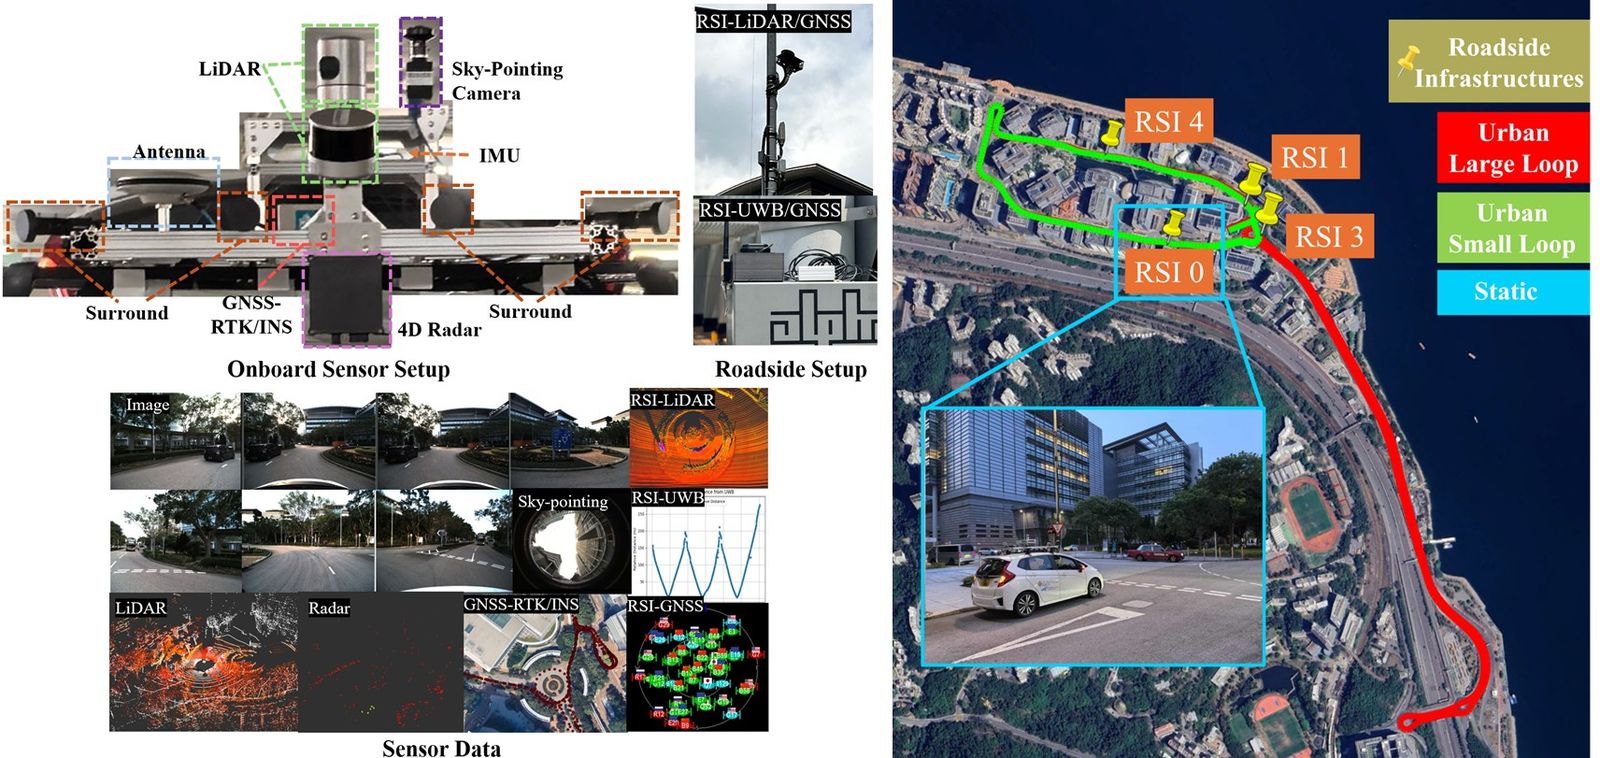
The UrbanV2X dataset: onboard and roadside sensor setups, sensor data and data collection routes.
Workshop
Our workshop, “4th Workshop on Intelligent Vehicle Meets Urban Safe and Certifiable Navigation and Control for Intelligent Vehicles in Complex Urban Scenarios”, has also been accepted. It will provide a platform for experts to exchange ideas on ensuring the safety, reliability and certifiability of intelligent vehicles operating in complex urban landscapes.
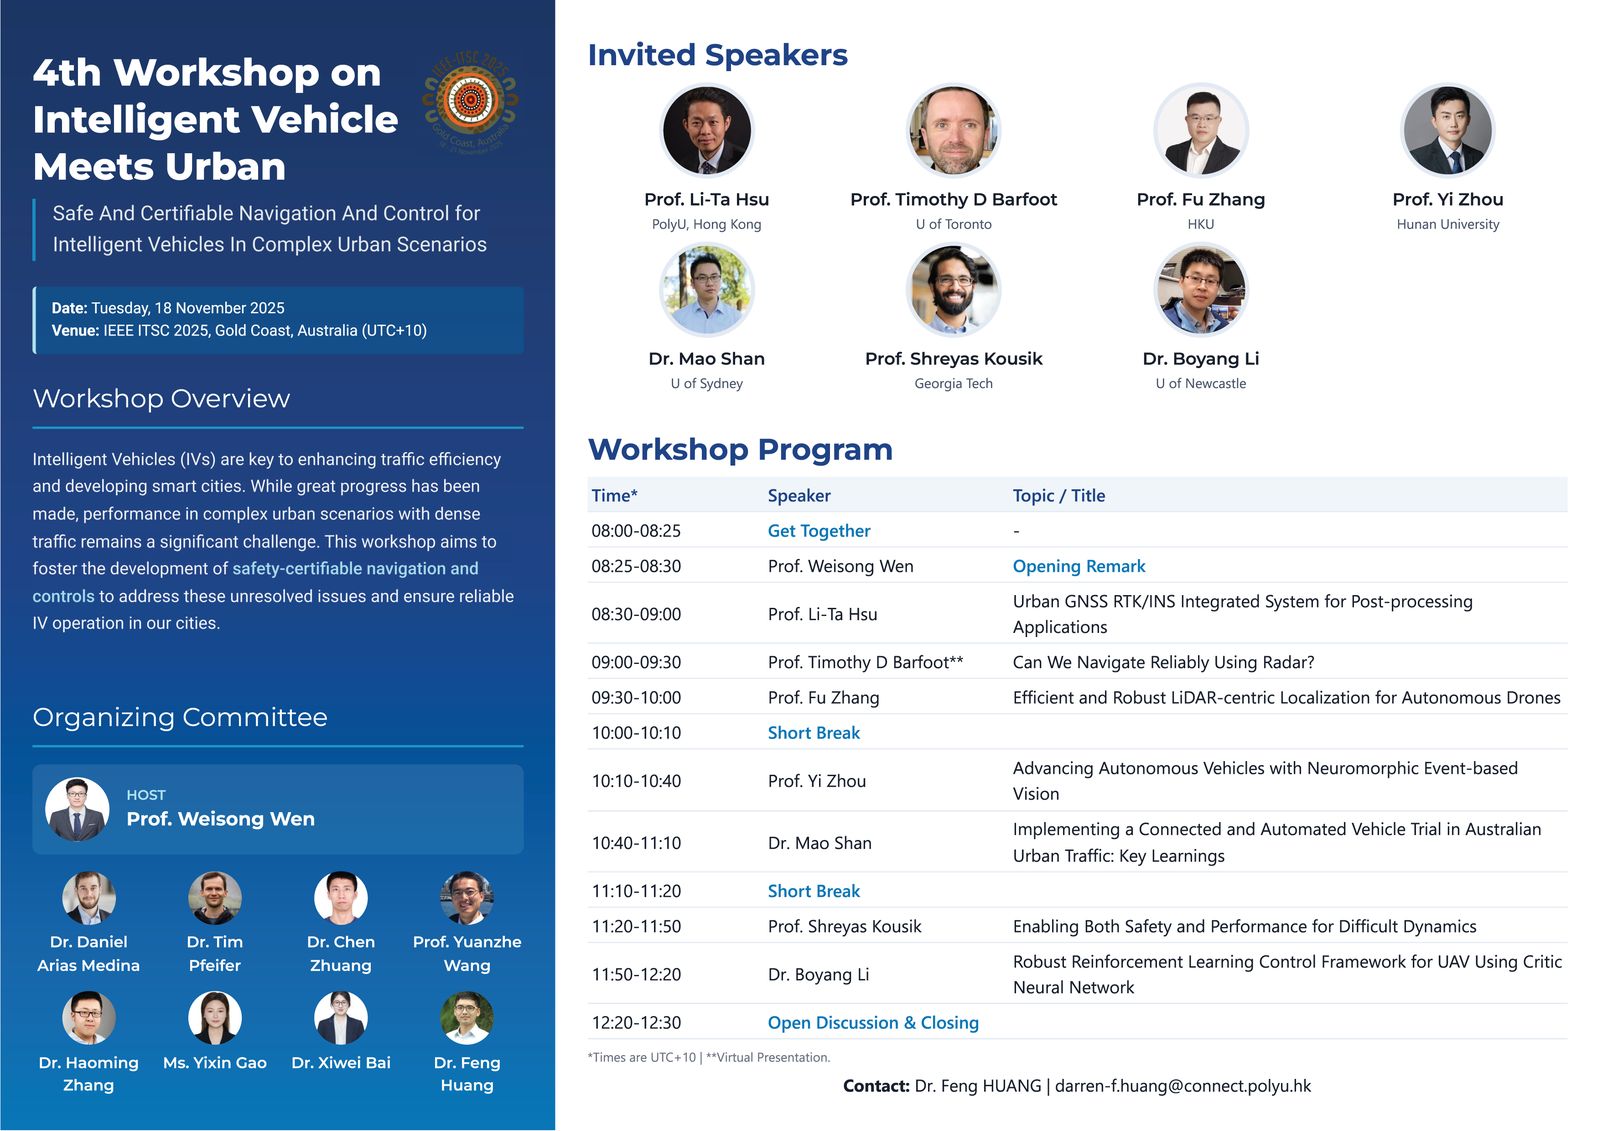
Programme of the 4th Workshop on Intelligent Vehicle Meets Urban.
“We are incredibly proud of our team’s success at ITSC 2025,” says Weisong WEN. “Having three papers accepted and leading a workshop at such a prominent conference is a testament to the dedication, innovation, and impactful research our team consistently delivers. We look forward to contributing to the global dialogue on intelligent transportation systems in Gold Coast.”
TASLAB remains dedicated to research on safer, more efficient and intelligent transportation solutions for the future.