The Trustworthy AI and Autonomous Systems Laboratory (TASLAB) is organizing the 1st Workshop on Robot Meets GNSS and Ranging for Seamless Autonomy at IEEE ICRA 2026, taking place on Friday, 5 June 2026, in Vienna. If you work on reliable autonomy in the real world, especially where GNSS/UWB/ranging gets messy, this workshop is for you. More details are available on the workshop page.
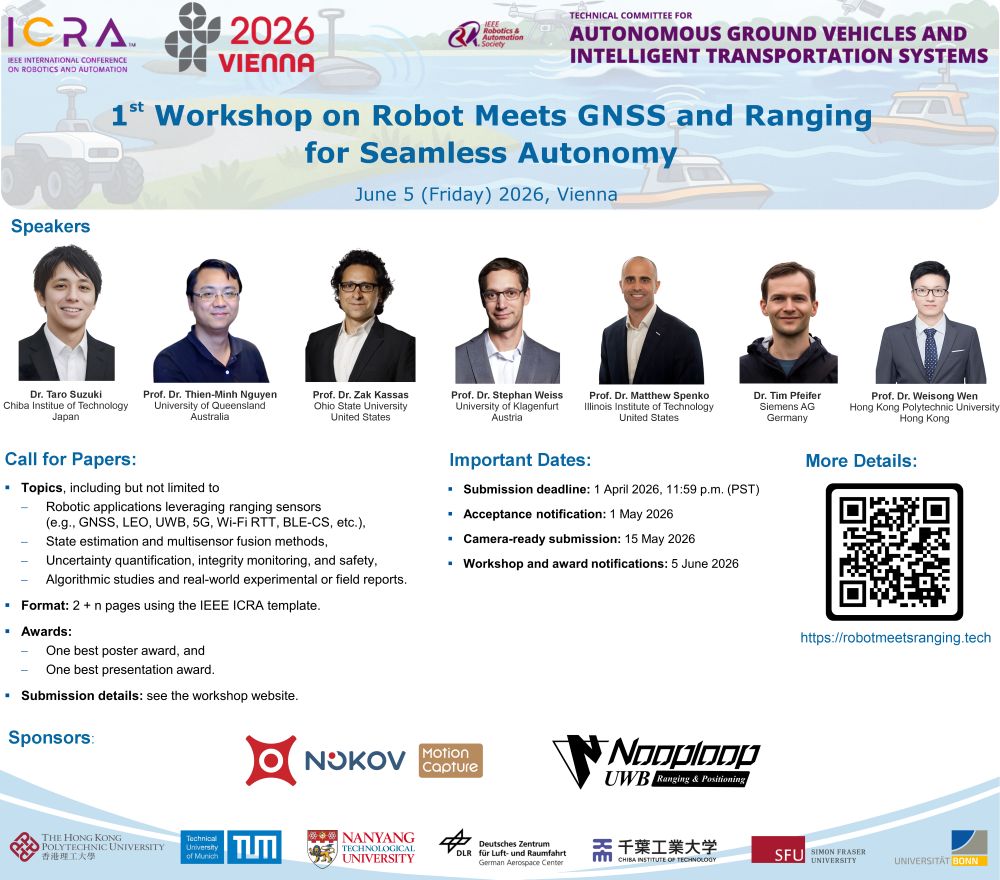
Workshop poster.
Recognizing shared challenges in sensor integration, error modeling, integrity monitoring and certifiable optimization of ranging observations from diverse systems (e.g. GNSS, Ultra-Wideband), the workshop emphasizes the critical role of ranging technologies in resilient robot navigation. It aims to identify open problems and promising research directions across domains, bringing together researchers from diverse communities to exchange knowledge and foster collaboration.
TASLAB remains dedicated to research on safer, more efficient and intelligent robotics solutions for the future.