On 5 March 2026, The Hong Kong Polytechnic University (PolyU) published a feature story titled “两会热点!理大深空造梦者实践科学家精神”, highlighting PolyU researchers whose work supports national priorities in high-level scientific and technological self-reliance, frontier innovation and the spirit of scientists. Among the featured researchers, Prof. Weisong Wen and his team were introduced for their vision and research direction in deep-space robotics.
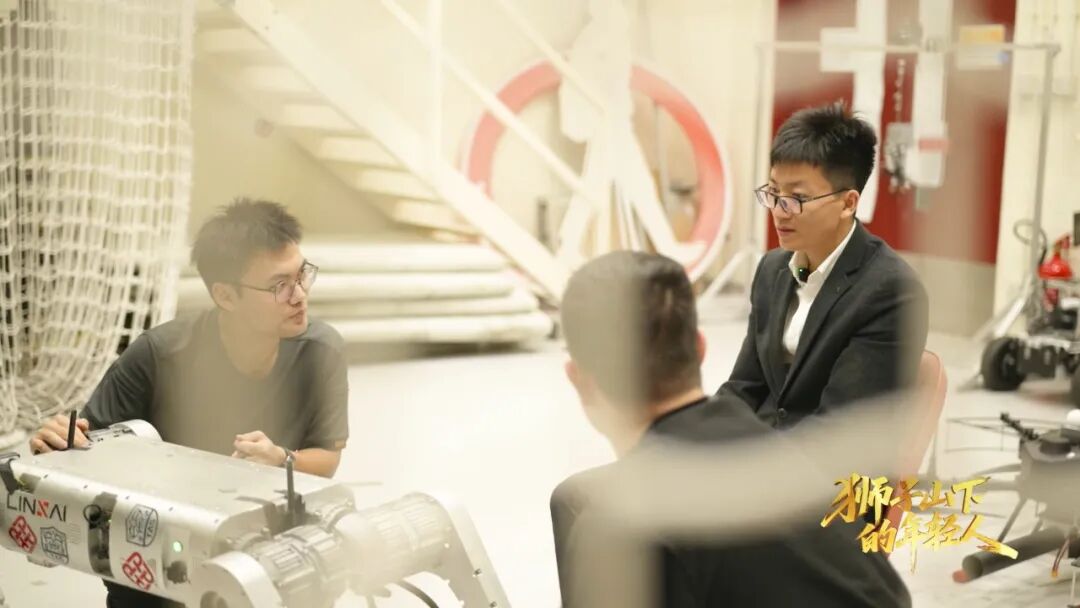
Prof. Weisong Wen and his team were featured in the PolyU report on deep-space robotics.
A vision for deep-space robots
The report presented Prof. Wen as a forward-looking robotics researcher, emphasising that future deep-space robots must go beyond basic mobility. For lunar and planetary missions, robots should be able to move steadily, operate reliably over long distances and complete complex tasks in harsh, uncertain and remote environments. This vision connects closely with the long-term research strengths of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) in trustworthy autonomous systems, robotic navigation, multi-sensor fusion, SLAM, localization and intelligent decision-making.
A key achievement highlighted in the report is the team’s work on intelligent robotic systems for lunar exploration. In such missions, robots are expected to serve as reliable carriers and autonomous agents that can perform designated tasks on the lunar surface. These systems require robust perception, precise localization, safe motion planning and dependable control, especially under limited communication, difficult terrain and extreme environmental conditions.
A three-stage roadmap
Prof. Wen also shared a three-stage development roadmap for deep-space robotics:
- Reliable robotic platforms: develop intelligent robot carriers for lunar exploration, enabling robots to perform assigned tasks on the lunar surface with stability and robustness.
- Earth-Moon communication and navigation networks: build the infrastructure for real-time data transmission and interaction among robots, Earth and future lunar bases. The report also highlighted Prof. Wen’s view that one day the Moon may have navigation services similar to GPS on Earth.
- Intelligent robotic brains: equip future robots with stronger autonomy, including environmental perception, decision-making, fault diagnosis and self-recovery. In this vision, robots will not only execute commands but also understand situations, respond to failures and support long-duration missions more independently.
The feature story showcased Prof. Wen's vision for the future of lunar and deep-space robots.
Interdisciplinary research
The feature also reflected the broader value of interdisciplinary research at PolyU. Deep-space robotics requires the integration of aerospace engineering, artificial intelligence, robotics, communication, navigation and advanced autonomy. By advancing trustworthy robotic systems for extreme environments, Prof. Wen and TASLAB aim to contribute not only to future lunar exploration but also to practical autonomous technologies that can benefit transportation, inspection, low-altitude autonomy and service robotics on Earth.
Through continuous experimentation, system integration and iterative engineering, TASLAB will keep pursuing robust and trustworthy autonomy for challenging real-world and off-world environments. The team’s future work will focus on reliable robotic platforms, resilient navigation and communication, and intelligent decision-making systems, supporting the long-term vision of enabling robots to explore, work and cooperate safely in the most demanding environments.
Original feature by PolyU WeChat: 两会热点!理大深空造梦者实践科学家精神.