On 25 June 2026, Prof. Weisong Wen, Director of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU), presented at the International Technical Symposium on Navigation and Timing (ITSNT 2026), held at the École Nationale de l’Aviation Civile (ENAC) in Toulouse, France.
As the opening speaker of Session 1 (chaired by Carl MILNER, ENAC), Prof. Wen presented “Efficient and Outlier-Aware GNSS/LiDAR/inertial Integrated Positioning for Autonomous Systems in Urban Canyons” from 9:15 to 9:45 AM. His talk was featured alongside presentations from researchers at the European Space Agency (ESA), CNES, Stanford University and other institutions, highlighting TASLAB’s growing international visibility in navigation and timing research.

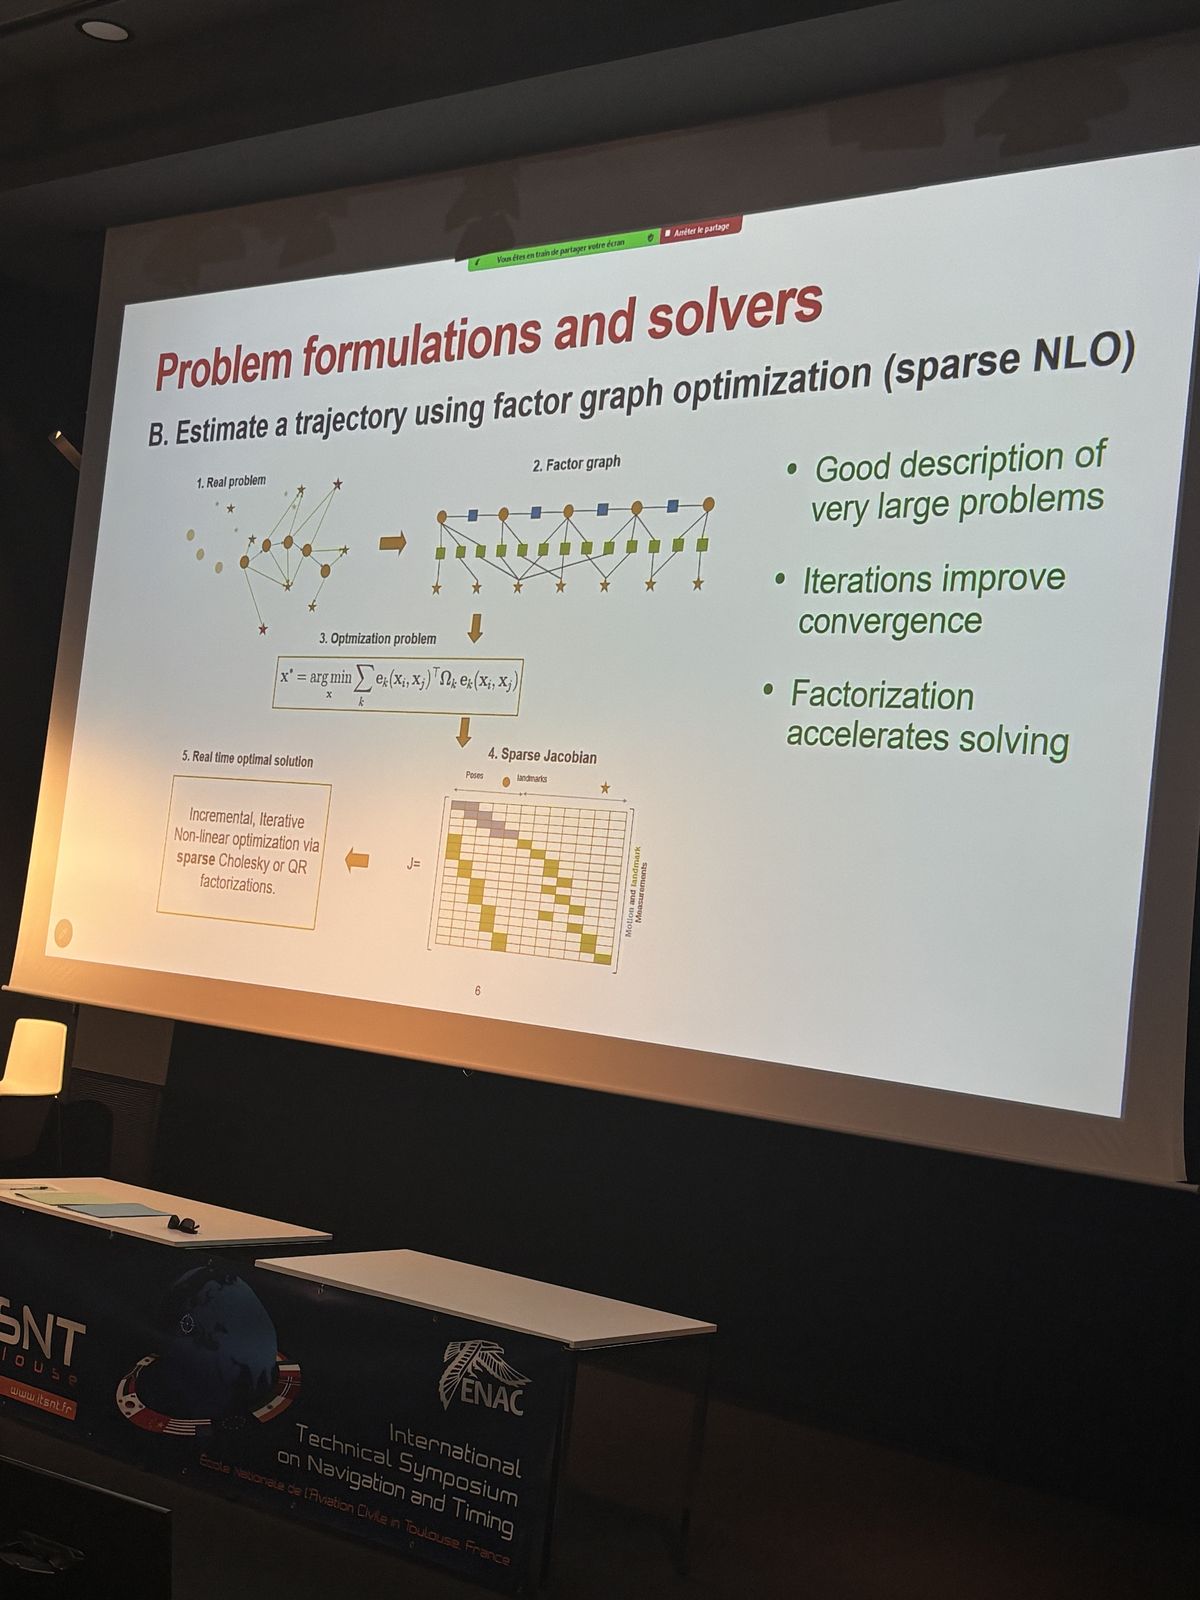
Prof. Wen's talk at ITSNT 2026.
Research roadmap
Prof. Wen’s presentation traced a coherent research roadmap on trustworthy positioning in urban canyons, from GNSS NLOS handling to tightly coupled multi-sensor fusion. The talk covered several key research threads from TASLAB:
- 3D LiDAR Aided (3DLA) GNSS: a systematic progression from NLOS detection and exclusion to Doppler-aided direction-of-arrival estimation and reflection-path-based NLOS correction in dense urban environments.
- 3DLA GNSS-RTK: an efficient factor-graph optimization framework integrating virtual satellites for geometry improvement and drift-free point-cloud-map-aided NLOS exclusion.
- GLIO: a globally consistent, tightly coupled GNSS/LiDAR/IMU odometry system for continuous and drift-free state estimation in urban areas (open-source code on GitHub).
- GLIO2: a GPU-parallelized LiDAR–Inertial–GNSS framework designed for robust, real-time global localization on edge devices.
- GNSS Integrity via Differentiable Protection Levels: a novel approach bridging robust robotics perception and aviation-grade integrity monitoring for safety-critical autonomous systems.
The talk also showed real-world applications of TASLAB’s positioning technologies, including autonomous facade-cleaning UAVs and guide-dog navigation systems for the visually impaired, demonstrating how robust multi-sensor fusion translates into practical solutions for safety-assured autonomous systems.
ENAC campus, the venue of ITSNT 2026 in Toulouse, France.
Prof. Wen’s participation at ITSNT 2026 reflects TASLAB’s commitment to advancing trustworthy AI and autonomous systems through research in urban navigation, multi-sensor fusion and safety-assured positioning, and to fostering international academic exchange with the global PNT community.
More details about the symposium program can be found on the ITSNT 2026 website.