On 12 October 2026, TASLAB PhD student ZHANG Yuanyuan successfully passed her PhD oral defense at The Hong Kong Polytechnic University. Her dissertation, supervised by Prof. Weisong Wen and co-supervised by Prof. Li-Ta Hsu, is titled Trustworthy Learning-enabled Safe and Robust Autonomous Navigation for Uncertain Environments.
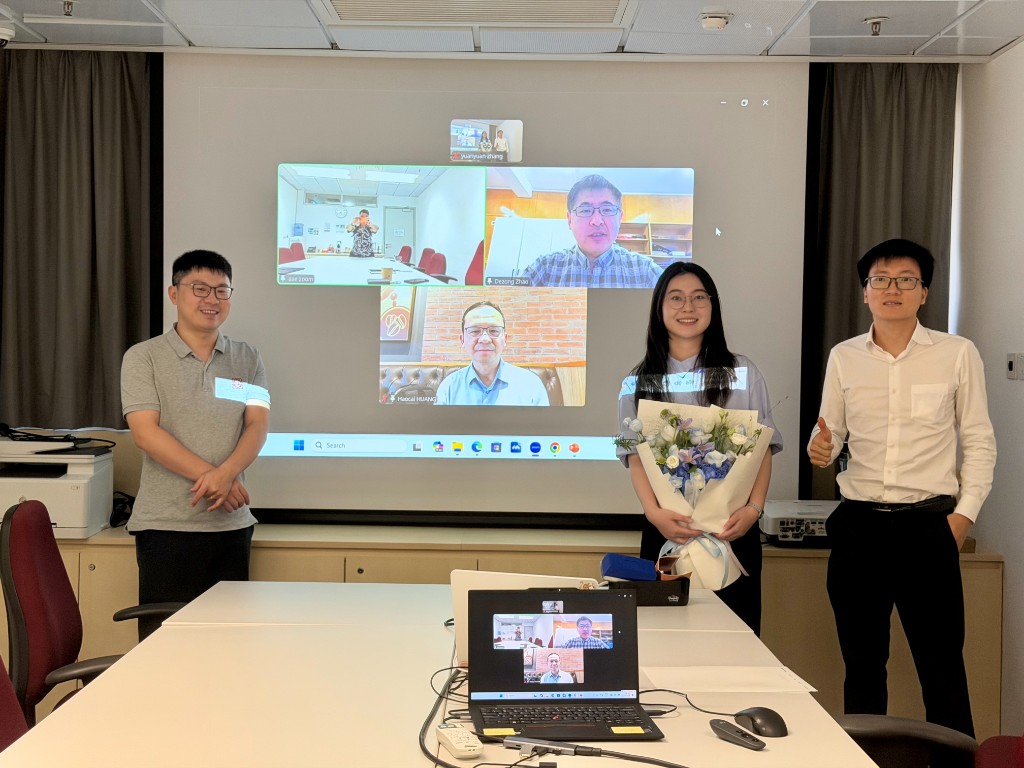
ZHANG Yuanyuan following her successful PhD oral defense, with members of the examination panel joining remotely.
Her doctoral research develops trustworthy learning-enabled navigation methods for autonomous systems operating in uncertain, partially observable and dynamic environments. The dissertation brings together four complementary directions:
- predictive safety assurance, enabling safety evaluation before an action is executed;
- epistemic integrity risk monitoring, improving trust in information under multi-source uncertainty;
- adaptive robust safe policy optimisation, addressing changing uncertainty and tail risks; and
- memory-enhanced safe exploration, using structured risk memory to learn more safely when risk feedback is sparse or delayed.
These contributions span UAV flight interaction and autonomous ground-robot navigation, connecting safety certification, observation-level trust monitoring, uncertainty-aware reinforcement learning and robust real-world deployment.
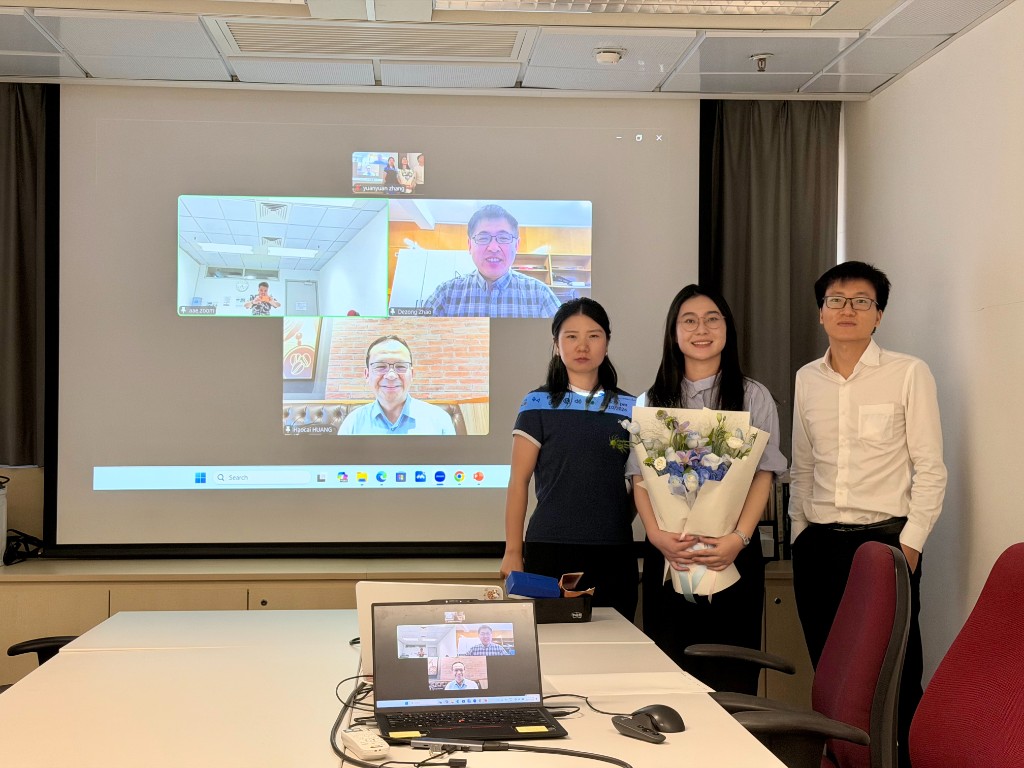
TASLAB warmly congratulates Yuanyuan on this important milestone and wishes her every success in the next stage of her career!