← All datasets & code
Semantic-Vector HD Map
Multi-Sensor HD Map Construction Pipeline for Autonomous Vehicles
- Developed by
- Runzhi Hu
- Repository
- ebhrz/HDMap
- GitHub
- 53 stars · 17 forks
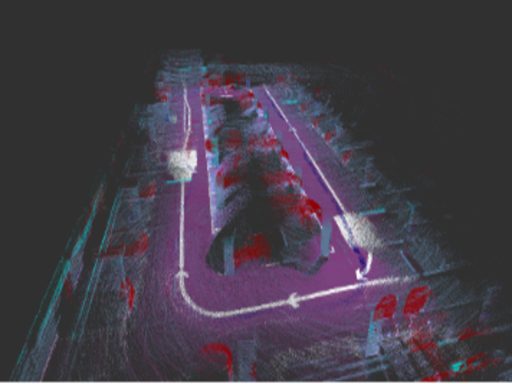
Summary
An open pipeline that builds high-definition semantic and vector maps from GNSS, INS, LiDAR and camera data, with an analysis of how errors propagate into the map.
Key innovations
- Semantic extraction with Vision Transformer and Swin Transformer models
- 3D positions of map elements from LiDAR depth instead of planar assumptions
- GNSS-RTK/INS poses and vector extraction of lane markings
- Error-propagation analysis of segmentation and LiDAR–camera calibration errors
Impact
- 53 GitHub stars and 17 forks
- Published in IET Intelligent Transport Systems (2024)
- Technology behind the HD-mapping system delivered to ASTRI
Cite this work
R. Hu, S. Bai, W. Wen, X. Xia and L.-T. Hsu, "Towards high-definition vector map construction based on multi-sensor integration for intelligent vehicles: Systems and error quantification," IET Intelligent Transport Systems, 2024. DOI