← All datasets & code
SafetyQuantifiable-PLVINS
Safety-Quantifiable Visual Localization with 3D Prior Map
- Developed by
- Xi Zheng
- Repository
- ZHENGXi-git/SafetyQuantifiable-PLVINS
- GitHub
- 6 stars · 0 forks
Summary
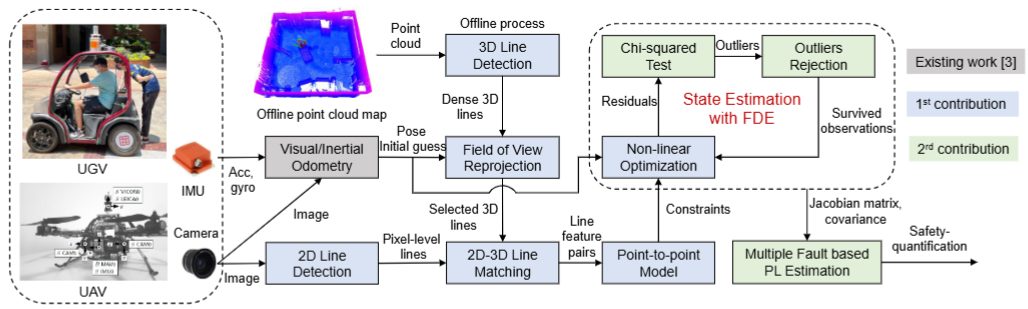
Monocular visual localization on a 3D prior line map that also reports a protection level, a certified bound on its own position and orientation error.
Key innovations
- Visual-inertial odometry constrained by 2D–3D line correspondences with a prior map
- GNSS-inspired integrity monitoring that computes protection levels
- First application of integrity monitoring to visual localization
Impact
- Published in IEEE Transactions on Intelligent Transportation Systems (2025)
- Brings aviation-style safety certification to camera-based localization
Cite this work
X. Zheng, W. Wen and L.-T. Hsu, "Safety-quantifiable line feature-based monocular visual localization with 3D prior map," IEEE Transactions on Intelligent Transportation Systems, 2025.