Cauchy–Gaussian Overbound for Heavy-Tailed GNSS Measurement Errors
Abstract
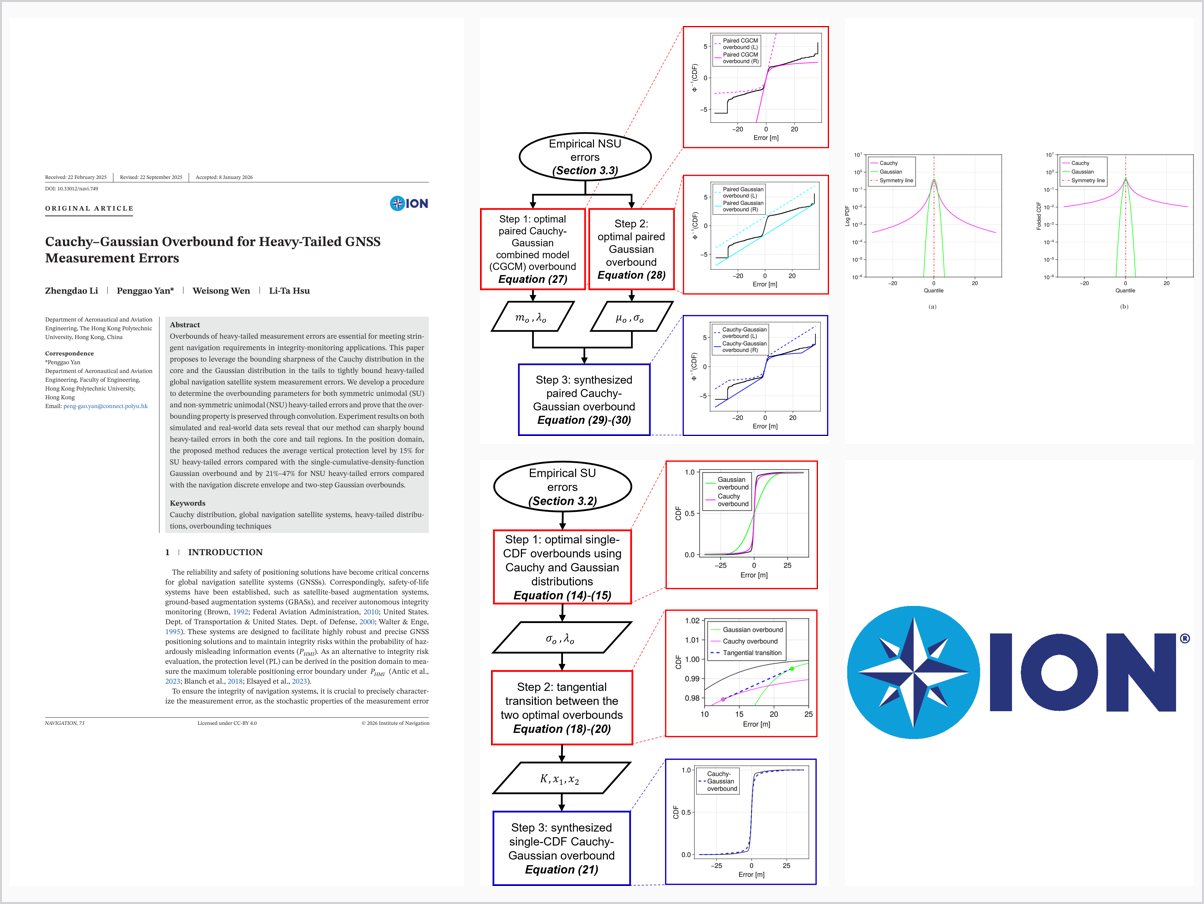
Abstract Overbounds of heavy-tailed measurement errors are essential for meeting stringent navigation requirements in integrity-monitoring applications. This paper proposes to leverage the bounding sharpness of the Cauchy distribution in the core and the Gaussian distribution in the tails to tightly bound heavy-tailed global navigation satellite system measurement errors. We develop a procedure to determine the overbounding parameters for both symmetric unimodal (SU) and non-symmetric unimodal (NSU) heavy-tailed errors and prove that the overbounding property is preserved through convolution. Experiment results on both simulated and real-world data sets reveal that our method can sharply bound heavy-tailed errors in both the core and tail regions. In the position domain, the proposed method reduces the average vertical protection level by 15% for SU heavy-tailed errors compared with the single-cumulative-density-function Gaussian overbound and by 21%–47% for NSU heavy-tailed errors compared with the navigation discrete envelope and two-step Gaussian overbounds.
Problem Addressed
Integrity-monitoring applications require overbounds of heavy-tailed GNSS measurement errors to meet stringent navigation requirements, but existing overbounding techniques cannot tightly bound such errors in both the core and tail regions.
Key Contributions
- Cauchy-Gaussian overbound combining the Cauchy distribution’s bounding sharpness in the core with Gaussian tails
- Parameter determination procedure for both symmetric unimodal and non-symmetric unimodal heavy-tailed errors
- Proof that the overbounding property is preserved through convolution
Conclusions
Experiments on simulated and real-world datasets show the method sharply bounds heavy-tailed errors in both core and tail regions. In the position domain, it reduces the average vertical protection level by 15% for symmetric unimodal errors compared with the single-CDF Gaussian overbound, and by 21%-47% for non-symmetric unimodal errors compared with the navigation discrete envelope and two-step Gaussian overbounds.