On 18 November 2025, the 4th Workshop on Intelligent Vehicle Meets Urban: Safe And Certifiable Navigation And Control was held at the Star Grand, Broadbeach, Gold Coast, Australia, in conjunction with the ITSC 2025 conference. The event brought together experts and researchers to address the critical challenges of ensuring safe, robust and certifiable autonomous navigation in complex urban environments.
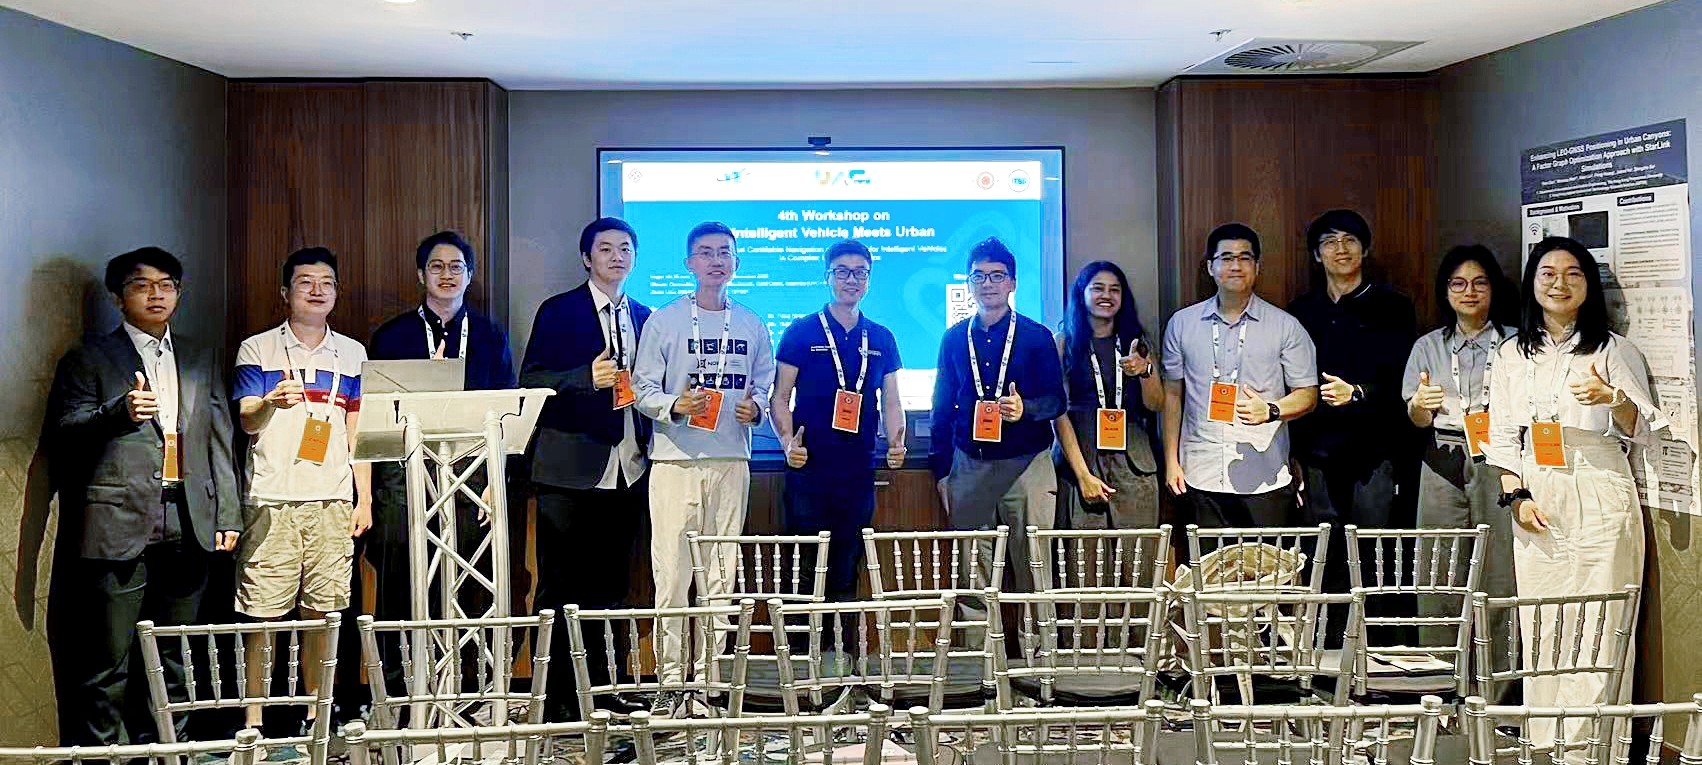
Speakers and attendees of the 4th IV Meets Urban workshop.
Invited speakers
- Prof. Li-Ta Hsu (The Hong Kong Polytechnic University)
- Prof. Timothy D Barfoot (University of Toronto)
- Prof. Fu Zhang (The University of Hong Kong)
- Prof. Yi Zhou (Hunan University, China)
- Dr. Mao Shan (The University of Sydney)
- Prof. Shreyas Kousik (Georgia Institute of Technology)
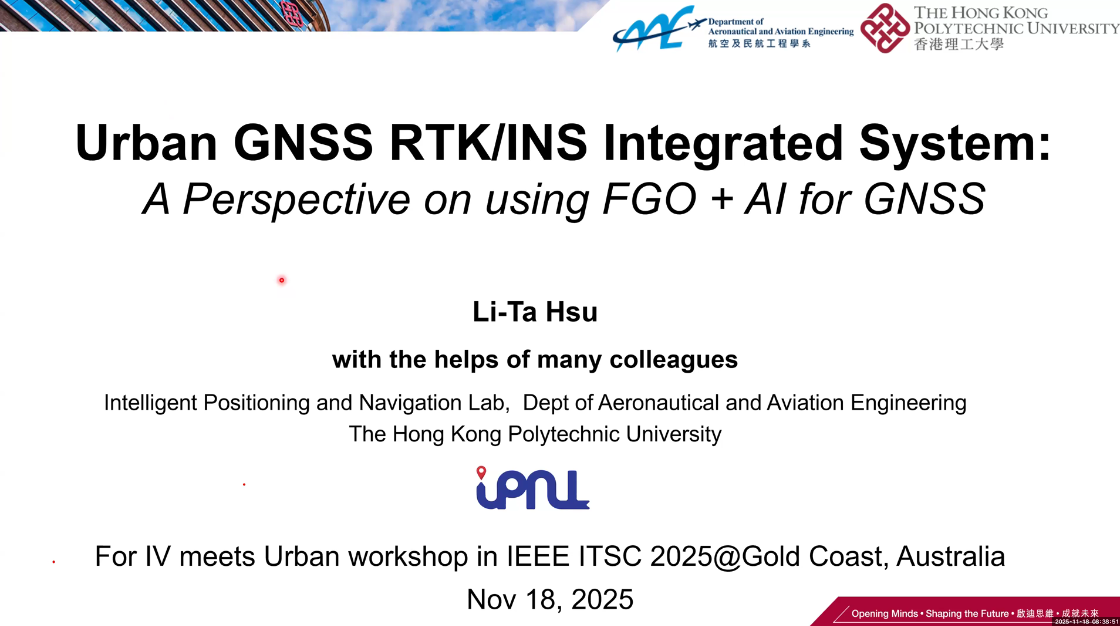
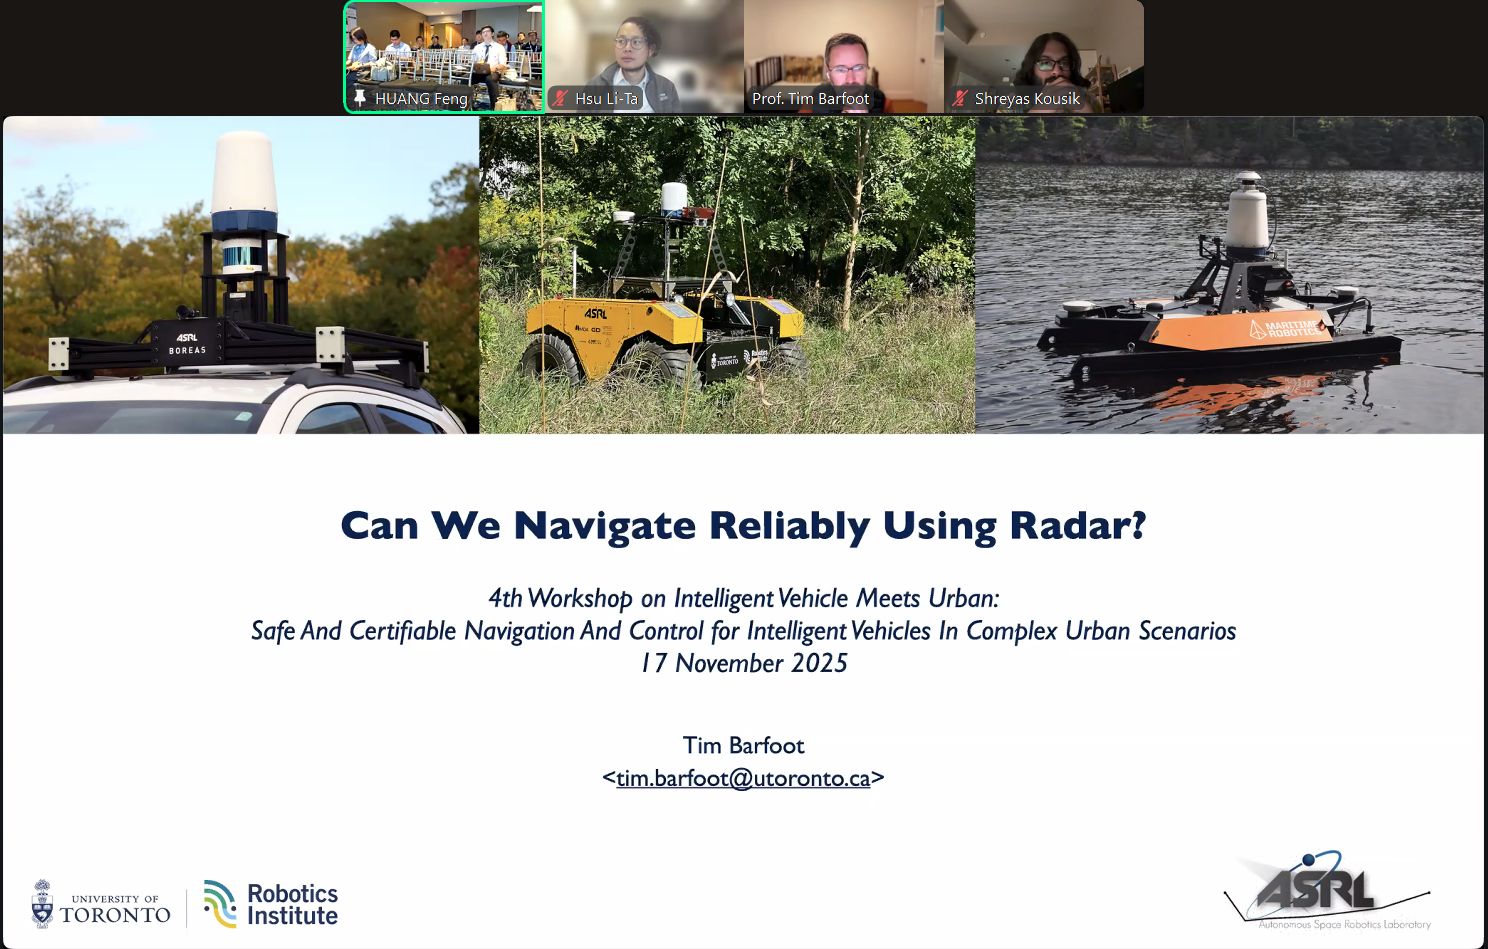
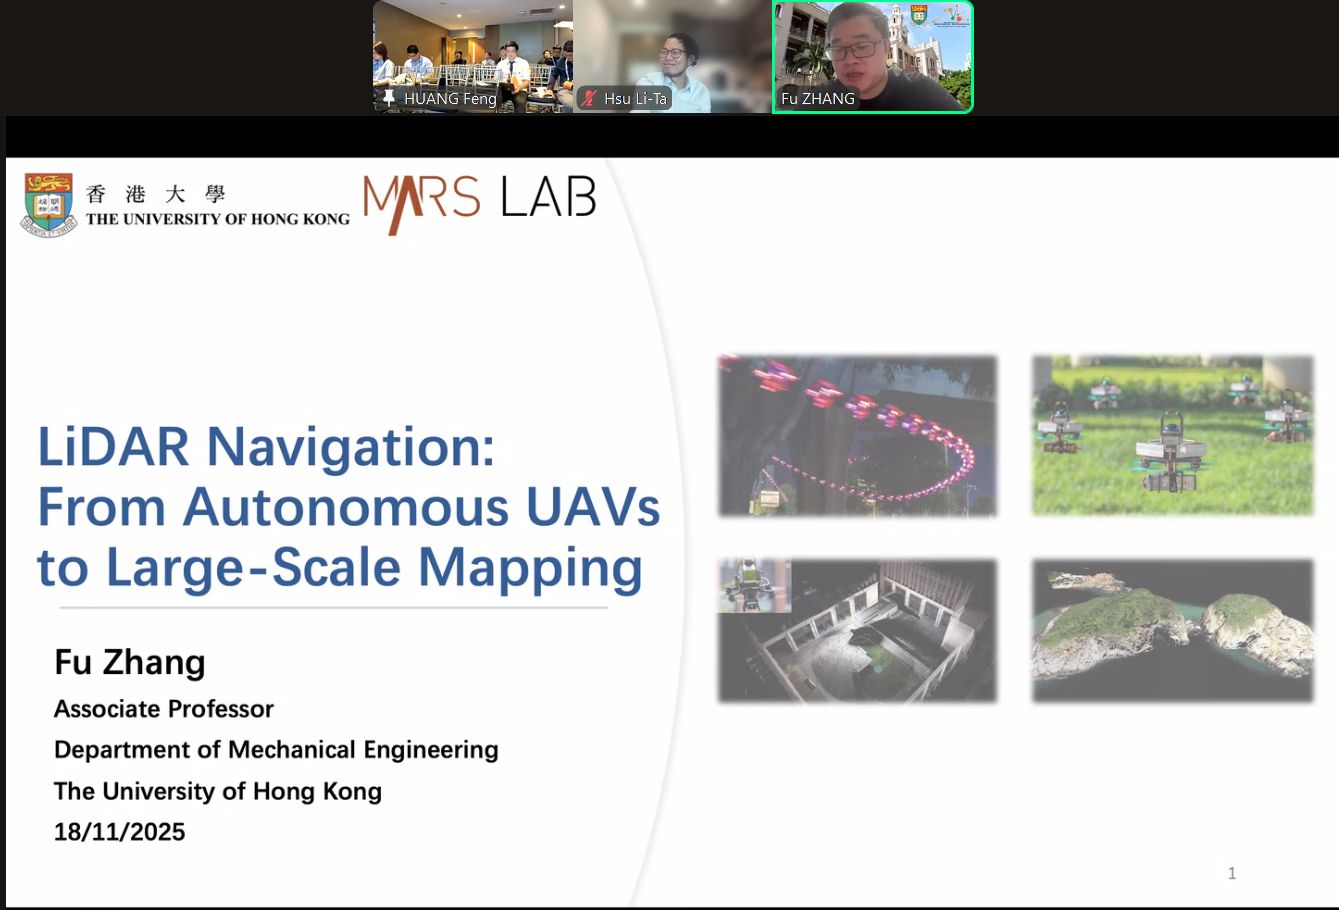
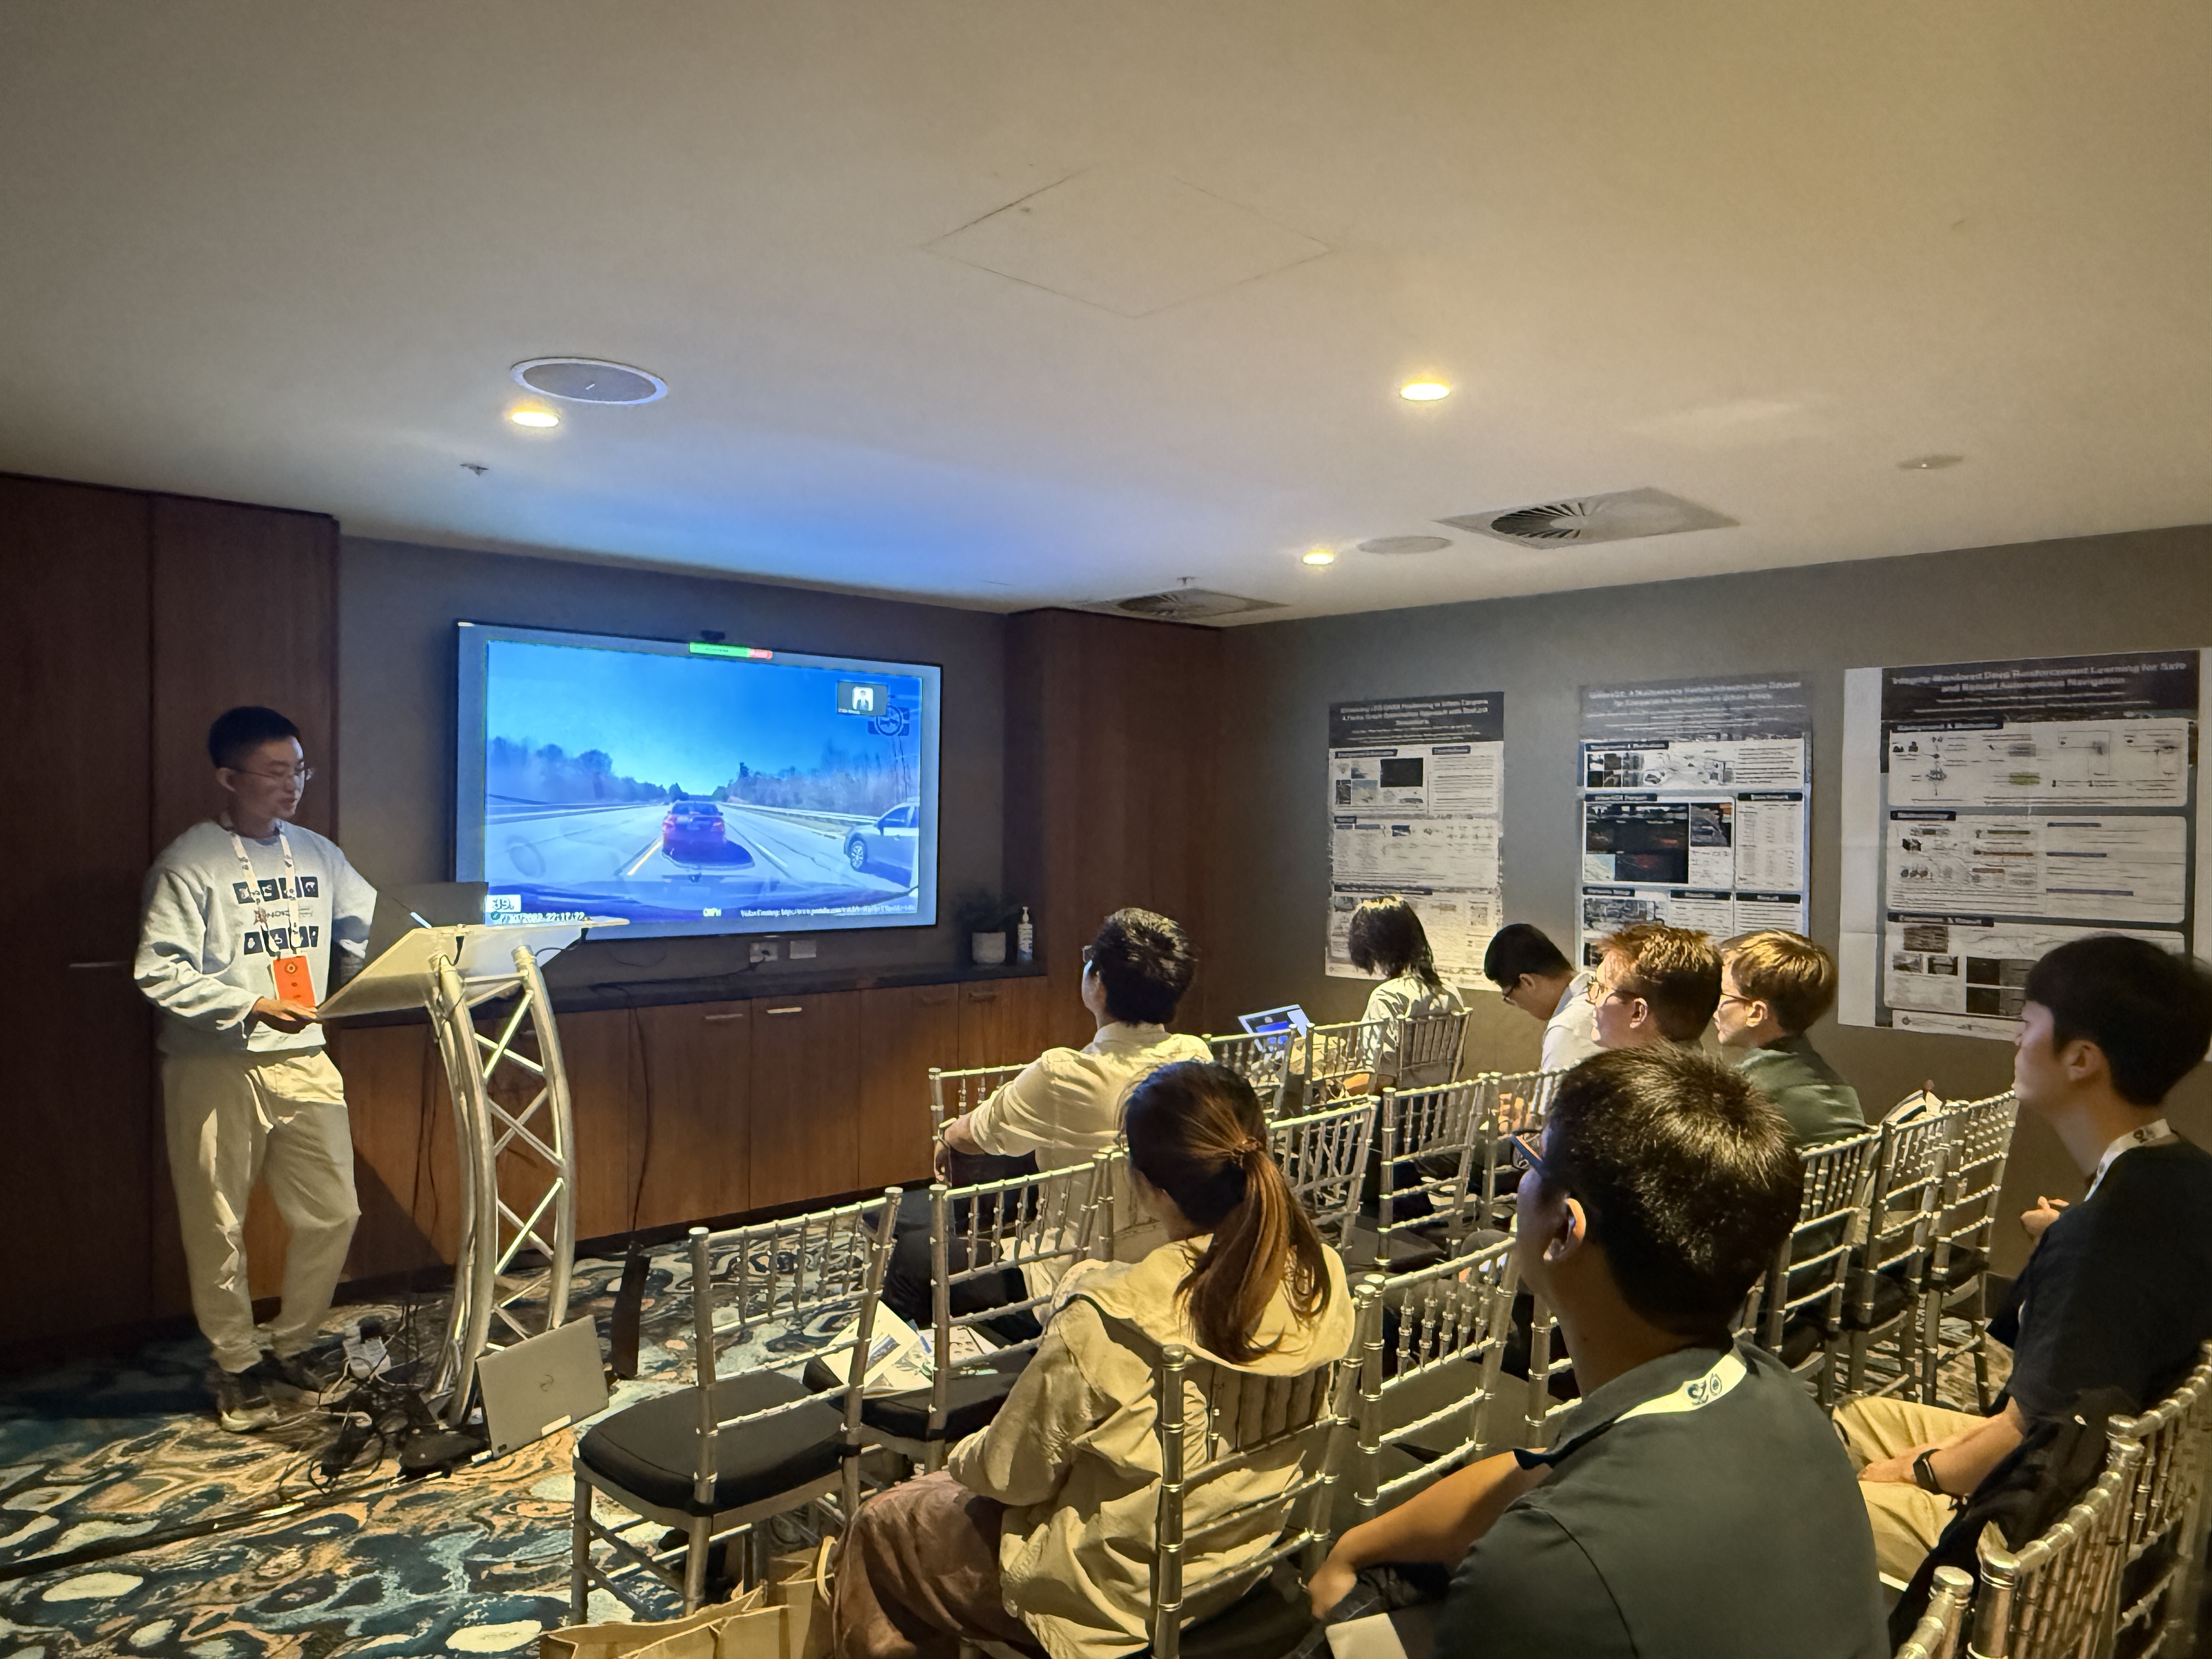
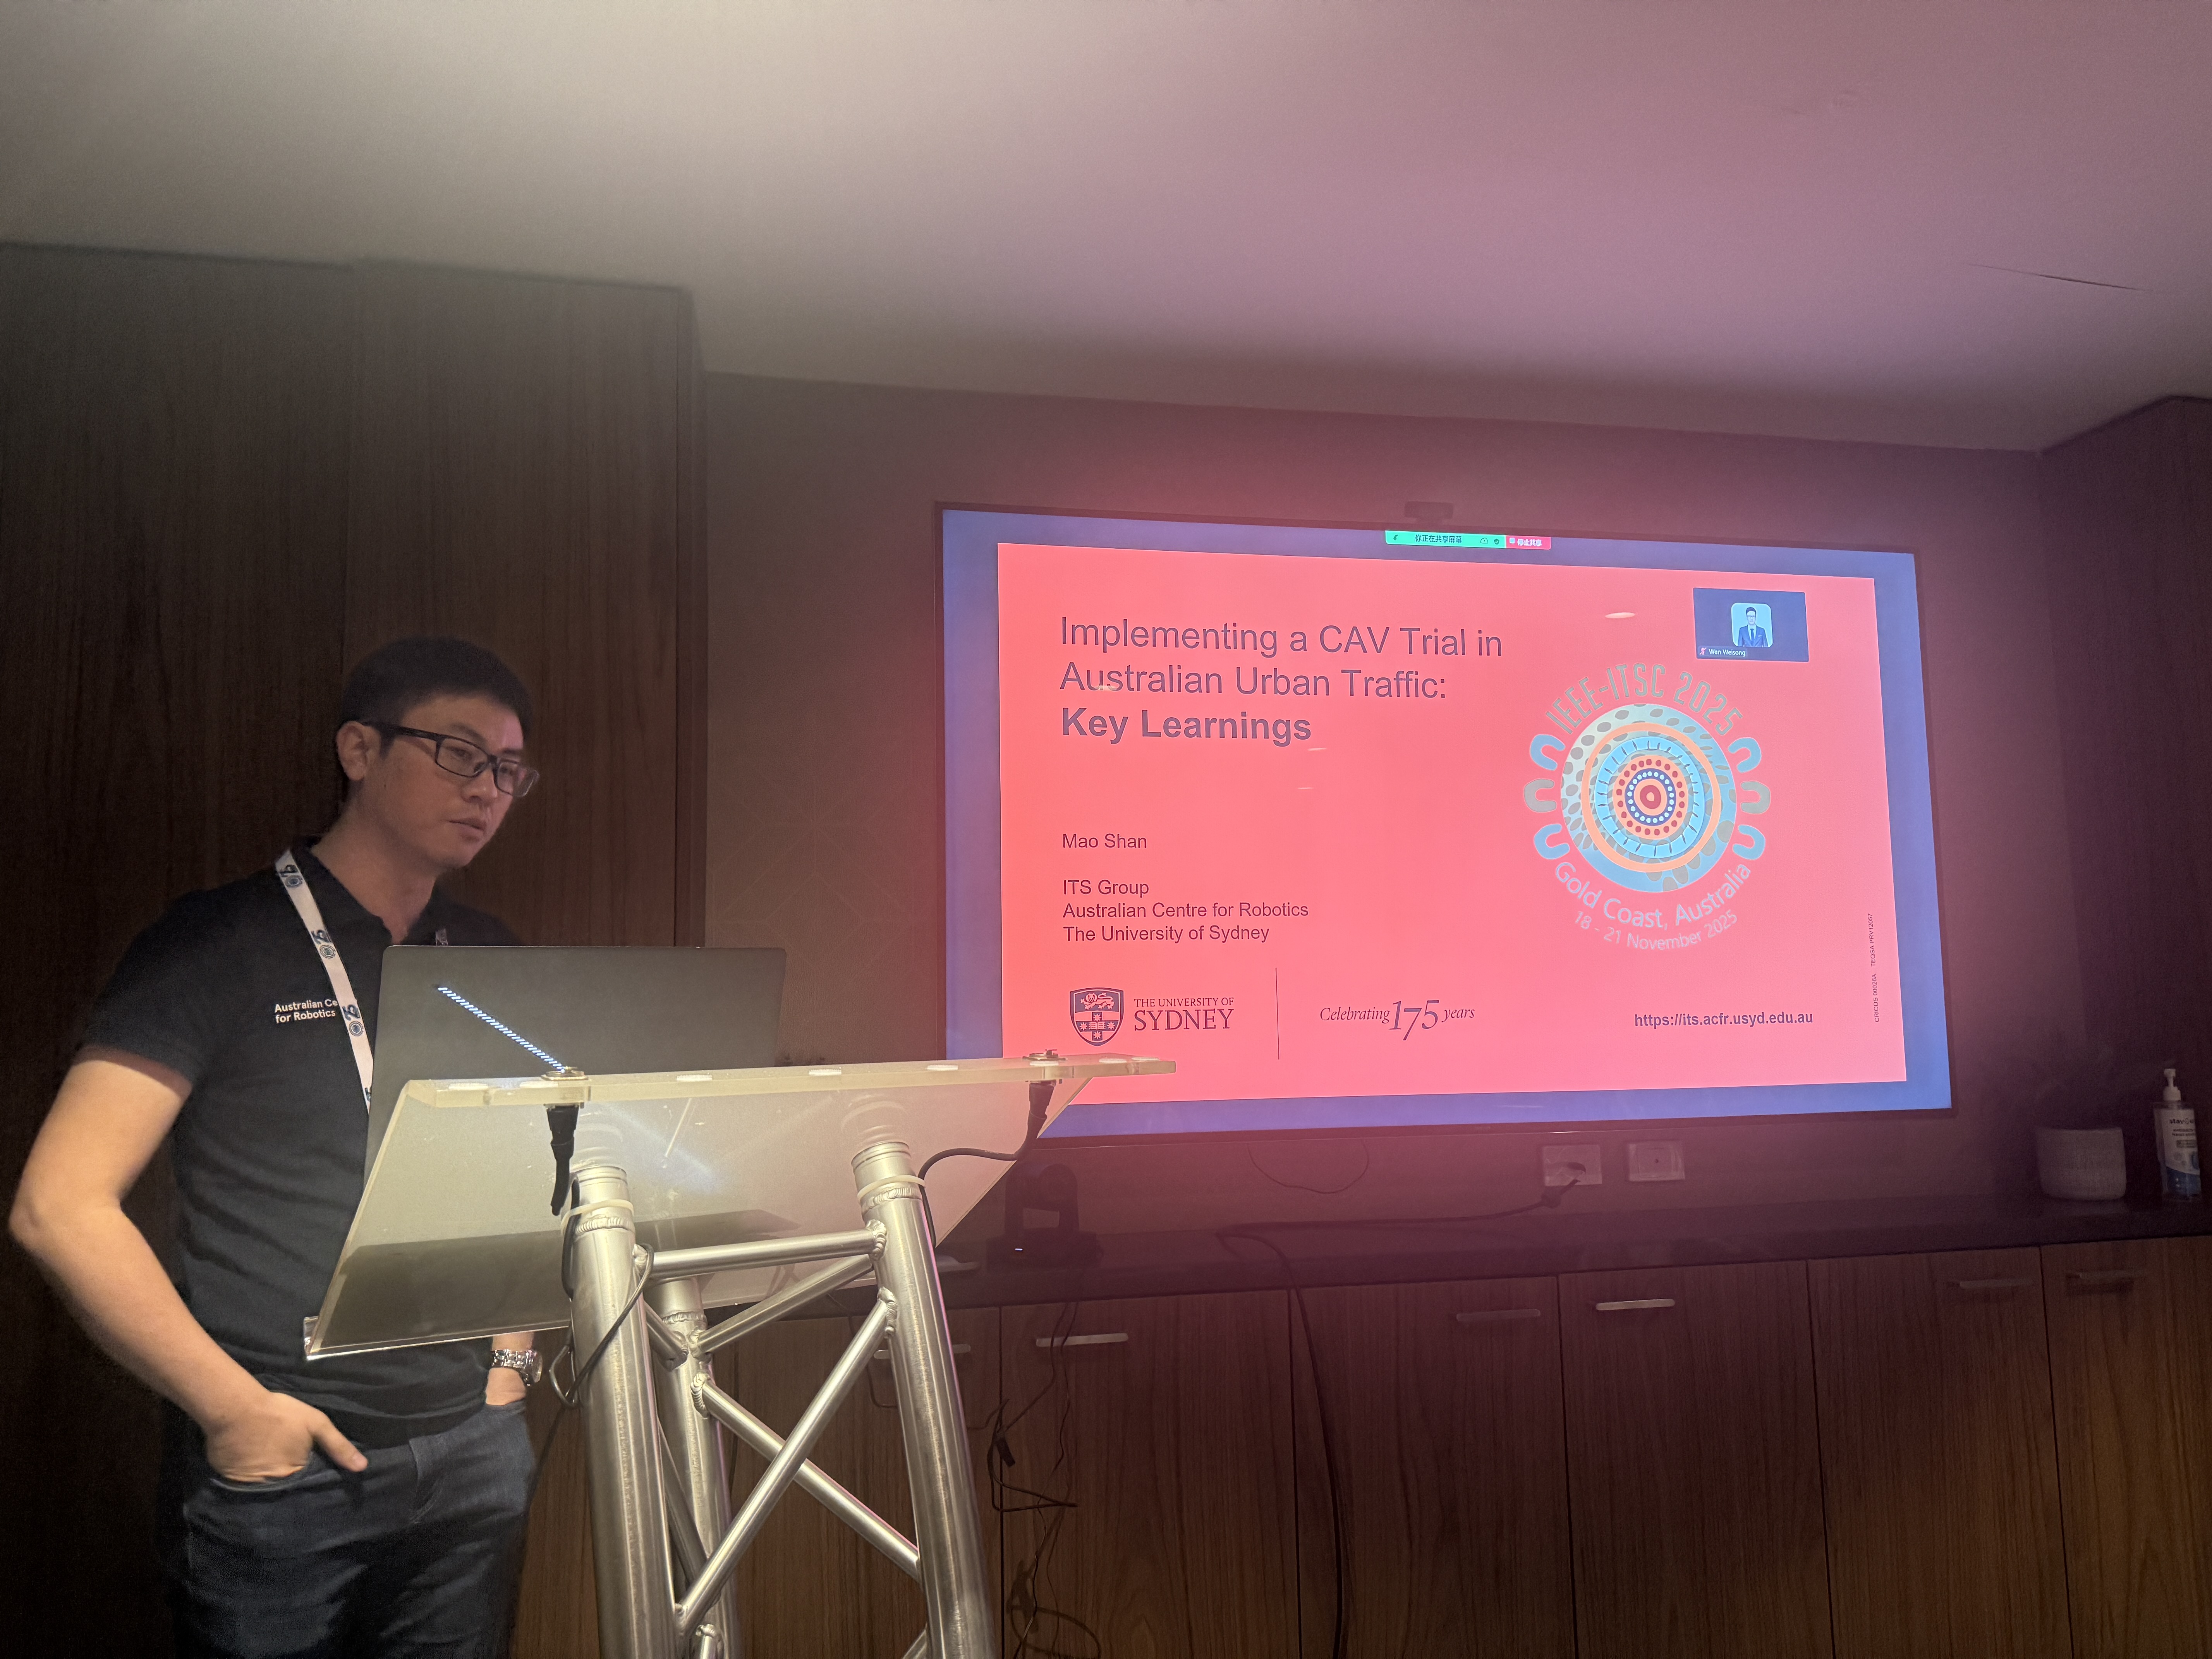
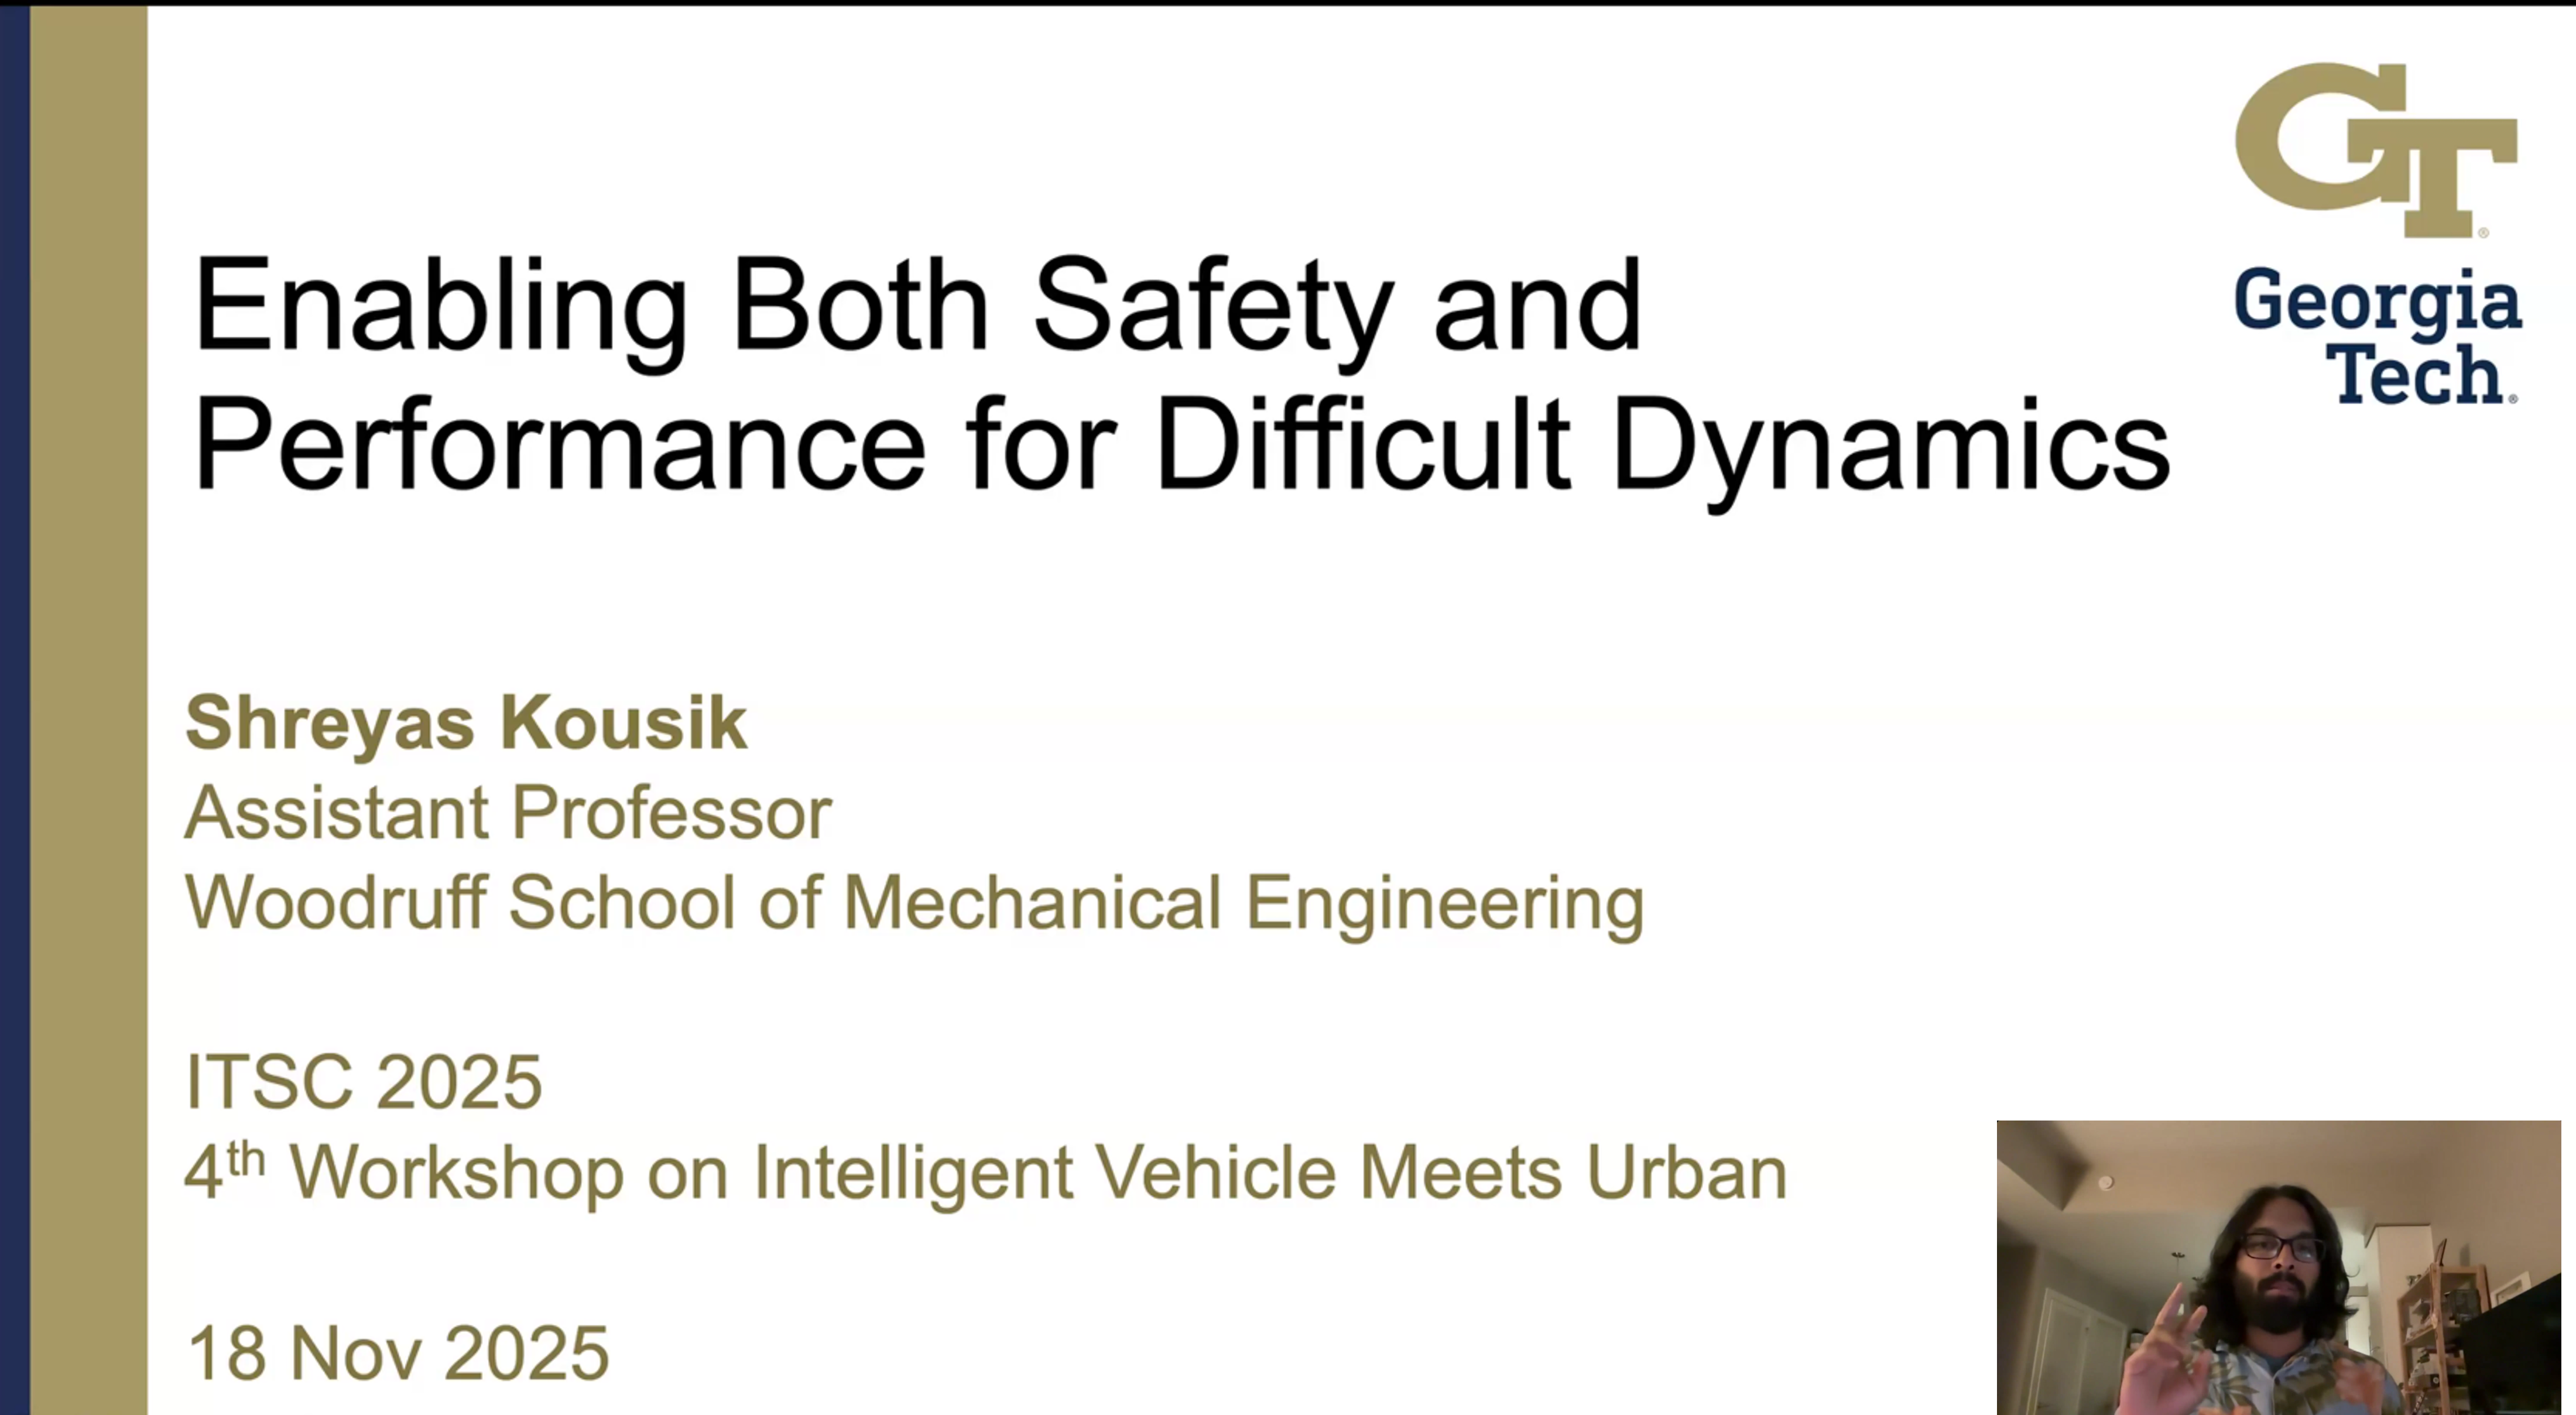
The invited speakers of the workshop.
The talks covered topics ranging from high-precision multi-sensor fusion and radar-based navigation to formal safety methods and LiDAR-centric systems for drones.
Poster session
A highlight of the event was the poster session. Members of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) and Zhenxing Ming from the University of Sydney presented their latest findings on next-generation intelligent vehicles, covering robust localisation, V2X data fusion and integrity monitoring for autonomous navigation.
The workshop fostered collaboration and set new directions for research in safe and certifiable autonomous systems. The organising committee thanks all invited speakers, poster presenters and attendees for their active participation.
For the detailed schedule, invited speaker abstracts and information on accepted posters and videos, please visit the official workshop page: 4th Workshop on IV meets Urban.