On 14 December 2025, the research team of the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU) took part in the inaugural “Hong Kong Polytechnic University Technology Transfer Conference & Inaugural Annual Exchange Meeting of the Institute for Technological Innovation (2025)” in Jinjiang City, Fujian Province, China. The event drew over 3,500 participants from government, academia and industry, and focused on advancing industry-academia-research integration and fostering an innovation ecosystem.
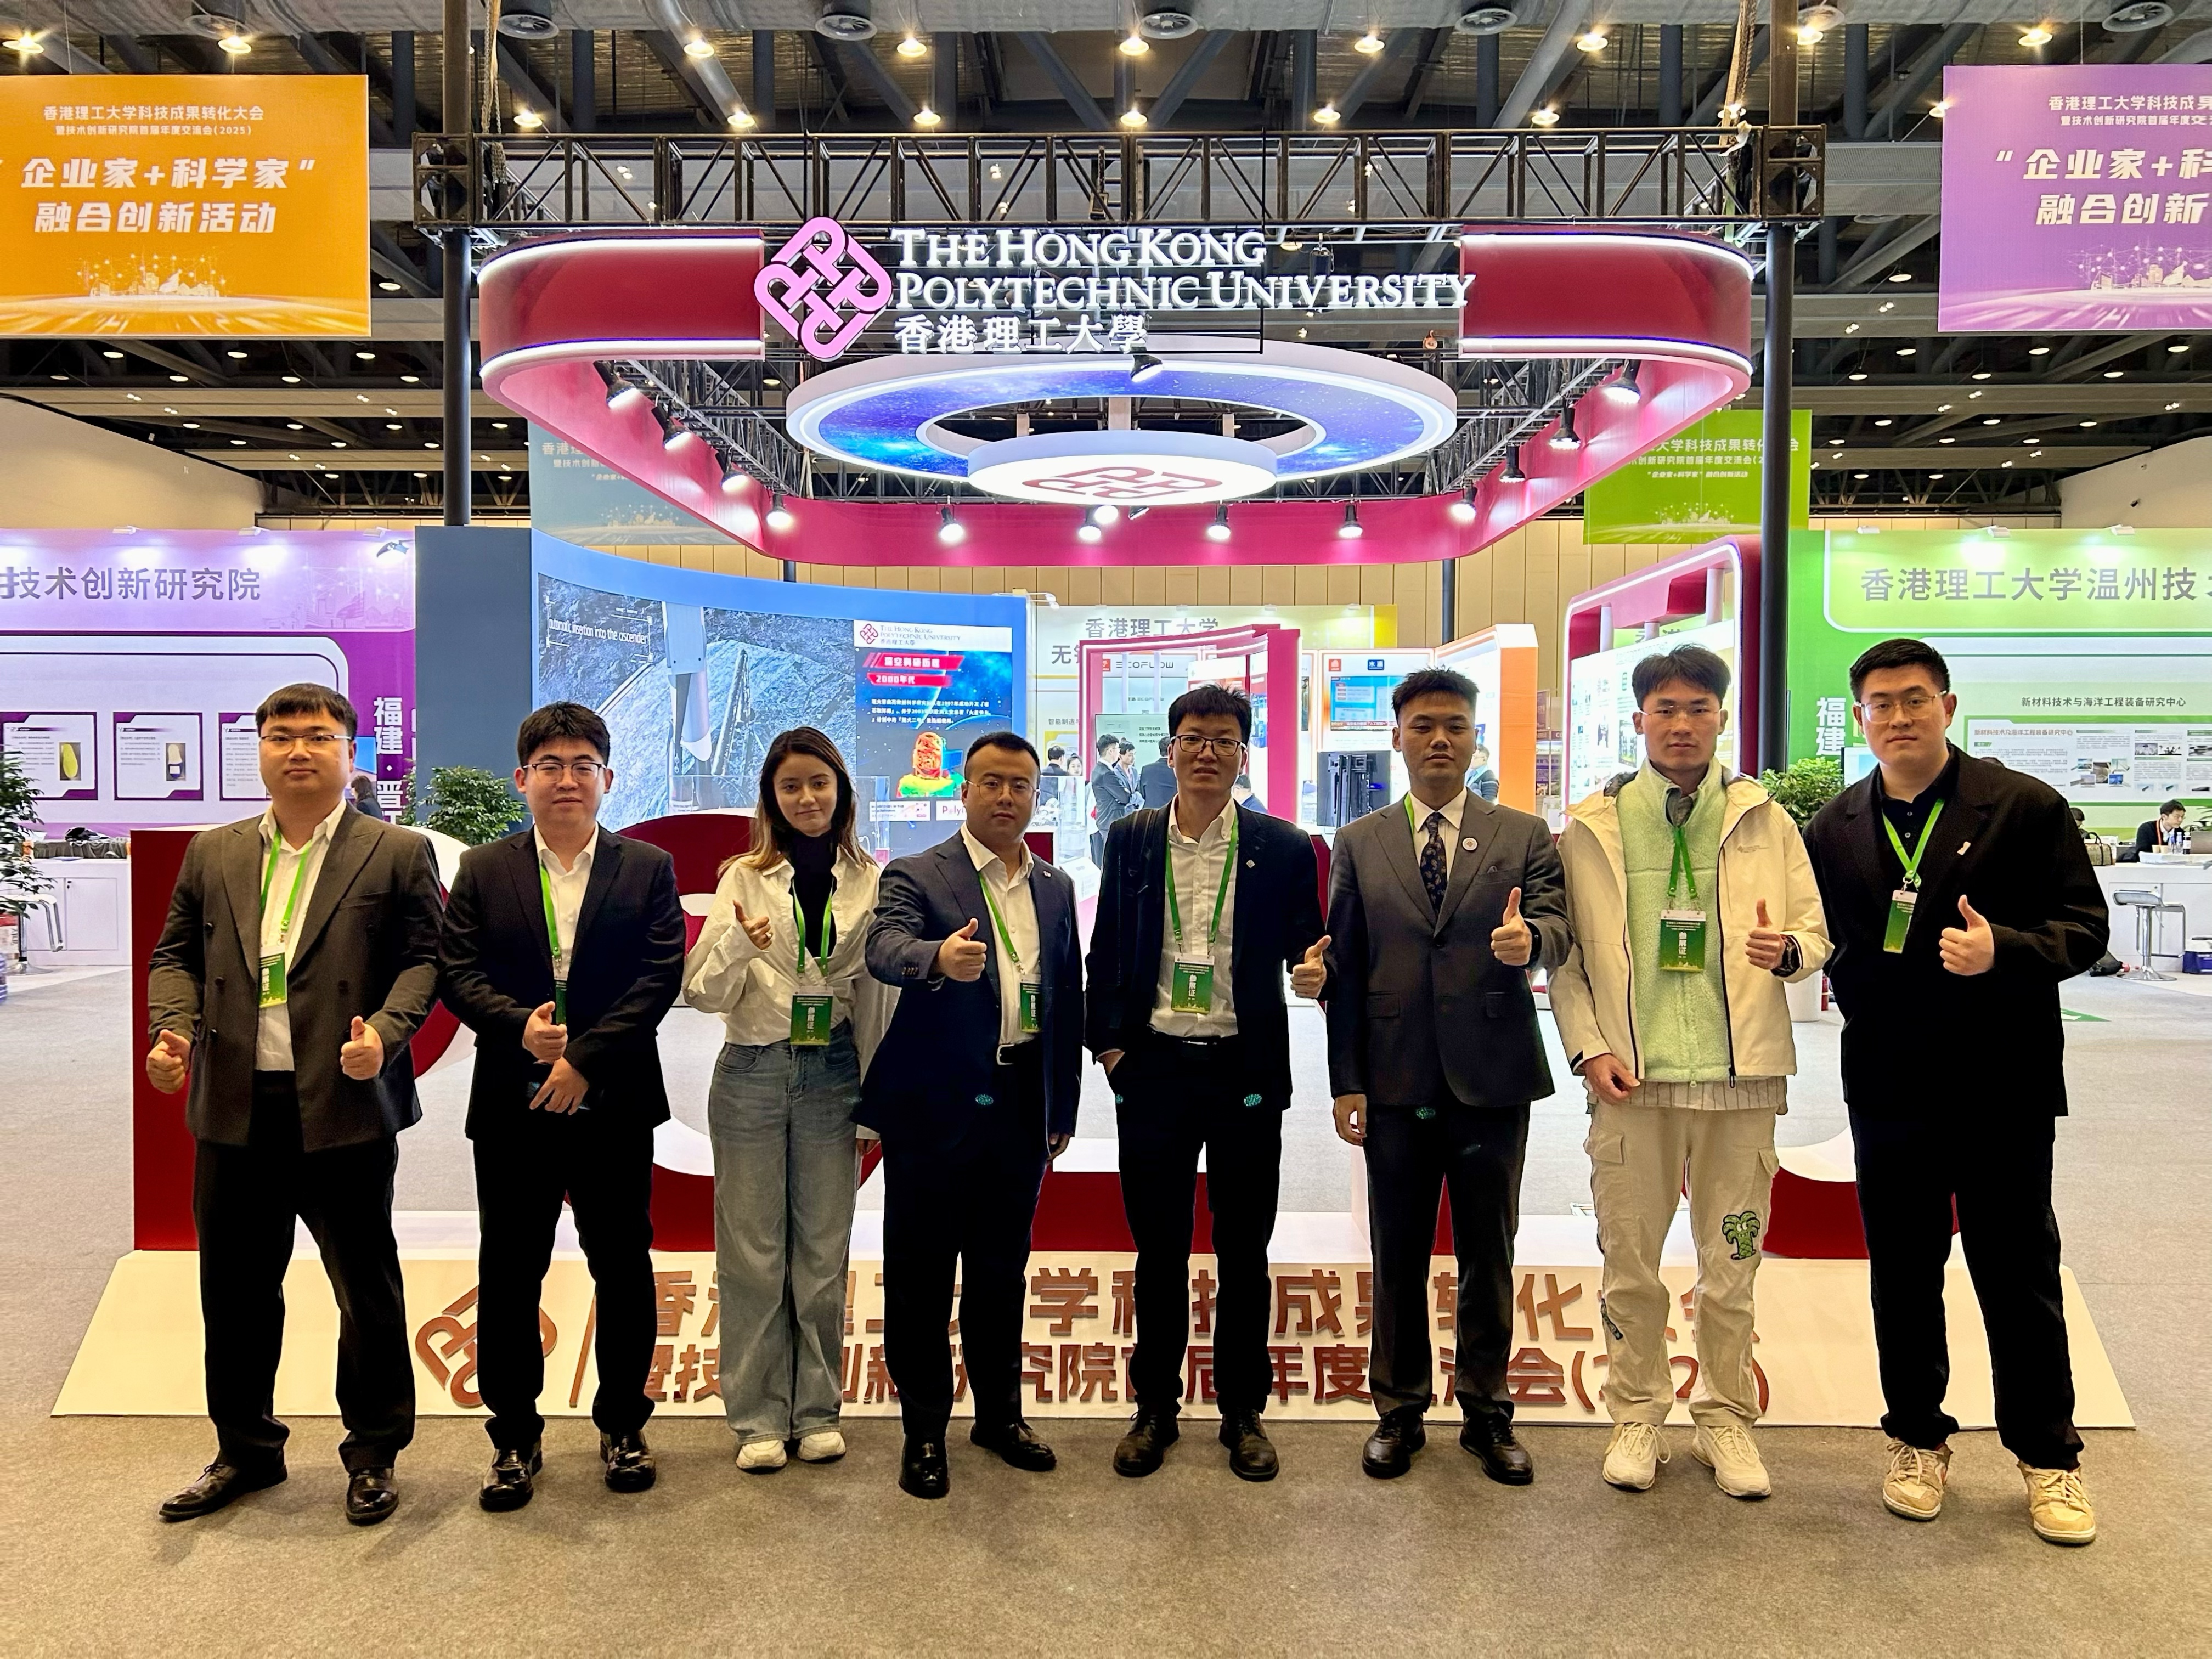
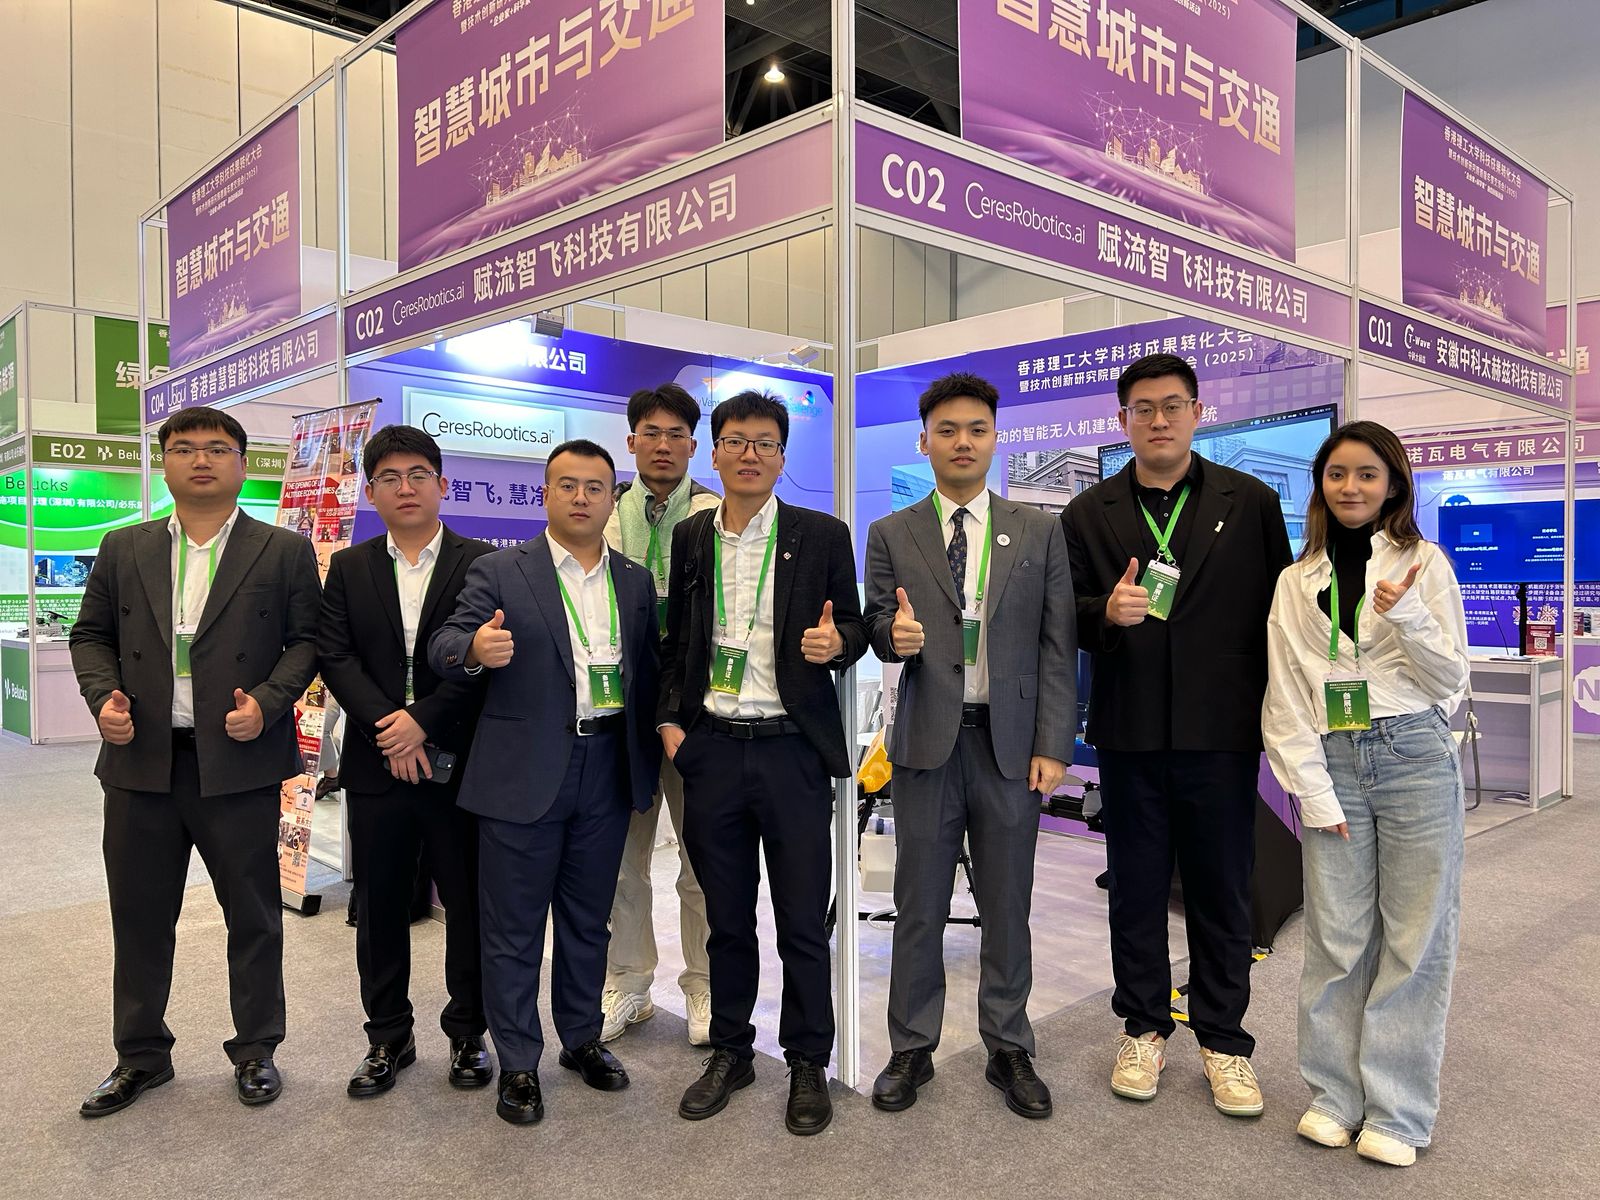
The TASLAB team at the PolyU Technology Transfer Conference in Jinjiang.
Reflecting PolyU’s commitment to turning research into real-world applications, the TASLAB team showcased its latest outputs in robotics and sensing technologies. Highlights included unmanned aerial vehicles (UAVs) for building window cleaning, quadruped robots designed for inspection and logistics, ultra-wideband (UWB) modules for precise positioning, and LiDAR scanners for high-resolution 3D environmental modeling. The demonstrations attracted keen interest from investors and professionals, underscoring PolyU’s role in driving national innovation strategies.
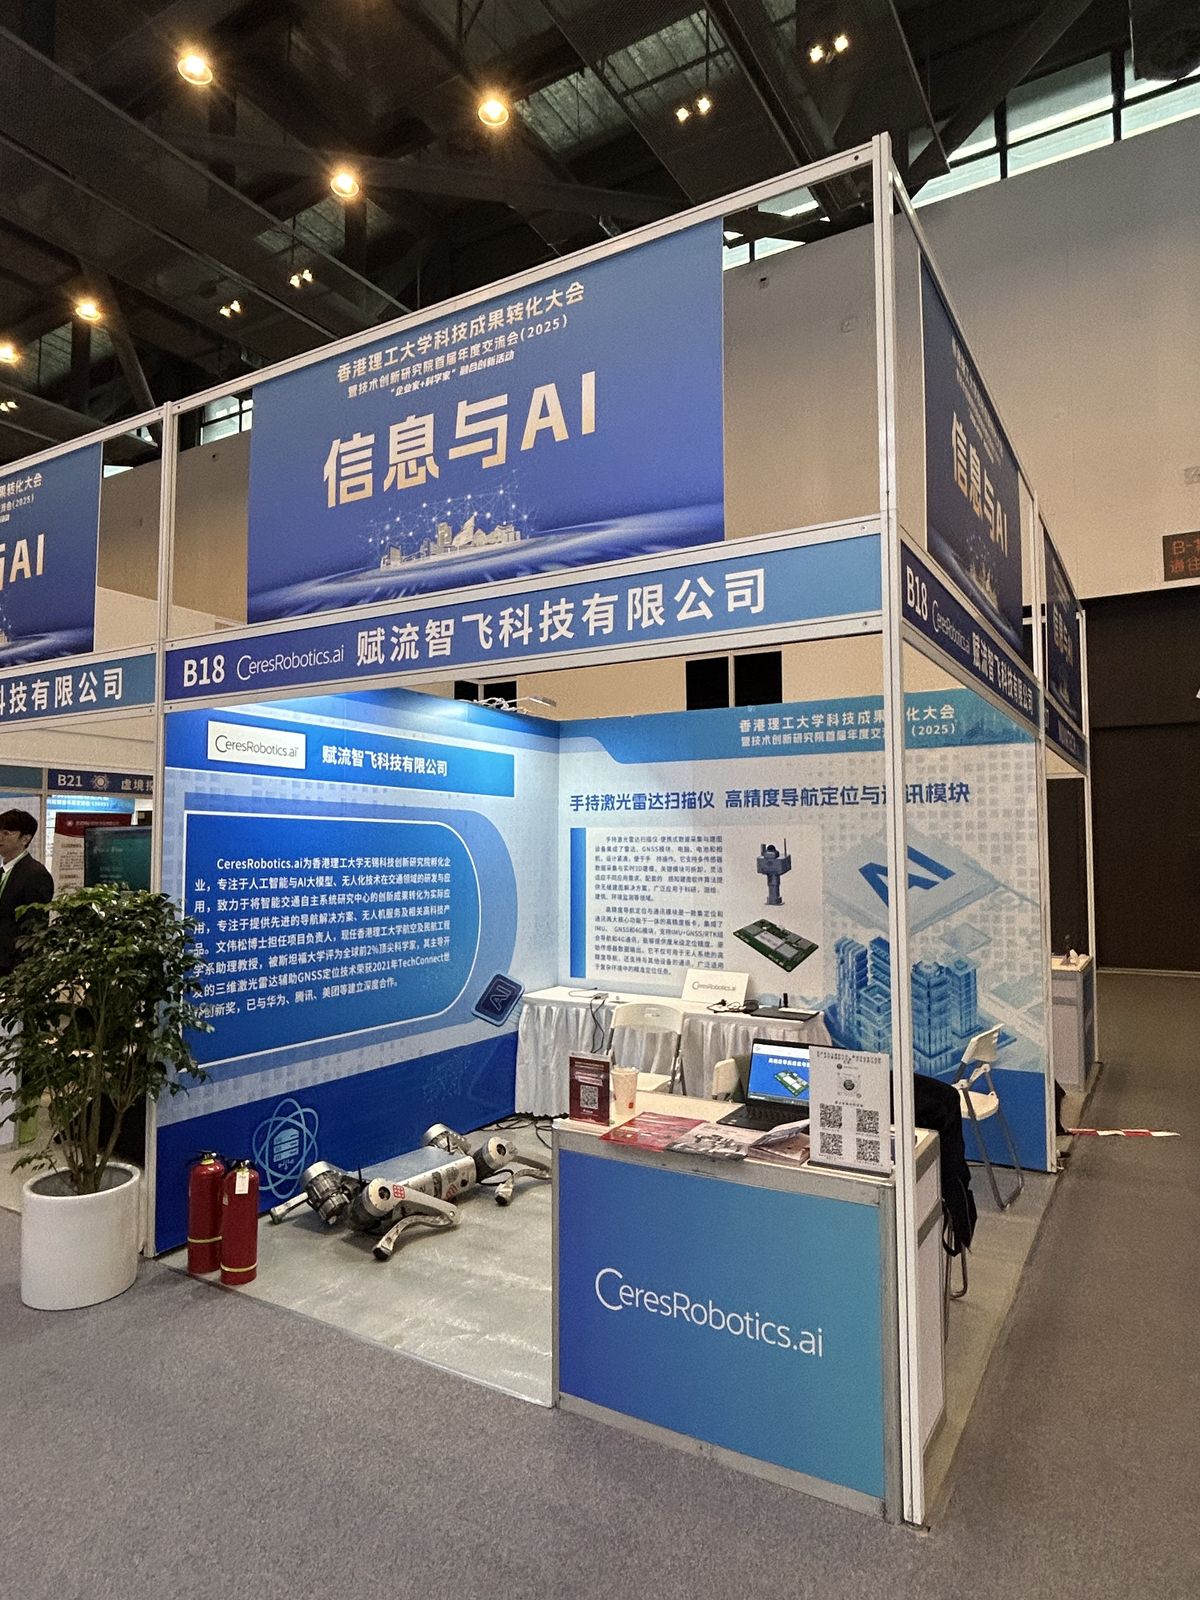
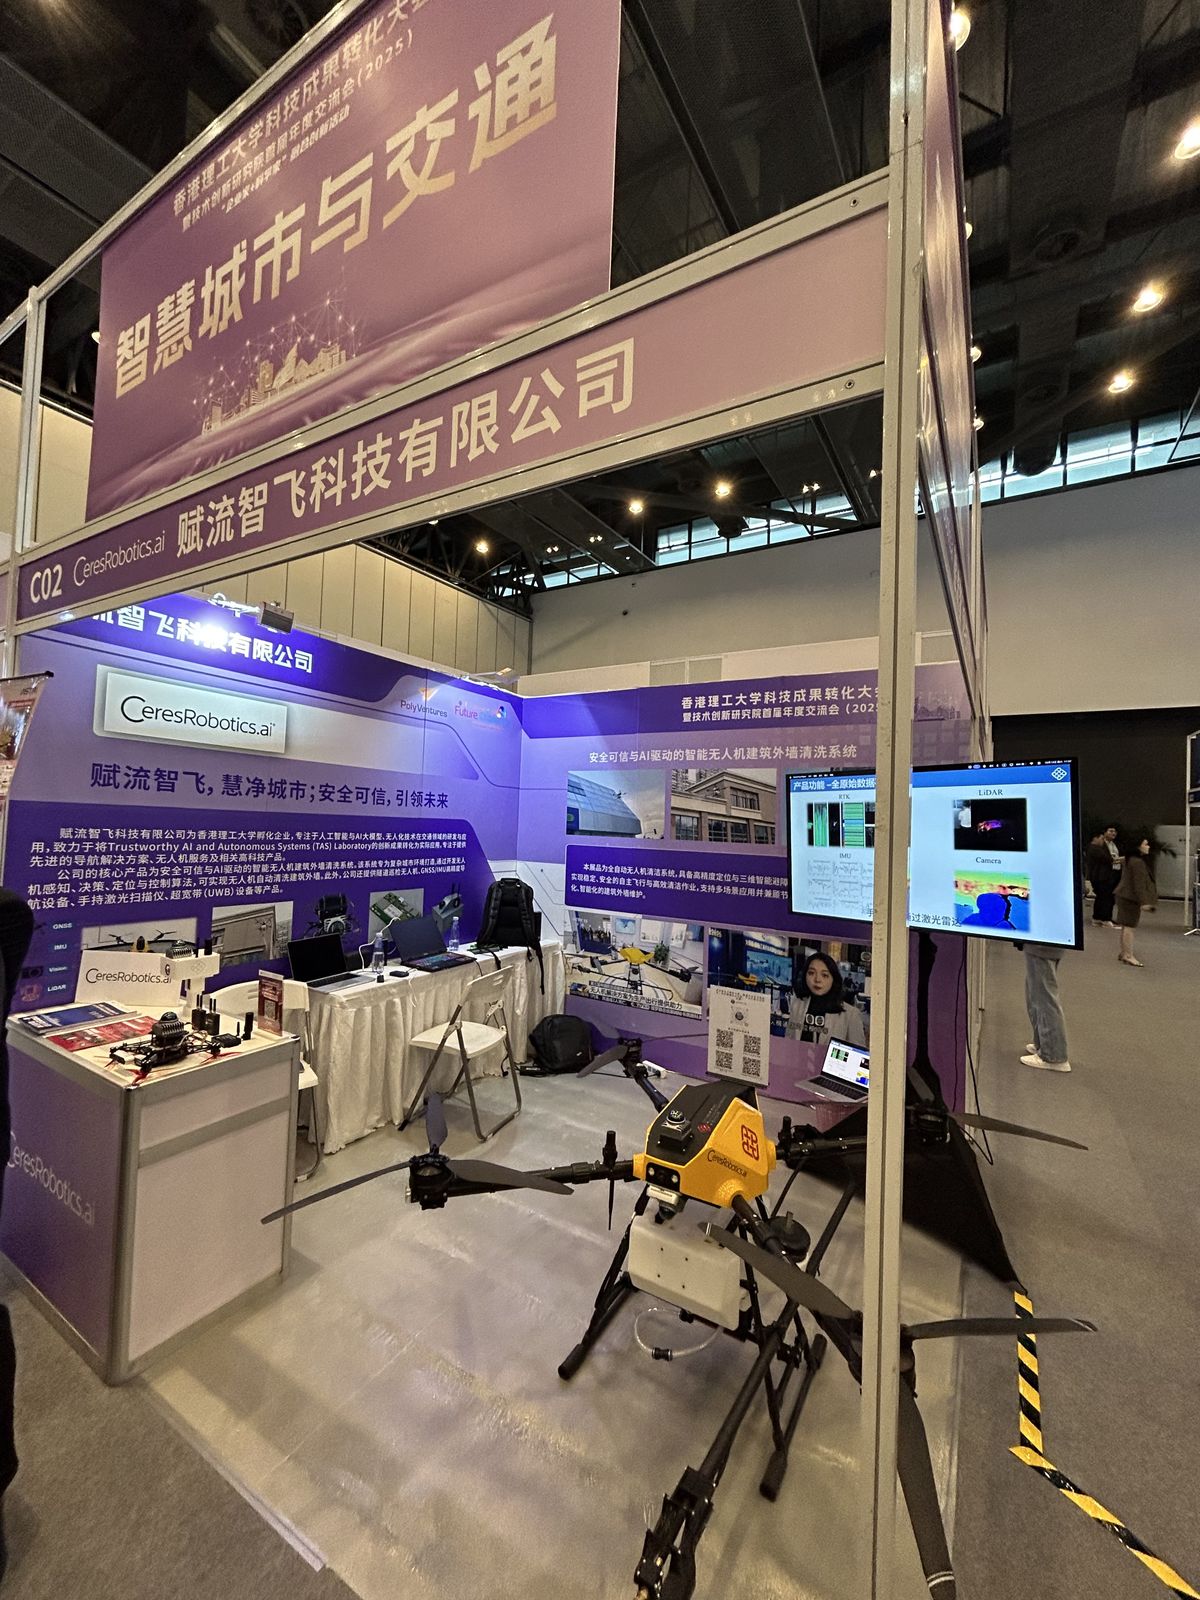
The exhibition booths with the quadruped robots, positioning modules and window-cleaning UAV.
As PolyU President Professor Teng Jinchao emphasised, the conference marks a milestone in converting laboratory breakthroughs into market-ready products, and TASLAB’s contributions exemplify this vision.
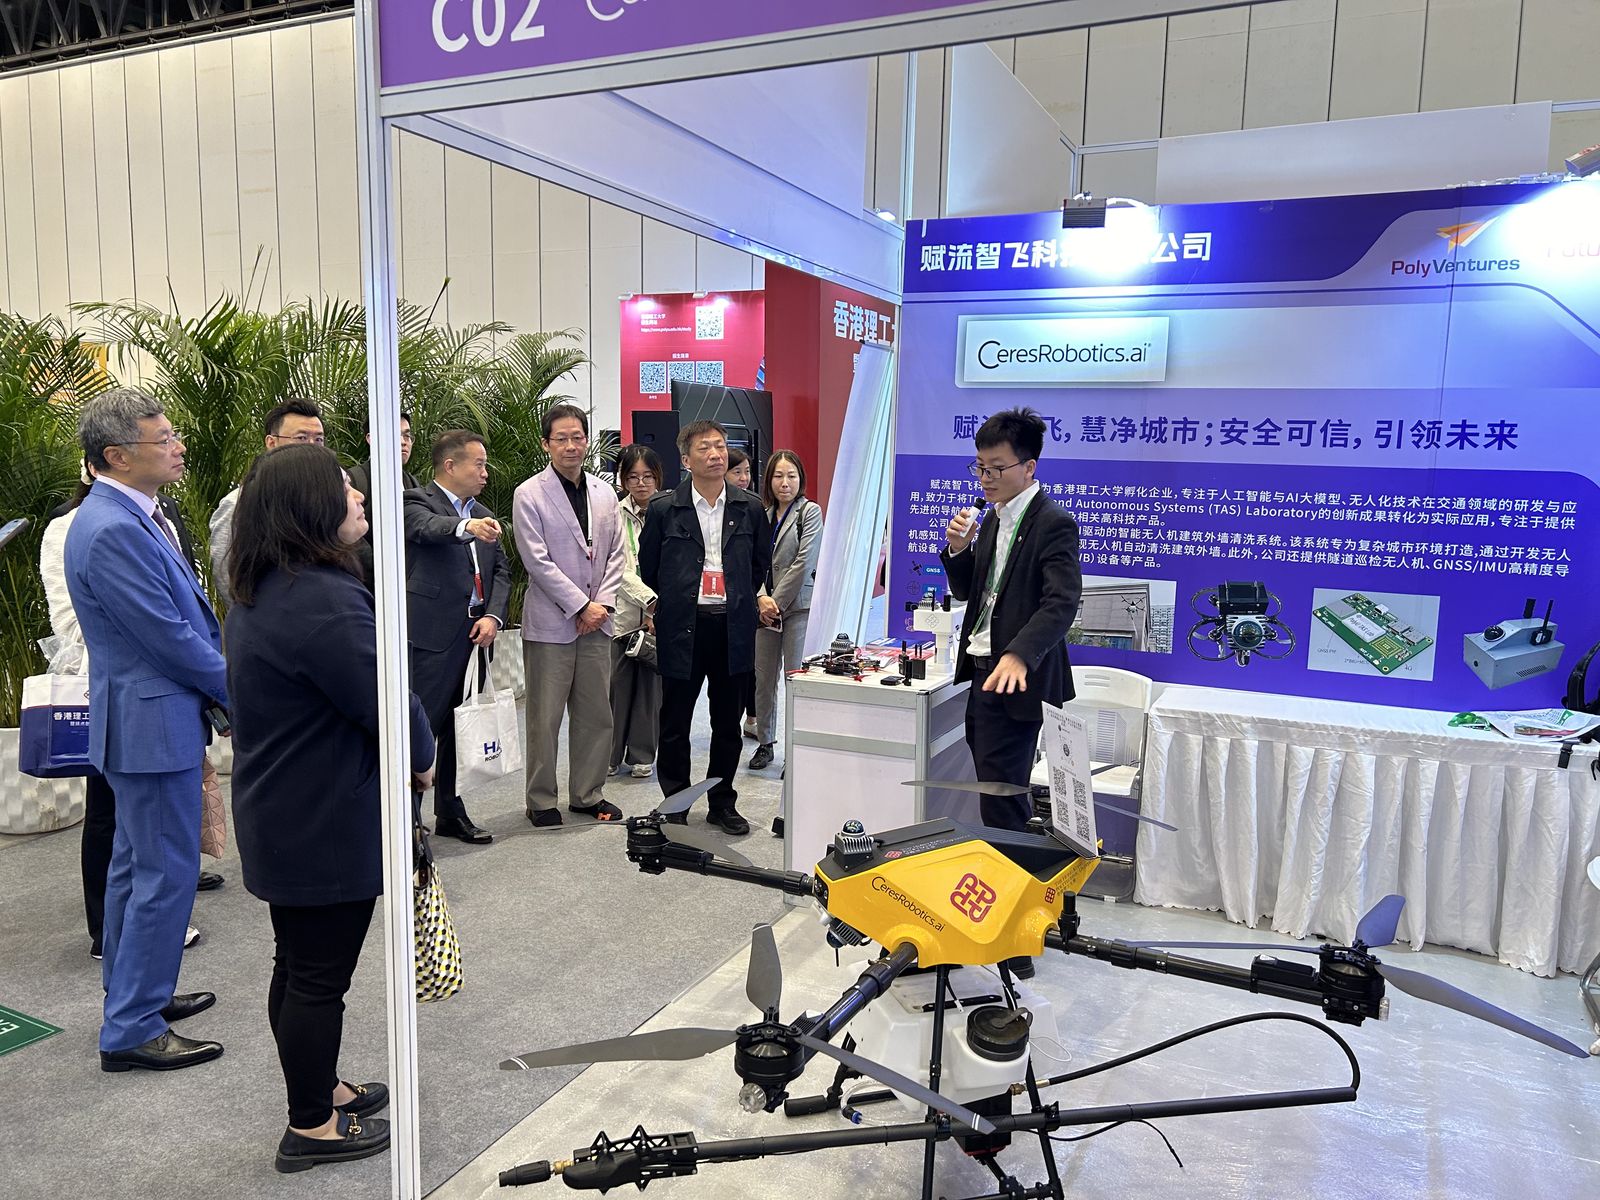
Introducing the window-cleaning UAV to visitors at the booth.