On 25 September 2026, TASLAB student CHENG Yuling successfully completed her MPhil oral defense at The Hong Kong Polytechnic University. Her thesis, supervised by Prof. Weisong Wen, is titled Multimodal Perception-Driven Semantic Traversability Mapping and Path Planning for Quadruped Robots.
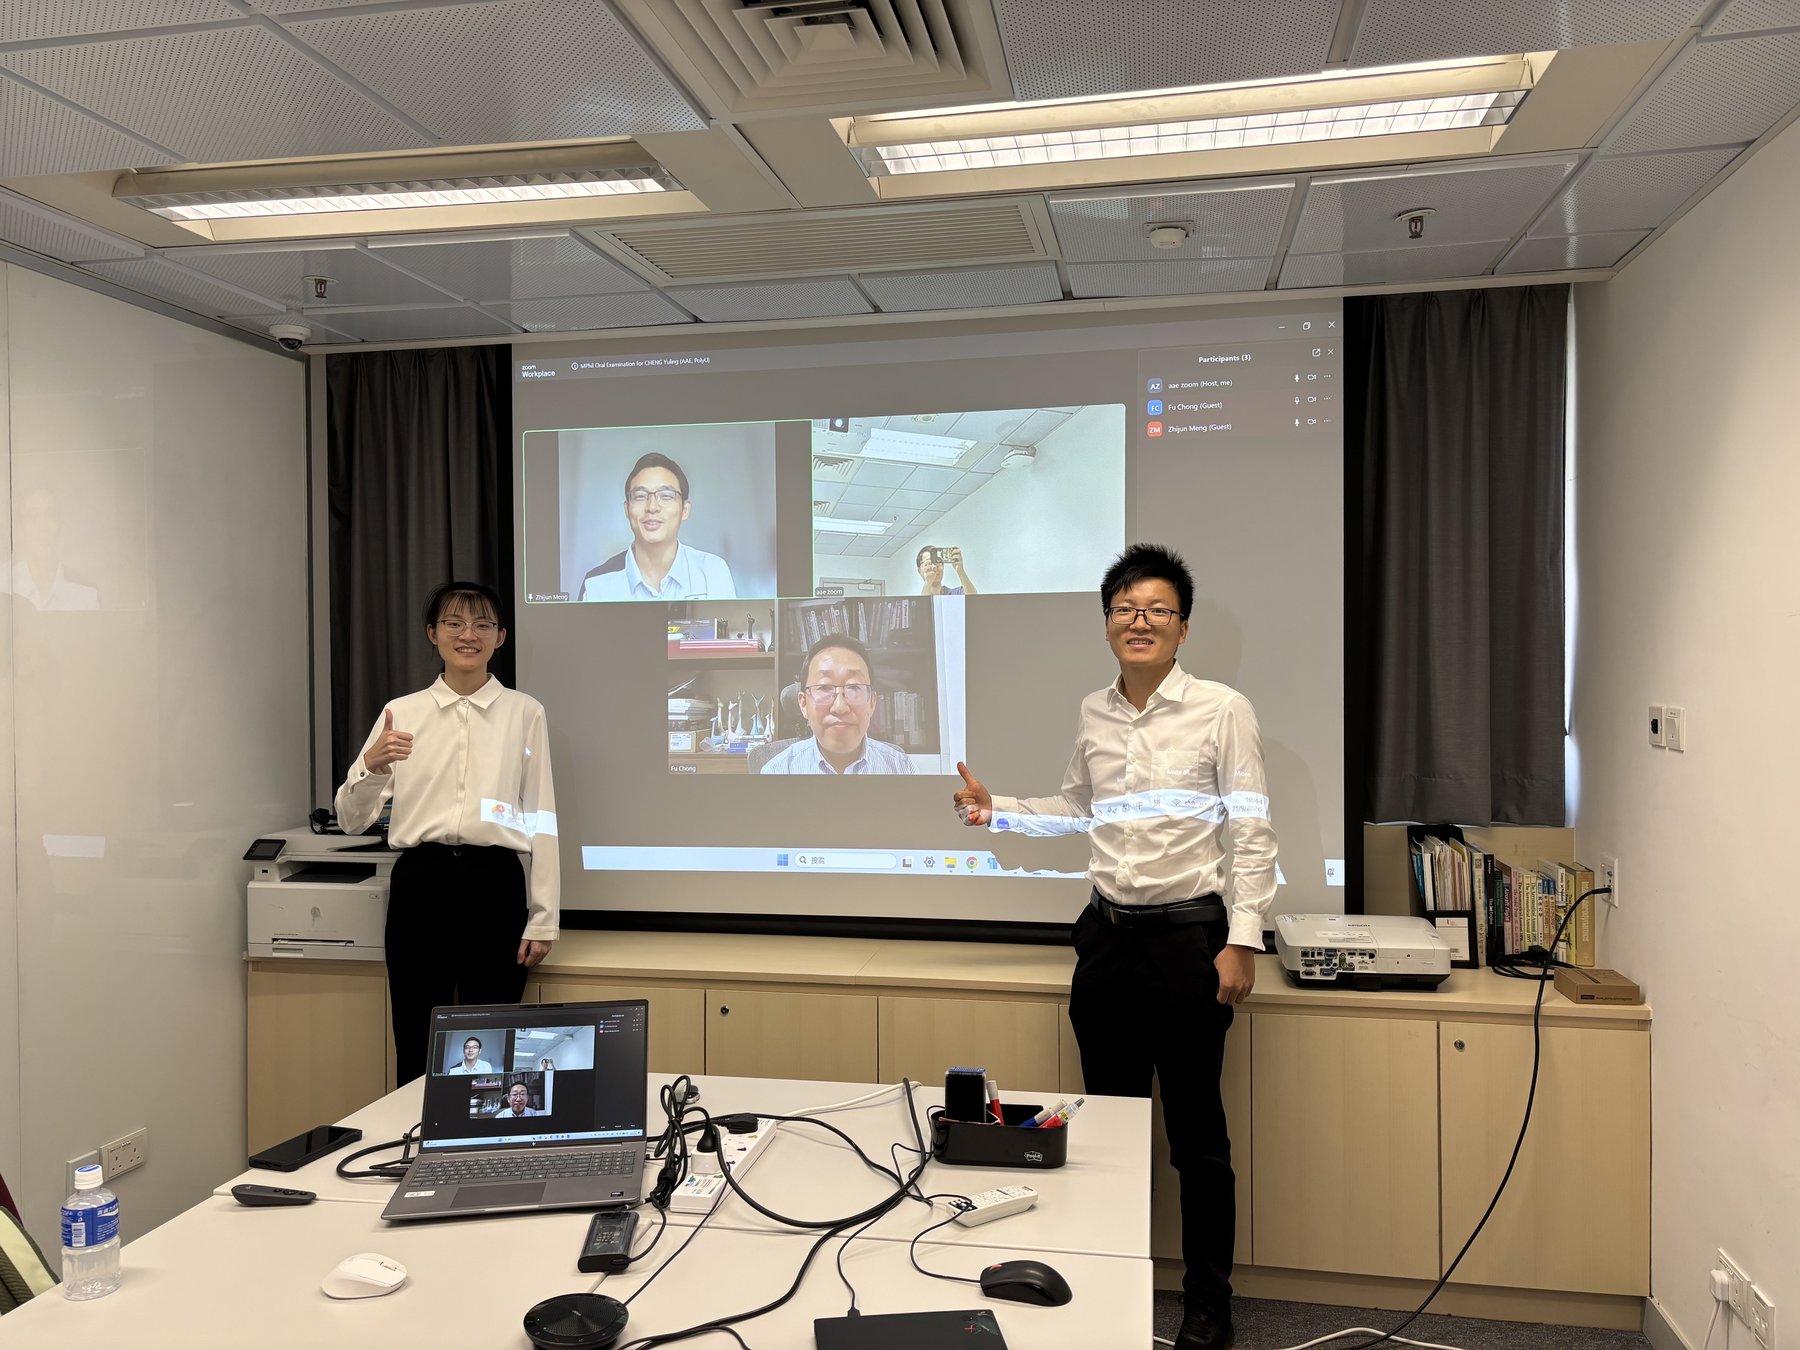
CHENG Yuling and Prof. Weisong Wen following the MPhil oral defense, with members of the Board of Examiners joining remotely.
Her research develops a semantic traversability mapping and path-planning framework for quadruped robots operating in complex outdoor environments. The framework integrates LiDAR-based occupancy mapping, camera-based semantic segmentation and semantic-aware A* path planning. By distinguishing terrain types—including concrete pavement, gravel, tactile paving, stairs and grass—it enables a robot to consider both geometric obstacles and terrain-specific traversal costs when planning a route.
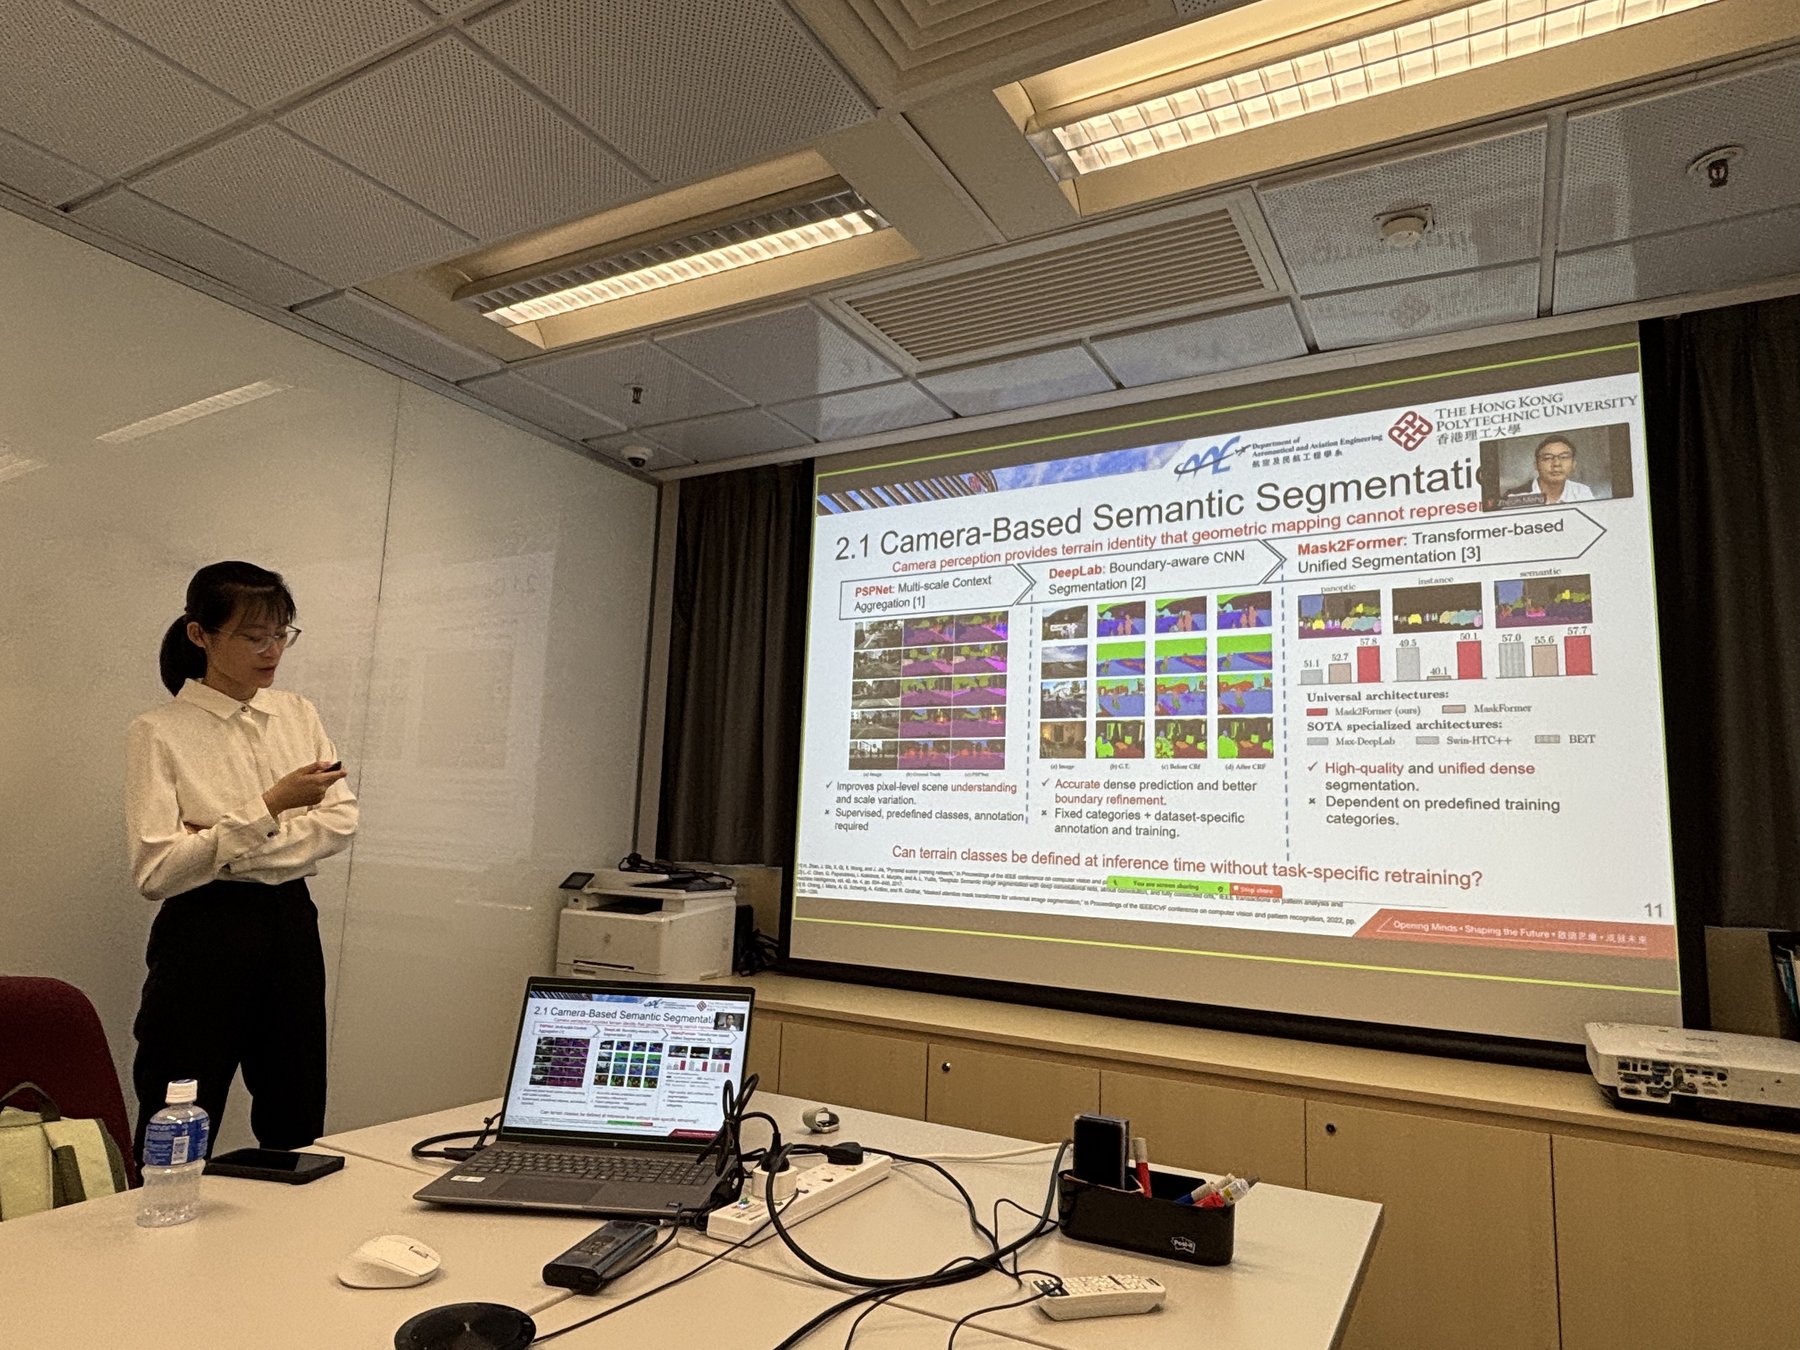
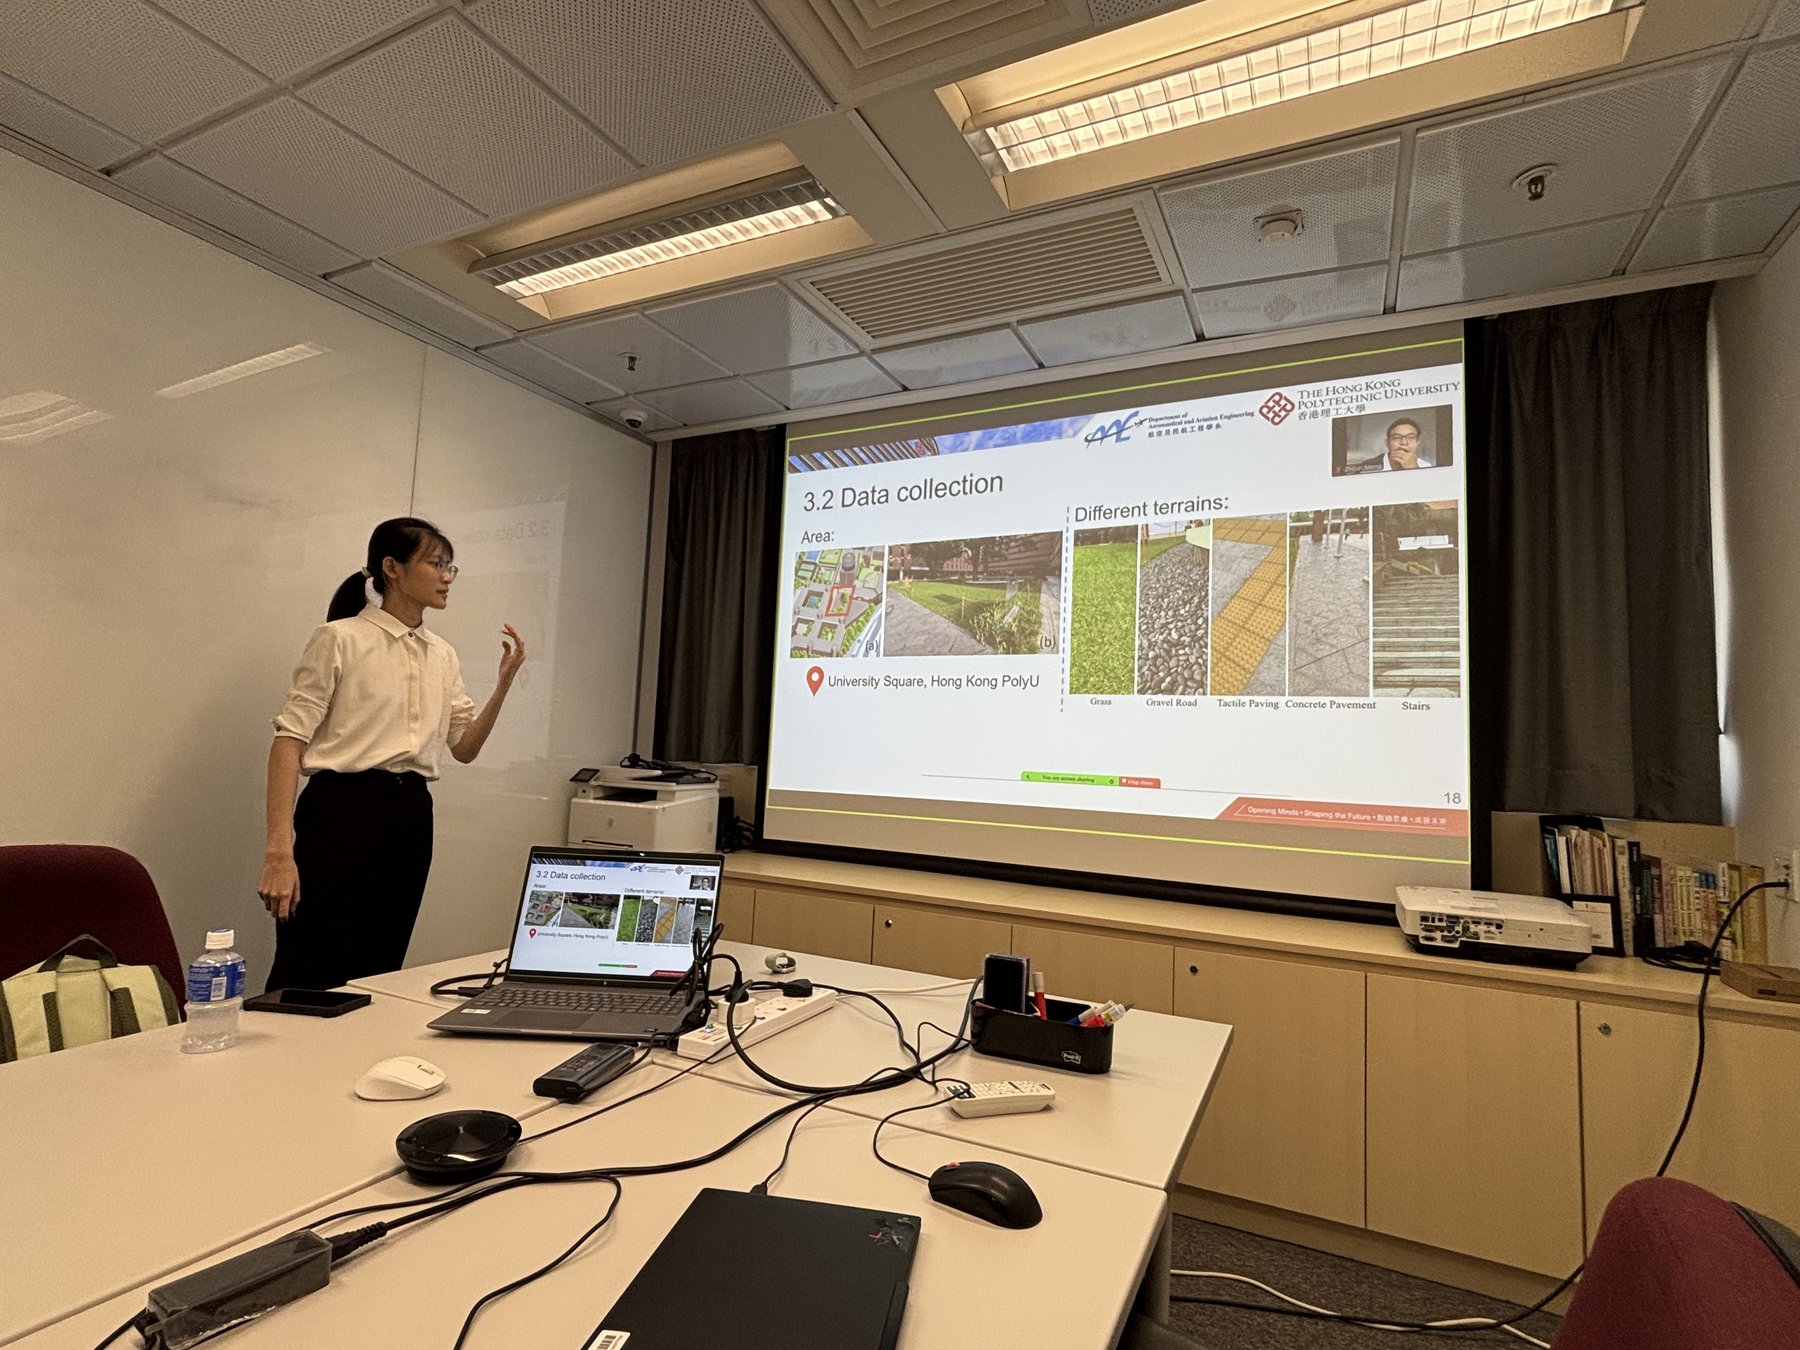
The framework was evaluated with real sensor data collected using a Unitree Go2 EDU quadruped robot in multiple outdoor scenarios. The results demonstrate how fused geometric and semantic information can support safer, terrain-aware navigation in unstructured environments.
Following the defense, Yuling completed the revisions requested by the Board of Examiners. TASLAB warmly congratulates her on this important milestone and wishes her continued success in her future studies and career.