On 15 September 2026, a delegation from Mammotion (Shenzhen KUMA Technology Co., Ltd.), a Shenzhen-based developer of intelligent outdoor robotics led by Dr. Chuhao Liu, visited the Trustworthy AI and Autonomous Systems Laboratory (TASLAB) at The Hong Kong Polytechnic University (PolyU). Mammotion is a national-level “little giant” enterprise specializing in smart courtyard robotics. It is known for its LUBA and YUKA series robotic lawn mowers and for the Tri-Fusion positioning system, which fuses LiDAR, RTK and vision on a single navigation platform to deliver centimetre-level localization without boundary wires or additional base stations.
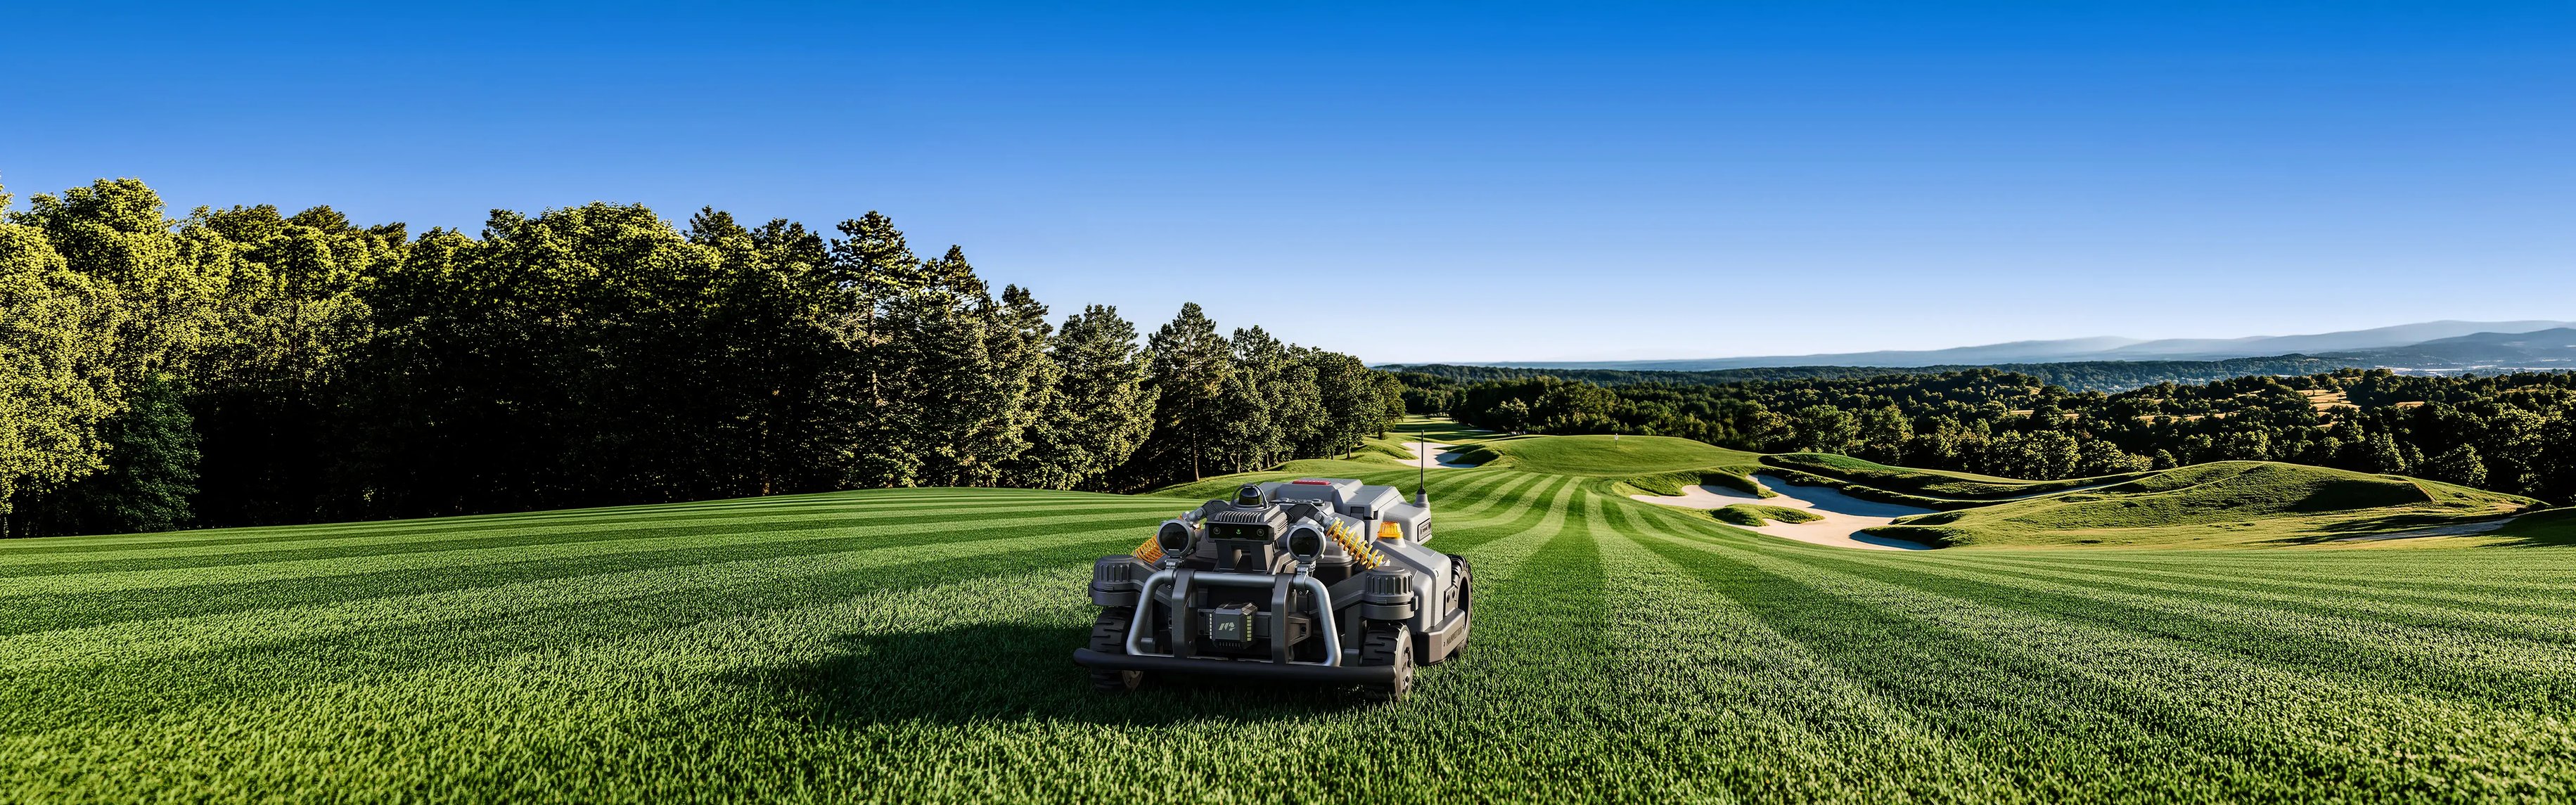
A Mammotion robotic lawn mower at work. Image source: Mammotion official website.
Visit and recruitment event
The delegation was welcomed by Dr. Feng Huang, Mr. Baoshan Song and Mr. Xiangru Wang. Dr. Huang introduced TASLAB’s research environment and ongoing work on trustworthy AI and autonomous systems. The visit also included a recruitment event at PolyU, where Mammotion presented its technology roadmap and career opportunities to PolyU students and researchers.
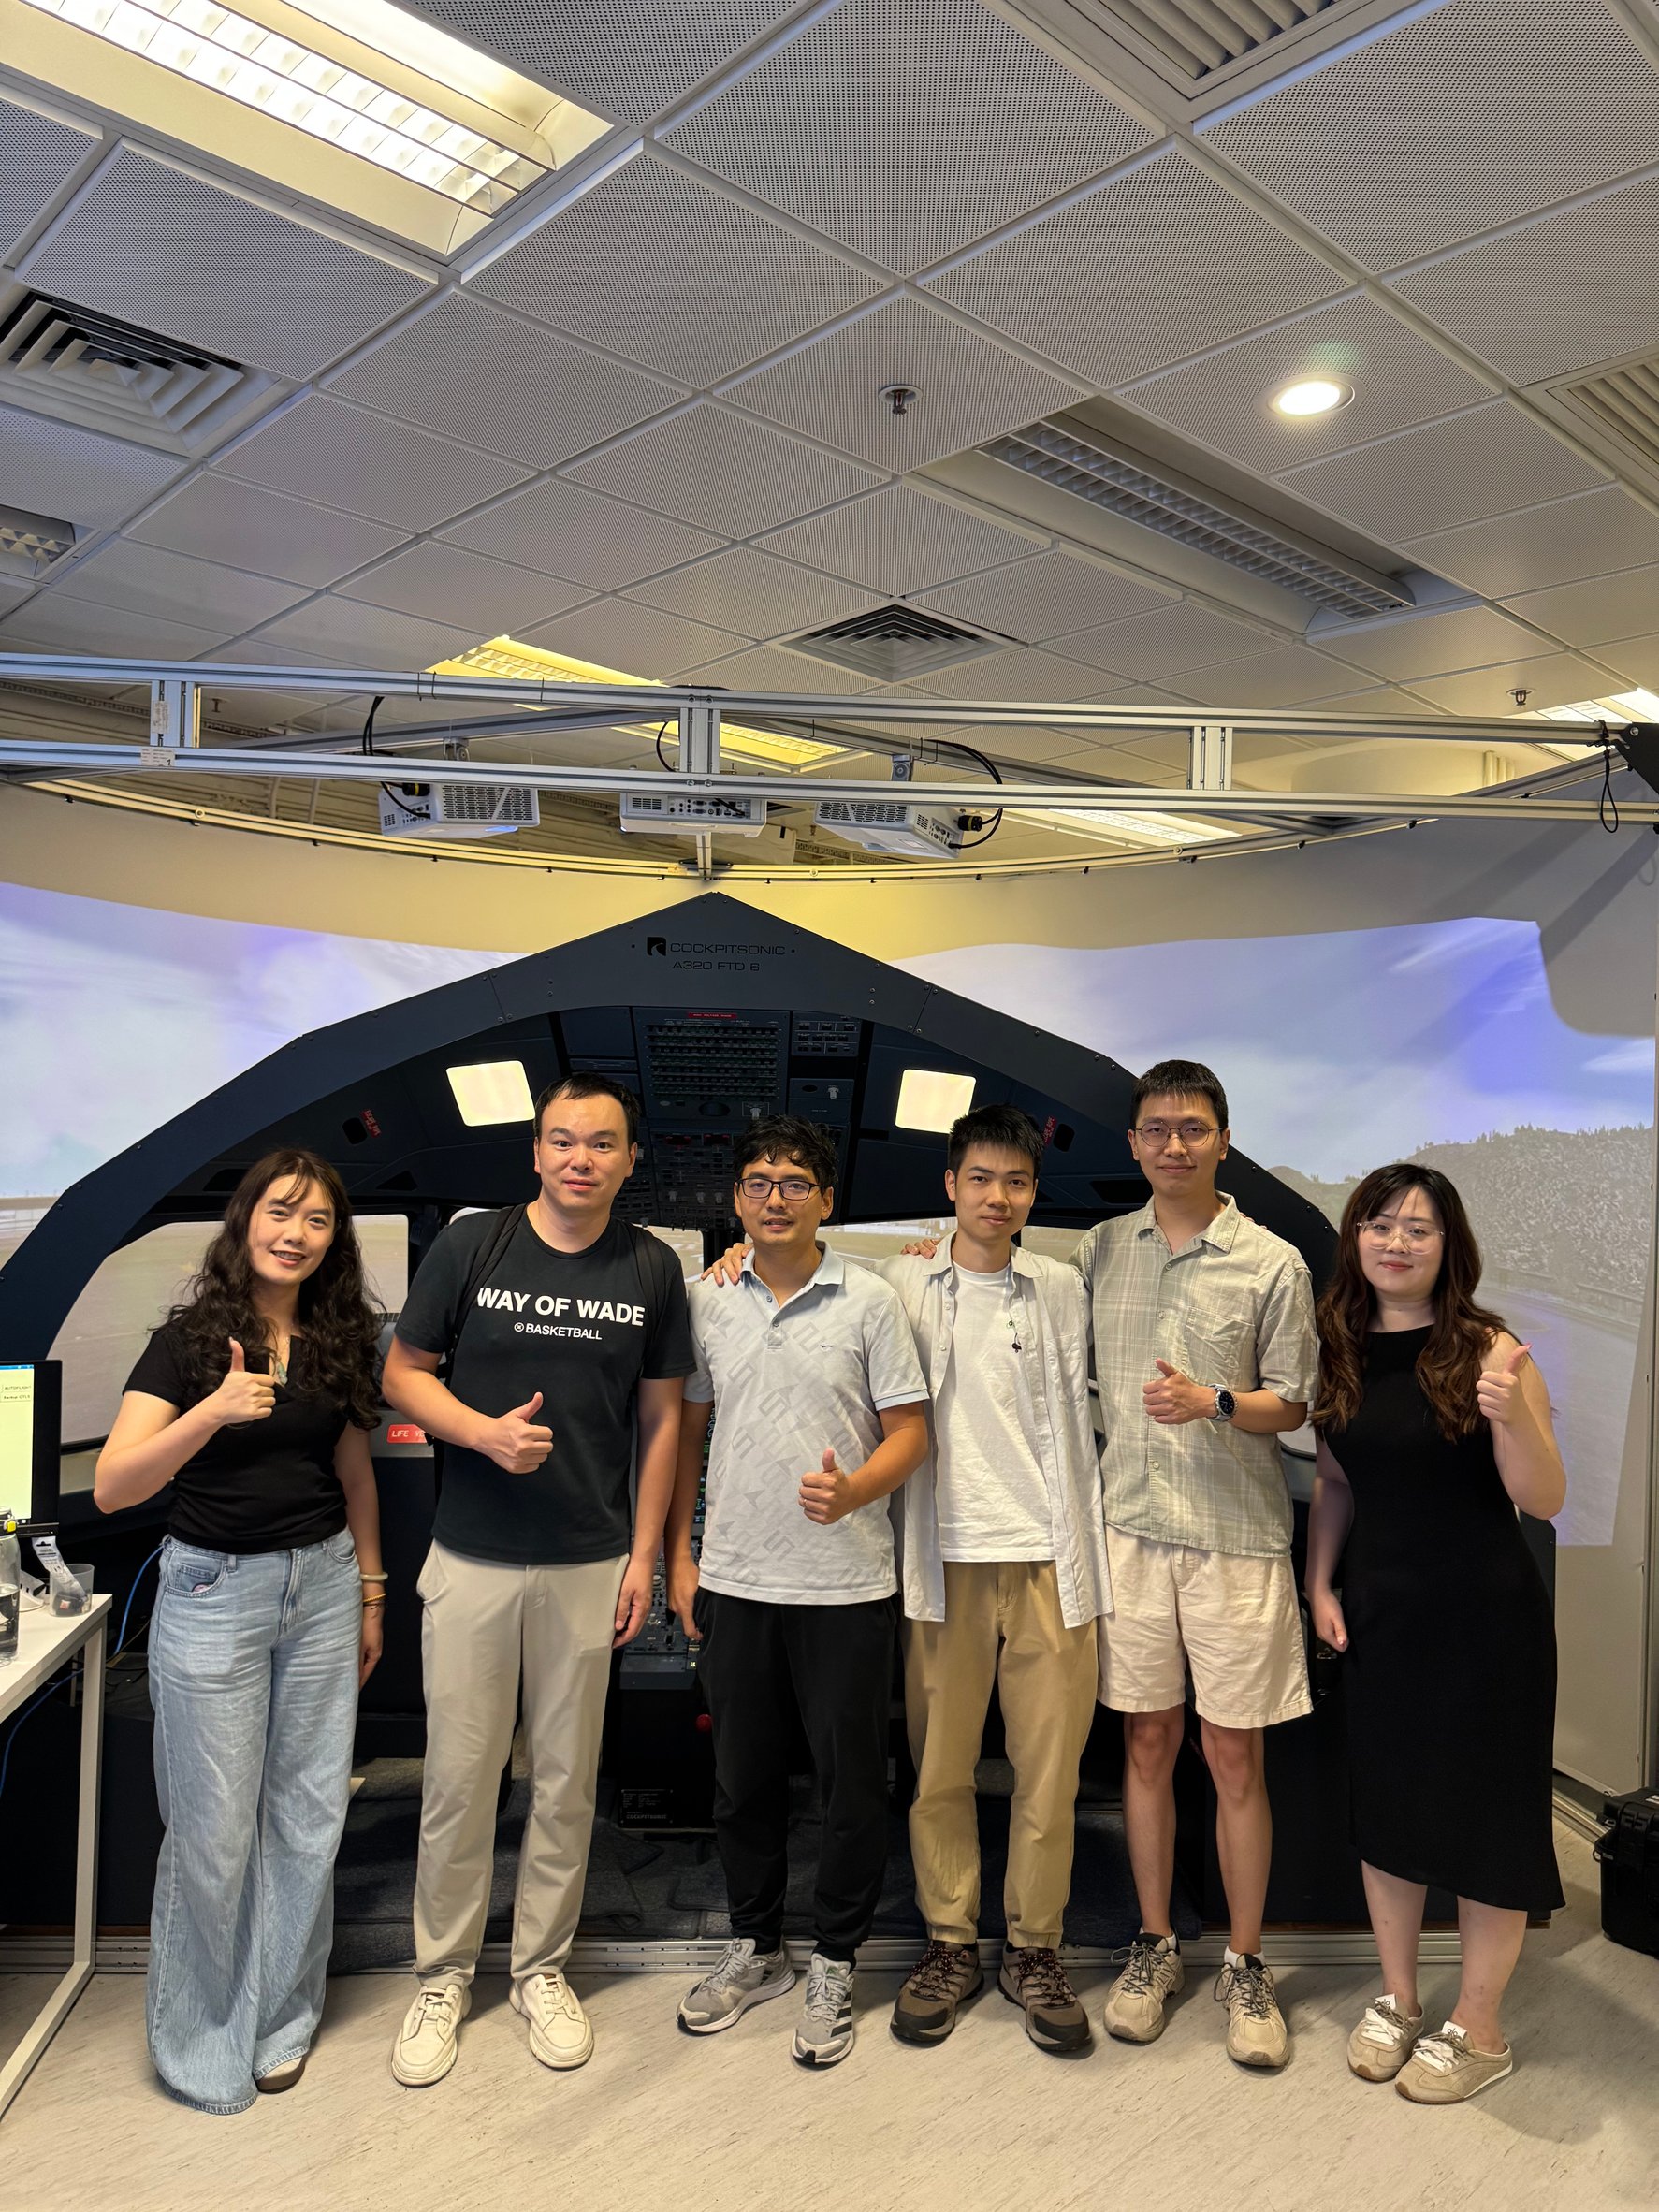
The Mammotion delegation with TASLAB members at PolyU.
Technical exchange
During the technical exchange, both sides discussed multi-sensor fusion and back-end optimization, including how LiDAR, RTK/GNSS and vision measurements can be tightly integrated within a factor-graph optimization framework to achieve robust and continuous localization in challenging environments. The discussion also covered perception for outdoor robotic platforms, reliable navigation under GNSS-degraded conditions, and the engineering challenges of deploying these algorithms on mass-produced products.
The visit strengthened the connection between TASLAB and Mammotion, and both sides agreed to keep in contact to advance the next stage of collaboration in intelligent outdoor robotics, multi-sensor fusion positioning and industry-oriented talent development.