← All datasets & code
GraphGNSSLib
GNSS Positioning and Real-Time Kinematic (RTK) Using Factor Graph Optimization
- Developed by
- Weisong Wen
- Repository
- weisongwen/GraphGNSSLib
- GitHub
- 629 stars · 156 forks
Summary
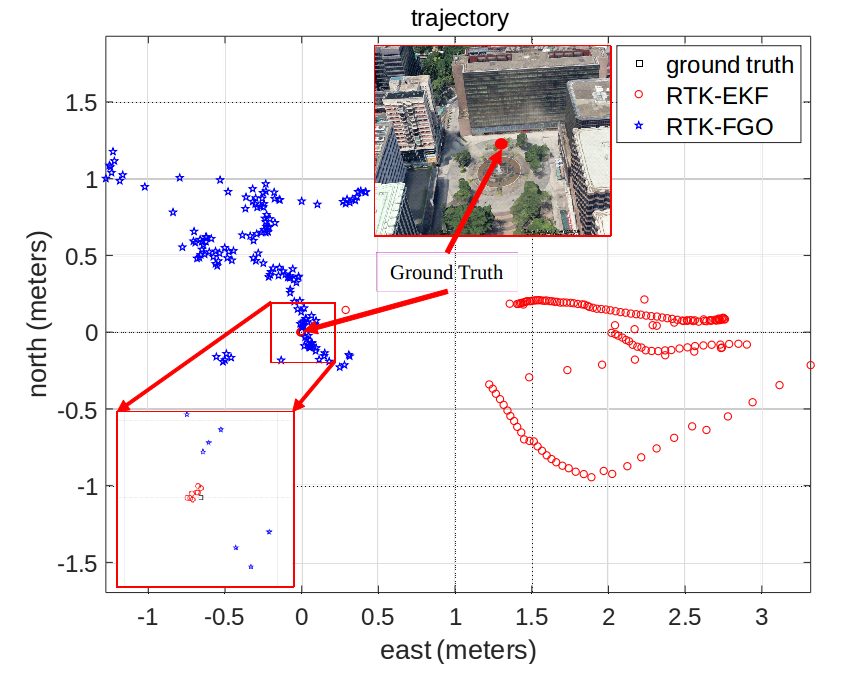
The first open-source library that solves GNSS positioning and GNSS-RTK with factor graph optimization, using measurements from past and current epochs together.
Key innovations
- Pseudorange and Doppler positioning as a factor graph instead of a single-epoch filter
- GNSS-RTK from double-differenced pseudorange, carrier phase and Doppler, with LAMBDA ambiguity resolution
- ROS-compatible C++ built on RTKLIB, so robotics researchers can use raw GNSS data directly
Impact
- 629 GitHub stars and 156 forks, the most-forked TAS Lab repository
- Published at ICRA 2021
- Basis of the lab's later GNSS/LiDAR/IMU fusion systems such as GLIO
Cite this work
W. Wen and L.-T. Hsu, "Towards Robust GNSS Positioning and Real-Time Kinematic Using Factor Graph Optimization," IEEE ICRA, 2021.