← All datasets & code
GLIO
Tightly-Coupled GNSS/LiDAR/IMU Integration for Continuous and Drift-free State Estimation
- Developed by
- Xikun Liu
- Repository
- XikunLiu-huskit/GLIO
- GitHub
- 439 stars · 43 forks
Summary
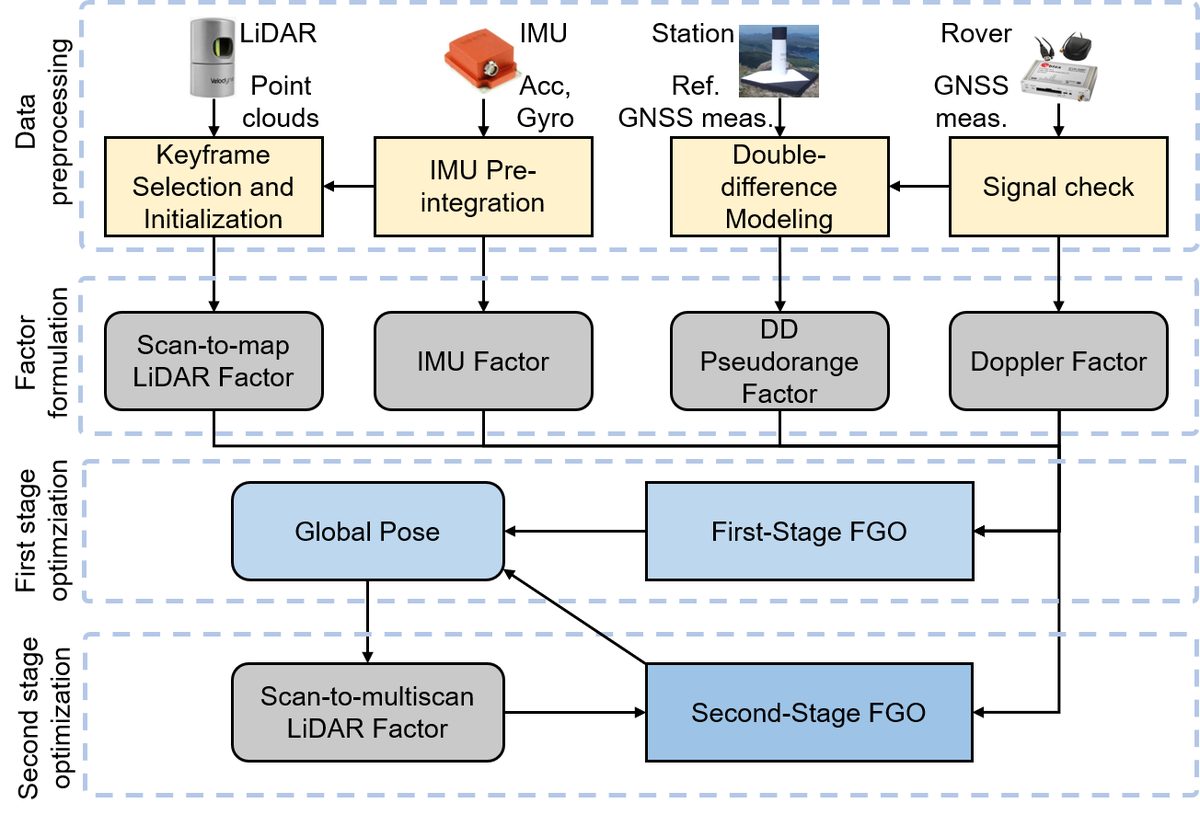
Online GNSS/LiDAR/IMU odometry that tightly fuses raw GNSS pseudorange and Doppler with LiDAR and IMU for globally consistent, drift-free poses in urban canyons.
Key innovations
- Raw GNSS factors, IMU pre-integration and LiDAR factors in one factor graph
- Two stages: a sliding window for real-time odometry and batch optimisation for global consistency
- Robust to GNSS outliers in deep urban canyons
Impact
- 439 GitHub stars and 43 forks
- Published in IEEE Transactions on Intelligent Vehicles (2023)
- Outcome of the Guangdong NSF project on 3D LiDAR-aided GNSS
Cite this work
X. Liu, W. Wen and L.-T. Hsu, "GLIO: Tightly-Coupled GNSS/LiDAR/IMU Integration for Continuous and Drift-free State Estimation of Intelligent Vehicles in Urban Areas," IEEE Transactions on Intelligent Vehicles, 2023.