← All datasets & code
TAS_MPC (JPCM)
Tightly Joined Positioning and Control Model for UAVs Based on Factor Graph Optimization
- Developed by
- Peiwen Yang
- Repository
- PolyU-TASLAB/TAS_MPC
- GitHub
- 4 stars · 1 forks
Summary
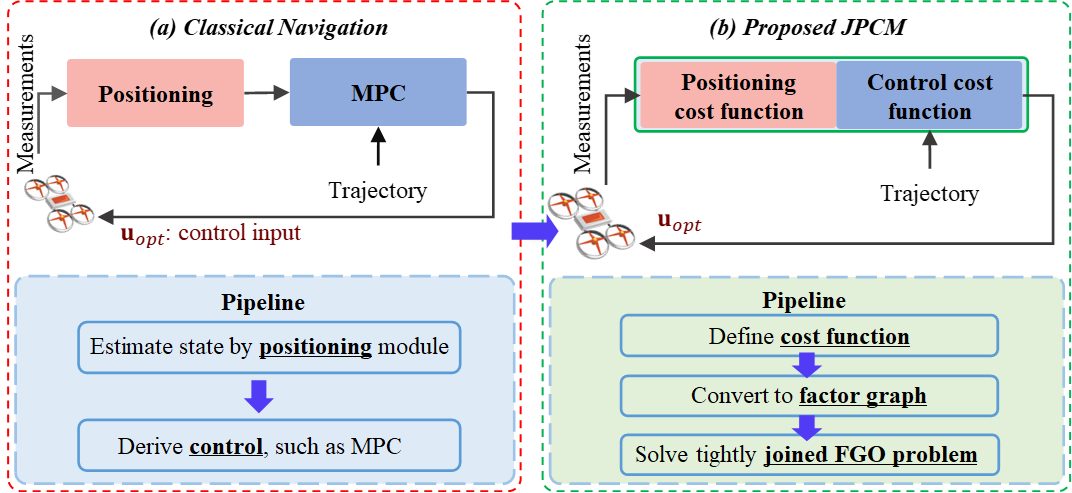
A joint positioning and control model that solves positioning and model predictive control for UAVs in one factor graph, so the controller accounts for positioning uncertainty.
Key innovations
- Positioning factors and MPC constraints in a single probabilistic graph
- Exploits the complementarity of positioning and control under urban GNSS errors and wind
- Better trajectory following in quadrotor simulation
Impact
- Basis of the lab's joint planning-and-control research for UAVs